-
-
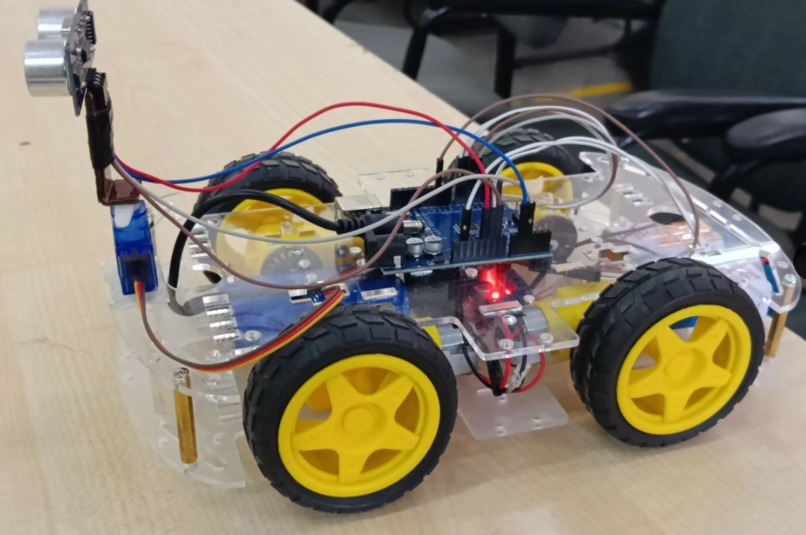
side view
-
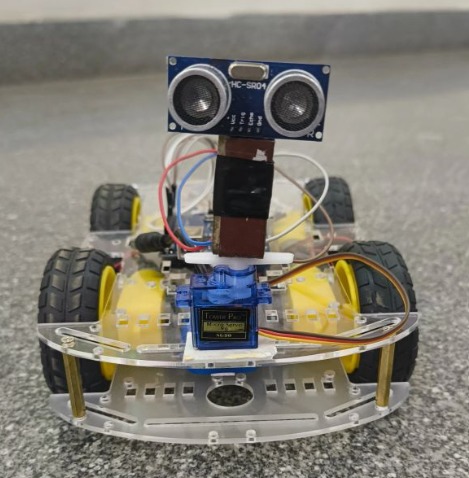
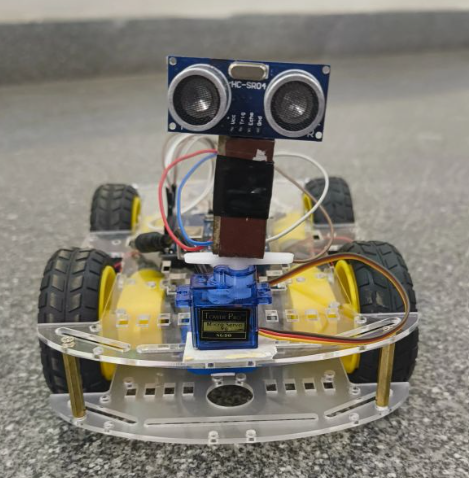
front view
-
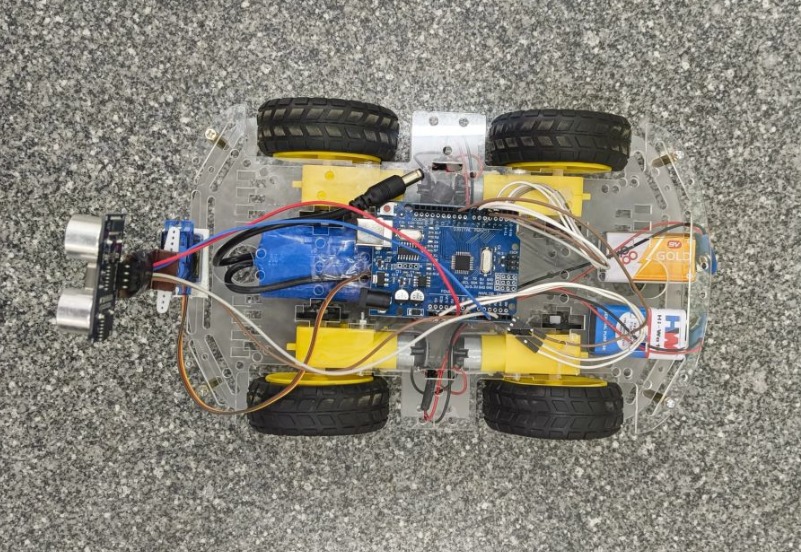
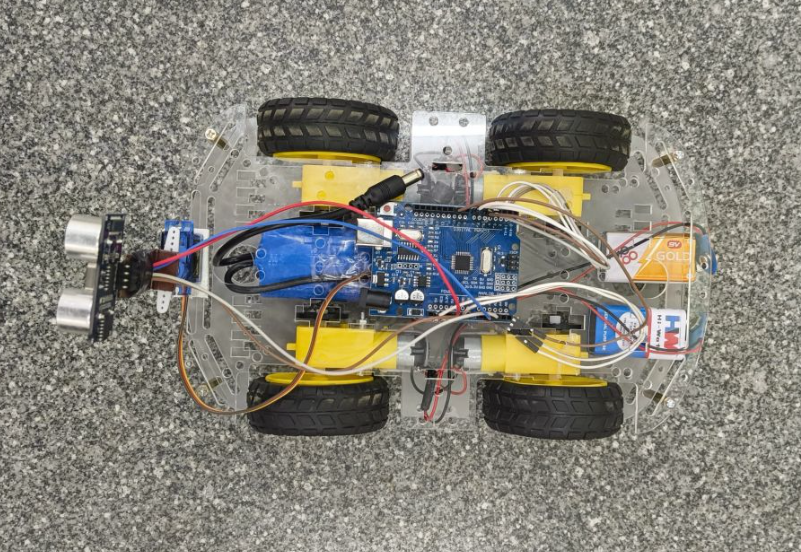
top view
Inspiration
The inspiration behind this project came from the idea of creating a simple robotic system that could sense its surroundings and make decisions without human control. Autonomous navigation is an important concept in robotics, self-driving systems, and smart automation.
I wanted to understand how sensors, microcontrollers, and motors can work together to create a robot capable of responding to its environment in real time.
What it does
The Obstacle Avoiding Robot Car is an autonomous robotic vehicle that detects obstacles in real time and changes its direction accordingly. An HC-SR04 ultrasonic sensor measures the distance between the robot and nearby objects. When an obstacle is detected within a defined range, the Arduino processes the sensor data and controls the motors to navigate in a different direction.
The project demonstrates the basic principles of autonomous navigation, real-time sensing, and intelligent decision-making.
How we built it
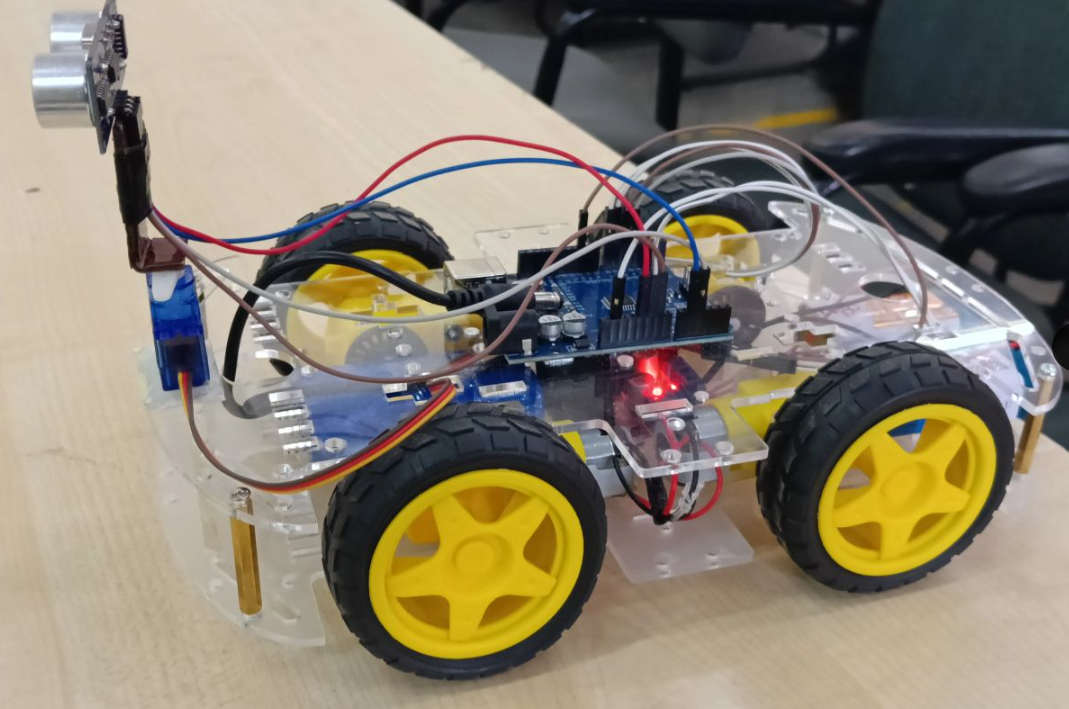
We built the robot using an Arduino UNO, HC-SR04 ultrasonic sensor, servo motor, motor driver module, DC motors, and a robot chassis.
The ultrasonic sensor continuously measures the distance to obstacles and sends the readings to the Arduino. The Arduino was programmed using Embedded C/Arduino programming to process these readings and make navigation decisions.
The motor driver receives control signals from the Arduino and operates the DC motors to move the robot forward and change direction when an obstacle is detected. The servo motor helps the sensing system check different directions.
Challenges we ran into
One of the main challenges was achieving reliable obstacle detection and smooth navigation. Ultrasonic sensor readings could vary depending on the position and distance of an object, which sometimes caused unexpected movements.
We also faced challenges in:
Interfacing the ultrasonic sensor with Arduino Controlling the direction and speed of the DC motors Coordinating the servo motor with obstacle detection Managing wiring and power connections Fine-tuning the distance threshold Debugging the control logic for smoother navigation
Testing and repeated adjustments helped us improve the robot's response and overall performance.
Accomplishments that we're proud of
We successfully developed a working autonomous robot car capable of detecting obstacles and changing its direction without manual control.
We are particularly proud of gaining hands-on experience in:
🤖 Autonomous robotics 📡 Ultrasonic sensor interfacing 💻 Embedded C programming ⚙️ Motor and servo control 🔌 Hardware-software integration 🧠 Real-time decision-making
What we learned
Through this project, we gained practical experience in robotics, embedded systems, and automation. We learned how to interface an ultrasonic sensor with an Arduino, process real-time sensor data, and use the information to make autonomous navigation decisions.
We also improved our understanding of Embedded C programming, motor driver control, servo motor interfacing, circuit connections, debugging, and hardware-software integration.
Most importantly, we learned how small hardware and software components can work together to create a system capable of sensing its environment and responding autonomously.
What's next for Obstacle Avoiding Robot Car
We plan to take the project further by making the robot smarter, more accurate, and more autonomous.
Future improvements include:
📡 Adding multiple ultrasonic sensors for wider obstacle detection 📷 Integrating a camera for visual recognition 🧠 Implementing AI-based obstacle detection and decision-making 🗺️ Adding path-planning and maze-navigation capabilities 📱 Adding Bluetooth/Wi-Fi connectivity for remote monitoring 🔋 Improving battery management and power efficiency 🚗 Exploring advanced autonomous navigation algorithms
Our long-term goal is to evolve the current prototype into a more advanced intelligent autonomous mobile robot capable of understanding its surroundings and choosing the most efficient path in real time.
Built With
- arduinoide
- dcmotors
- embeddedc
- embeddedsystems
- hc-sr04
- microcontroller
- motordriver
- real-timesystems
- sensorinterfacing
- servomotor
- ultrasonicsensor

Log in or sign up for Devpost to join the conversation.