-
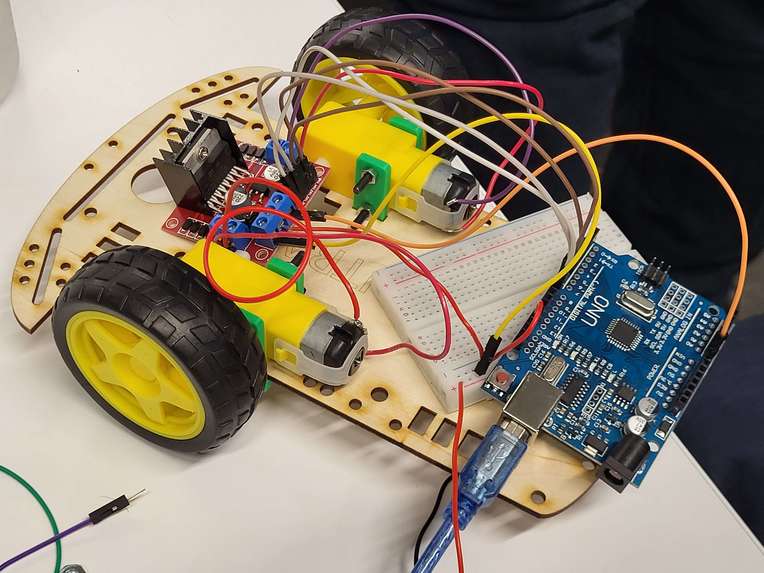
Wiring of our rover
-

Assembly of our rover


About our rover
We assembled our autonomous rover using an Arduino UNO board connected two infared colour sensors and an ultrasonic sensor at the front. We also have a motor driver than powers up two DC gear motors.
Line Tracking
By using colour sensors positioned on two sides of the rover, it knows whether it is on the left/right side of a line, or whether it is positioned on top of the line, allowing it to self adjust it's position.
Obstacles and Maze Solving
Our rover detects incoming collisions ahead of time using the ultrasonic sensor, which then will make a turn to the appropriate direction until there is no more obstacle ahead. Within a period of time, if the rover does not detect an incoming object after a turn, it will attempt to return to it's original path before the obstacle, ideally bypassing the object ahead.
Challenges we ran into
Having the hardware cooperate with our software end was especially challenging because the motors we used were older and had a lot of friction. We worked hard to balance between the power of the motors allowing the wheels to move and the precision of our position tracking.
Accomplishments that we're proud of
As a team without much experience with robotics programming on arduino, we are proud to have completed the entire design process from the assembly of our rover, wiring up the components correctly, and the final control system software.


Log in or sign up for Devpost to join the conversation.