Inspiration
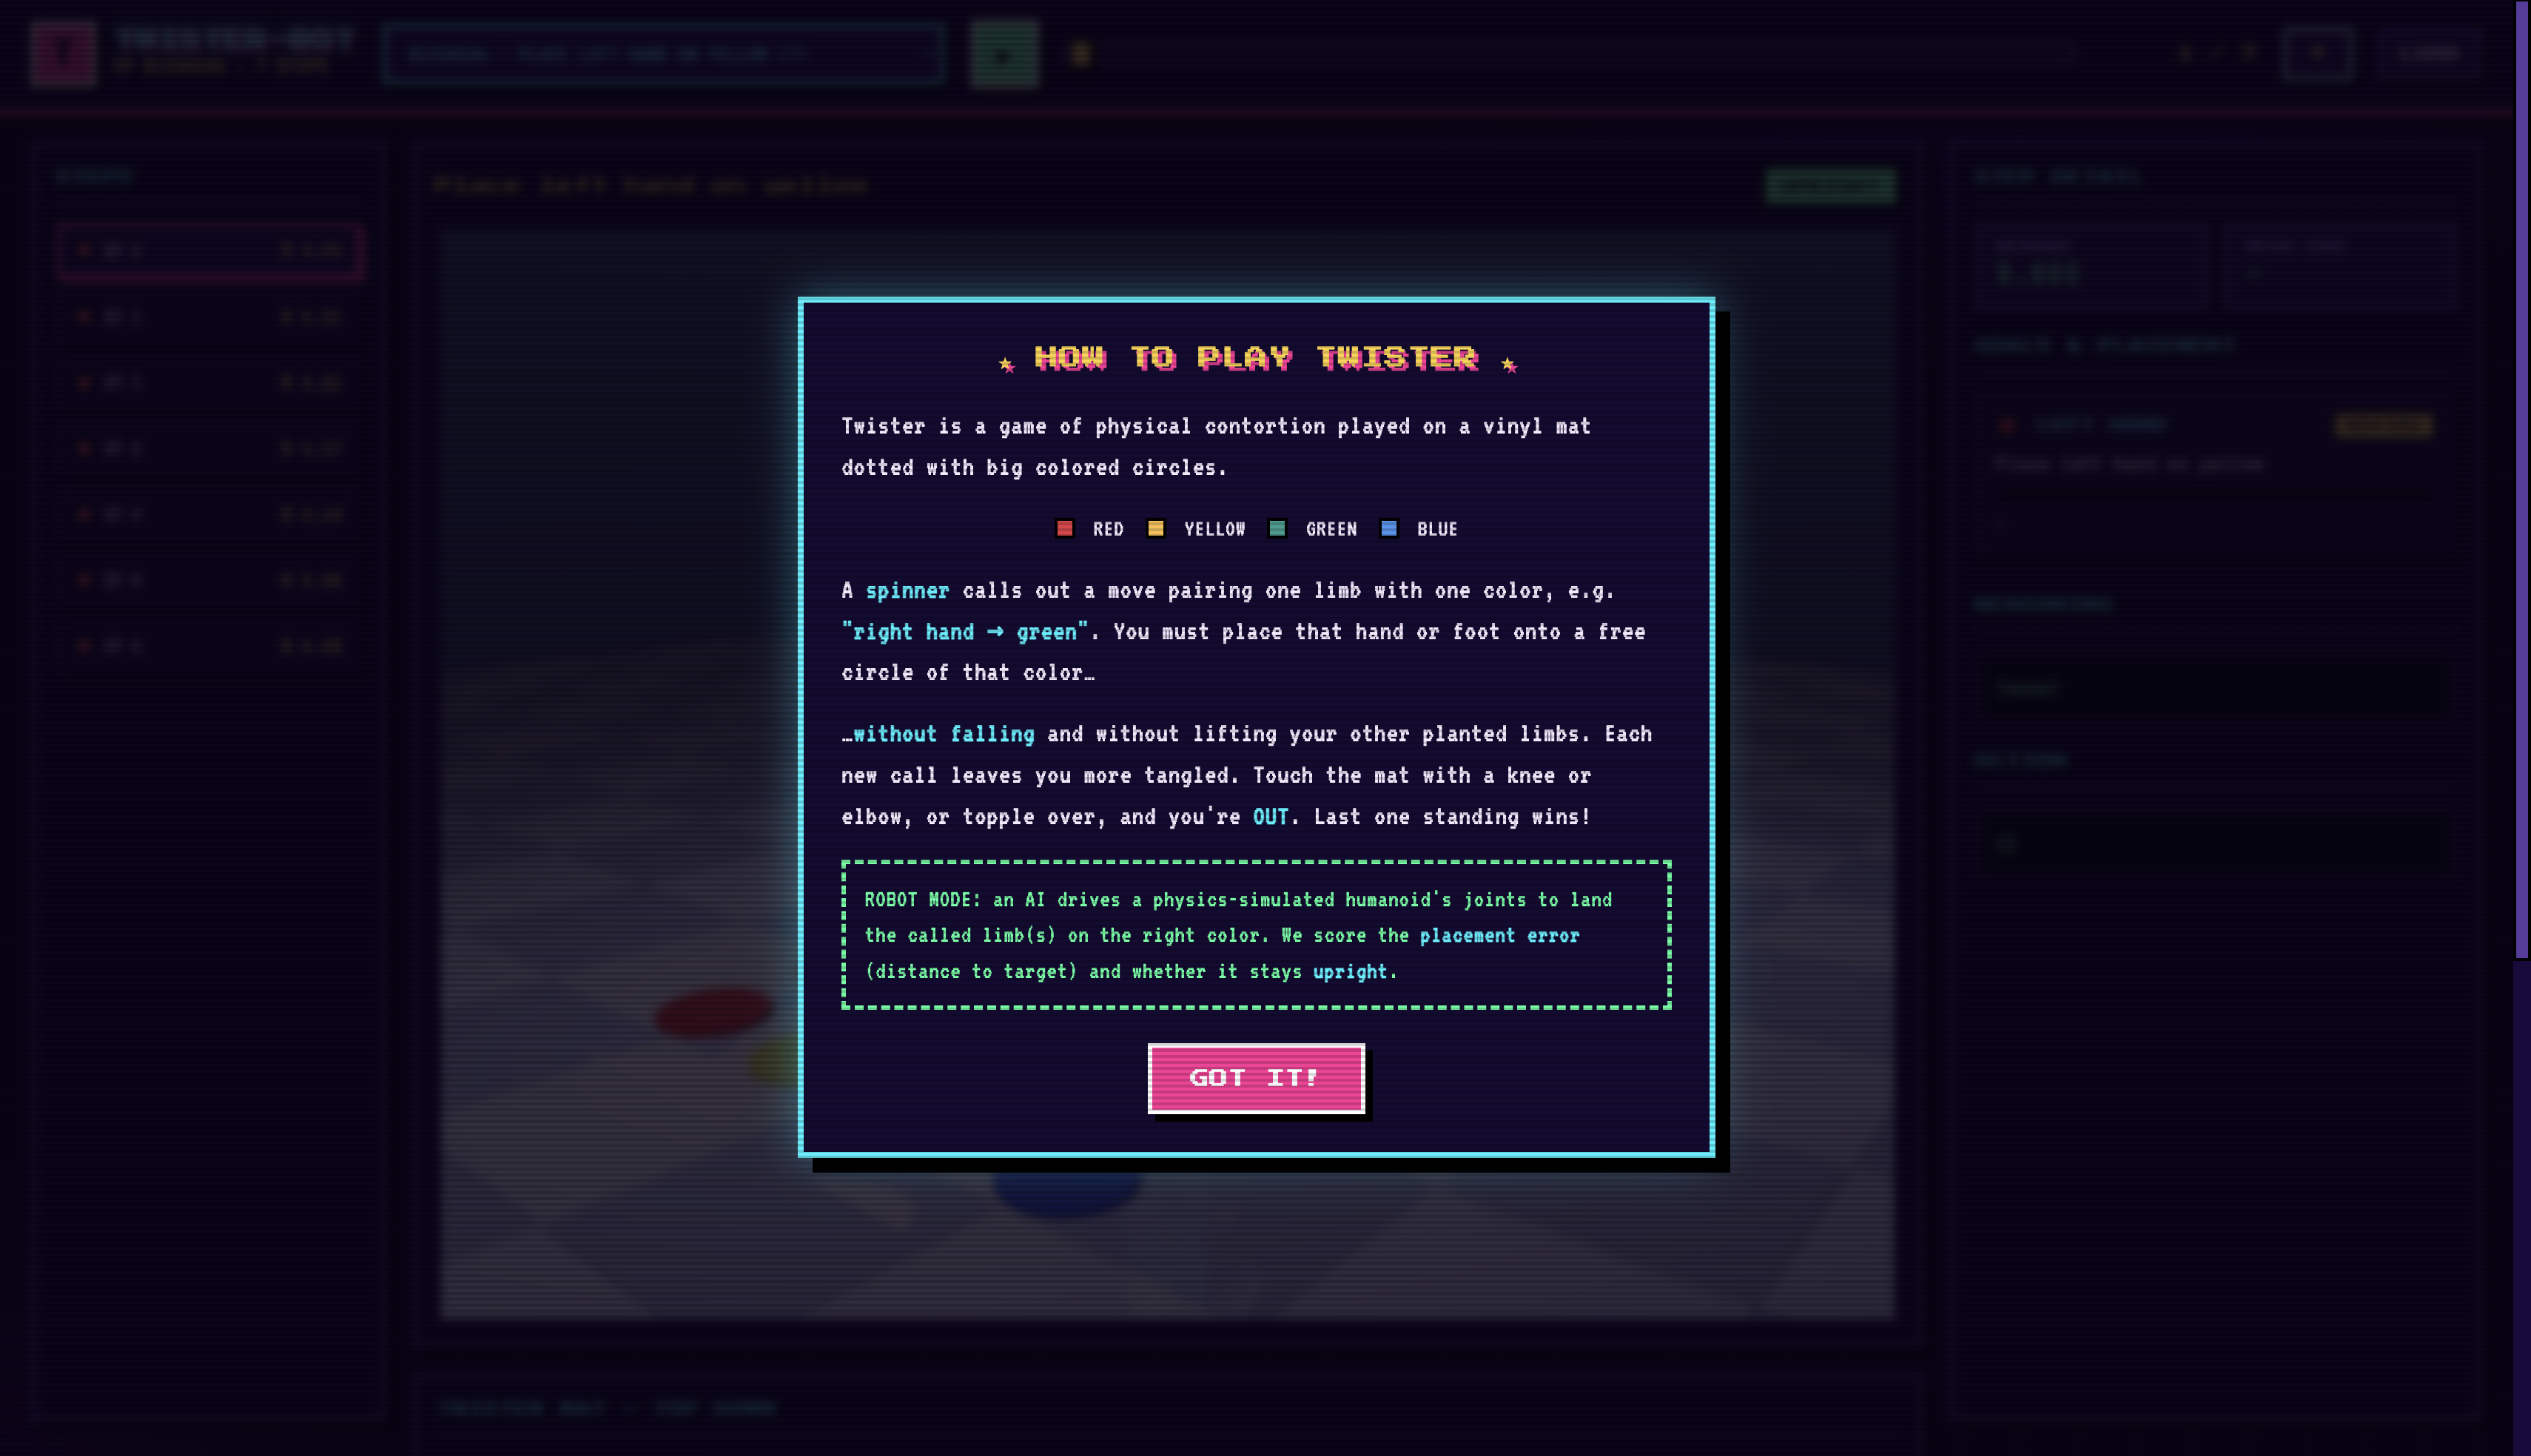
We were inspired by turning a familiar physical game, Twister, into a robotics and AI benchmark. Twister is easy for humans to understand, but difficult for an embodied agent because it requires balance, reachability, limb coordination, and long-term planning.
What it does
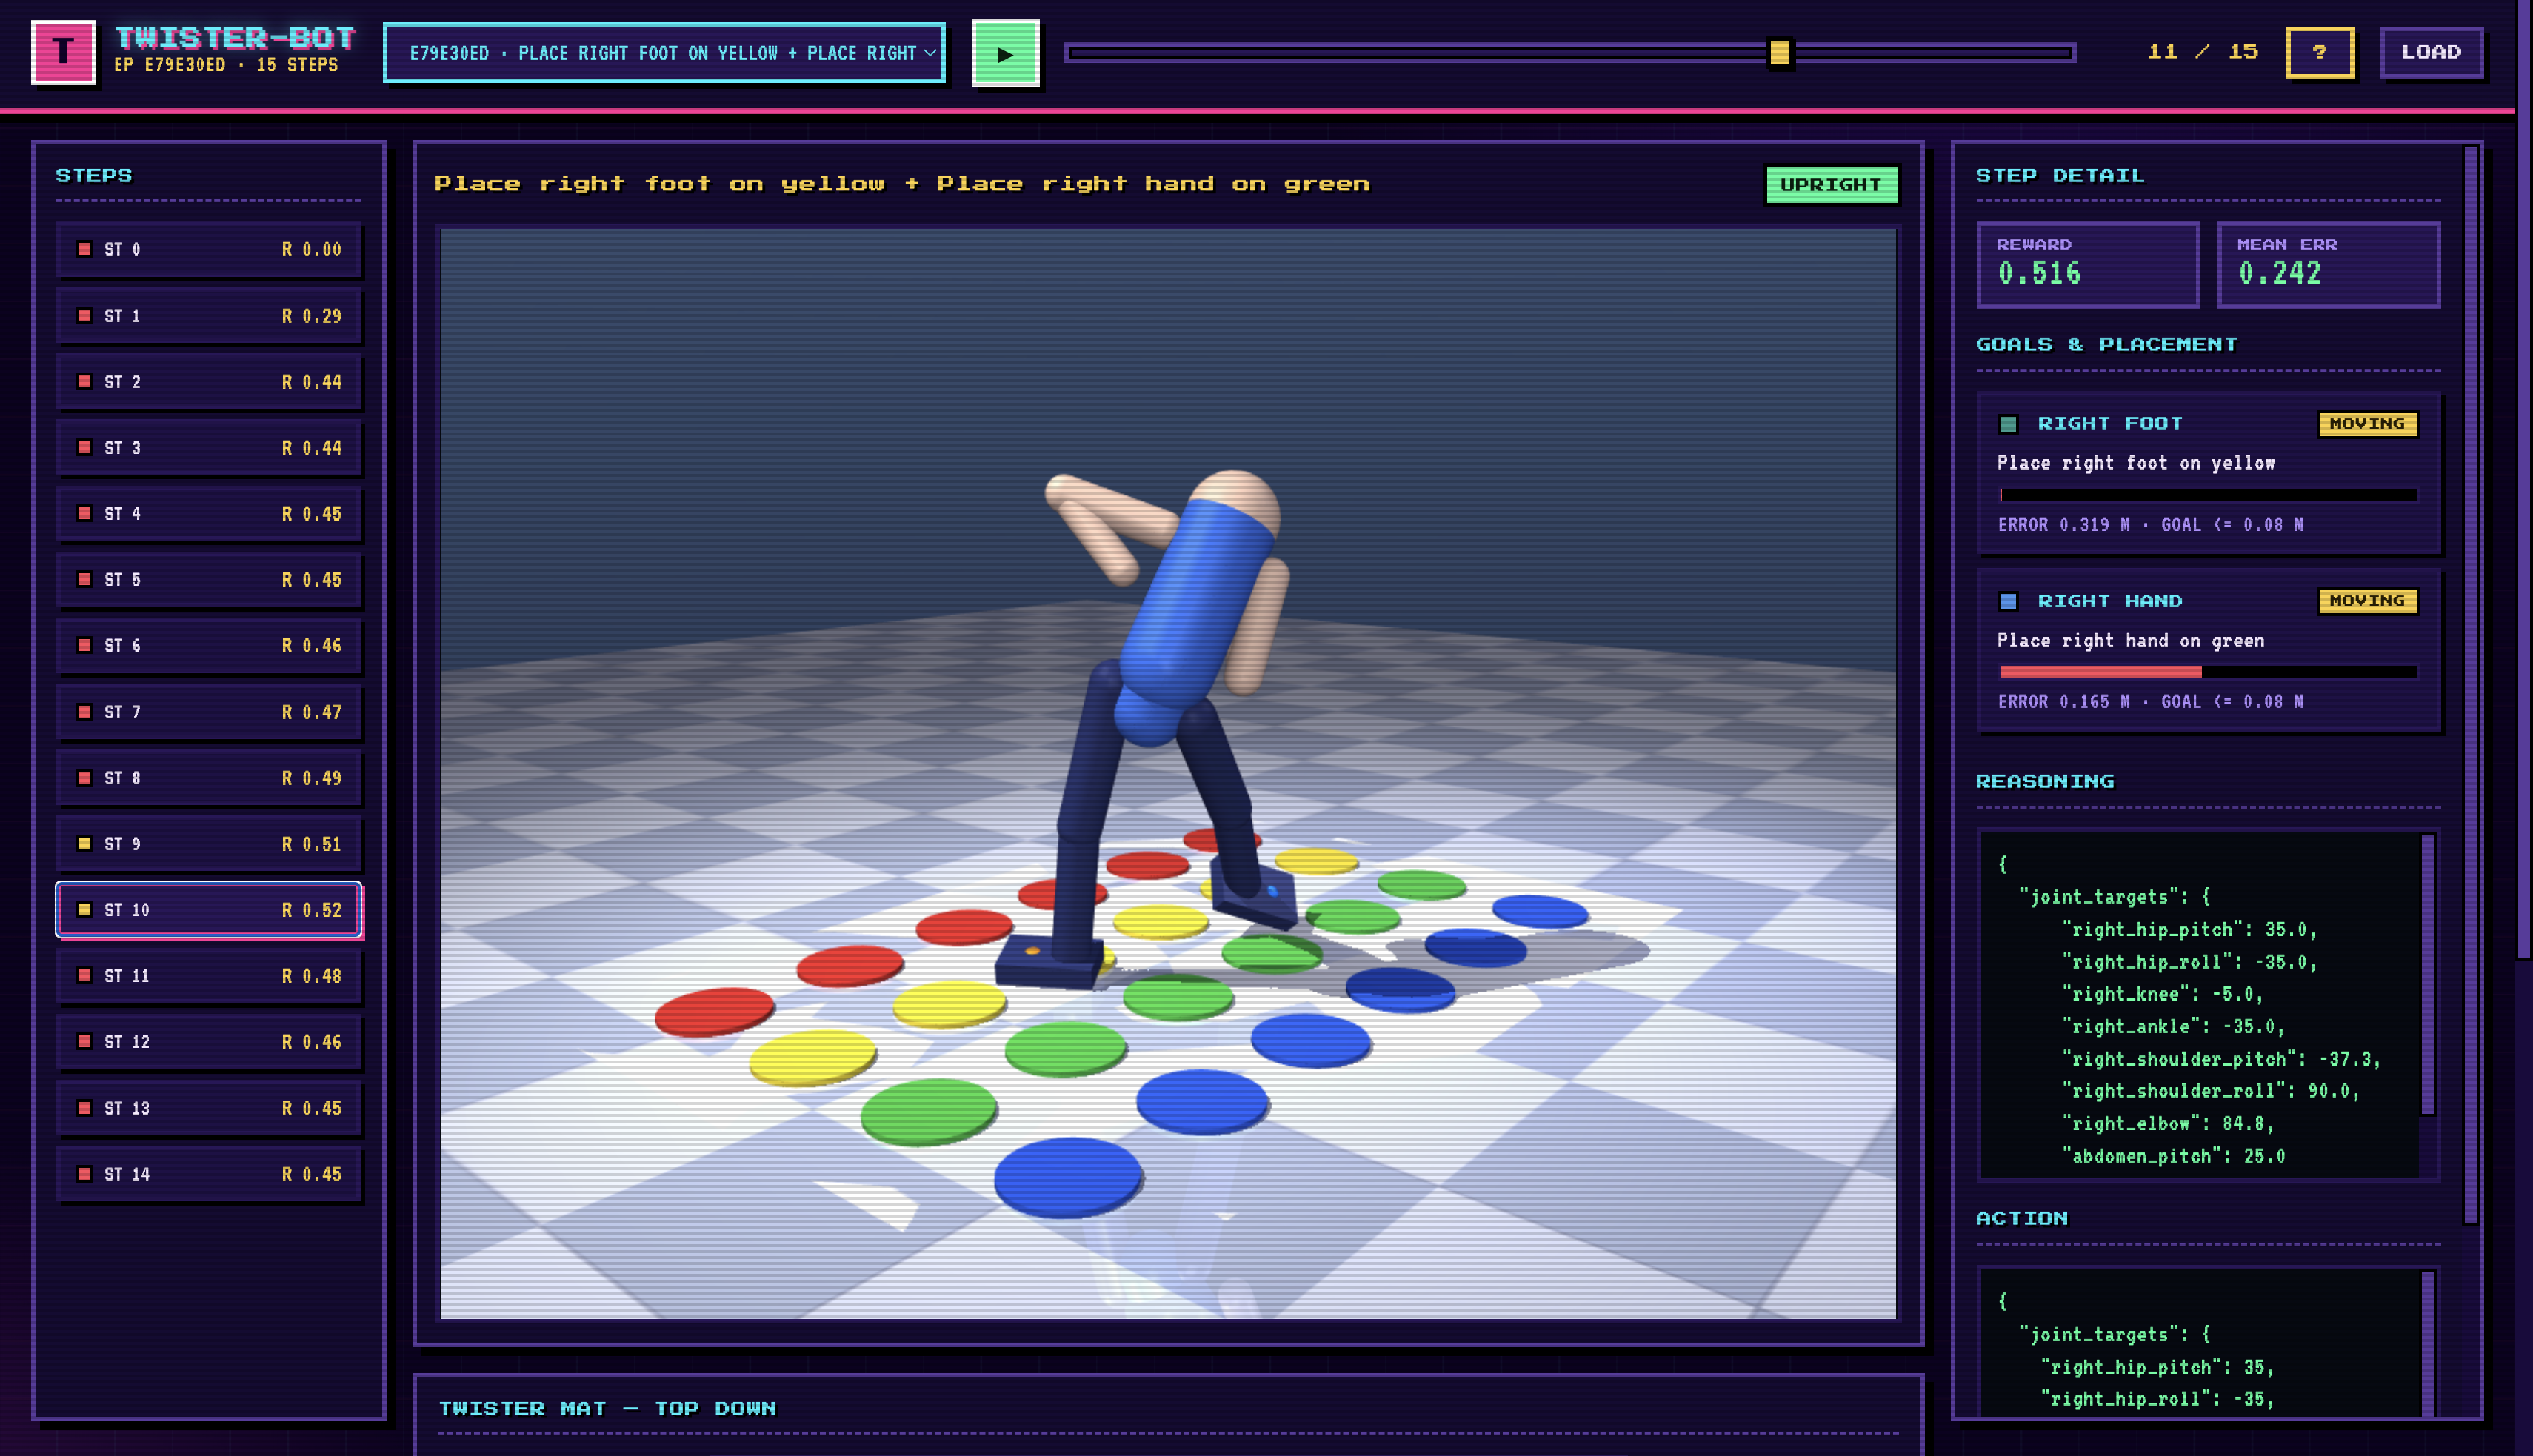
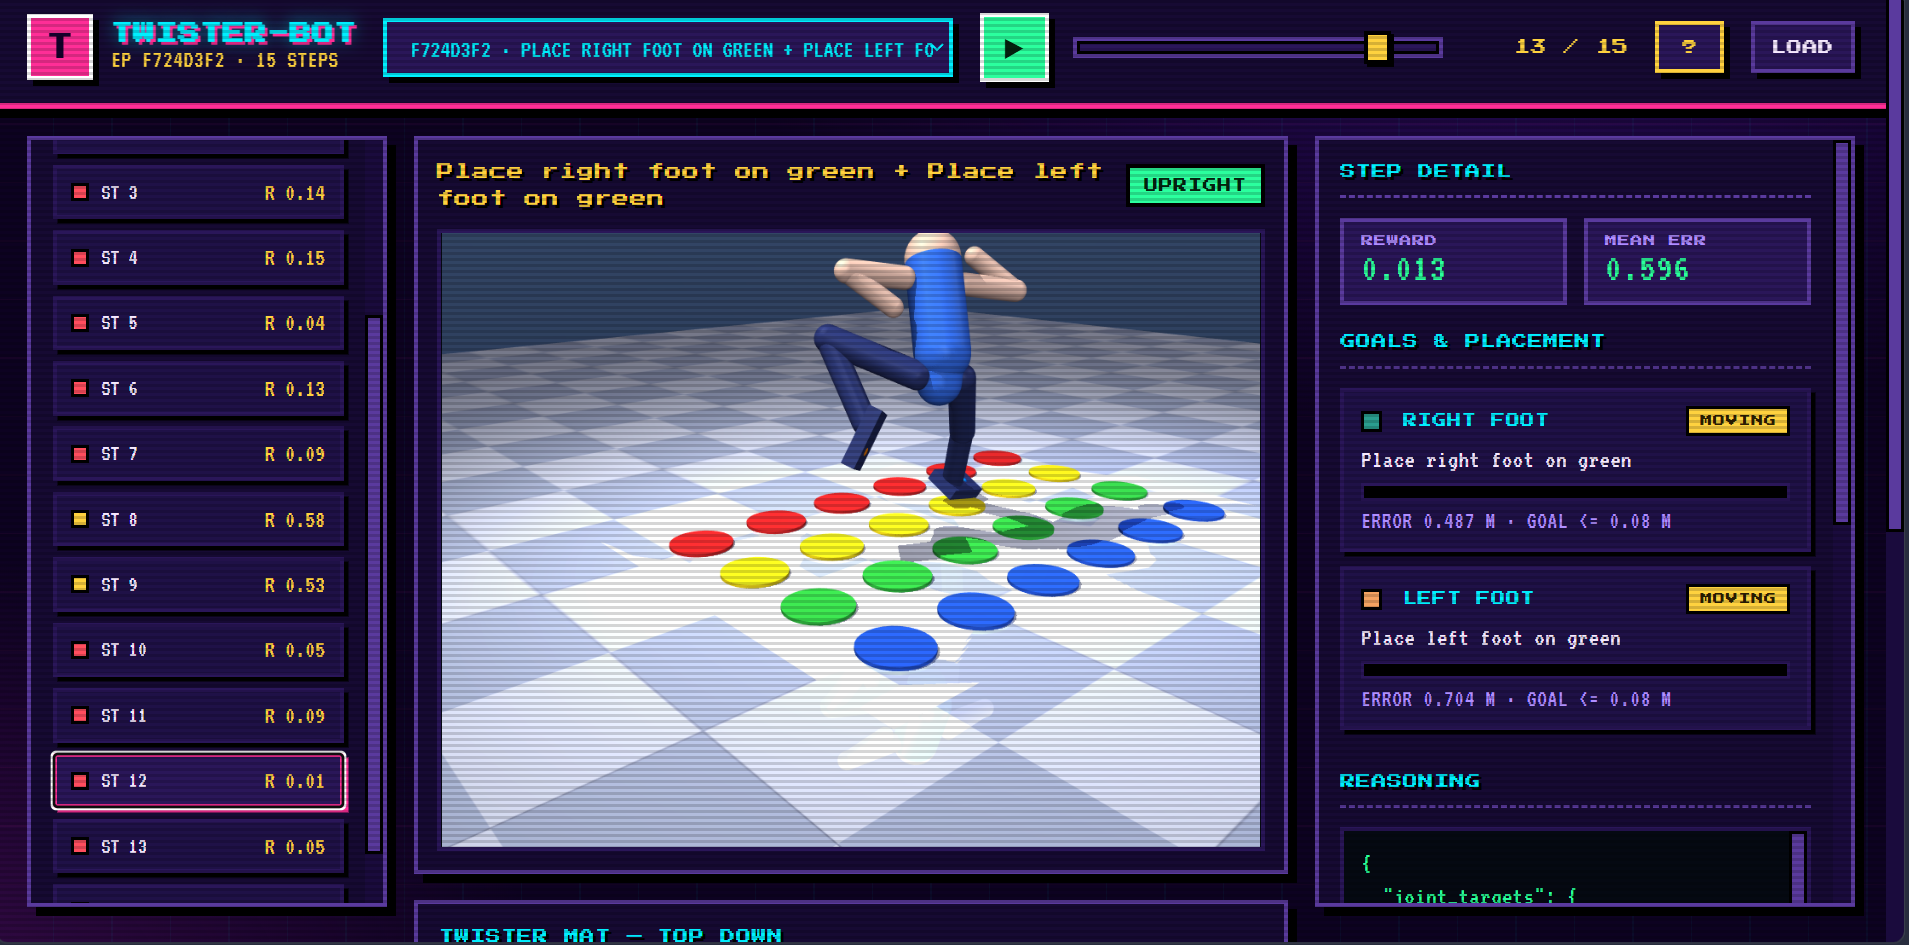
TwisterBench simulates a humanoid playing Twister in MuJoCo. The agent receives commands like placing a specific hand or foot on a colored circle, then must move while preserving balance, maintaining locked contacts, and avoiding constraint violations.
How we built it
We built TwisterBench in Python using MuJoCo for humanoid physics simulation. We created modules for game logic, world state tracking, inverse kinematics, reachability, balance control, rewards, replay recording, and benchmarking. We also added a BenchAnything adapter so agents can interact with the environment through standardized JSON observations, actions, rewards, and metrics.
Challenges we ran into
The biggest challenge was making the environment both physically realistic and benchmarkable. Humanoid balance, contact constraints, and limb reachability are tightly connected, so solving one Twister move can easily cause the agent to fall or violate another rule. We also had to design observations and rewards that were useful without making the task too easy.
Accomplishments that we're proud of
We are proud of building a complete benchmark around a fun, recognizable game while still testing serious embodied AI skills. TwisterBench combines physics simulation, whole-body control, inverse kinematics, balance reasoning, and standardized evaluation in one environment.
What we learned
We learned how complex embodied AI becomes when reasoning, physics, and control are combined. Even a simple game like Twister requires careful coordination between simulation, environment design, rewards, and evaluation metrics.
What's next for TwisterBench
Next, we want to improve the humanoid controller, add more scenarios and difficulty levels, expand replay visualization, and support stronger agent comparisons across planning, balance, reach accuracy, and survival.
Built With
- benchanything
- cursorai
- mujoco


Log in or sign up for Devpost to join the conversation.