-
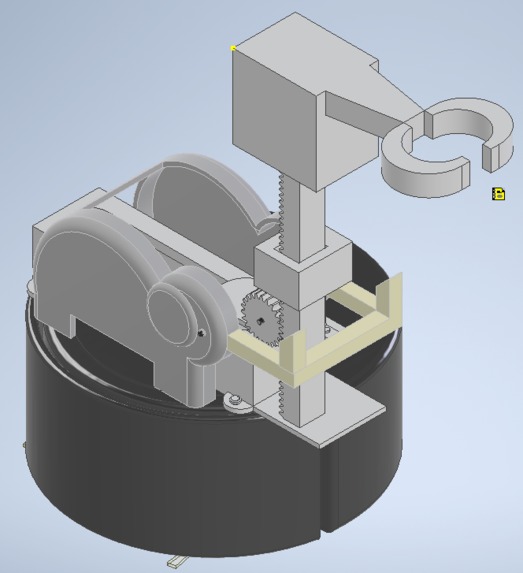
The Elephant Cleaner

Given our problem, we wanted to build something that uniquely cleaned and solved the current difficulties of Roombas and other similar vacuums in household. Our team thought of the idea to build a gripper, lifting legs of appliances to clean those circles of dirt hidden underneath table legs.
The Elephant Cleaner uses a slider, rack and pinion, and claw gripper interdependently to lift up legs of furniture and other appliances to clean underneath the table legs effectively.
Using Autodesk Inventor, we made CAD models of each mechanism and component we planned to integrate to the design.
The source of power to push up the gripper was contentious, as we needed something powerful enough to support a chair leg, for example, while also being small and mobile as to not interfere with the robot's mobility. Our rack and pinion was covered by the Elephant case to protect the system from any obstacles.
The design itself is creative, with its aesthetic exterior of an elephant design and the claw gripper representing its trunk. We worked hard to make a more feasibly functioning power source with the rack and pinion, along with connecting it to the slider and all the other working parts. We in particular like how when the robot is moving, that motion itself is what causes the slider to move.
In testing a variety of mechanisms, we researched and learned about the costs of these materials and its usability in manufacturing and assembly lines. In testing and constantly making criticisms and questioning the integrity of our design, we were able to develop our model into something stronger and more protected.
What's next for The Elephant Cleaner:
We want to improve its mechanism further and grow the functions possible for the model! More functions, more efficiency, and more cleanliness!
Built With
- autodesk
- cad

Log in or sign up for Devpost to join the conversation.