
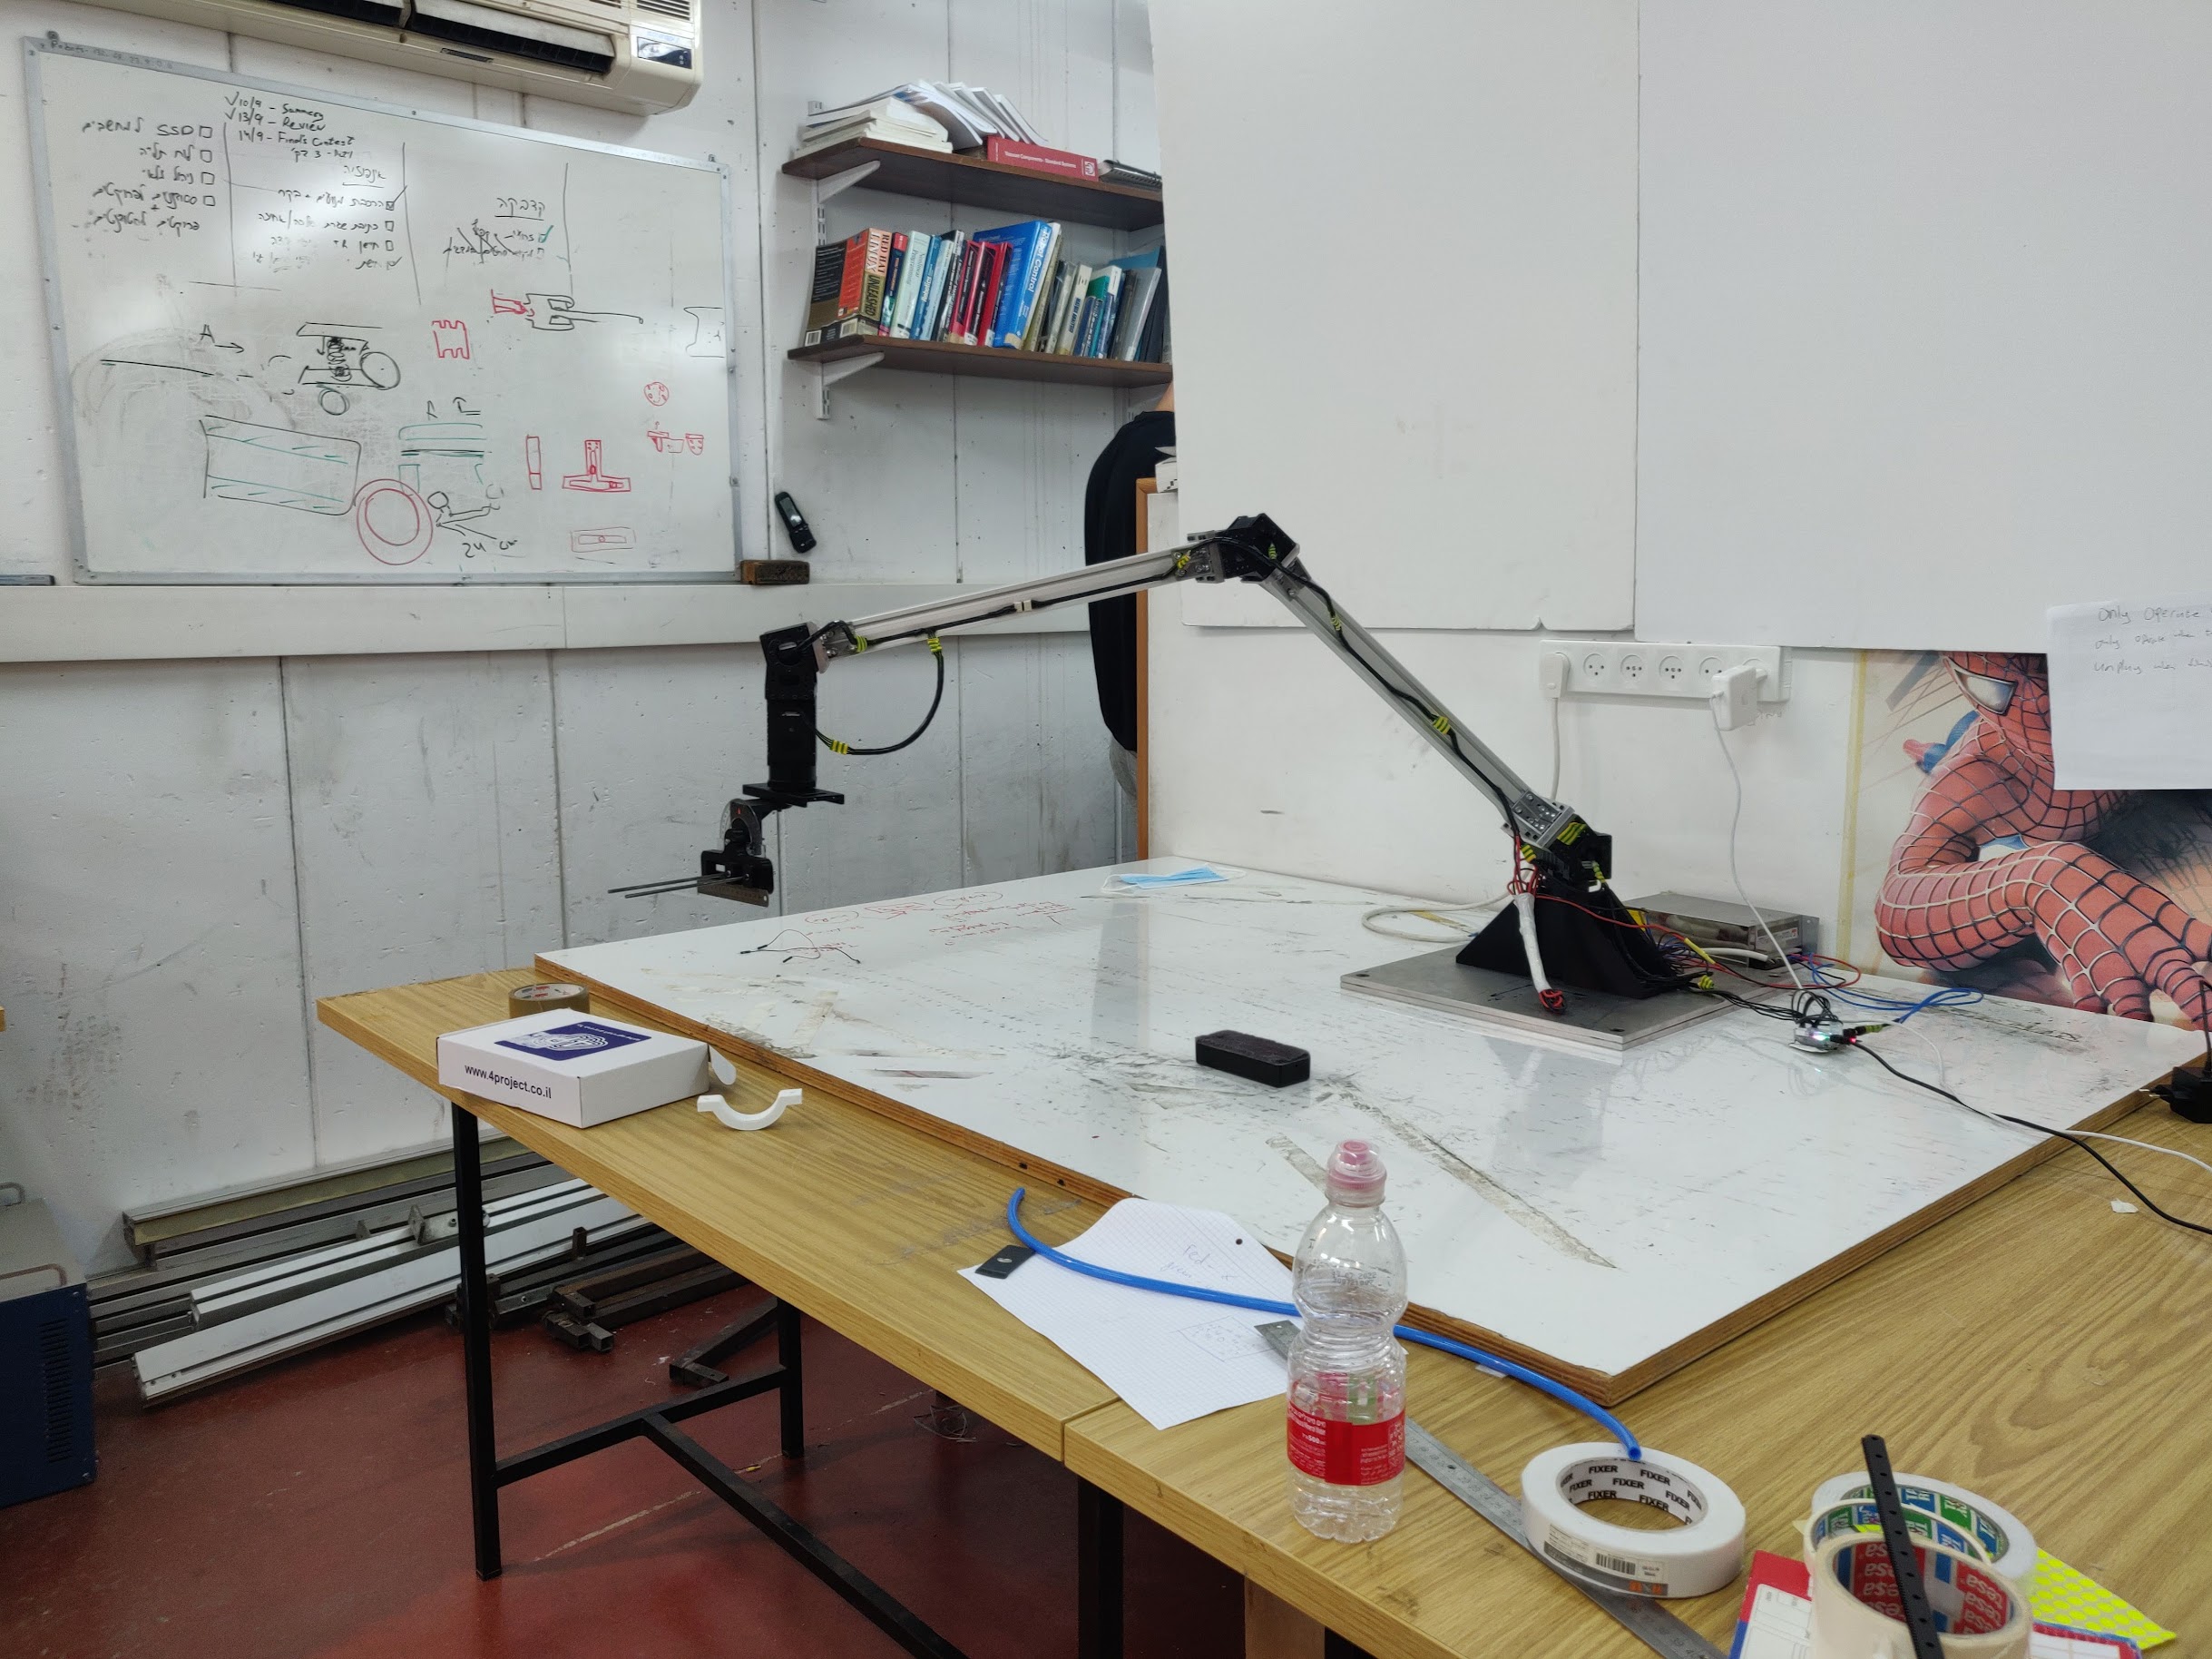
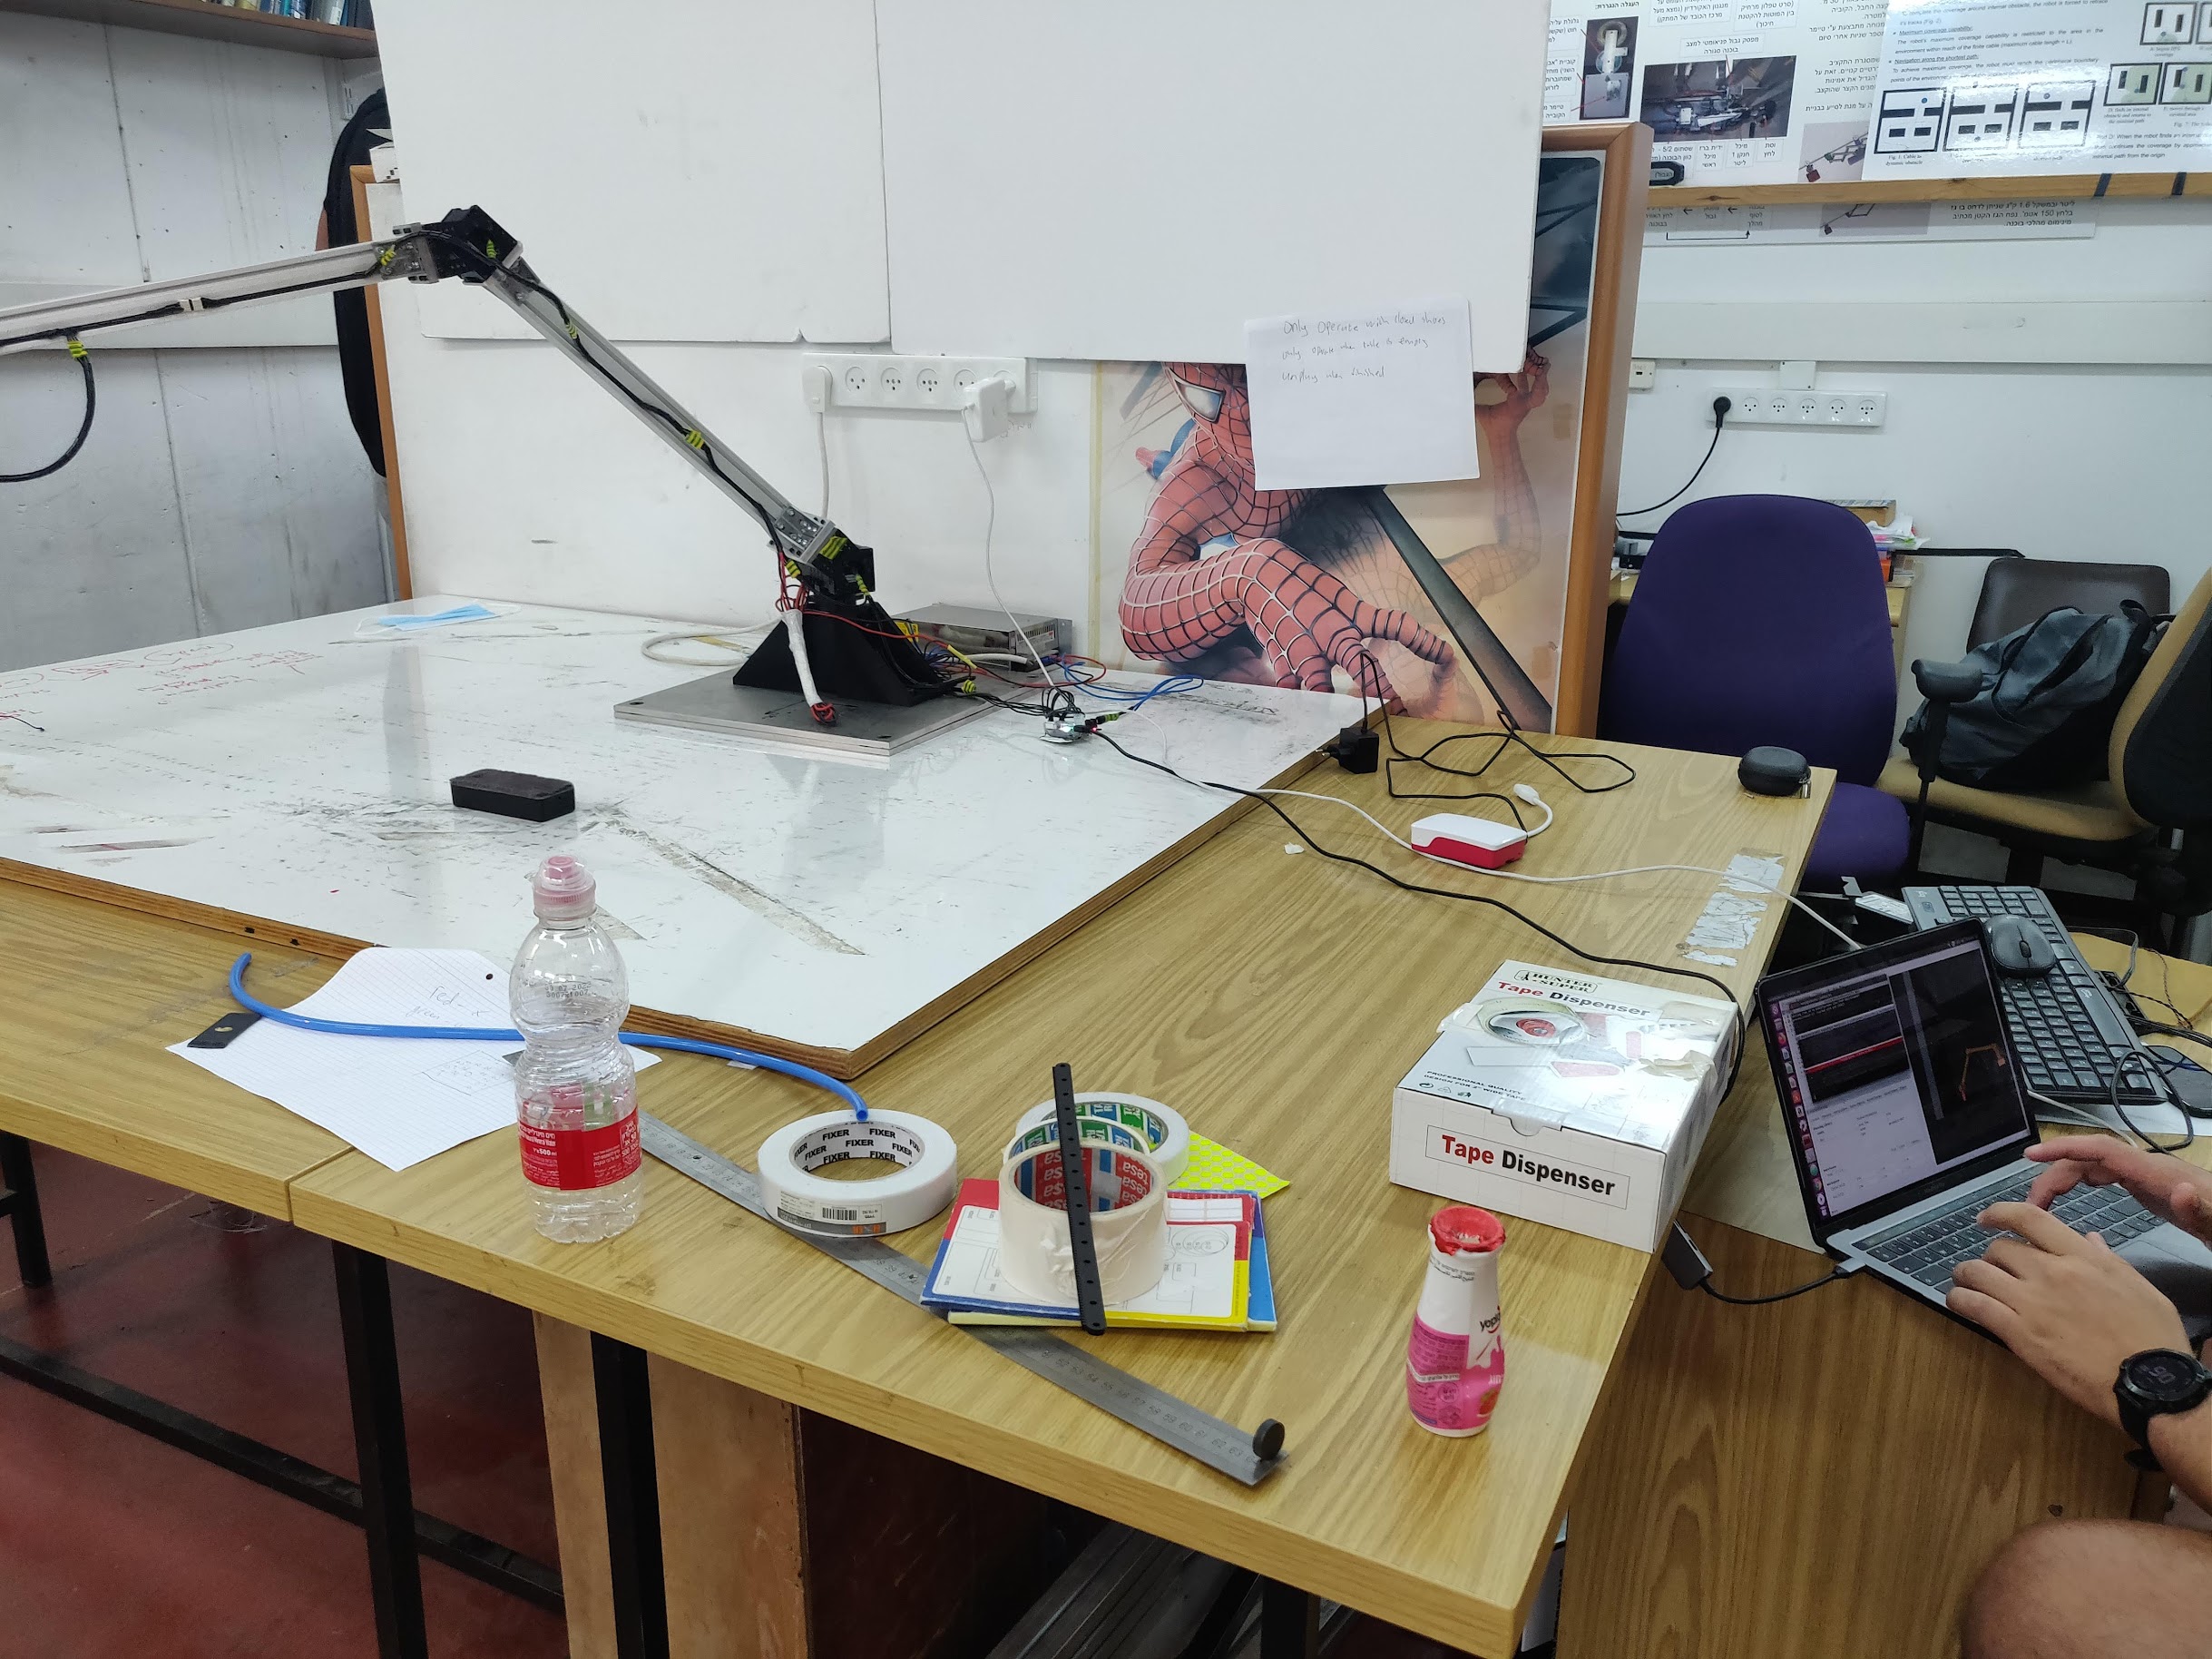
This is part of my final project while doing my Mechanical Engineering degree at Technion - Israel Institute of Technology.
What it does
The pictures are of the robotic arm itself and not the End-Effector since that part is undisclosed. The End-effector uses adhesion similar to a gecko's tongue to wrap and stick around an object to manipulate it.
How I built it
We used ROS to control the arm and send instructions to the end-effector which runs on Arduino. The arm itself can change end-effectors based on which type of object it needs to pick up. We utilise computer vision to handle object recognition and environment awareness.
Challenges I ran into
Although the arm is made using steel trusses, the End-effector itself is 3D printed for iteration speed. This presents a set of challenges since we need to have a light-weight yet robust chassis.
Accomplishments that I'm proud of
Though this is a final project worked on by final year and masters students, I'm the only 2nd year student to work on the project. We worked closely with the professor who partners with researchers at Ben Gurion University.

Log in or sign up for Devpost to join the conversation.