Inspiration
I was inspired by Spider-Man and mmWave radar.
What it does
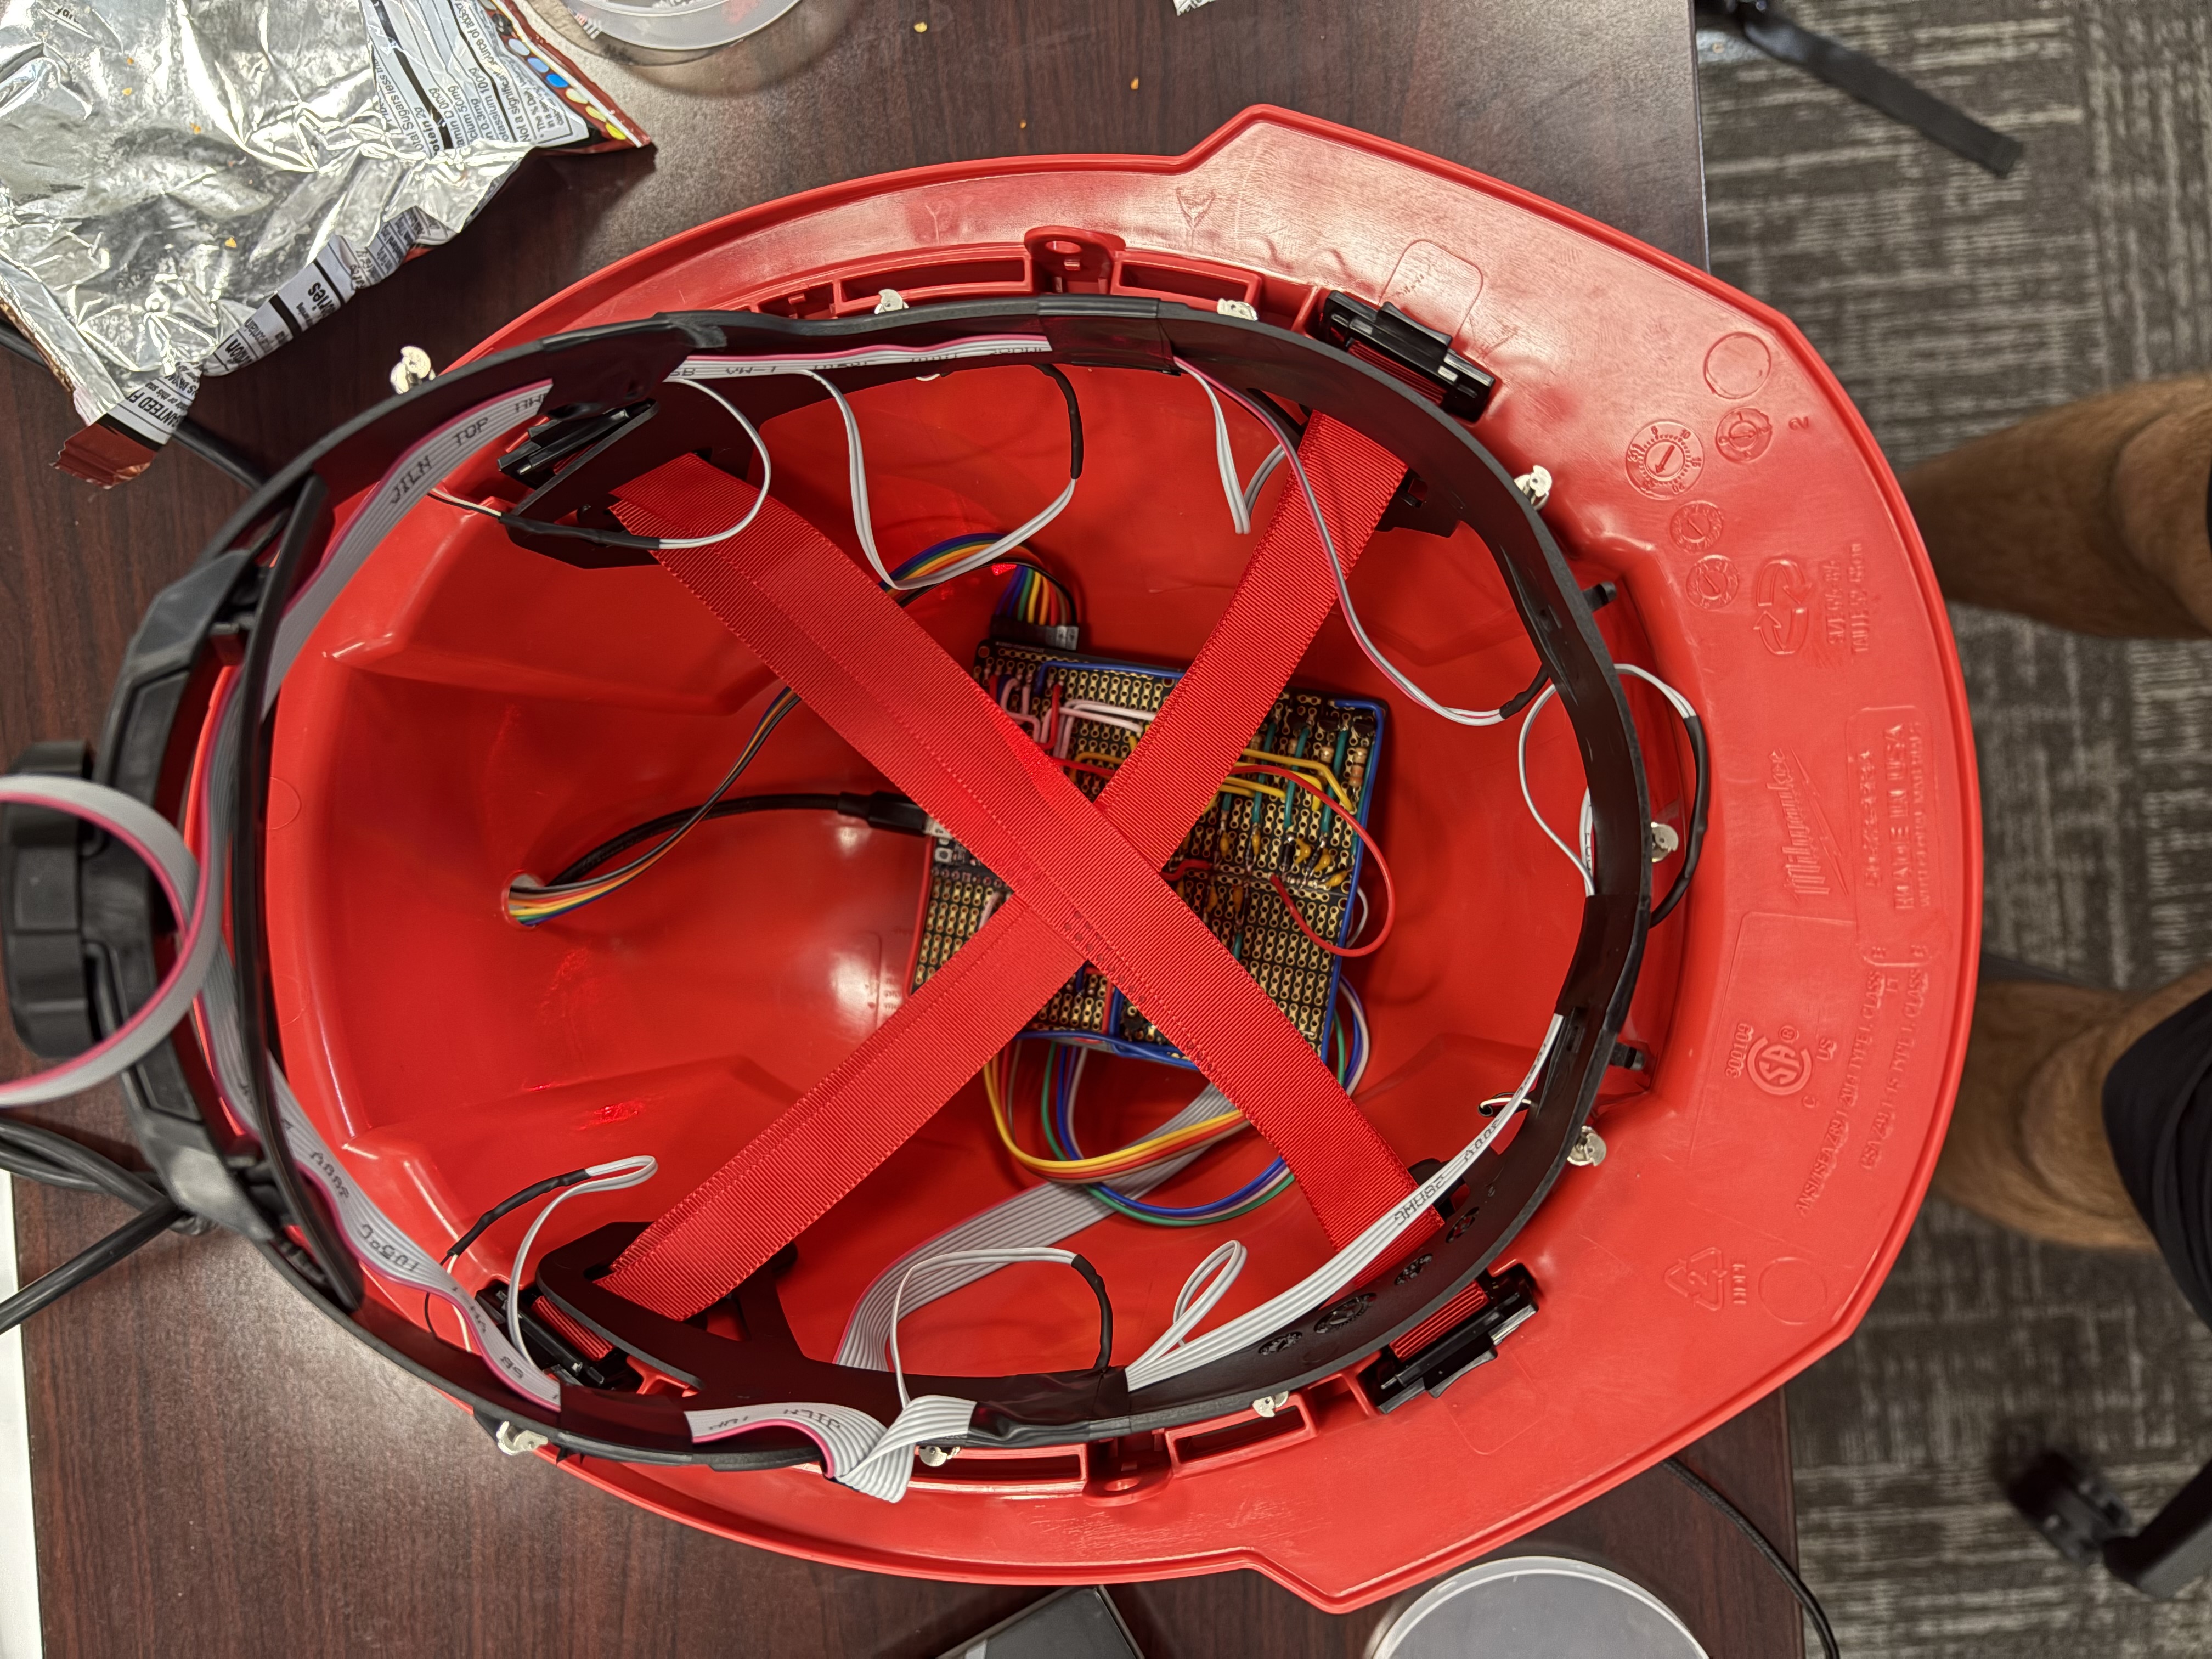
Spidey Sense leverages haptics, mmWave radar and an accelerometer to point first responders to victims that are moving or even stationary.
How we built it
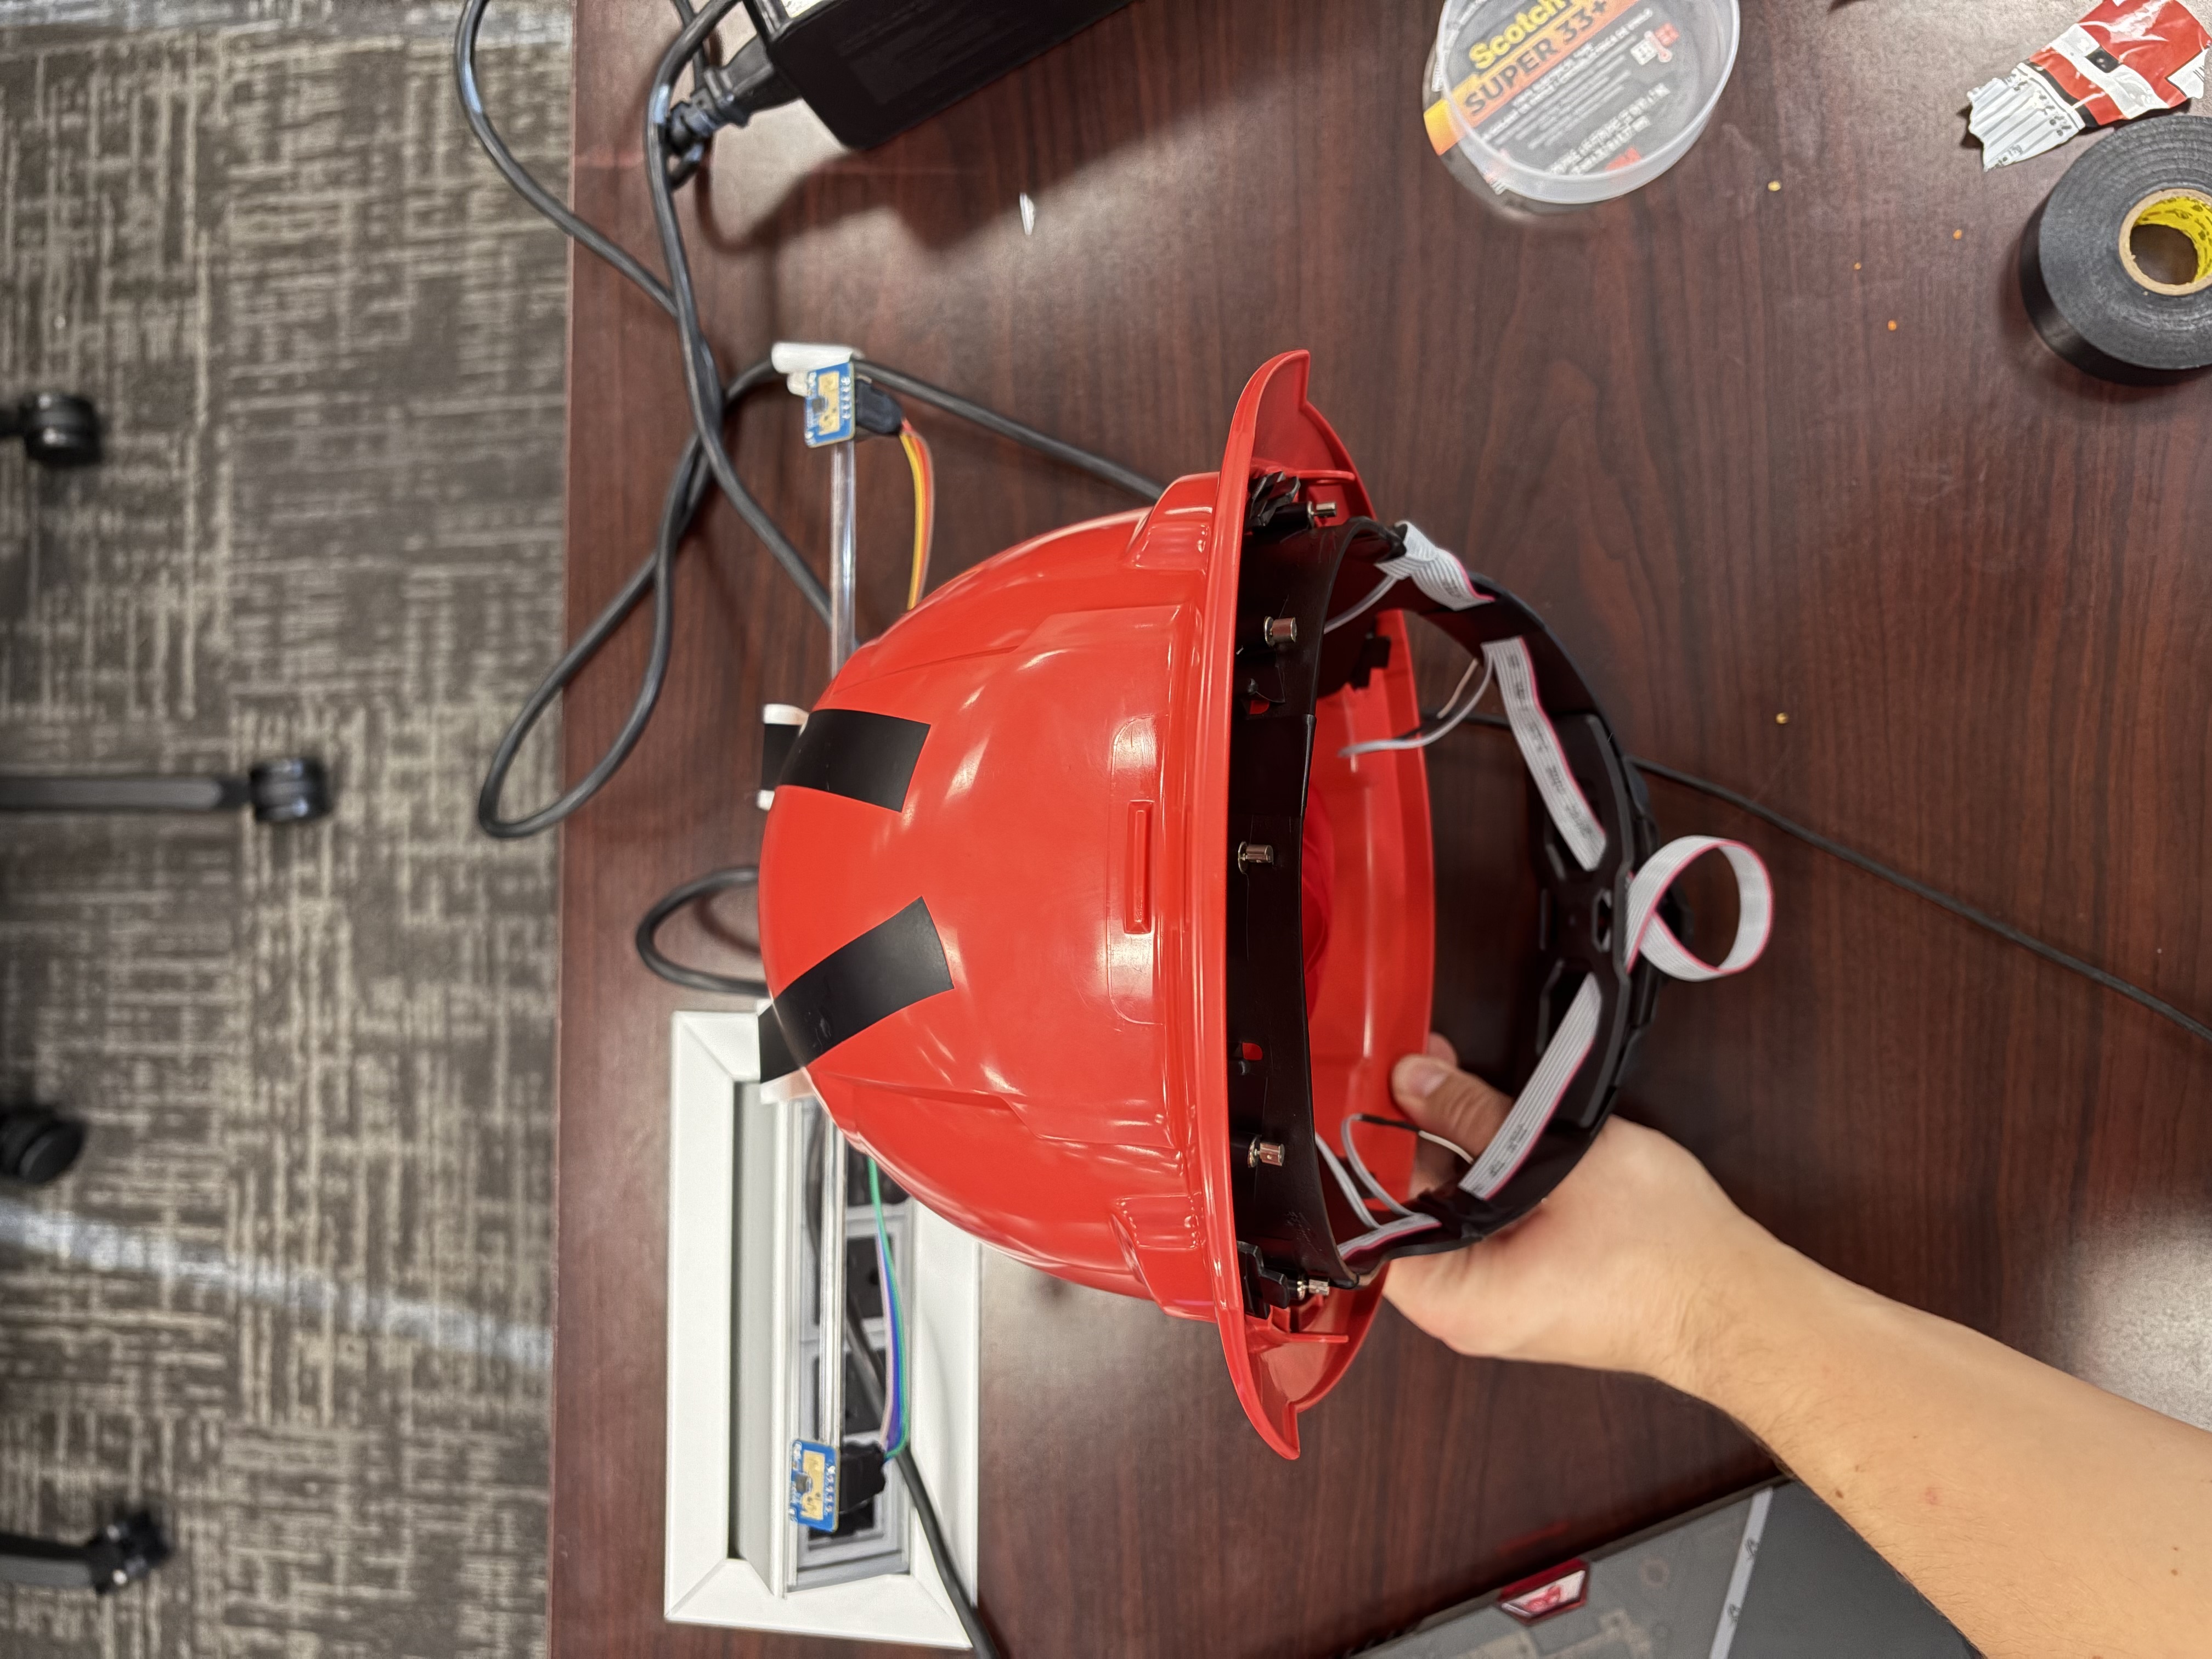
I mapped out all the outputs and gpio first before soldering the motors to the motor control board (custom built) with an esp32 microcontroller as the brain. Then I added two uart mmWave radars which are spaced 1 ft apart to allow for angle assertions through kinematics. Then I mapped angles measured to certain motors and used Google Gemini to code and troubleshoot the device. Next I added the accelerometer for the compass feature which allows the user to double tap the helmet and lock in an anchor direction to make the device act like a compass. This feature was implemented but not fine tuned.
Challenges we ran into
The mmWave radars I had were not actually able to calculate the angles so I had to space them and used Gemini to help me come up with a strategy to derive angles from the device. This left the feild of view much lower than I would have liked but I’m still very happy with the result.
Accomplishments that we're proud of
I’m very proud of the idea, implementation of the idea, and how well it worked. Each motor works almost perfectly and the radars actually work a lot better than I expected. Although they don’t have a full range of view and are a little slow but I think this is largely a result of the mmWave radars being very cheap and not specifically meant for this.
What we learned
I learned about mmWave radar and how to leverage an accelerometer in creative ways
What's next for Spidey Sense
What’s next is putting much better angle detecting radars on as well as a magnetometer to better determine direction
Built With
- c
- esp32
- mmwave


Log in or sign up for Devpost to join the conversation.