-
-
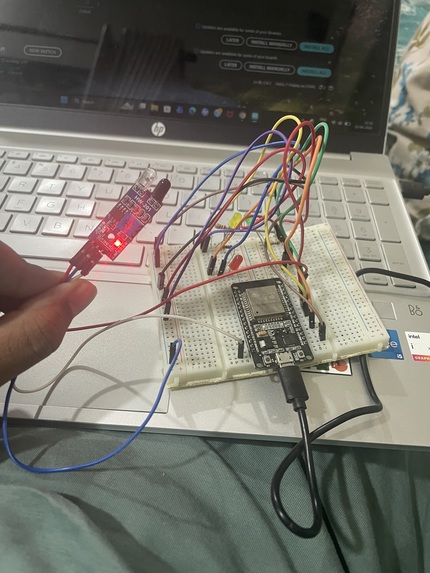
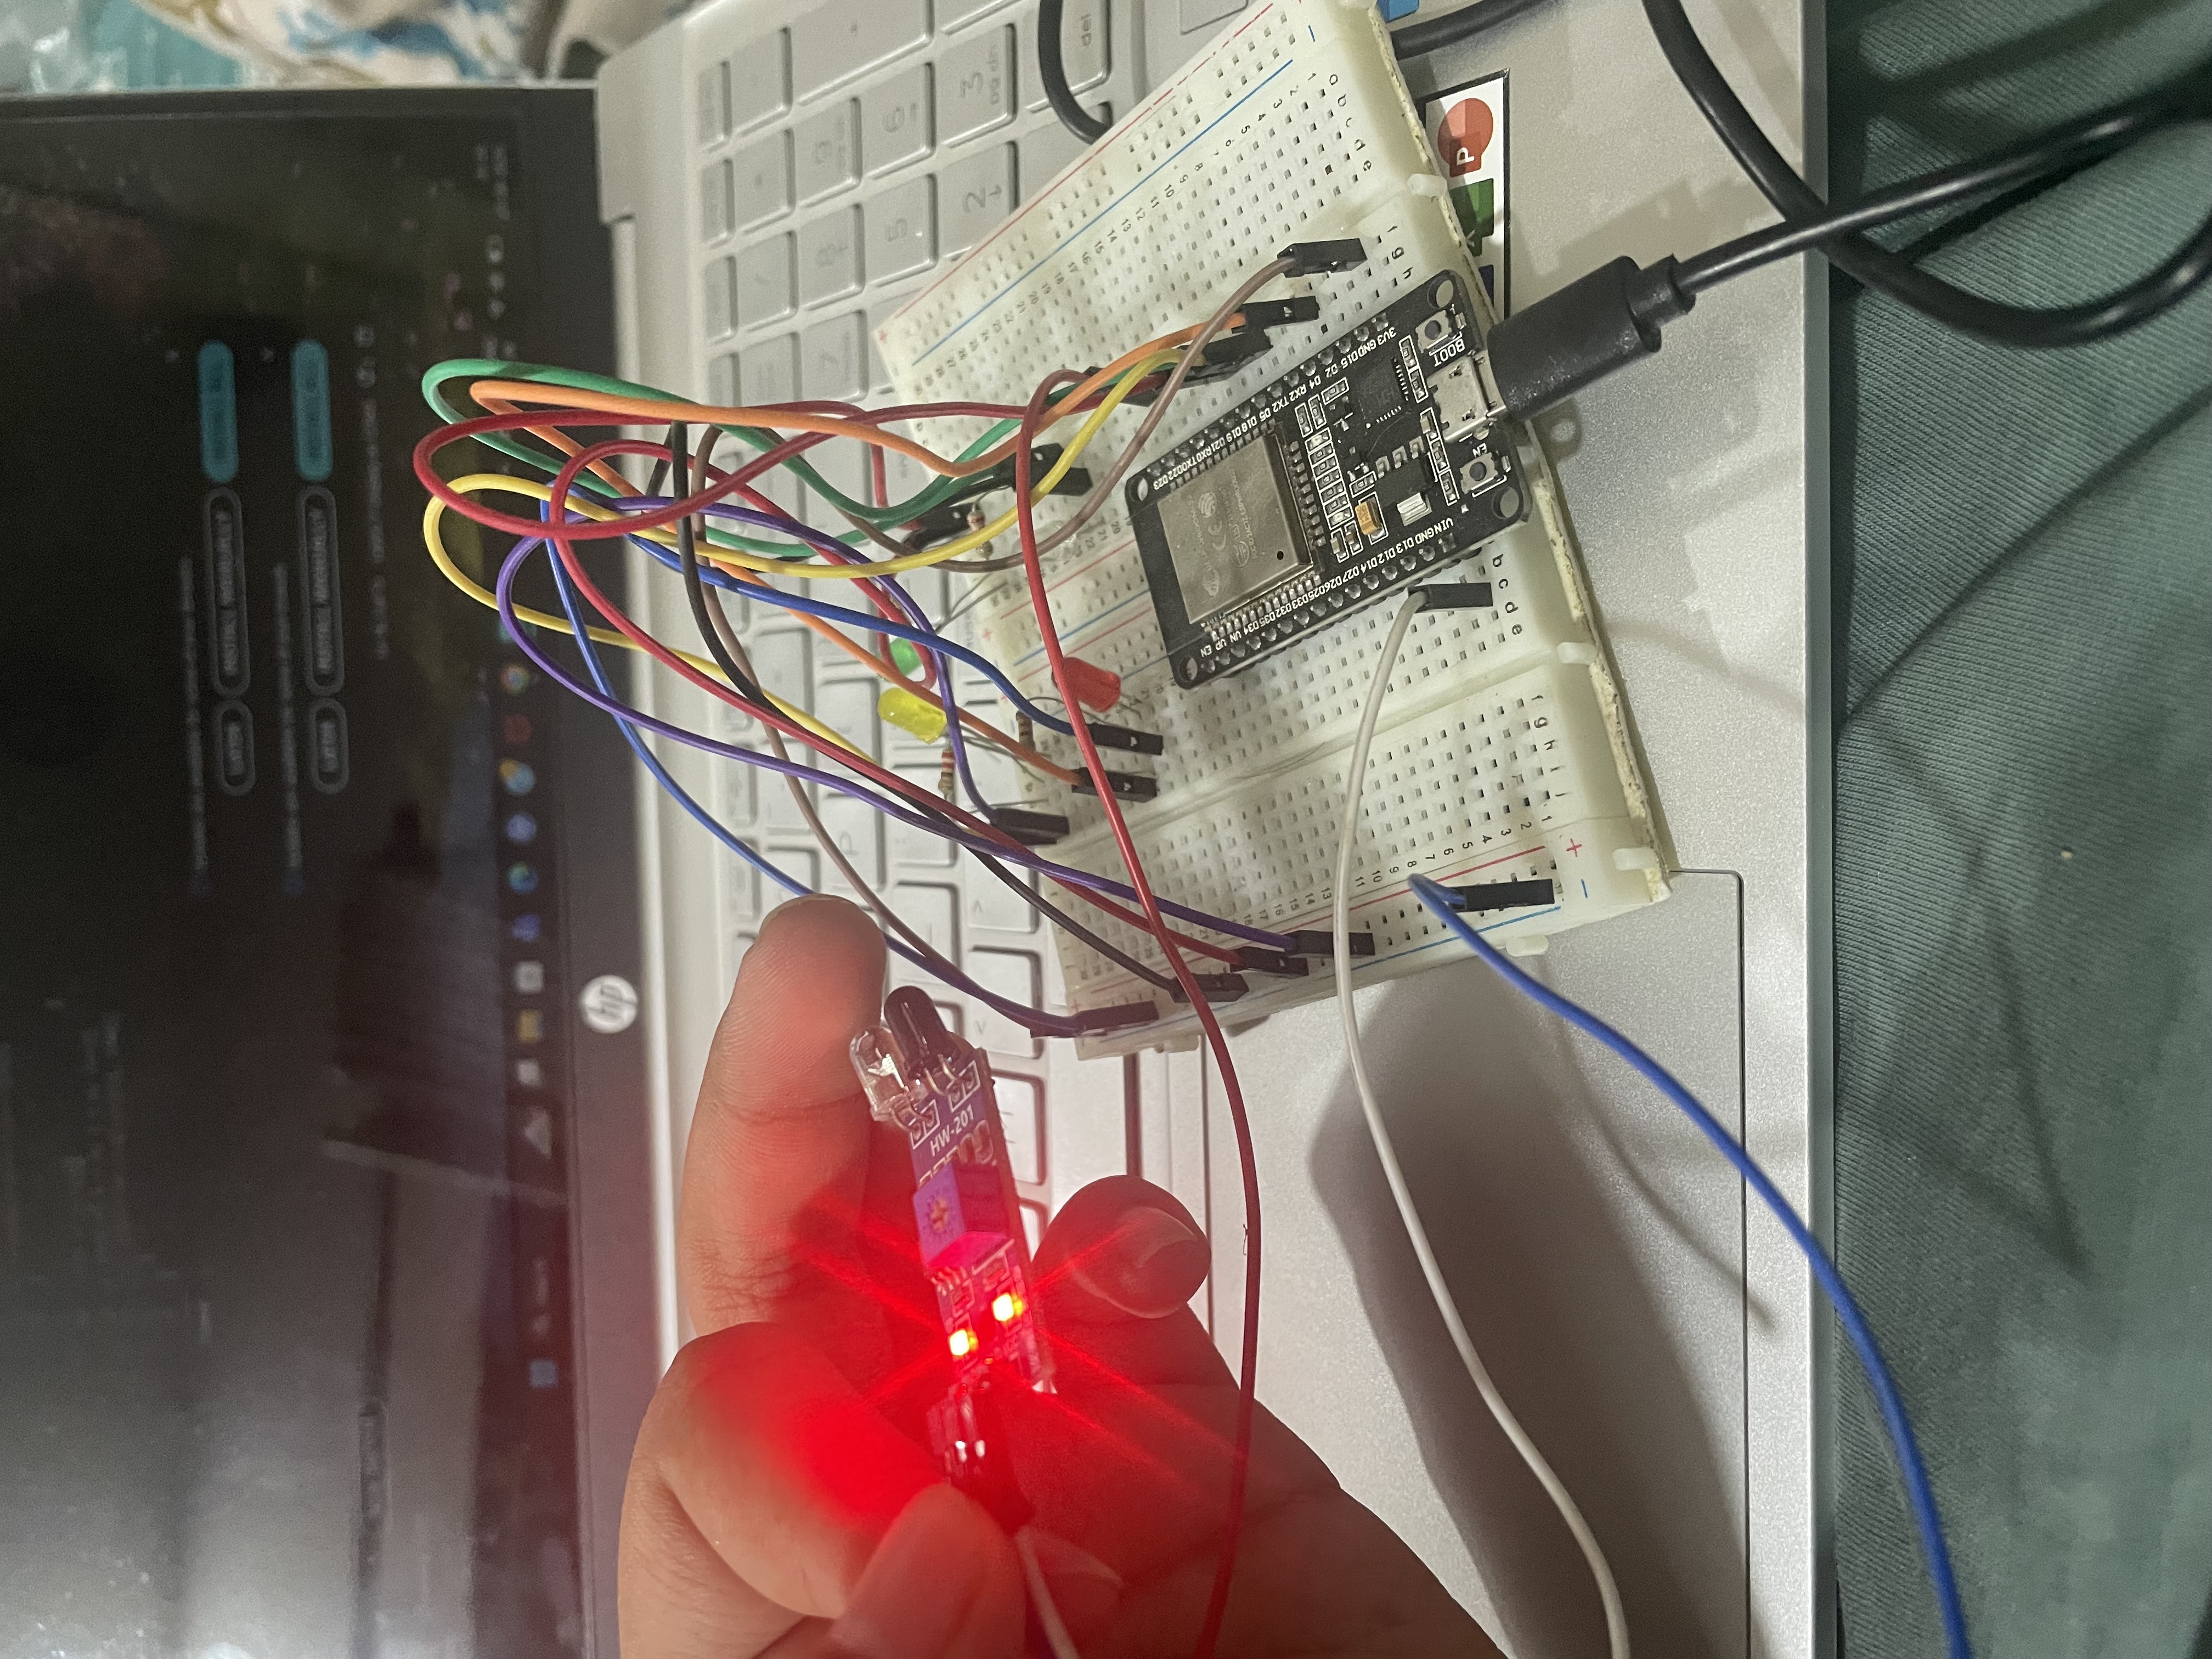
Before sensing
-
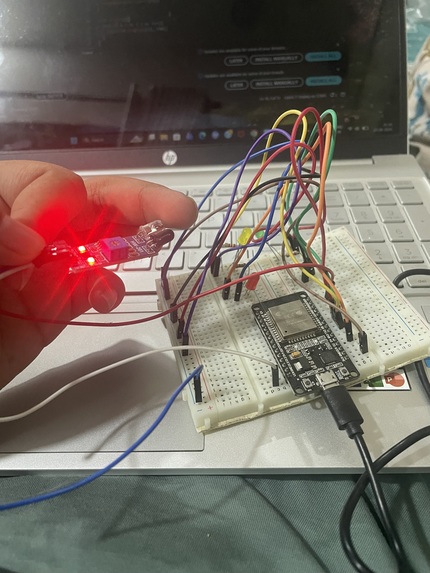
After sensing
-
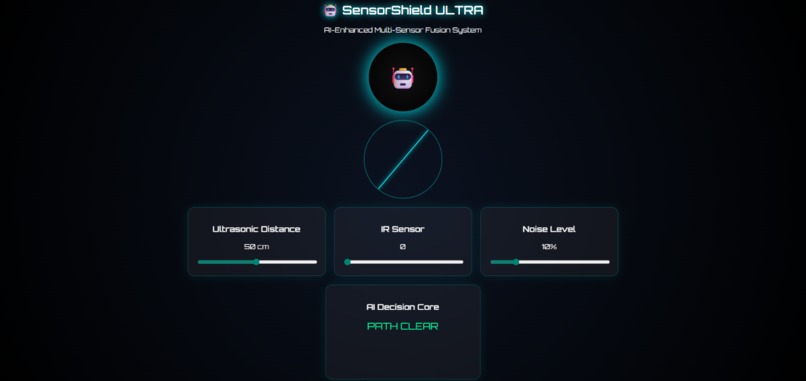
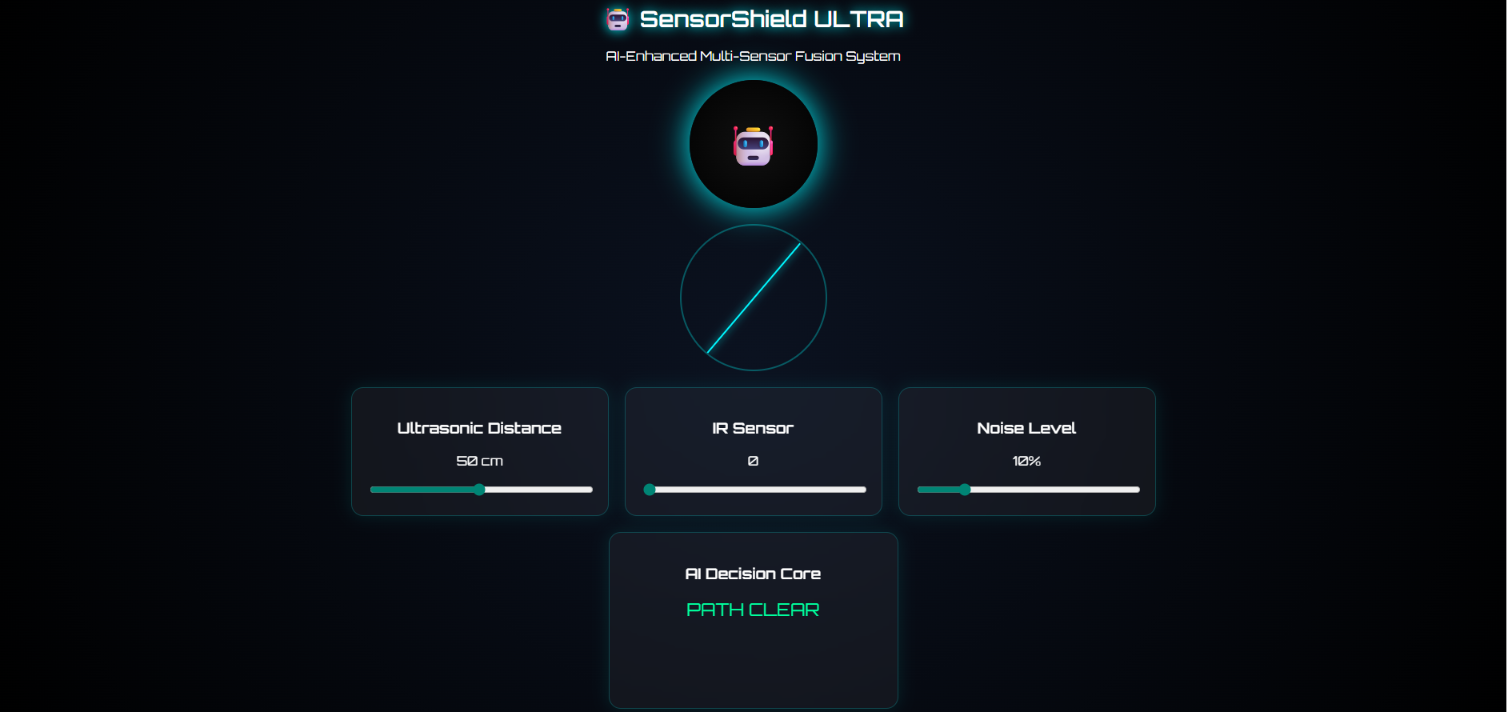
Website
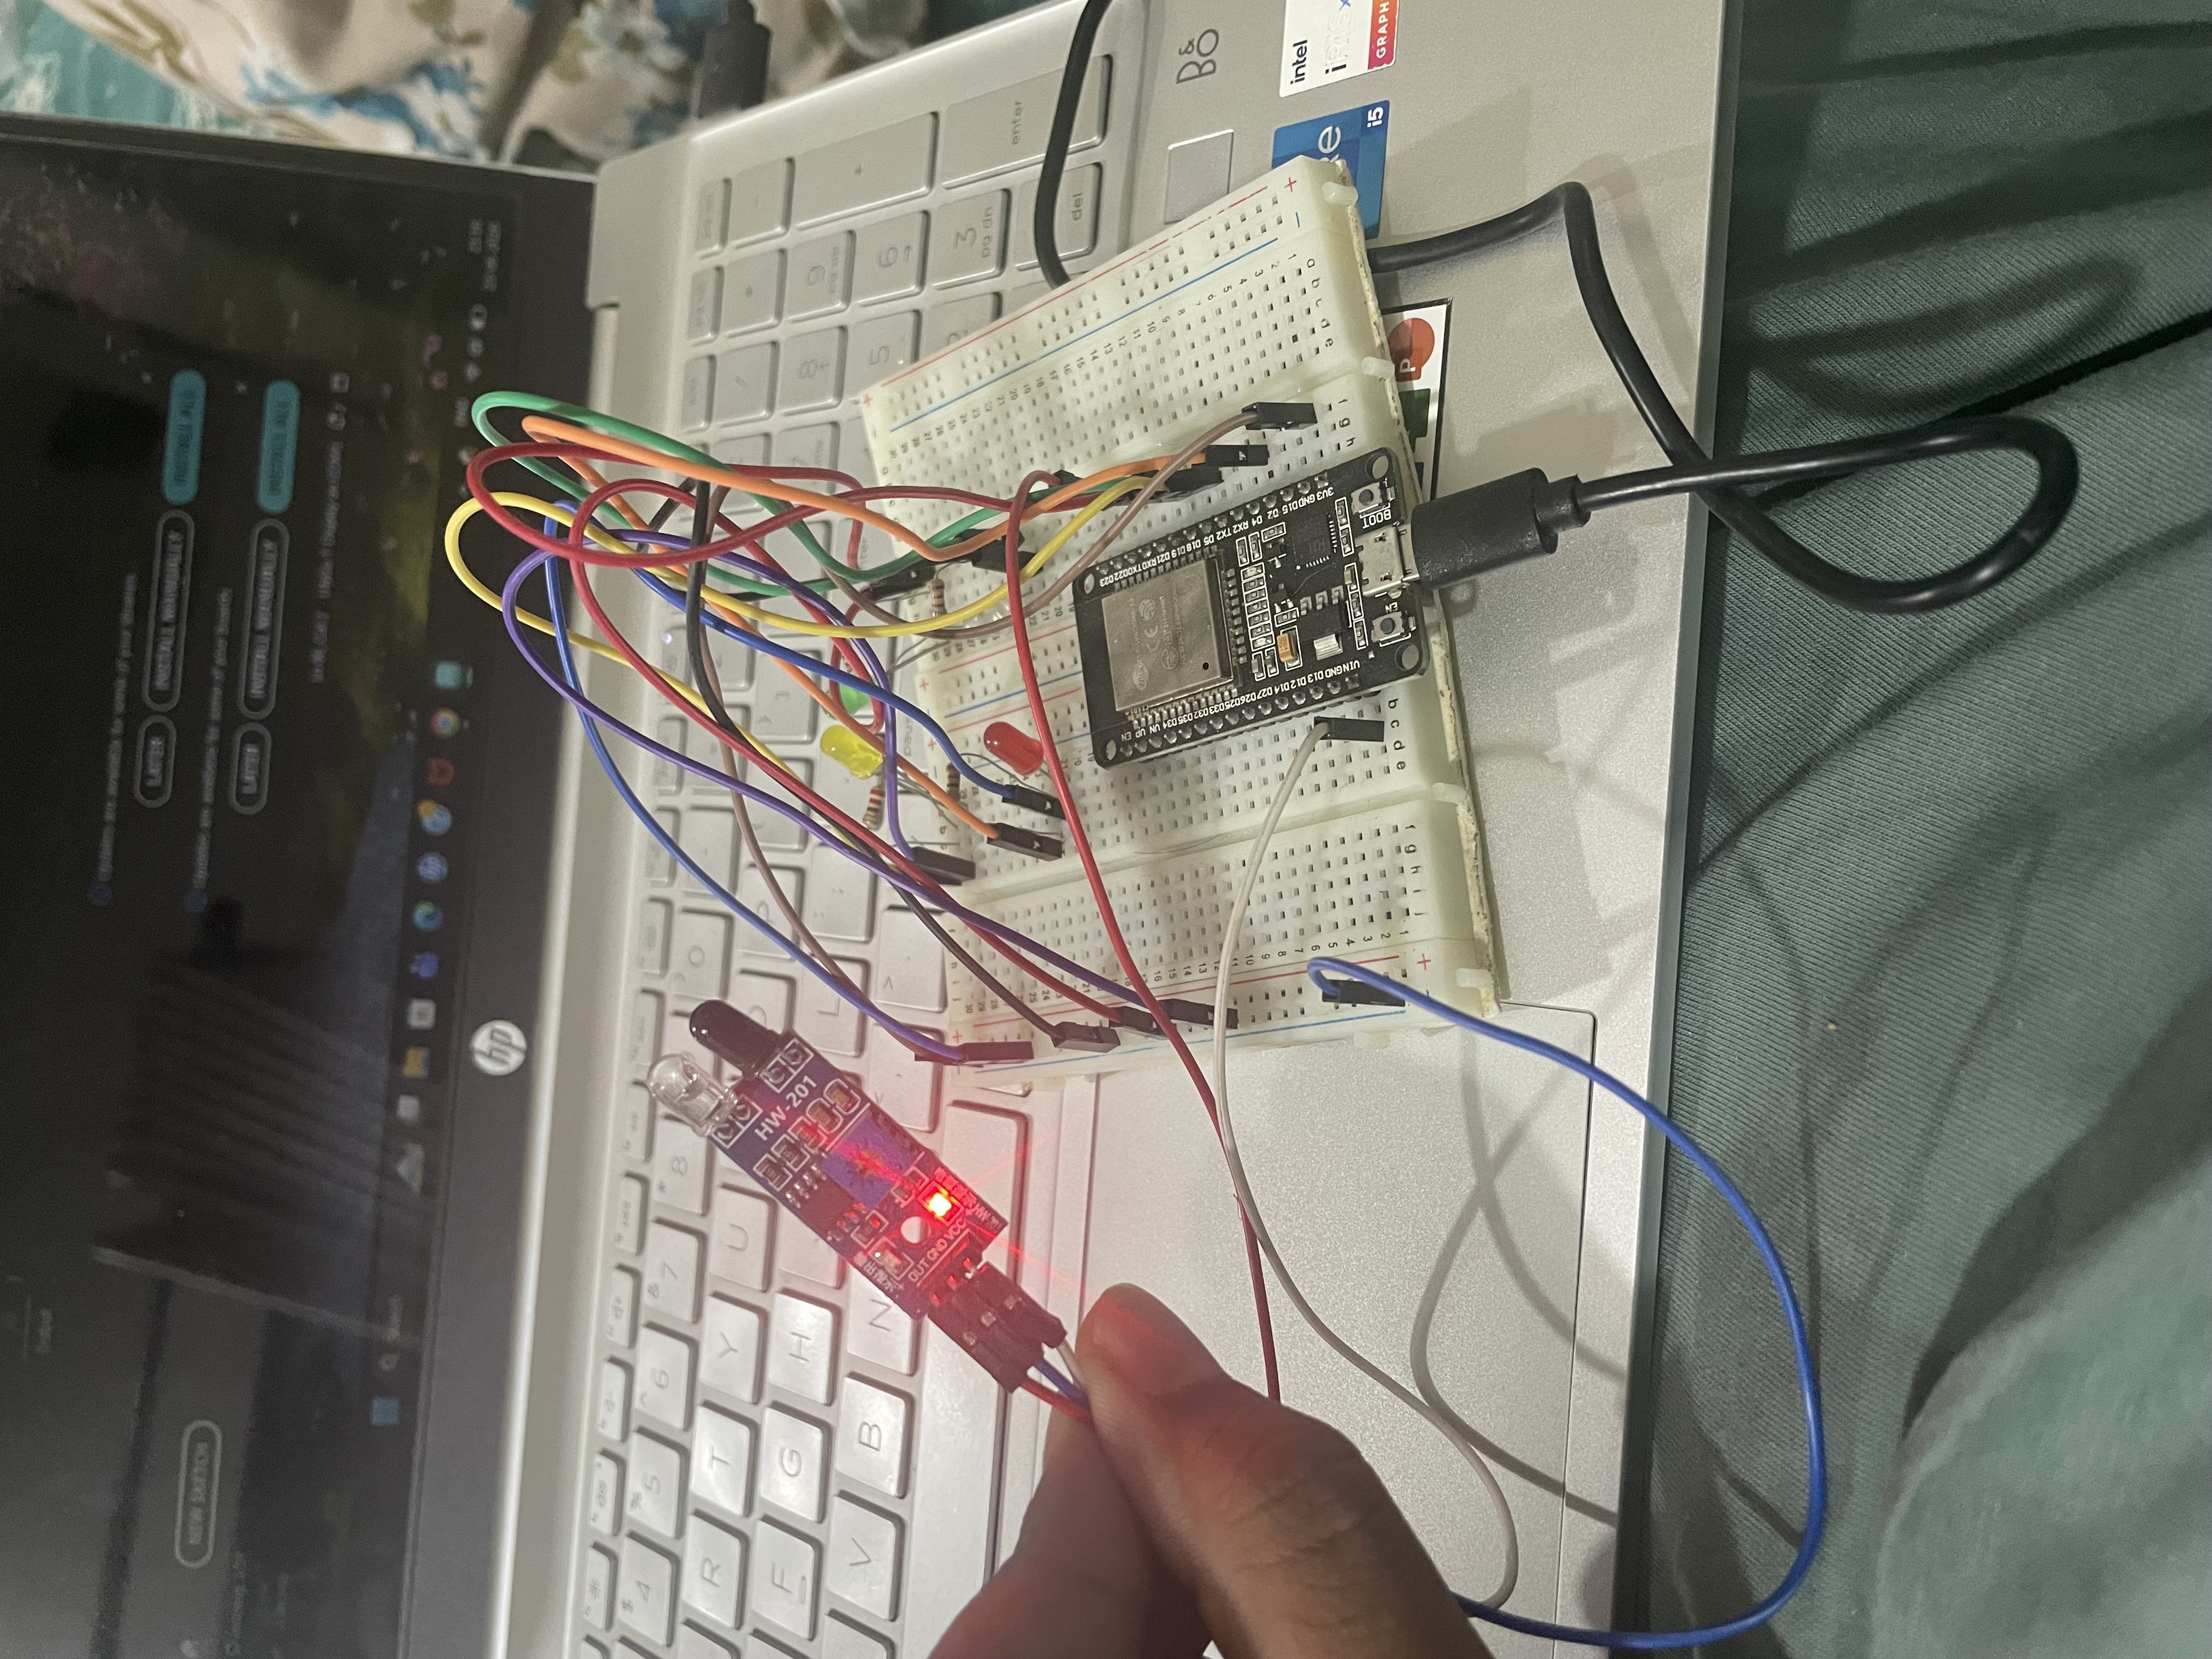
SensorShield: Multi-Sensor Obstacle Detection
I was inspired by the limitations of low-cost robotic systems that rely on a single sensor for obstacle detection, which often leads to unreliable performance in real-world conditions due to distance variation, surface reflectivity, and environmental noise. SensorShield addresses this by combining IR and ultrasonic sensors with a simple decision-making logic to improve detection reliability and reduce false readings. The system was designed using a microcontroller-based (or simulated) setup where both sensors continuously collect distance and presence data, which is then processed through a rule-based logic to determine obstacle presence with higher confidence. While building the project, we faced challenges in handling inconsistent sensor readings under different environmental conditions and designing a system that remains both accurate and low-cost without adding unnecessary complexity. Despite these challenges, we successfully implemented a functional multi-sensor fusion approach and validated that combining sensor inputs significantly improves reliability compared to single-sensor systems. Through this project, we learned how different sensors behave under varying conditions, how noise affects embedded systems, and how simple decision logic can meaningfully enhance system performance. Moving forward, we aim to improve SensorShield by adding adaptive calibration, real-time data visualization, and potential integration with IoT dashboards for remote monitoring and smarter robotic applications.
Built With
- arduino-(c/c++)-for-embedded-system-programming
- basic-rule-based-decision-logic-for-sensor-fusion
- ir-sensor-and-ultrasonic-sensor-modules-for-obstacle-detection
- vscode

Log in or sign up for Devpost to join the conversation.