Introduction
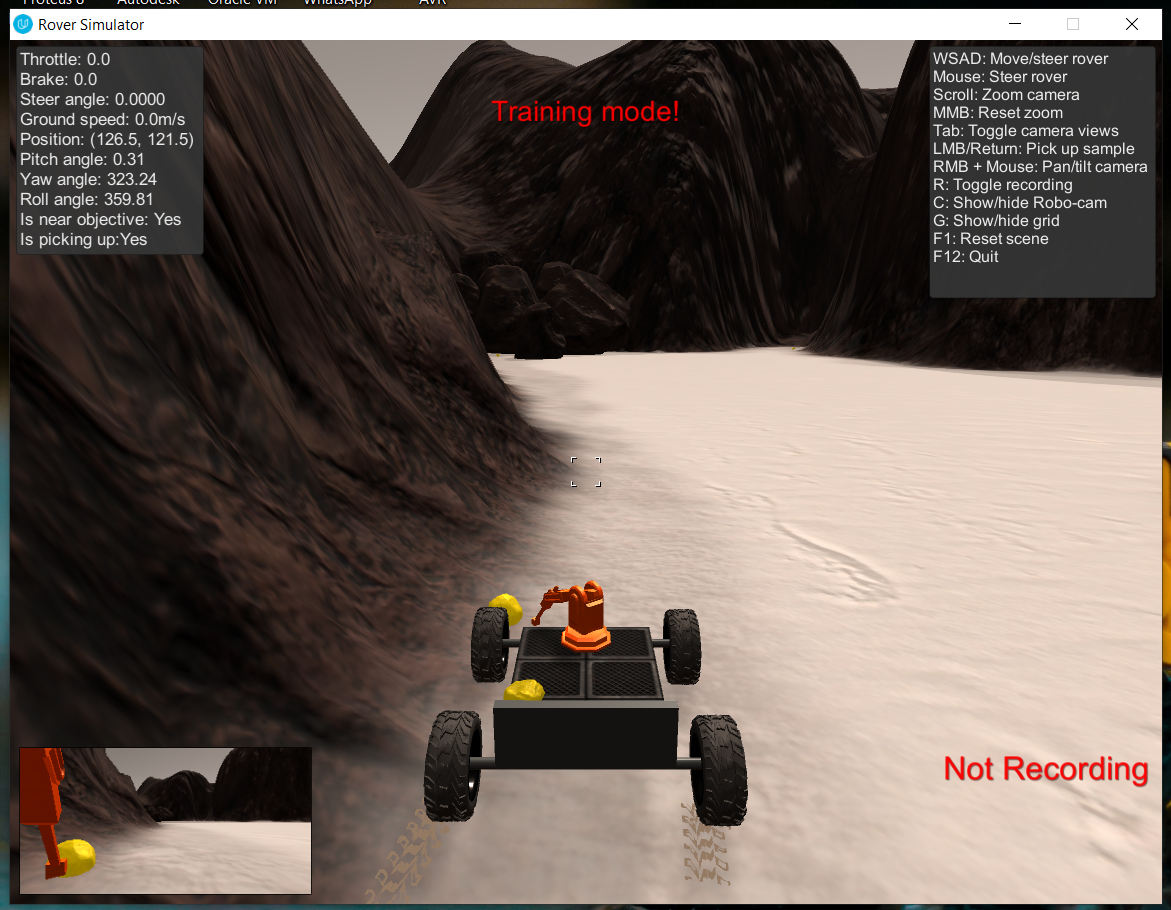
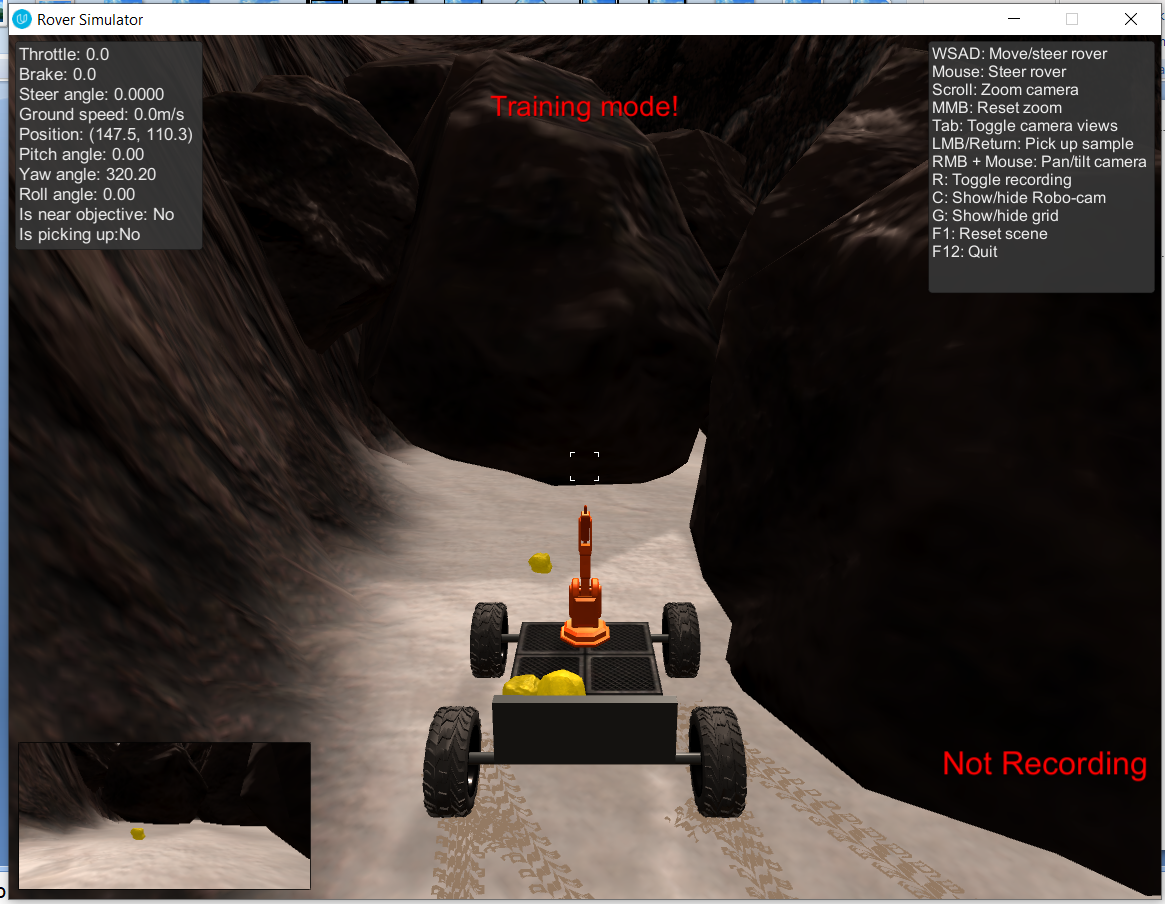
I am going to use the Udacity rover simulator to autonomously drive a rover which will look for samples in a terrain area. The simulator has been modelled after the NASA sample return challenge . The simulator has two modes – Training mode, where we can drive the rover using the keyboard and collect training data and Autonomous mode, where we will be driving the rover autonomously by modifying the functions present in the python driver codes.
The **Github** repository has provided all the required python template codes. We have to implement our algorithm by modifying the codes.
Here is a very basic solution to the project by Udacity - [link]https://youtu.be/oJA6QHDPdQw
Github Repo- [link]https://github.com/udacity/RoboND-Rover-Project

Log in or sign up for Devpost to join the conversation.