Satellite Trajectory AI
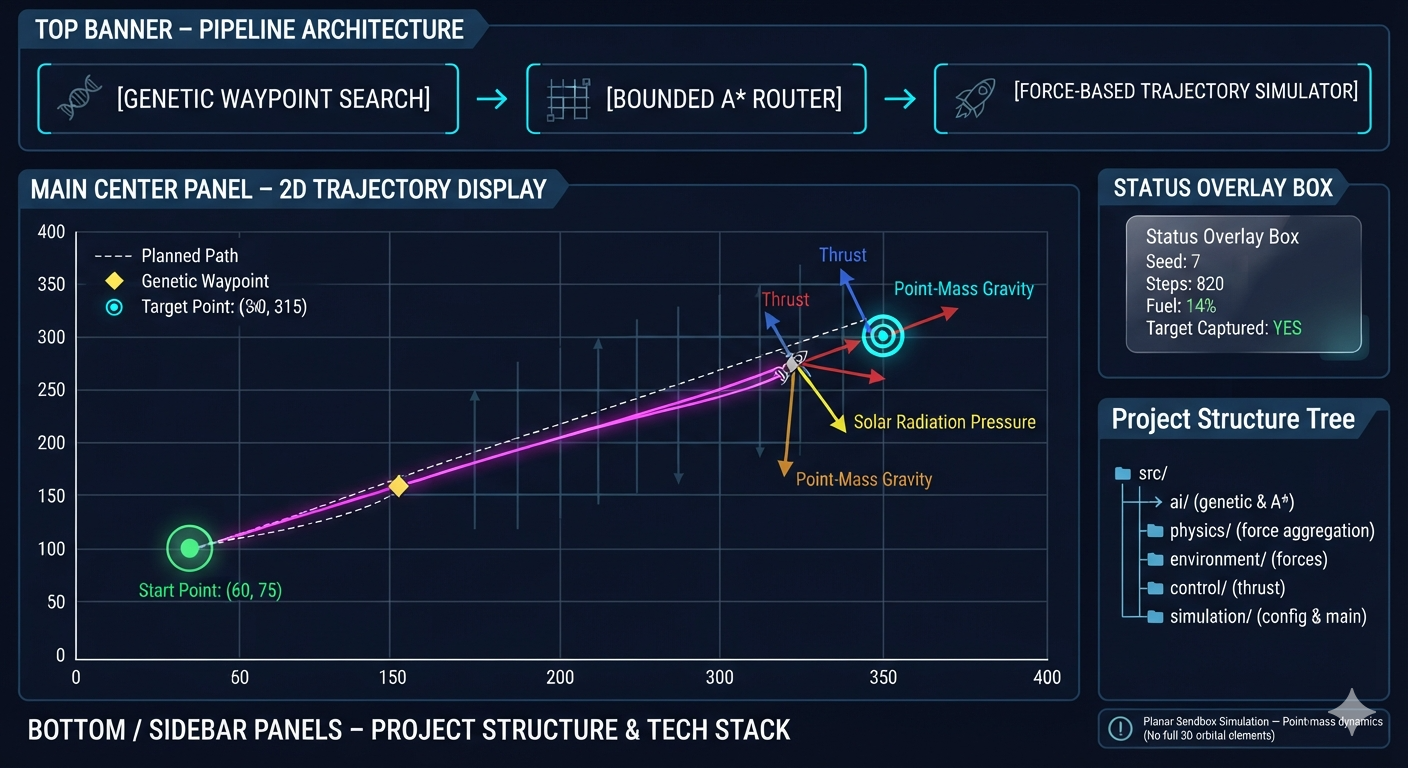
A runnable two-dimensional satellite-transfer simulator that combines a genetic waypoint search, bounded A* routing, and force-based trajectory following.
The project is an educational planning and controls sandbox. It does not attempt to be a high-fidelity orbital mechanics package.
What it does
- Models a satellite with position, velocity, mass, and finite fuel.
- Plans an intermediate waypoint with a seeded genetic algorithm.
- Builds a bounded, eight-direction A* route through the workspace.
- Applies thrust, softened point-mass gravity, optional quadratic drag, and optional solar pressure.
- Stops on target capture, fuel exhaustion, boundary exit, excessive drift, or a step limit.
- Produces an optional plot of both planned and simulated trajectories.
Quick start
Use Python 3.10 or newer.
python -m venv .venv
.venv\Scripts\Activate.ps1
python -m pip install -r requirements.txt
python src/main.py
The default deterministic scenario starts at (60, 75) and targets (340, 315). With seed 7, it captures the target in 820 steps.
Command-line options
python src/main.py --seed 12
python src/main.py --plot
python src/main.py --save-plot trajectory.png
--seed controls the genetic planner's random source. --plot opens an interactive chart; --save-plot writes the chart without opening a window.
Configuration
Edit src/simulation/config.py to define another mission. The Config dataclass exposes workspace dimensions, initial state, target, integration time step, fuel, capture conditions, planning grid size, environmental forces, and random seed.
To use the components directly, add src to Python's import path and compose a configuration, planners, and simulator:
from ai.astar import AStarPlanner
from ai.genetic import GeneticPlanner
from simulation.config import Config
from simulation.simulator import Simulator

config = Config()
simulator = Simulator(
    config,
    GeneticPlanner(config),
    AStarPlanner(config.SPACE_WIDTH, config.SPACE_HEIGHT, config.GRID_RESOLUTION),
)
trajectory = simulator.run()
Project layout
src/
  ai/           waypoint fitness, genetic search, and A* planning
  control/      thrust and heading utilities
  environment/  workspace and external force models
  physics/      body state, force aggregation, and integration
  simulation/   mission configuration and execution
  main.py       command-line entry point
docs/
  problem_statement.md
  physics_model.md
  algorithms.md
  results.md
Documentation
Limitations
This is a planar point-mass simulation. It excludes true orbital elements, three-dimensional motion, real propulsion models, rotating reference frames, and obstacle generation. Treat its output as an algorithmic demonstration, not a navigational or mission-design result.

Log in or sign up for Devpost to join the conversation.