Inspiration
Inspired from the AT-ST Walker in Star Wars
What it does
A robot capable of running, navigation and delivery
How we built it
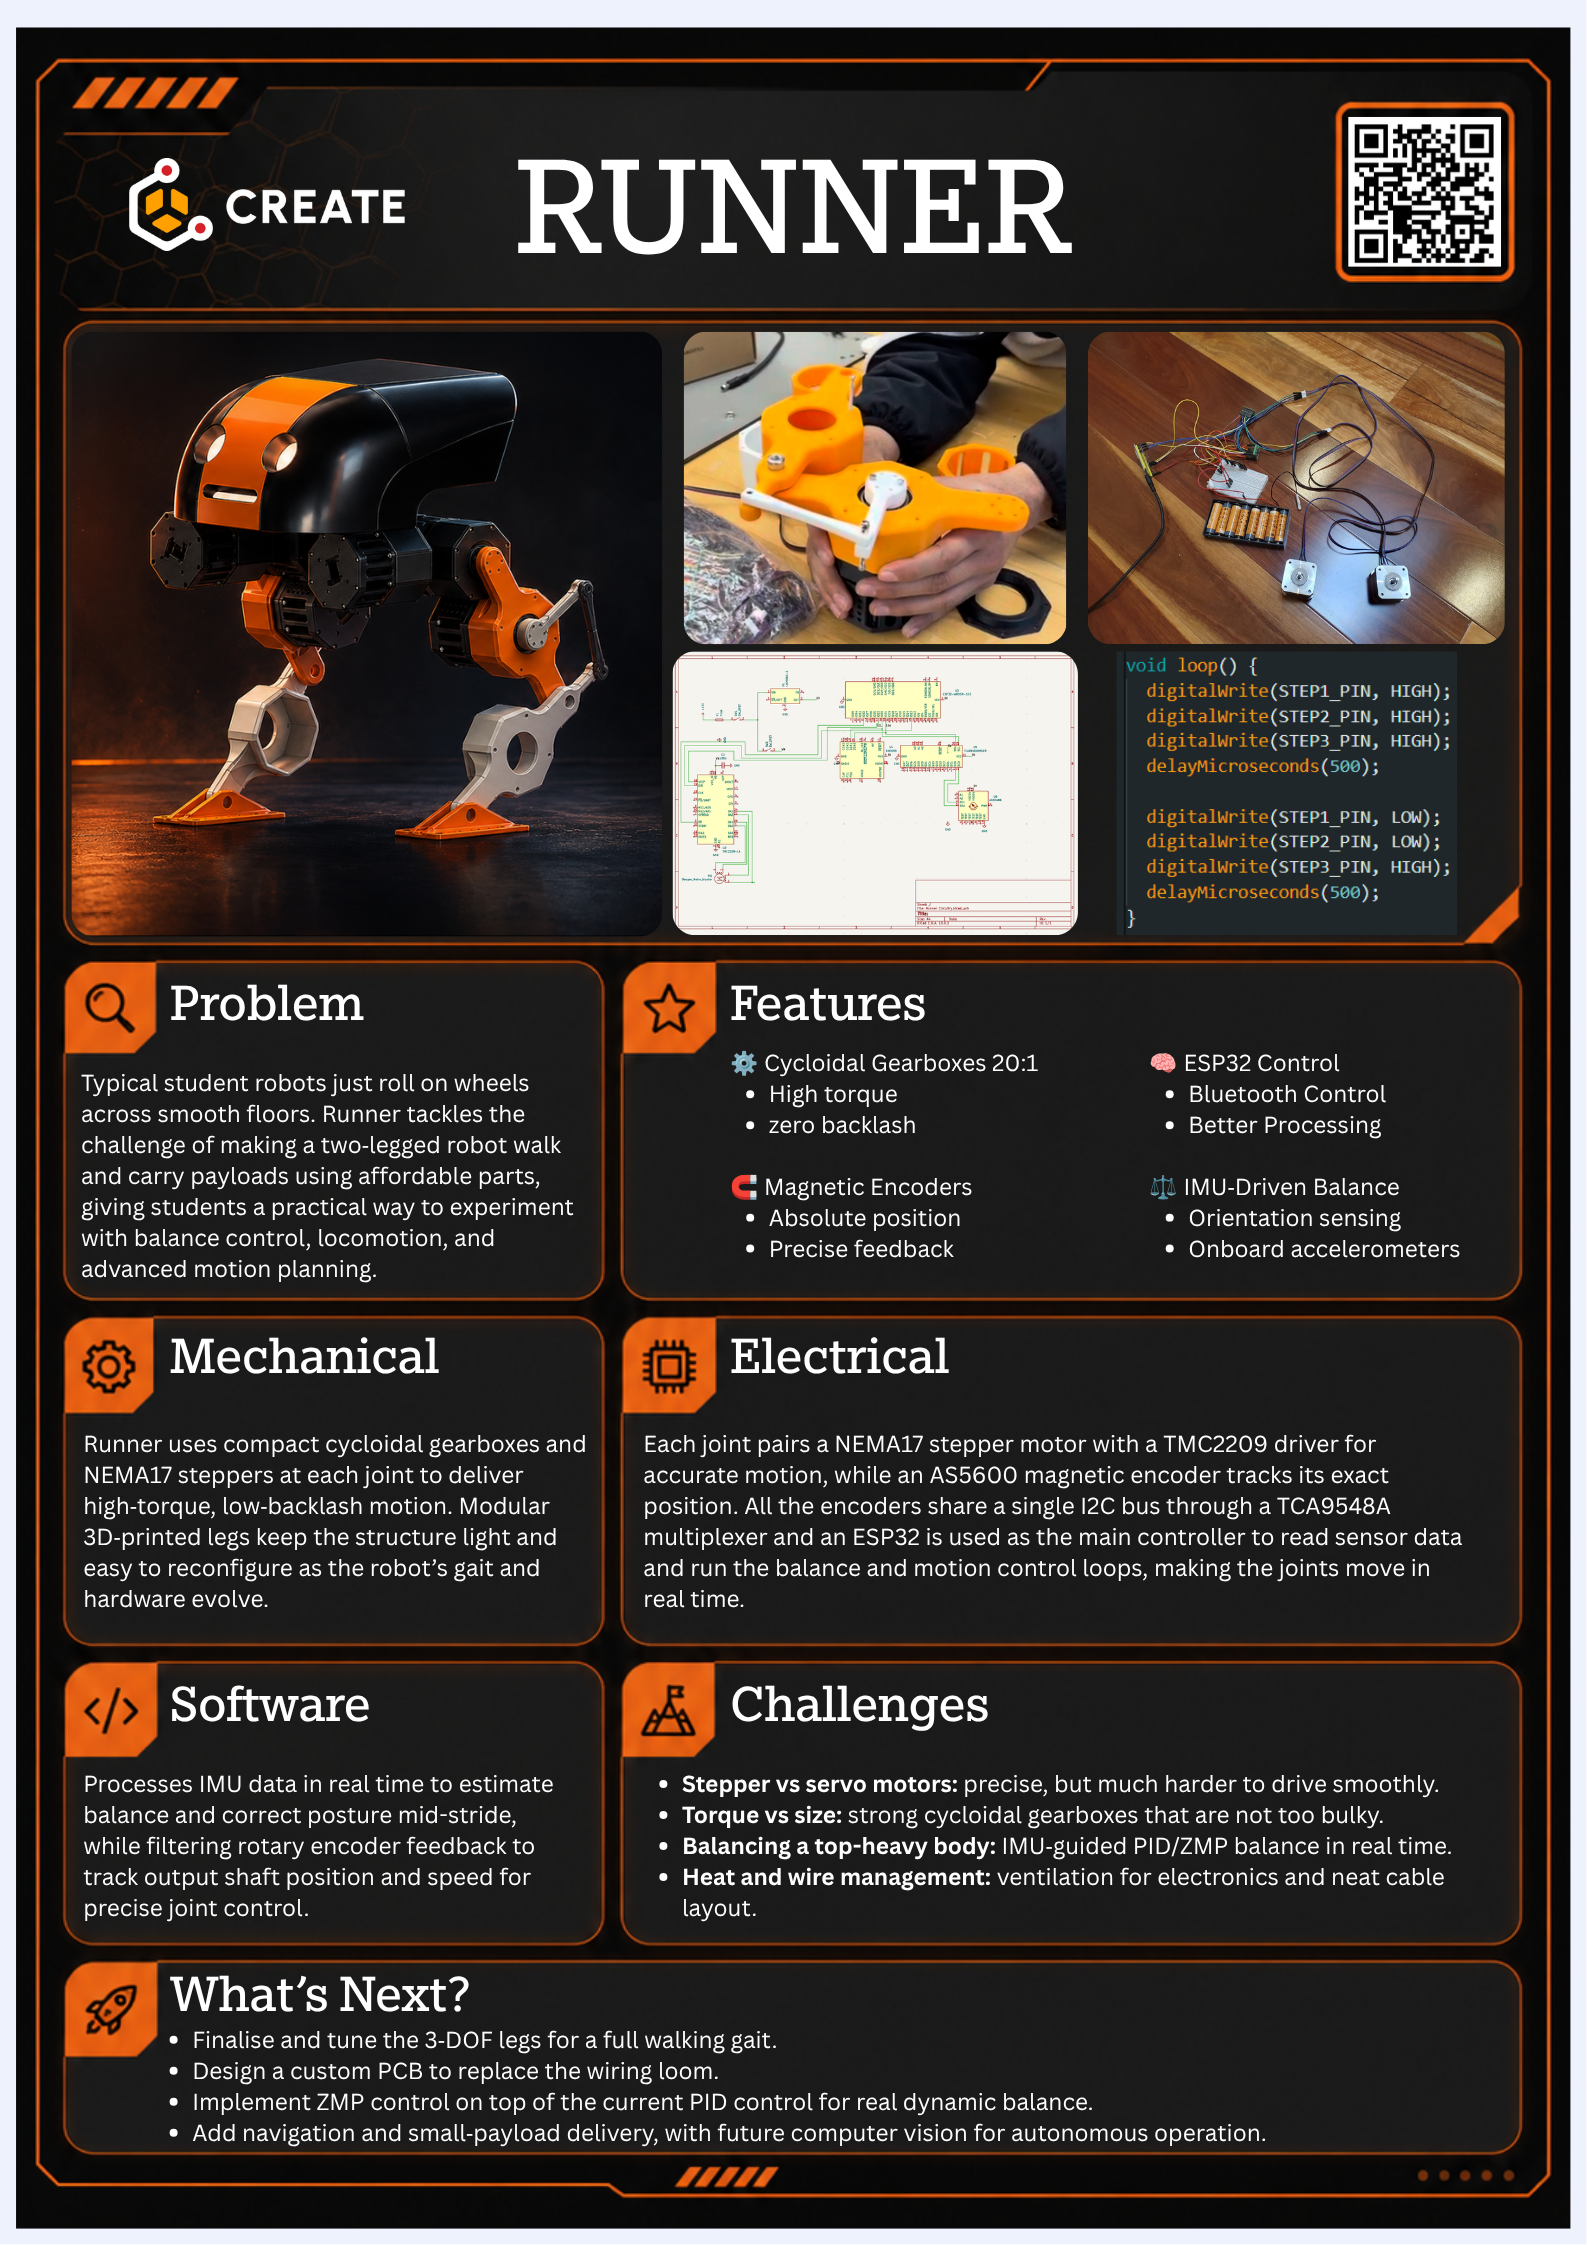
ESP32 microcontroller; the joints consist of a motor driver, a stepper motor and a magnetic encoder, in a cycloidal gearbox. PID and ZMP code will be used for balance control
Challenges we ran into
The fitting of the cycloidal gearbox, motors jittering. In future, it will be testing our PID and ZMP code
Accomplishments that we're proud of
As of right now, we have verified that a joint moves through our cycloidal gearbox and will be looking to do a complete construction of the robot shortly
What we learned
We learnt how to construct a cycloidal gearbox as well as how the electronic components like the motors, motor driver, encoder and IMU all work together to drive the robot. We will soon be working on learning how to make a PCB for it. We will also be learning sophisticated PID control code and soon, ZMP control
What's next for Runner
Doing a full construction of the robot and then getting into the testing of the PID code
Built With
- arduino
- arduinoide
- encoder
- esp32
- gearbox
- imu
- nema17
- pid
- tmc2209
- zmp
