-
-
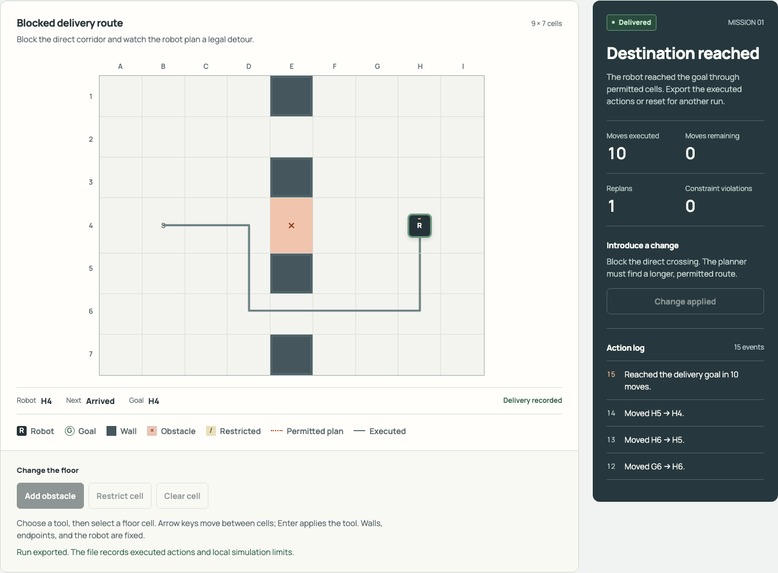
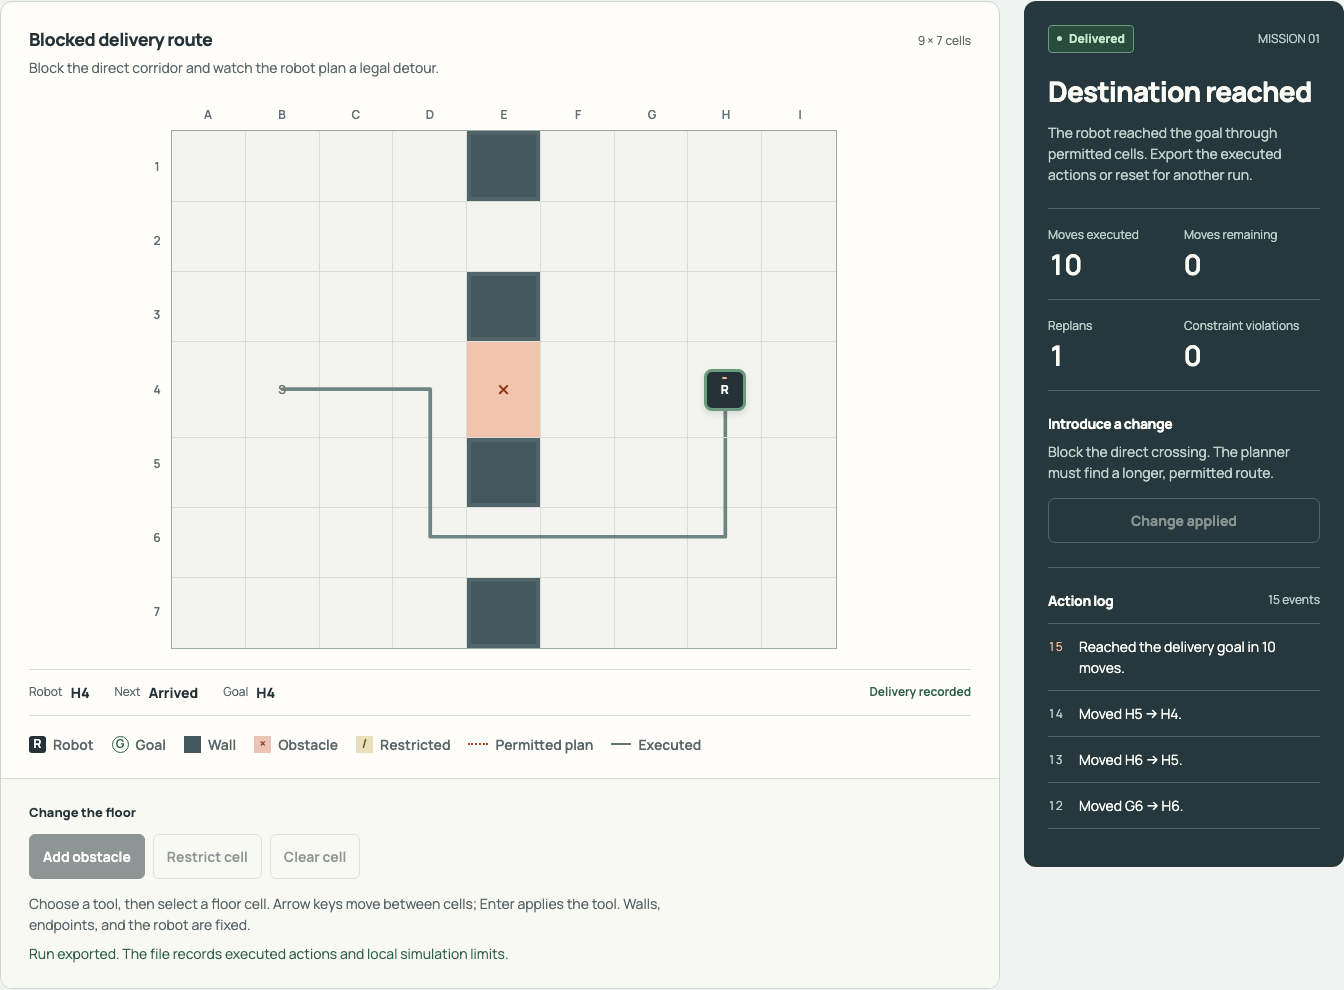
Actual synthetic grid simulation: ten moves and one replan. No robot, physical safety validation, or cloud execution.
-
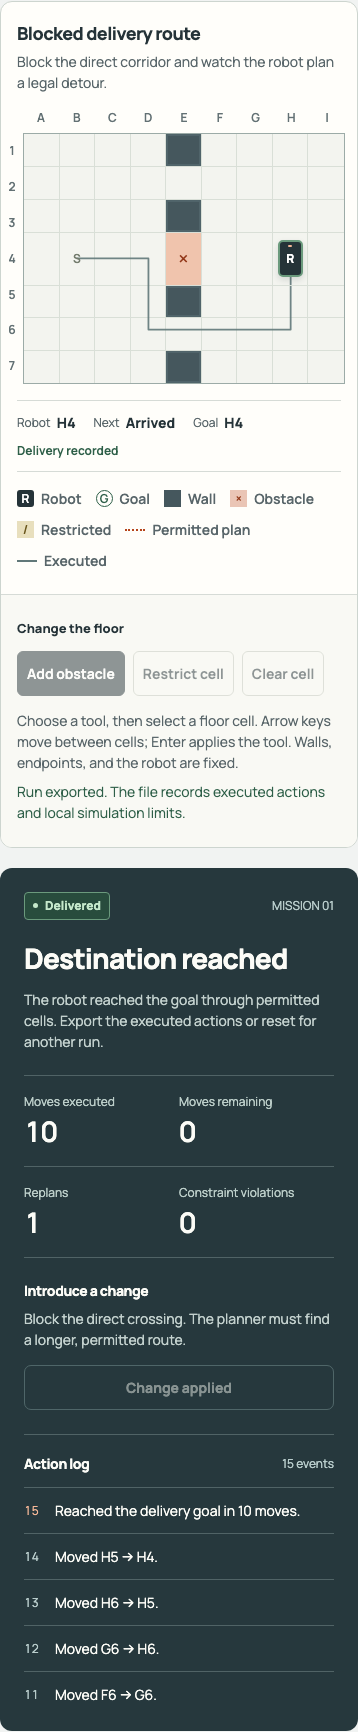
Mobile synthetic route recovery with audited movement. Live NVIDIA model and Nebius cloud-job execution remain unverified.
The problem
When a delivery route becomes blocked, a recovery suggestion needs a visible state, constrained actions and an inspectable outcome. Route Recovery lets an operator test that process in a fully known synthetic grid.
The product
Change obstacles or restrictions, inspect a recovery suggestion and explicitly apply it. NVIDIA Nemotron Lightning (nvidia/Nemotron-3_5-Lightning) on Nebius Token Factory selects follow, hold or request operator clearance for the exact reviewed state. A deterministic breadth-first planner validates movement; the model cannot invent coordinates, clear an obstacle or declare success. A changed map invalidates the old decision. The export preserves the actual action history.
Sponsor technology and build
The Node.js and browser implementation separates model advice from constrained execution. A real Tavily search retrieves navigation references, and selected passages feed a separate Nemotron evaluation checklist. Web content never grants movement clearance.
A reviewable Nebius AI Cloud Serverless Jobs bundle is implemented to evaluate the same state and policy. No Cloud job has run: verified funded access is still unavailable. Preparing a bundle is not cloud execution. Deepgram Aura-2 Thalia generated narration audio that passed technical checks; the public edited demo is linked below; listening review is not claimed.
What is verified
One live Nemotron decision was applied to the synthetic detour scenario. Ten audited grid moves reached the goal with zero constraint violations and a valid saved history. This establishes that scenario only. The standalone full suite passed 82 tests; later focused checks passed 17 research units and two API/browser checks. Counts overlap, and local fixtures remain distinct from live inference.
The latest research output quotes relevant pause/replanning options but assumes Nav2 and XML details that this product does not implement. Original outputs are preserved and a separate assistant review narrows the comparisons. The product uses no robot hardware, sensors, physics engine, Isaac Sim or Nav2 runtime. It does not establish physical safety. Physical AI qualification remains unverified while real Serverless Jobs proof is unfinished. The video now includes 67.373 seconds of time-preserved actual local module capture, excluding gaps over one second; no generated intermediate states were added.
Run and current access
Public repository · Exact-commit test-build ZIP
Published and checked on 30 October 2026 at commit a7e845386fa28939237215ff0af72b913dce137f. The public repository includes an MIT license, setup documentation, source and tests. The exact-commit ZIP was prepared from this release; the public archive URL was checked without authentication.
Download the ZIP, unzip it, enter the extracted folder and run the commands below. Node.js 22+ is required. Local controlled examples work without provider keys. Live sponsor actions require private user-owned environment configuration, verified provider access and a fresh free-usage review; no credentials are bundled.
npm ci
npm start
Open http://127.0.0.1:4190/route/. For local fixture tests, run npx playwright install chromium and npm test without provider credentials. This is the deterministic synthetic grid application. A completed Nebius AI Cloud Serverless Jobs evaluation remains unverified; no robot hardware, sensor or physics validation is claimed.
This download is a local source test build. The server binds to loopback; no always-on hosted application or organizer-managed provider credentials are supplied. The public English demo video is attached below. It combines dated saved inference evidence with current actual local module capture.
AI tools and development
Codex assisted with implementation, interface refinement, test authoring, debugging and independent review. NVIDIA Nemotron performed the bounded runtime tasks described above; Tavily supplied search results, and Deepgram generated narration. AI output was checked against saved state, validation rules and actual execution evidence. Separate Claude-built hackathon projects are not part of this entry. No controlled head-to-head comparison with other models was performed.
Public demonstration — 30 October 2026
Watch the demo. The 151.02-second video includes 67.373 seconds of actual local module operation. That deterministic mission reached the goal in ten moves, with one replan and zero recorded constraint violations. Dated 22 October evidence shows the separate live Nemotron decision. No Cloud Job, physical robot, dynamics, Nav2 runtime or physical-safety validation is claimed. Technical full decoding and selected visual checks passed; narration uses saved Deepgram audio only.
Built With
- css
- deepgram
- html
- javascript
- nebius-token-factory
- node.js
- nvidia-nemotron-lightning
- playwright
- tavily
