-
ROBOT!
Inspiration
The inspiration began with the concept of a maze-like game, but quickly evolved into a more practical discussion of the merits of mazes. This robot was born of a desire to solve puzzles, an impetus of the curious mind.
What it does
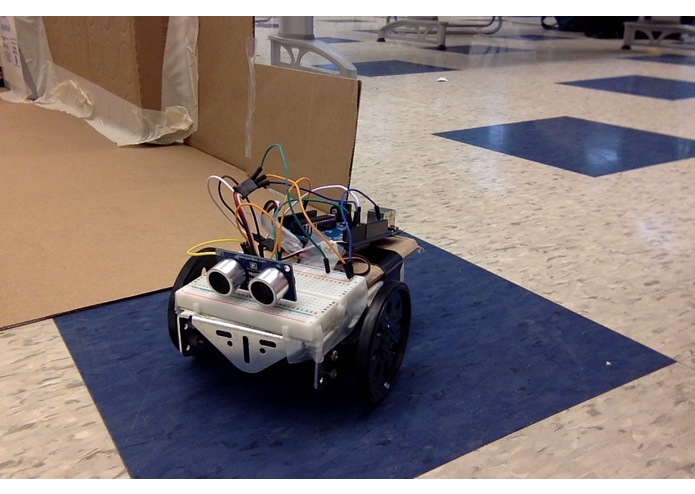
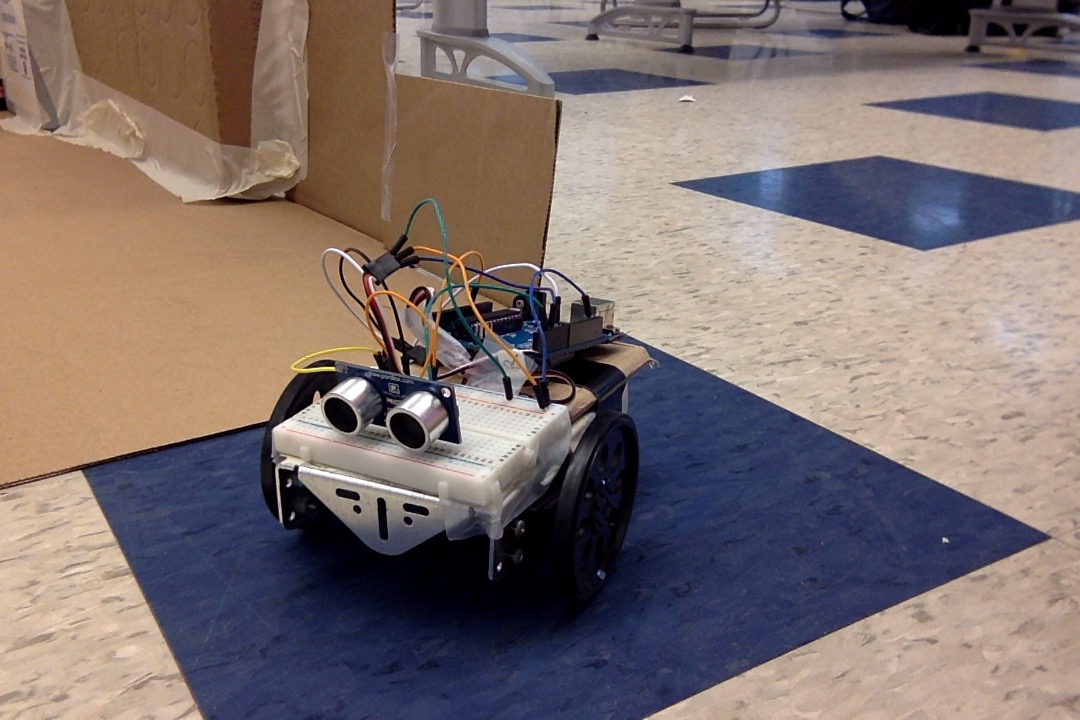
Solves a closed maze by an unoptimized route utilizing an ultrasound range sensor.
How we built it
We began with a chassis and a dream, then through the application of an Arduino, and liberal amounts of tape, hope, and perseverance, we turned it into a reality.
Challenges we ran into
It was especially challenging to learn all of the Arduino IDE that we did in such a short time, and thus the application also gave us challenge as we were unsure as to best practices, and struggled along many dead end roads before finding what we felt was functional.
Accomplishments that we're proud of
The construction of the maze itself is an impressive feat of engineering due to the materials and restrictions placed on it by the design of the robot, and also the application of technologies nobody in our group was familiar with was enlightening.
What we learned
The advantages of wireless communication between bots and controllers, and also the sheer resilience of bugs.
What's next for Robot Run
Robot Run is outdated tech that is usurped by the speed of route optimization by supercomputers and quantum computing.
Built With
- arduino
- duct-tape
