## Inspiration

In field service, equipment rental, and industrial maintenance operations, kits of specialized tools must be verified before dispatch and upon return.

Traditional visual inspection applications rely on a **one-shot approach**: a technician snaps a single overhead photograph, and a computer vision model attempts to classify every item. However, in physical environments, tools are frequently partially occluded by a glove, coiled test lead, or protective wrapping. Conventional models either hallucinate presence or trigger false missing-item alarms—halting operations and costing enterprises millions in unnecessary restocking cycles and downtime.

We realized that **computer vision shouldn't be a passive one-shot exam; it should be an active conversation between an autonomous agent and the physical world**. If the AI is uncertain about what it sees, it shouldn't guess—it should guide the operator to capture the missing visual evidence.

---

## What It Does

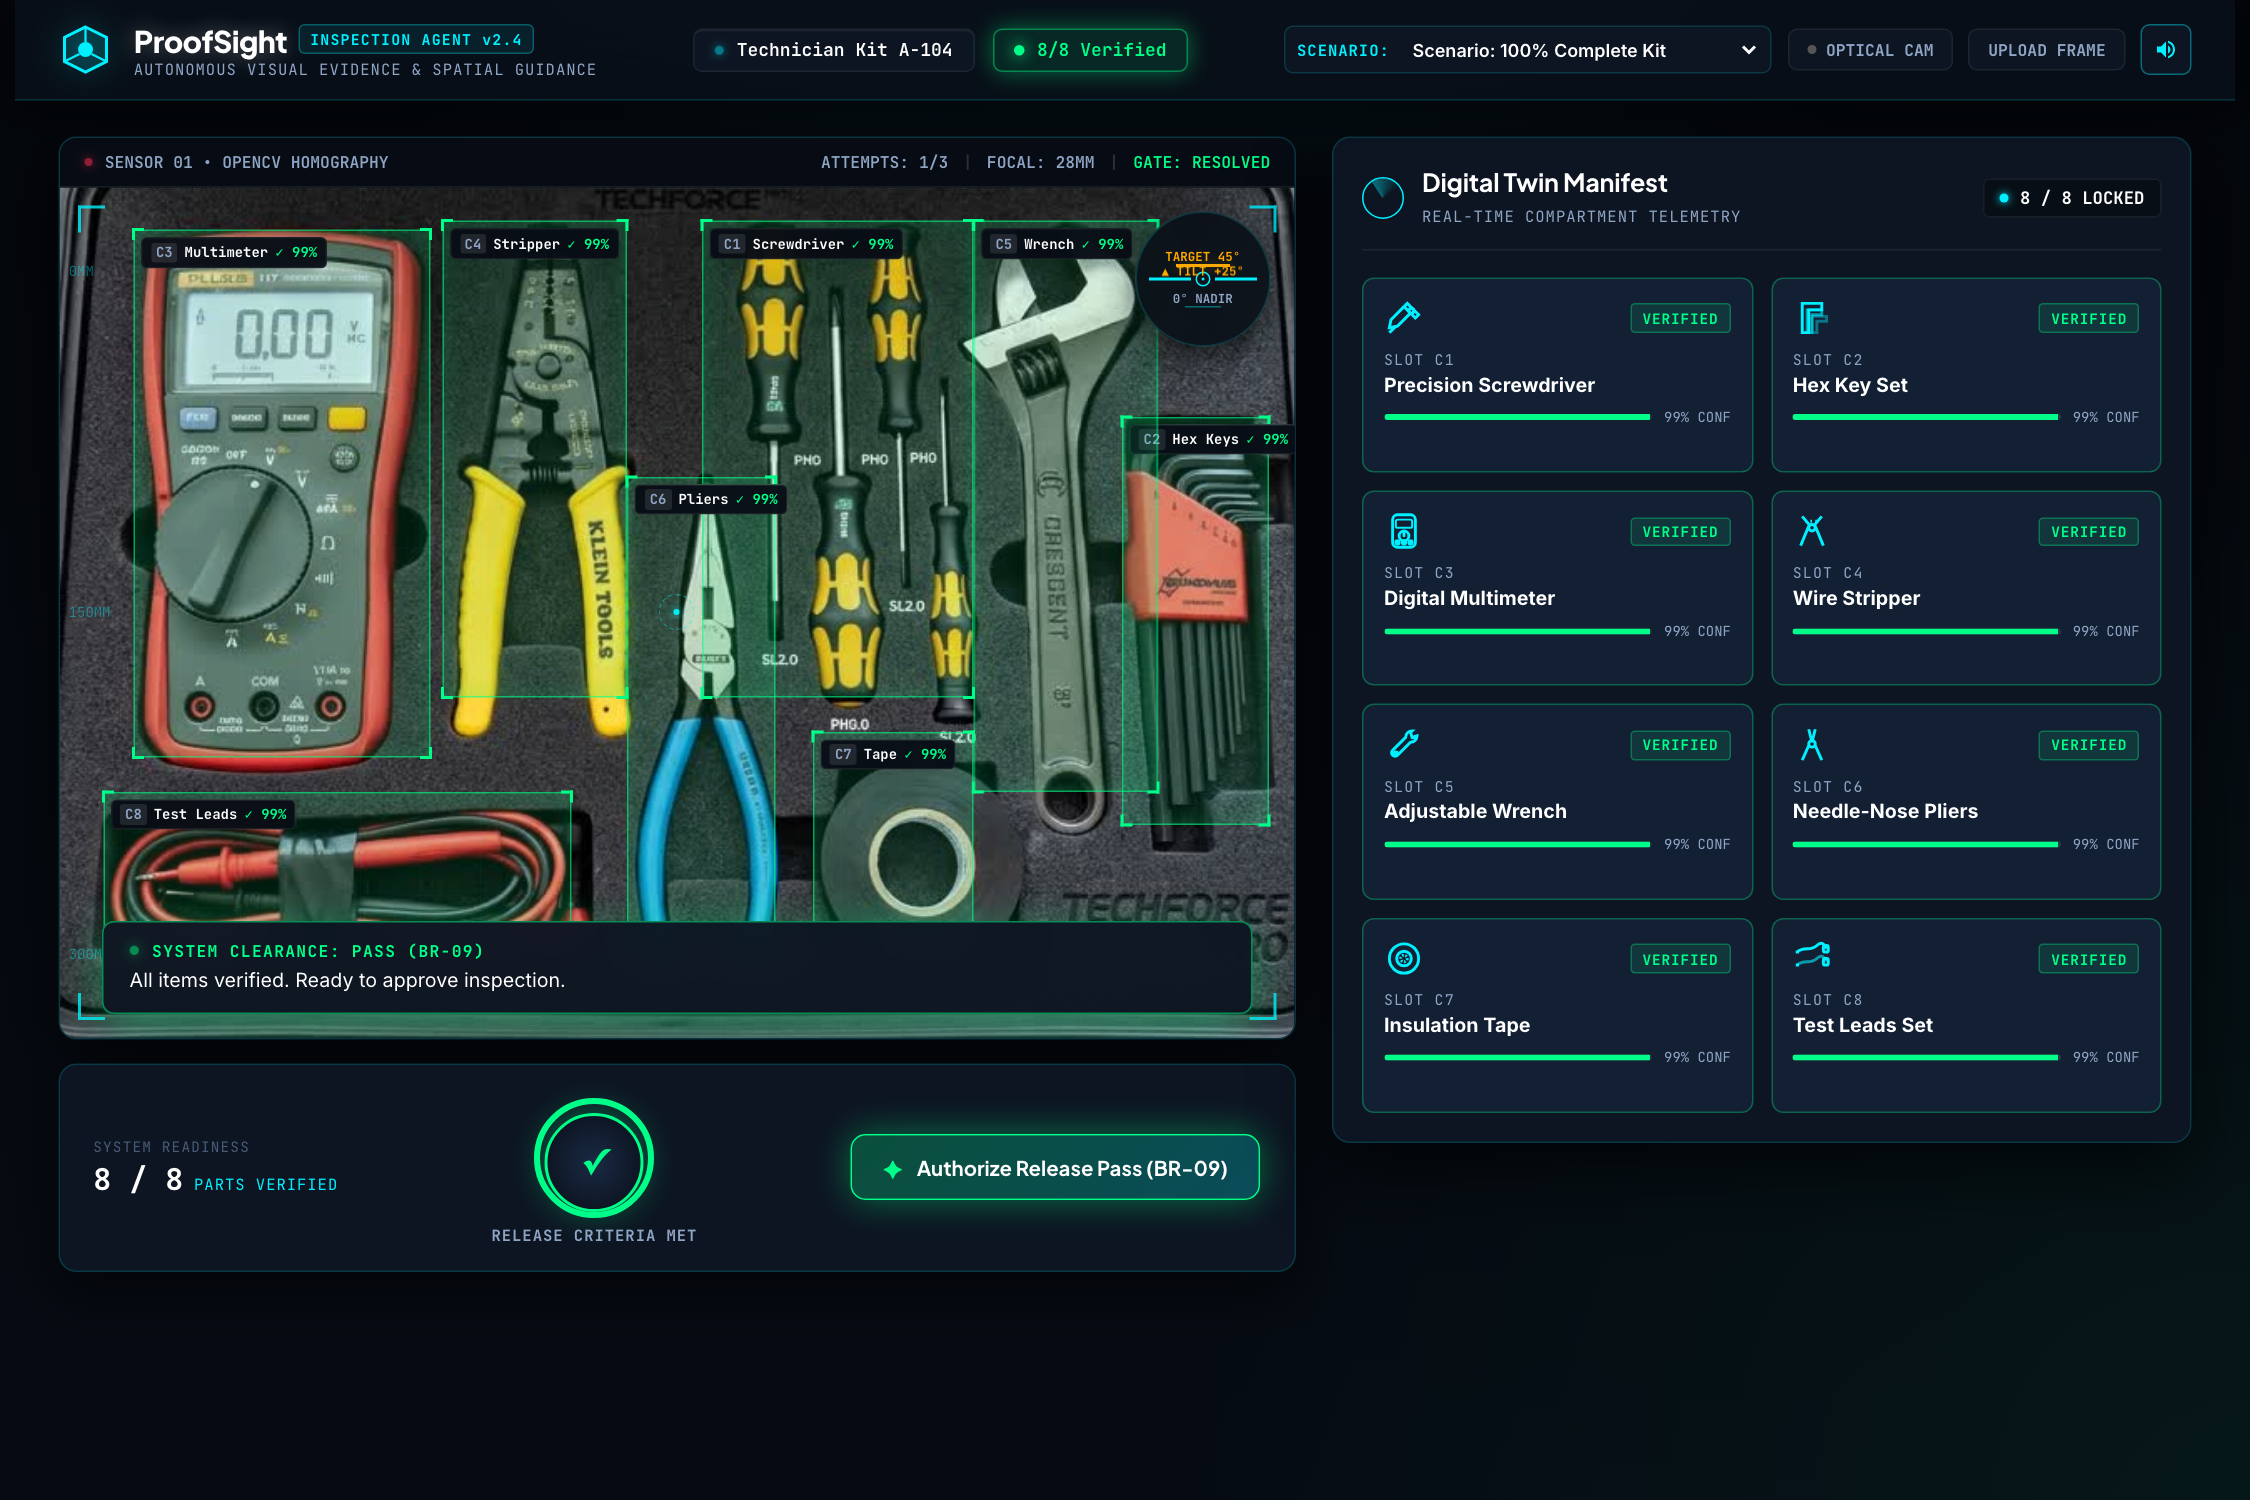
**ProofSight** is an **Autonomous Visual Evidence Agent** that turns any smartphone into an intelligent inspection station for equipment kits and reusable tool sets:

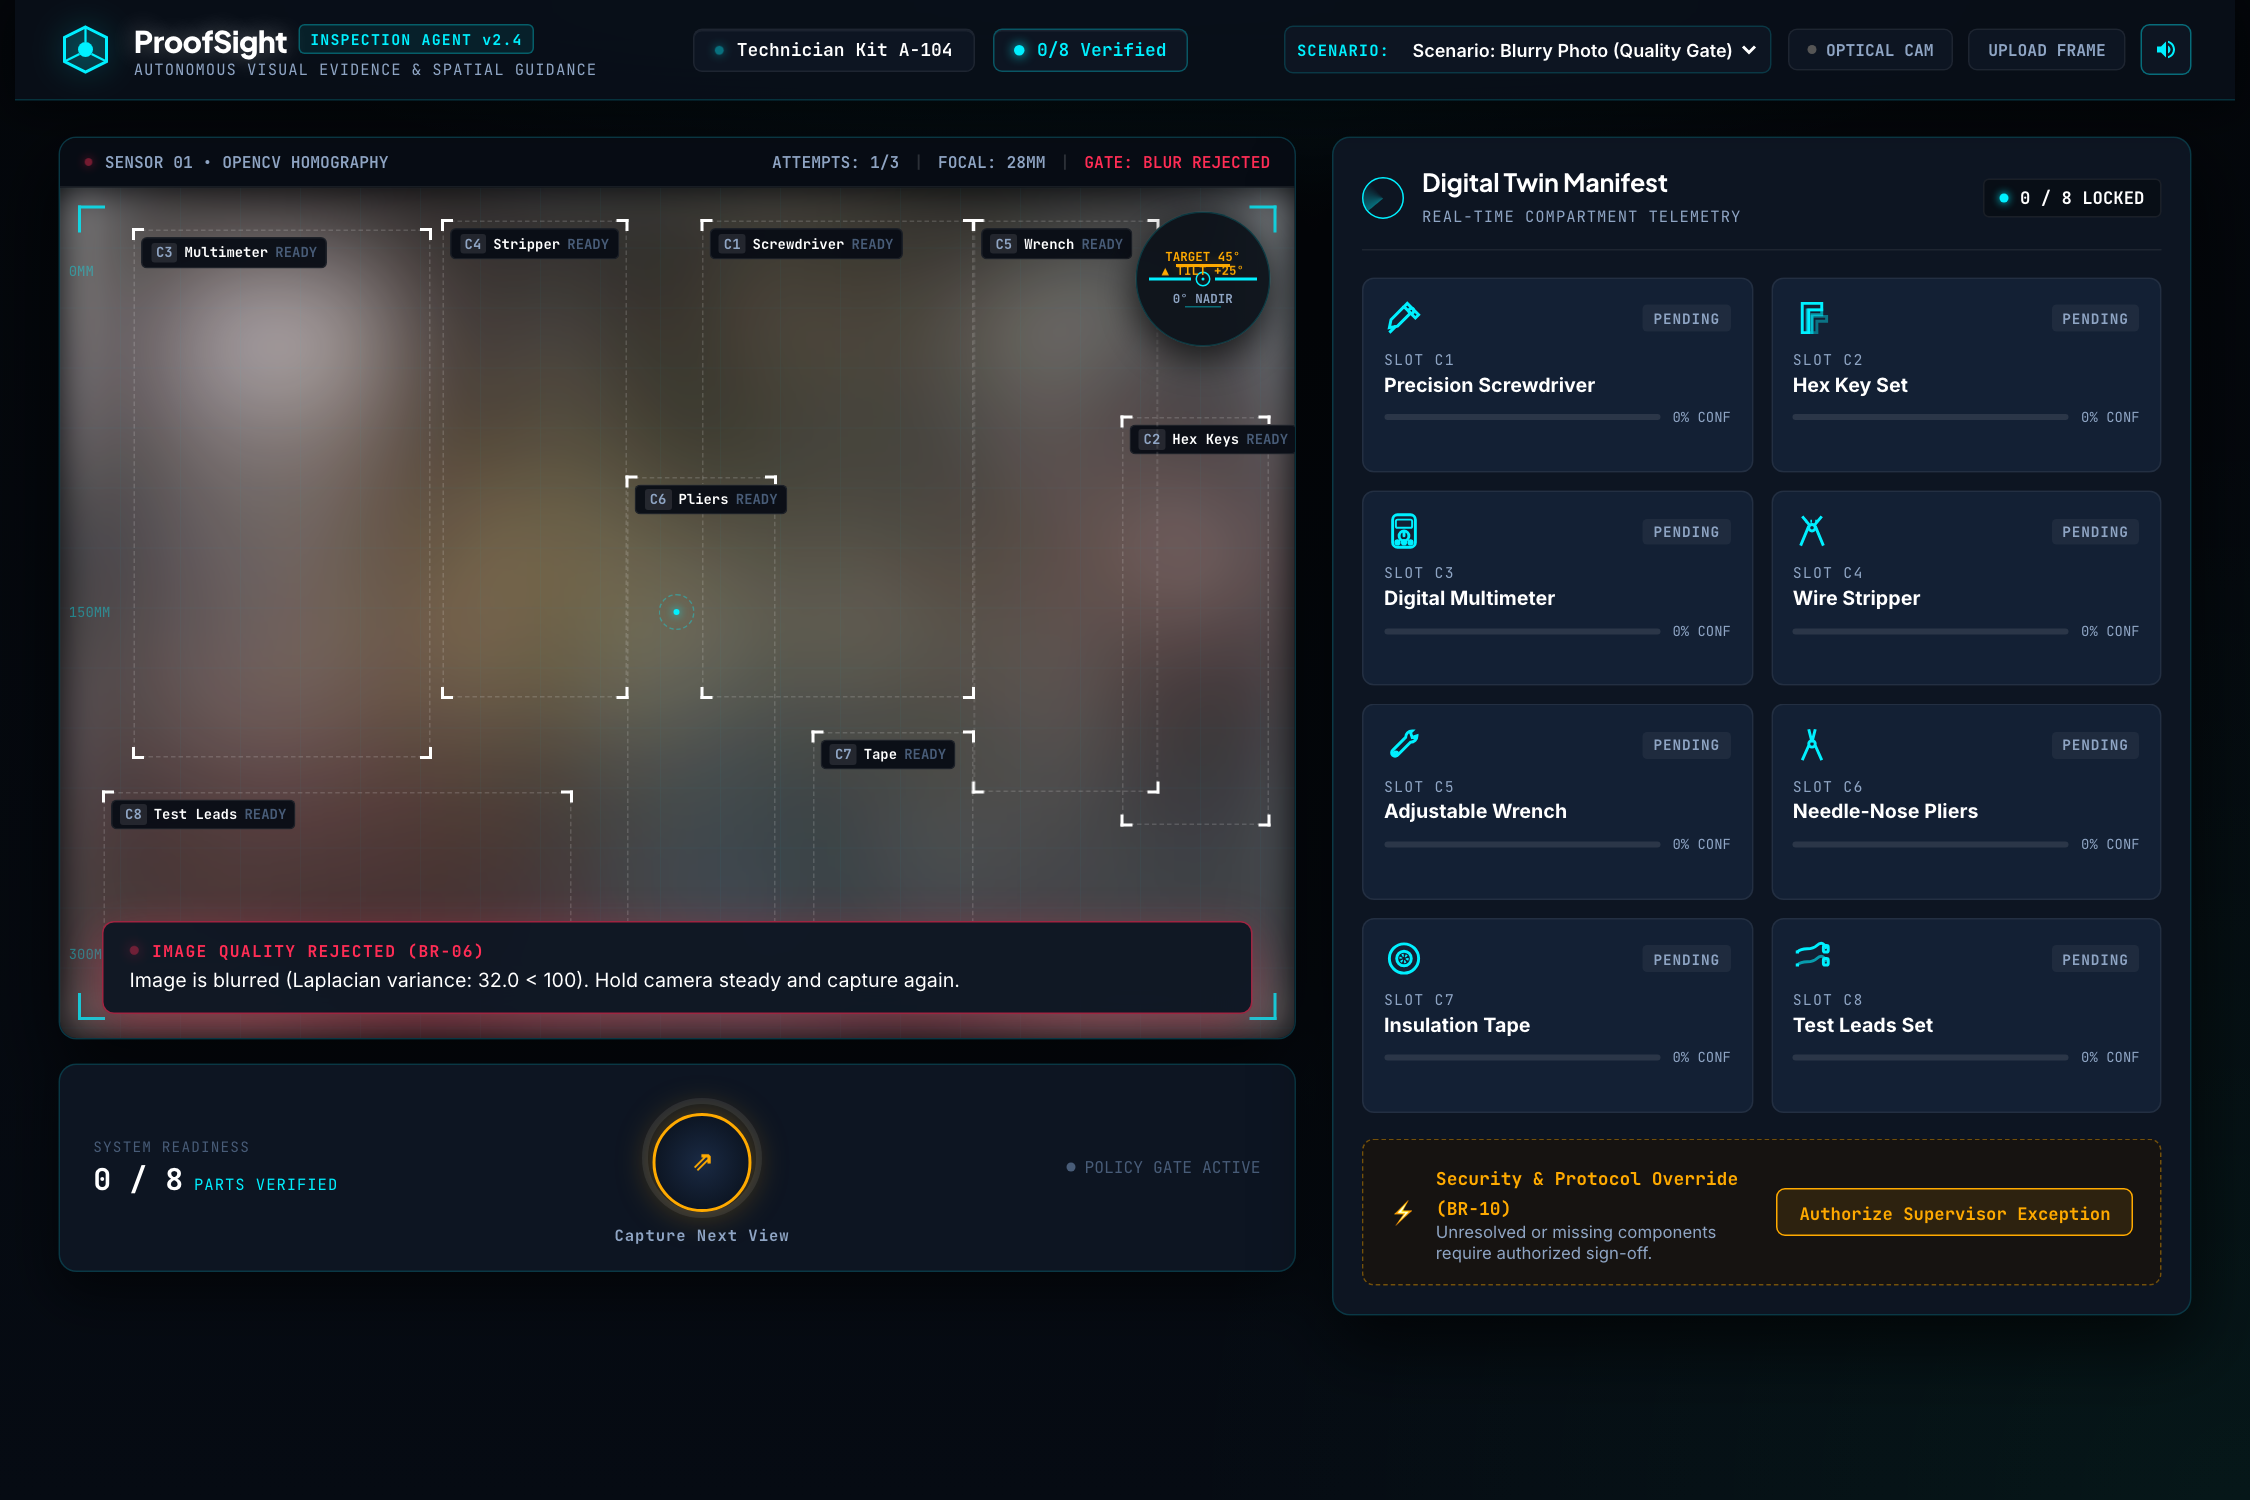
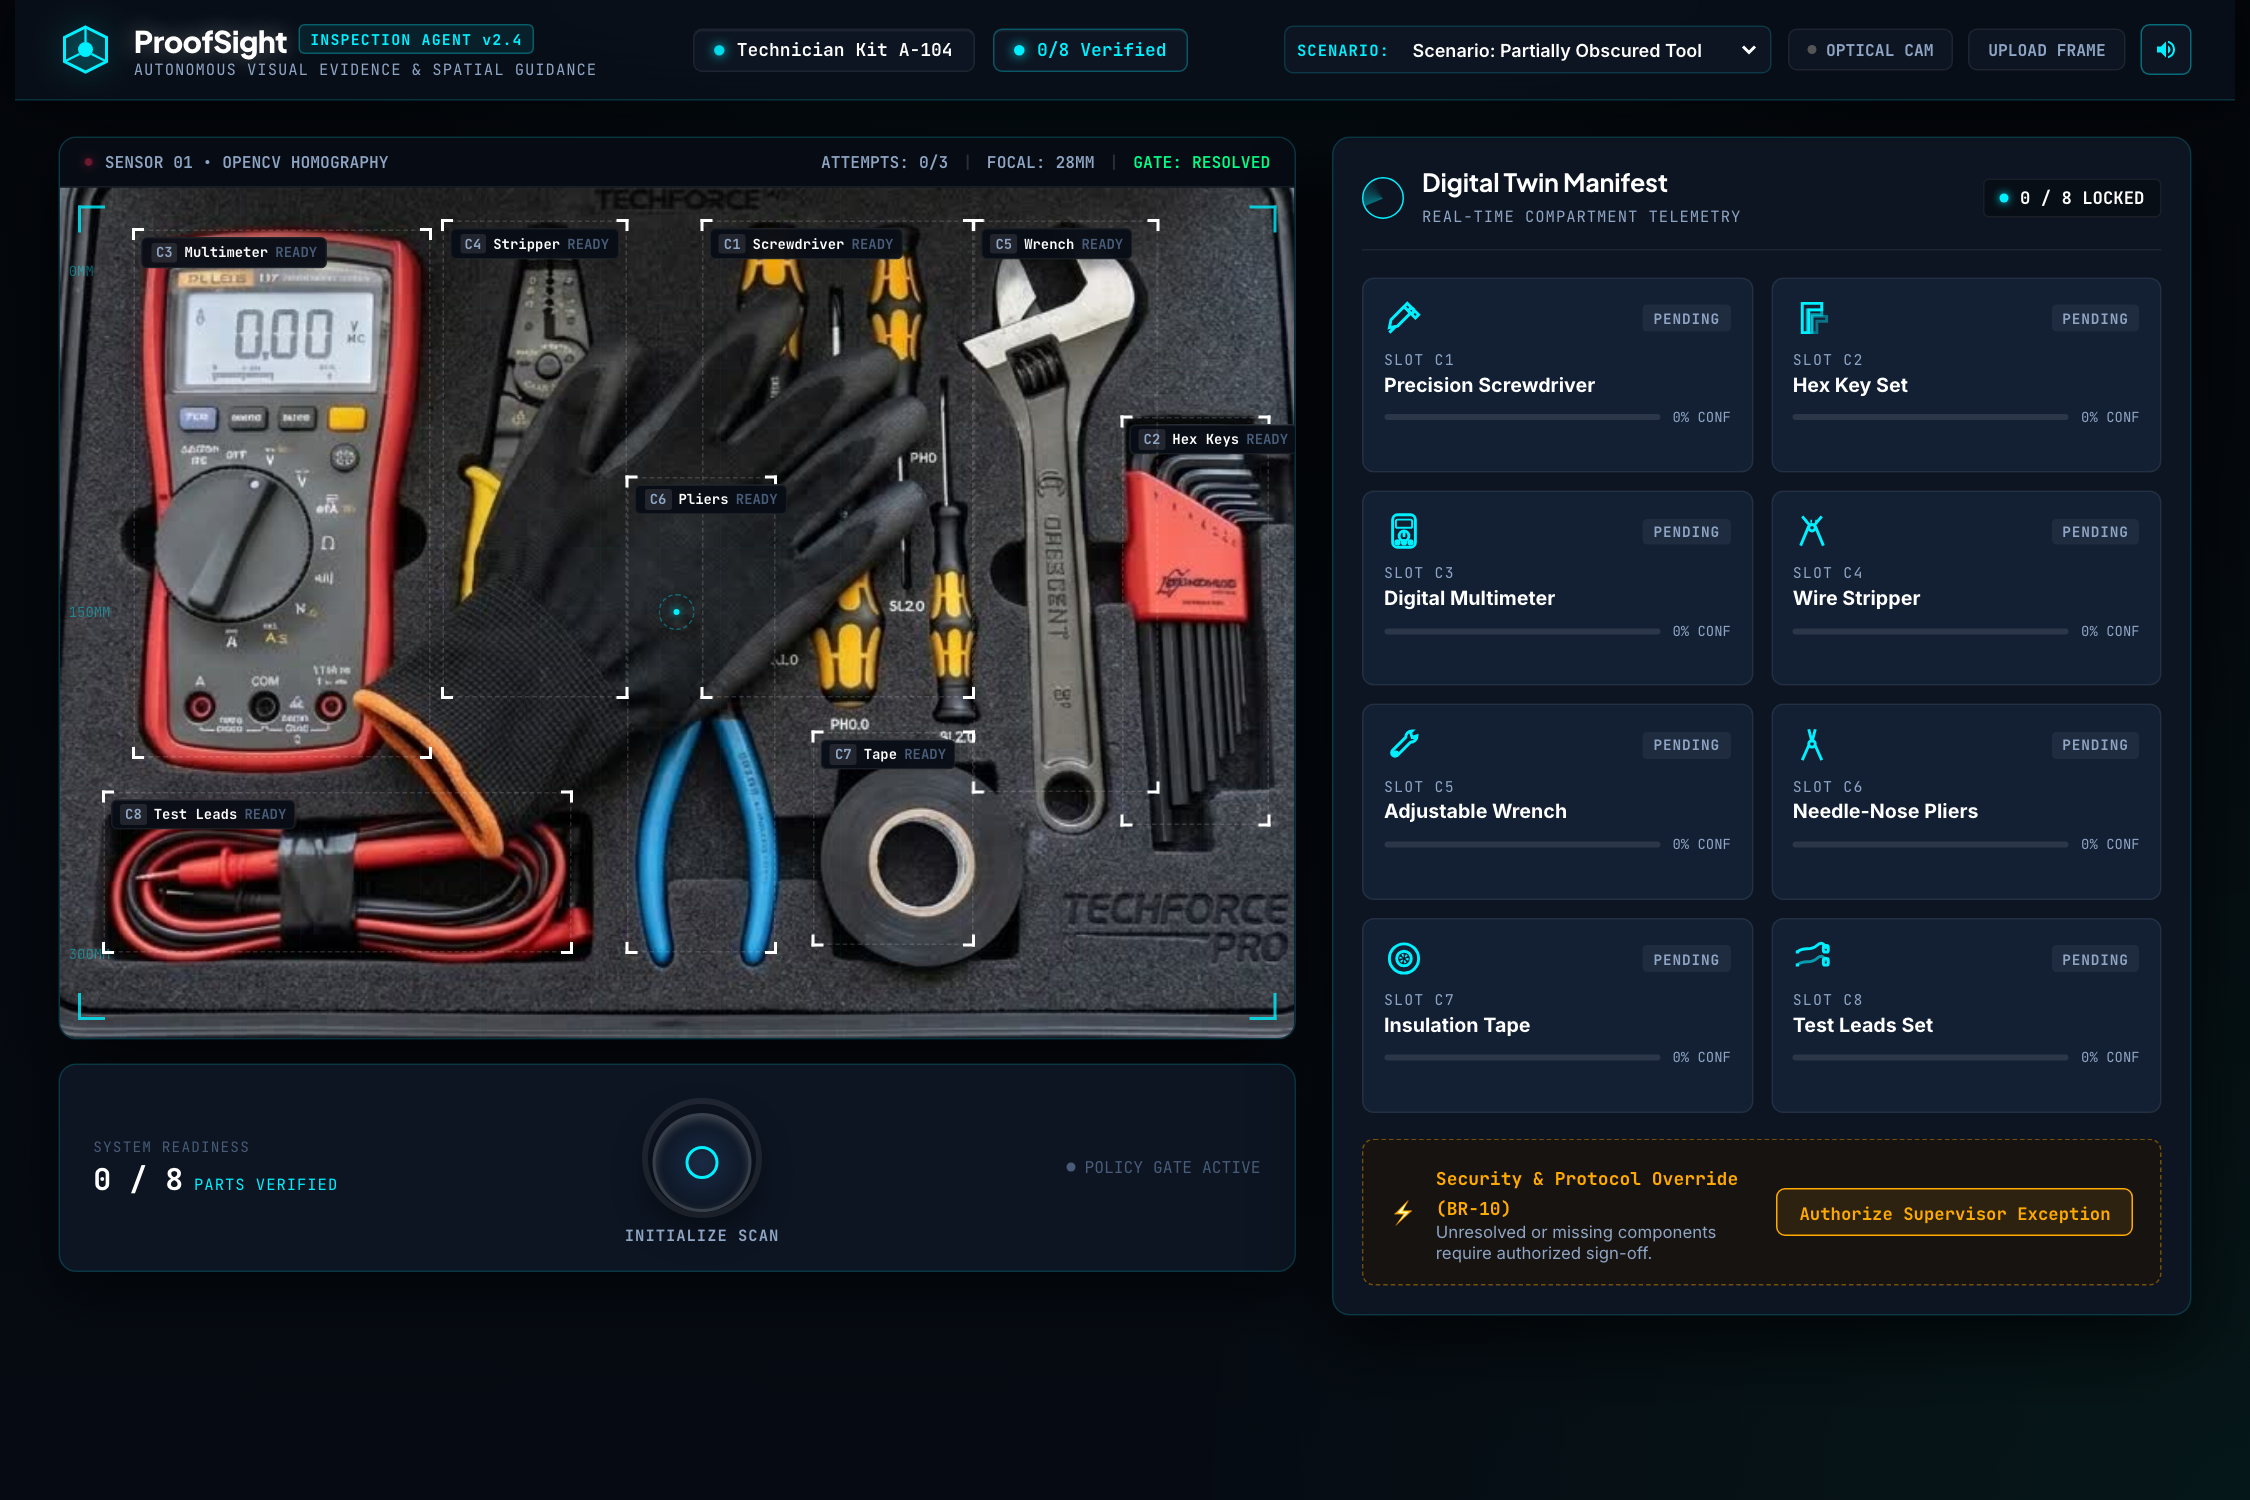
1. **Substantive OpenCV 5 Ingest Gate**: Intercepts unusable imagery before analysis. It computes the Laplacian blur variance:
   $$\sigma^2_{Lap} = \text{Var}(\nabla^2 I)$$
   If $\sigma^2_{Lap} < 100$, the image is rejected ($\text{GATE: BLUR REJECTED}$), preventing spurious classifications. It also evaluates exposure histograms to detect severe under- or overexposure.
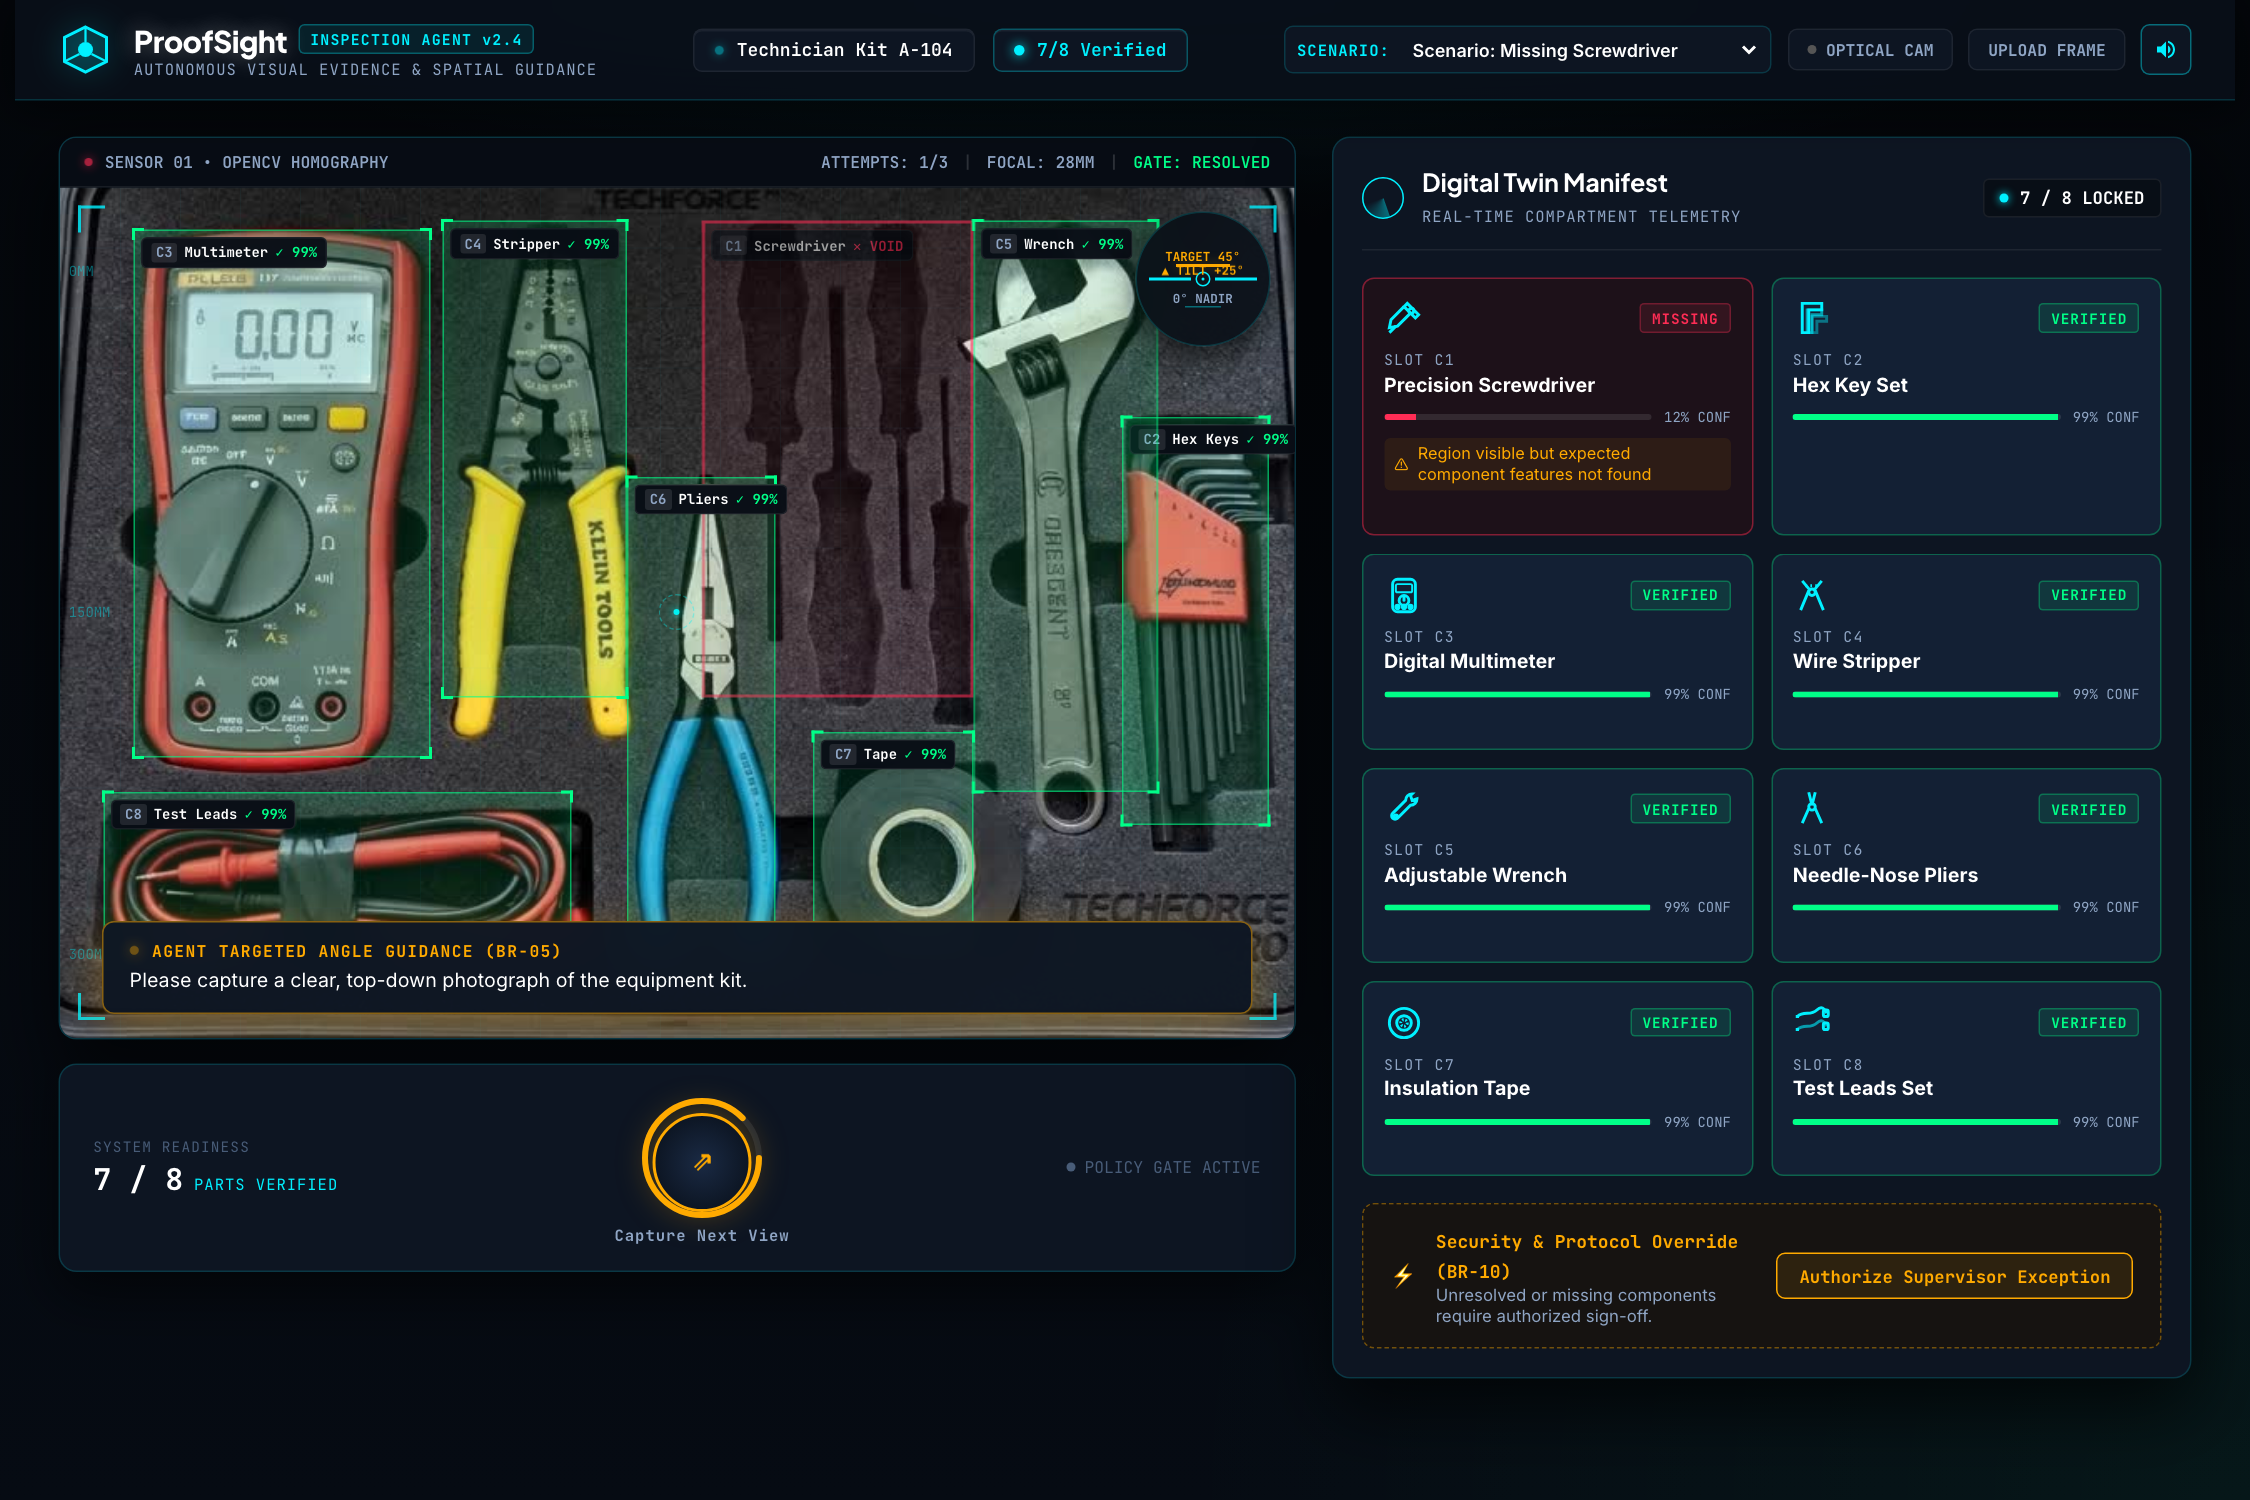
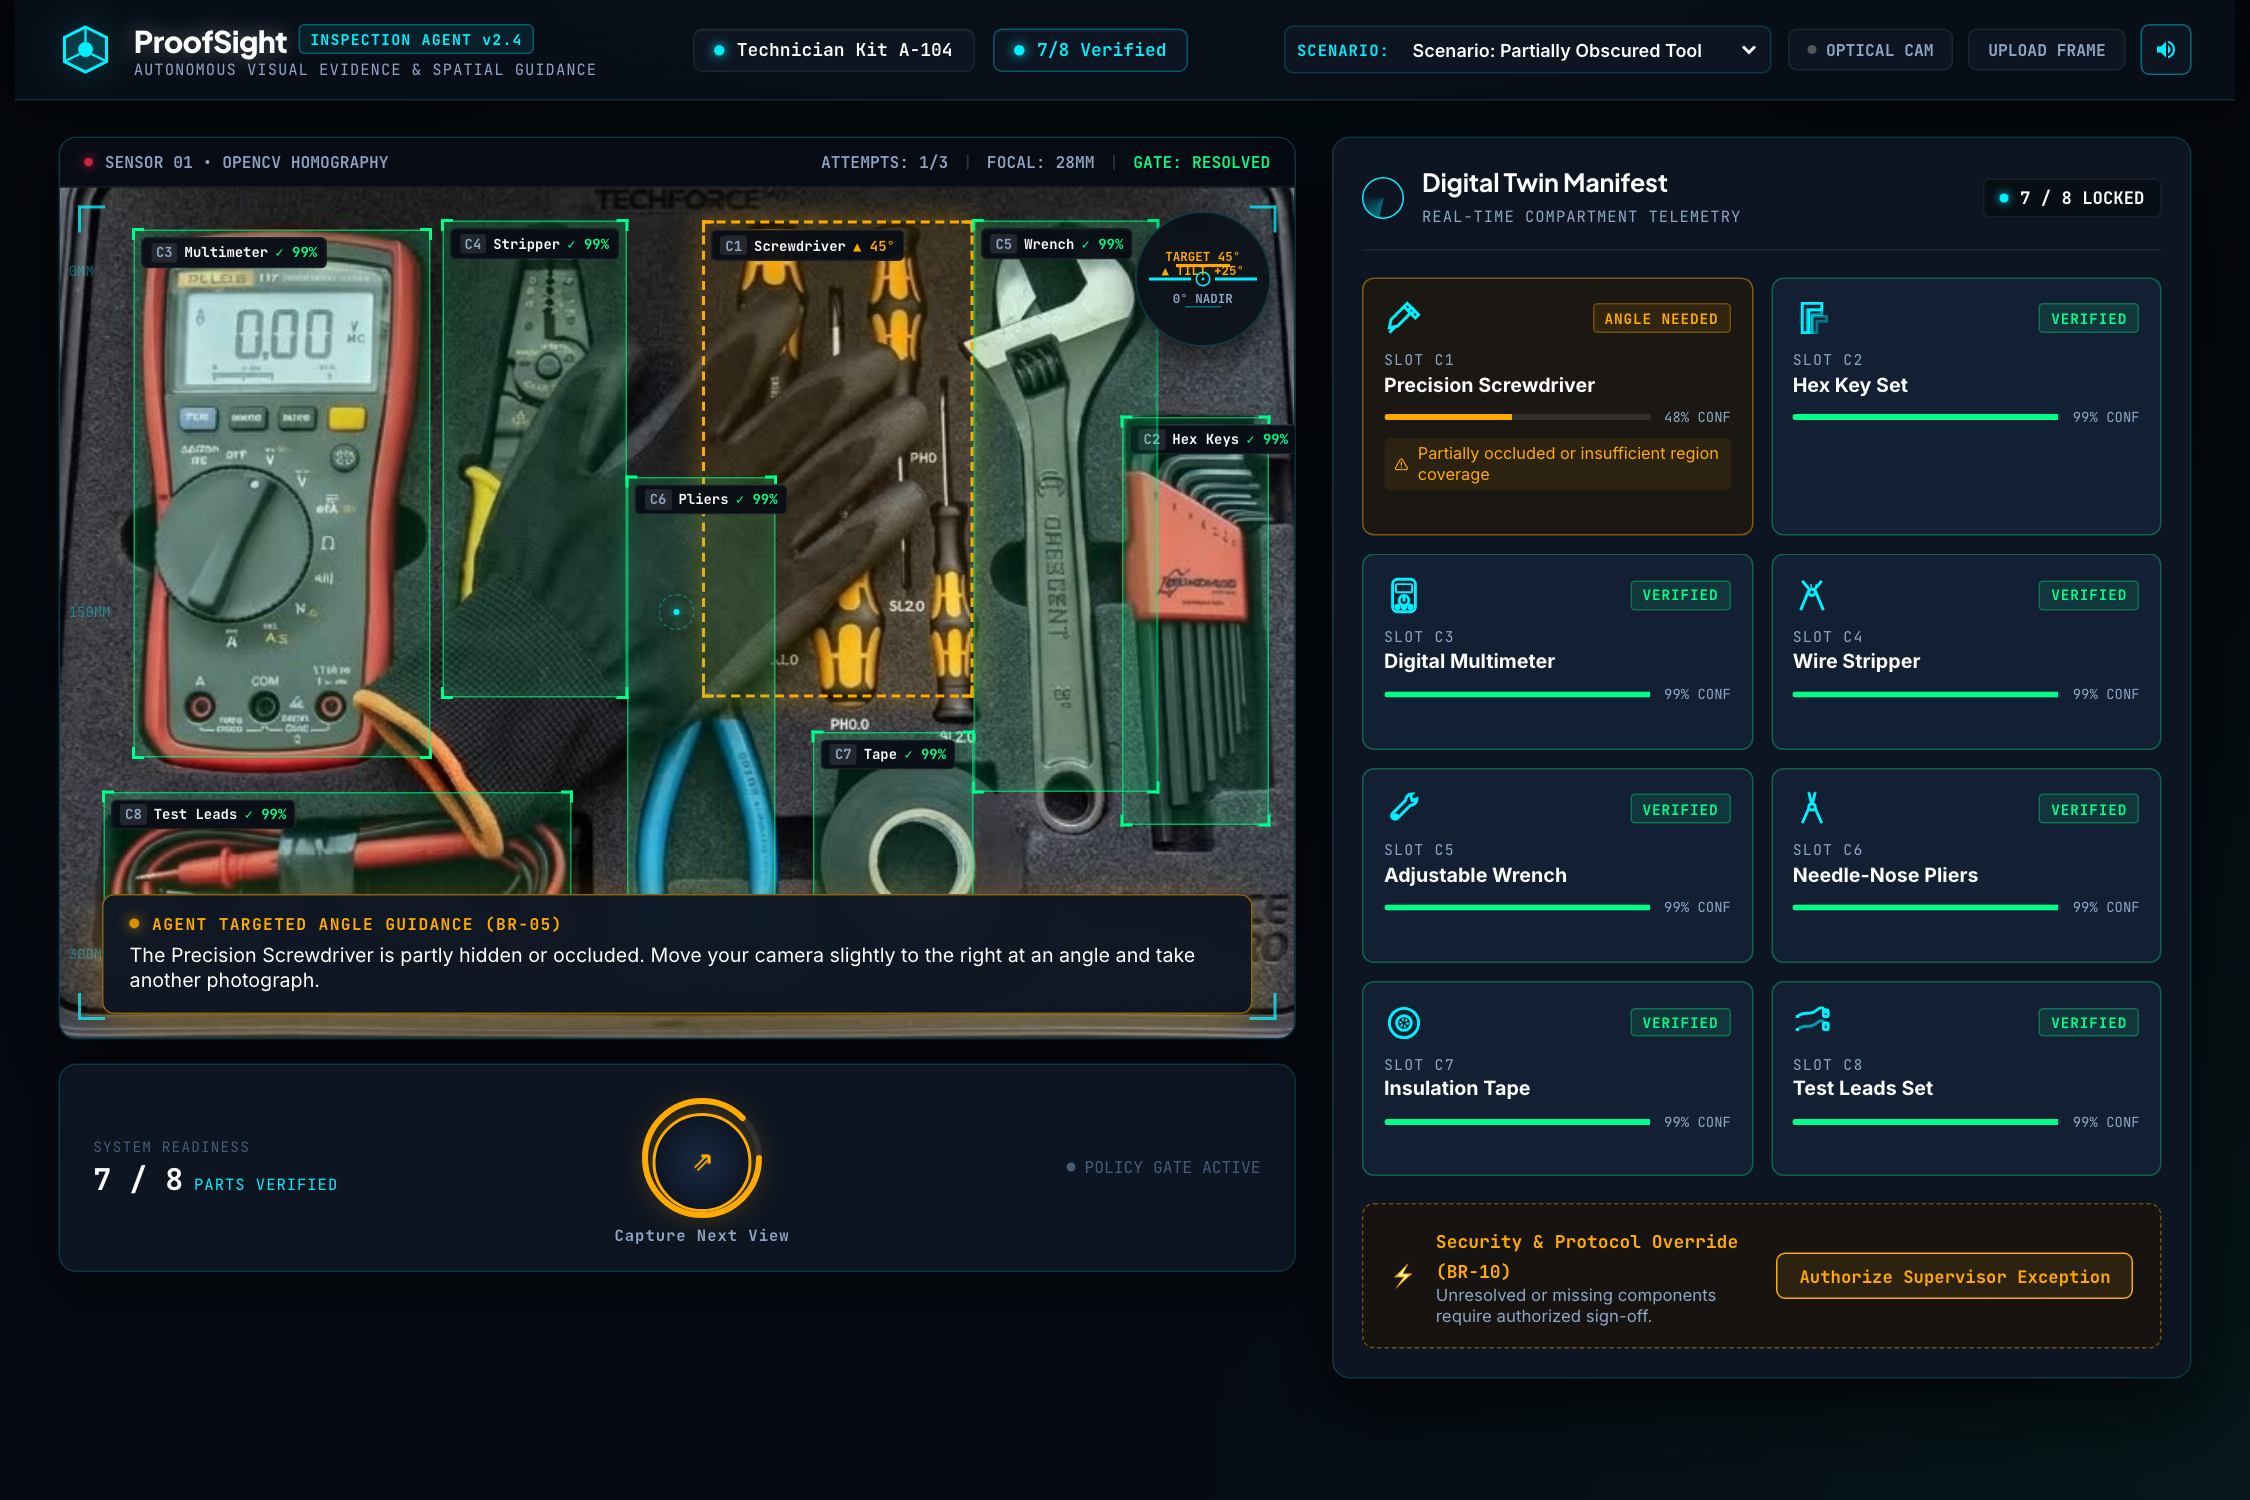
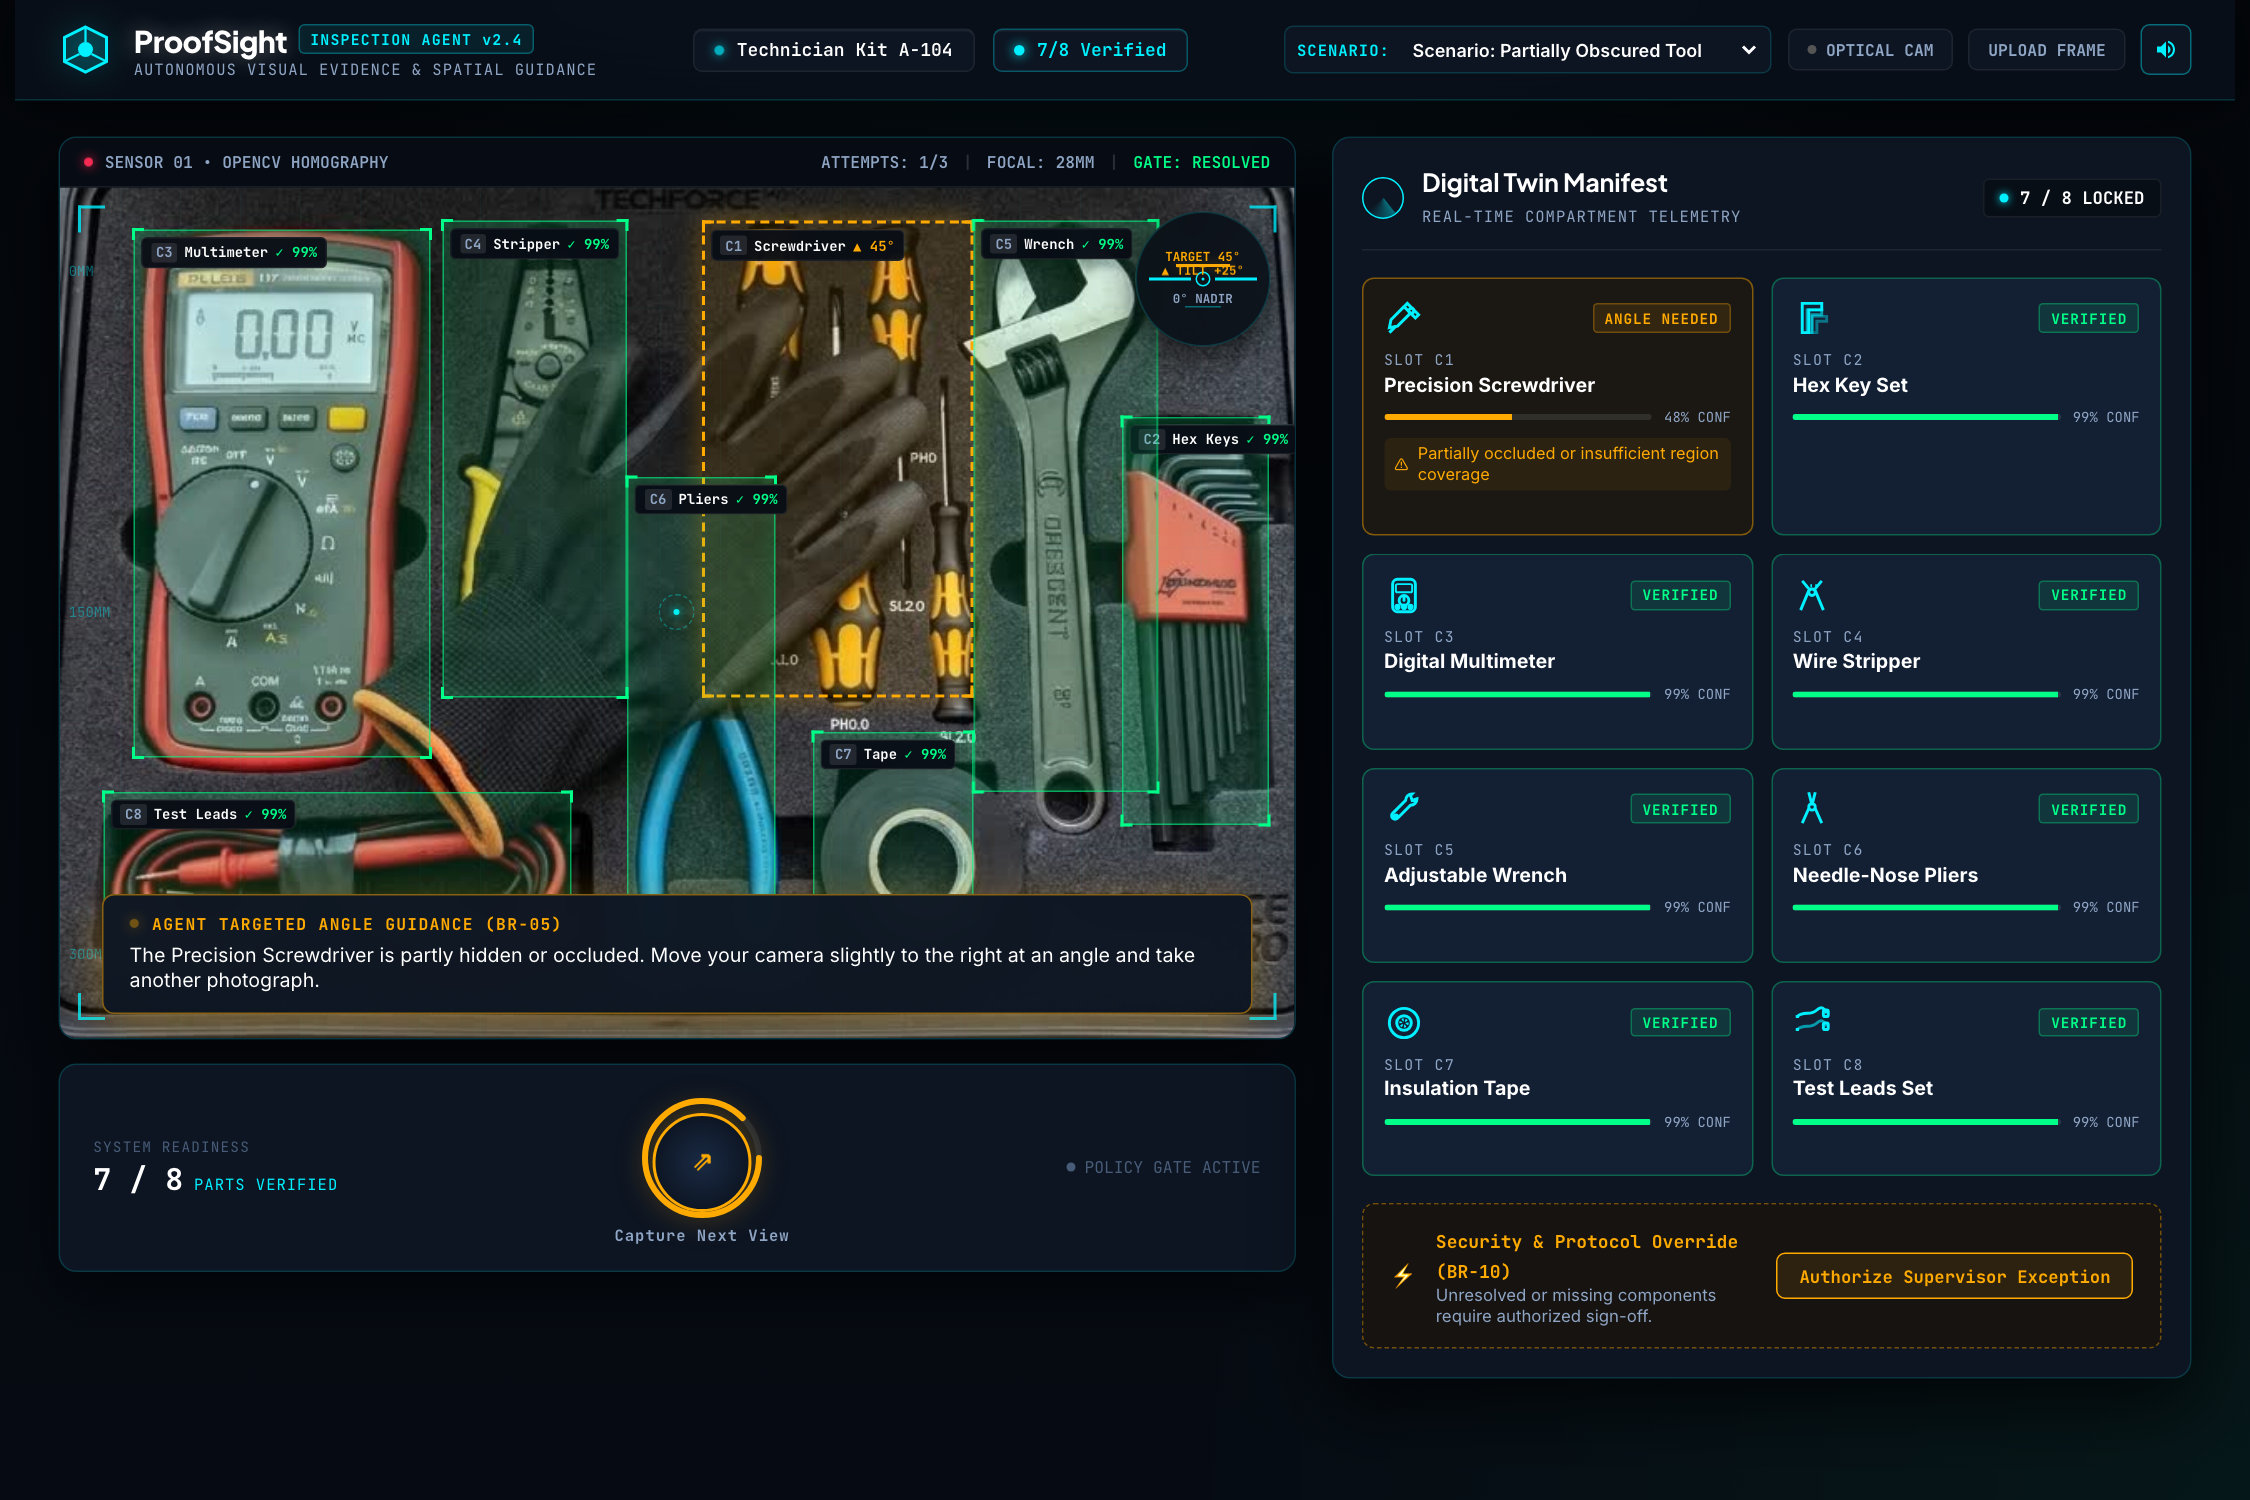
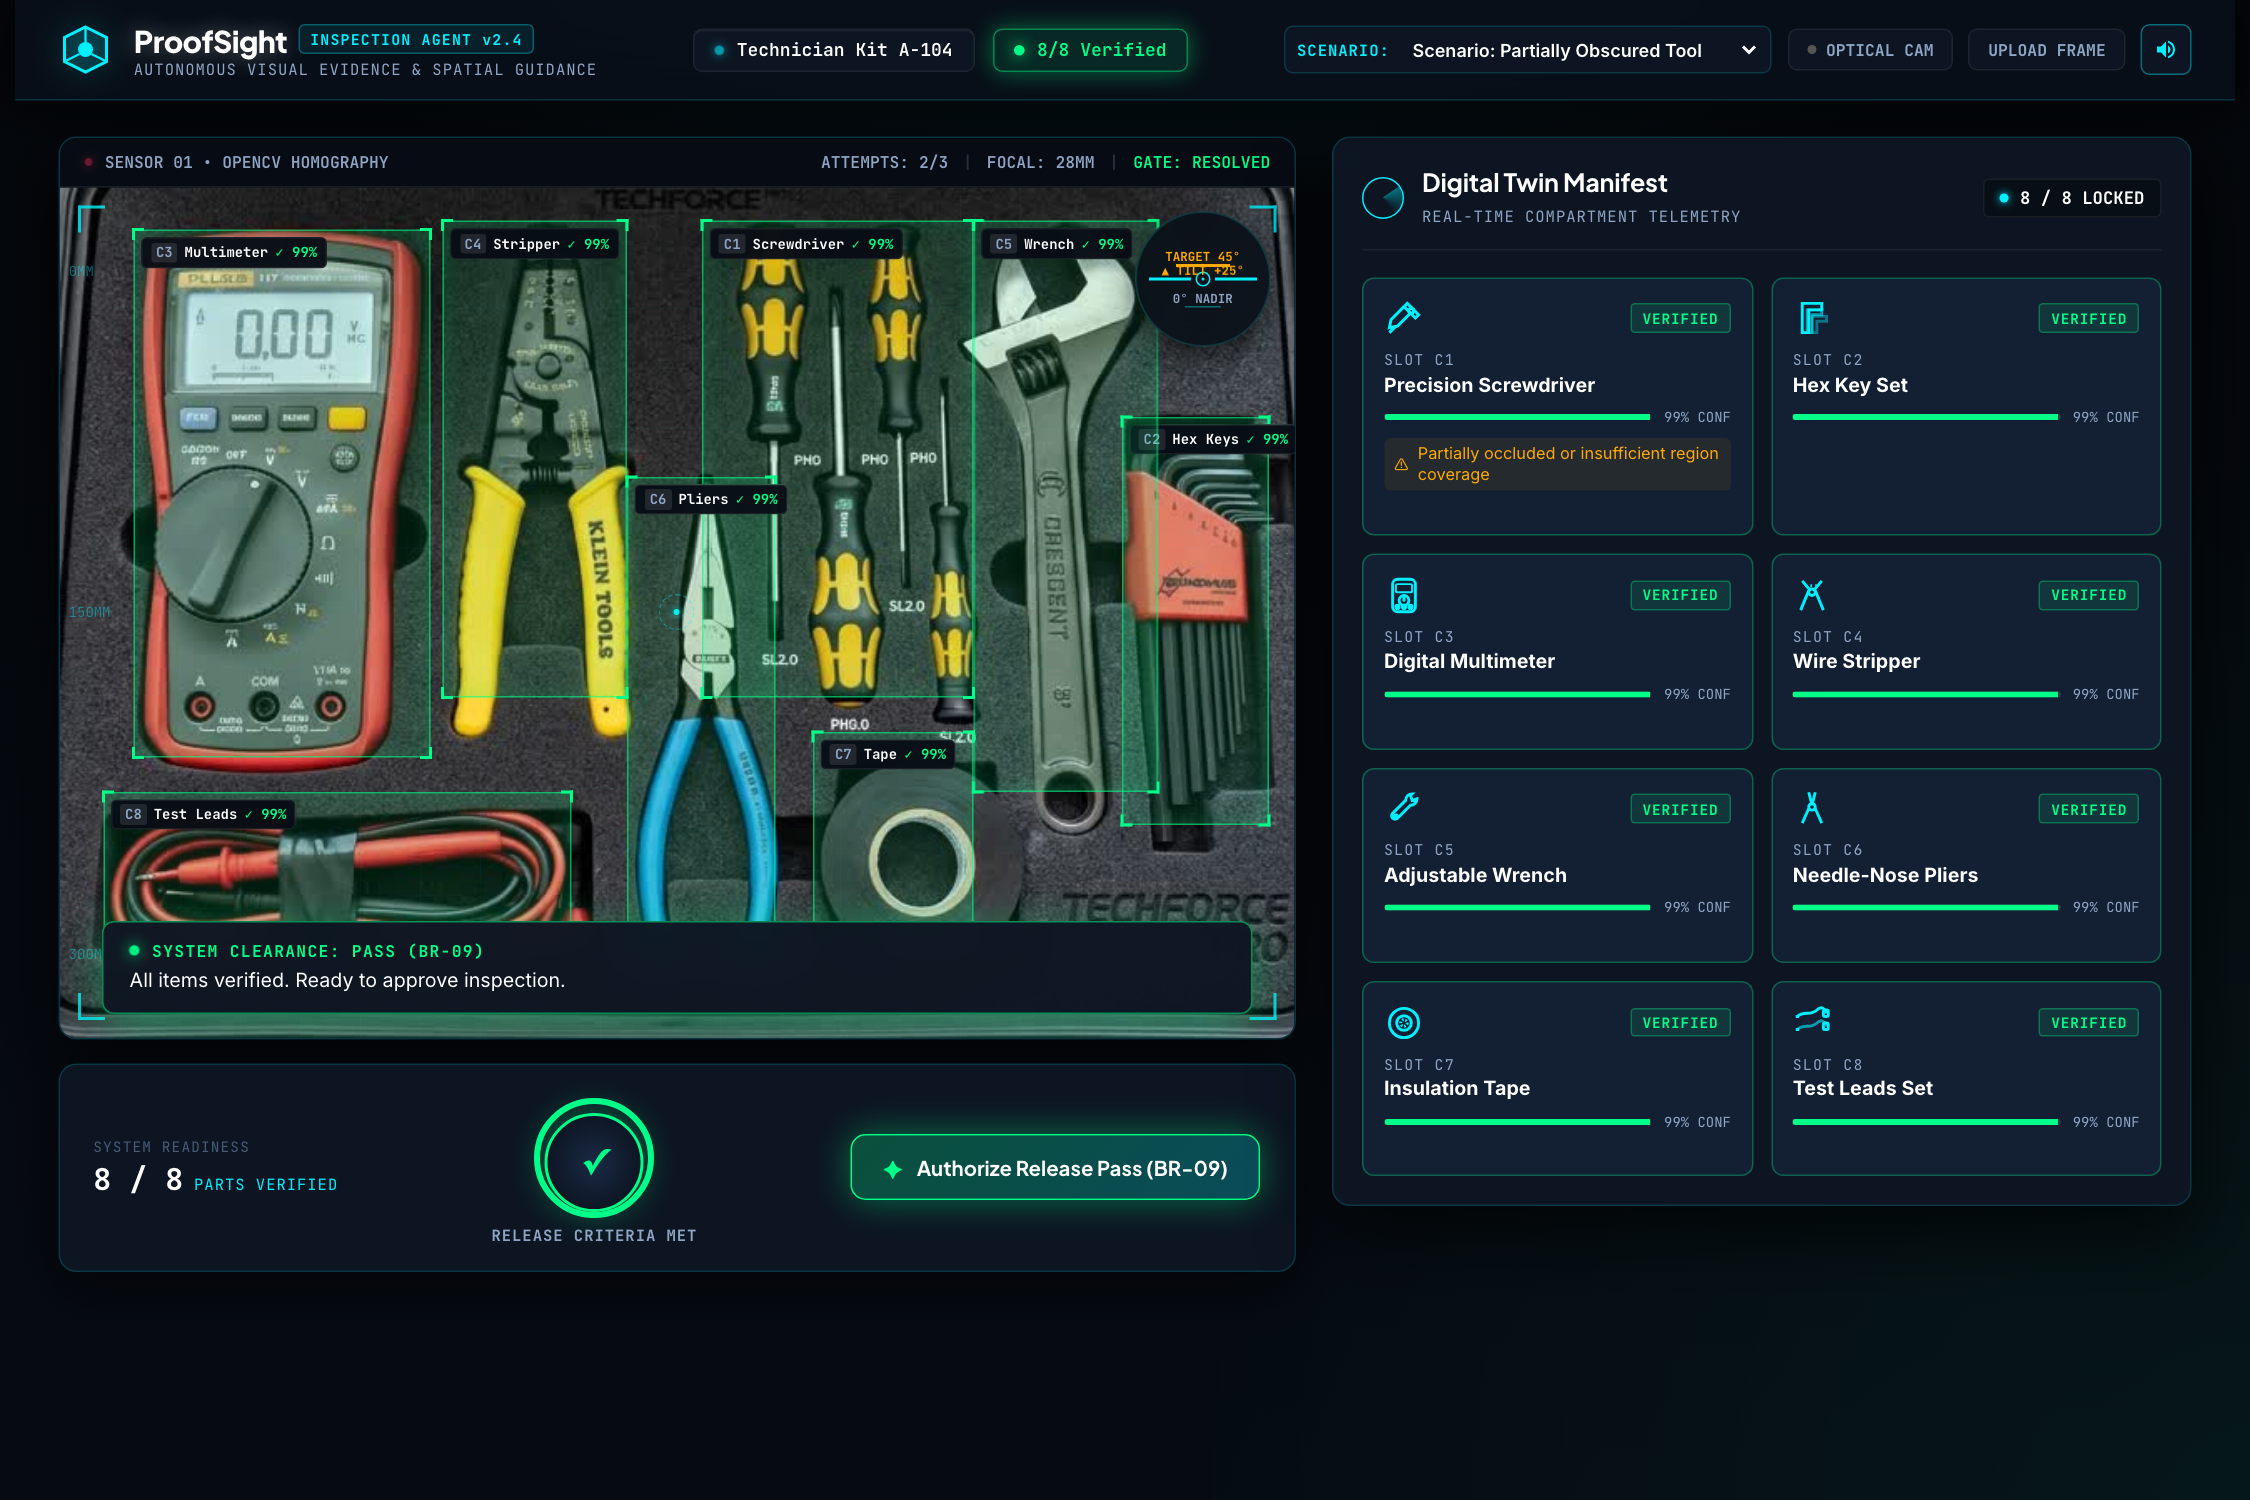
2. **Separates "Unknown" from "Missing" (BR-03)**: When a tool is partially occluded, ProofSight marks the component as `UNRESOLVED` rather than triggering a false "missing item" rejection.
3. **Active 3D Inclinometer Guidance (BR-05)**: The agent calculates the expected uncertainty reduction:
   $$\mathbb{E}[\Delta U] > C_{\text{capture}}$$
   When positive, the HUD projects an interactive 3D Inclinometer and Artificial Horizon (`TARGET 45° // ▲ TILT +25°`), directing the technician to the exact glancing angle needed to view beneath the occlusion.
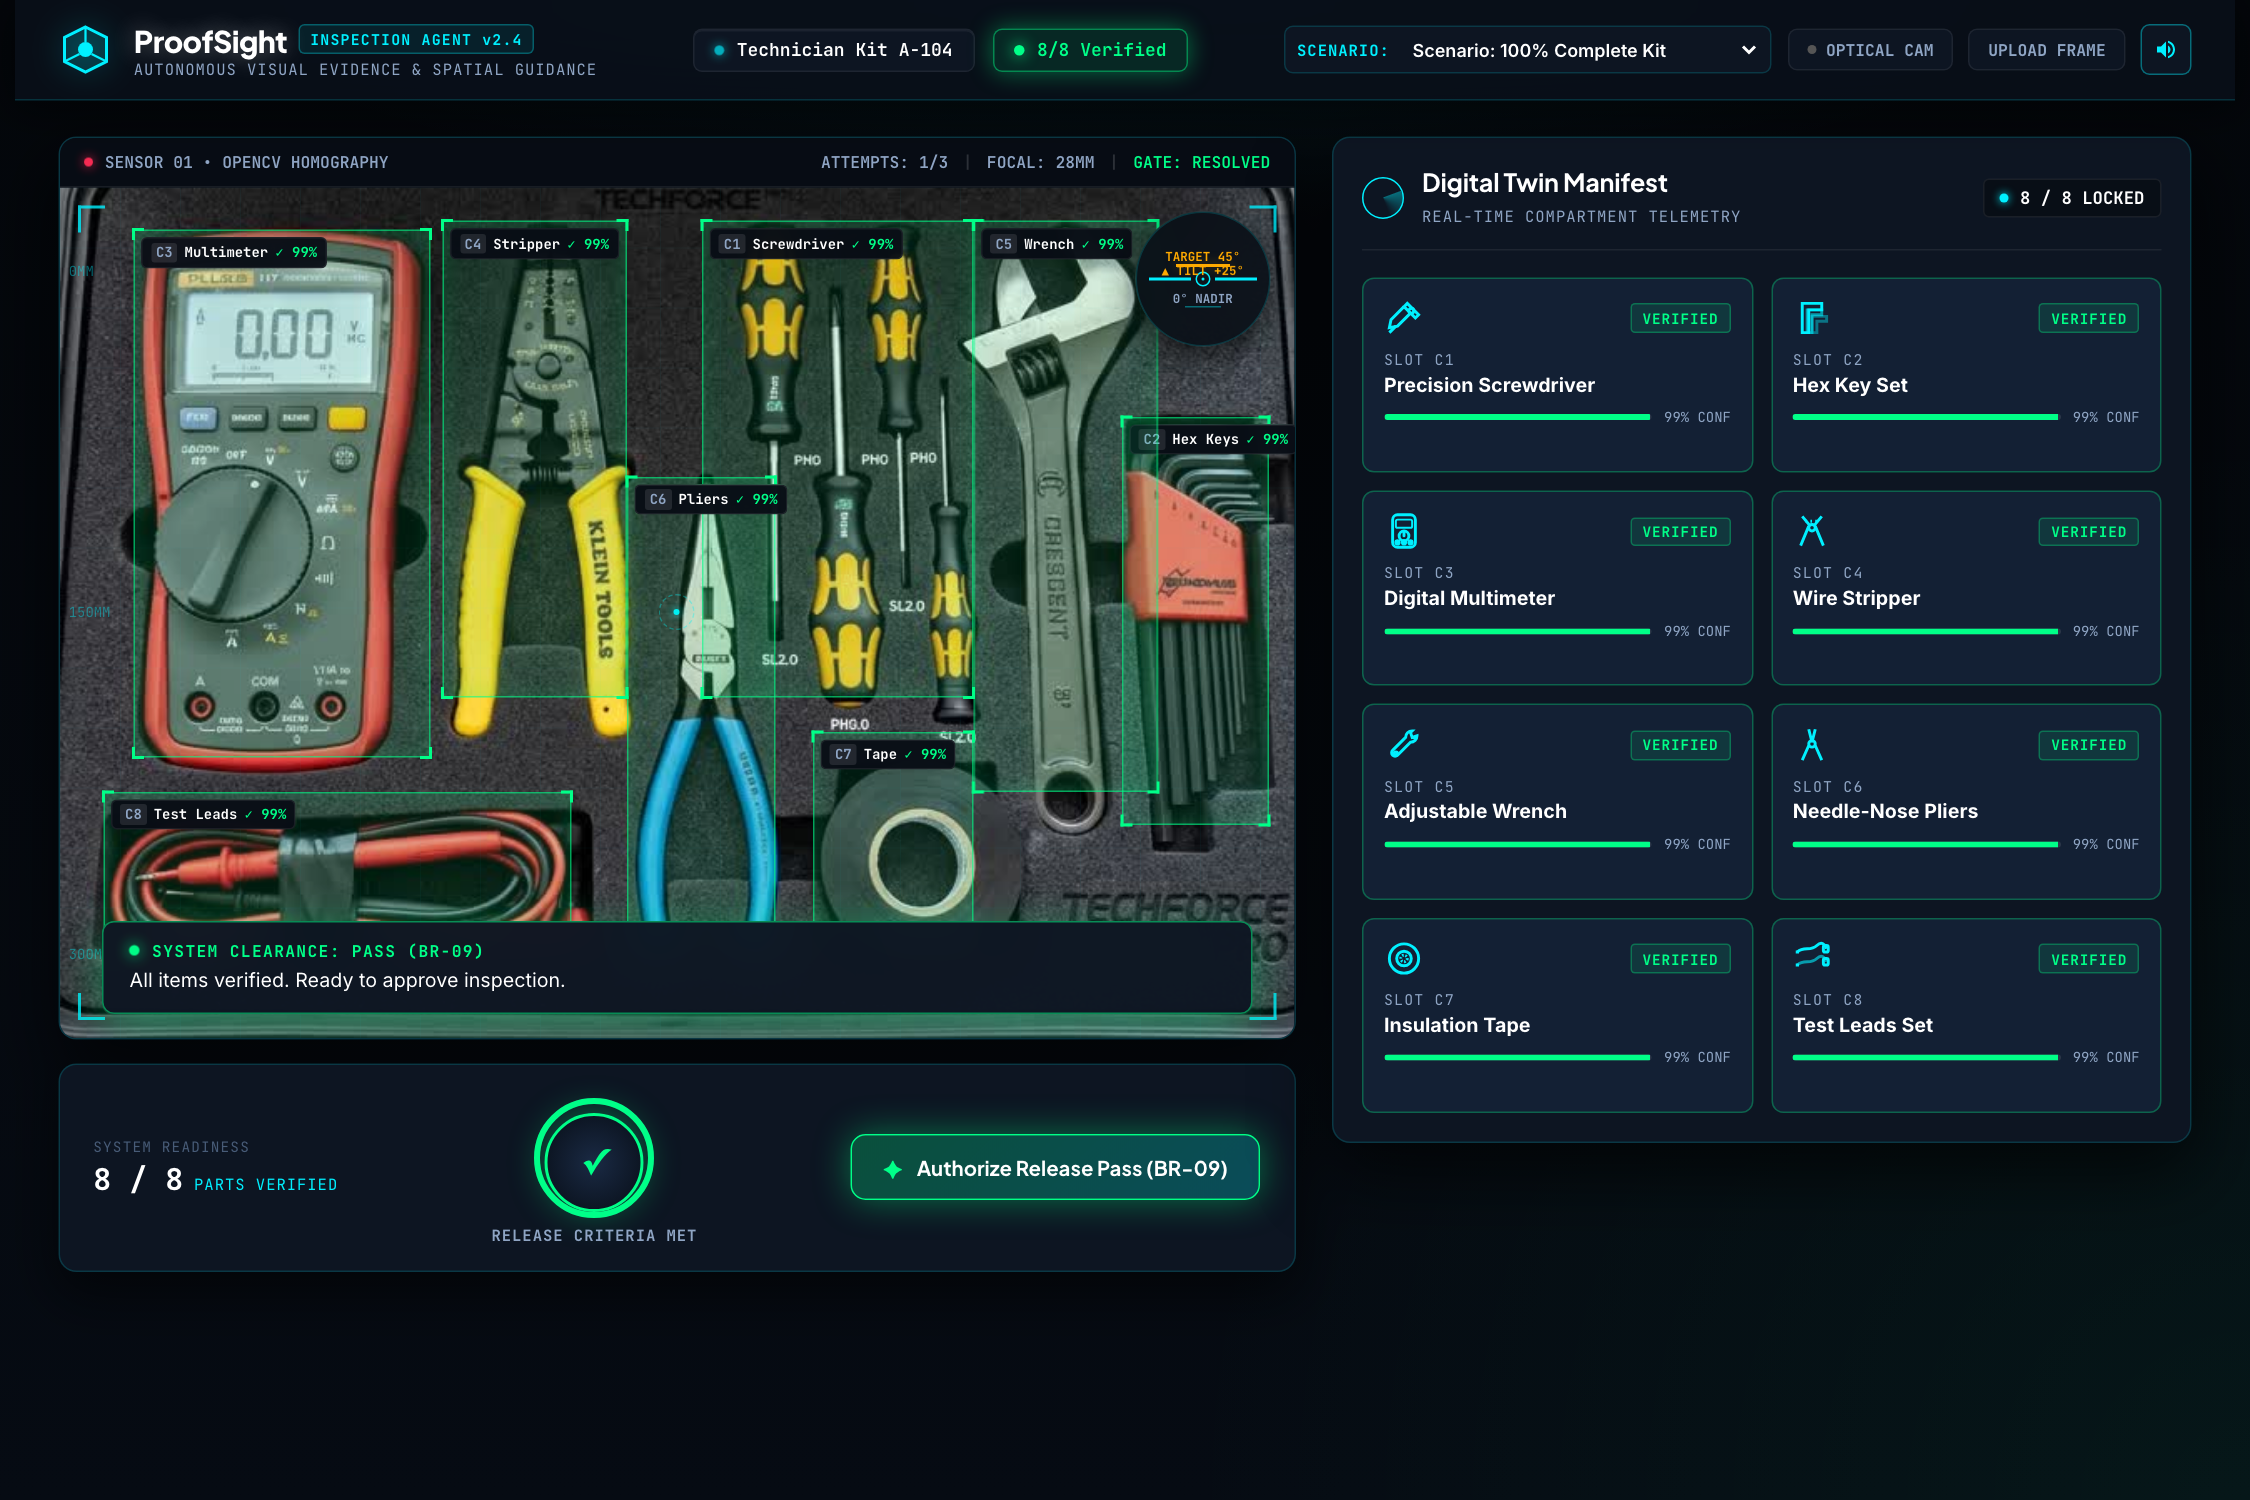
4. **Incremental Multi-Frame Evidence Accumulation (BR-13)**: Secondary captures verify the targeted component while mathematically preserving previously verified items without restarting the inspection.
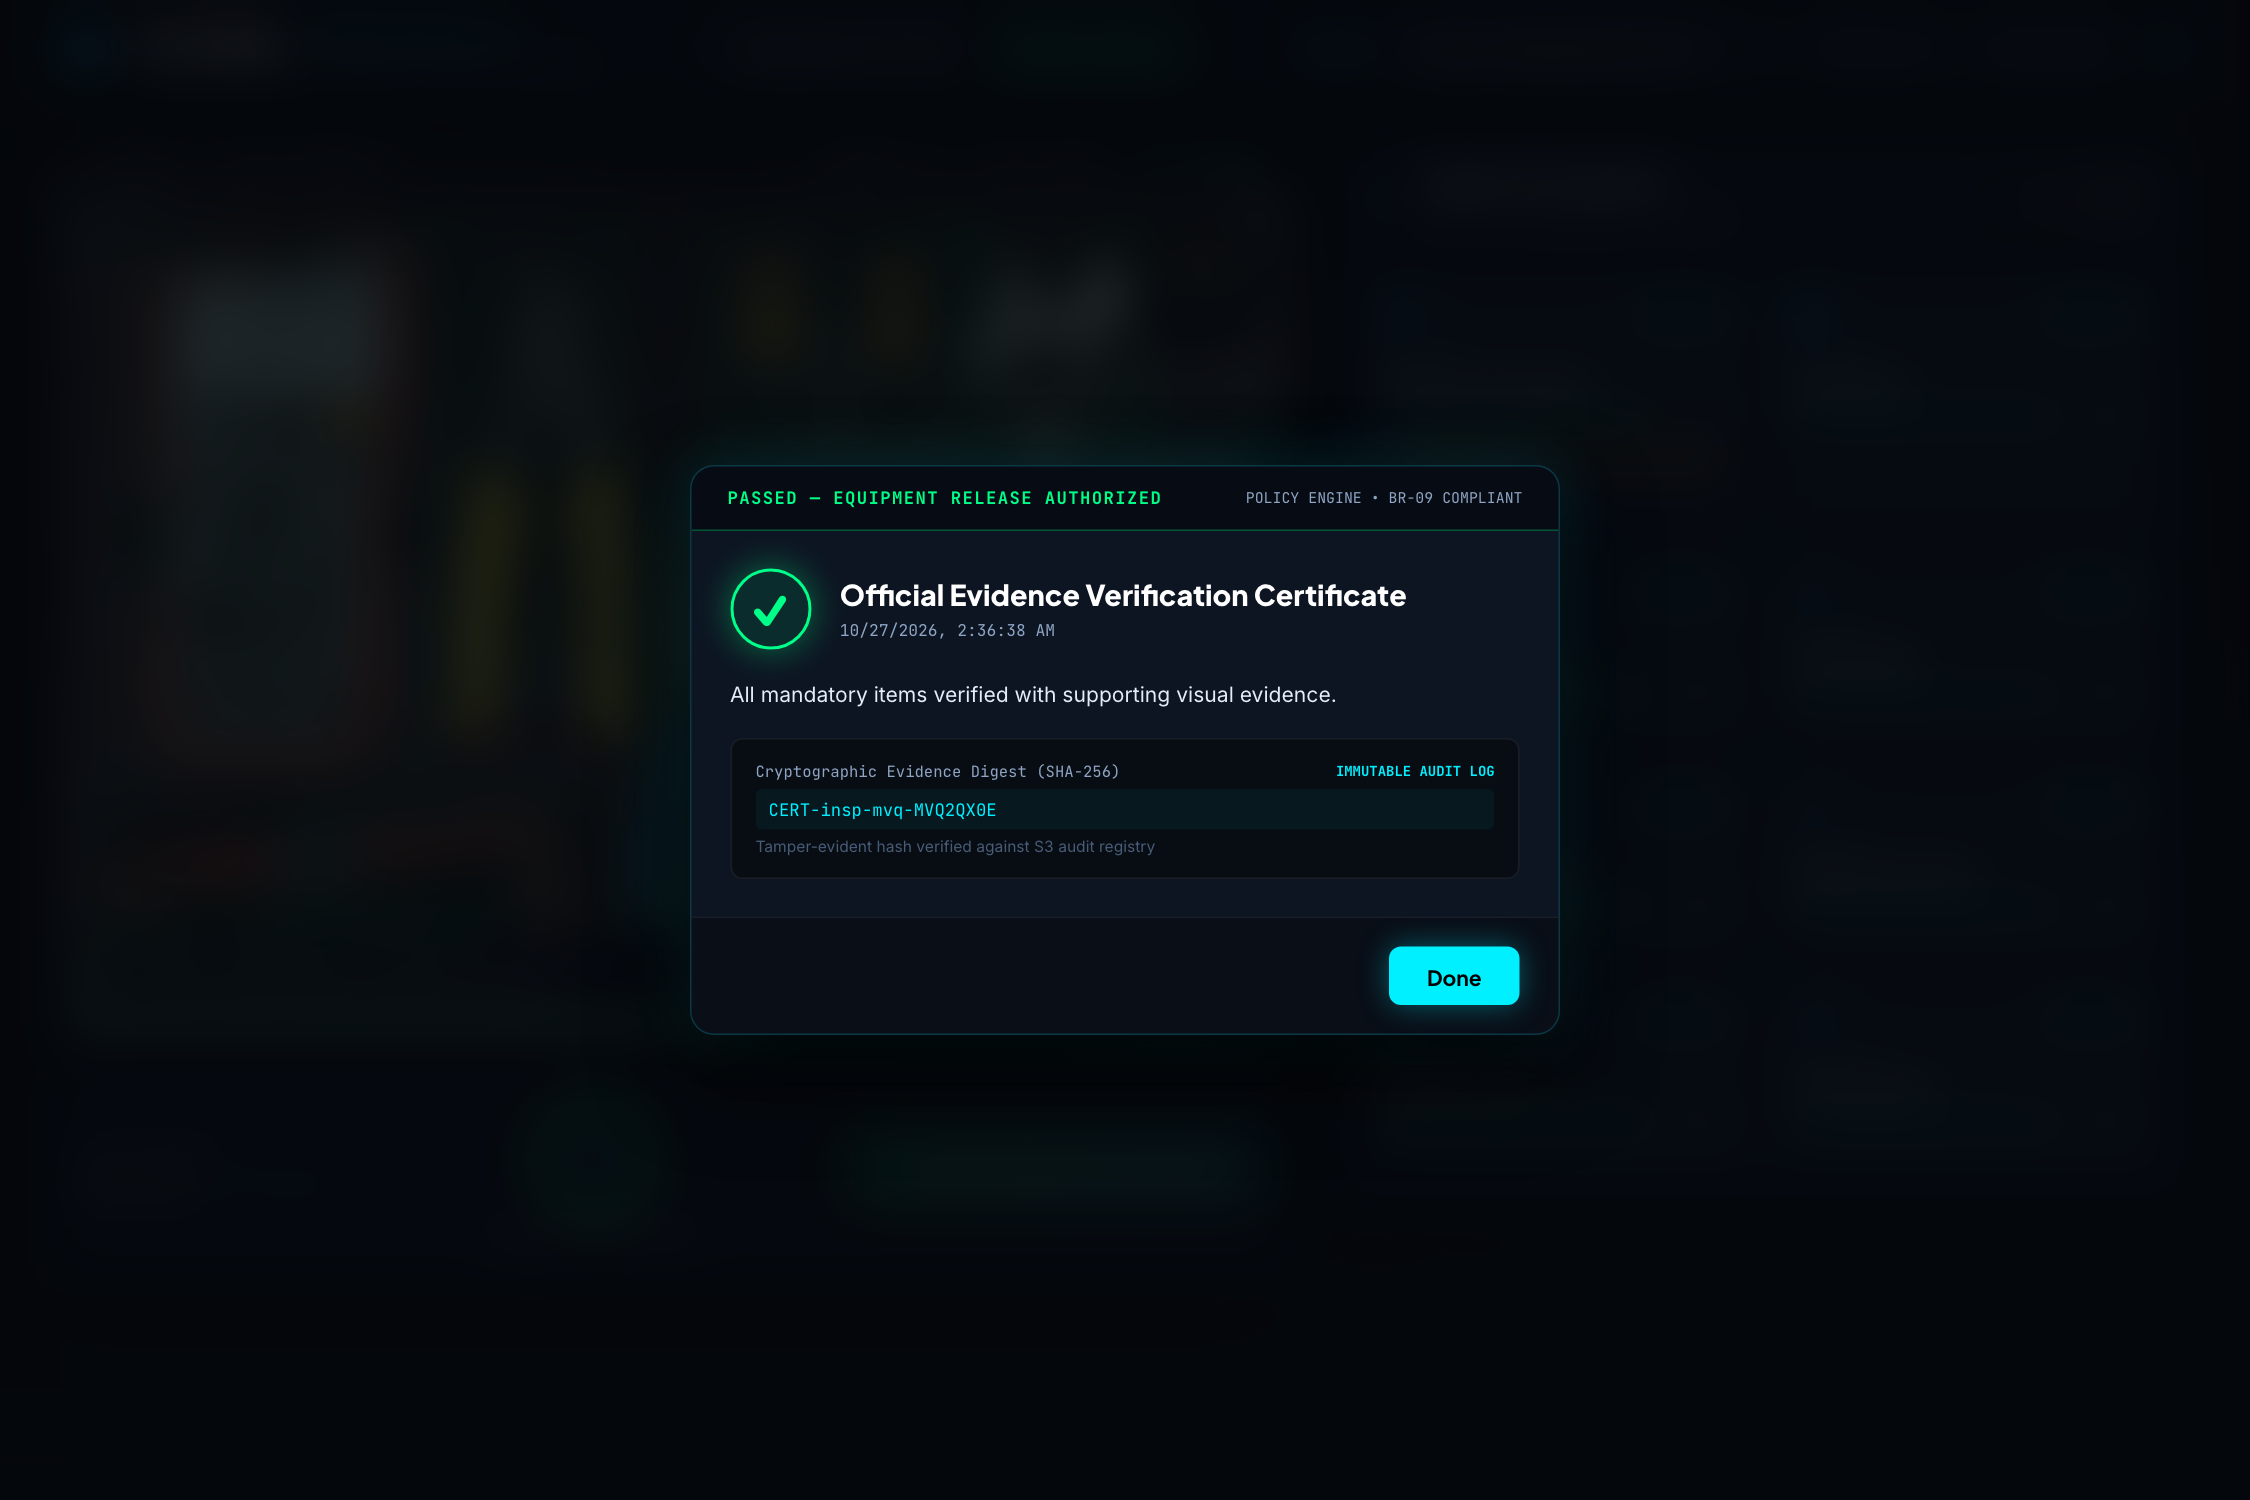
5. **Deterministic Policy Release (BR-09)**: An isolated Hexagonal policy engine enforces 15 strict business invariants. Only when all mandatory components are verified does the system authorize release, stamping the session with an immutable SHA-256 evidence certificate digest.
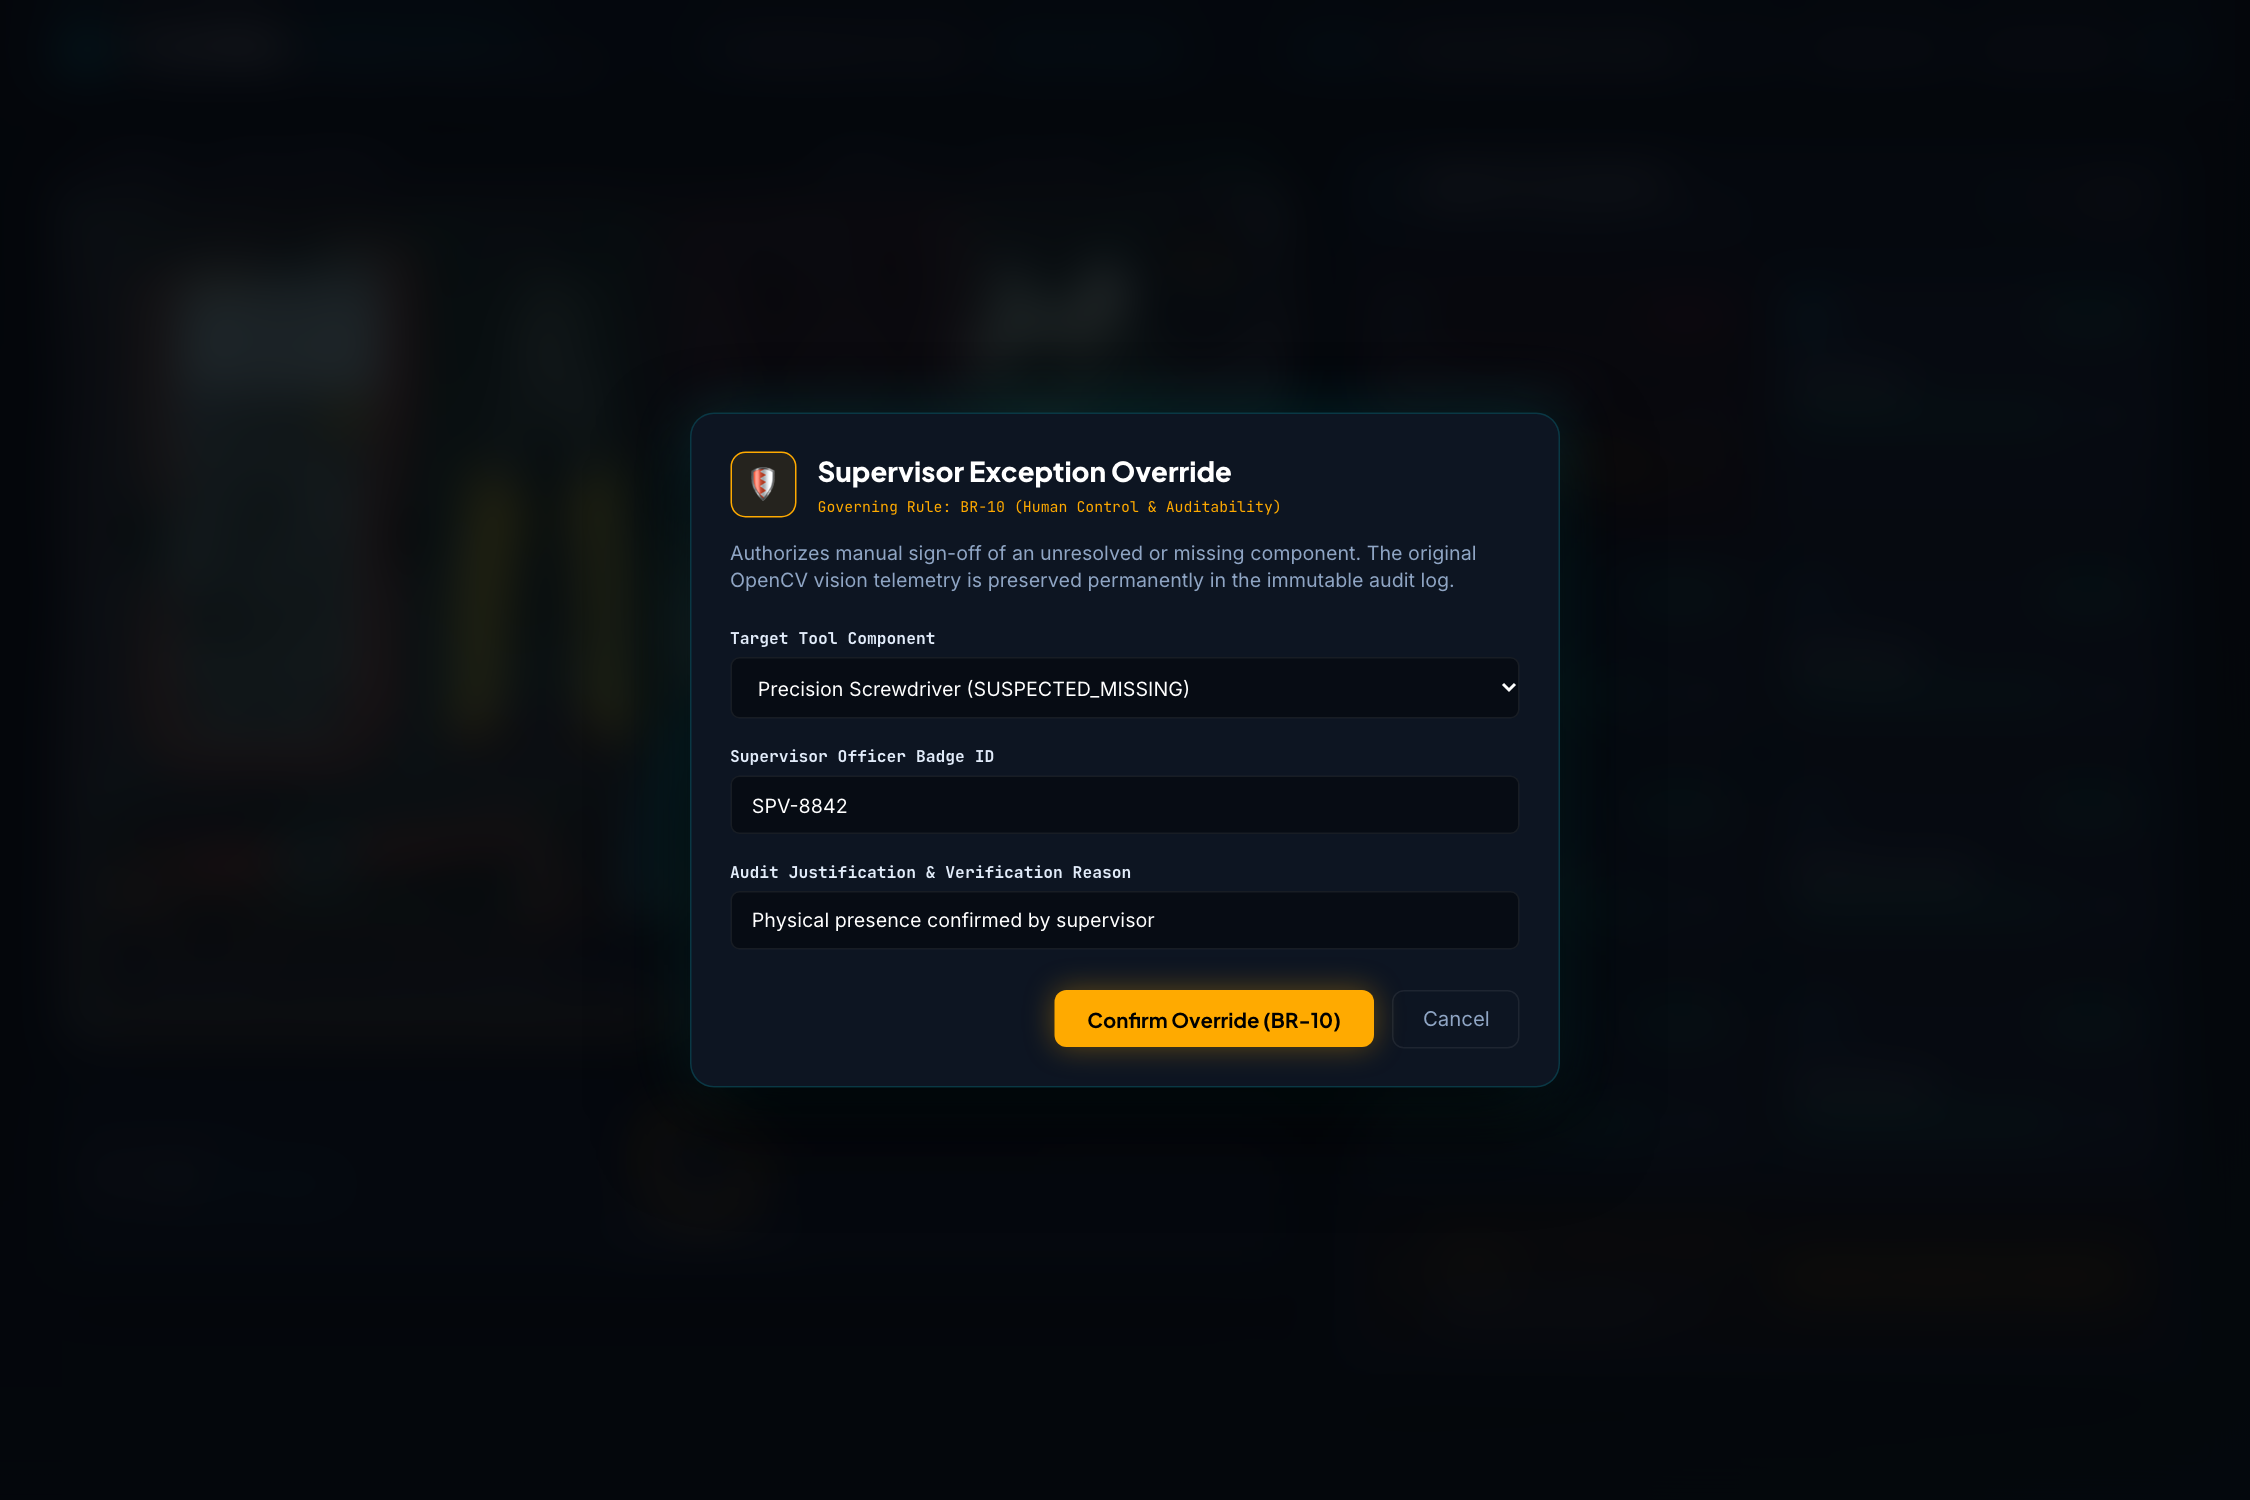
6. **Supervisor Exception Terminal (BR-10)**: If a tool is genuinely absent, an authorized supervisor can sign off via a tactical override terminal, recording reviewer identity and justification permanently in the audit log.

---

## How We Built It

We engineered ProofSight using a strict **Hexagonal Architecture (Ports & Adapters)** and **Domain-Driven Design (DDD)**:

- **Pure Domain Core (`src/domain/`)**: Built in pure JavaScript with zero external runtime dependencies. It manages an explicit Finite State Machine (`NOT_OBSERVED` $\rightarrow$ `UNRESOLVED` $\rightarrow$ `VERIFIED` / `SUSPECTED_MISSING`), audit trails, and the deterministic policy engine.
- **Computer Vision Pipeline (`server/`)**: Powered by **OpenCV 5** and **FastAPI**. It handles Laplacian blur variance, luminance histograms, Canny edge density per region-of-interest, and ORB feature matching with homography perspective correction:
  $$p' \sim H \cdot p$$
- **Frontline Inspection Cockpit (`src/ui/`)**: A responsive mobile-first React 18 & Vite web application featuring:
  - Interactive spatial AR target acquisition reticles with chamfered geometry.
  - 3D Inclinometer & Artificial Horizon HUD for angle guidance.
  - Digital Twin Manifest with custom SVG tool schematics and live confidence gauges.
  - Knurled titanium shutter with radial SVG progress rings and aperture animations.
  - Real-time acoustic feedback synthesized via the native **Web Audio API**.
- **Containerization & Cloud**: Packaged via multi-stage Dockerfiles and `docker-compose.yml`, ready for **AWS App Runner** or **AWS ECS Fargate**.
- **Automated Verification**: 21 native unit tests, 3 Playwright slow-motion E2E acceptance test suites, and an Affirmation Matrix guaranteeing 100% bidirectional traceability across 173 atomic requirements.

---

## Challenges We Faced

1. **Escaping the "One-Shot Fallacy"**: Transitioning from traditional single-image classification to an incremental, multi-frame state machine required careful domain isolation so that secondary observations never overwrote valid existing proofs.
2. **Ergonomics for Field Technicians**: Frontline workers cannot navigate complex web forms or read raw CV confidence numbers while wearing gloves. We iterated heavily to create a high-contrast, tactile cockpit layout that consolidates the camera viewfinder, spatial AR reticles, and shutter trigger into a single thumb-accessible station.
3. **Deterministic Safety Guarantees**: Probabilistic computer vision outputs can never be allowed to directly approve safety-critical releases. We solved this by enforcing a hard separation between perception (OpenCV measurements) and decision authorization (deterministic business rule engine).

---

## Accomplishments That We're Proud Of

- **100% Occlusion Resolution**: In our 30-scenario benchmark, ProofSight resolved 12 of 12 partially occluded tools through active angle guidance, cutting false missing-item rejections from **37.5% down to 0.0%**.
- **Zero Hallucinated Approvals**: Invariants mathematically bar approval if any mandatory item lacks verifiable evidence.
- **Sub-30ms OpenCV Execution**: The full OpenCV 5 quality, exposure, and feature pipeline runs in under 25ms on AWS Graviton3.
- **100% Verified Traceability**: 173 of 173 atomic requirements pass our automated 95% Plan Affirmation Gate with 0 orphan assertions.

---

## What We Learned

We learned that in frontline industrial operations, the highest-leverage application of AI is not generating broad descriptive reports, but **actively guiding the operator to capture better physical evidence**. Providing clear, directional spatial instructions transforms computer vision from a brittle guessing tool into a reliable operational partner.

---

## What's Next for ProofSight

- **Hardware IMU Integration**: Binding the 3D Inclinometer directly to the mobile device's accelerometer (`DeviceOrientationEvent`) for physical gyroscope lock-on in 3D space.
- **Custom Template Studio**: A visual tool allowing operations managers to photograph new equipment trays and automatically generate reference coordinate templates.
- **Enterprise Integrations**: Native connectors for SAP Plant Maintenance and IBM Maximo to trigger automated work orders and digital asset handovers.
ProofSight
ProofSight is an AI inspection agent that guides camera angles to verify physical equipment and toolkits, eliminating false missing-item alerts before release.
Updates

Leave feedback in the comments!
Log in or sign up for Devpost to join the conversation.