-
-
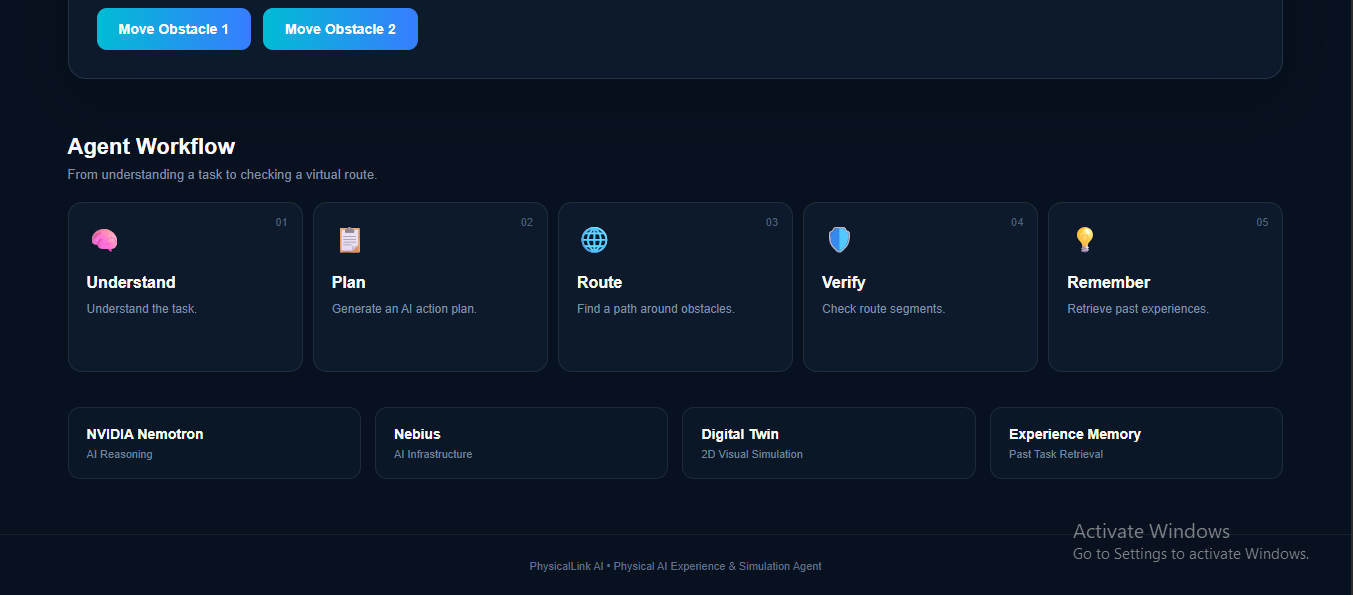
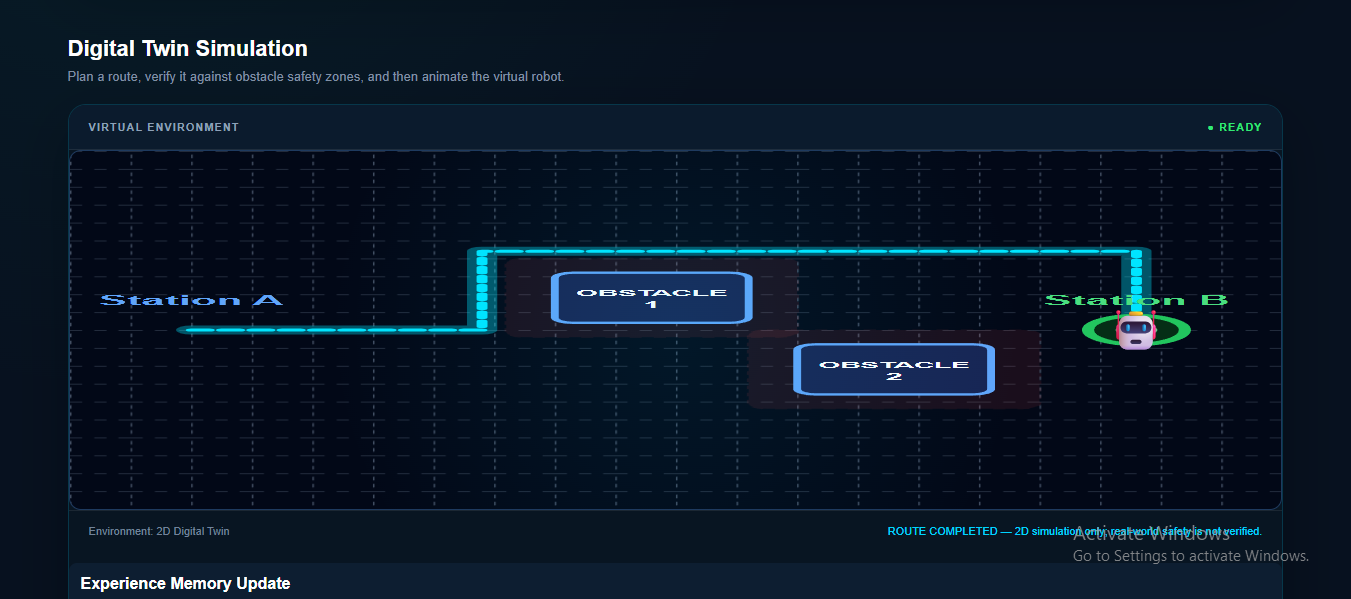
Robot Route Simulation – The virtual robot follows a planned path while avoiding obstacles.
-
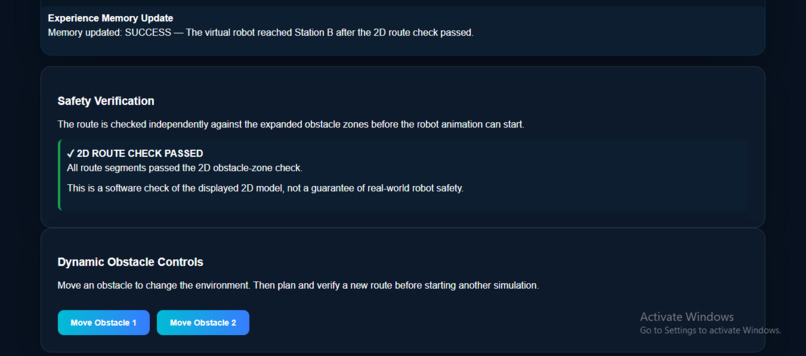
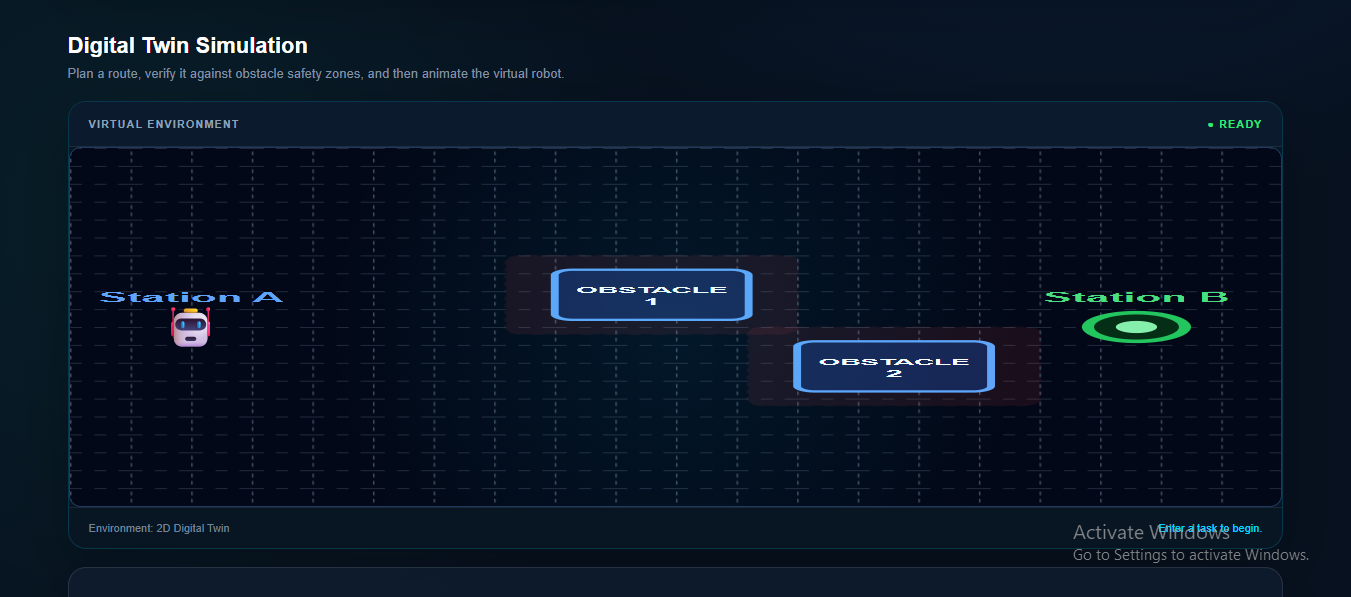
Safety Verification – The system checks every route segment against 2D obstacle zones before simulation.
-
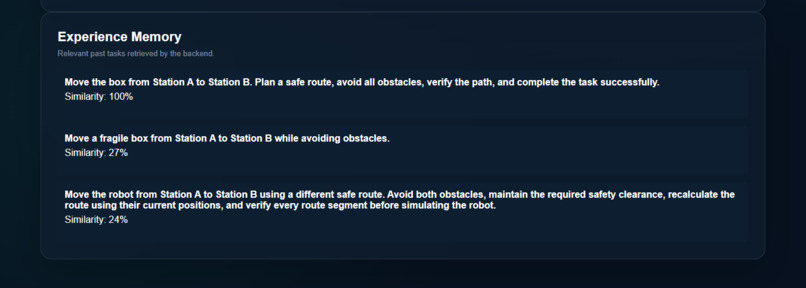
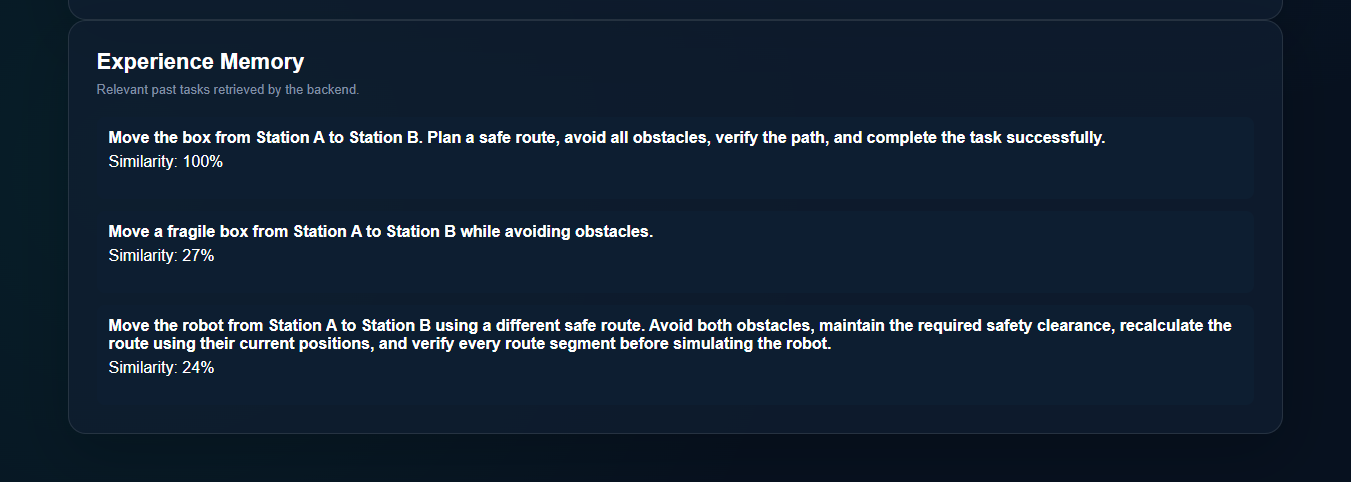
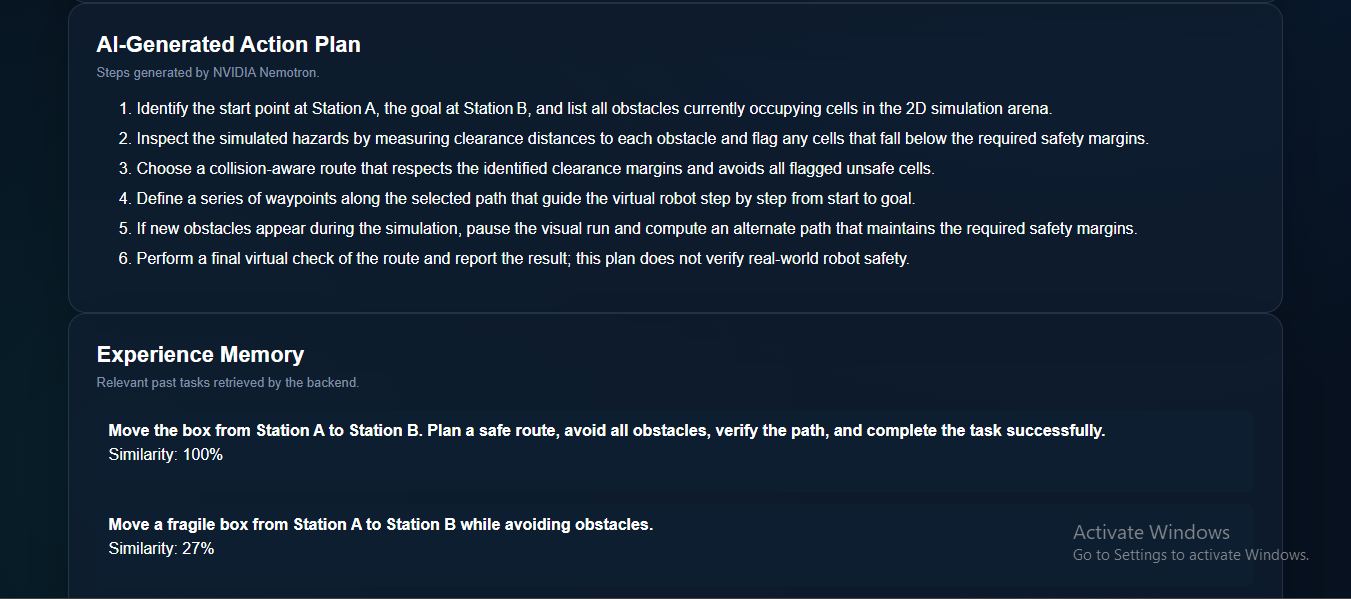
Experience Memory – Retrieves previous tasks and identifies similar experiences to improve planning.
-
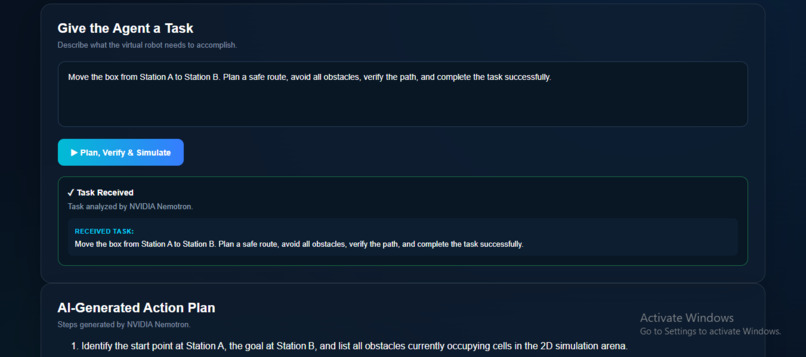
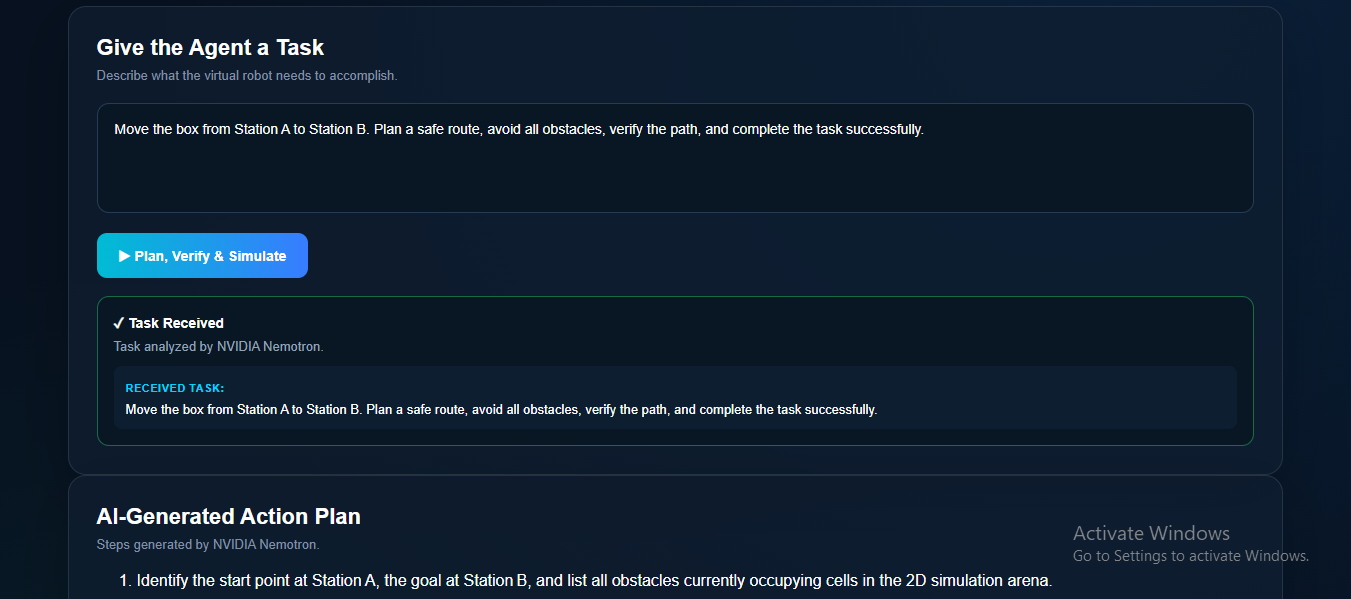
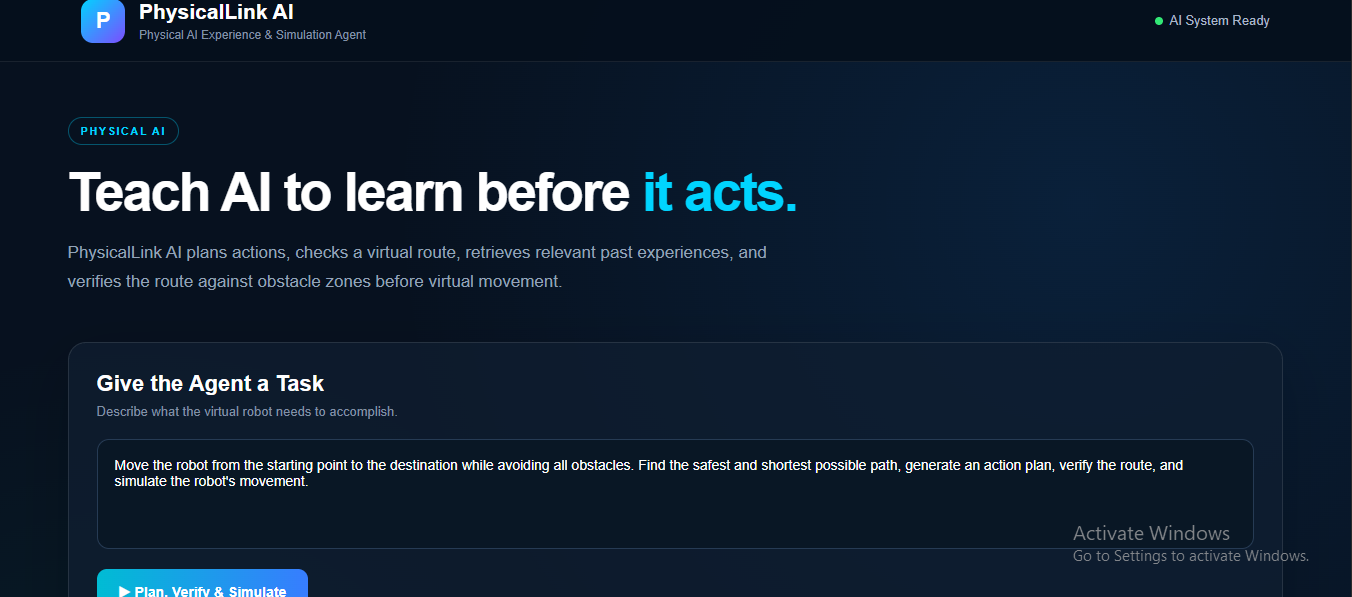
Task Input – Users provide natural-language instructions for the AI agent to perform.
-
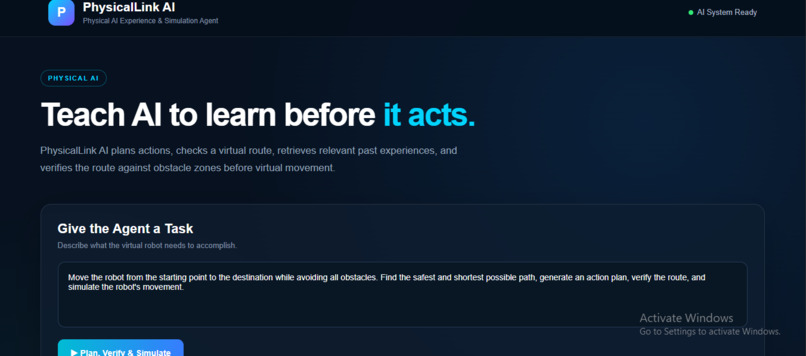
PhysicalLink AI – An Intelligent Physical AI Experience and Simulation Agent.
-
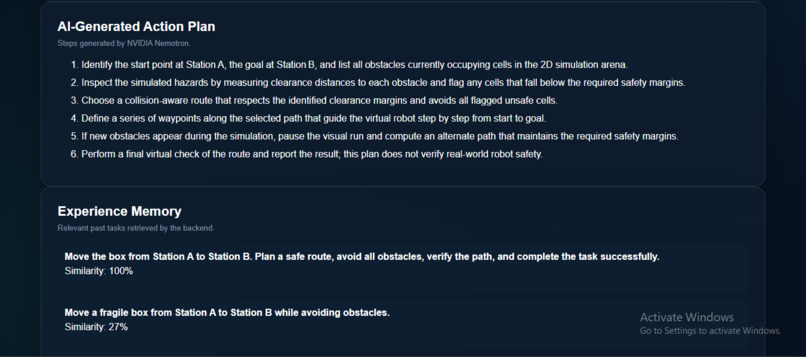
AI-Generated Action Plan – NVIDIA Nemotron generates a six-step plan for safe robot navigation.
-
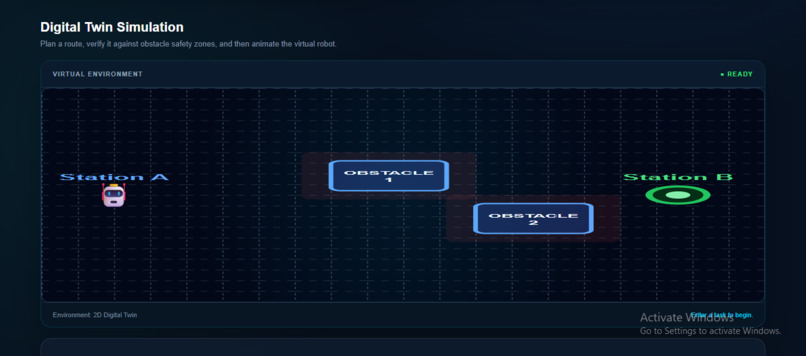
Digital Twin Environment – A virtual robot environment with Station A, Station B, and dynamic obstacles.
-
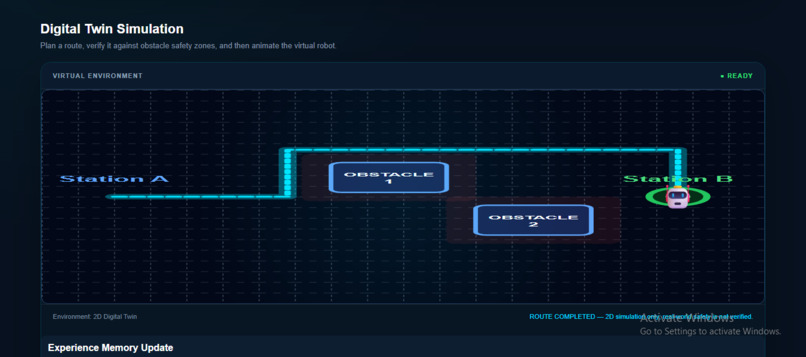
Memory-Based Learning – The system uses previous task experiences to support future decisions.

Inspiration
Robots need to make safe decisions before moving. We created PhysicalLink AI to help AI understand tasks, plan routes, and avoid obstacles in a virtual environment.
What it does
PhysicalLink AI uses NVIDIA Nemotron to understand user instructions and plan actions. It creates a route from Station A to Station B, checks obstacles, and simulates robot movement in a 2D digital twin. It also uses past experiences to improve future decisions.
How we built it
We built a web-based interface with a 2D virtual environment, two stations, obstacles, route planning, safety verification, and robot simulation. NVIDIA Nemotron supports task understanding and action planning.
Challenges we faced
We worked on displaying the virtual environment correctly, positioning obstacles, planning routes, and checking whether the robot can reach its destination safely.
What we learned
We learned how AI planning, obstacle avoidance, route verification, and digital twin simulation can work together to support safer robotic decisions.
What's next
We plan to improve route planning, add more obstacle scenarios, enhance the simulation, and connect the system with real robotic environments in the future.
Built With
- ai
- digital
- javascript
- nemotron
- nvidia
- python
- react
- robotics
- twin
- vite
