Inspiration
Today’s hospital telepresence robots are essentially eyes and ears on wheels. While they allow remote doctors to see and speak with patients, they cannot physically interact with the room. In high-risk infectious isolation wards—like those seen during the COVID-19 pandemic—or in rural clinics lacking on-site specialists, bedside nurses still have to physically enter the room to hand over medication, adjust equipment, or hold diagnostic tools.
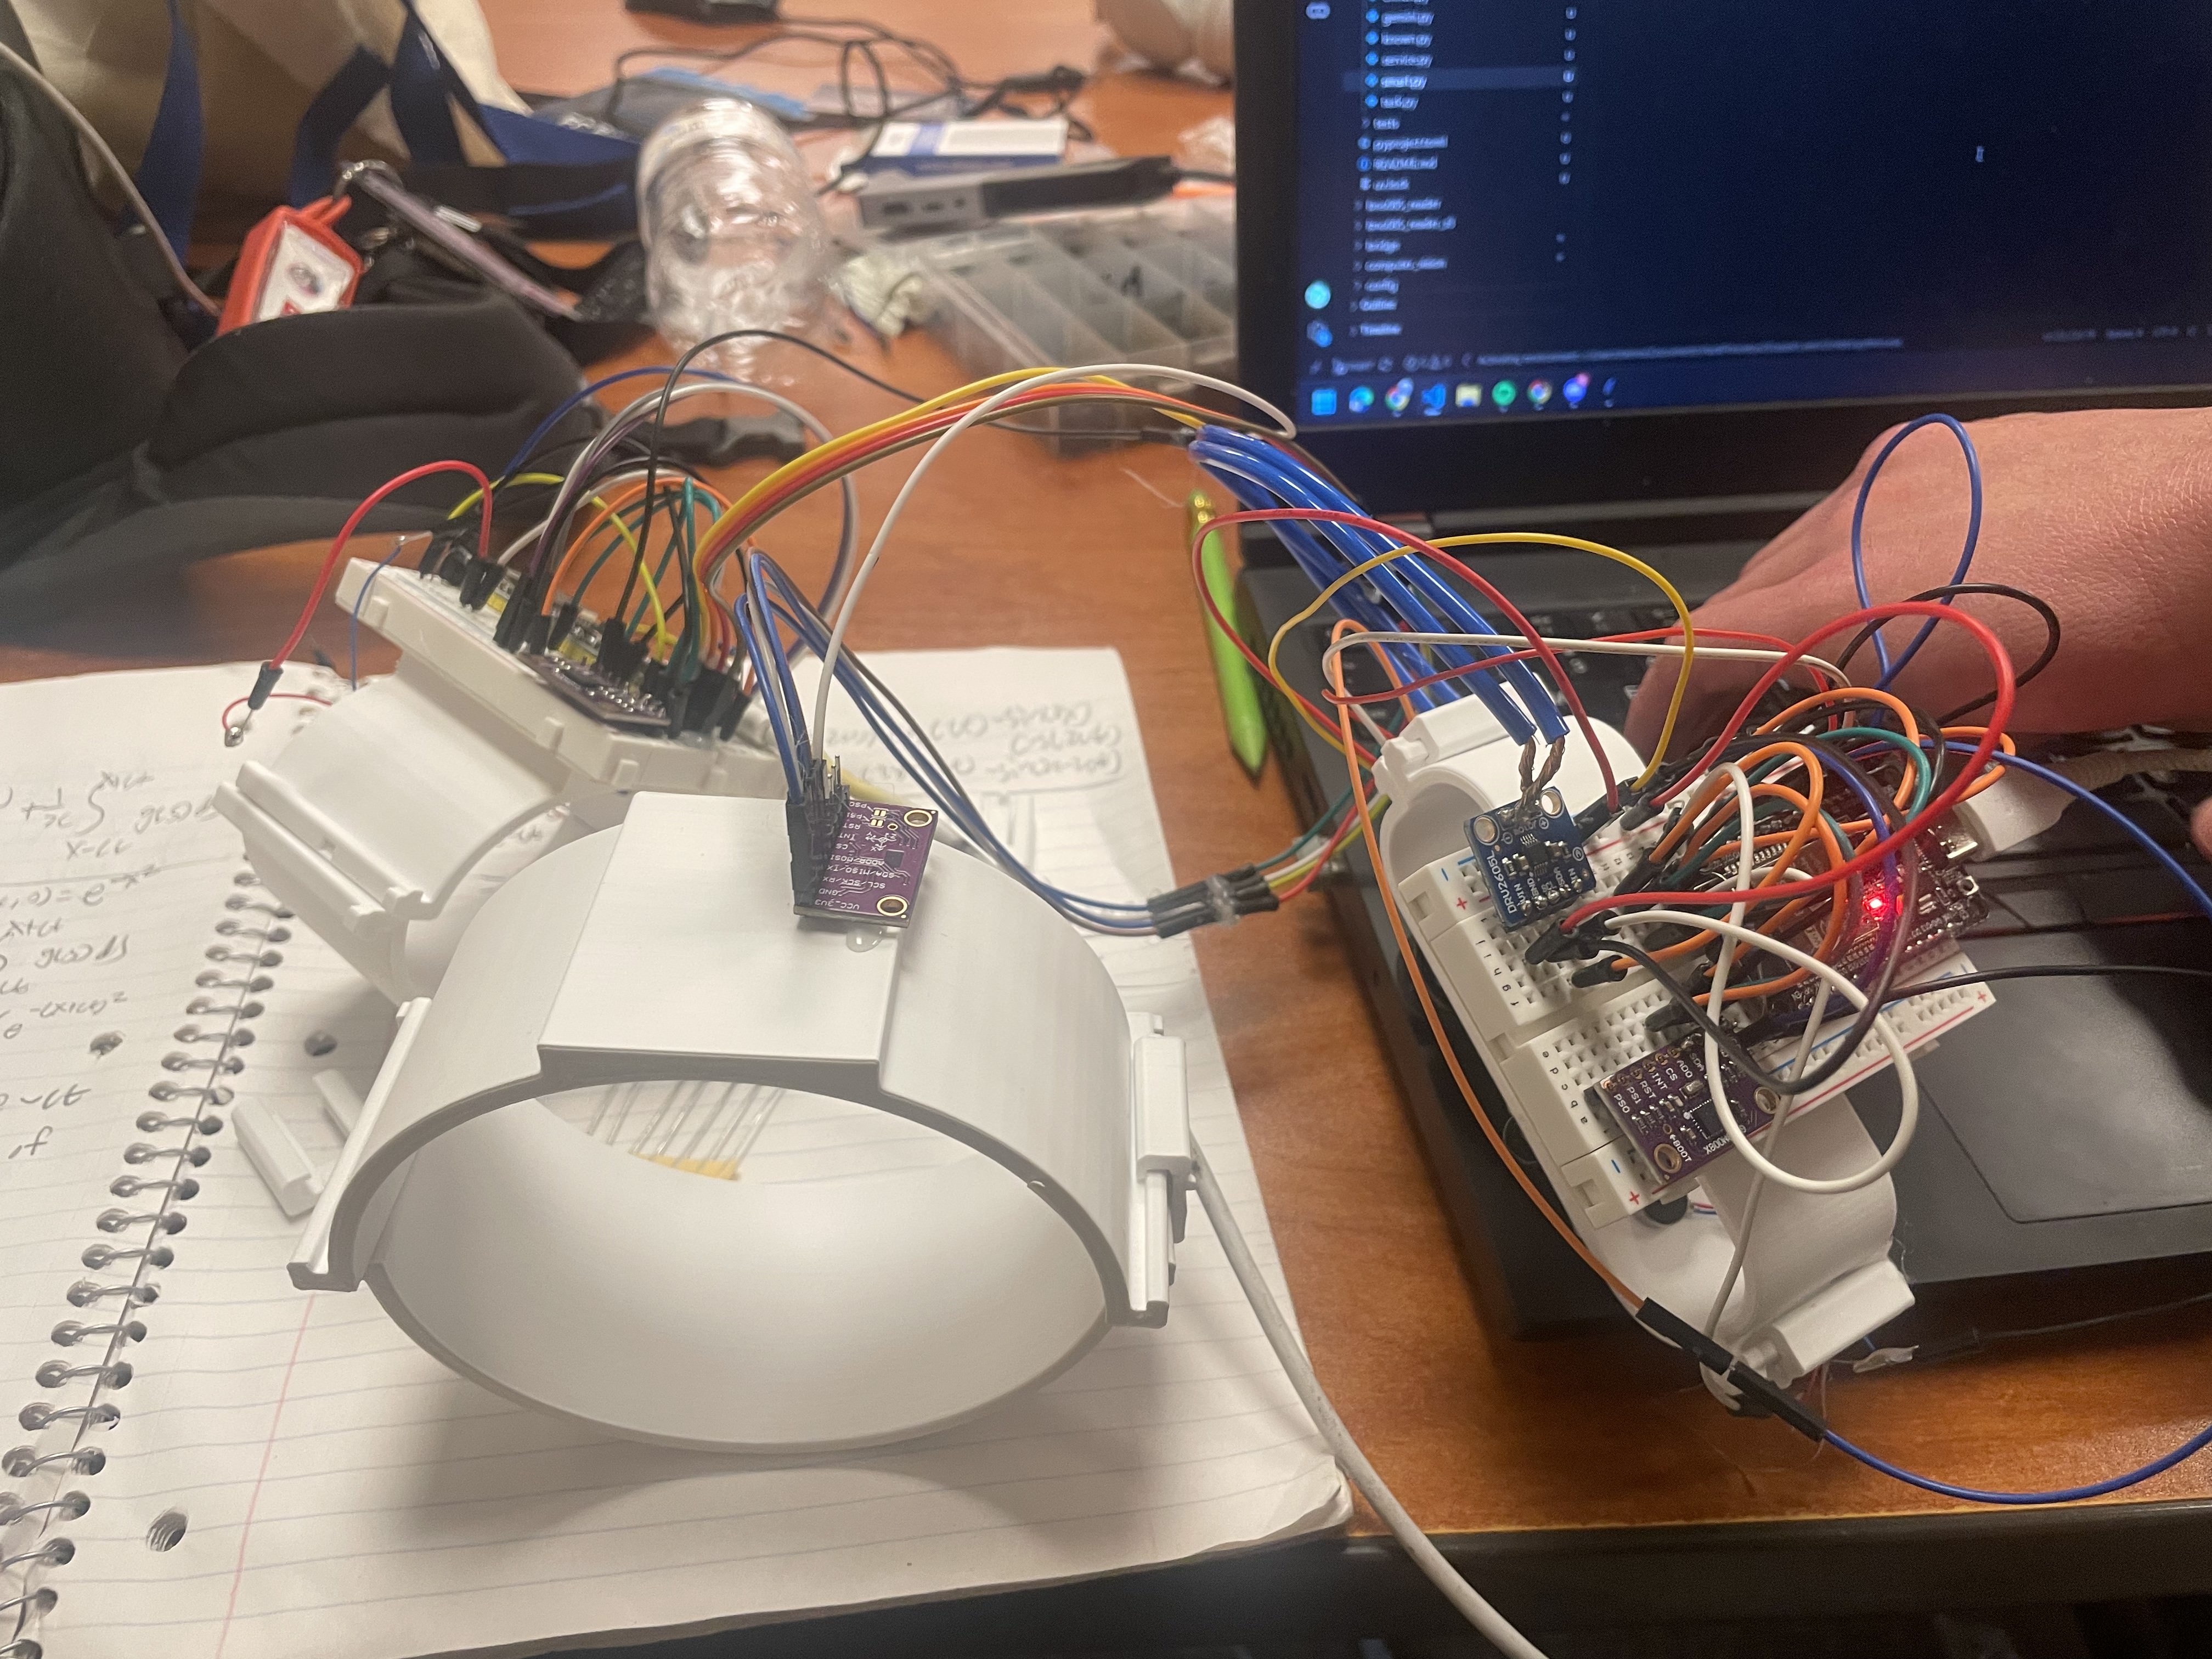
We wanted to move remote healthcare beyond passive telepresence into safe, active tele-action. Existing haptic teleoperation systems typically require bulky VR headsets and expensive mechanical exoskeleton gloves. Our goal with PAUL (Proprioceptive Arm User Link) was to build a lightweight, accessible wearable system that lets a clinician naturally move a bedside robotic arm and genuinely feel what it touches—all through a standard web browser.
What it does
PAUL turns a standard robotic manipulator into a tactile, remote-care assistant for healthcare providers:
Natural Arm-to-Robot Control: A clinician slips on a lightweight wearable armband that maps their real-time arm orientation and motion directly to a bedside LeRobot Arm 101.
Bidirectional Sense of Touch & Weight: When the robot touches an object or lifts a load, the clinician feels real-time tactile feedback through haptic motors on their arm—allowing them to distinguish between a light touch on a fragile cup and the weight of a full water bottle.
AI Spatial & Voice Guidance: Arm-mounted cameras run a computer vision model that estimates object size and proximity, speaking live voice distance cues aloud so the operator never loses depth perception over a 2D video stream.
Browser-Based Telehealth Dashboard: Everything connects through a unified web interface displaying live camera feeds, computer vision overlays, and real-time force telemetry for zero-friction deployment.
