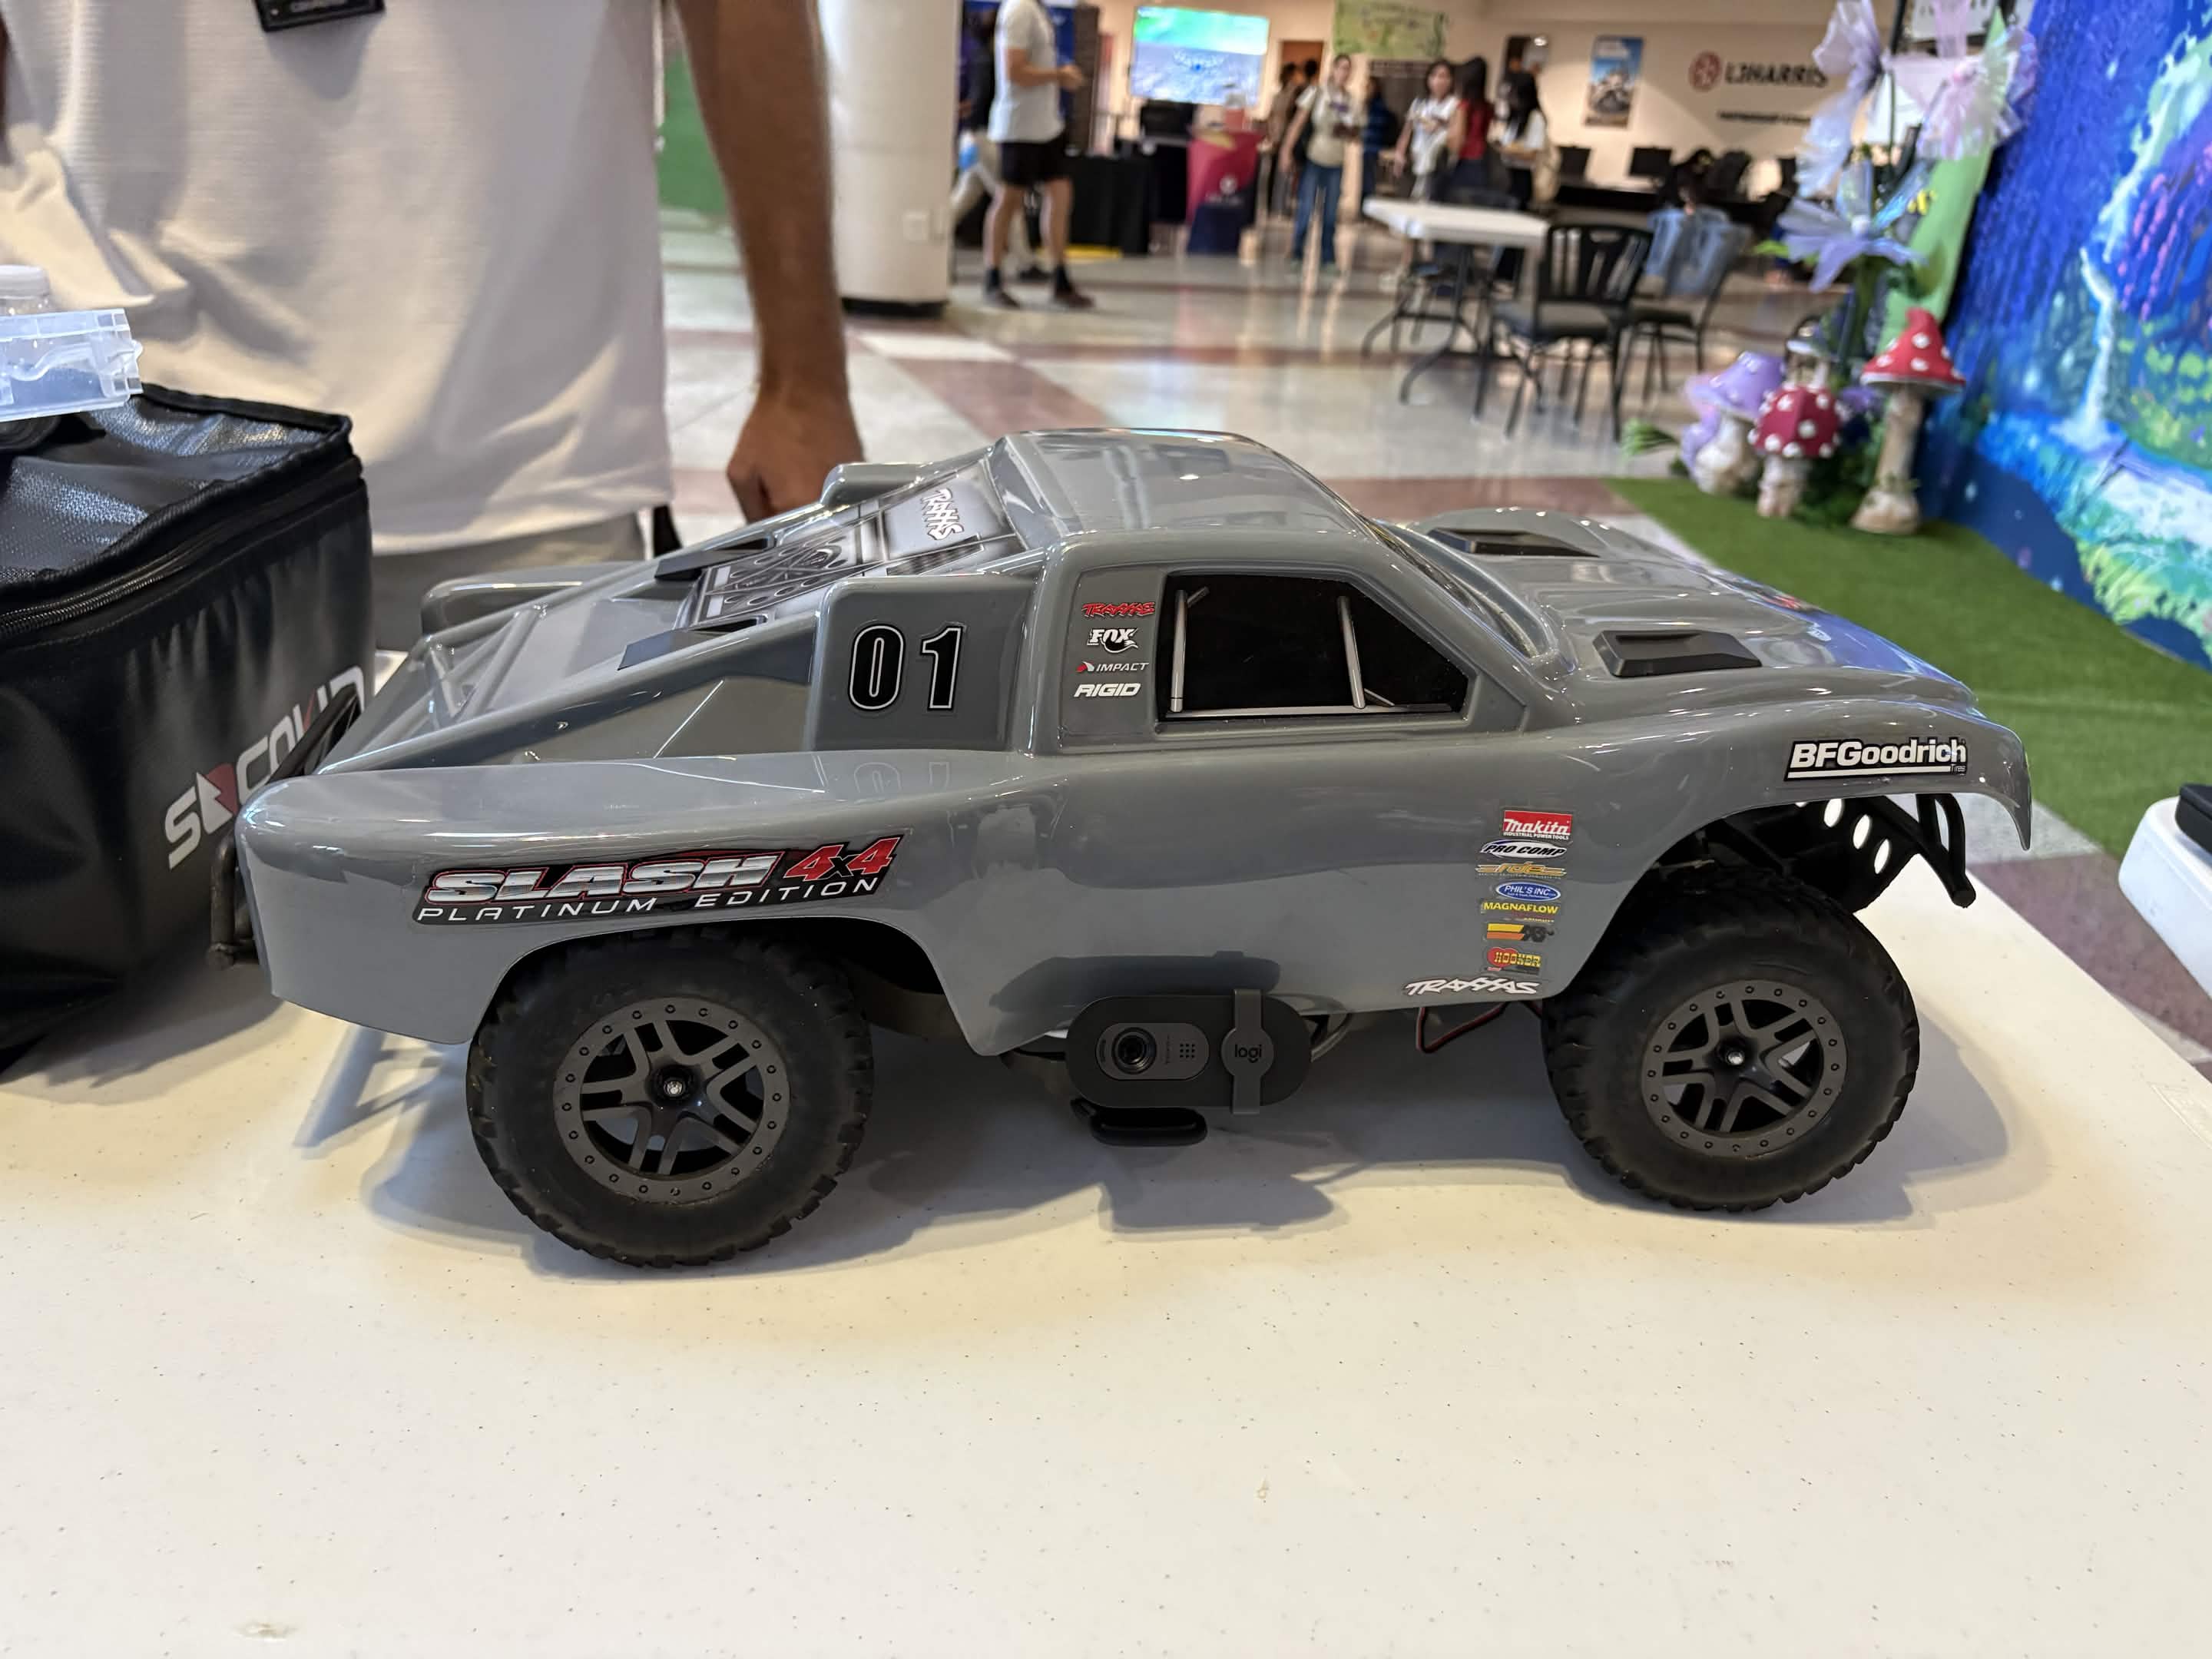
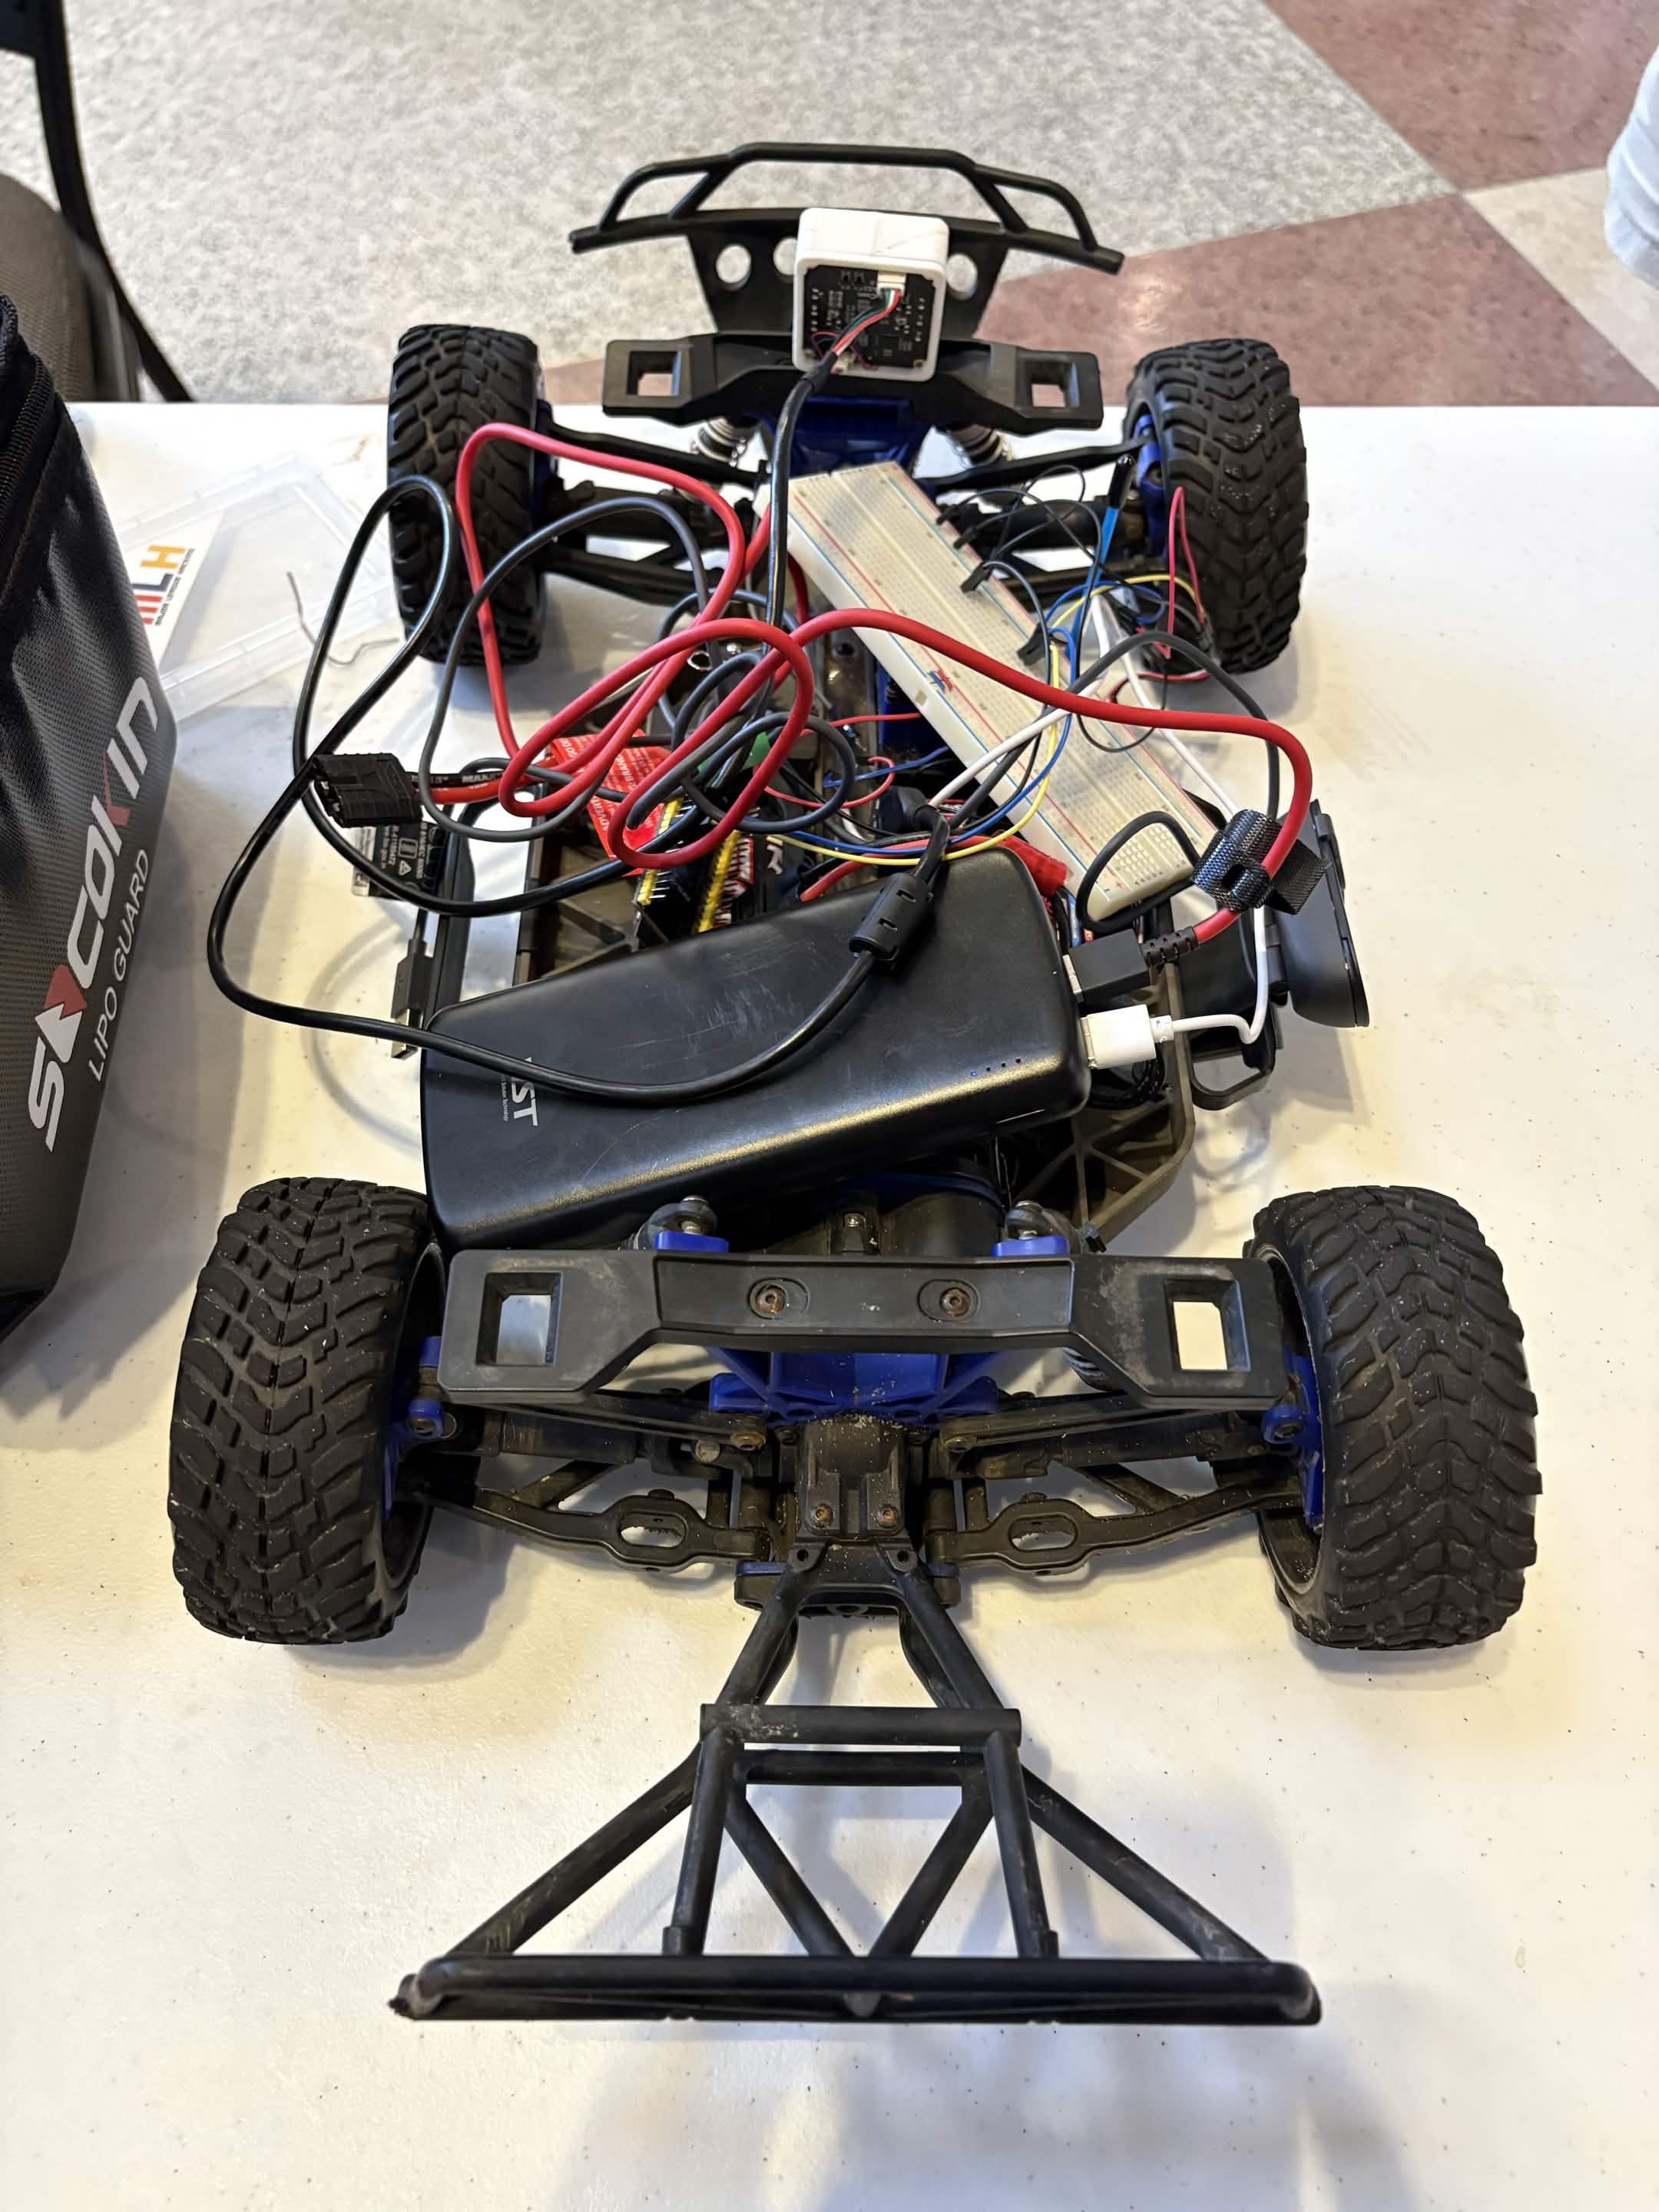
ParkVision: Building a Smart Autonomous Parking Rover | UCF Hackathon 2026 🚗 For UCF Hackathon 2026, our team has been developing ParkVision, a smart RC rover project that brings together embedded systems, computer vision, autonomous navigation, and web development. Our goal is to combine physical robotics with intelligent software to explore how a small-scale autonomous vehicle can navigate and support parking-related applications. What We're Building Our project brings together three major components: 🔧 Embedded Systems & Robotics Using an ESP32-S3 microcontroller programmed in C++, we've developed a control system for our RC rover that supports Wi-Fi communication, steering and throttle control, and autonomous movement. The rover can execute a programmed square route using calibrated motor timing and steering adjustments. We've also implemented connection recovery and navigation status feedback. 👁️ Computer Vision Our project includes a computer vision component intended to help the system interpret its surroundings and support parking-related decision-making. By integrating visual processing with the rover's control system, we're working toward a more intelligent approach to autonomous navigation. 💻 Frontend Development We're developing a web-based dashboard to provide an interface for interacting with the system and viewing information from the rover. This brings the hardware, robotics logic, and user interface together into one project. Collaboration and Development One of the most valuable aspects of this hackathon has been integrating multiple areas of software engineering into a single system. Our team organized the project into separate GitHub directories for the Arduino firmware, computer vision code, and frontend application. This allowed us to work on different components while maintaining a shared codebase. We've also encountered challenges involving sensor integration, hardware calibration, and communication between components. Troubleshooting these issues has been an important part of the engineering process. Technologies ESP32-S3 / Arduino C++ Python Computer Vision JavaScript / Web Development Wi-Fi Communication Git & GitHub What's Next? We're continuing to work toward integrating the rover's embedded control system, computer vision functionality, and dashboard into a complete demonstration. ParkVision represents an opportunity for our team to turn software engineering concepts into a physical, interactive robotics project. We're excited to bring these components together and demonstrate what we've built!
Parking Enforcement RC Car
UCF enforces parking via large trucks, consuming gas and paid hours. This is cost ineffective. Instead, we trained an autonomous ground car with computer vision to assess parking availability
Updates

Leave feedback in the comments!
Log in or sign up for Devpost to join the conversation.