## Inspiration
During structural collapses, first responders are often blocked by dense rubble. We built the LASKO bot as a WiFi operated search-and-rescue platform to navigate confined disaster environments and establish a direct communication link where humans cannot safely reach.

## What it does
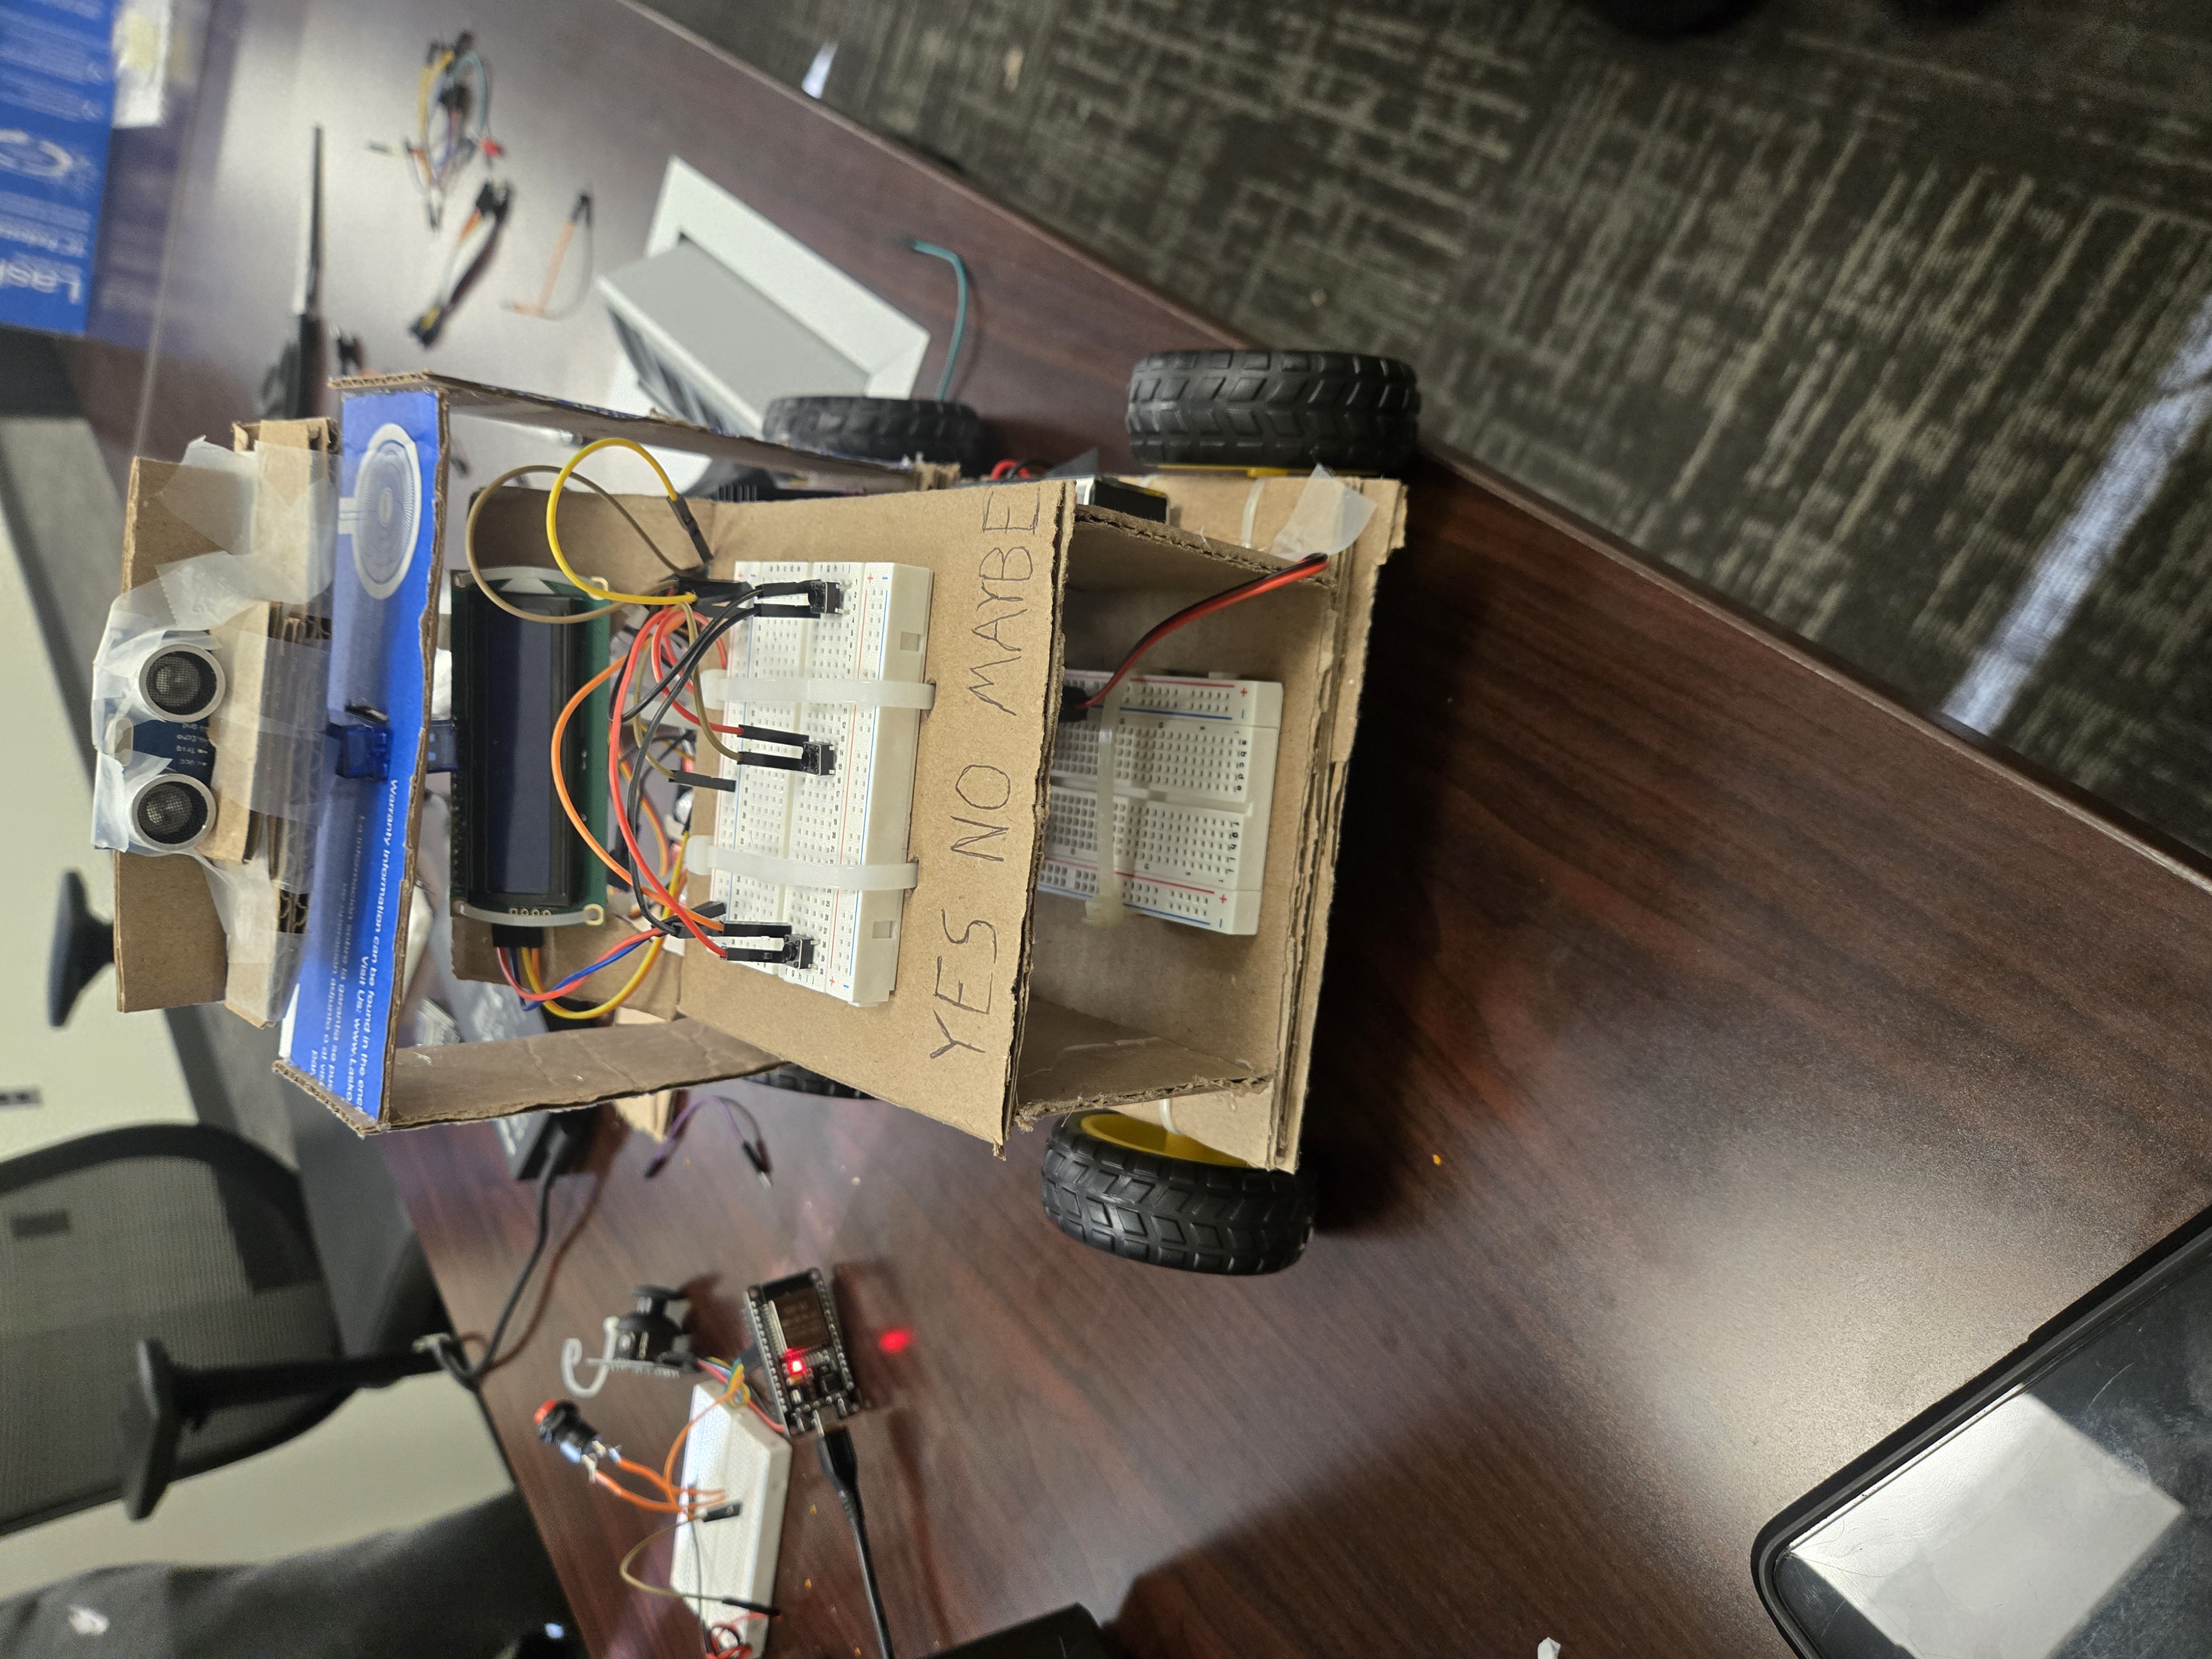
LASKO bot is a remote-controlled rescue scout. It traverses hazardous spaces based on operator inputs and features a unique two-way communication system. The operator can send critical data to be displayed on the robot's onboard LCD, and anyone encountering the bot can use built-in buttons to send three distinct, pre-programmed responses back to the controller.

## How we built it
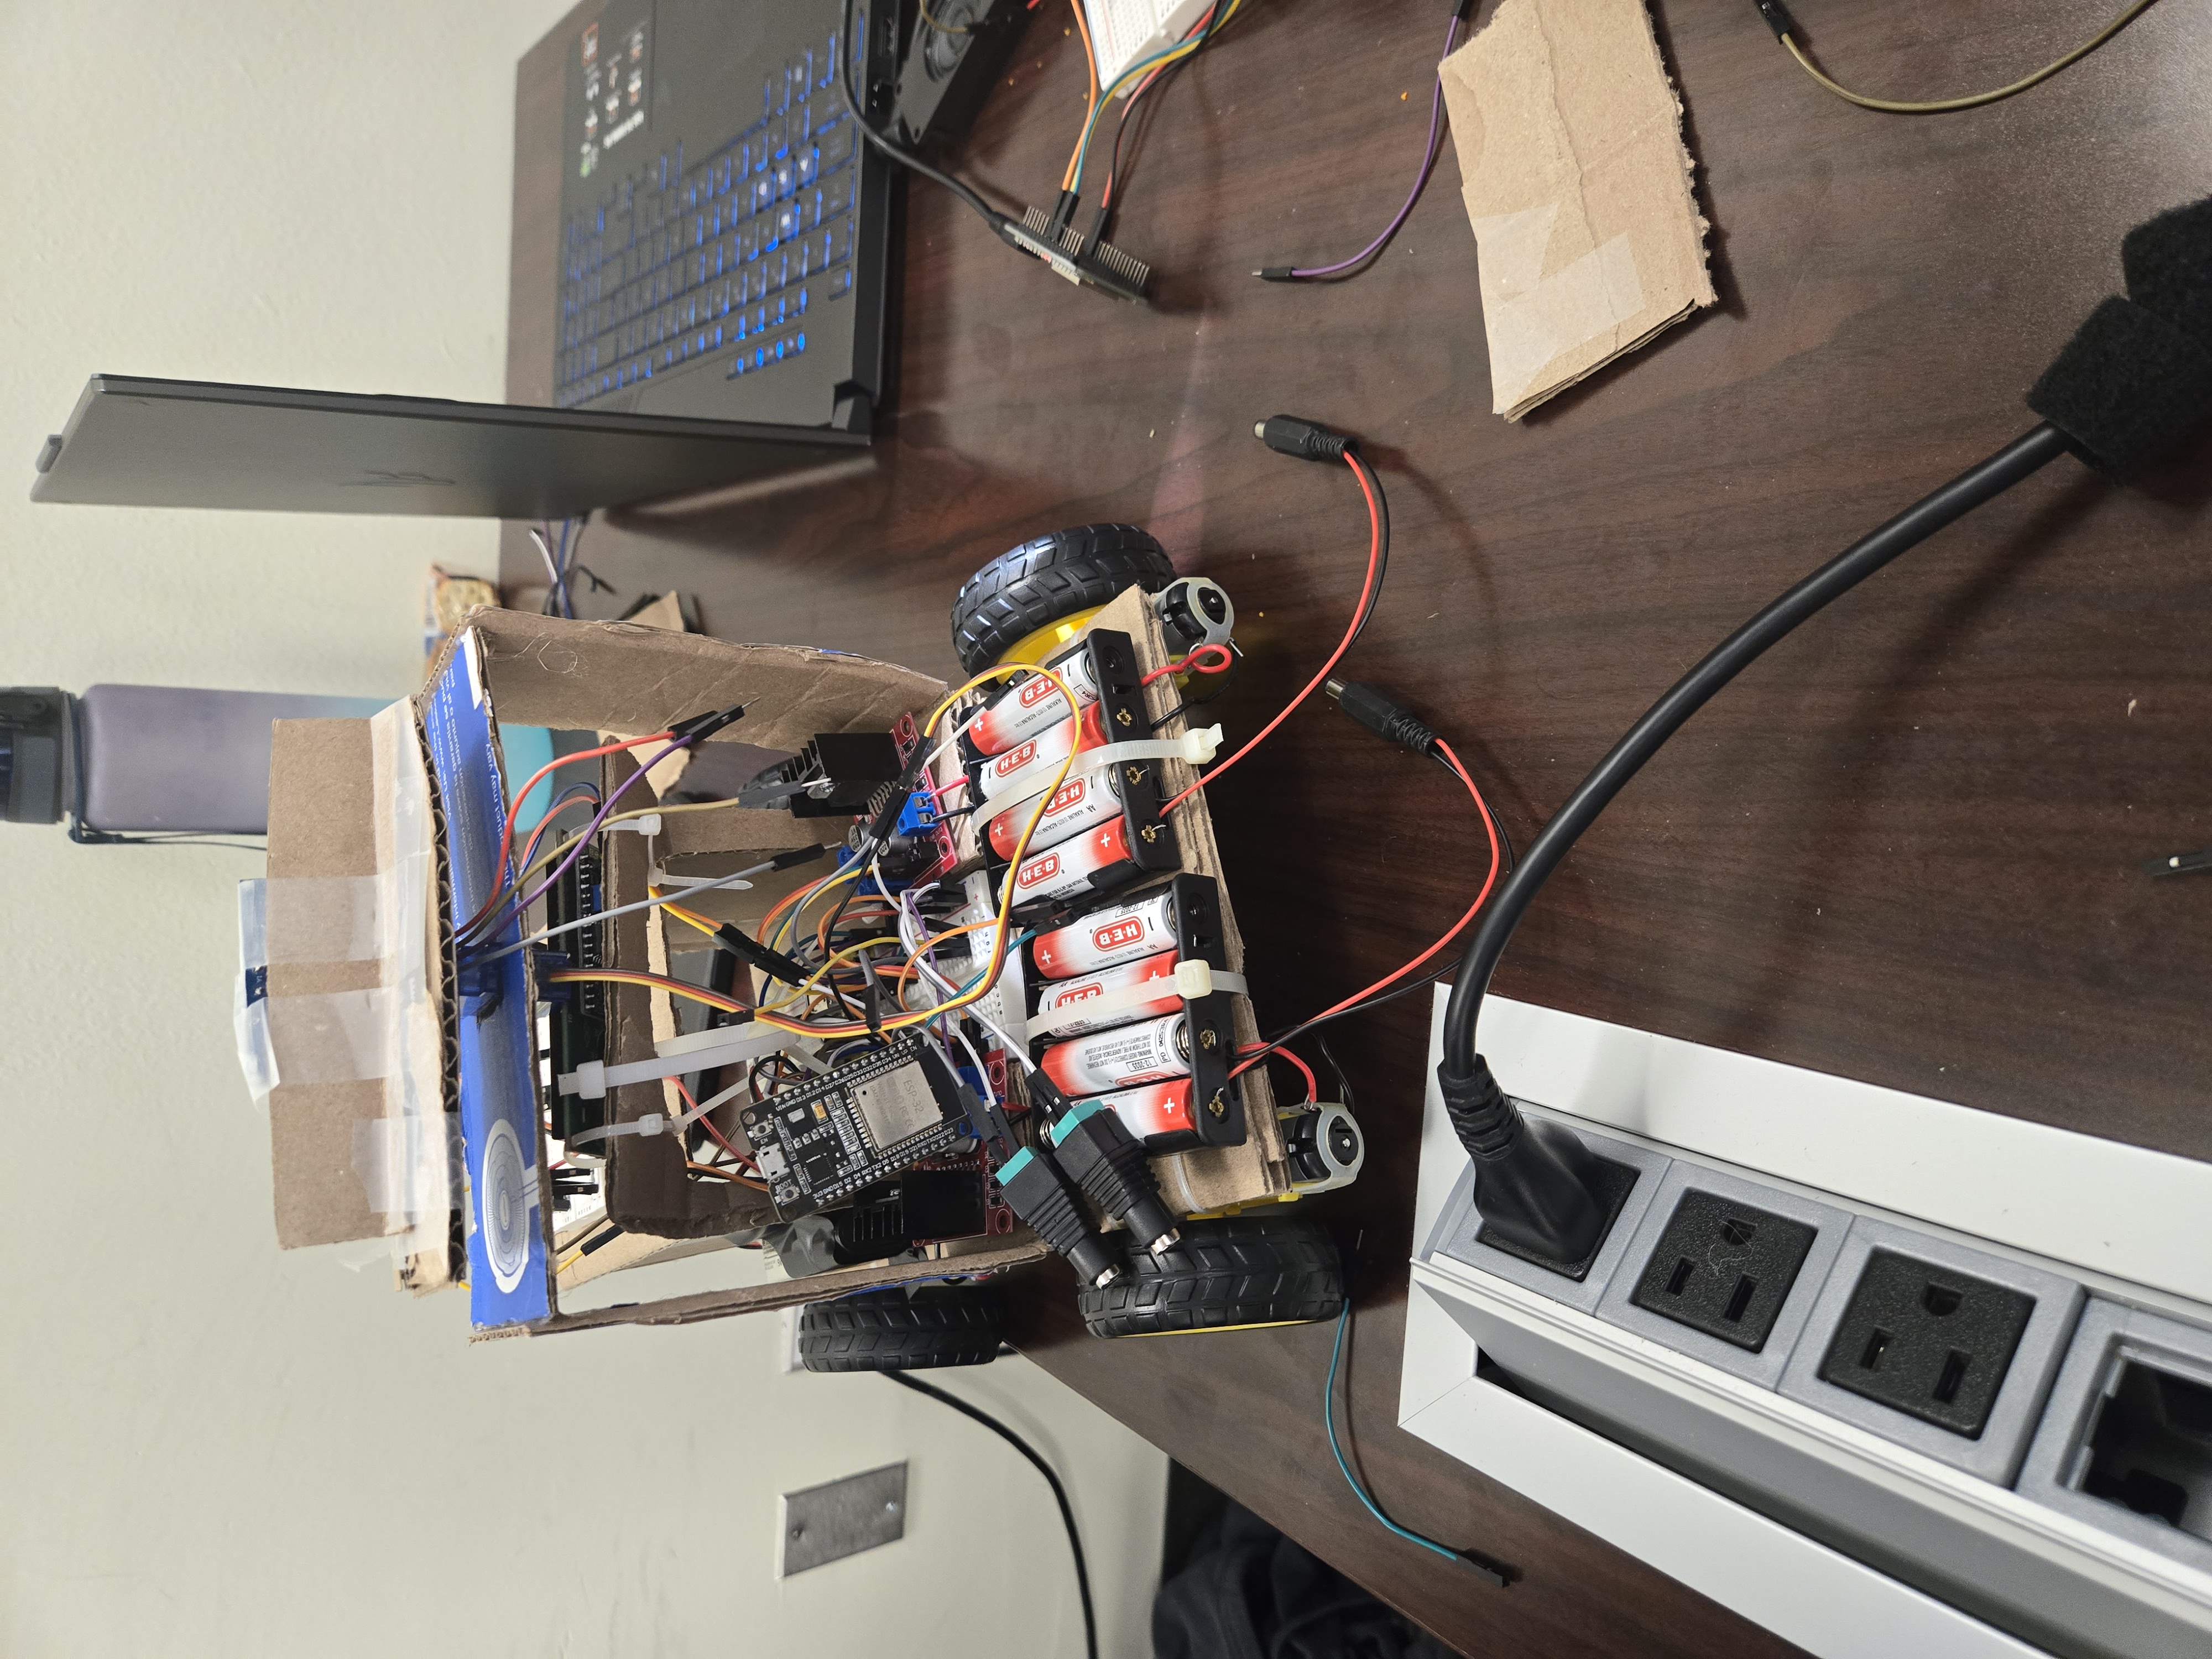
We engineered the bot around an **ESP32** microcontroller for its compact footprint and wireless capabilities:
*   **Mobility:** The robot moves via direct tele-operation from the controller inputs.
*   **Data Transmission:** The controller wirelessly sends text and data payloads to the robot's **LCD screen**.
*   **Feedback Interface:** Three physical buttons mounted on the robot's chassis allow users on the receiving end to trigger specific responses that are transmitted back to the operator's controller.

## Challenges we ran into
Establishing a reliable, low-latency, two-way wireless connection between the controller and the robot was our primary hurdle. We also had to carefully manage the ESP32's processing so it could seamlessly drive the motors while simultaneously listening for incoming LCD data and monitoring the physical buttons for hardware interrupts.

## Accomplishments that we're proud of
We successfully built a robust tele-operated platform and established a stable two-way communication loop. Getting the controller to smoothly drive the robot while maintaining real-time text transmission and button feedback was a major win for the team.

## What we learned
We deepened our understanding of wireless data transmission with the ESP32, motor control logic, and hardware interfacing. Specifically mapping remote signals to physical displays and handling physical button states.

## What's next for LASKO bot
We plan to re-integrate autonomous features like ultrasound sensors to assist with obstacle avoidance, upgrade the chassis for more rugged terrain, and expand the two-way communication capabilities.
OSHA V.
A compact, ESP32-powered search-and-rescue robot that uses WiFi to establish links between victims and rescue in hard-to-reach locations.
Updates

Leave feedback in the comments!
Log in or sign up for Devpost to join the conversation.