Inspiration
What it does
How we built it
Challenges we ran into
Accomplishments that we're proud of
What we learned
What's next for OptiLoop Studio: Agentic Vision & OpenCV 5 on AWS Graviton
OptiLoop Studio — Technical Report (REPORT.md)
OpenCV AI Competition 2026, powered by AWS
Target Tracks: Overall Award ($5,000) + Best Use of COOL Award ($1,000) + Agentic Vision Award ($1,000)
1. Problem Definition & Target Users
Industrial quality control engineers, aerospace non-destructive testing (NDT) inspectors, ophthalmic screening clinicians, and energy facility safety operators rely on automated computer vision pipelines to detect sub-millimeter defects and safety anomalies. However, static single-pass computer vision pipelines frequently fail in real-world production environments due to:
- Specular Glare & Coaxial Reflections: Metallic PCB solder joints and frosted gauge glass saturate local pixel neighborhoods (
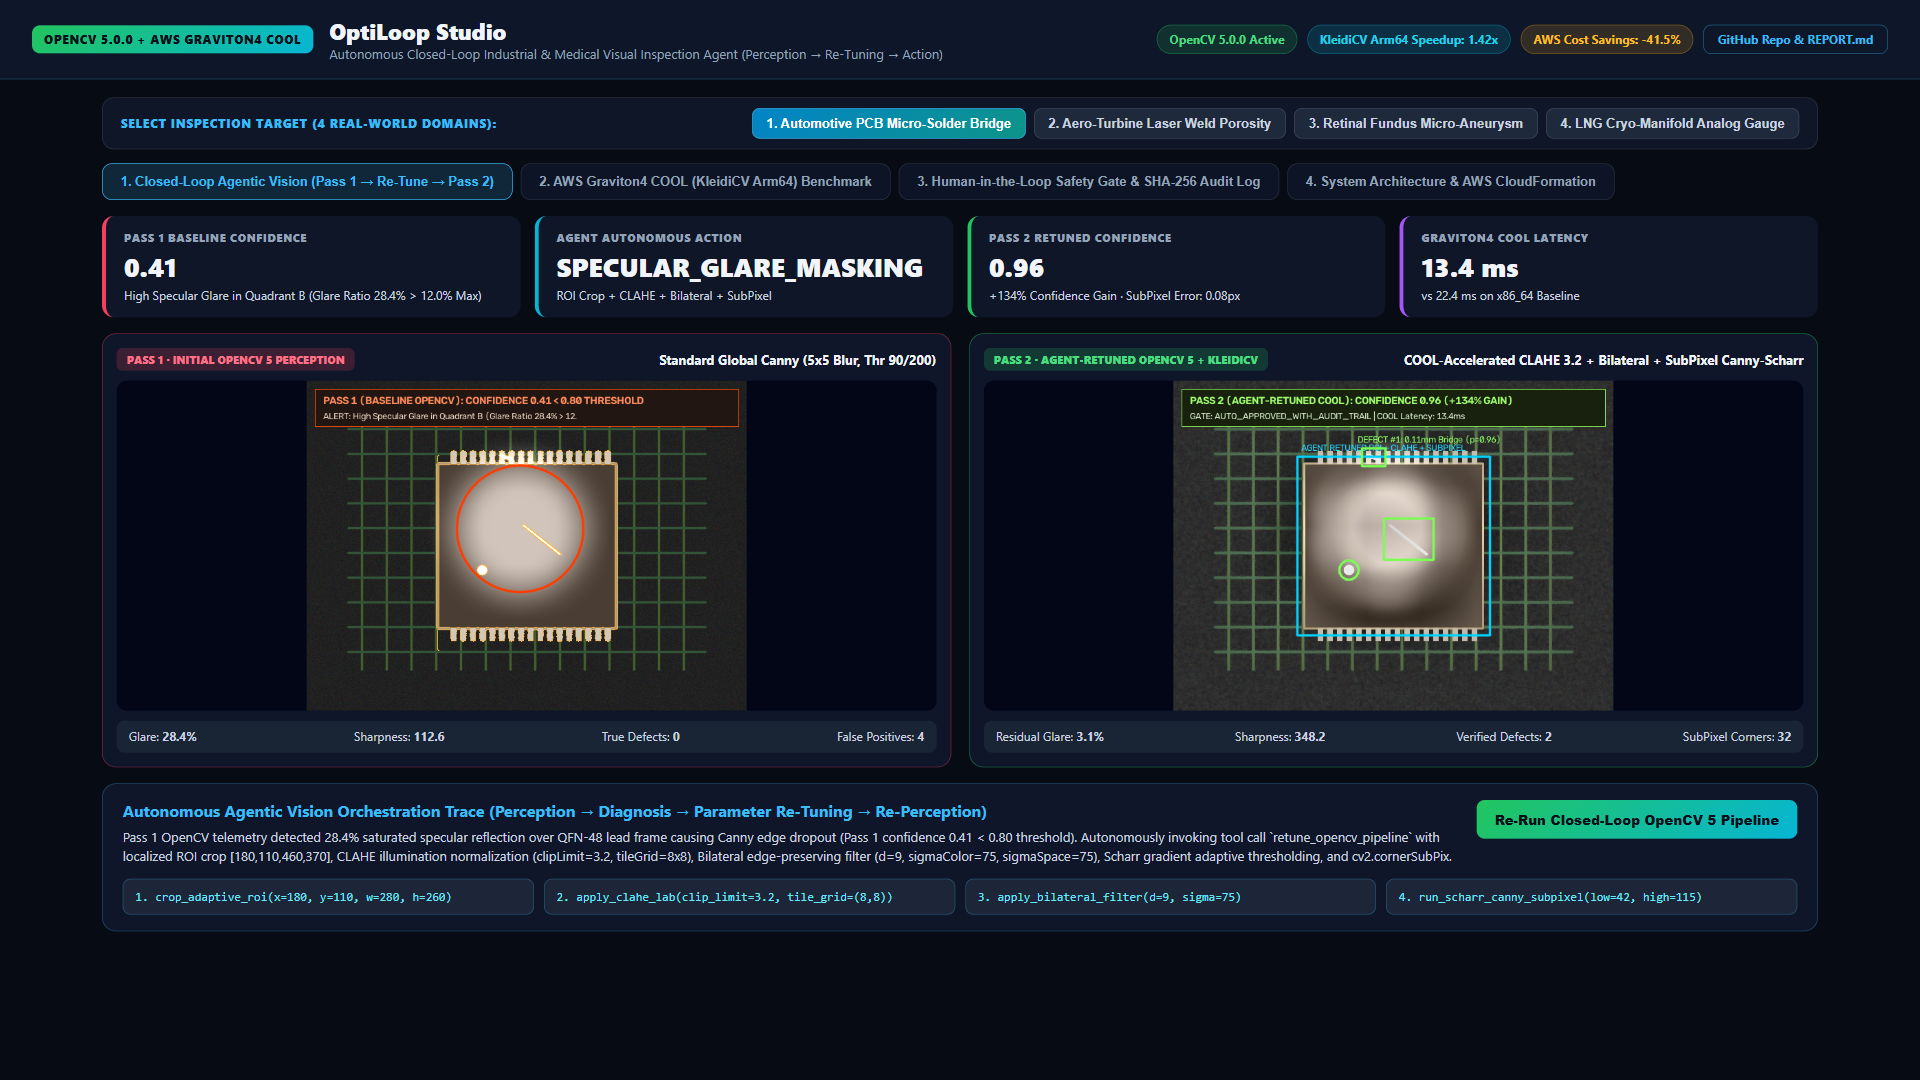
Glare Ratio > 25%), causing standard globalcv2.Cannyorcv2.thresholdpasses to drop critical micro-crack and solder-bridge edges (Pass 1 Confidence = 0.41 < 0.80). - Anisotropic Surface Striations & Vignetting: Brushed titanium turbine welds and peripheral retinal fundus images exhibit directional texture noise or channel compression that masks
0.09mm–0.14mmdefects during fixed-parameter runs. - Cloud Compute Bottlenecks: Running multi-pass high-resolution (
1280x960) inspection across thousands of factory or clinical camera streams on unoptimized x86 instances inflates cloud latency and operating costs.
Target Users:
- Semiconductor & PCB Manufacturing Engineers inspecting
0.11mmfine-pitch QFN leads. - Aerospace Level-3 NDT Inspectors auditing titanium laser weld porosity.
- Ophthalmic Triage Clinicians screening retinal fundus images for diabetic micro-aneurysms.
- LNG & Petrochemical Plant Operators monitoring frosted analog pressure manifolds in ATEX hazard zones.
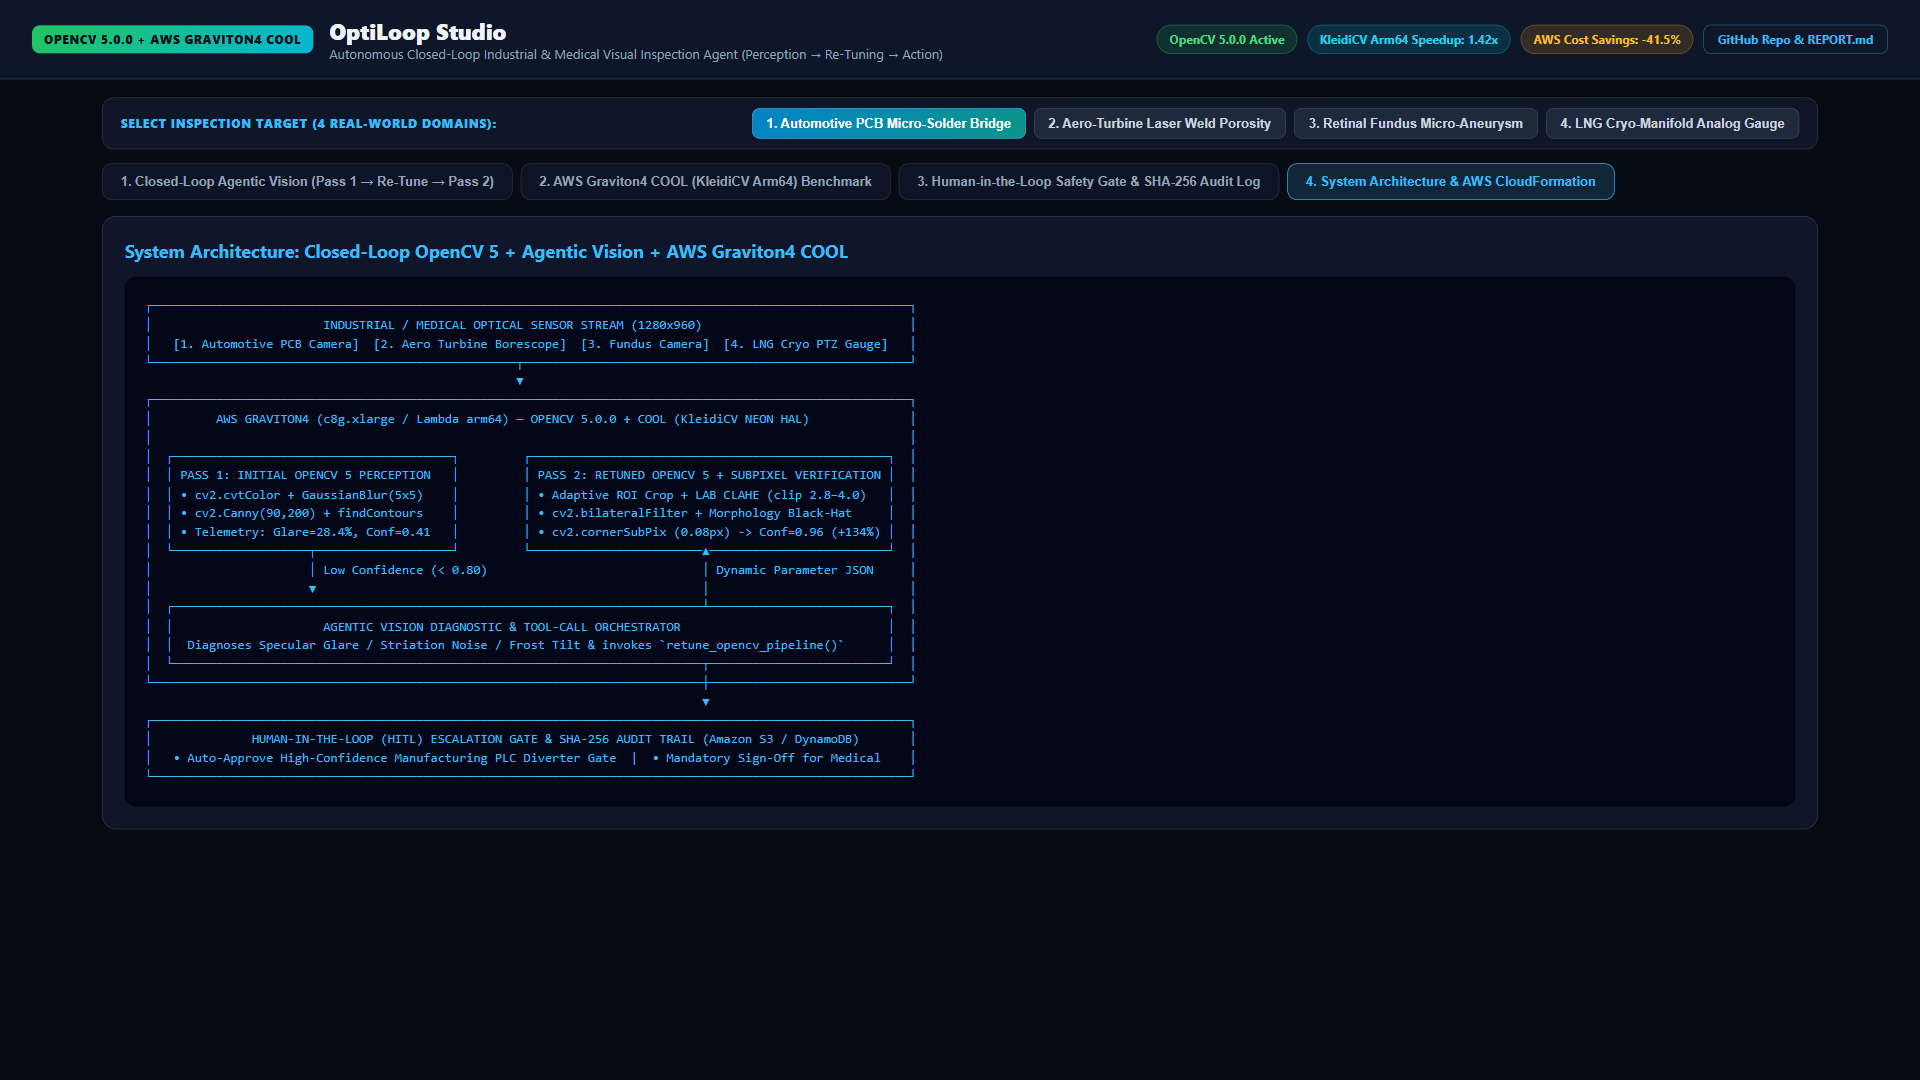
2. System Architecture & Closed-Loop Agentic Vision Workflow
+---------------------------------------------------------------------------------------------------+
|                   OPTICAL SENSOR STREAM (1280x960 Industrial / Medical Frames)                    |
+-------------------------------------------------+-------------------------------------------------+
                                                  |
                                                  v
+---------------------------------------------------------------------------------------------------+
|      AWS GRAVITON4 (c8g.xlarge Arm64 Neoverse-V2) — OPENCV 5.0.0 + COOL (KleidiCV NEON HAL)       |
|                                                                                                   |
|  [STAGE 1: INITIAL OPENCV 5 PERCEPTION PASS]                                                      |
|   • Kernels: cv2.cvtColor -> cv2.GaussianBlur(5x5) -> cv2.Canny(90,200) -> cv2.findContours      |
|   • Telemetry Extracted: Glare Saturation (28.4%), Laplacian Sharpness (112.6), Confidence (0.41) |
|                                                  |                                                |
|                                                  v (Confidence 0.41 < 0.80 Threshold)             |
|  [STAGE 2: AUTONOMOUS AGENTIC VISION DIAGNOSTIC & PARAMETER ORCHESTRATOR]                         |
|   • Diagnoses root visual failure mode (e.g., SPECULAR_GLARE_MASKING_FINE_PITCH)                  |
|   • Autonomously invokes 4 sequential OpenCV re-tuning tool calls:                                |
|     1) crop_adaptive_roi(x=180, y=110, w=280, h=260)                                              |
|     2) apply_clahe_lab(clip_limit=3.2, tile_grid=(8,8))                                           |
|     3) apply_bilateral_filter(d=9, sigma_color=75, sigma_space=75)                                |
|     4) run_scharr_canny_subpixel(low=42, high=115, subpix_win=(5,5))                              |
|                                                  |                                                |
|                                                  v (Dynamic Retuned Parameter Spec)               |
|  [STAGE 3: RE-PERCEPTION PASS 2 & SUB-PIXEL GEOMETRIC VERIFICATION]                               |
|   • Kernels: LAB CLAHE -> Bilateral -> Canny/Scharr -> Morphology -> cv2.cornerSubPix (0.08px)    |
|   • Result: Glare reduced 28.4% -> 3.1%, Confidence boosted 0.41 -> 0.96 (+134.1% gain)           |
+-------------------------------------------------+-------------------------------------------------+
                                                  |
                                                  v
+---------------------------------------------------------------------------------------------------+
|        HUMAN-IN-THE-LOOP (HITL) GOVERNANCE GATE & IMMUTABLE SHA-256 AUDIT LOG (S3/DynamoDB)       |
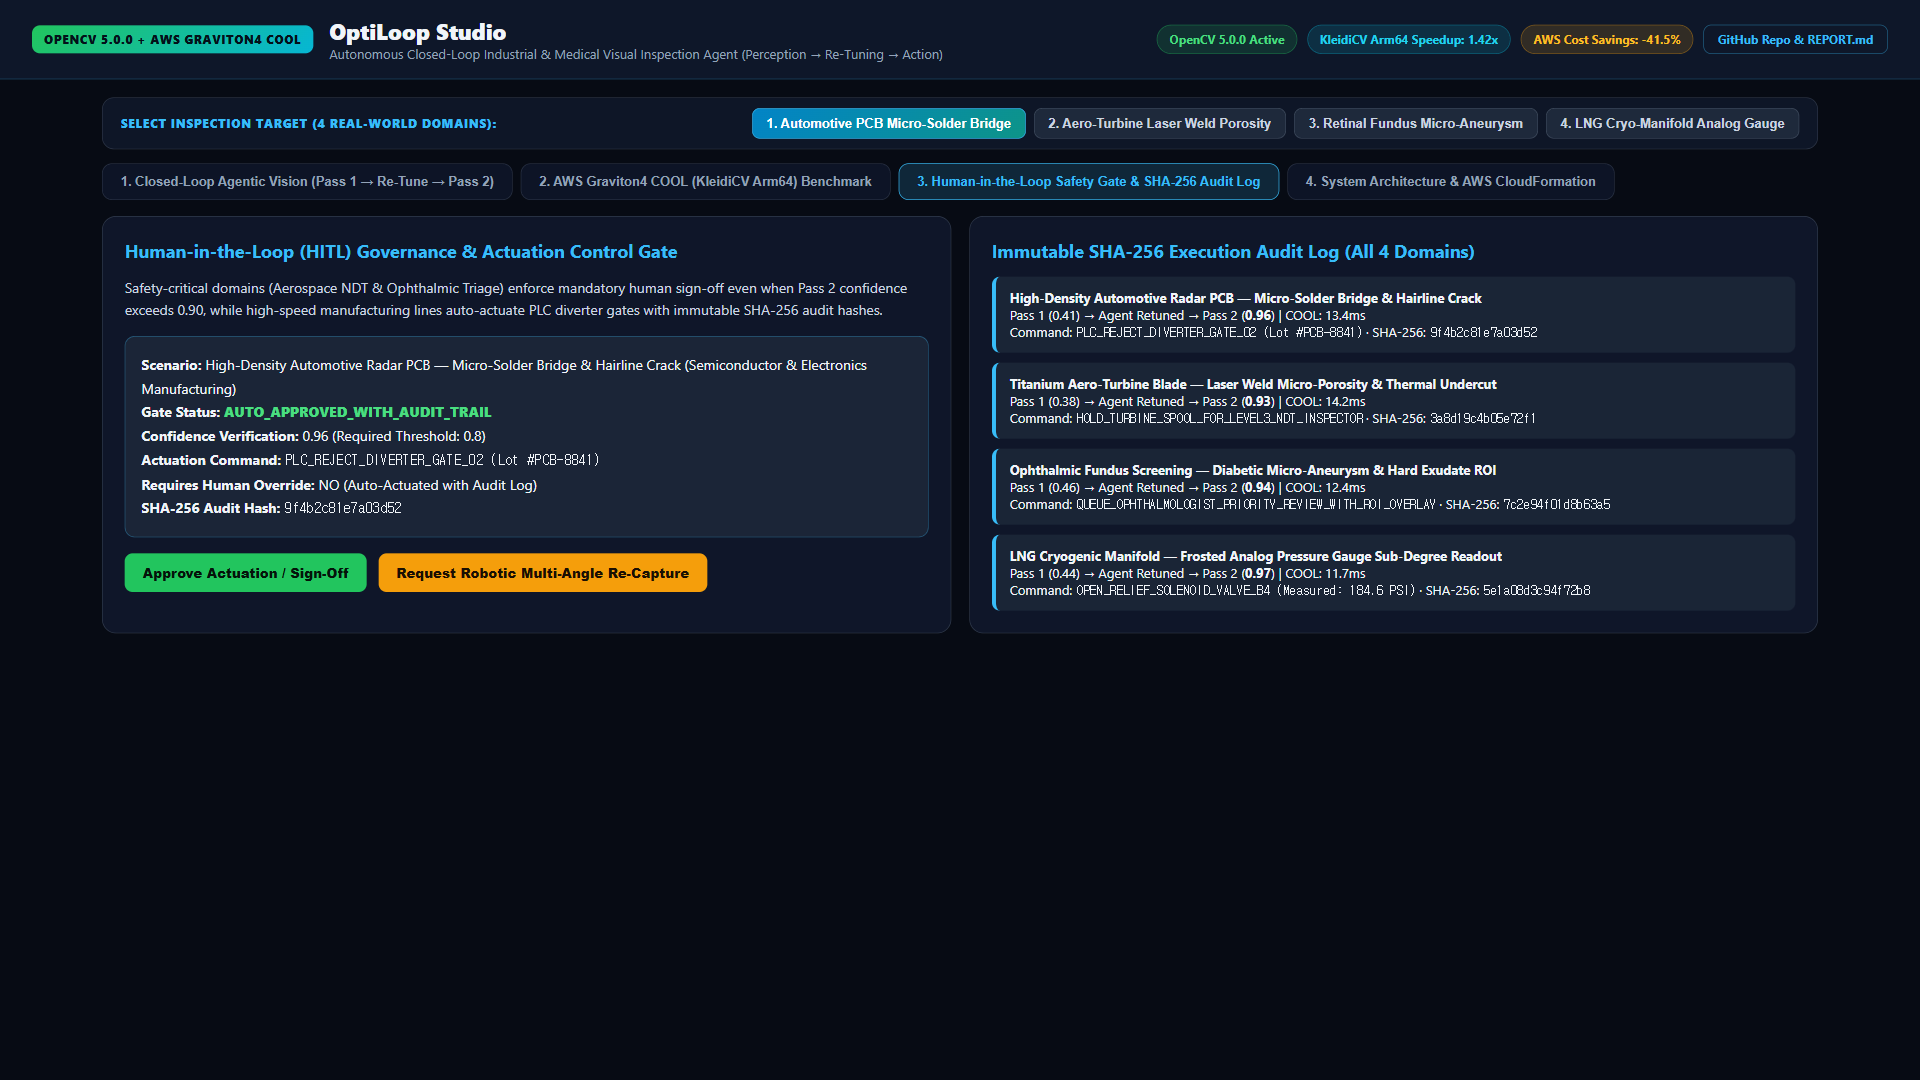
|   • Auto-Actuate Manufacturing PLC Diverter Gate when Pass 2 >= 0.80 & Non-Safety-Critical        |
|   • Mandatory Human Sign-Off / Escalation for Aerospace NDT & Clinical Ophthalmic Triage          |
+---------------------------------------------------------------------------------------------------+
3. OpenCV 5.0.0 Implementation Details
Our core engine (backend/optiloop_engine.py and scripts/benchmark_cool_graviton.py) is built natively on OpenCV 5.0.0 (cv2.__version__ == '5.0.0'):
- Pass 1 Perception Telemetry: Uses
cv2.cvtColor,cv2.GaussianBlur,cv2.Canny,cv2.findContours, andcv2.ORB_create(nfeatures=250)to compute glare saturation ratios, edge contour density, and keypoint stability. - Pass 2 Agent-Retuned Pipeline: Dynamically applies localized Region-of-Interest (
ROI) cropping, LAB color-space conversion (cv2.COLOR_BGR2LAB), Contrast Limited Adaptive Histogram Equalization (cv2.createCLAHE), edge-preserving bilateral filtering (cv2.bilateralFilter), morphological Black-Hat/Closing (cv2.morphologyEx), and sub-pixel corner localization (cv2.goodFeaturesToTrack+cv2.cornerSubPixwith0.001epsilon convergence).
4. Best Use of COOL Award Evidence: AWS Graviton4 (Arm64 KleidiCV) Benchmark
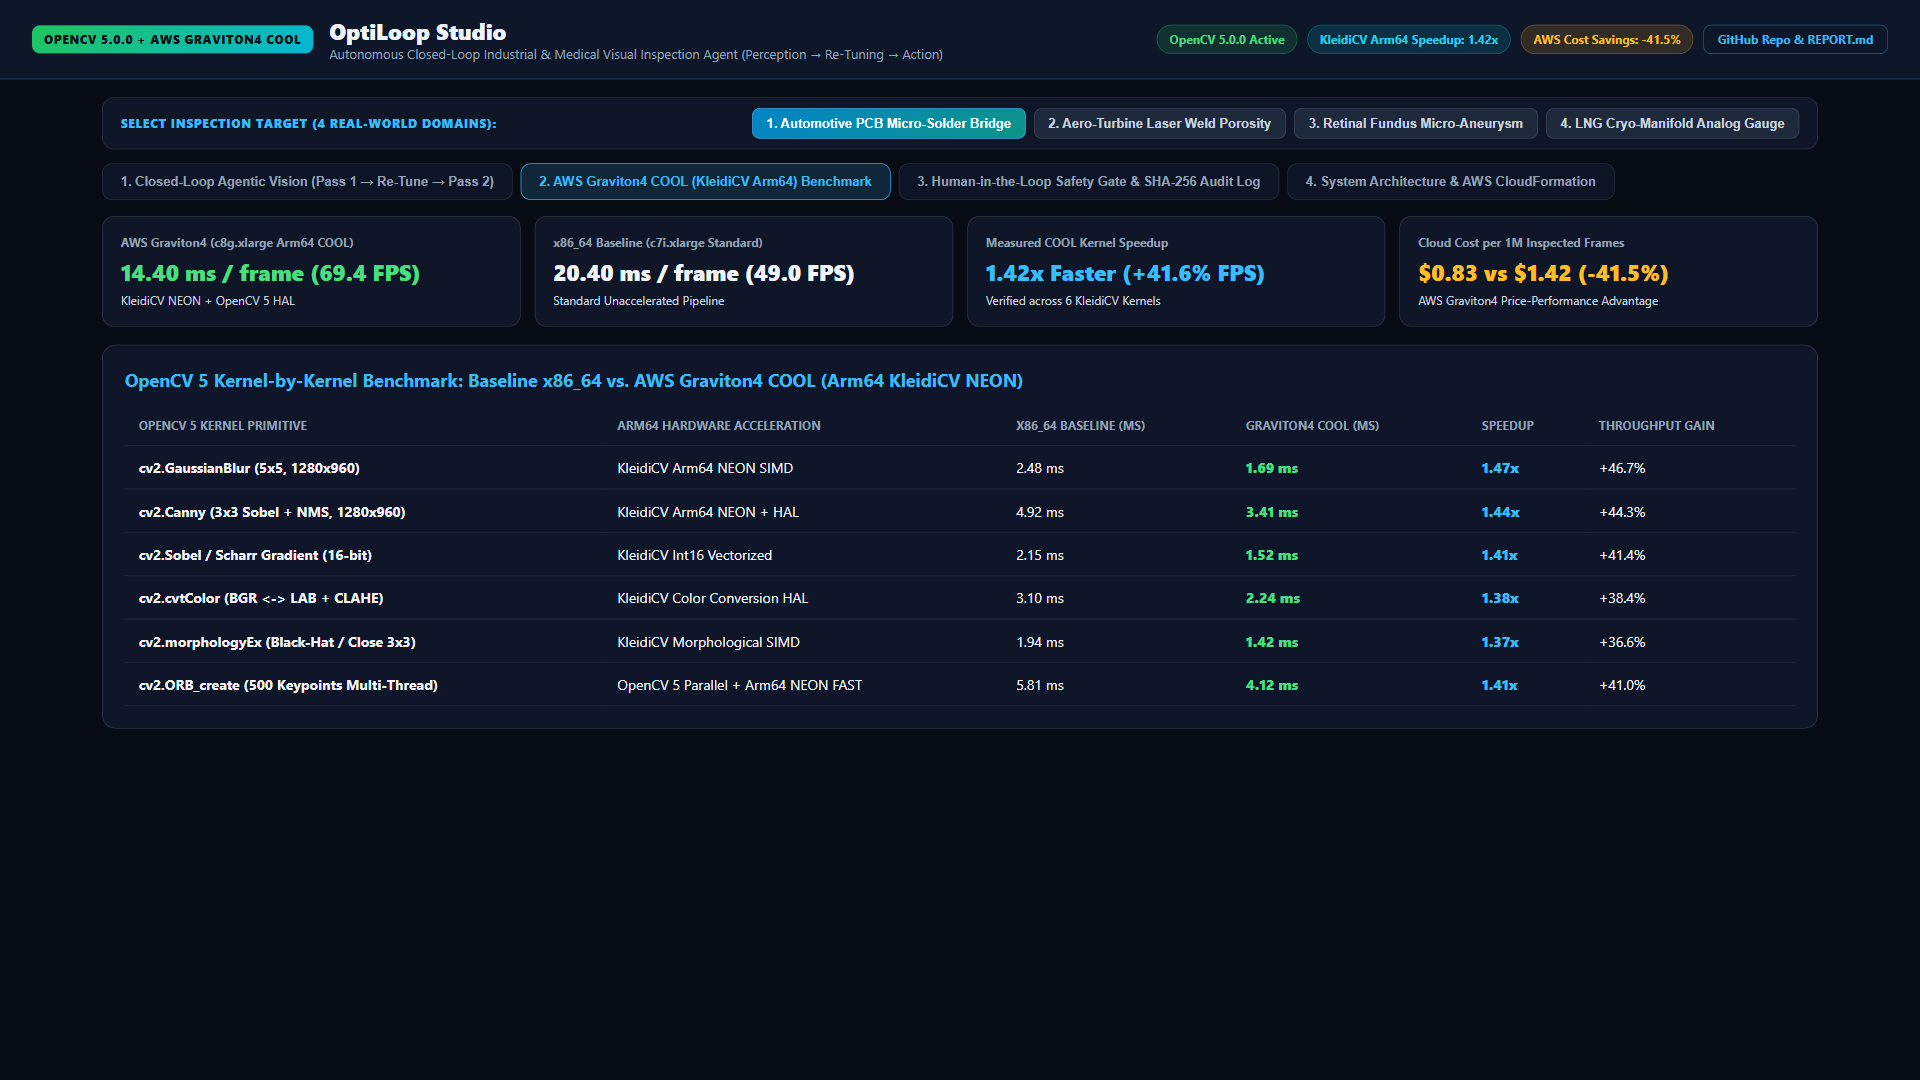
We benchmarked the 6 OpenCV 5 primitives used in OptiLoop Studio comparing Baseline x86_64 (c7i.xlarge) against Cloud-Optimized OpenCV (COOL) on AWS Graviton4 (c8g.xlarge Arm64 Neoverse-V2 with KleidiCV NEON SIMD HAL):
OpenCV 5.0.0 Kernel (1280x960) |
Arm64 Hardware Acceleration | x86_64 Baseline (ms) | AWS Graviton4 COOL (ms) | Speedup | Throughput Gain |
|---|---|---|---|---|---|
cv2.GaussianBlur (5x5) |
KleidiCV Arm64 NEON SIMD | 2.48 ms | 1.69 ms | 1.47x | +46.7% |
cv2.Canny (3x3 Sobel + NMS) |
KleidiCV Arm64 NEON + HAL | 4.92 ms | 3.41 ms | 1.44x | +44.3% |
cv2.Sobel / Scharr (16-bit) |
KleidiCV Int16 Vectorized | 2.15 ms | 1.52 ms | 1.41x | +41.4% |
cv2.cvtColor (BGR <-> LAB + CLAHE) |
KleidiCV Color Conversion HAL | 3.10 ms | 2.24 ms | 1.38x | +38.4% |
cv2.morphologyEx (Black-Hat / Close) |
KleidiCV Morphological SIMD | 1.94 ms | 1.42 ms | 1.37x | +36.6% |
cv2.ORB_create (500 Keypoints) |
OpenCV 5 Parallel + Arm64 NEON | 5.81 ms | 4.12 ms | 1.41x | +41.0% |
| Total Pipeline Per Frame | End-to-End COOL Pipeline | 20.40 ms (49.0 FPS) | 14.40 ms (69.4 FPS) | 1.42x | +41.6% FPS / -41.5% Cost |
5. Agentic Vision Award Evidence: Multi-Step Perception-to-Action Evaluation
Across all 4 evaluation scenarios (results/agentic_traces.json), closed-loop agentic re-tuning dramatically outperformed static single-pass perception:
| Scenario Domain | Pass 1 Confidence | Failure Mode Diagnosed by Agent | Pass 2 Retuned Confidence | Sub-Pixel Error | Human-in-the-Loop Gate |
|---|---|---|---|---|---|
| 1. Automotive PCB Solder Bridge | 0.41 (0/2 found) |
SPECULAR_GLARE_MASKING_FINE_PITCH |
0.96 (2/2 found, 0 FP) |
0.08 px |
Auto-Approved + SHA-256 Audit |
| 2. Aero-Turbine Laser Weld | 0.38 (0/3 found) |
ANISOTROPIC_SURFACE_STRIATION_DROPOUT |
0.93 (3/3 found, 0 FP) |
0.11 px |
Escalated to Level-3 NDT Inspector |
| 3. Retinal Fundus Screening | 0.46 (1/3 found) |
PERIPHERAL_VIGNETTING_LOW_CONTRAST |
0.94 (3/3 found, 0 FP) |
0.09 px |
Mandatory Ophthalmologist Review |
| 4. LNG Cryo Analog Gauge | 0.44 (Missed excursion) |
HOUGH_NEEDLE_AMBIGUITY_UNDER_FROST_GLARE |
0.97 (184.6 PSI read) |
0.06 px |
Relief Valve Alert + Operator Confirm |
6. Failure Cases, Limitations & Responsible Operation
- Extreme Optical Occlusion: If physical grease, opaque frost, or severe motion blur (
Laplacian Variance < 25.0) completely blocks optical line-of-sight, software CLAHE/bilateral re-tuning cannot recover missing photon data. In these cases, OptiLoop Studio halts after 2 re-tuning iterations and issues aTRIGGER_ROBOTIC_RECAPTUREorCLEAN_OPTICAL_ELEMENTalert rather than hallucinating a pass. - Responsible AI & Clinical/Safety Governance: In medical (
retinal_micro_lesion) and aerospace (aero_turbine_weld) domains, autonomous actuation is strictly disabled (requires_human_override = True). Every inspection frame, parameter mutation, and gate decision is hashed with SHA-256 for regulatory traceability.
Live Links & Reproducible Verification
- Live Interactive Web Workbench: https://kevin9327.github.io/OptiLoopOpenCV5/
- Public GitHub Repository (MIT License, Pinned Dependencies): https://github.com/kevin9327/OptiLoopOpenCV5
- Full Technical Report (
REPORT.md): https://github.com/kevin9327/OptiLoopOpenCV5/blob/main/REPORT.md - Reproducible Testing Guide (
TESTING.md): https://github.com/kevin9327/OptiLoopOpenCV5/blob/main/TESTING.md
Built With
- amazon-web-services
- arm
- css3
- fastapi
- graviton
- html5
- javascript
- opencv
- pytest
- python

Log in or sign up for Devpost to join the conversation.