Inspiration
Wildlife-vehicle collisions put both drivers and animals at risk. We wanted to build a system that could predict dangerous crossings before accidents happen.
What it does
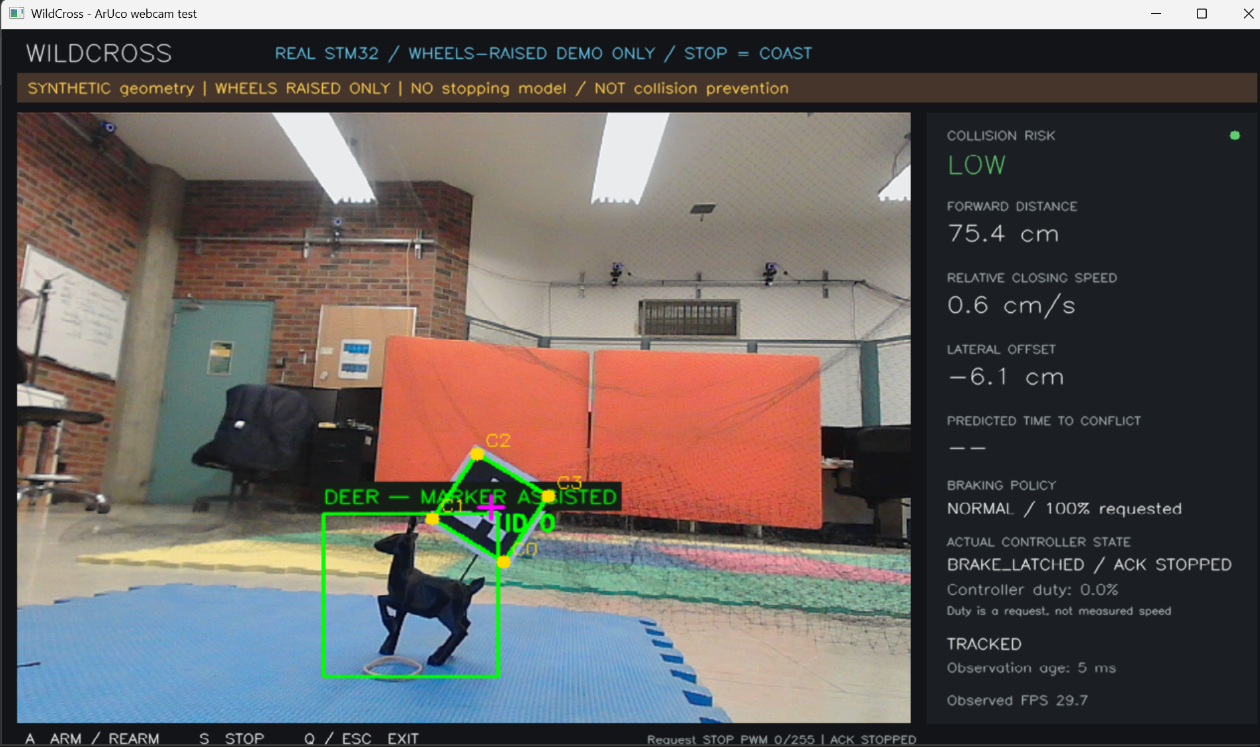
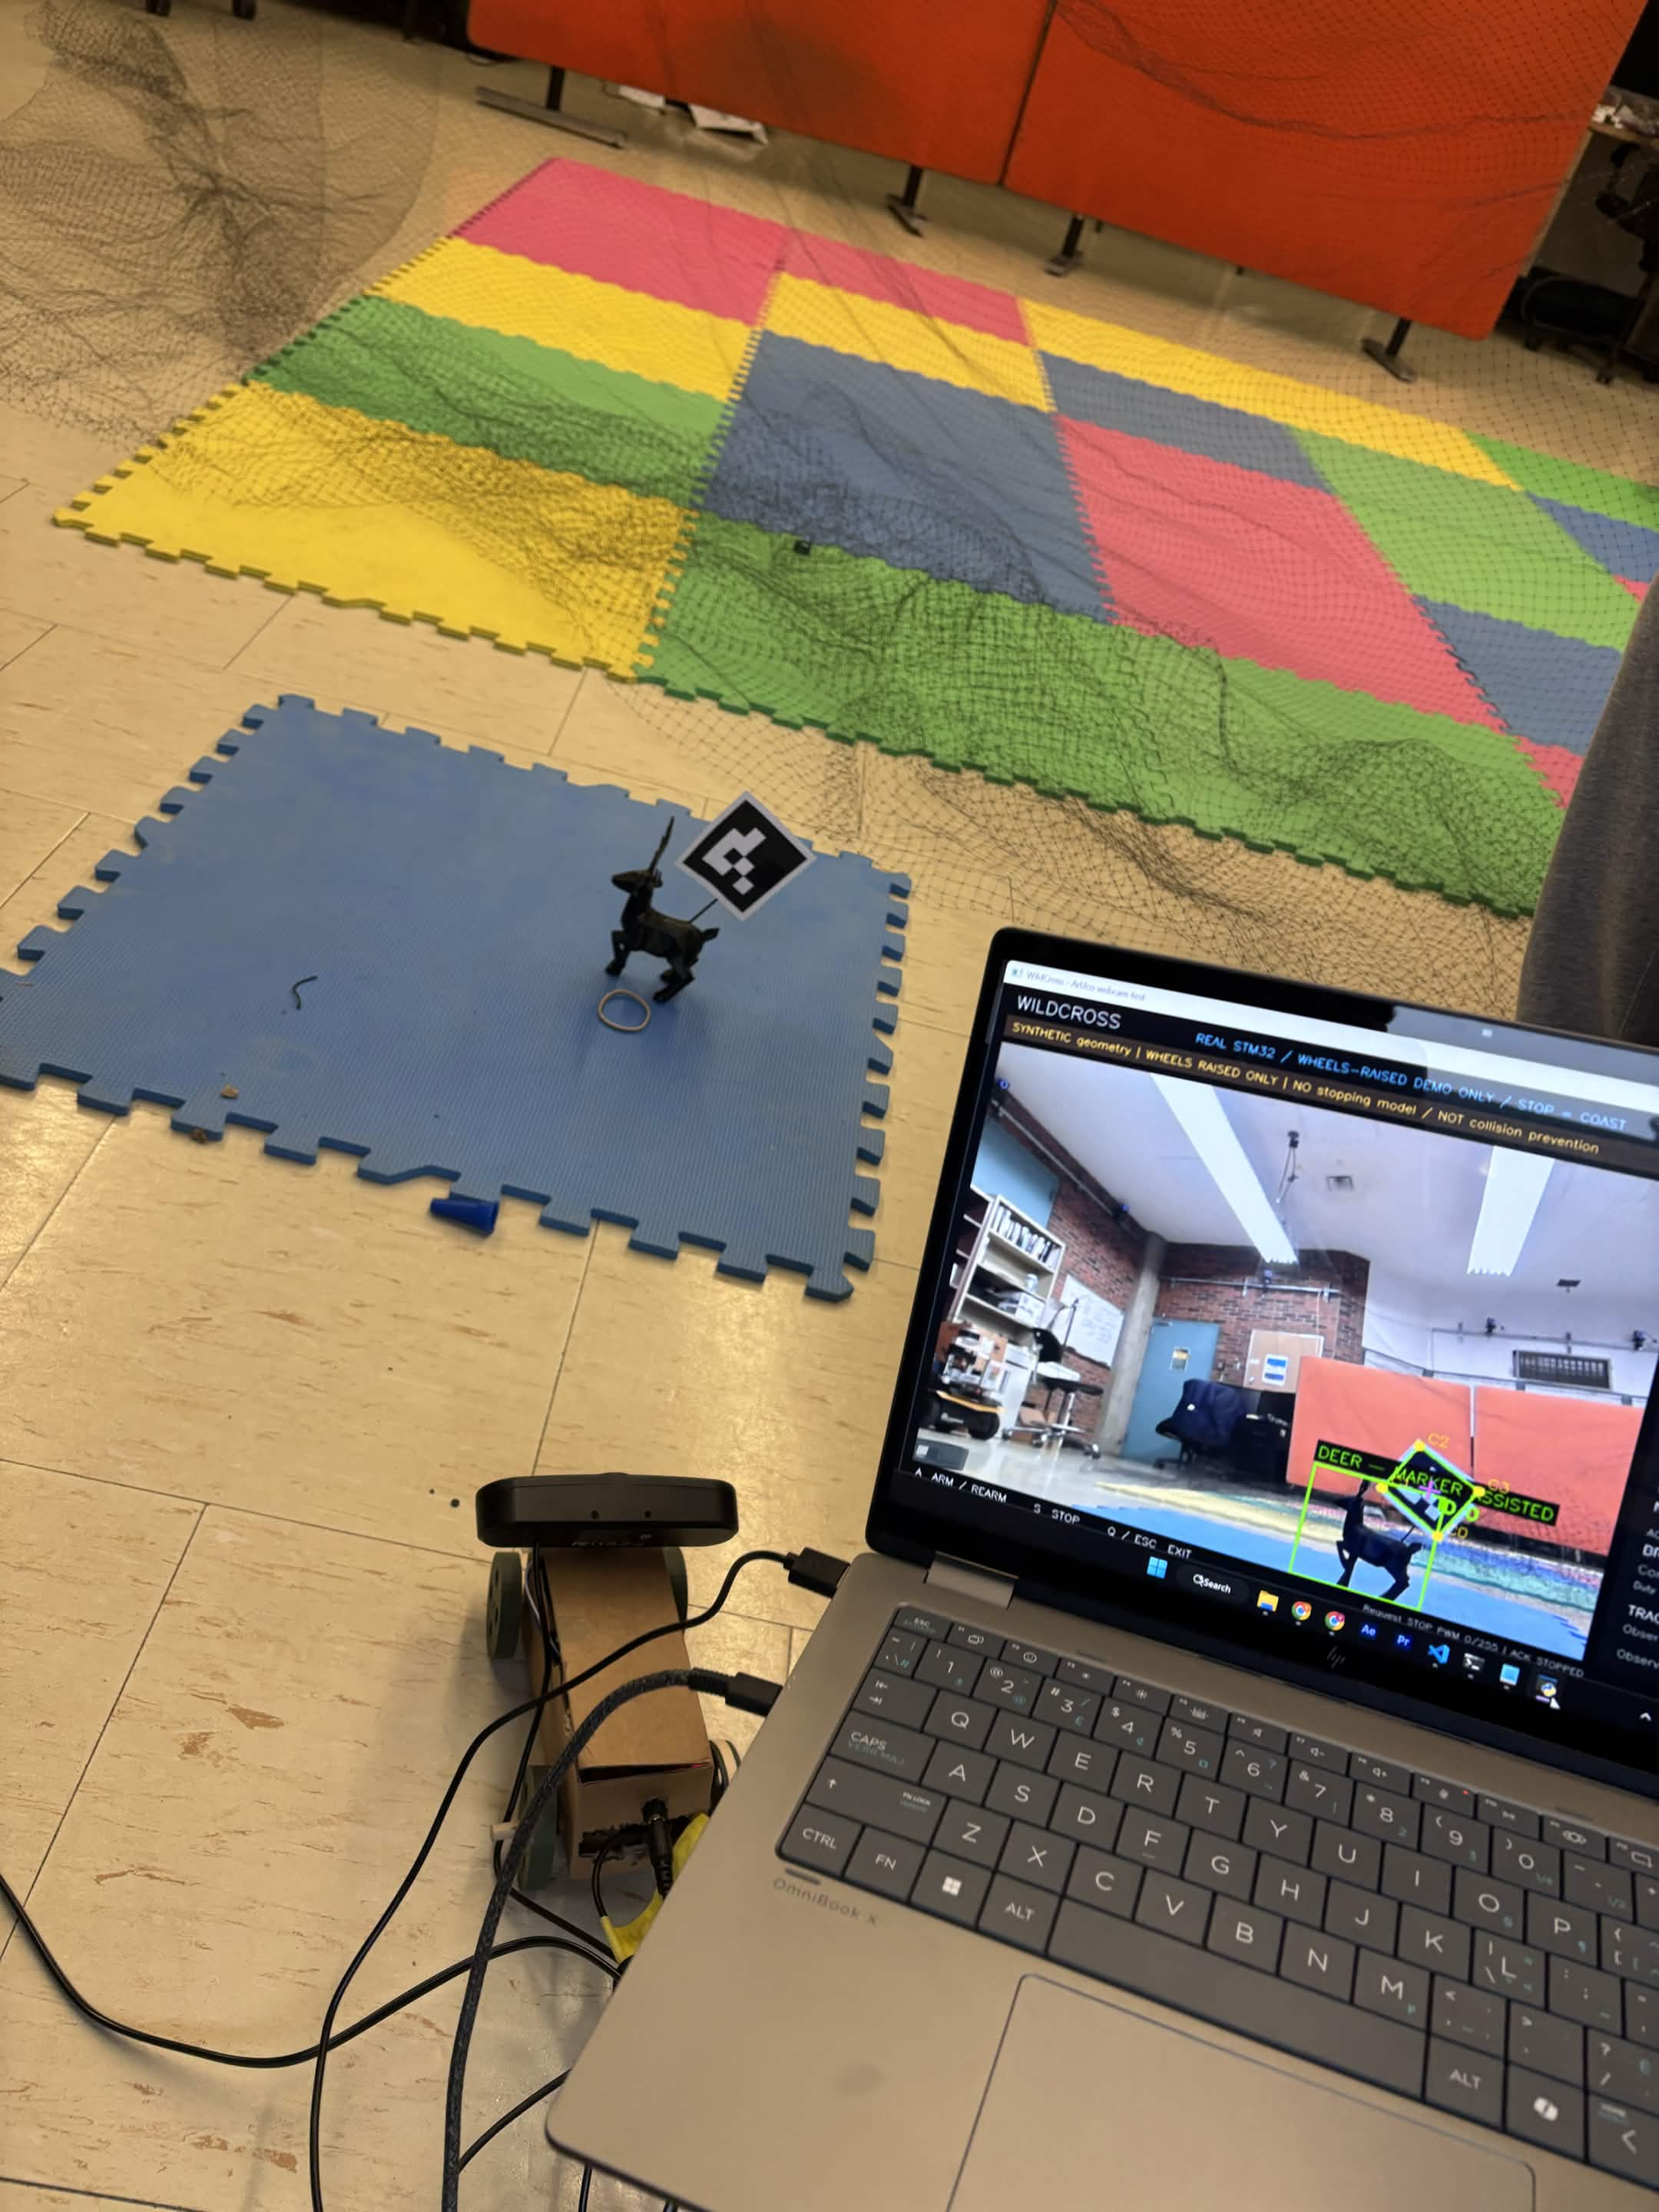
Oh Deer! uses computer vision to track a potential hazard, predict collision risk, and automatically send commands to slow or stop a vehicle.
How we built it
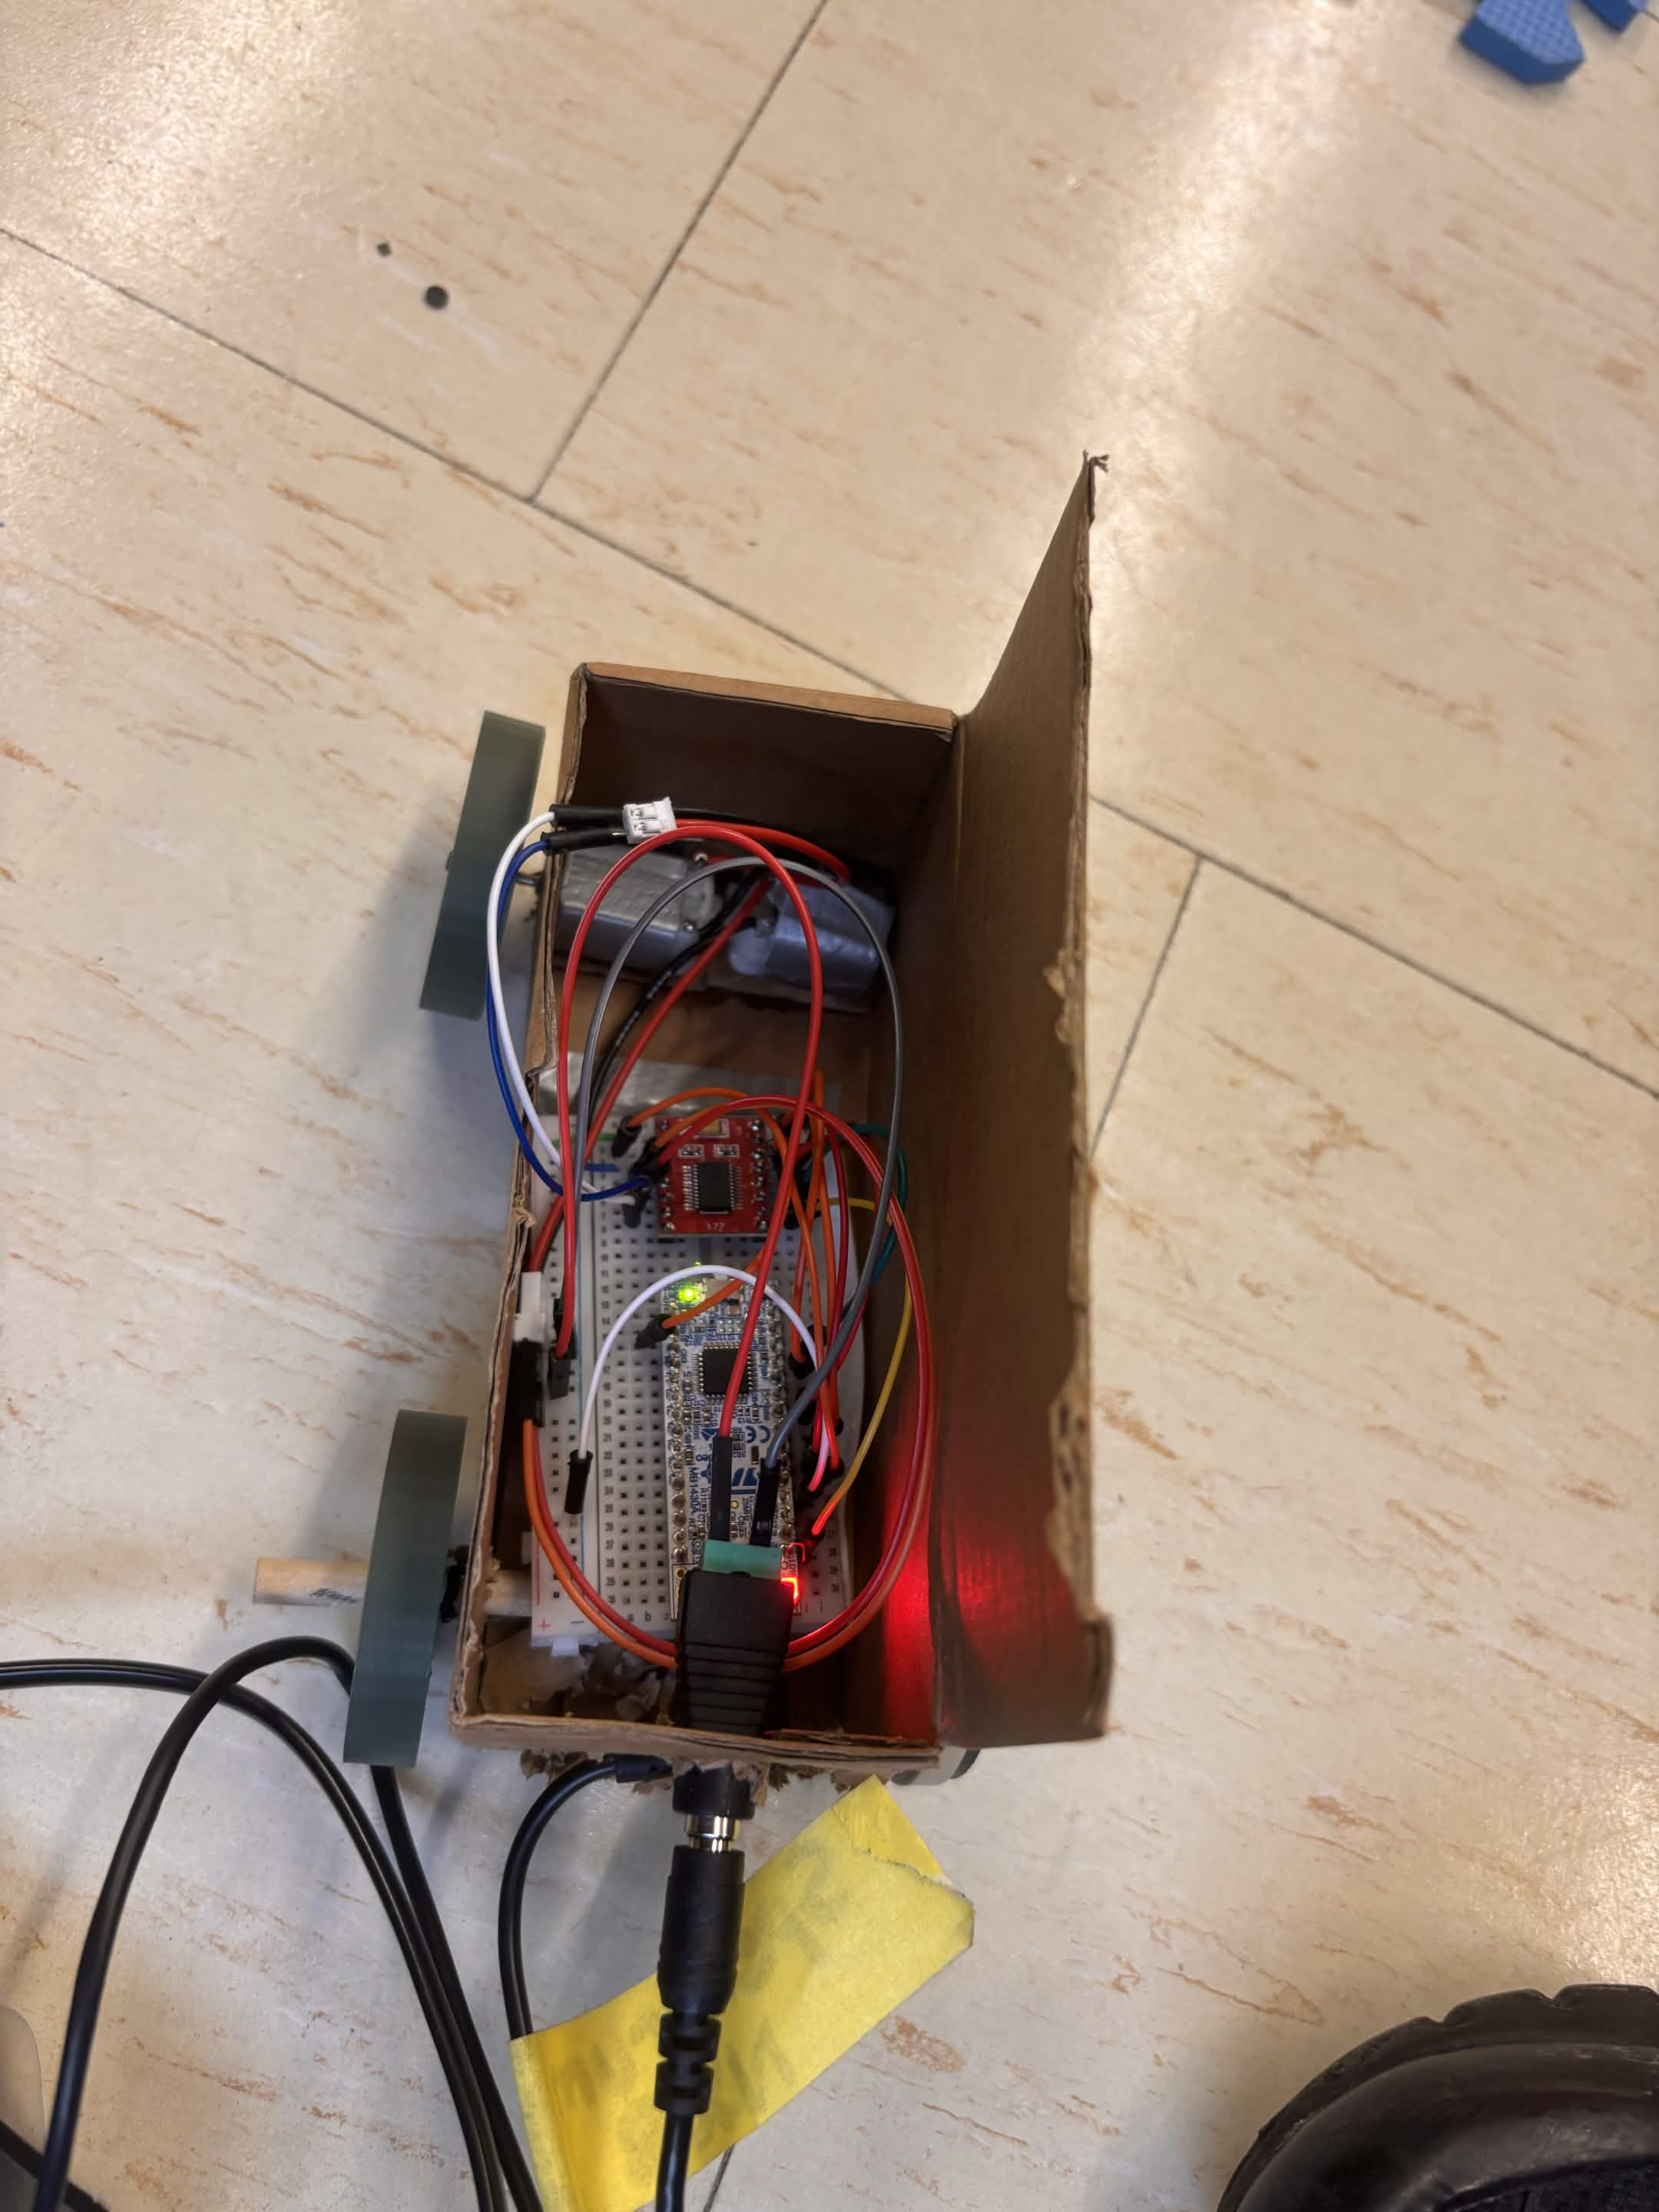
We used Python, OpenCV, ArUco markers, and collision-prediction algorithms, connecting everything to an STM32 microcontroller and motor driver on a 3D-printed car.
Challenges we ran into
We faced motor torque limitations, power and wiring issues, unreliable camera tracking, and difficulties synchronizing real-time predictions with motor commands.
Accomplishments that we're proud of
We built a working camera-to-motor control pipeline, calibrated our camera for distance estimation, and implemented automatic safety stops when tracking is lost.
What we learned
We gained hands-on experience with embedded systems, computer vision, serial communication, and the challenges of integrating software with physical hardware.
What's next for Oh Deer!
We plan to replace marker-assisted tracking with real wildlife detection, improve braking reliability, and test the system under realistic driving conditions.
