-
-
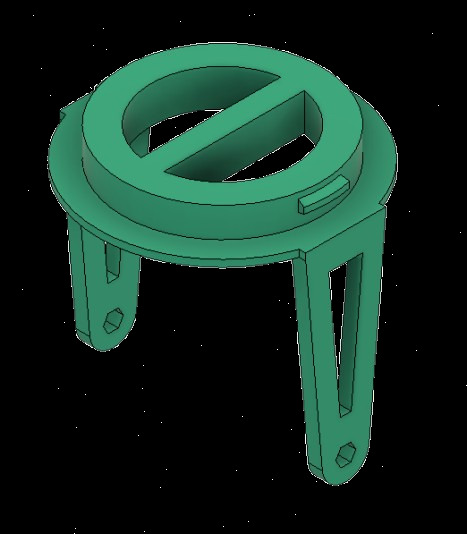
Arm
-
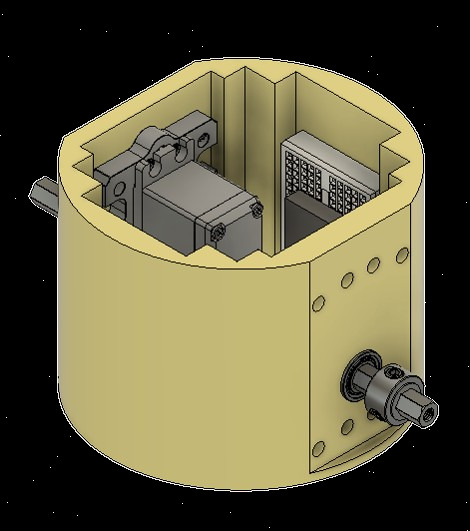
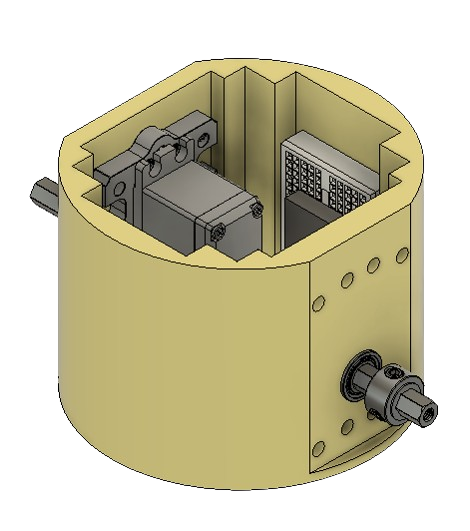
Servo-Sub Module
-
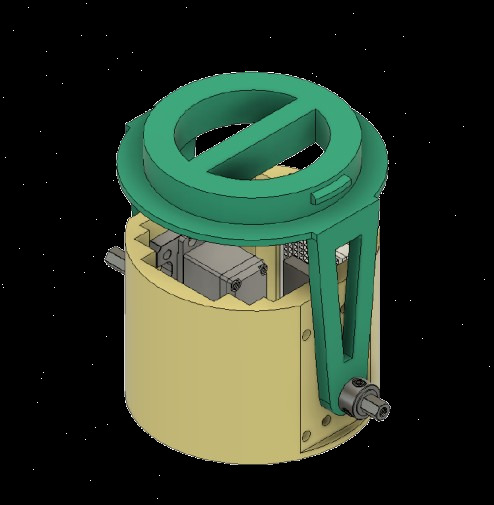
Modular Joints
-
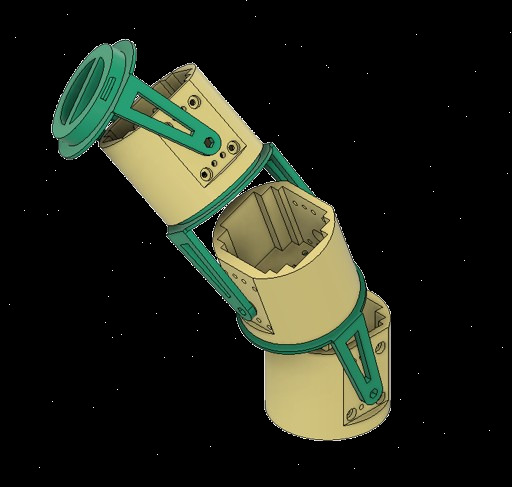
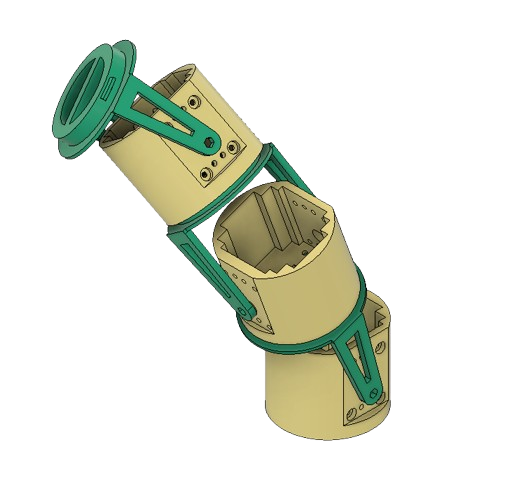
Complete customized robotic arm; Modular Joints in a chain
-
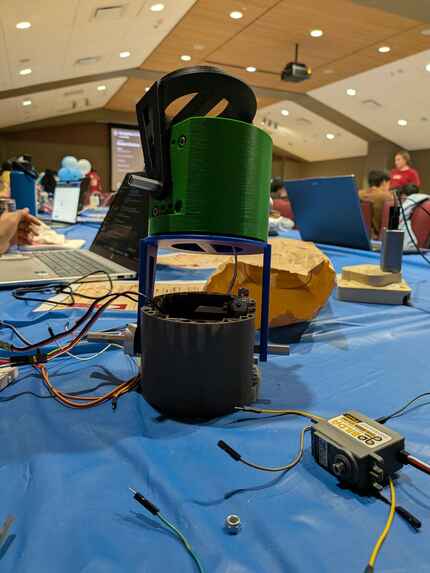
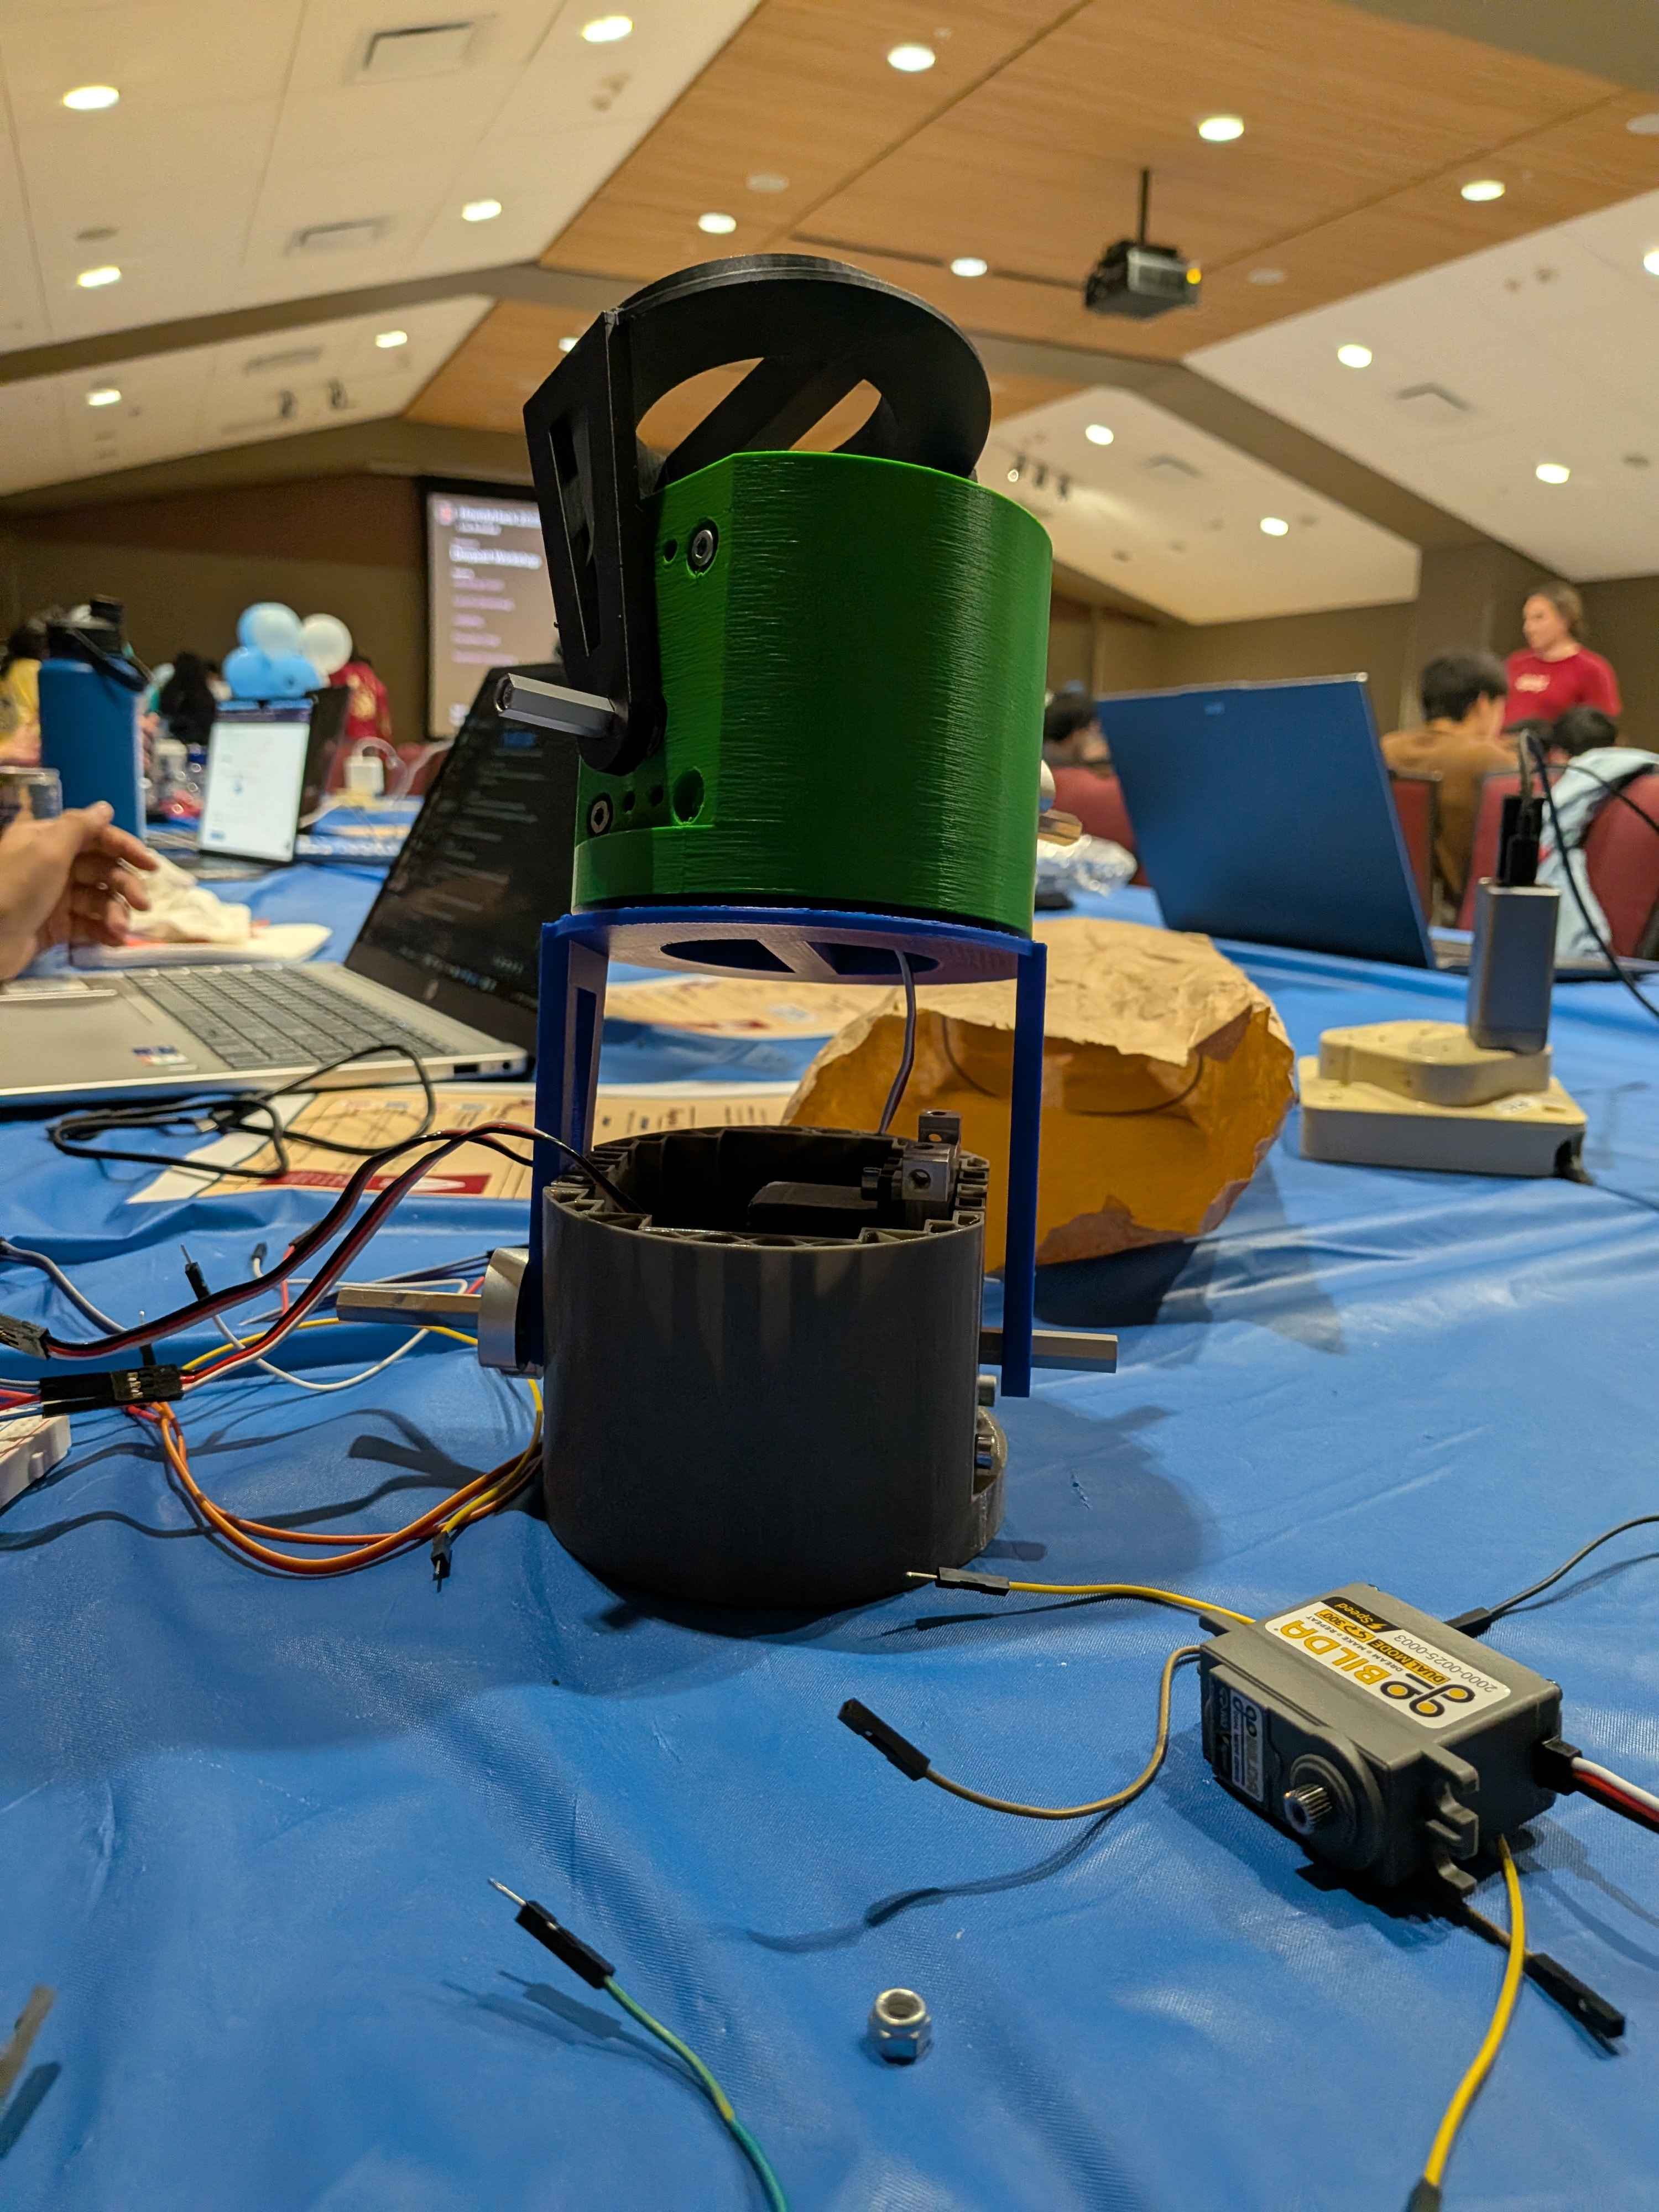
Partly assembled Modular Joints Arm [Real Image]
-
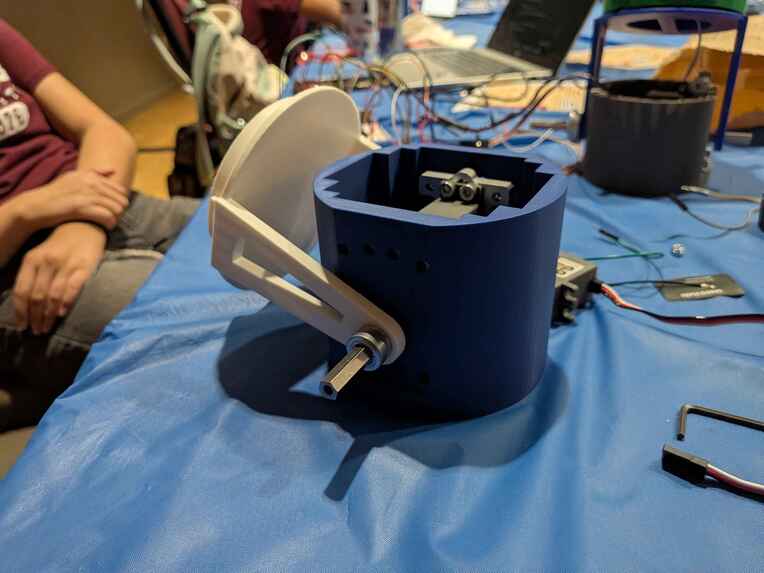
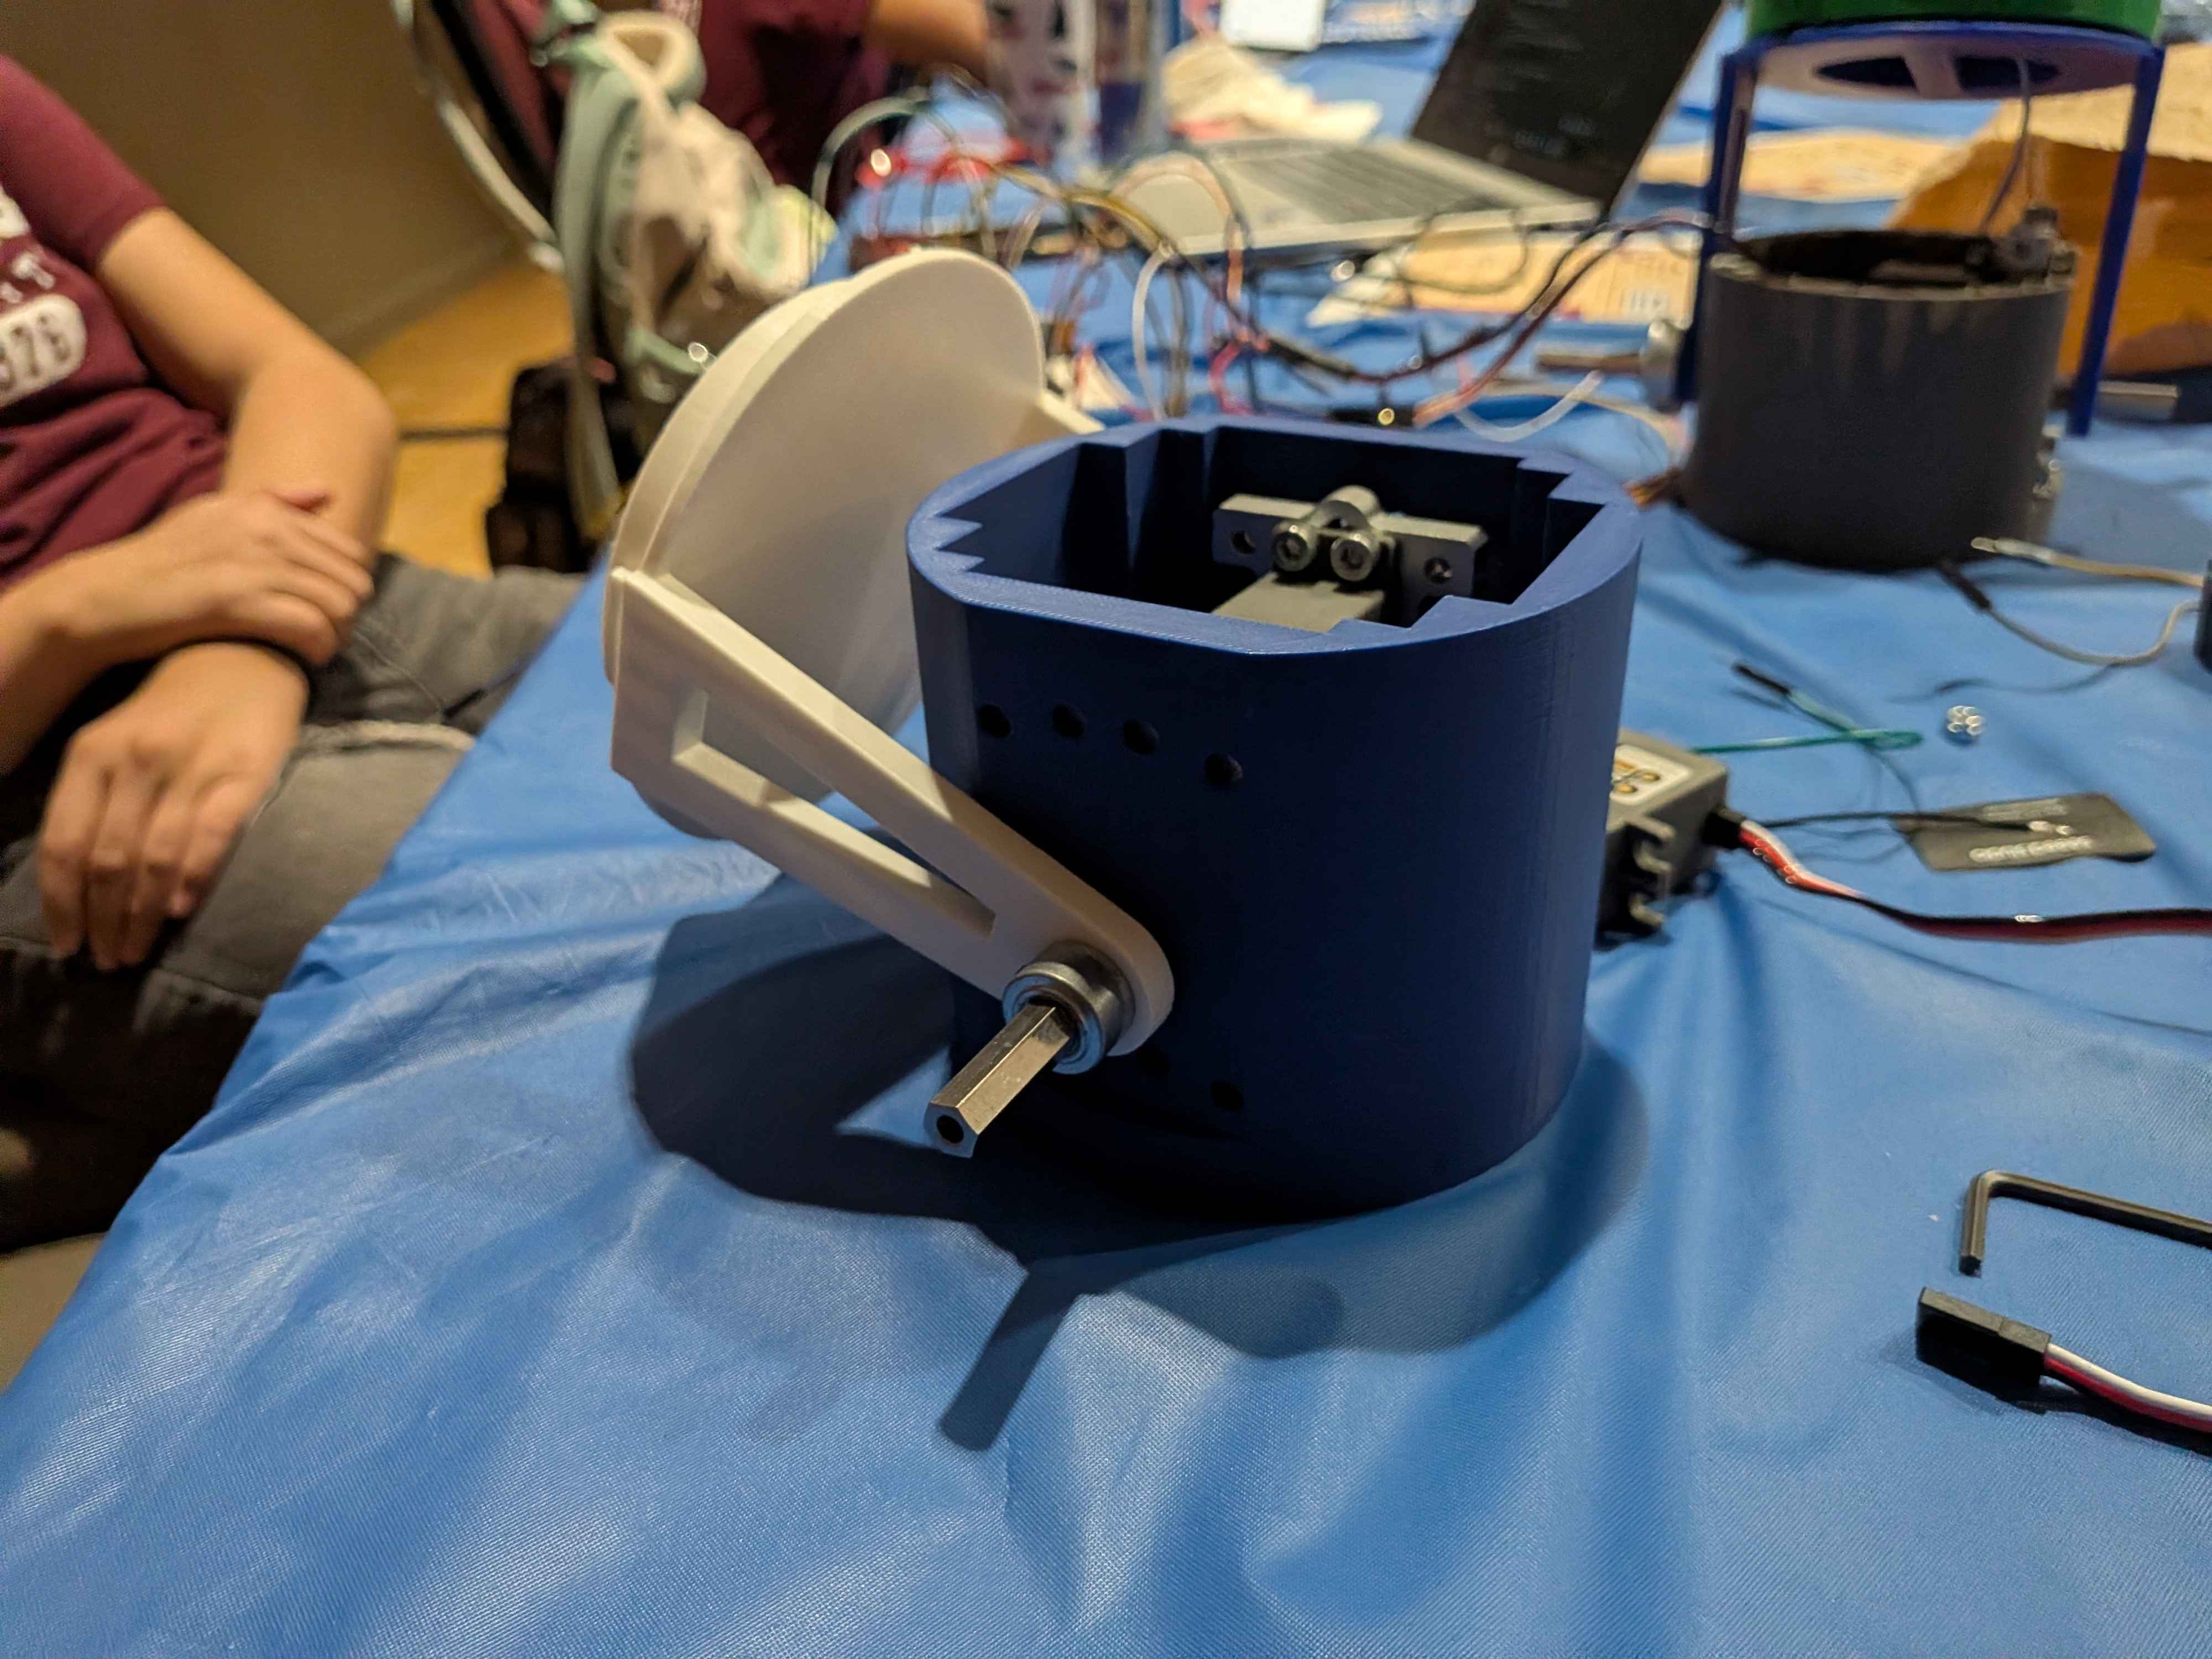
Modular Joint [Real Image]
-
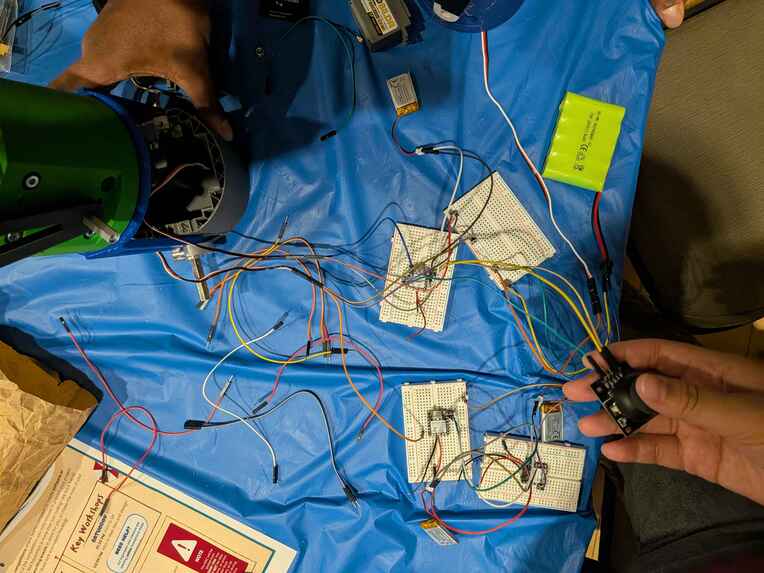
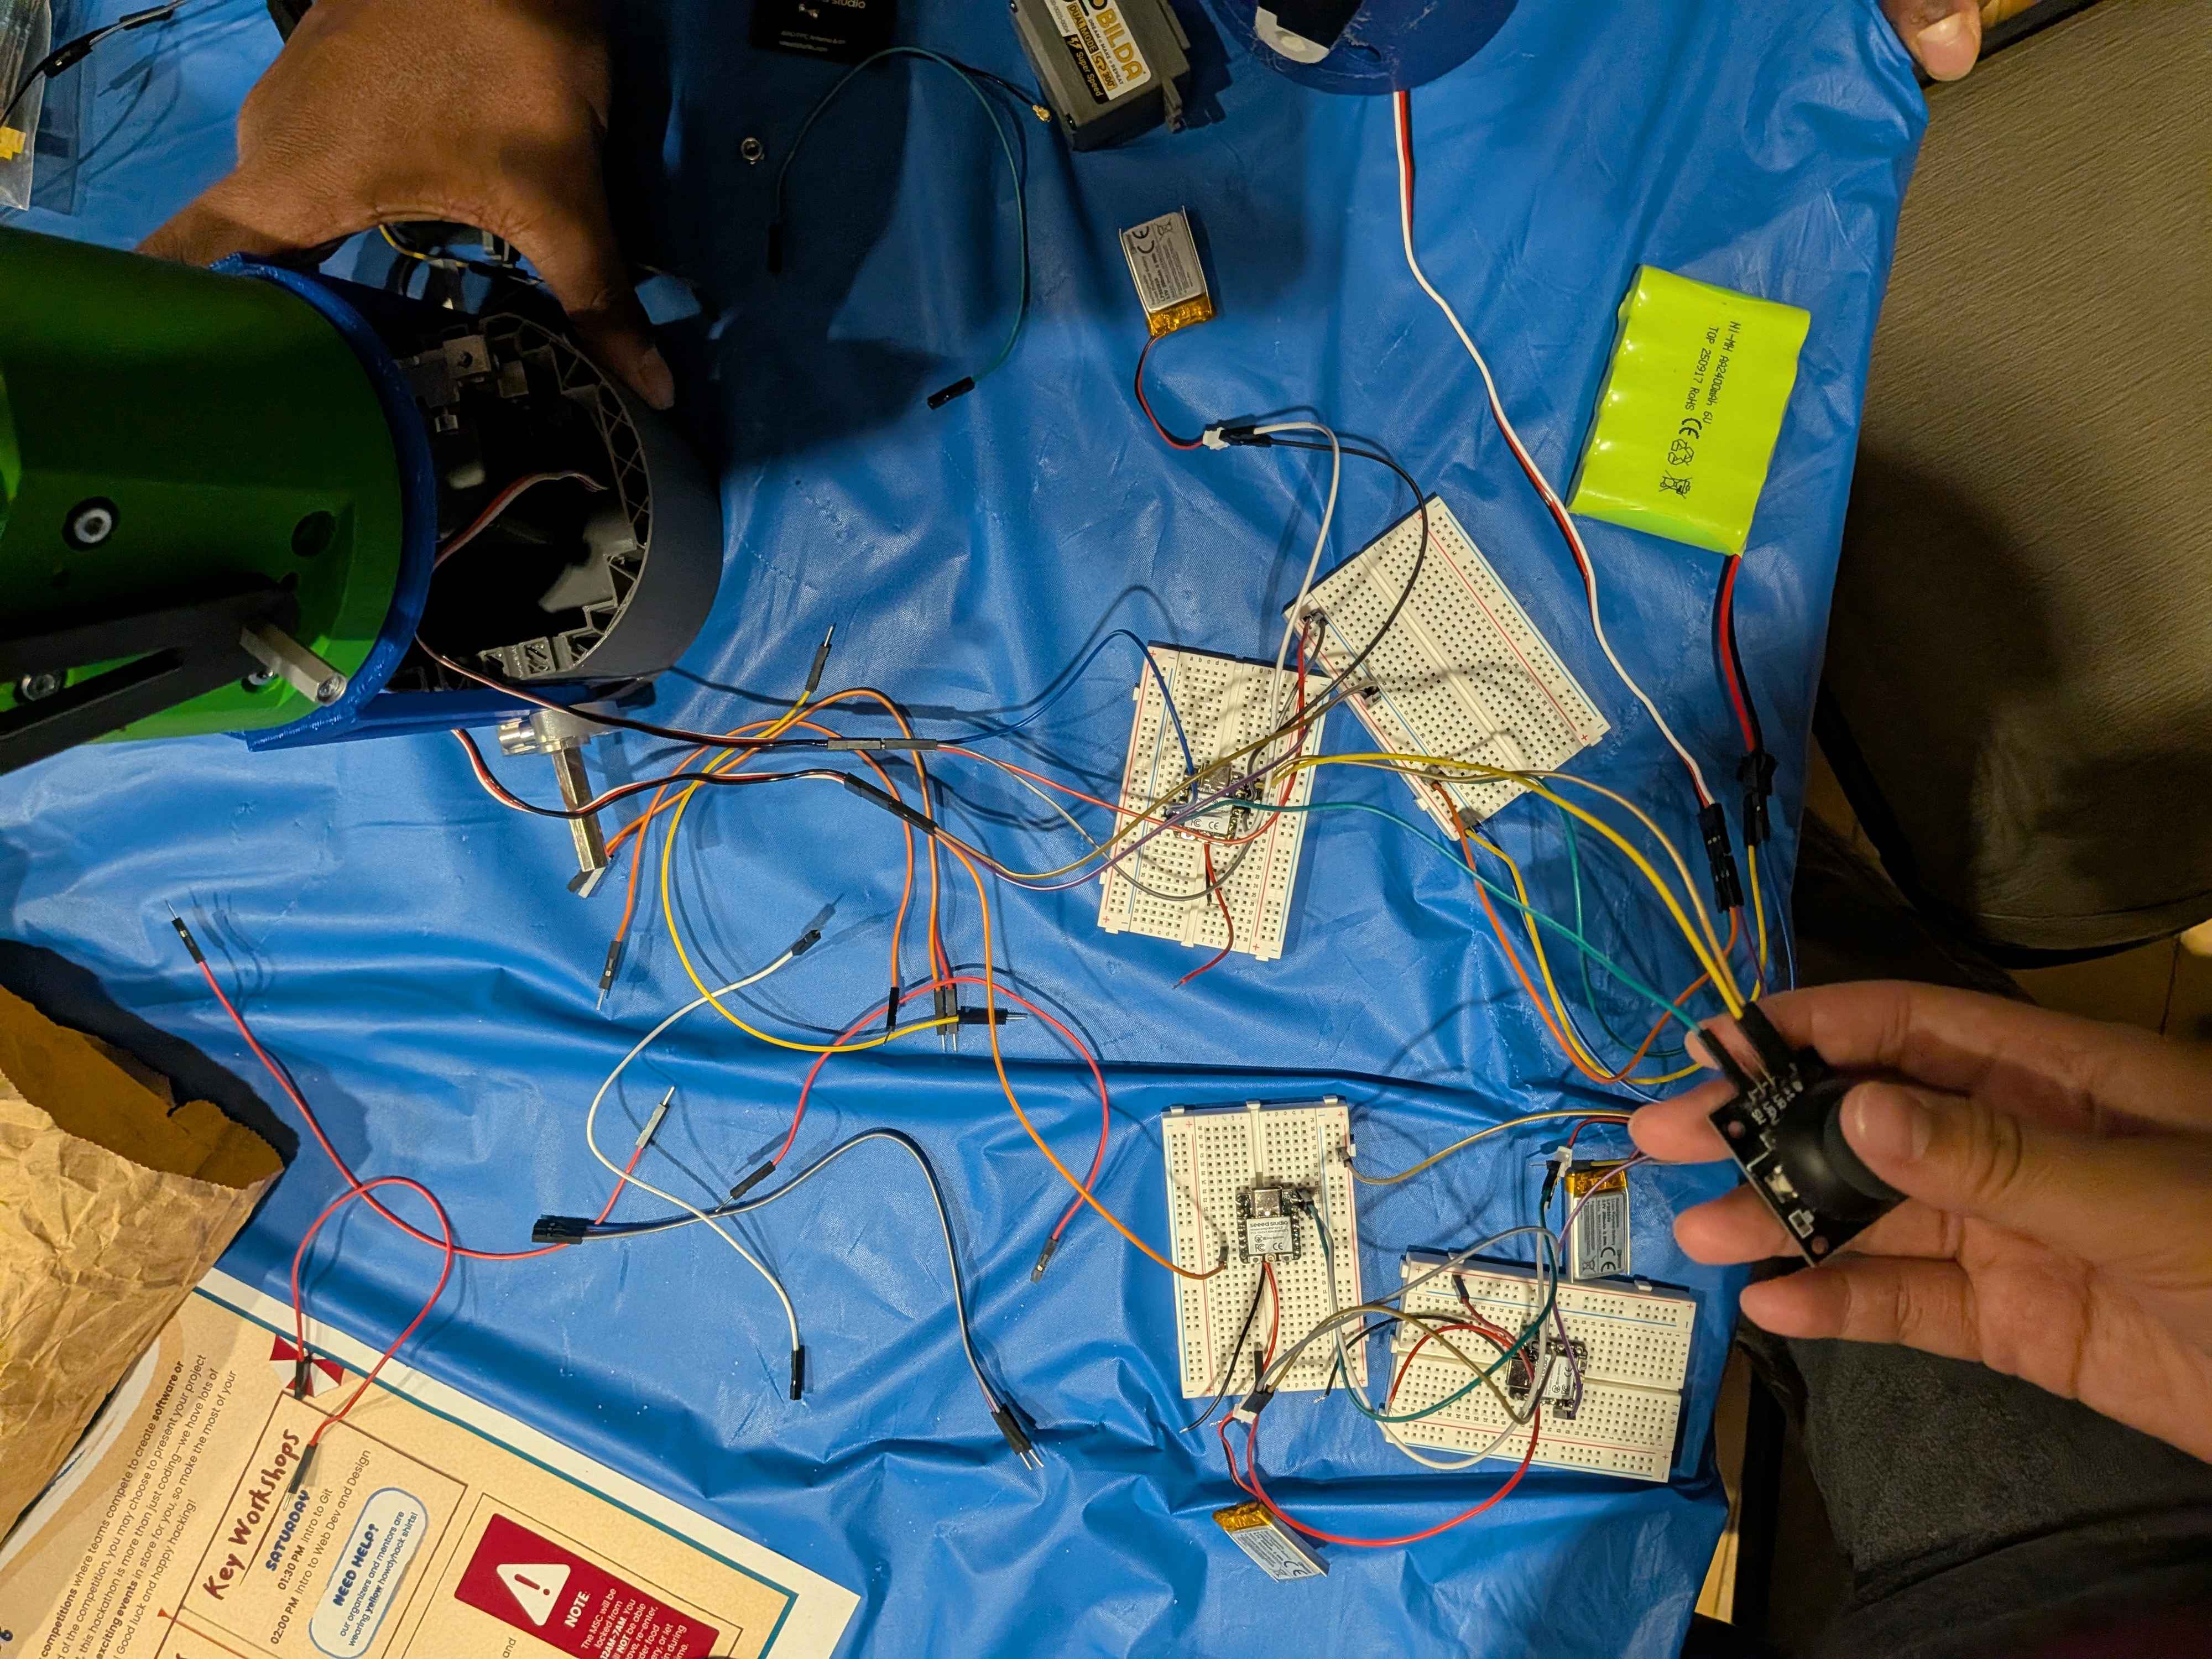
Wiring of ESPs - 2 Child Modules, One Parent Module, One Breadboard for Servo Power[Real Image]
Inspiration
As aspiring robotics engineers, we wanted to build a robot arm; however, we found that current components for our ideas were highly expensive. Specifically for modular robotic arms, the cheapest robotic arm we found was priced in thousands of USD! While disparaged by the high barrier to entry into robotics, we found our purpose:
We wanted to make modular robotics more accessible to students aspiring to get into robotics; for students, like ourselves.
What it does
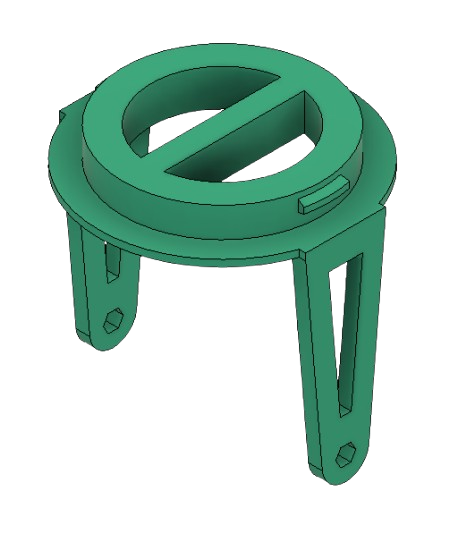
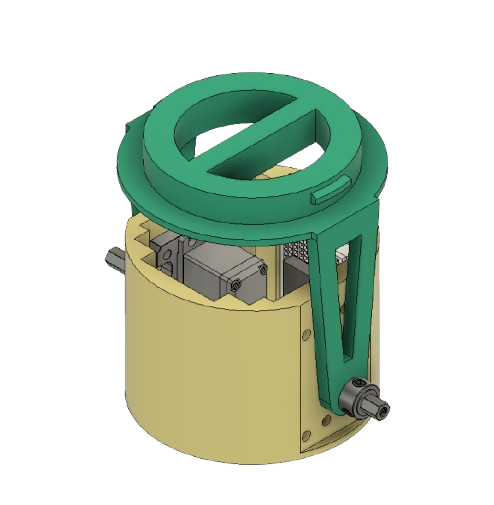
Each Modular Joint has a twist-lock feature to lock onto other Modular Joints, making a chain that can operate in a robotic-arm fashion; however, this is not the only application. The modules talk to each wirelessly using ESP 32 c3 minis powered by their own battery pouches. The servos have a separate, larger battery to power them and help them handle heavier loads. Since these Modulars Joints are highly customizable due to the twist-lock (you can pretty much attach any type of movement), our modular joints can make robots that have nearly unlimited degrees of movement.
How we built it
We 3D printed each module and arm. Each module houses the servo, ESP 32s, and battery pouches. The servos are chained to each other with another battery.
Here is the link: link
Challenges we ran into
We ran into a variety of challenges, primarily with the wiring. The wireless connection was difficult to configure, certain ESPs would not talk to each other, and batteries were finnicky. Sometimes, the servo modules had the wrong mechanical connections, so we had to make a lot of last-minute fixtures.
Accomplishments that we're proud of
We're proud of making the modularity work; we're proud of making the wiring work (somewhat). In the span of a week, we made a lot of progress.
What we learned
We learned a great deal about 3D printing, compliant mechanisms, and complicated electronics including but not limited to wireless communication.
What's next for Modular Joints
We will take this to other competitions and continue developing it until we can make it publicly accessible.
Built With
- 3dprinting
- arduino
- breadboard
- c++
- esp32
- servo

Log in or sign up for Devpost to join the conversation.