Mechano – Smart Autonomous Floor Cleaning Robot
Inspiration
Cleaning floors is a repetitive and time-consuming household task. We wanted to explore how robotics and embedded systems could automate this process using affordable and easily available hardware. The goal was to build a prototype capable of navigating indoor environments intelligently while minimizing human intervention.
What It Does
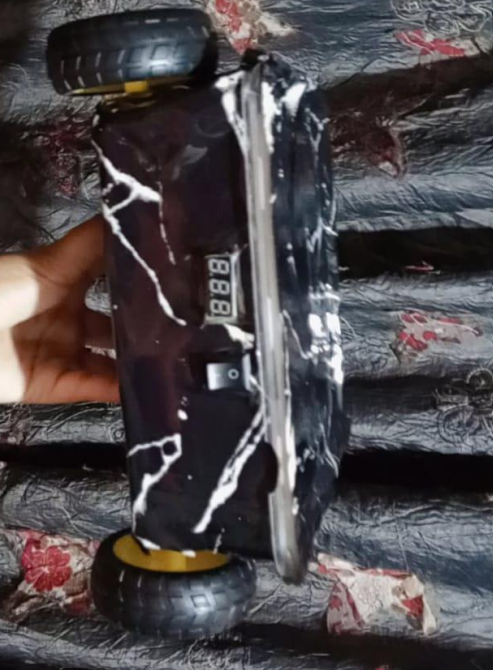
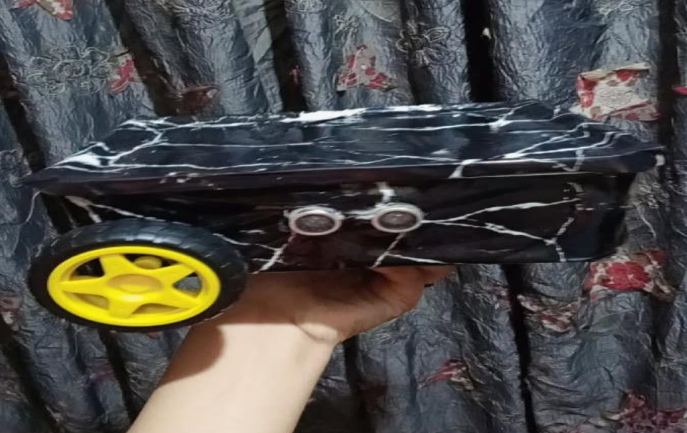
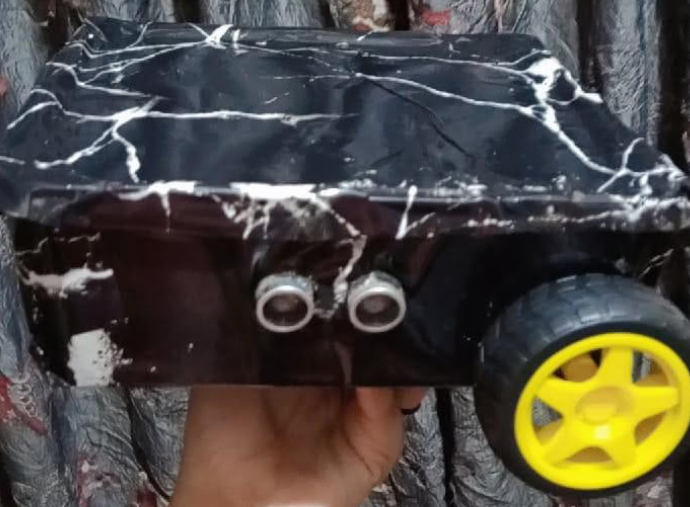
Mechano is an Arduino-based autonomous floor cleaning robot designed to move around indoor spaces while avoiding obstacles. The robot uses three ultrasonic sensors to detect obstacles from the left, front, and right directions. An IR sensor helps detect edges or surface changes, improving navigation safety.
The robot supports two operating modes:
- Autonomous Mode: Detects obstacles and decides whether to move forward, turn left, turn right, or reverse.
- Manual Mode: Allows the user to control the robot using serial or Bluetooth commands such as Forward, Backward, Left, and Right.
How We Built It
The robot was developed using:
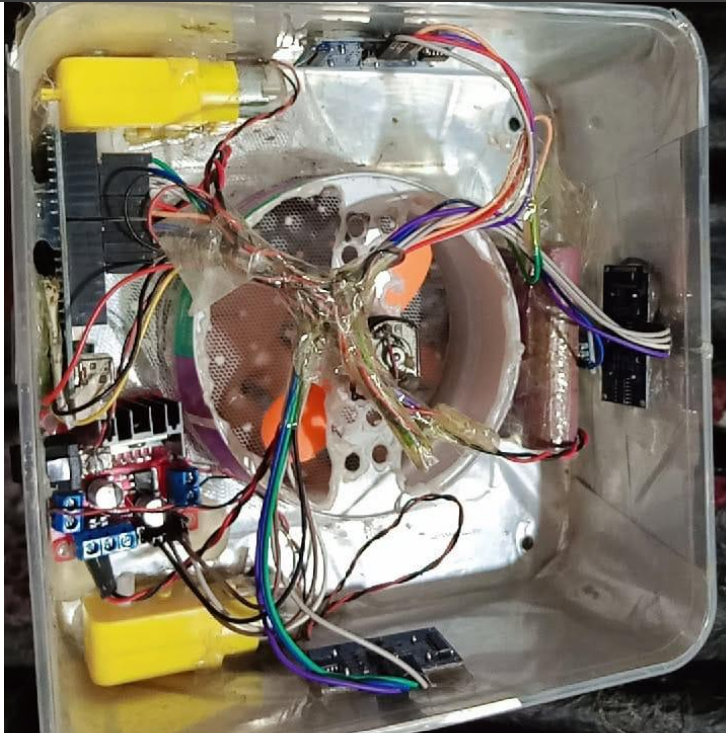
- Arduino Uno as the main controller
- Three HC-SR04 ultrasonic sensors
- IR sensor for edge detection
- DC motors with a motor driver
- Robot chassis with wheels
- Embedded C/C++ programmed in the Arduino IDE
The Arduino continuously reads sensor data, processes obstacle distances, and controls the motors according to predefined navigation logic. Manual commands can override autonomous behavior whenever needed.
Challenges We Faced
During development, several challenges had to be addressed:
- Calibrating ultrasonic sensors for accurate distance measurements.
- Preventing false obstacle detections caused by sensor noise.
- Designing movement logic that avoids collisions while maintaining smooth navigation.
- Integrating autonomous and manual control without conflicts.
- Testing and tuning motor movements for stable turning and forward motion.
What We Learned
This project strengthened our understanding of:
- Arduino programming and embedded systems.
- Sensor integration and real-time data processing.
- Autonomous navigation algorithms.
- Motor control and robotics fundamentals.
- Debugging hardware-software interactions in robotic systems.
Future Improvements
Future versions of Mechano will include:
- Rotating cleaning brushes and vacuum suction.
- Bluetooth and Wi-Fi mobile application control.
- Smart room mapping using SLAM.
- AI-based path planning and object recognition.
- Automatic charging dock and battery monitoring.
Impact
Mechano demonstrates how low-cost embedded systems can be used to create practical autonomous robots for smart homes. It serves as a foundation for future intelligent cleaning systems that are affordable, efficient, and scalable.
Built With
- breadboard
- c/c++
- dc
- driver
- embedded
- hc-sr04
- ide
- ir
- jumper
- l298n
- motor
- motors
- pwm
- sensors
- ultrasonic
- uno
- width
- wires

Log in or sign up for Devpost to join the conversation.