Inspiration
We were inspired by people with limited mobility who face challenges with everyday tasks that many of us take for granted. We wanted to create something that could make these tasks easier while giving users more independence and allowing them to live their daily lives with less assistance.
What it does
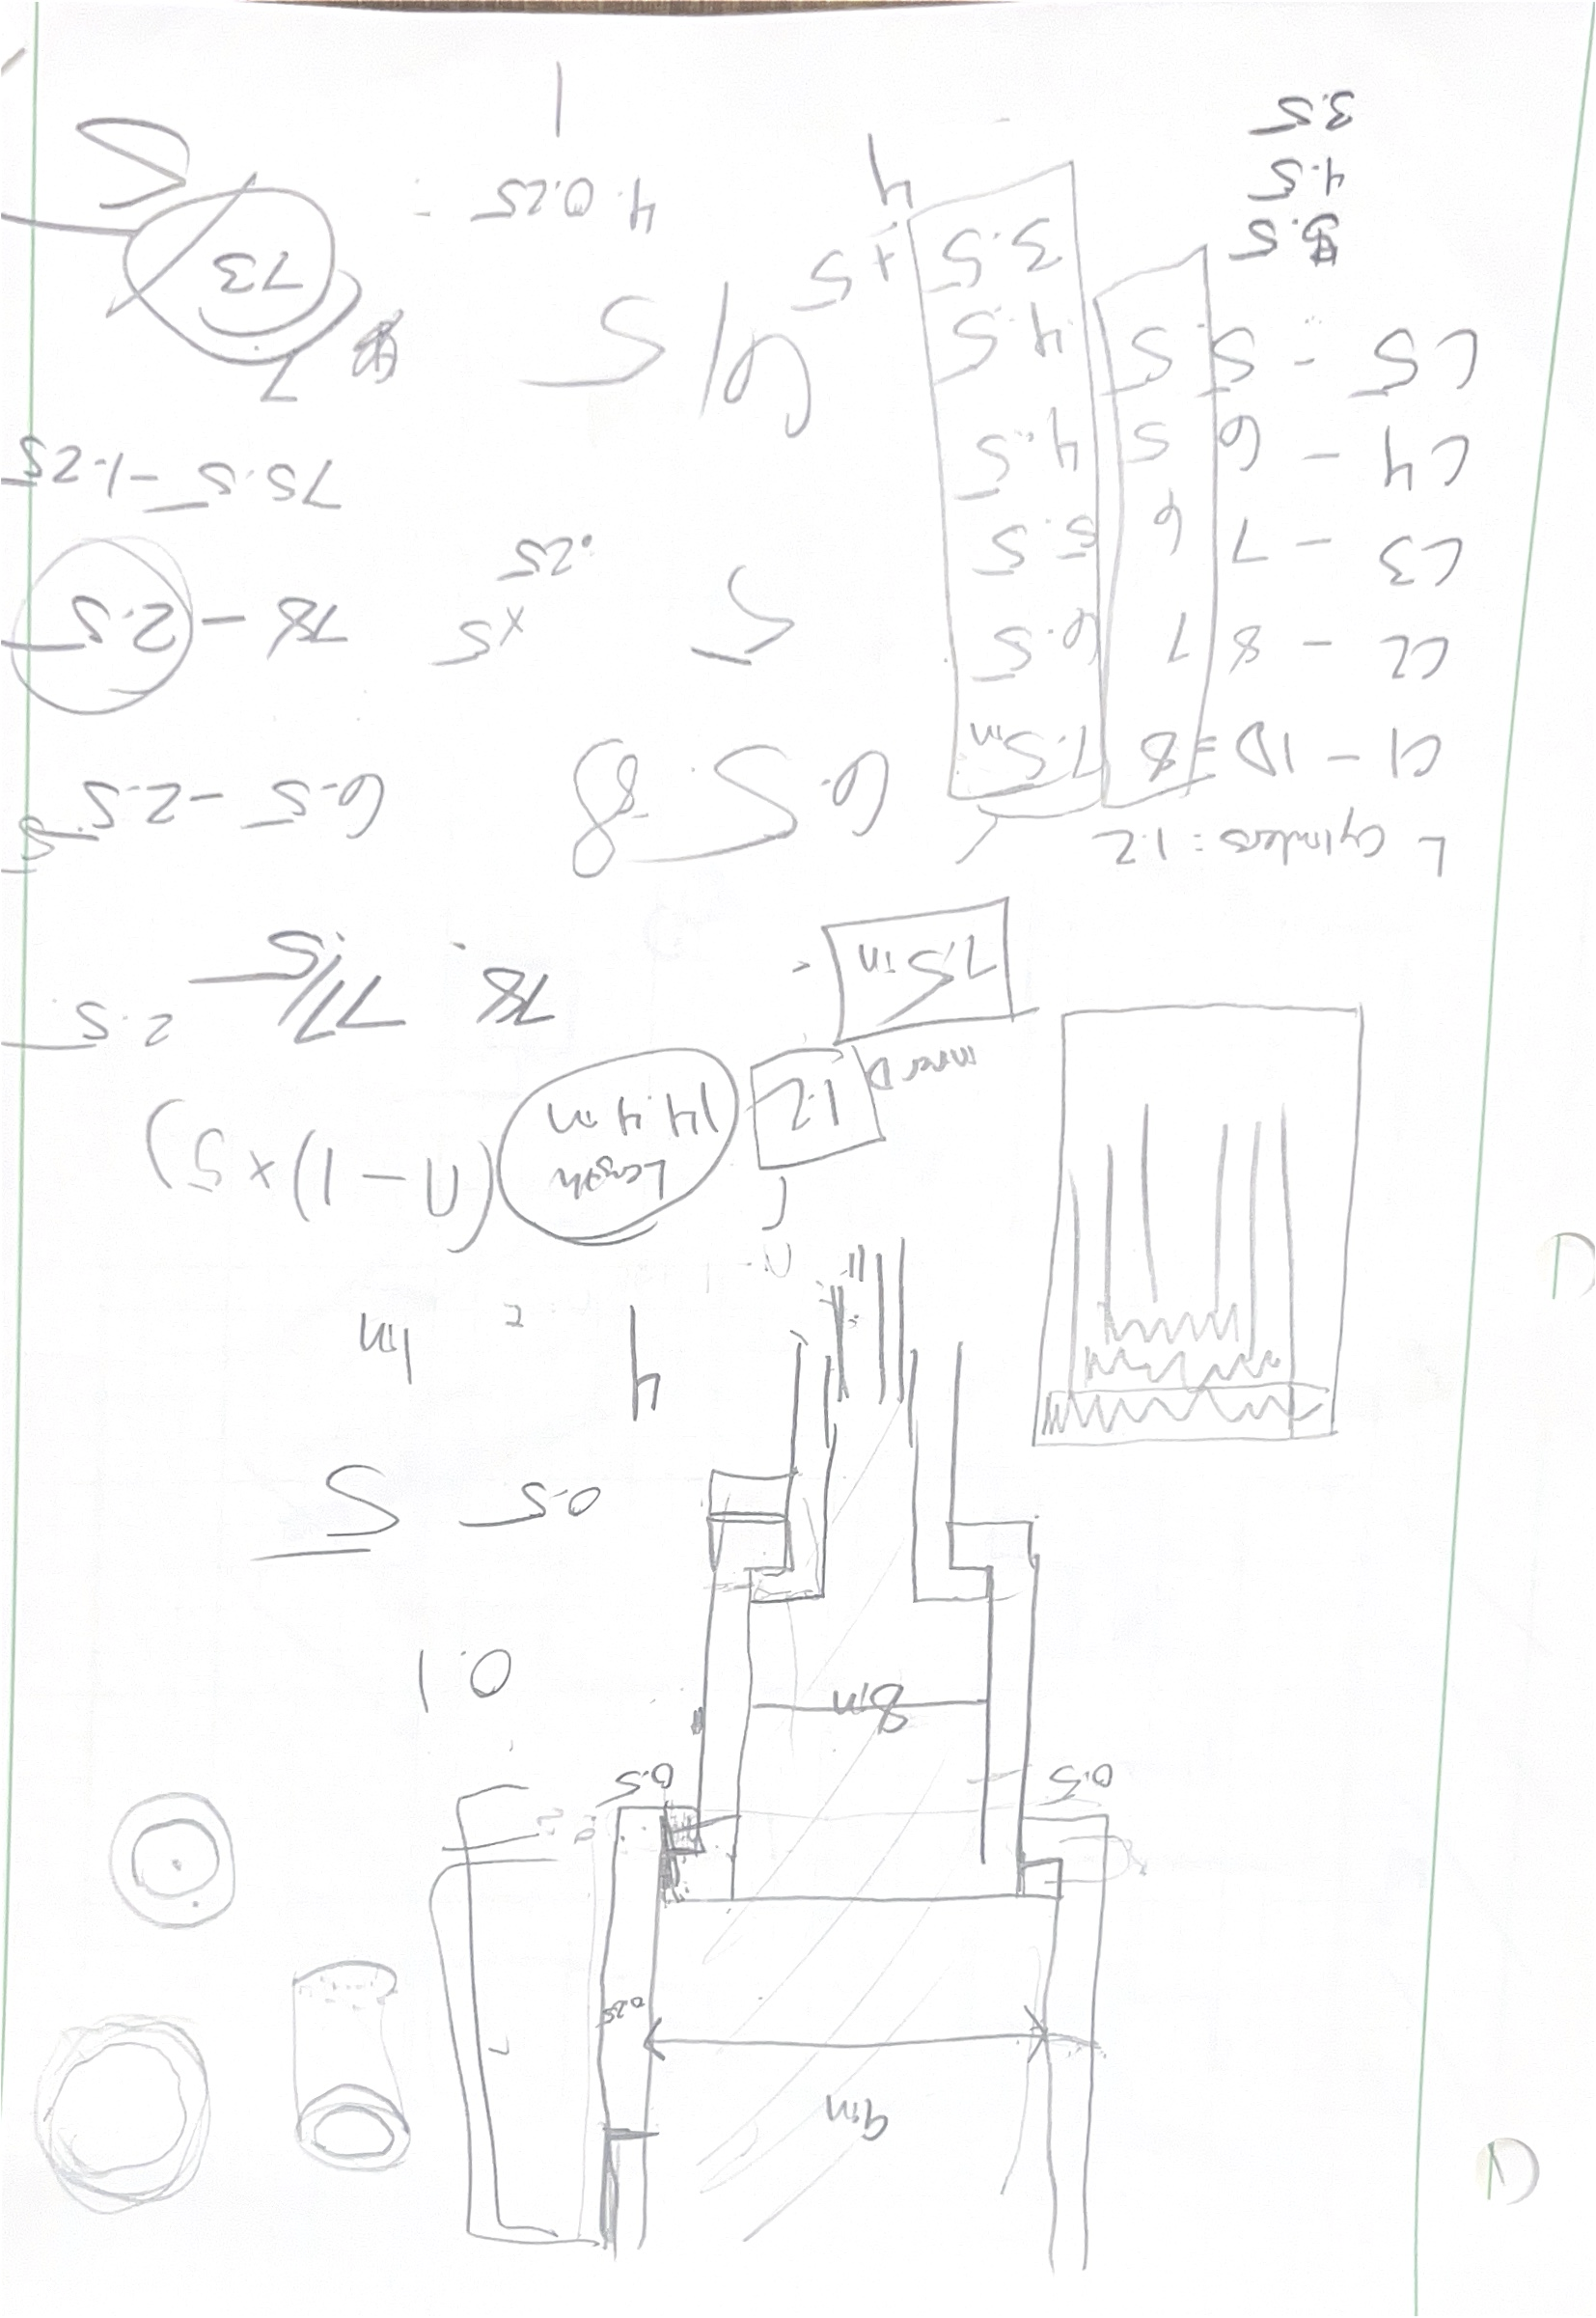
The MA Grabber is an overhead grabbing system that allows users to retrieve objects around a room. It travels along a 12-foot railing connected to the upper wall and uses multiple mechanisms to position and operate the grabber.
How we built it
We designed the MA Grabber in CAD, focusing on creating a system that could move horizontally, vertically, and rotationally while also allowing the claw to grab objects. We incorporated a 12-foot support railing, motors, a hydraulic lifting system, and a mechanical grabbing mechanism.
Challenges we ran into
One of our biggest challenges was balancing cost, weight, and functionality. We needed materials that were cost-effective while still being strong enough to support the system. We also had to keep the design lightweight without sacrificing stability or the ability to move and grab objects effectively.
Accomplishments that we're proud of
We are proud that we were able to turn our original idea into a complete working concept. We successfully designed a system that combines multiple mechanisms into one solution while keeping accessibility and independence at the center of the design.
What we learned
This project taught us that engineering requires more than simply creating something that works. We learned how important it is to consider cost, weight, materials, functionality, and the user's needs simultaneously. We also learned how to work through design challenges and adapt our ideas as we developed the system.
What's next for MA Grabber
Our next step would be to build and test a physical prototype. We would focus on improving the system's reliability, reducing its weight and cost, and making sure it can safely and effectively retrieve different types of objects. Ultimately, we hope the M² Grabber can become a practical tool that gives people with limited mobility greater independence.
Built With
- onshape

Log in or sign up for Devpost to join the conversation.