-
-
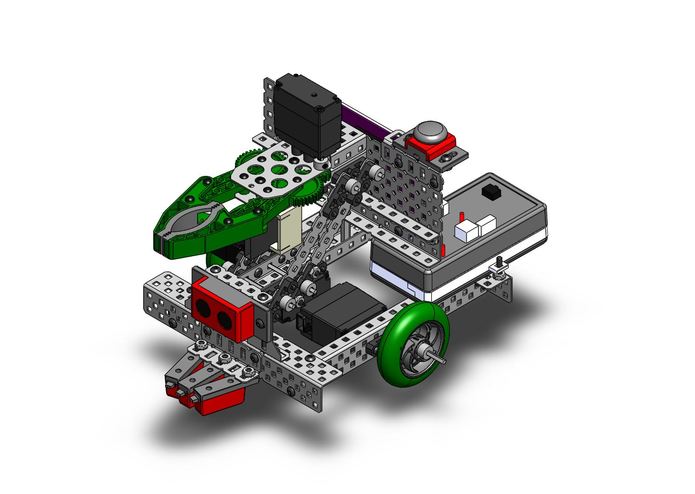
SolidWorks Model
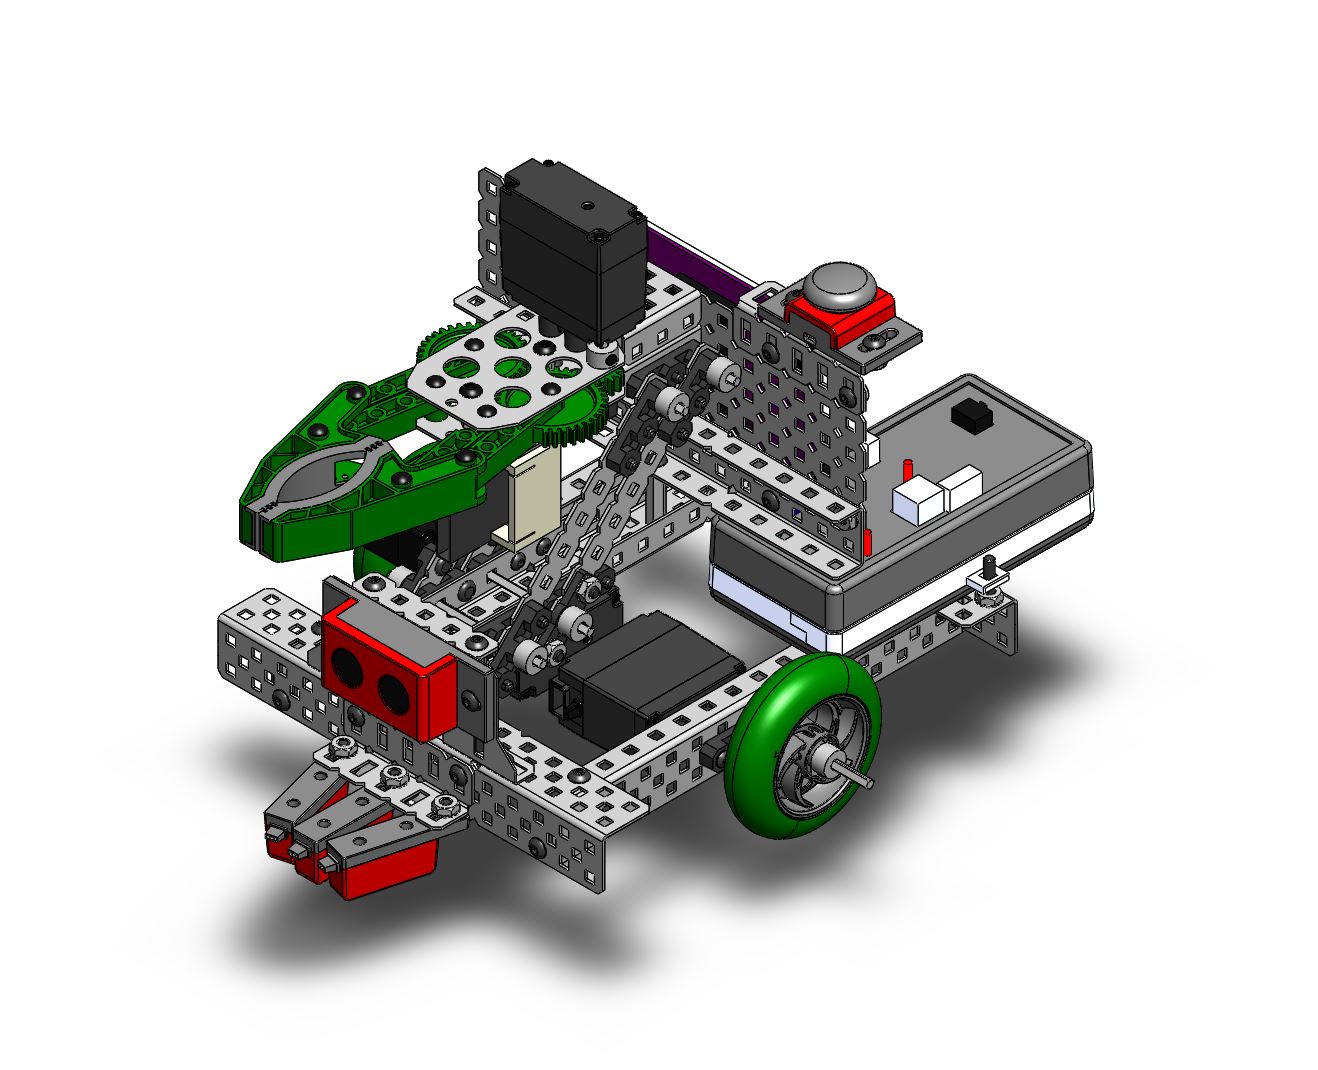
Line-Tracking-Robot
Second year Mechatronic Design project. Built and coded a line following robot that has a retractable arm to pick up objects.
What I Learned
I have used Arduino's before in mechatronic systems, taking information from the environment and to make decisions. However I have never built something this complex, measuring so many parameters, to execute more then one task autonomously. I learned how to use ultrasound sensors, line tracking sensors, encoders and light sensors. Using this information it allowed to Robot to finish the course as seen in the video

