-
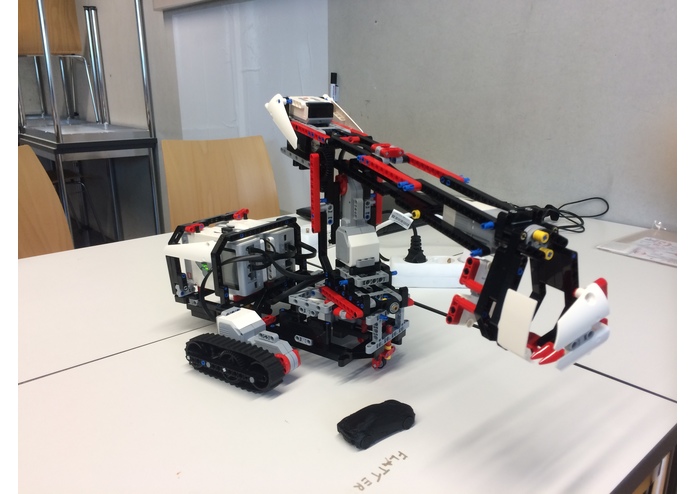
G-Bot
-
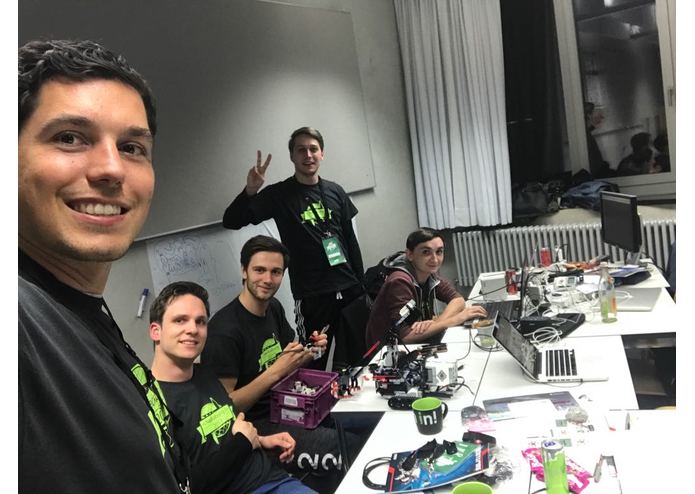
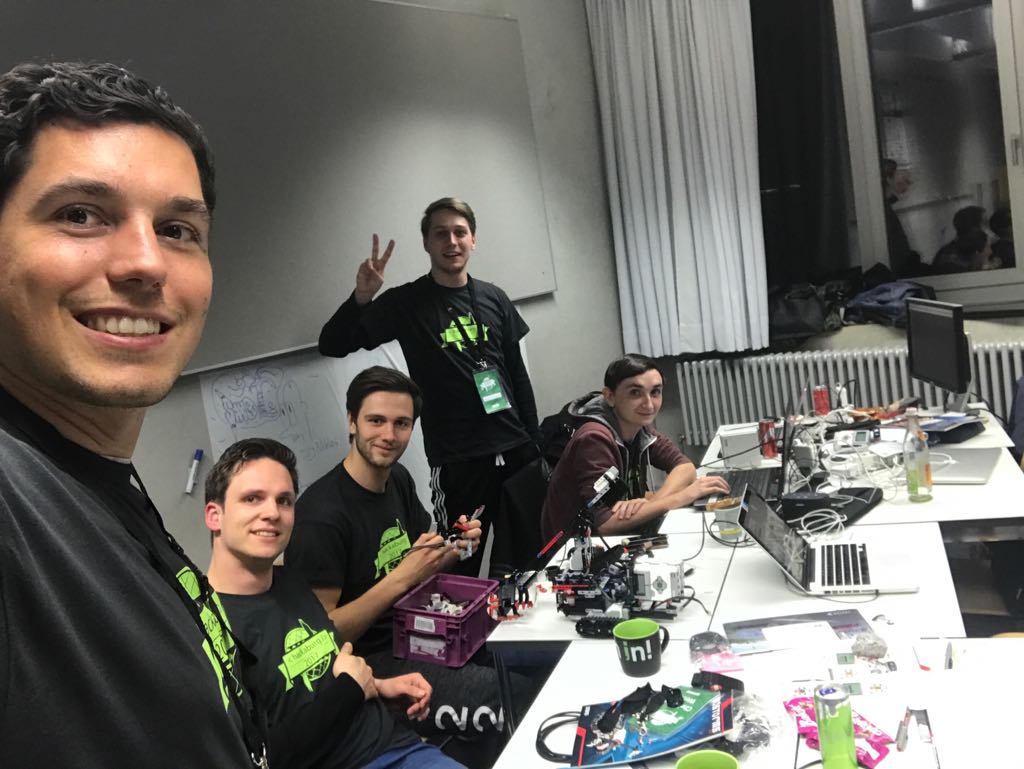
The Team
Inspiration
Human machine cooperation - Remove the barriers between humans and technology
What it does
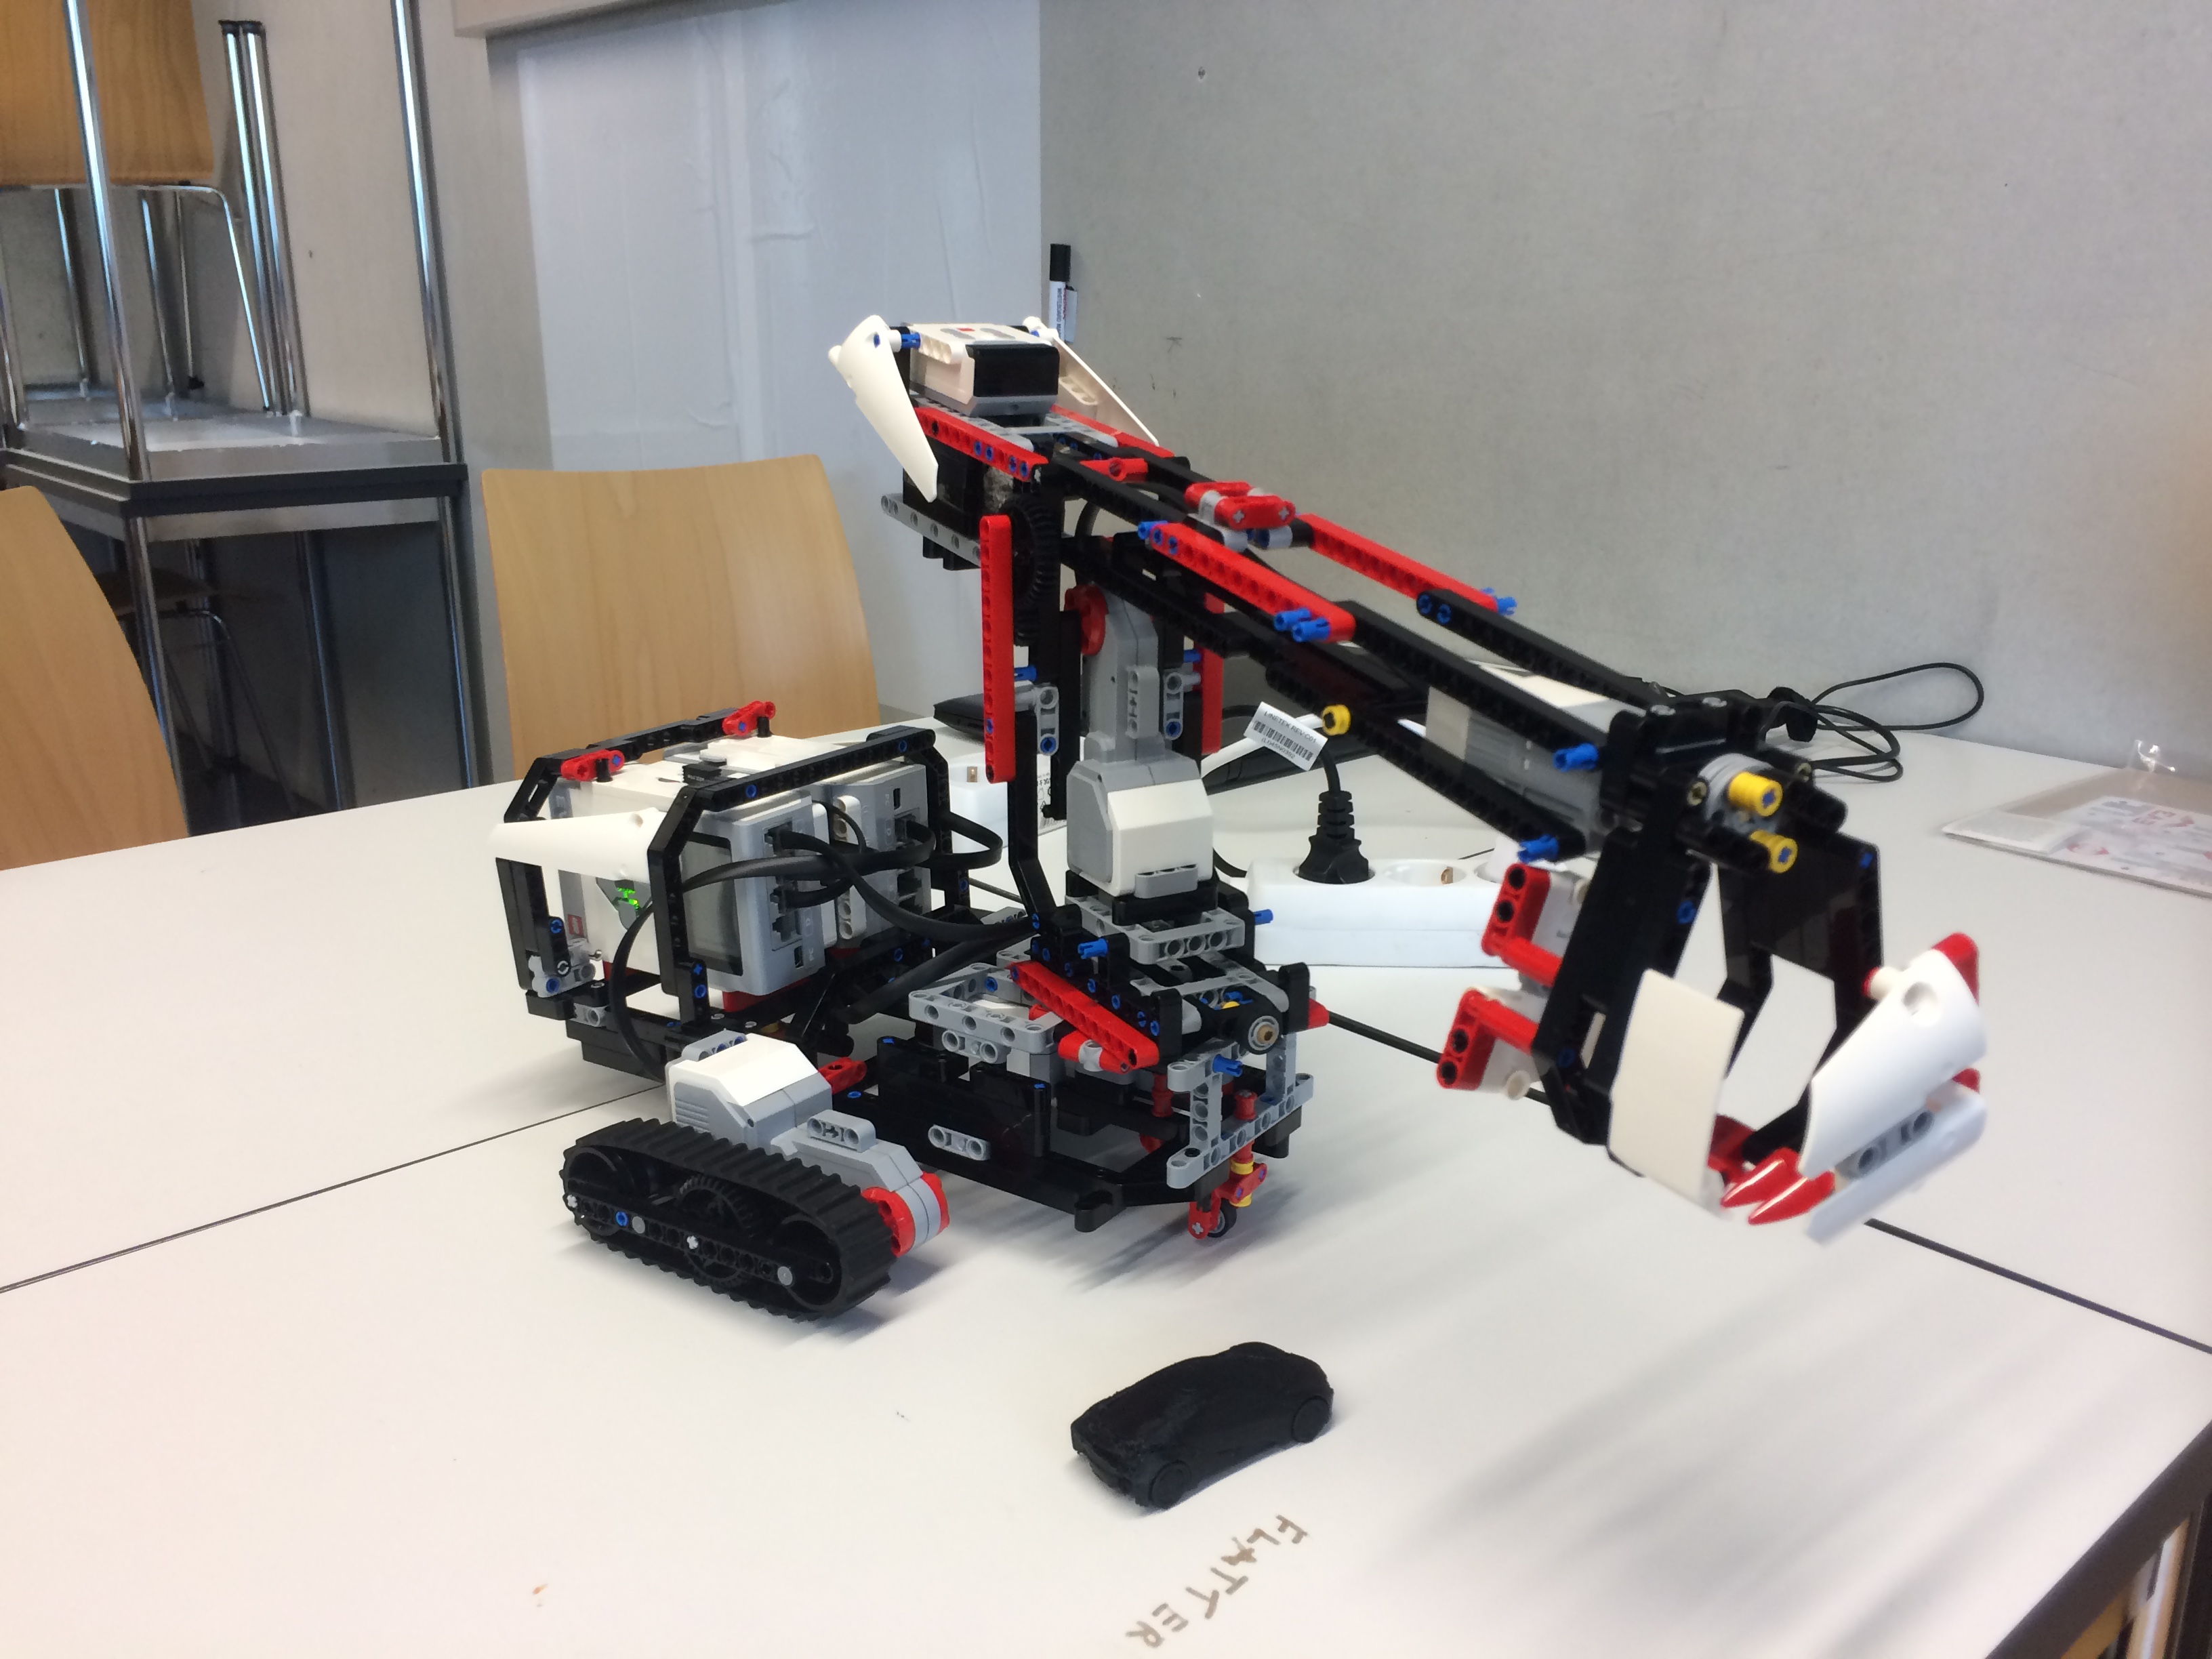
The movement of our G-Bot (Gesture Robot), a robot gripper arm (_ Robotergreifarm _) is based on gesture control (for example swiping hands) as our hands are the best original universal interface. By your hands you can control the G-Bot in three axes and additional you can steer the gripper.
How I built it
Lego Mindstorms builds the basis for our G-Bot. As a motion capturing tool we use a Leap Motion Controller. The Leap Motion controller is connected to a Laptop and provides the gesture data to a nodejs server on a Rasperry Pi, which we use as an access point. The Rasperry Pi sends the data to the Lego Mindstorms controller, which also run with nodejs. The Lego Mindstorms controller takes the gesture data and the electric drives execute the movements.
Challenges I ran into
Building the Robot by Lego Mindstorms:
- Develop a construction concept which is stable enough to hold the "heavy" electric drives
- Didn't know how many axes we can use
- The maximum of flexibility with a minimum of electric drives
- Our G-Bot is a battery consuming monster!!! G-Bot finished 18 AA batteries at the Hackaburg
Send Data to the Robot:
- To set up a communication between three different systems (Robot, Leap Motion Controller, Rasperry Pi)
- Use live data
Accomplishments that I'm proud of
- Everything
What I learned
- Playing with Lego is still fun
- Communication setup with different systems
- Capability of Leap Motion Controller
What's next for Gesture controlled robot
- Hey G-Bot bring me a cold bottle of beer out of the fridge!!! :-)
Built With
- javascript
- leap-motion
- lego-mindstorms
- node.js
- raspberry-pi


Log in or sign up for Devpost to join the conversation.