

Inspiration
I always wanted to work on a gesture-controlled robot that can be controlled by my changing the orientation of my hands. So this weekend I worked on a gesture-controlled robot using two ESP32 boards.
What it does
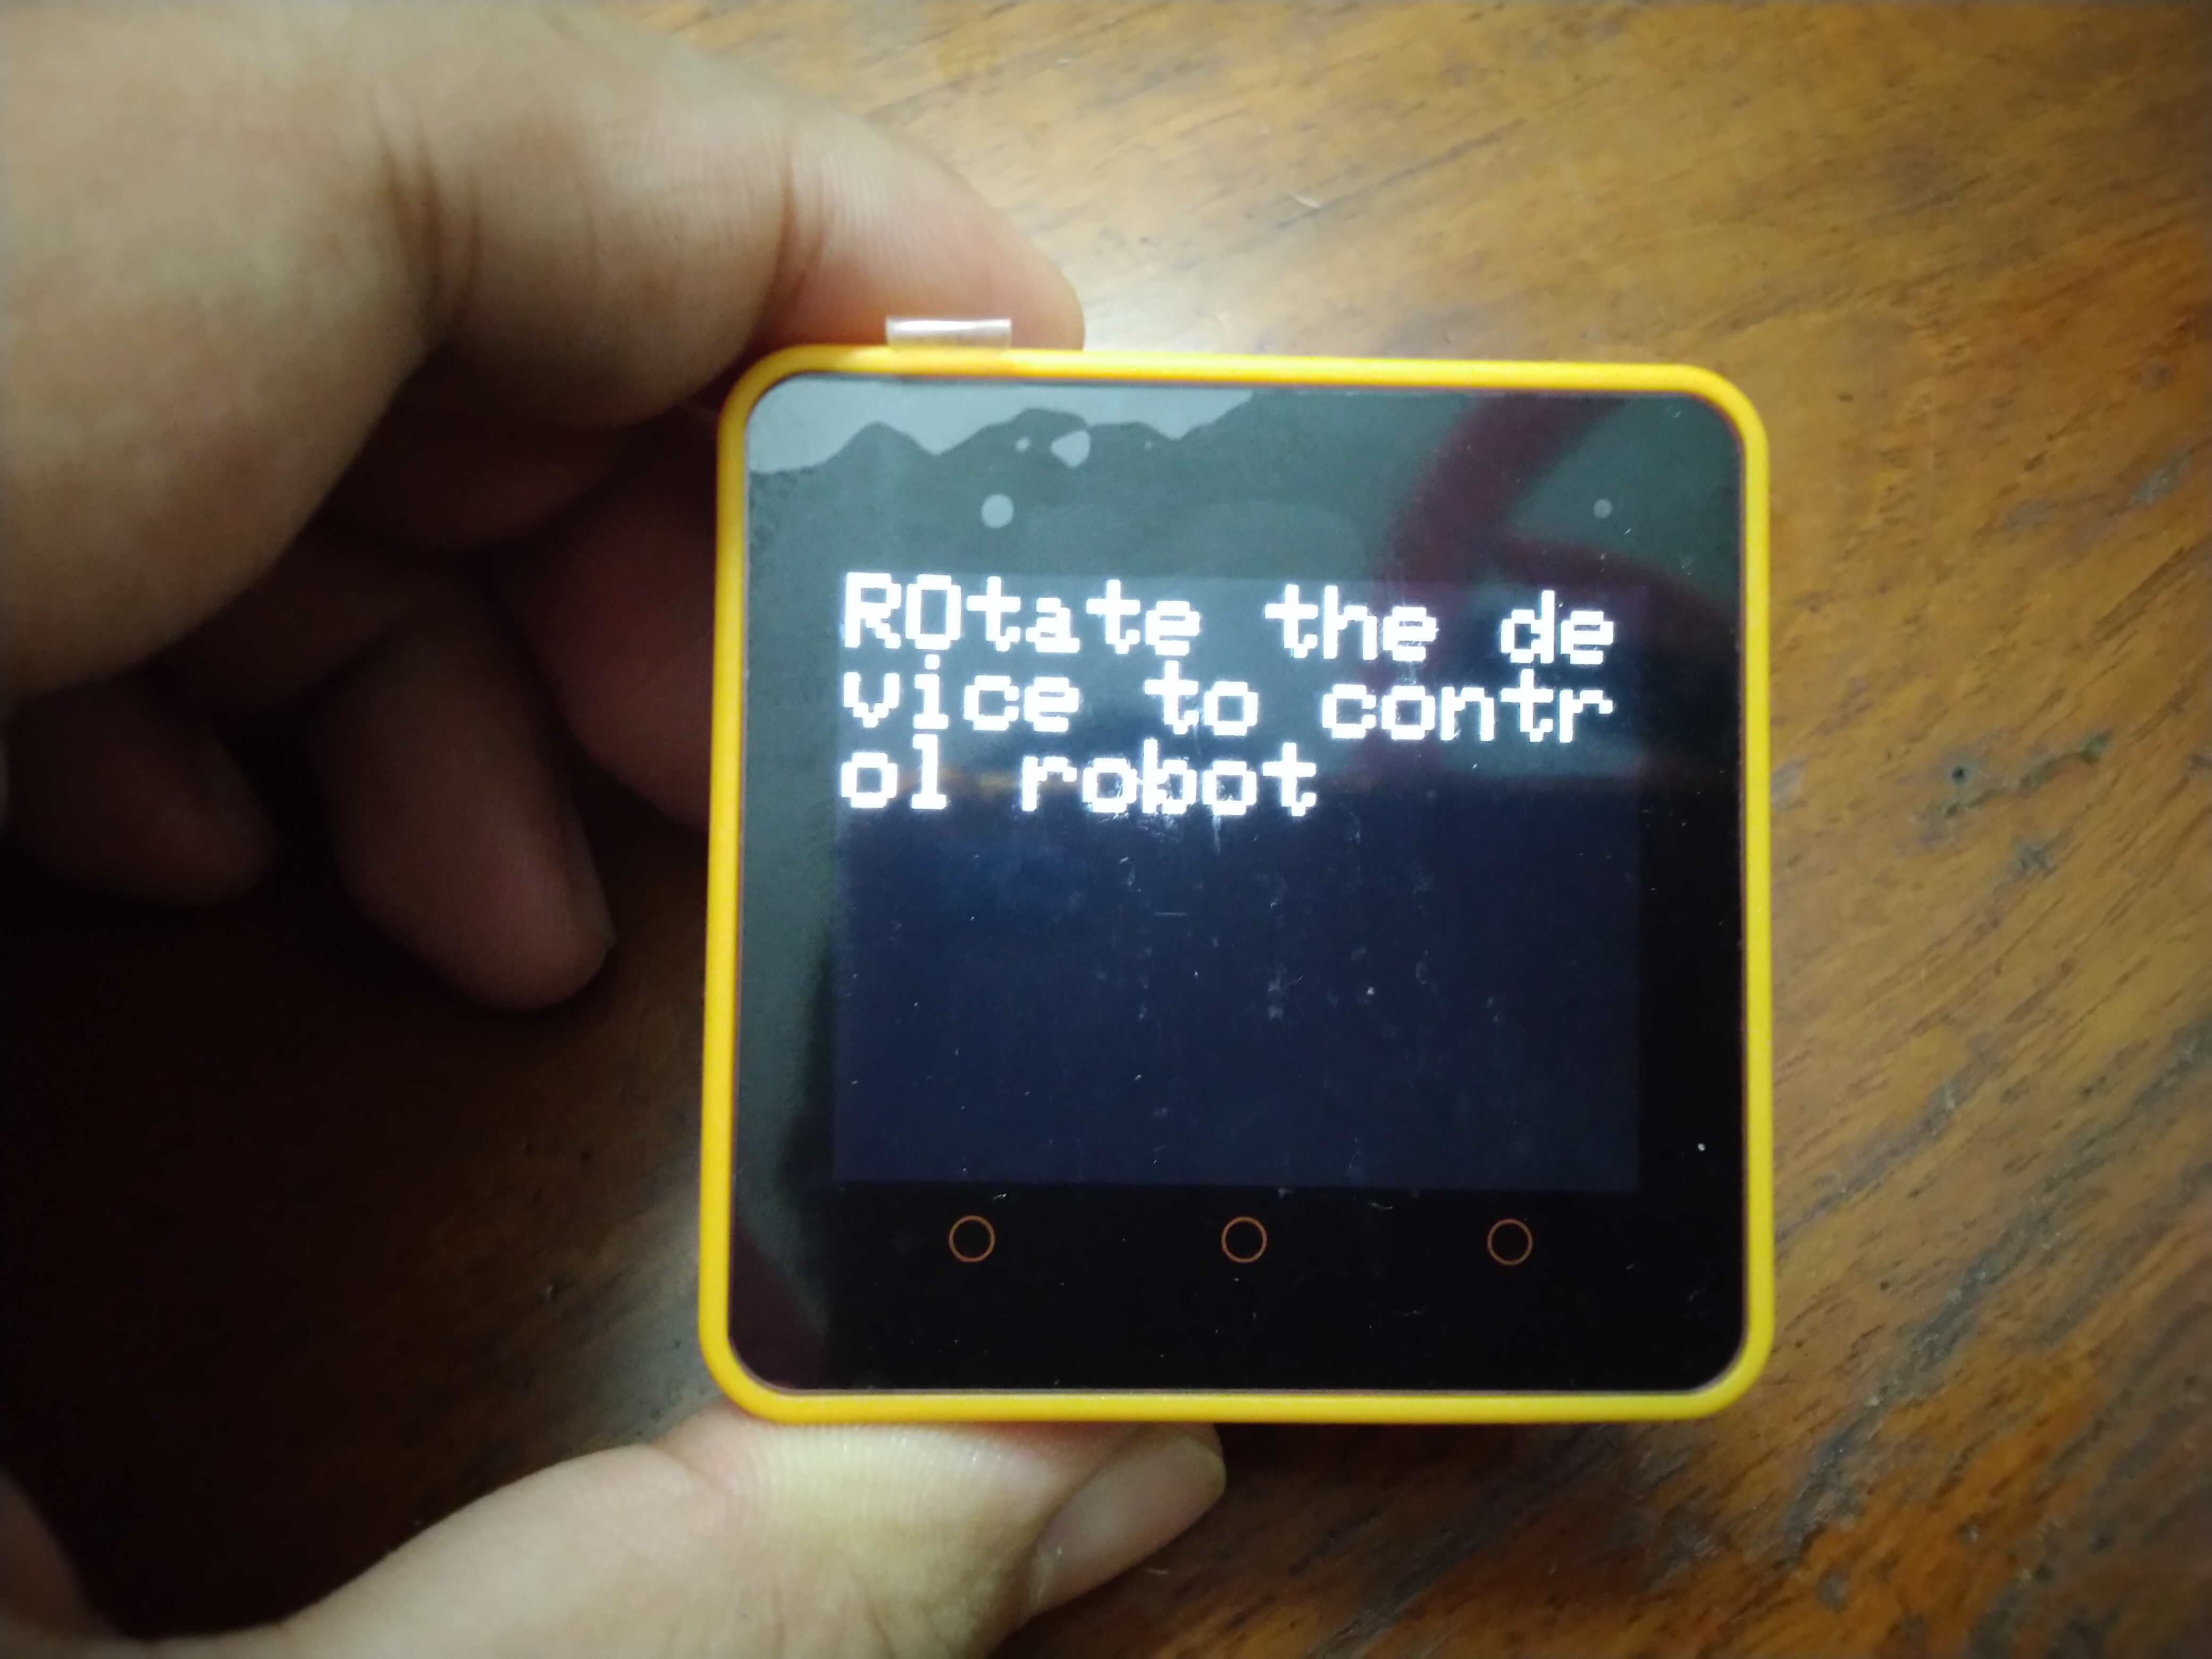
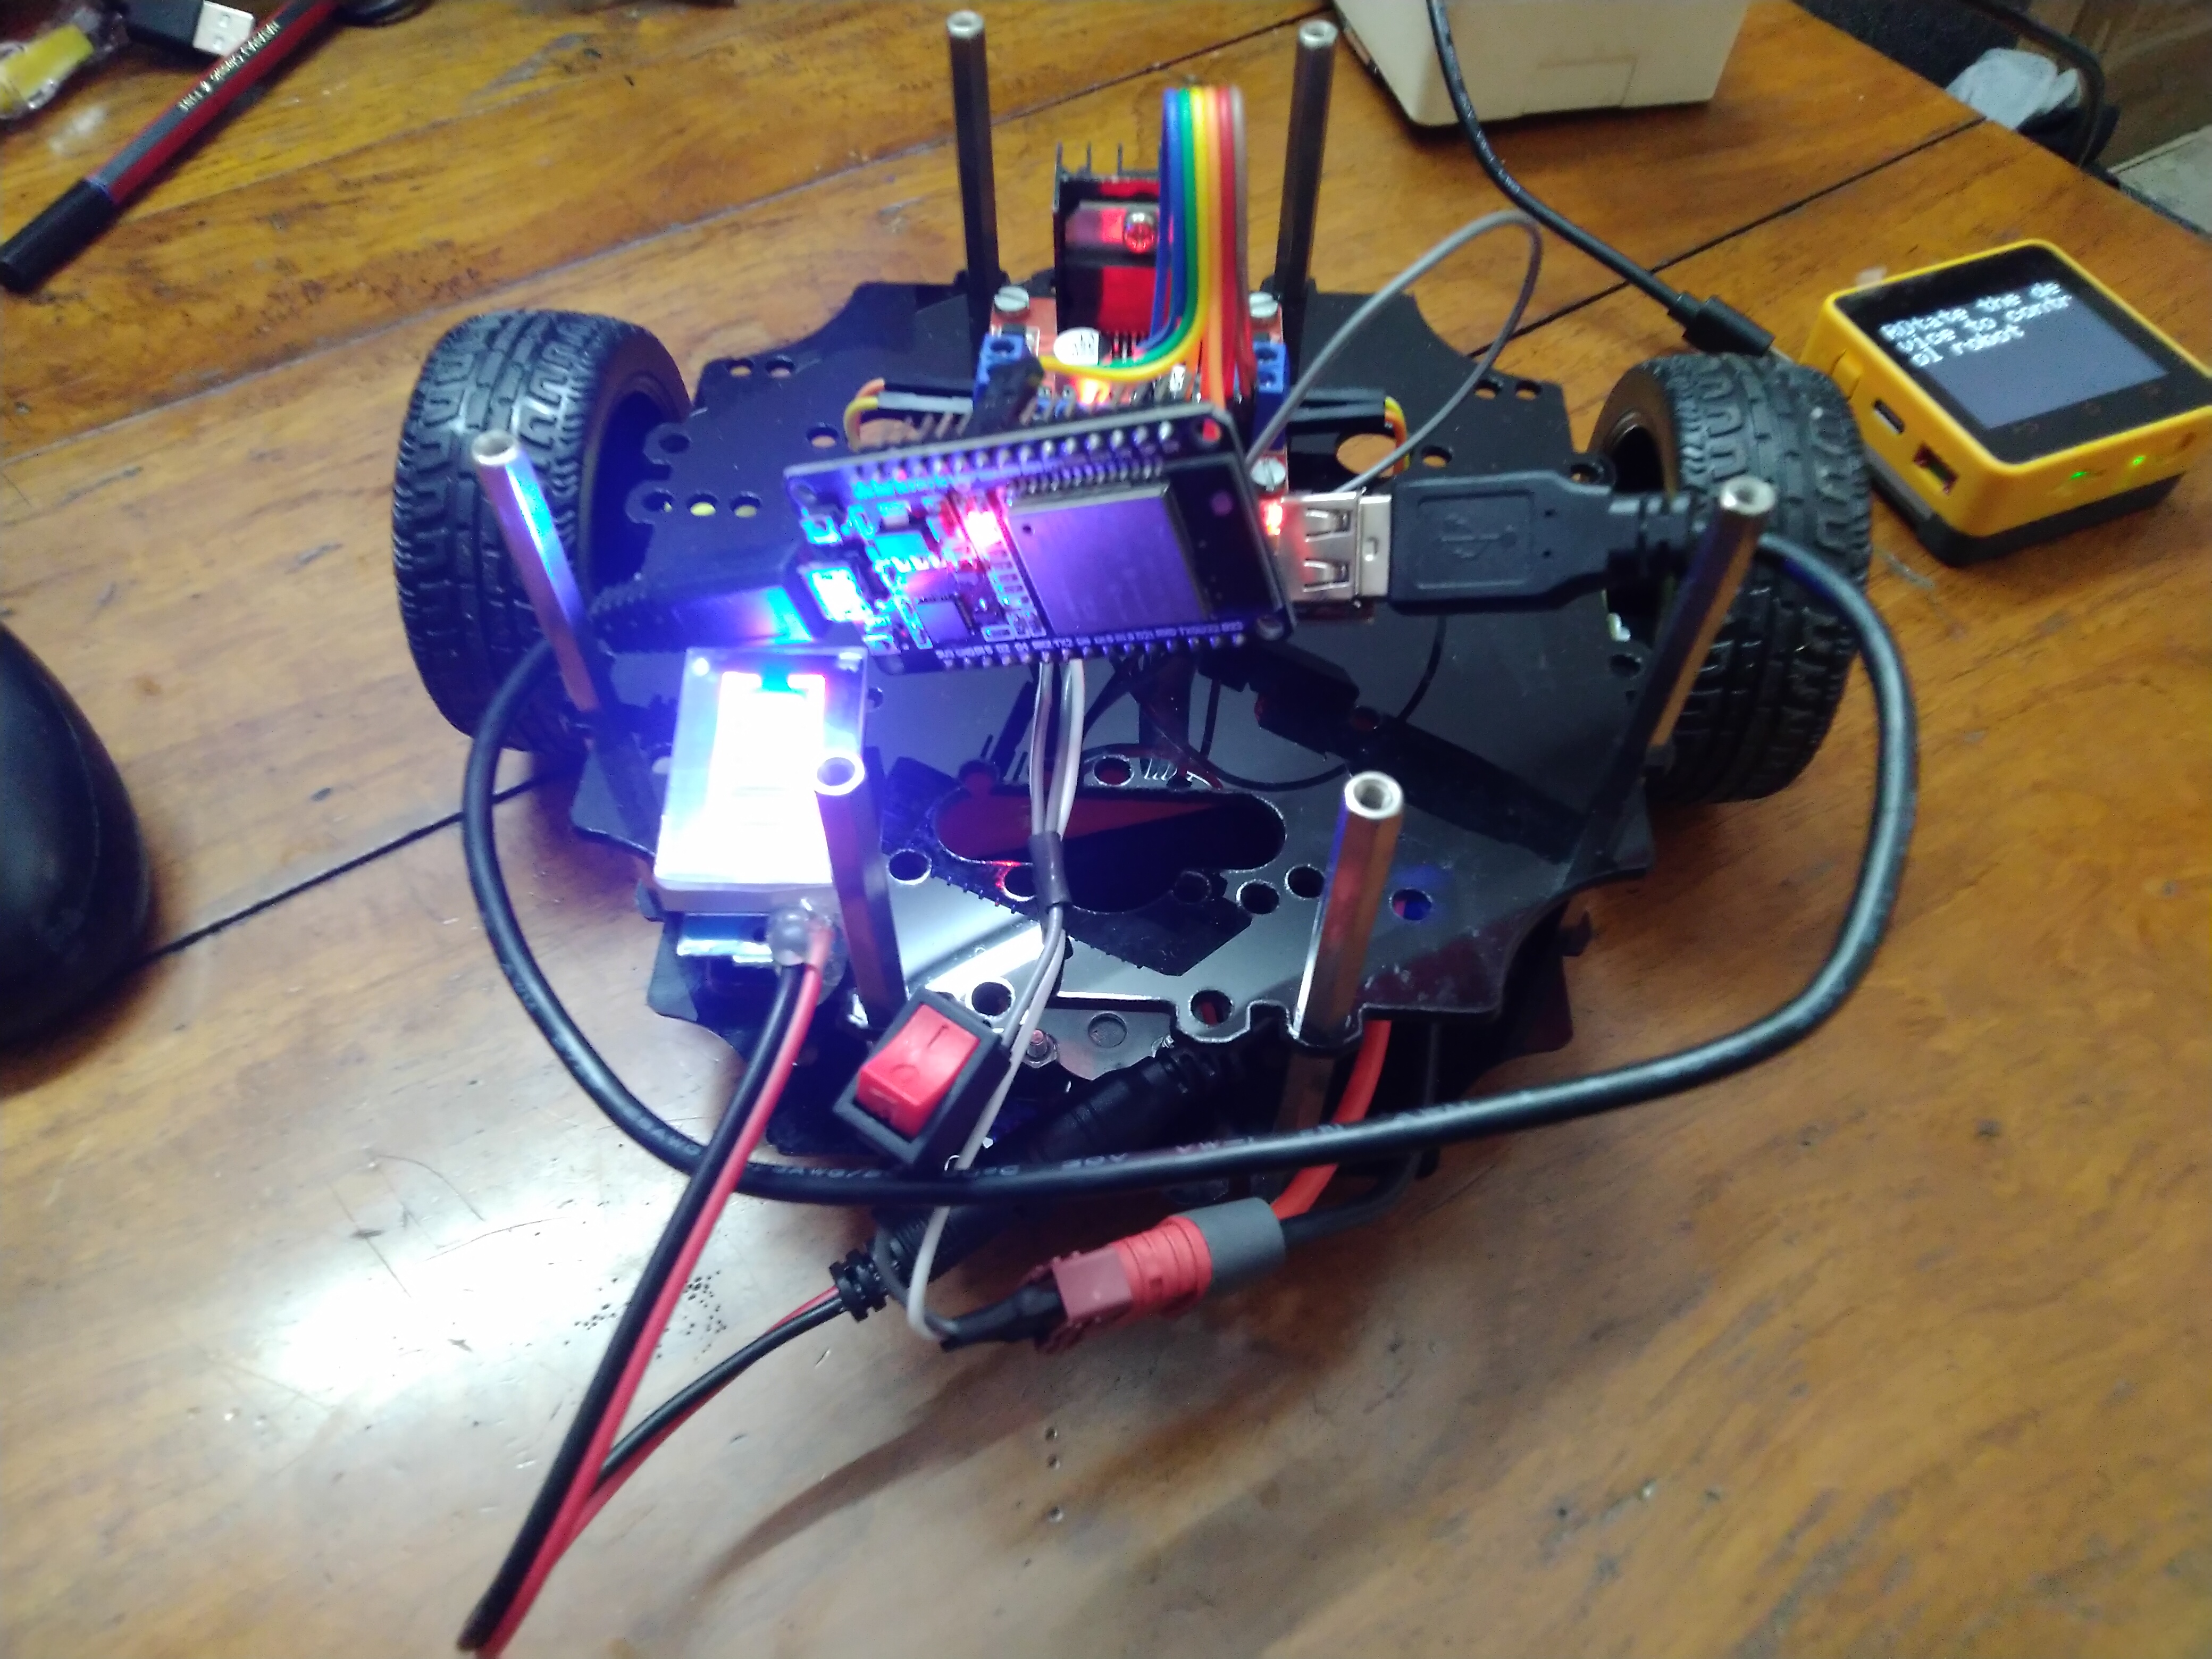
It is a gesture-controlled robot that is controlled by sending commands from an M5Stack ESP32 board and another ESP32 receives the command for motor control.
How we built it
I used a M5Stack ESP32 board which contains an in-build IMU sensor for detecting the gestures. The gestures are detected using the accelerometer. The acceleration in the X and Y axis data are send to the onboard EPS32 of the robot using the ESP-NOW protocol.
Challenges we ran into
Finding a way to send the accelerometer data of the IMU from the M5Stack to the ESP32 on the robot was a bit challenging. Initially, I decided to use Bluetooth protocol but it was not working properly according to my needs. So after a lot of research, I switched to ESP-NOW protocol.
Accomplishments that we're proud of
As one can see in the video, the robot obeys my commands.
What's next for Gesture Control Bot
I intend to include some graphics in the display of the M5stack board so as to make it more impressive and interesting.
