-
-
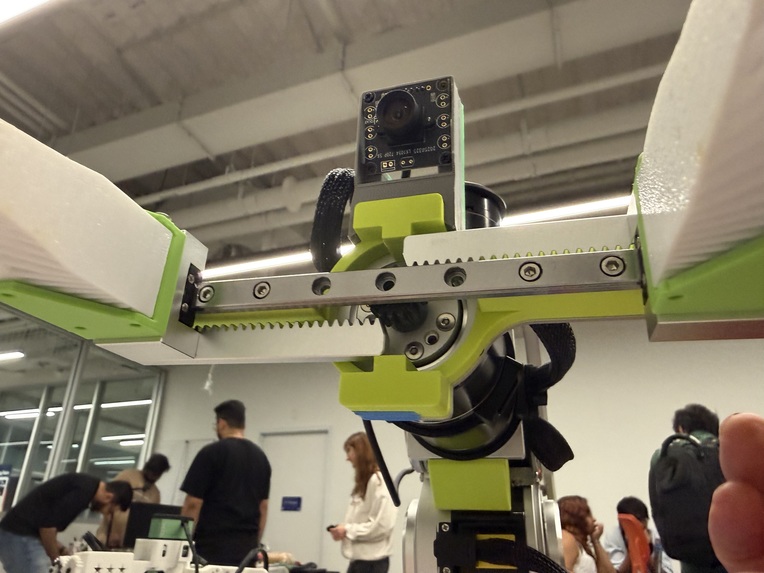
arm breaks
-
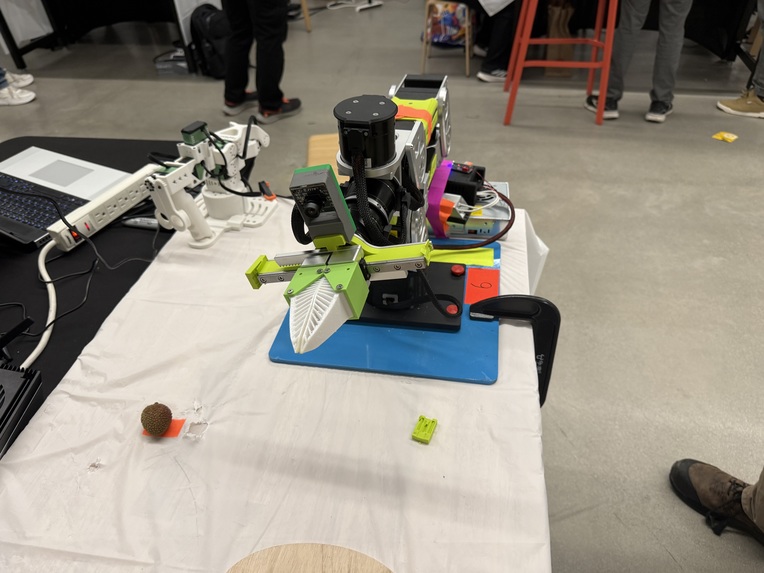
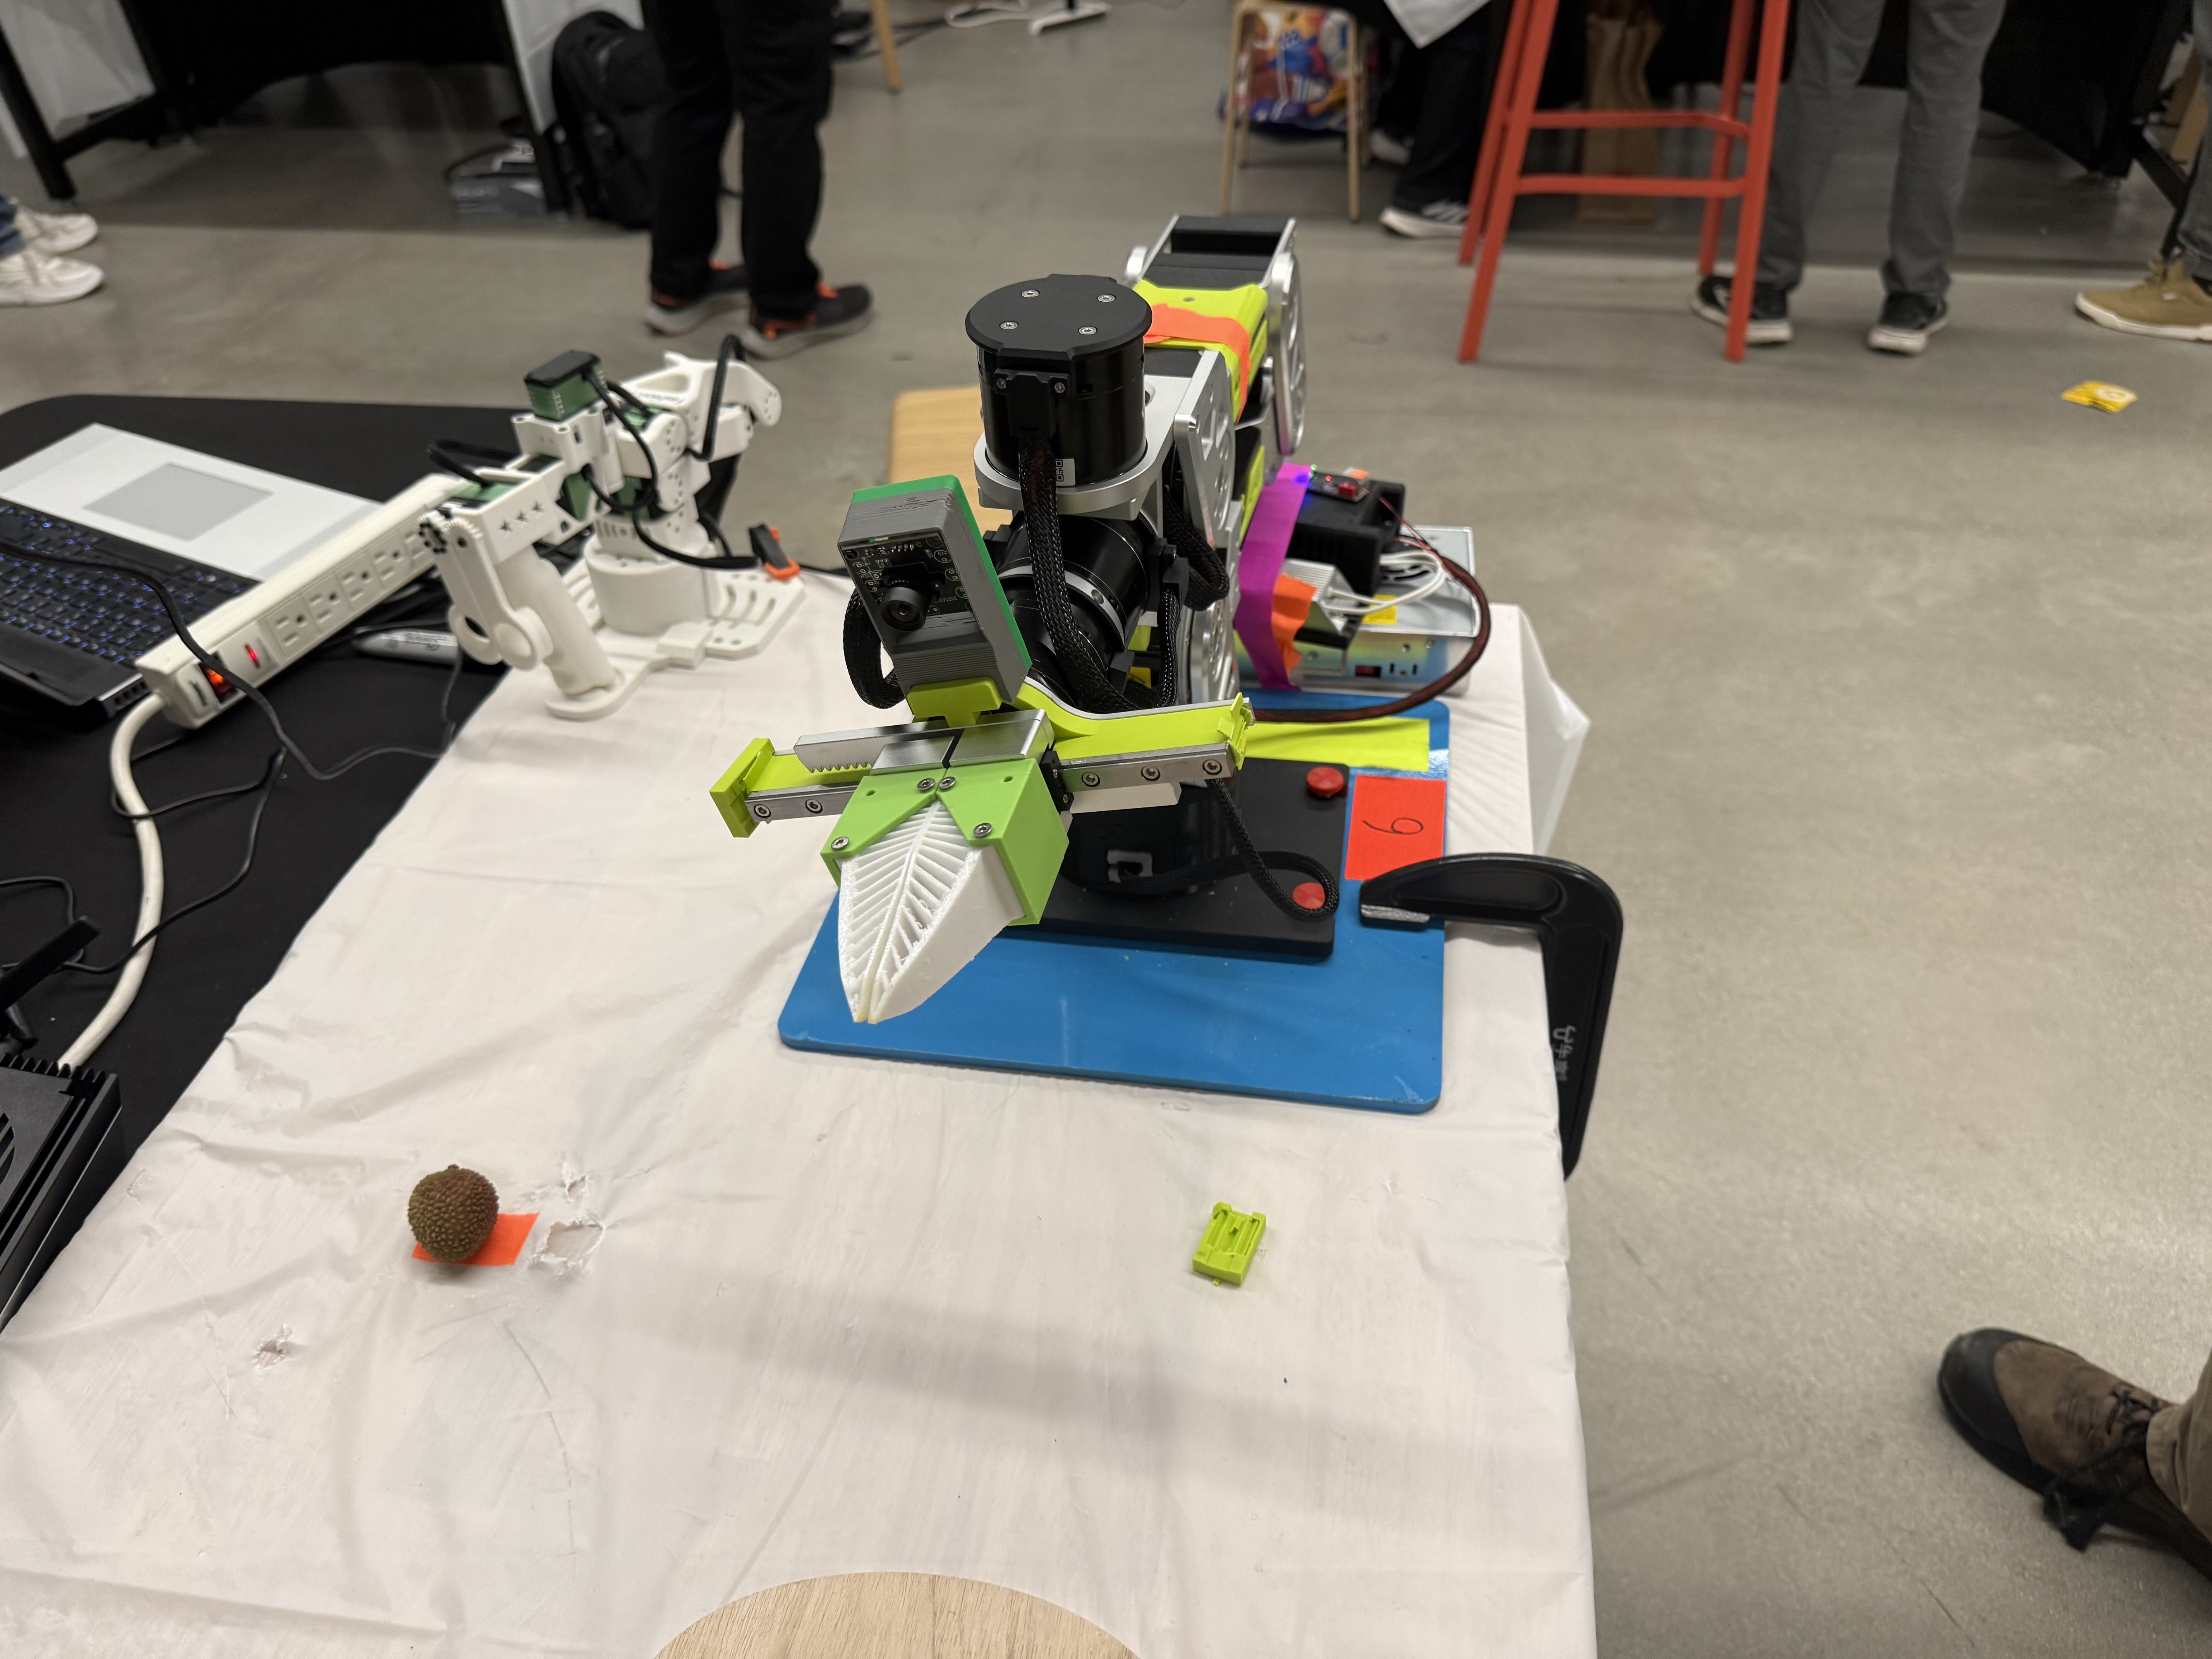
gripper in action
-
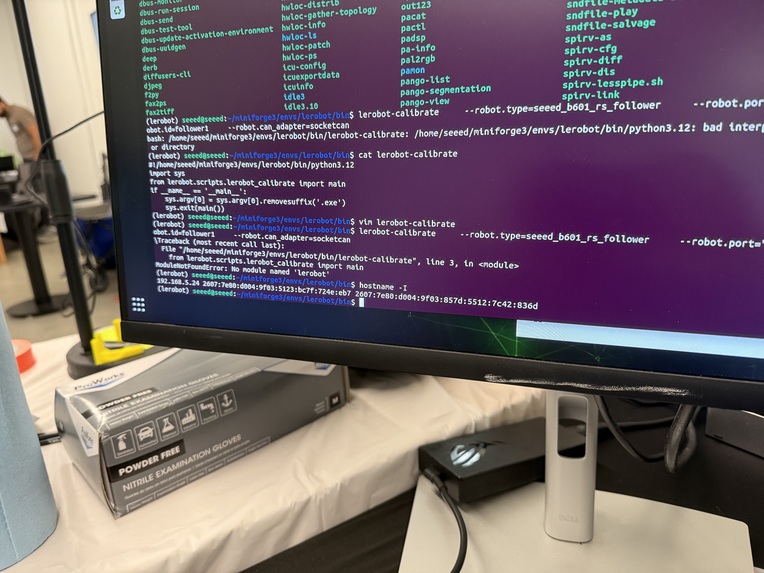
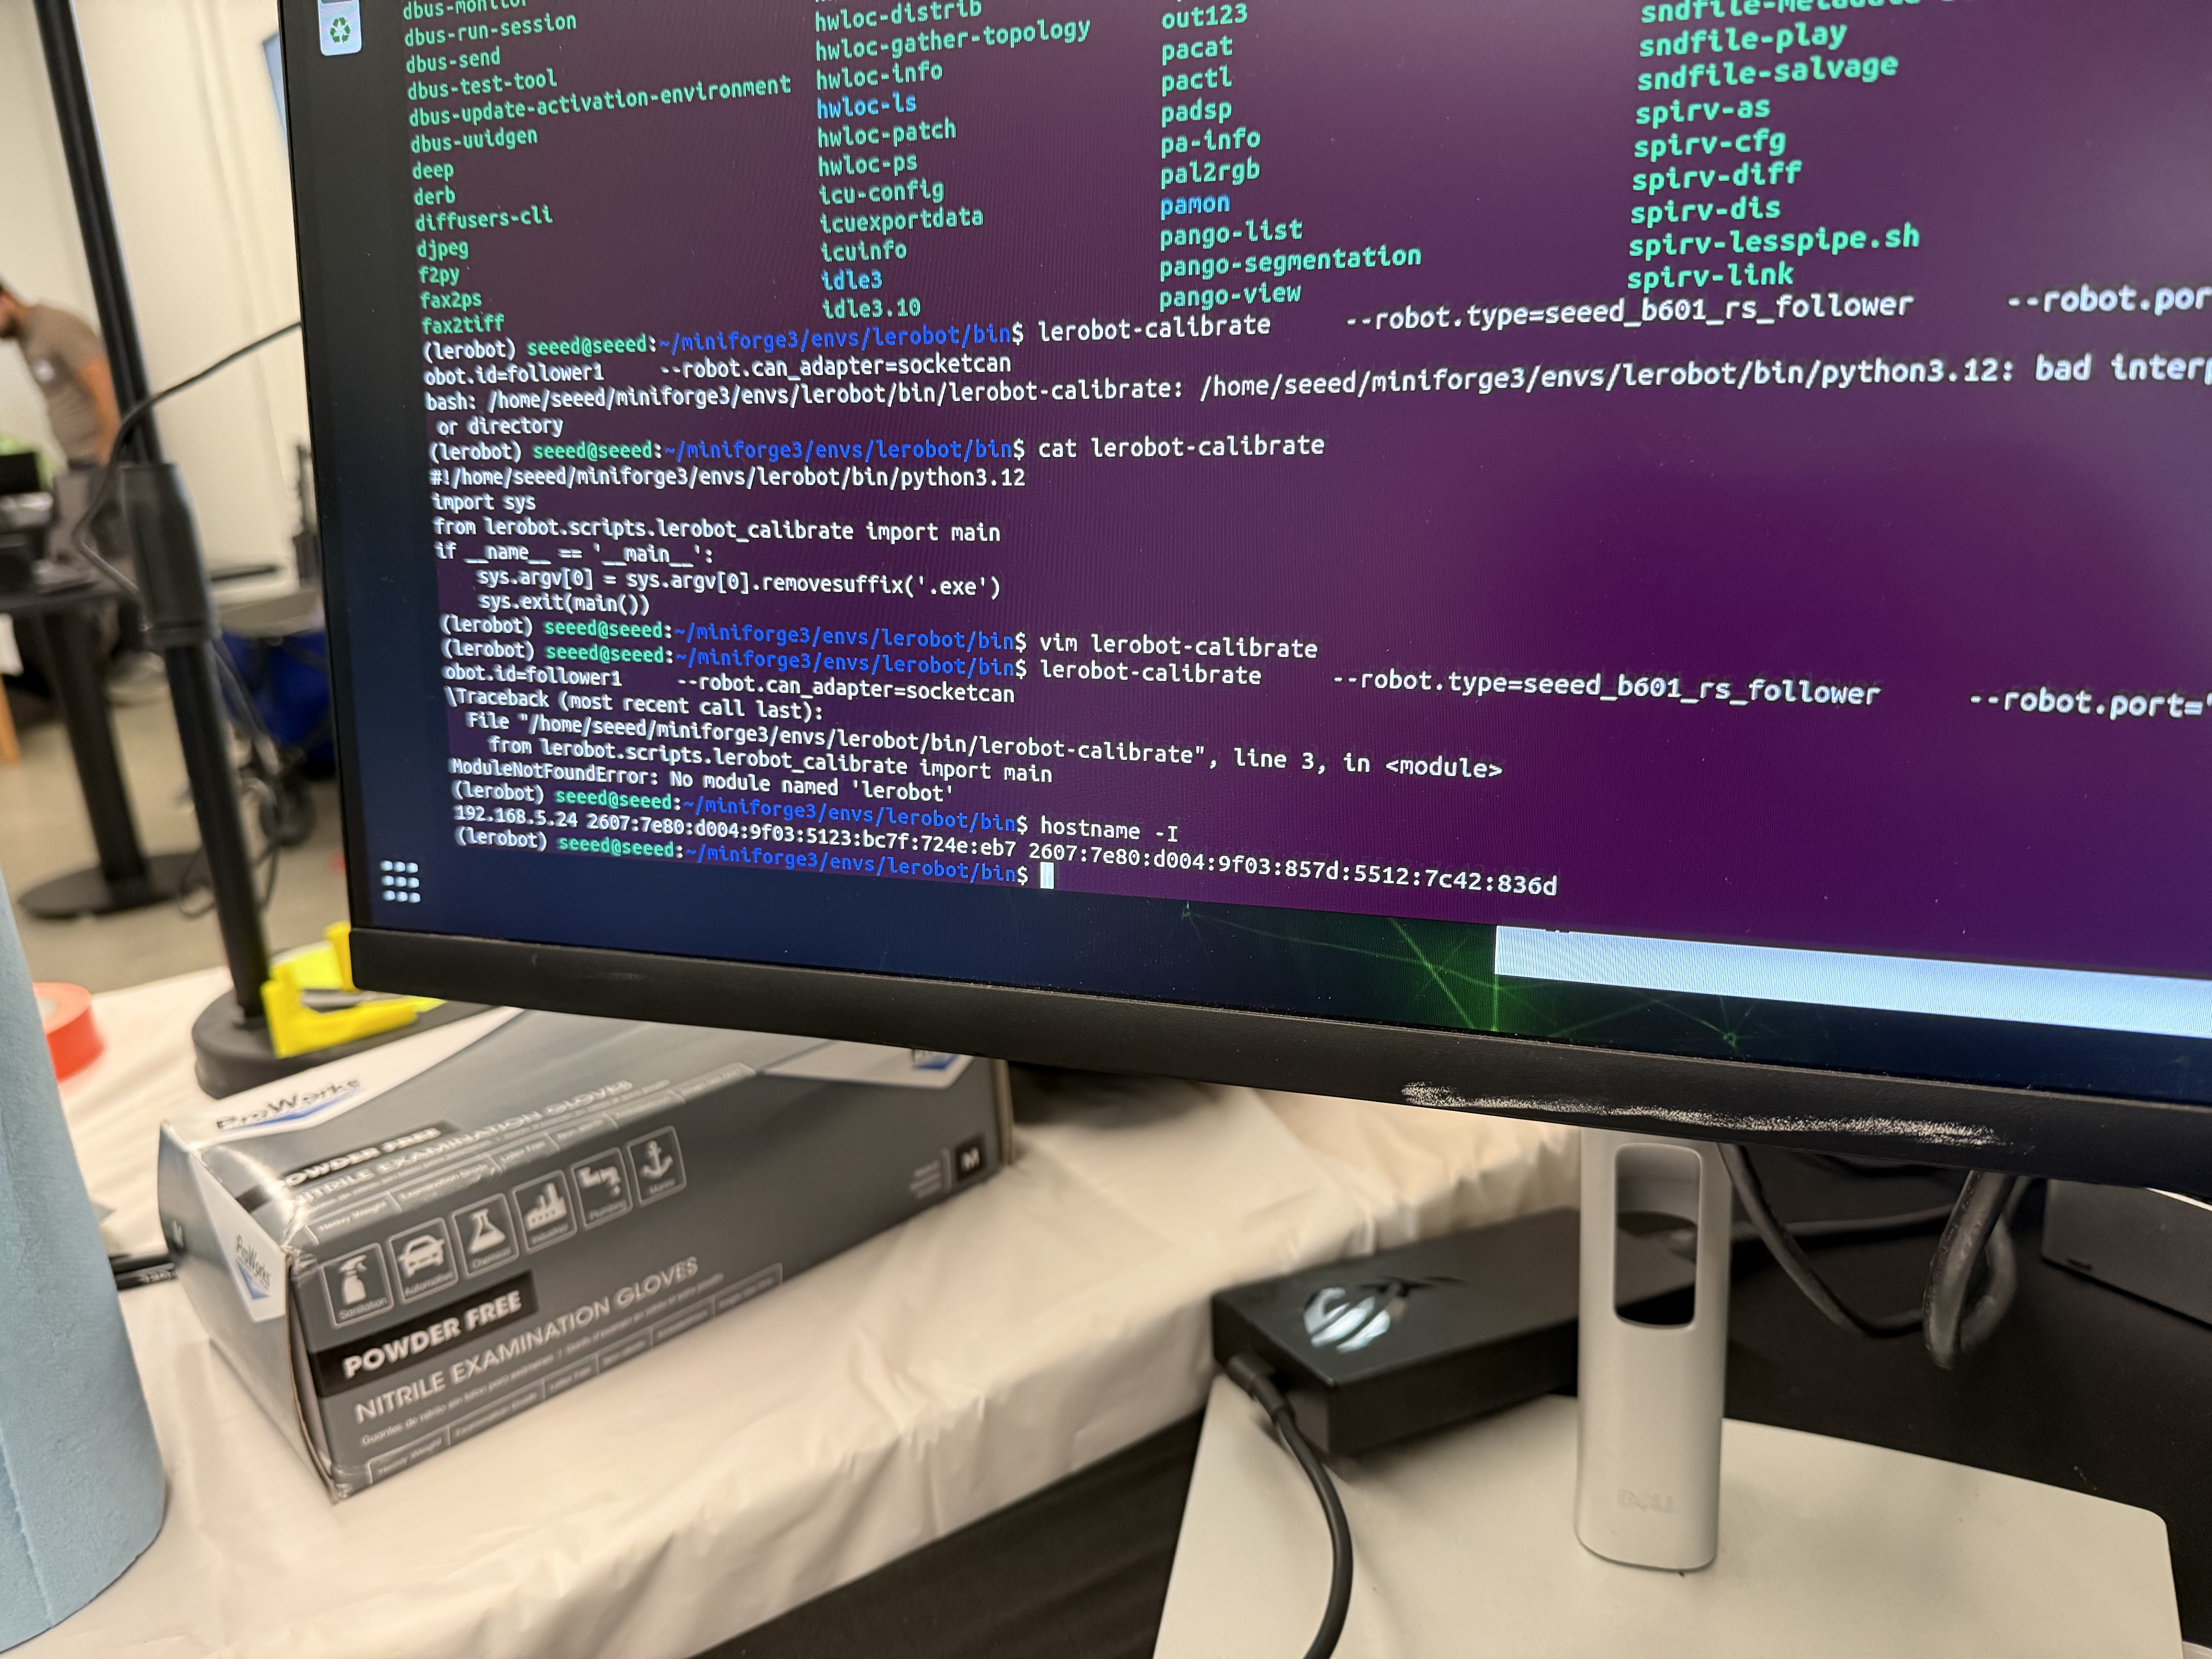
errors enountered
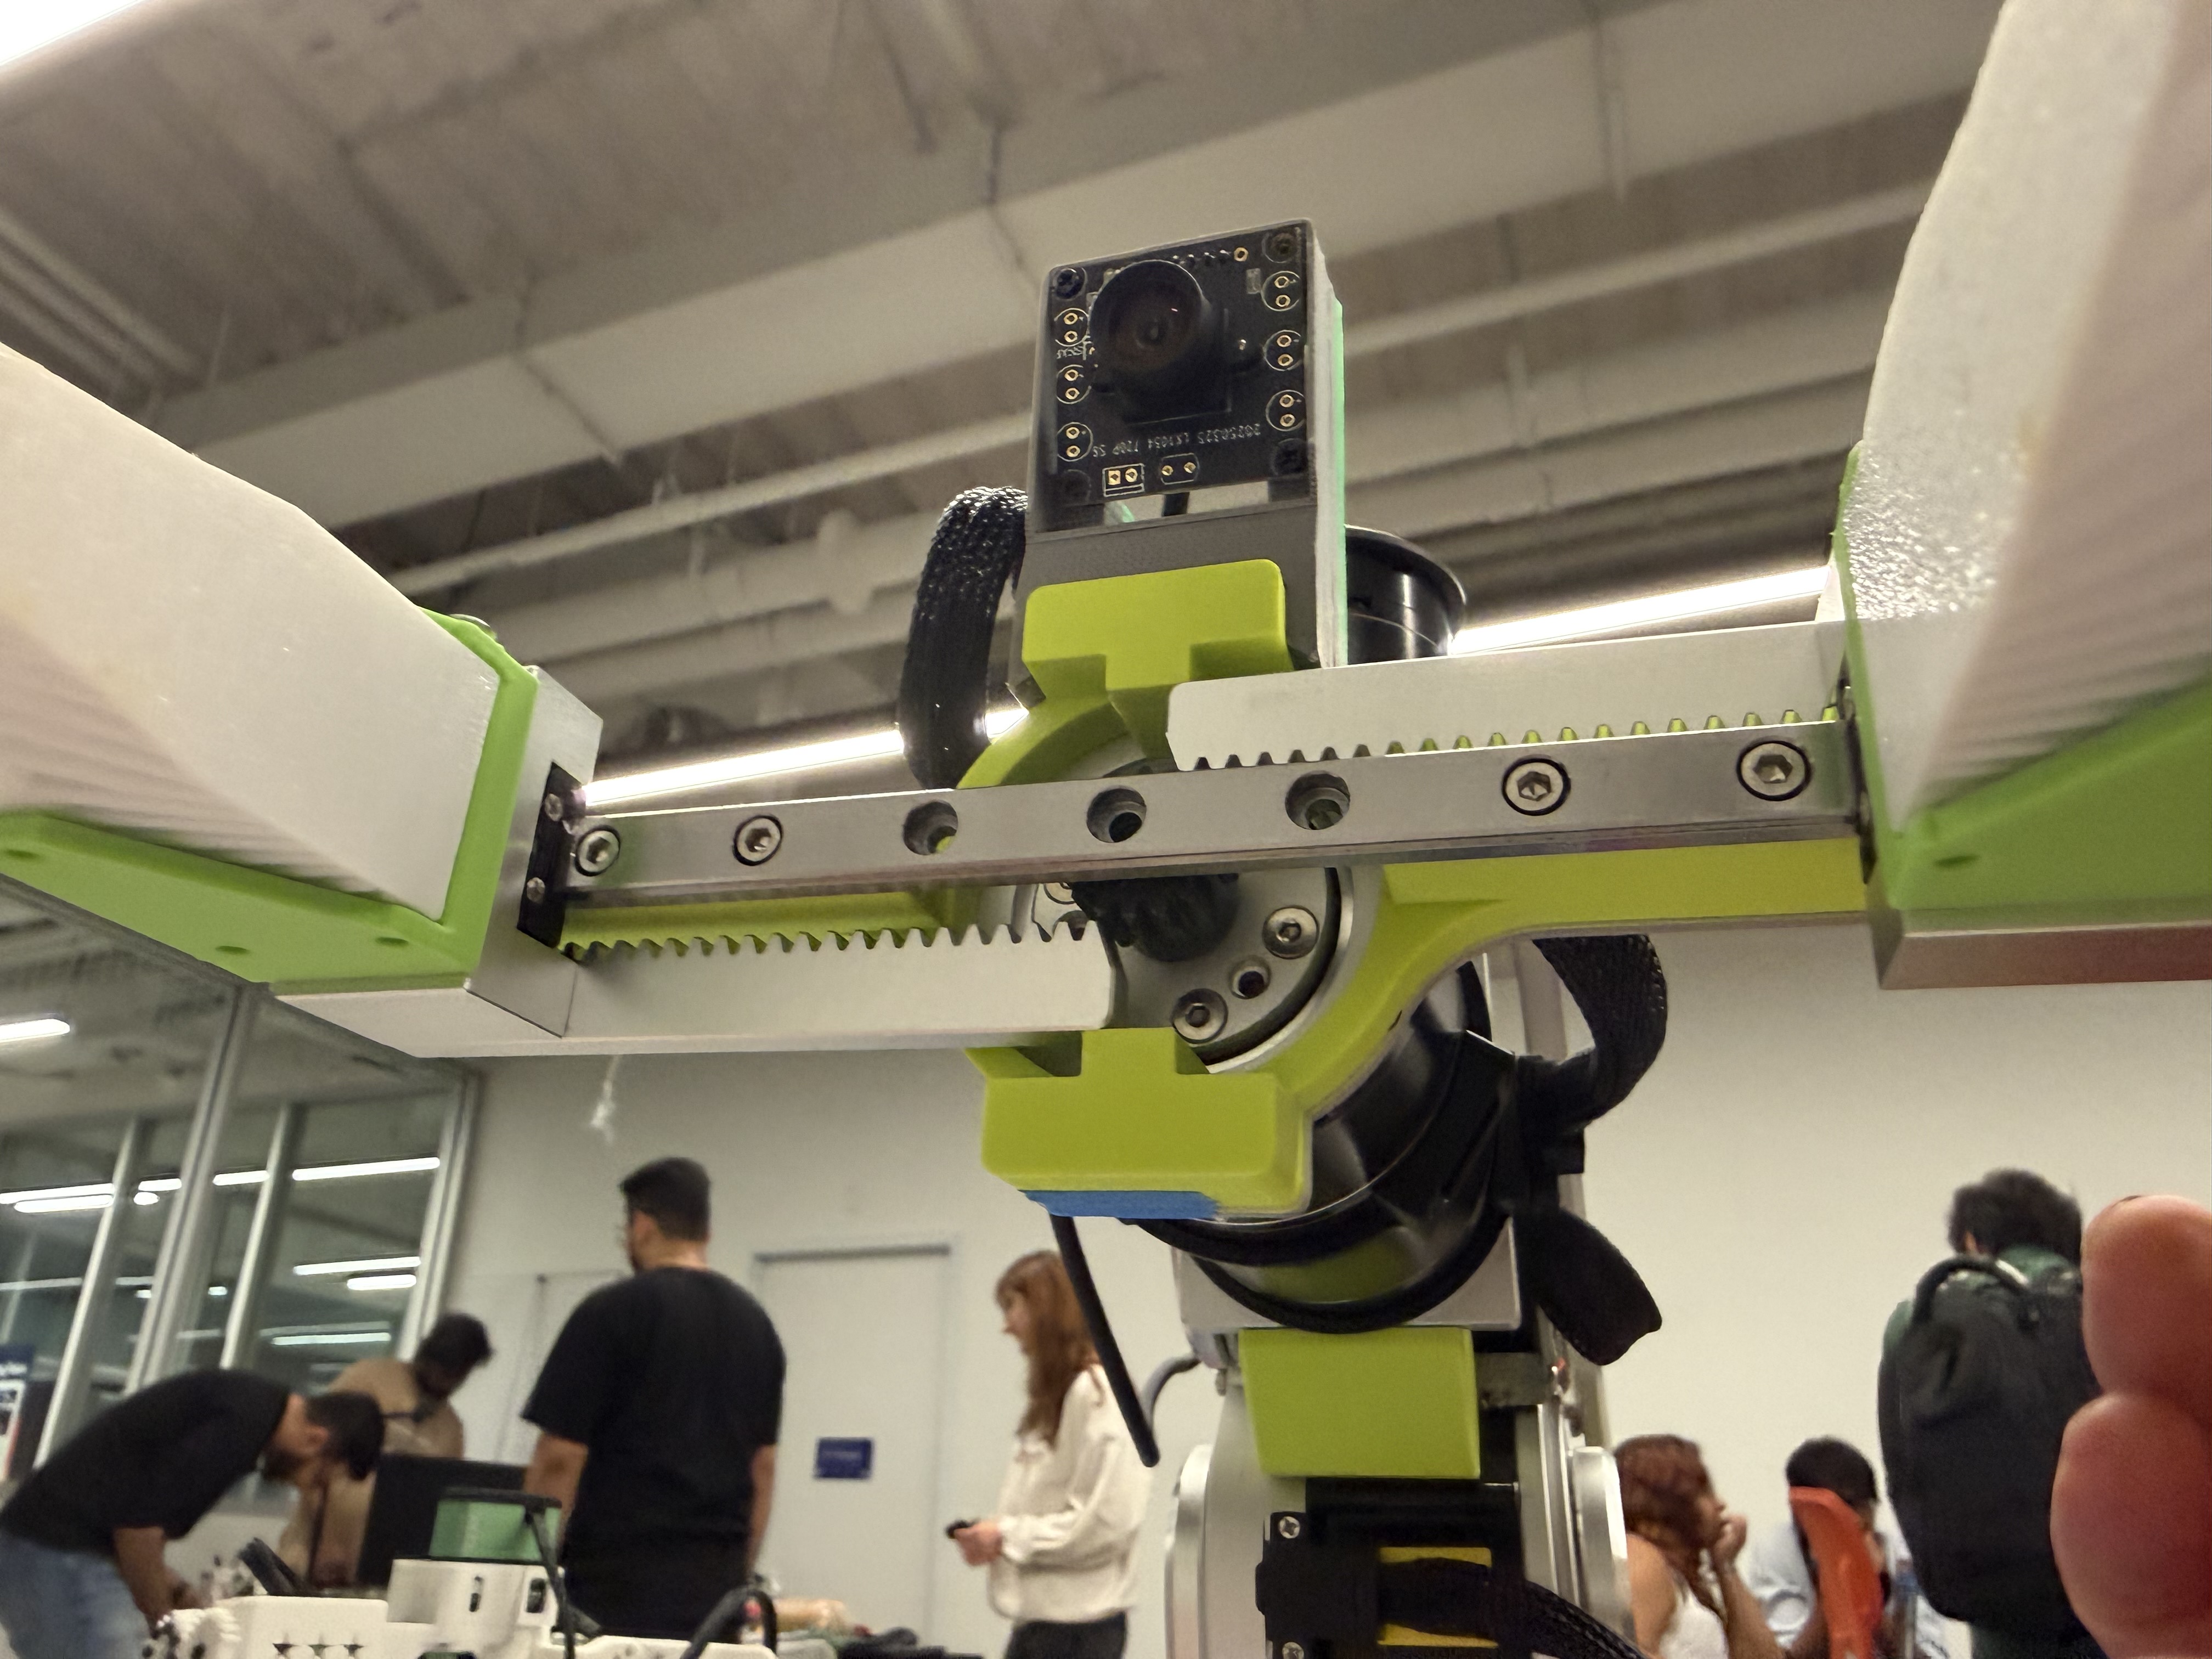
🍊 Fruitinator
A robot arm's journey from "let's plate a beautiful charcuterie board" to "please just pick up the orange" to "...why did it destroy the orange."
Built at Revolute — Boston's first robotics + physical AI hackathon. Theme: cooking with robot arms. Reality: cooking with our own sanity.
One-Liner
Fruitinator picks and places a fruit — and sometimes destroys it instead. Which is, appropriately, also a decent summary of what happens when you try to train a manipulation policy in two days.
TL;DR
An SO-100-class arm (reBot B601 RS) watches two cameras, learns from teleop demonstrations, and tries to autonomously pick up a piece of fruit — orange, lychee, or grape. It sometimes succeeds. It sometimes doesn't. It sometimes has opinions about the fruit.
📉 The Descent
A timeline of a charcuterie board slowly, painfully becoming an orange.
Hour 0–?: The Jetson has other plans
The Jetson decided setup day was optional. Certain libraries were locked to specific versions that didn't play nice with each other — the kind of dependency hell where fixing one thing breaks two more. lerobot-calibrate couldn't even find its own interpreter, then couldn't find the lerobot module at all.
Rage quit → new laptop
Eventually we cut our losses and started fresh on a different laptop entirely. Sometimes the fix isn't debugging harder, it's a clean slate.
The Great Downgrade: board → orange (→ lychee → grape)
Ambition met reality. We scaled the plan down from a full charcuterie board to individual fruit — orange, lychee, and grape got the teleop treatment one at a time.
Gripper drama
The gripper was the recurring troublemaker throughout — the part most likely to hold, drop, or straight-up ignore whatever fruit was in front of it. Every fix here bought a few good runs before something else went sideways again.
📸 Media
Event photos and general demo footage live on our shared Drive folder / demo video, rather than in this repo. The MuJoCo real-vs-sim comparison video and random rollout gif, however, are committed directly under media/ since they're generated technical artifacts of the sim work, not event photos:
media/episode0-real-vs-sim.mp4media/random-rollout.gif
🛠️ System Architecture & Story
🦾 Arm Setup
- Follower arm: reBot Arm B601 RS (
seeed_b601_rs_follower), connected over CAN bus via SocketCAN - Leader arm:
rebot_arm_102_leader, connected over serial (/dev/ttyUSB0) - CAN interface brought up at 1 Mbps (
bitrate 1000000,restart-ms 100,txqueuelen 1000) before anything else could talk to the arm - Verified the link with
lerobot-teleoperate(leader → follower) before recording any data
🎮 Teleoperation & Data Collection
- Recorded via
lerobot-recordwith two USB cameras:front(index 0) andside(index 2), both 640×480 @ 30fps, MJPG - 50 episodes recorded per fruit — orange, lychee, and grape — at 15s per episode with a 7s reset between each
- Fun fact: the lychee and grape datasets are named
*-fixed-10even though 50 episodes were actually recorded for each — a naming leftover nobody caught in time - Bigger fun fact: every single dataset's task label still says
"Grab the black cube"— a copy-pasted placeholder from the original starter template that survived all the way through, even for a project literally called Fruitinator - Orange and lychee datasets were later merged into one (
lerobot-edit-dataset --operation.type merge)
🧠 Model Training & Fine-Tuning
- Policy: ACT (Action Chunking Transformer), via
lerobot-train - Orange: trained for 50,000 steps (
act_orange-50-run2) - Lychee: trained for 50,000 steps (
act_lychee) - An earlier template/test run (
orange-fixed_4) was trained for only 20,000 steps — a shorter, earlier pass before scaling up - All runs:
policy.device=cuda, W&B logging disabled, no push to hub
🧪 Simulation (MuJoCo)
Alongside the real hardware pipeline, the arm was modeled in MuJoCo (converted from a URDF) so we could test things without waiting on the physical setup:
sim/rs-arm.urdf→sim/rs_arm.xml/sim/scene.xml: MuJoCo model of the follower arm, including a mocap-driven target sphere and a front-matching camera for visual comparison against the real footagesim/mujoco_gym_arm.ipynb: wraps the model in a custom Gymnasium environment,RSArmReach-v0— torque control over the 6 arm joints + 2 gripper fingers, reward shaped by distance to a randomly sampled target, with a small bonus on reaching it- Real-vs-sim replay: recorded teleop episodes (from the
orange-fixed_4dataset) are replayed kinematically in the sim model and rendered side-by-side against the real camera footage — seemedia/episode0-real-vs-sim.mp4 - Random rollout:
media/random-rollout.gifshows the untrained/random policy flailing around in sim — a nice visual baseline for "the arm has no idea what it's doing yet" notebooks/open_parquet.ipynb: a small utility notebook for loading and inspecting the recorded LeRobot dataset (parquet files) directly, outside of the training pipeline
Where this was headed next (per the notebook's own "potential next steps," not yet implemented):
- Estimating each fruit's size/location automatically and feeding that into a config rather than hardcoding it
- Training a policy in sim to move an object between two locations, using that as a cheaper/faster complement to real-world training
- Running the full pick-and-place sequence across all three fruits back-to-back, more like a real motion-planning task
🚀 Edge Deployment / Inference
- Evaluation run via
lerobot-record, loading the trained checkpoint (checkpoints/050000/pretrained_model) directly on hardware — no separate "inference-only" script, eval just re-runs the record pipeline with a policy attached instead of a human - Ran separate eval passes for orange and lychee, logged as new
eval_test_*datasets for review - Recorded runs on both fruits: at least one clean successful pick, and at least one drop/miss — captured on video (see Media section above)
🎬 Current Status
Partially working. The trained policy (ACT, 50k steps) can pick up fruit — but grip and release aren't fully reliable yet. Sometimes it gets a clean grasp, sometimes it drops the fruit mid-transit, and sometimes it just... misses. Consider it a solid proof of concept with an honest amount of "it depends on the fruit's mood that day."
What's confirmed working end-to-end:
- CAN bus + camera pipeline stable
- Teleop recording pipeline solid (150 episodes across 3 fruits)
- ACT policy trains and loads onto hardware for inference
What's still cursed:
- Grasp reliability (drops / misses)
- Consistency across different fruit shapes/sizes
🧠 What We'd Do Differently
- Actually update the task label instead of shipping "Grab the black cube" to production for a fruit-picking robot
- Fix dataset naming before recording 50 episodes, not after
- Test the CAN bus and camera setup the night before, not at hour zero of the hackathon
👥 Team
- Jinhee
- Phil
Acknowledgments
Thanks to Seeed Studio for the hardware, FabLab Kendall for hosting, and the orange for its sacrifice.
Built With
- act