Inspiration
Fog and low-visibility conditions can make it difficult for vehicle operators to identify nearby vehicles and obstacles in time. In mining environments, this becomes especially important because large vehicles operate close to each other and reduced visibility can affect safe movement and productivity.
This inspired us to build FogSafe, a connected vehicle safety system that can provide additional awareness when human visibility is limited.
What it does
FogSafe monitors the safety conditions around connected vehicles using multiple sensing and communication methods.
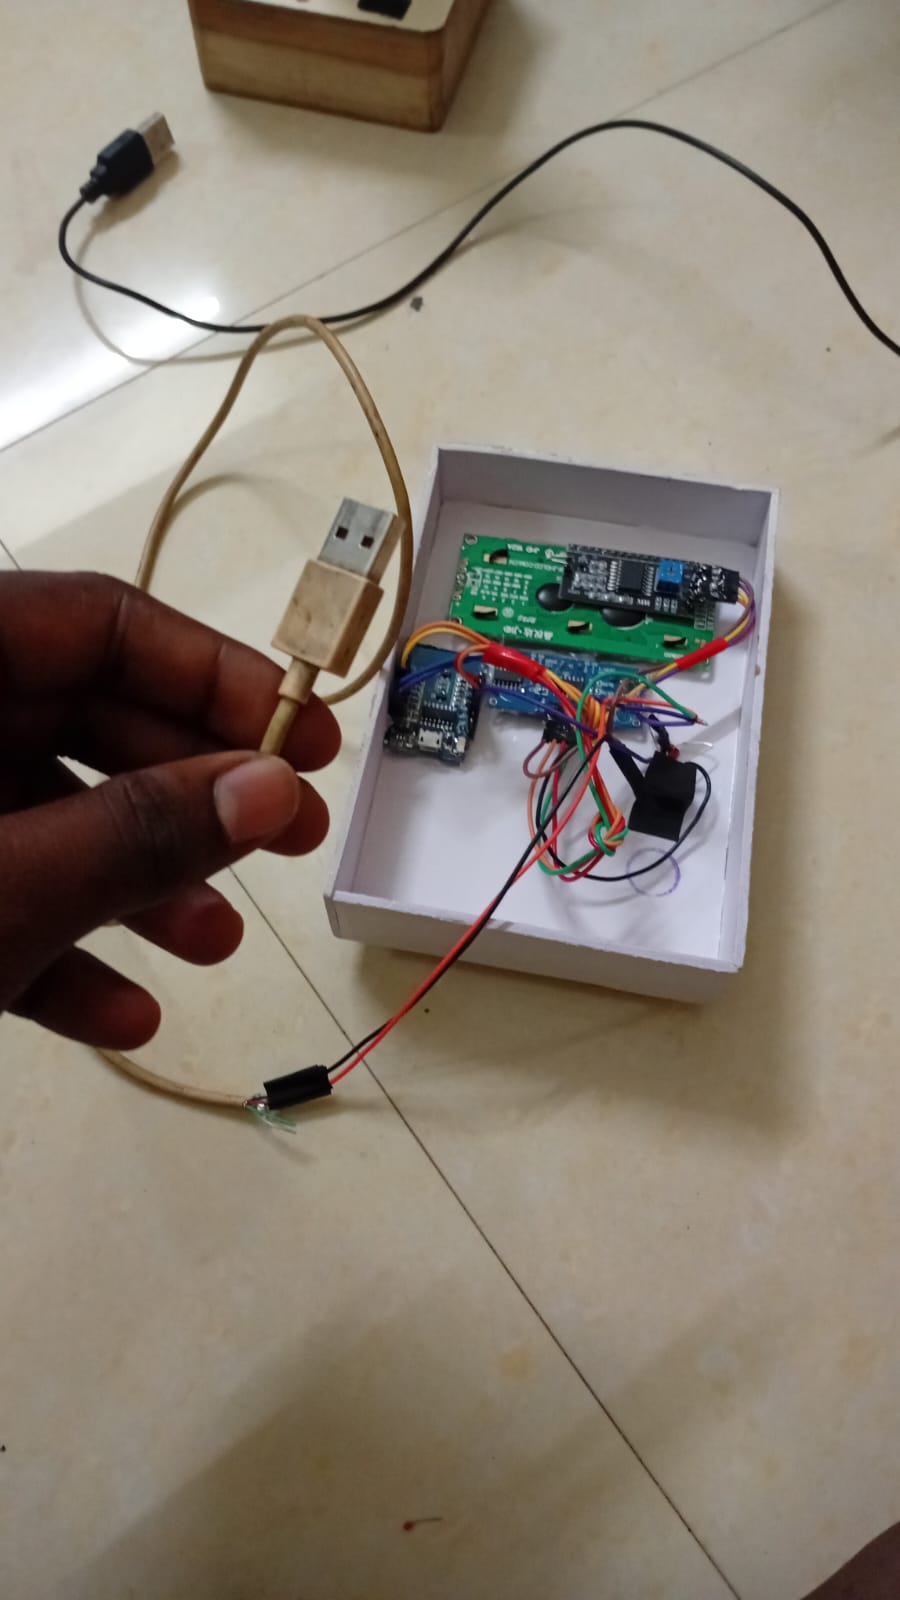
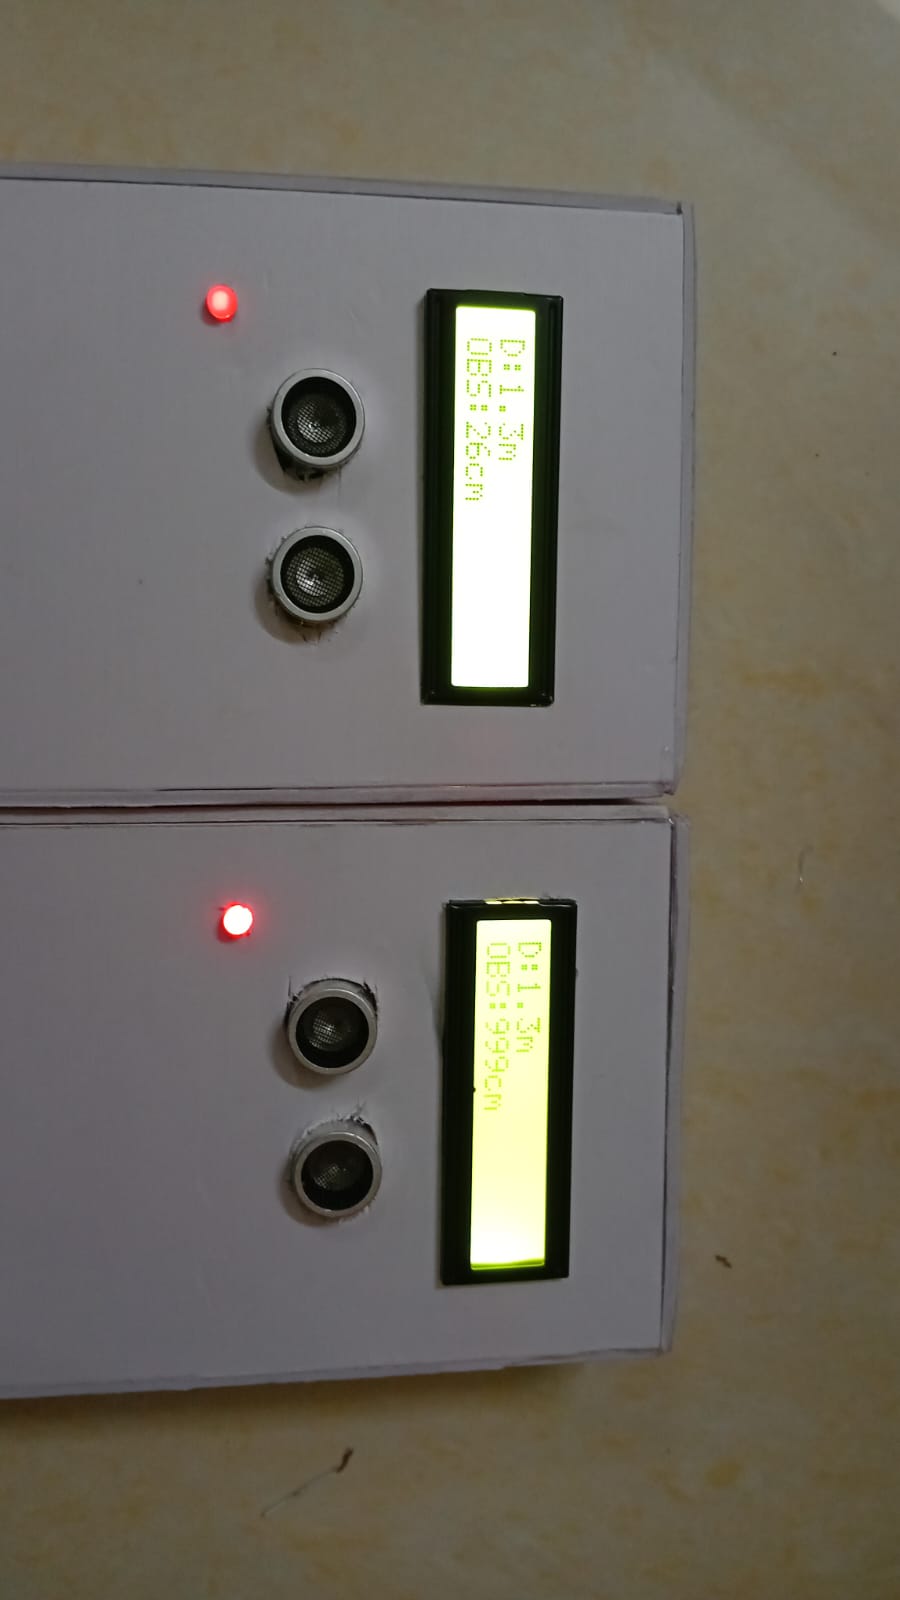
Our working prototype uses ESP8266 controllers, ultrasonic sensors, LCD displays, buzzers, and Wi-Fi communication. Ultrasonic sensors detect obstacles in front of the vehicles, while Wi-Fi signal strength (RSSI) is used to estimate the approximate distance between vehicles.
The information is also displayed on a web dashboard, where users can monitor vehicle proximity, obstacle distance, Wi-Fi signal strength, and safety status such as SAFE, WARNING, and DANGER.
How we built it
We developed a two-vehicle prototype using ESP8266 boards as the main controllers. Each vehicle is equipped with an ultrasonic sensor for obstacle detection and an LCD for local monitoring.
The ESP8266 boards communicate through Wi-Fi, allowing us to use RSSI to estimate approximate inter-vehicle proximity. A buzzer provides local warning alerts, while the web dashboard provides a centralized view of the monitored information.
Our broader system architecture is designed to support future integration of technologies such as radar, LiDAR, thermal cameras, GPS, V2V/V2I communication, and edge AI.
Challenges we ran into
One of the main challenges was combining vehicle-to-vehicle communication, obstacle detection, local alerts, and dashboard monitoring into one connected prototype.
RSSI-based distance estimation is also affected by the surrounding environment, so we treat it as an approximate measurement rather than an exact distance. We also had to design the prototype so that important warnings could be provided locally without depending entirely on the dashboard.
Accomplishments that we're proud of
We successfully developed a working prototype that connects two vehicle representations through Wi-Fi and combines proximity estimation, obstacle detection, LCD monitoring, buzzer alerts, and a web-based dashboard.
We are especially proud of bringing hardware and software together into a single connected safety system rather than demonstrating each component separately.
What we learned
Through this project, we learned how embedded systems, wireless communication, sensors, web interfaces, and real-time monitoring can work together to solve a practical safety problem.
We also learned the importance of validating sensor limitations and designing safety systems with both local and centralized monitoring.
What's next for FogSafe: AI Enabled Multi Sensor Vehicle Safety System
Our next step is to move from the current prototype toward a more robust multi-sensor system for real-world low-visibility environments.
Future development can include sensor fusion using LiDAR, mmWave radar, thermal cameras, and GPS, together with edge AI for risk assessment. We also aim to extend the system from two connected vehicles to a larger fleet and provide centralized monitoring through a mine control-room dashboard.
Built With
- buzzer
- c++
- communication
- css
- dashboard
- detection
- embedded
- esp8266
- html
- iot
- javascript
- lcd
- obstacle
- proximity
- real-time
- rssi
- sensor
- systems
- ultrasonic
- web
- wi-fi
- wireless


Log in or sign up for Devpost to join the conversation.