FlyBrain — Lightweight neurological inference for hardware agnostic robotic challenges.
Robotics is not software. There is very difficult power and compute constraints when solving hard problems like avoiding collisions, self-balancing, swarm directions, etc. Almost all robots from drones to autonomous vehicles to insectoids need some/all of these features.
FlyBrain addresses this challenge through neural inference using actual fly connectome data. Our Python backend compiles the neural inference into a standalone C99 file, meaning you can run on any microcontroller, chip, or GPU, with visibility into inference cost, voltage, rates, etc.
We also activate the flys synaptic weights which allow for continuous learning, temporarily stored for any environment. We take all sensory input and action chunking and store it in Tiger data, that way we can persist the continual memory as long-term policy rl.
We use Nemetron to identify joints within a URDF and then map the fly's action chunker into any joints. So running the fly's brain on a drone versus a quadruped or a humanoid is all indifferent.
Visual motion and approaching threats drive that activity, and a motor decoder translates neural outputs into steering, thrust, and escape commands. Collision avoidance is our first target for hardware validation.
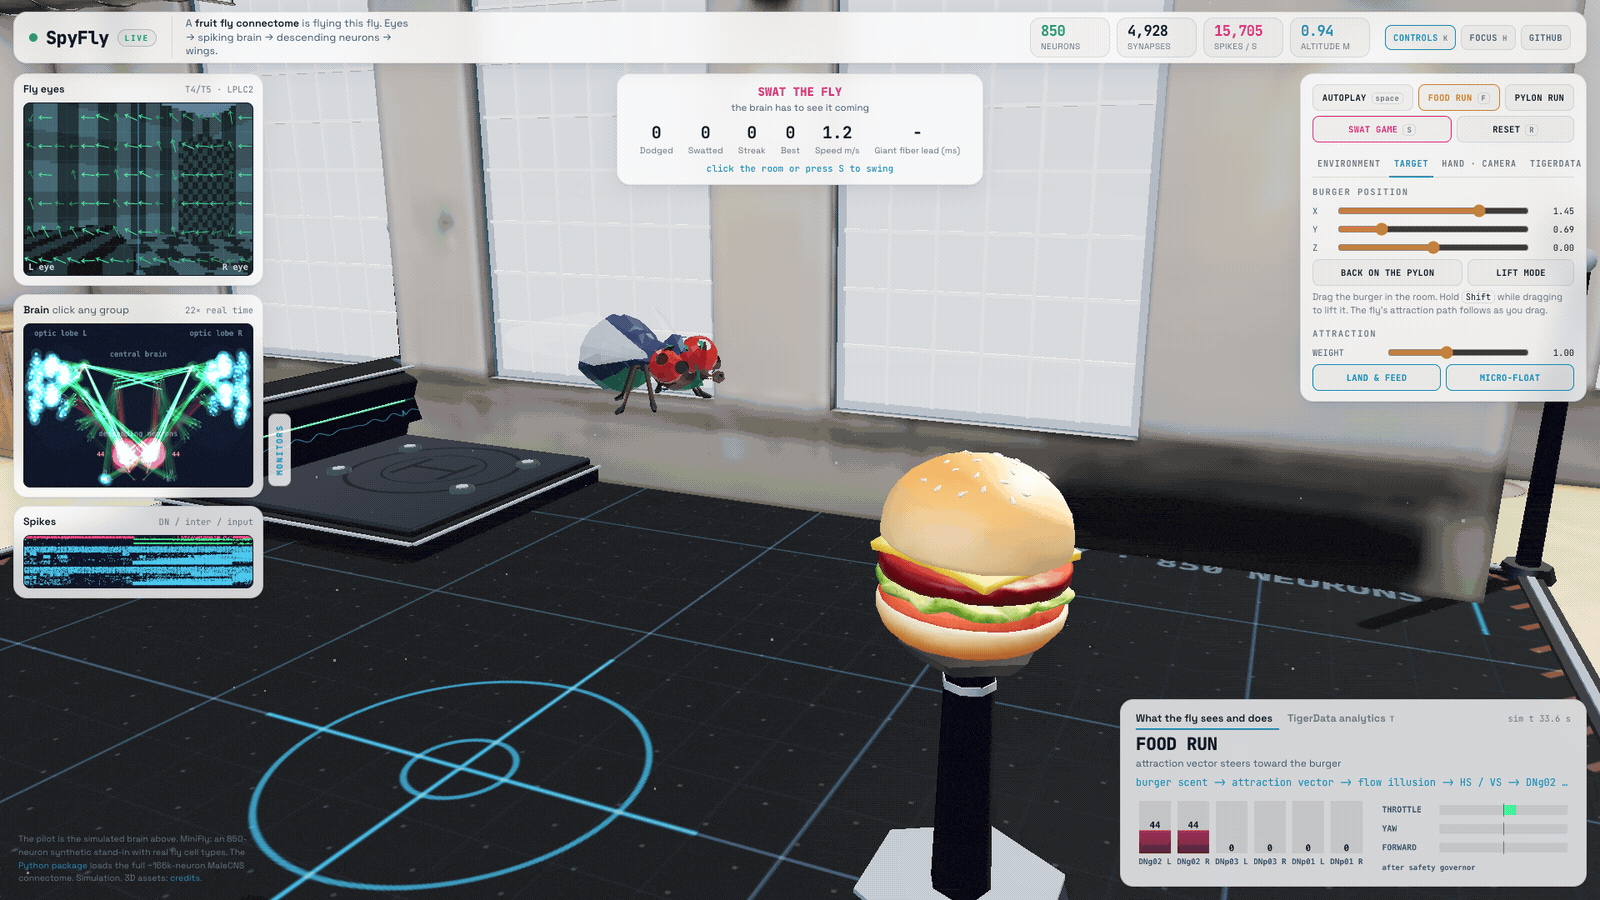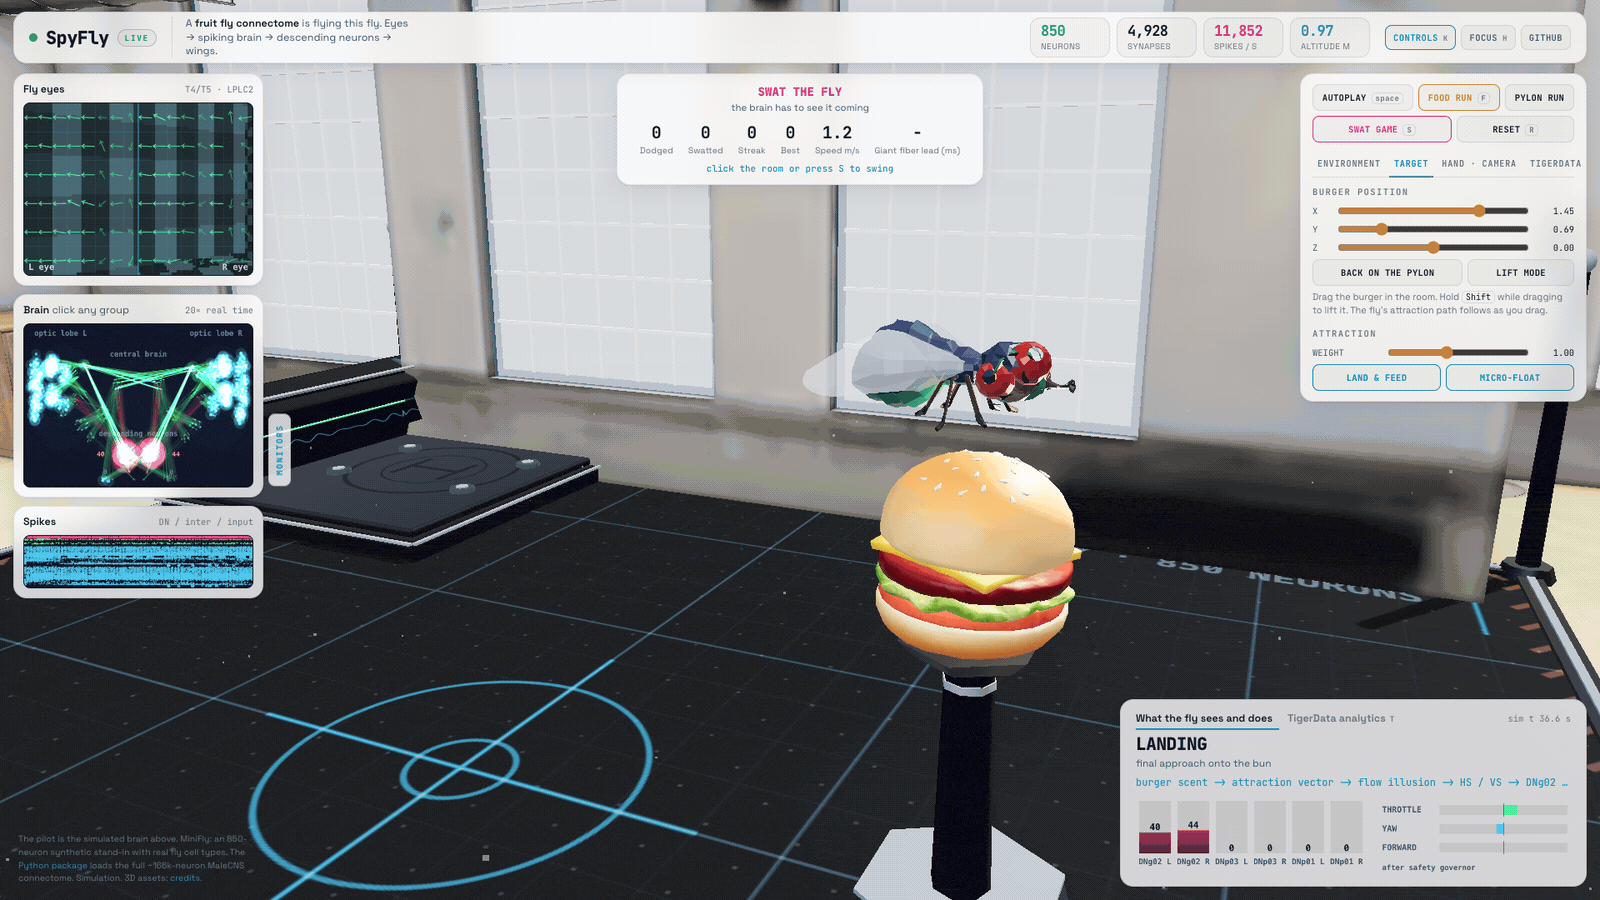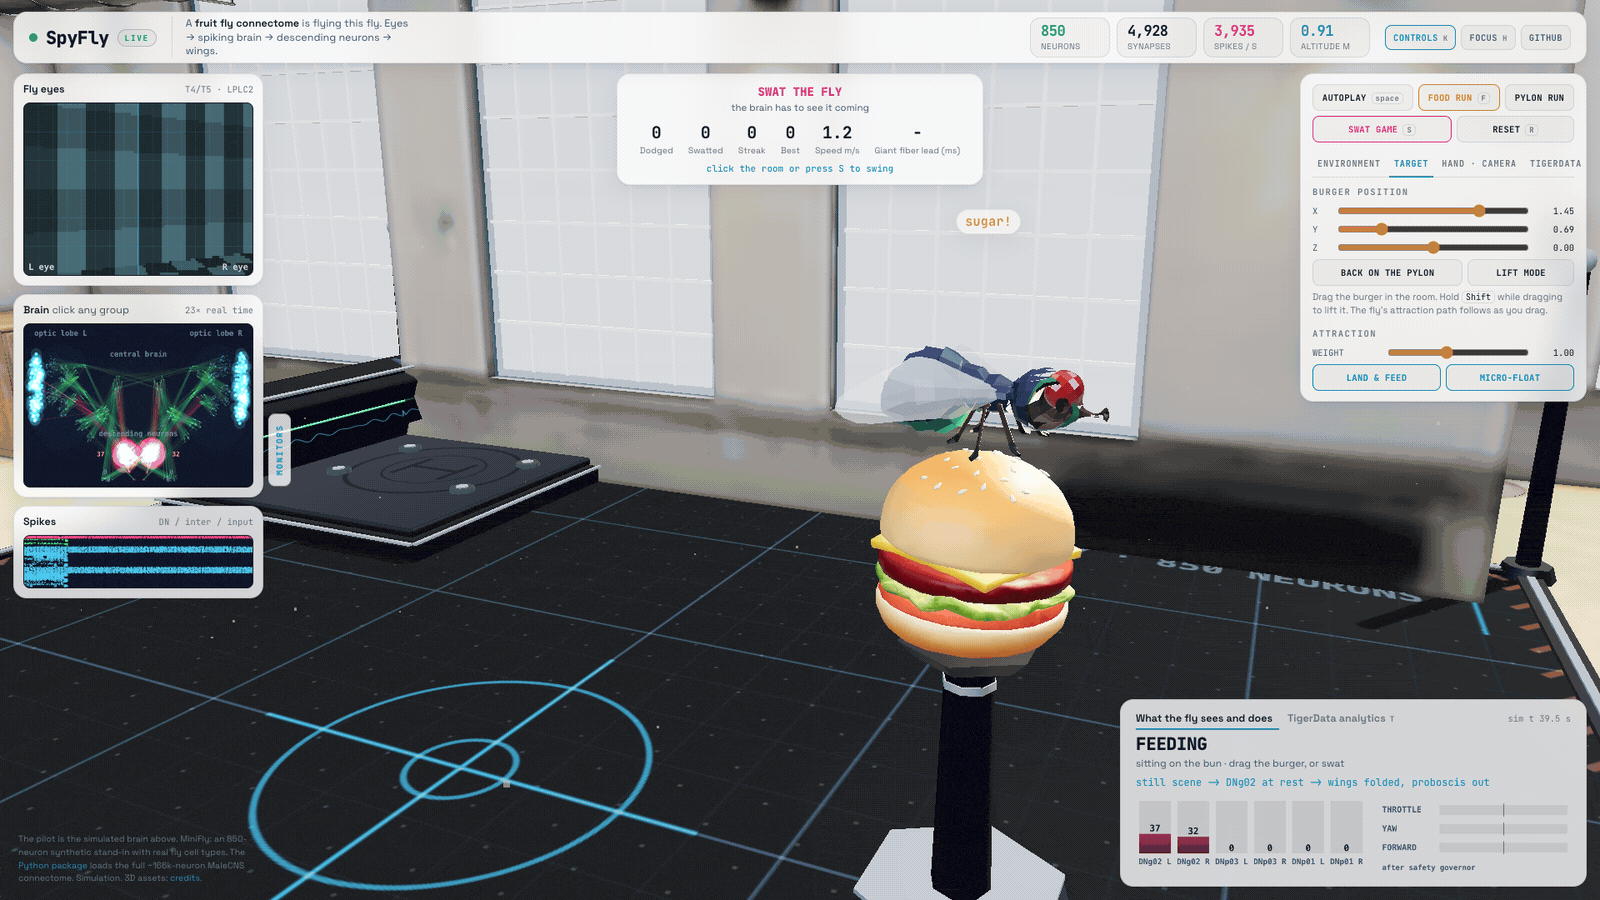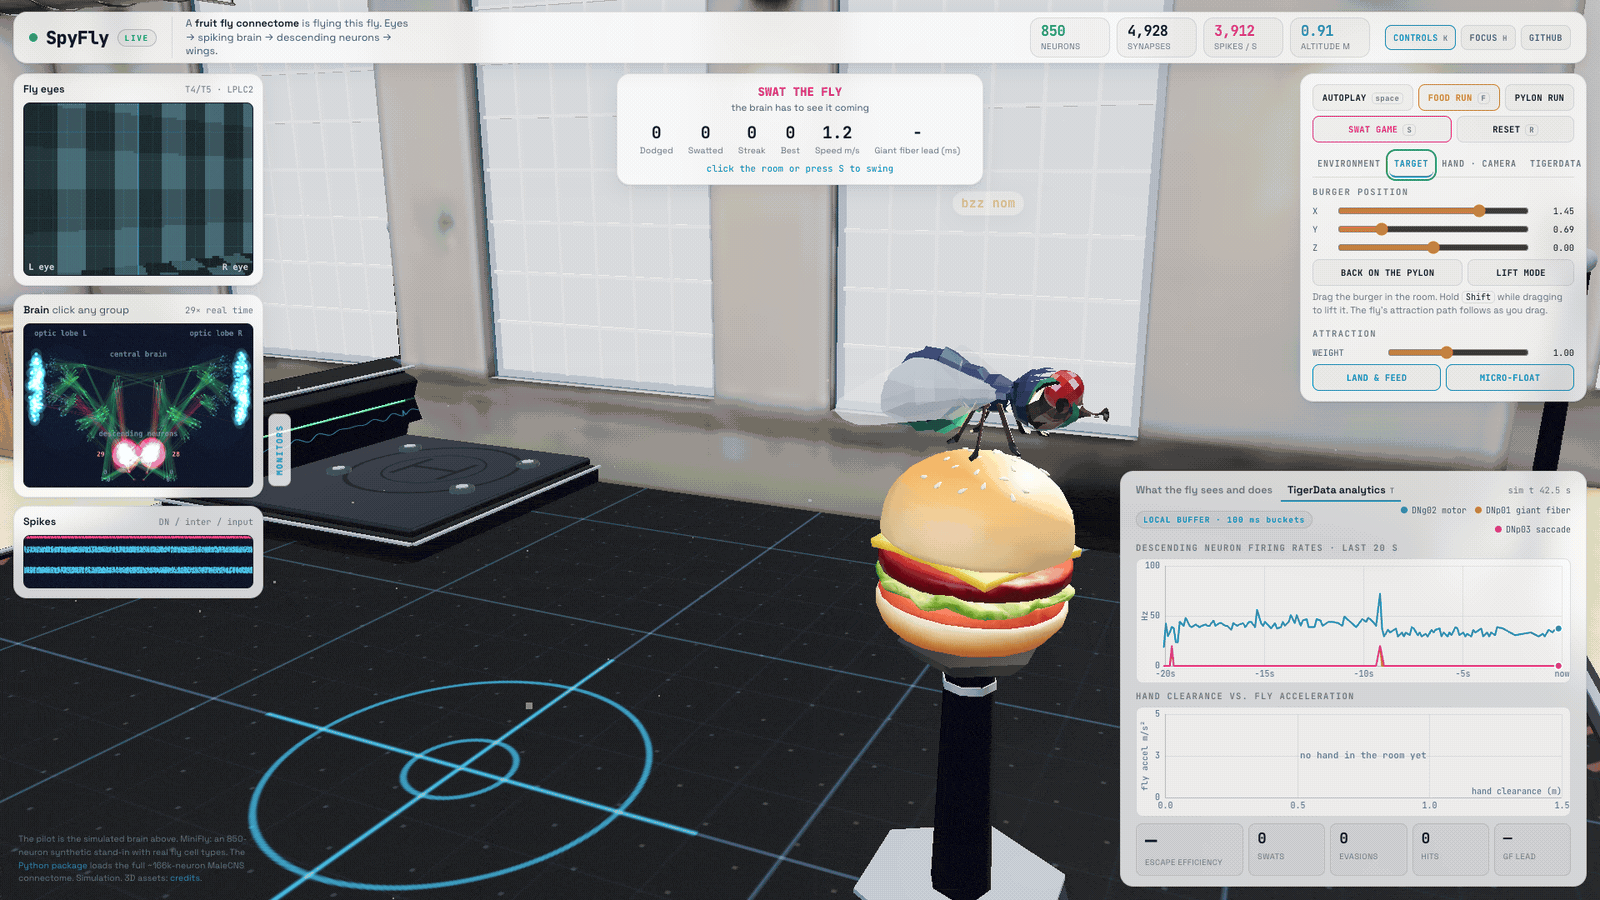
Our browser sim is a lightweight kinematics physics simulation. allowing users introduce an approaching hand (reflex), move a burger target (dopaime/goal setting), walled area (collision avoidance) and watch the fly respond, in a lightweight kinematics physics simulation.
Biology has solved many robotics problems after years of evolution for extremely low compute. We harness that and allow anyone to compile this circuitry to their robot even with no connectivity.
Our next step is to validate collision avoidance on physical hardware and measure reaction timing, reliability, and energy not just against benchmarks. Also being able to agentically create simulations and rl environments/evals for different robots.
The main product is an API to compile neurlogical inference to hardware.
Built With
- bci
- c99
- nemotron
- onnx
- python
- tigerdata


Log in or sign up for Devpost to join the conversation.