Inspiration
Seeing people throw trash in the wrong bins, we realized that they don't know which bin to actually throw it in, and nobody has time or want to put in the effort to actually search for which box it goes in. For example, when a recycling bin gets contaminated with garbage from a random person who didn’t care enough to look, the recyclable material can be ruined, and at worst, all of the recycling will be sent to a landfill instead. Vice versa, if someone puts recycling in a garbage bin, it wastes the potential of it getting another life. Although it seems like a small problem, with almost the entire global population disposing waste each day, just by creating a hugely scalable solution for this seemingly small problem, we can face the waste, internationally.
What it does
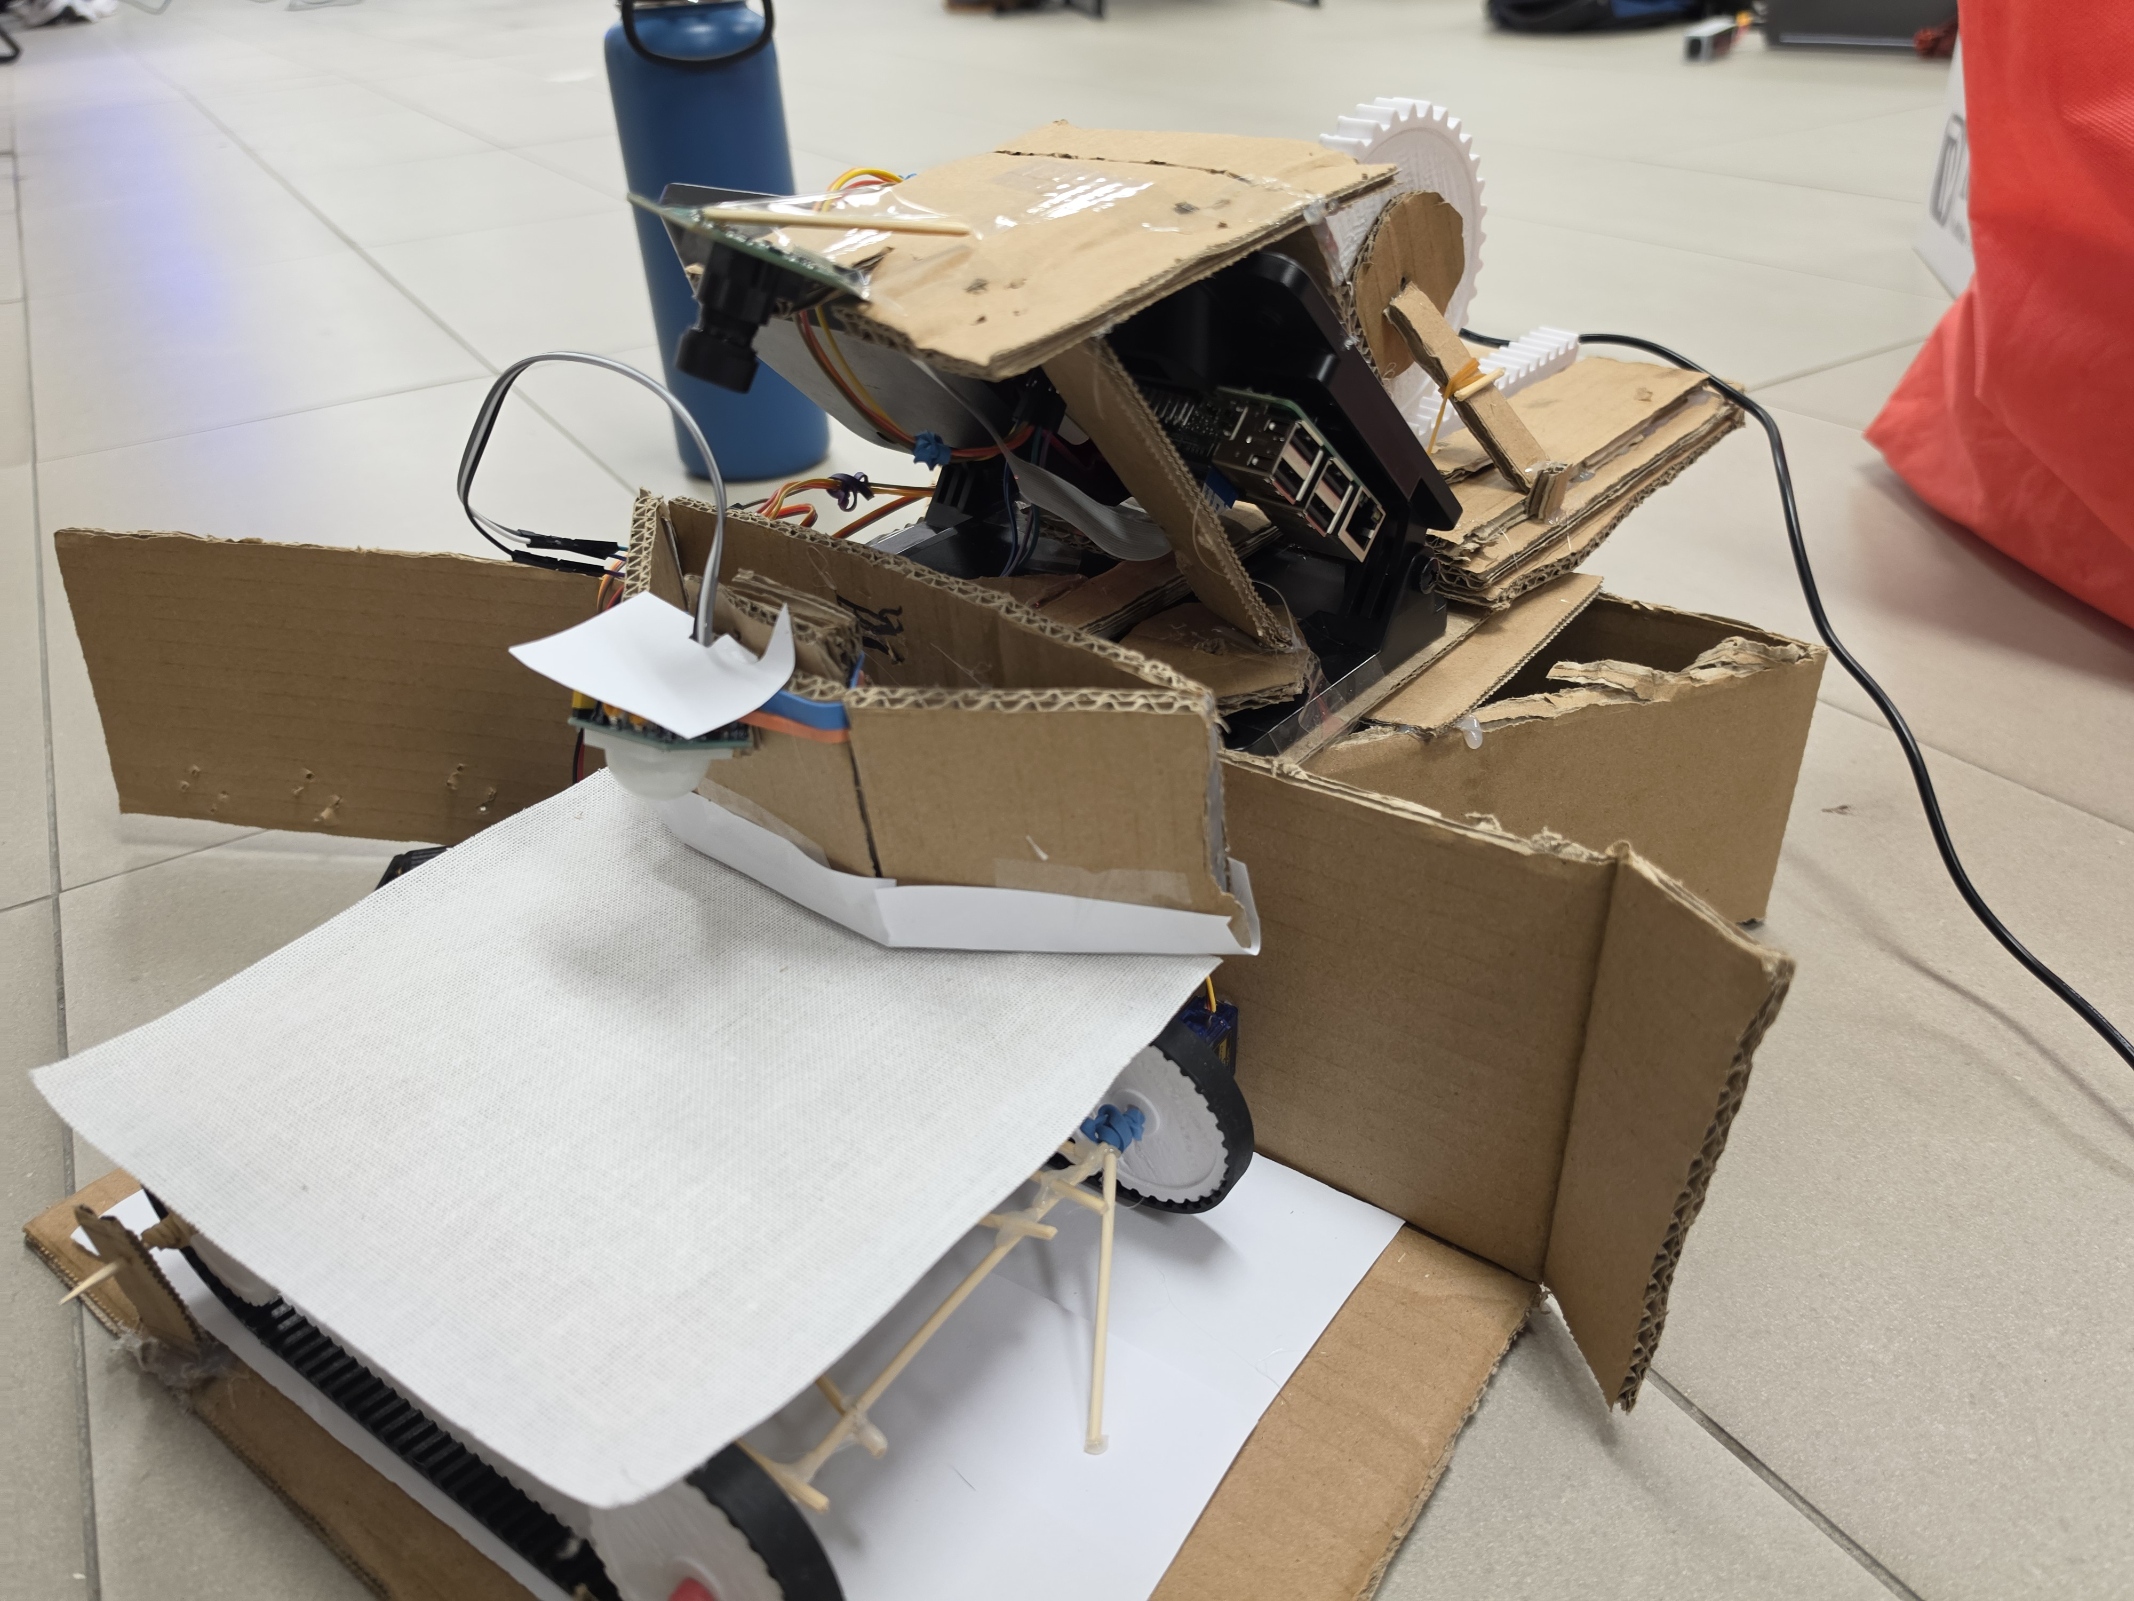
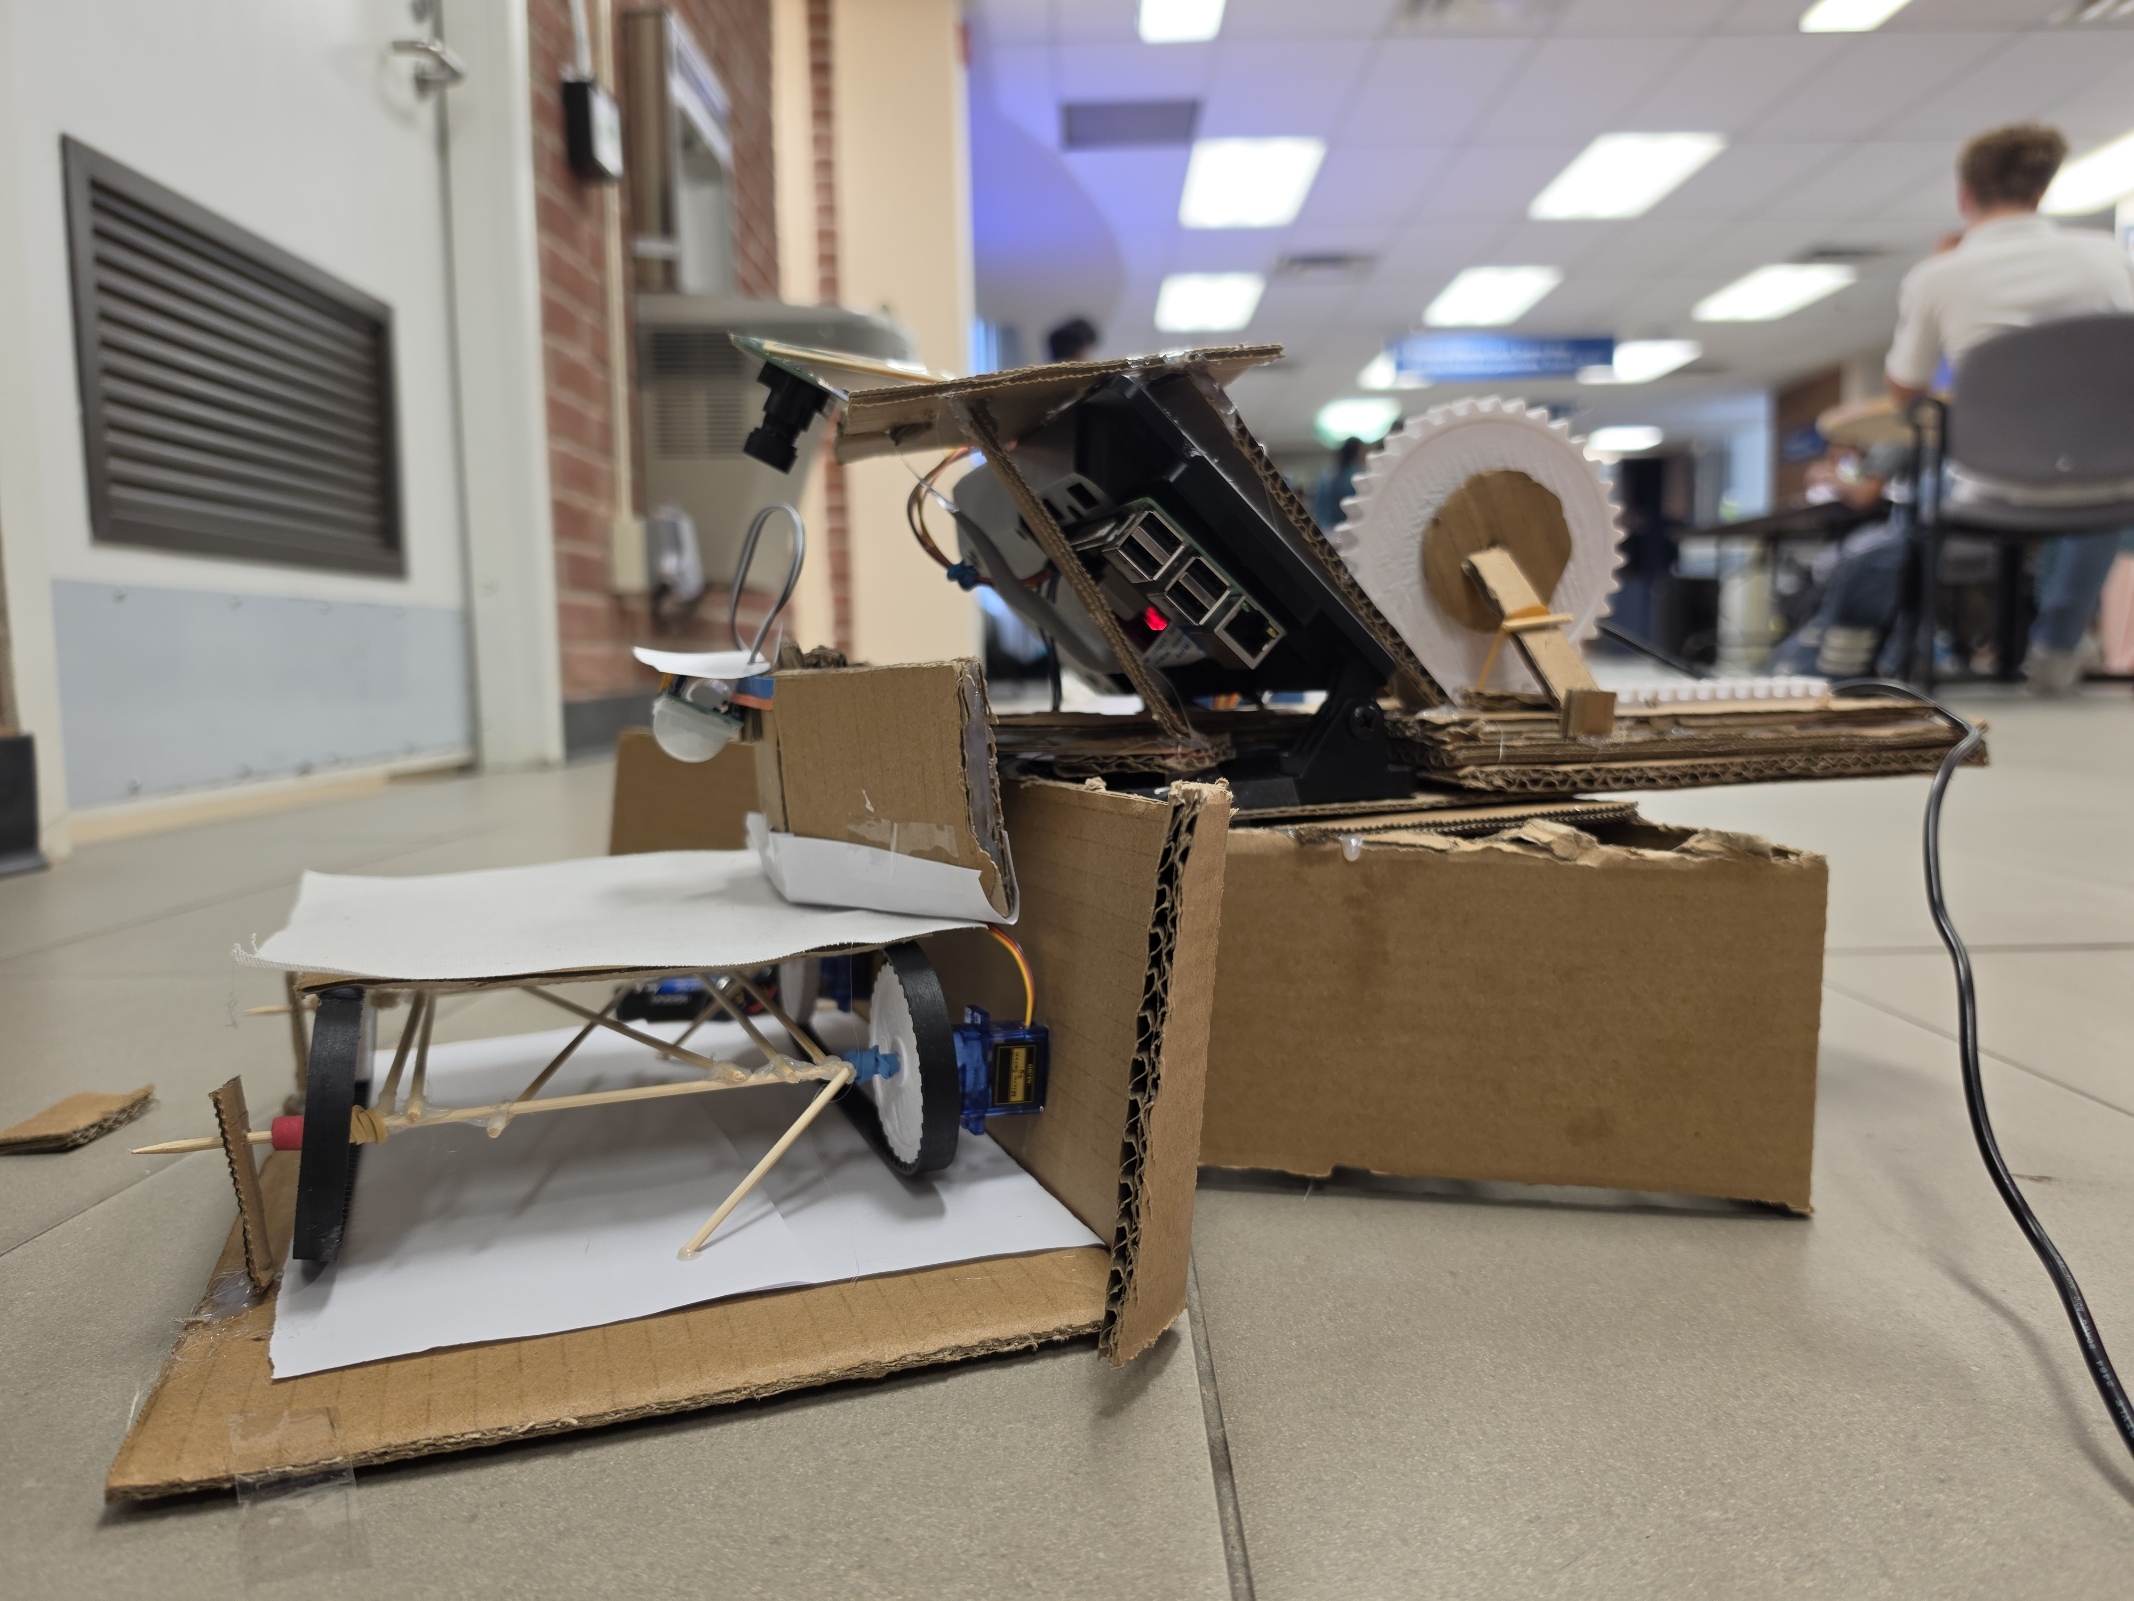
GPIO infrared sensor detects when waste is deposited Signals to InnoMaker Camera to take a 320 x 320 resolution image Image is directed to Gemini API Key where garbage is categorized into Garbage, Recycling, or Compost Gemini API returns category output back to Raspberry Pi Category output determines servo motor movement which pushes waste into designated bins Process Repeats (runs in a while loop)
How we built it
we used Raspberry Pi along with the Gemini API to categorize images the sorting process would use 180o servo motors for both the conveyor belt and the scraper overall materials: raspberry pi InnoMaker raspberry pi camera raspberry pi GPIO motion sensor AA batteries x 4 PCA9685 cardboard 3D printed materials Jumper cables Micro-Servo SG90
Challenges we ran into
installing various libraries on the raspberry pi (due to old version) finding workarounds for running scripts on the raspberry pi due to the dated version capturing images using the InnoMaker camera getting the servo motors to work on the raspberry pi (mainly a power issue) designing the build to be the least reliant on human action as possible making our design easily scalable with lower priced materials and a stable build organizing the overall build to fit all parts as neatly and compactly as possible
Accomplishments that we're proud of
It works
What we learned
Installing and connecting InnoMaker Camera (OV5647) on Raspberry Pi, controlling and collecting images with code to upload to the ai model Using Servo Motors with Raspberry Pi through PCA9685 and controlling the motors through code based on AI categorical output How to use Gemini API Keys and link to code and return outputs based on inputted prompt in the code Powering Multiple servo motors safely and efficiently through battery pack Linking Raspberry Pi and Computer through SSH Designing and connecting gears to operate a conveyer belt 3D Modelling CAD to design efficient mechanisms
What's next for Face the Waste
Make this device more accessible, portable, categories for unclassified (tech, batteries) Possibly use a pre-trained model instead of gemini api (limit because it has wifi and Gemini API limit) Possibly calibrate for different sizes of waste + placements of waste bins Sound + visual reminder / explanation for why the waste goes in its corresponding bin Creating a portable device that classifies + sorts garbage compatible on all types of garbage bins such as outdoors

Log in or sign up for Devpost to join the conversation.