
Inspiration
We were inspired by underwater robotics and wanted to create a submarine that could navigate and observe its surroundings
What it does
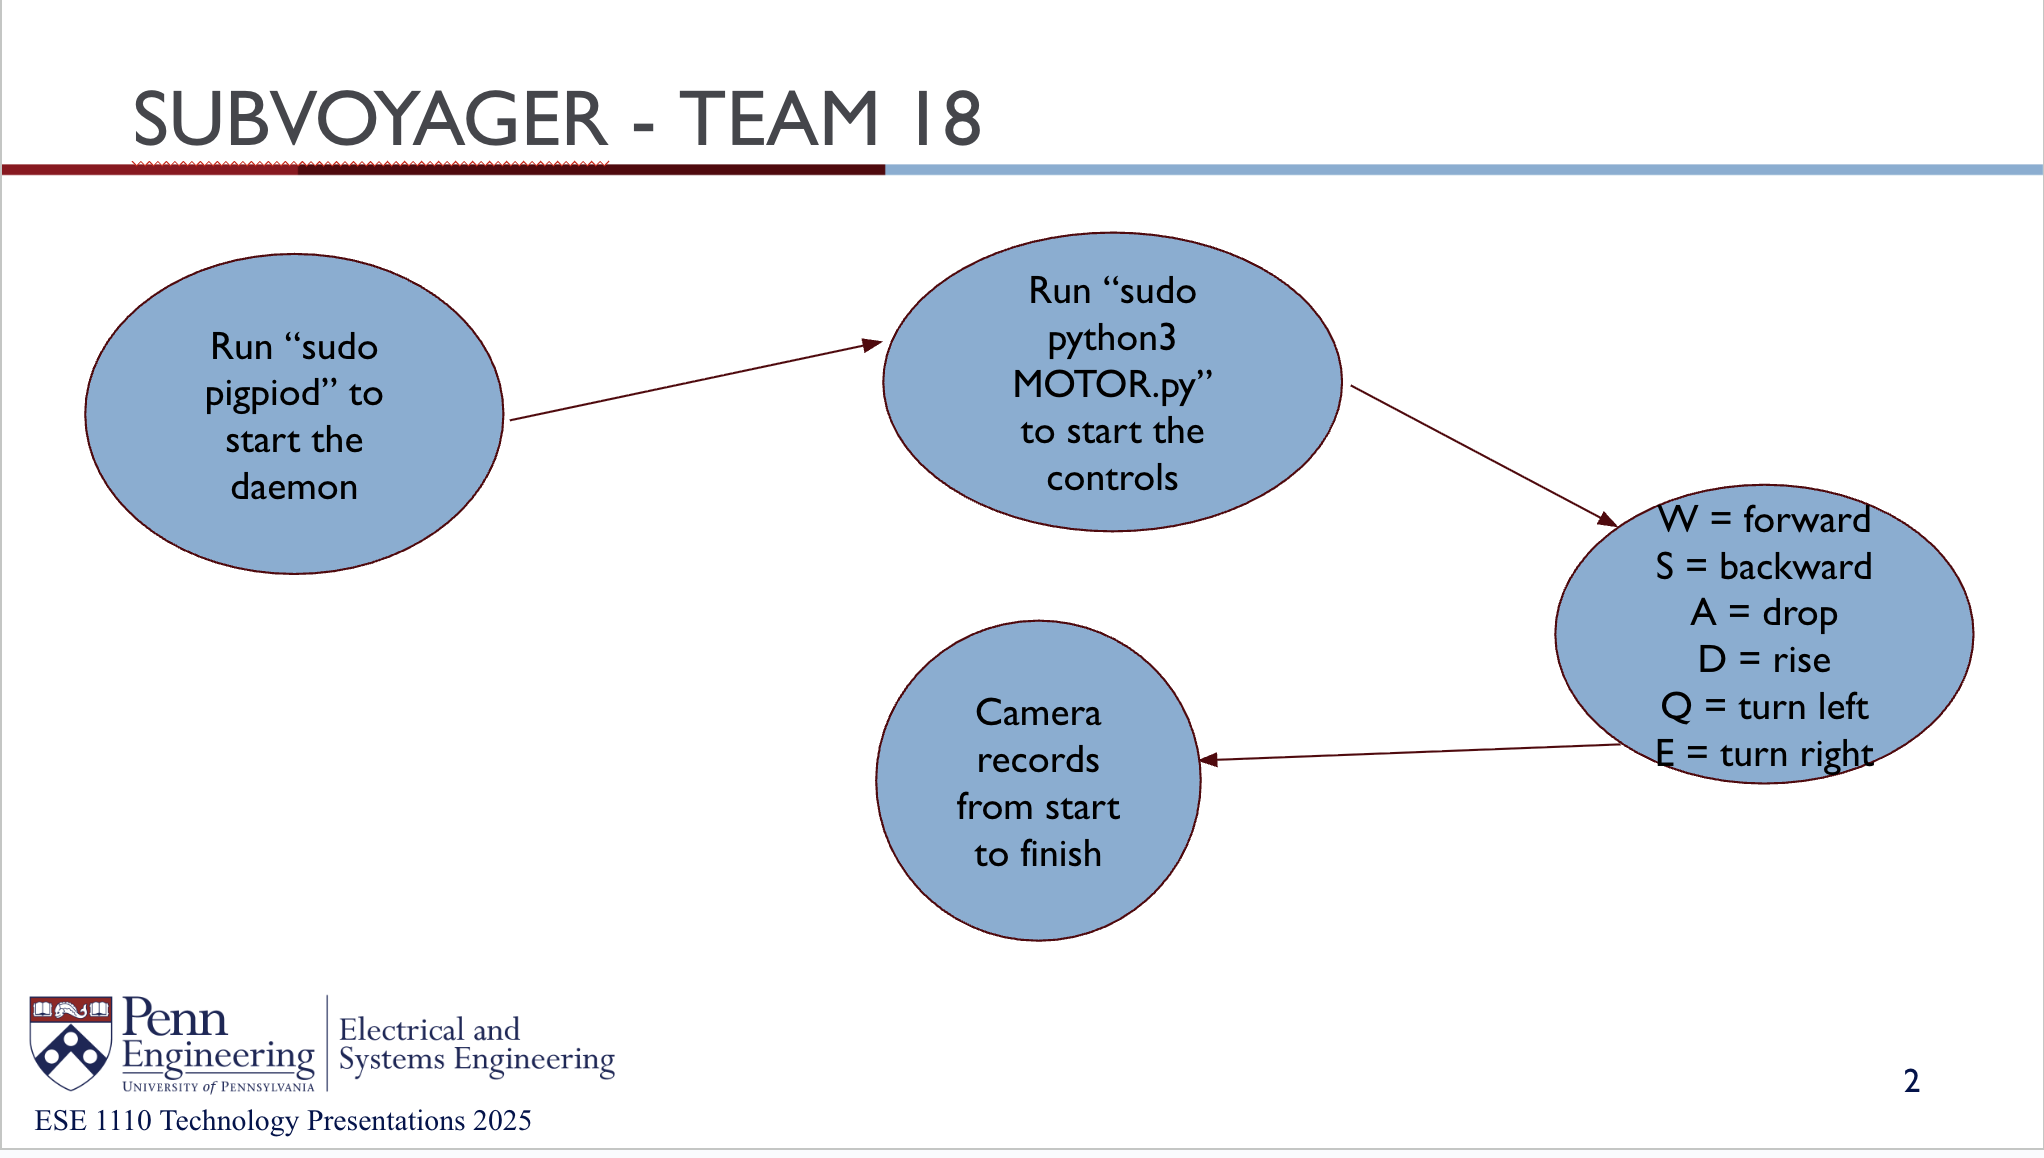
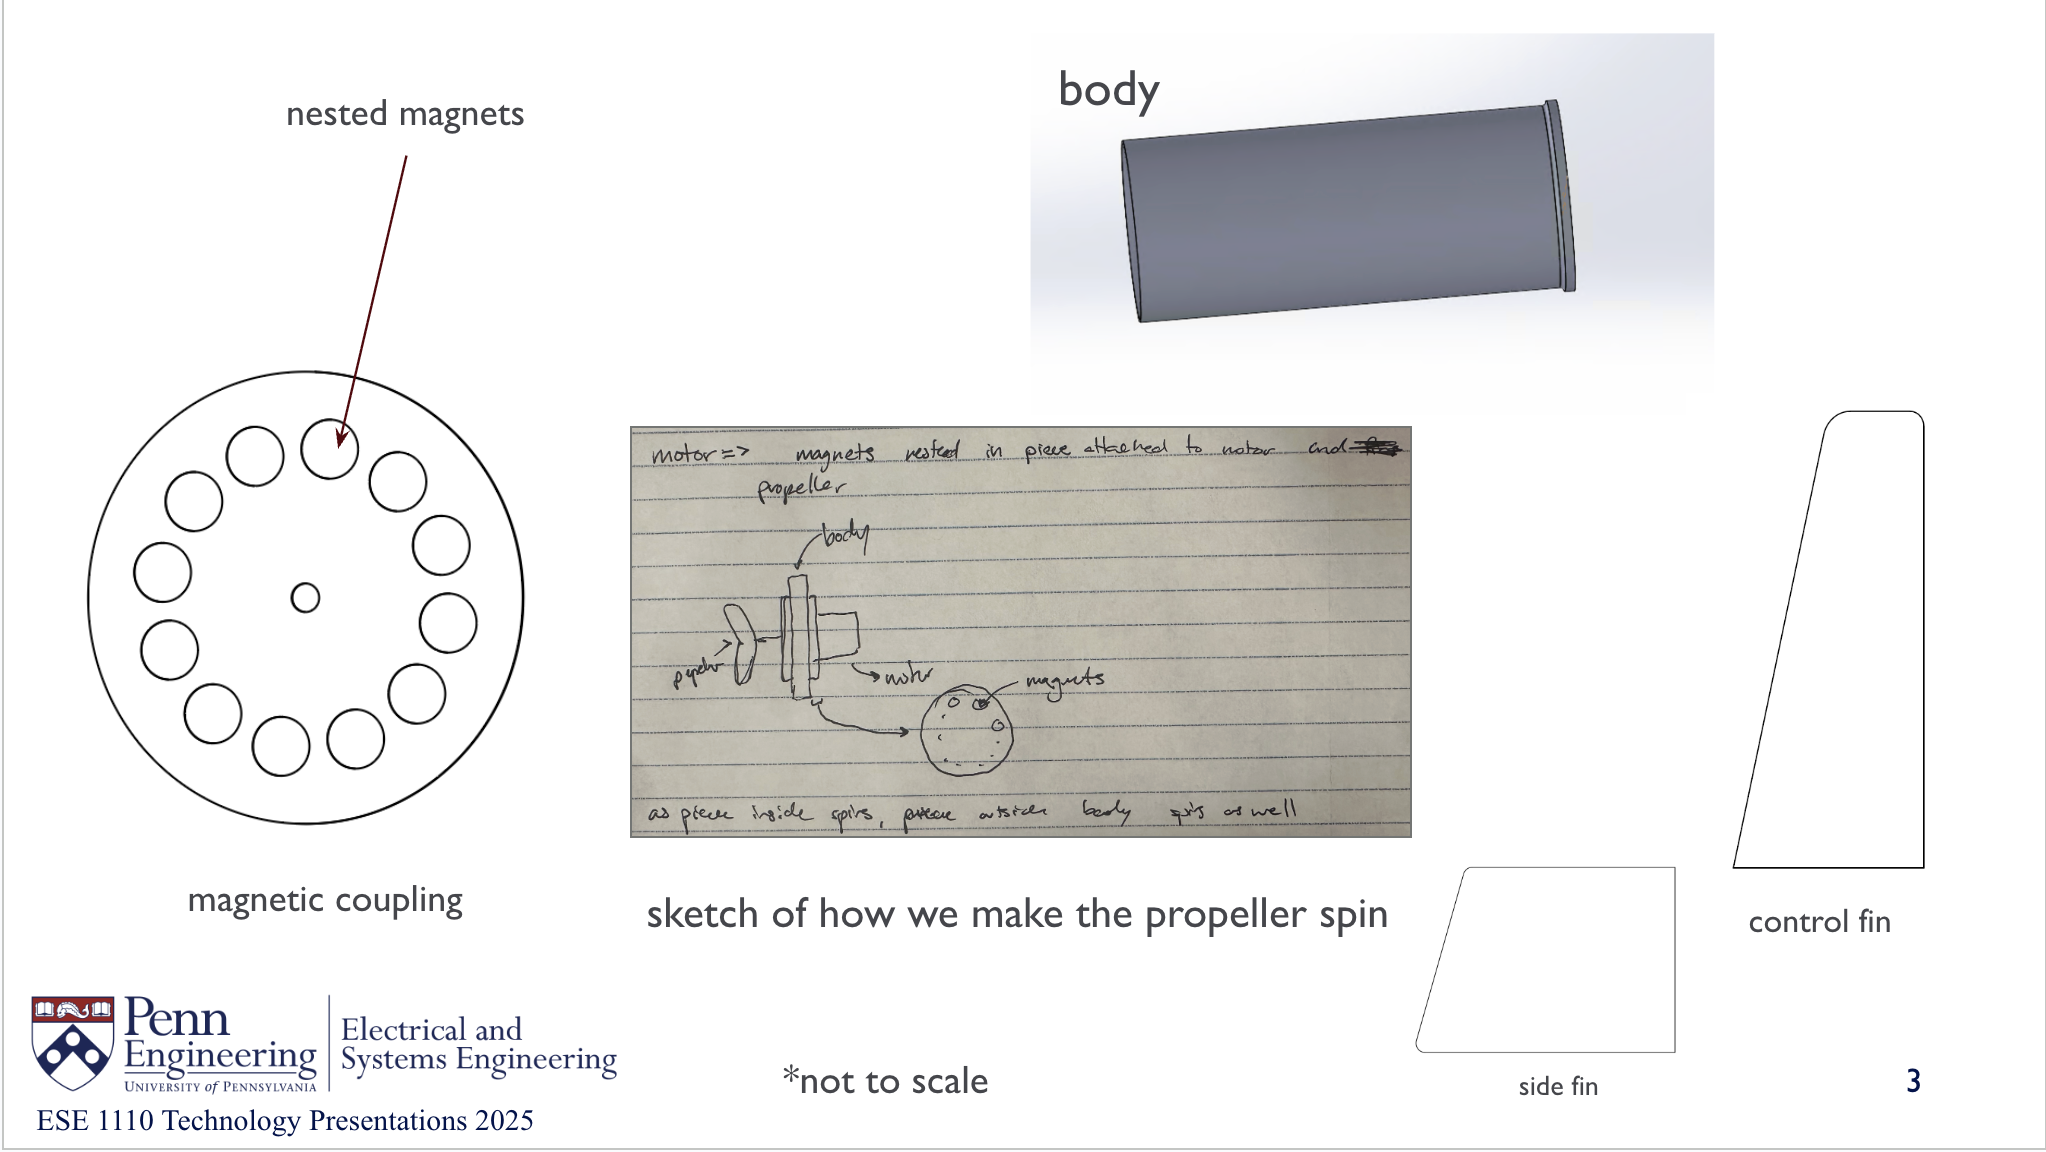
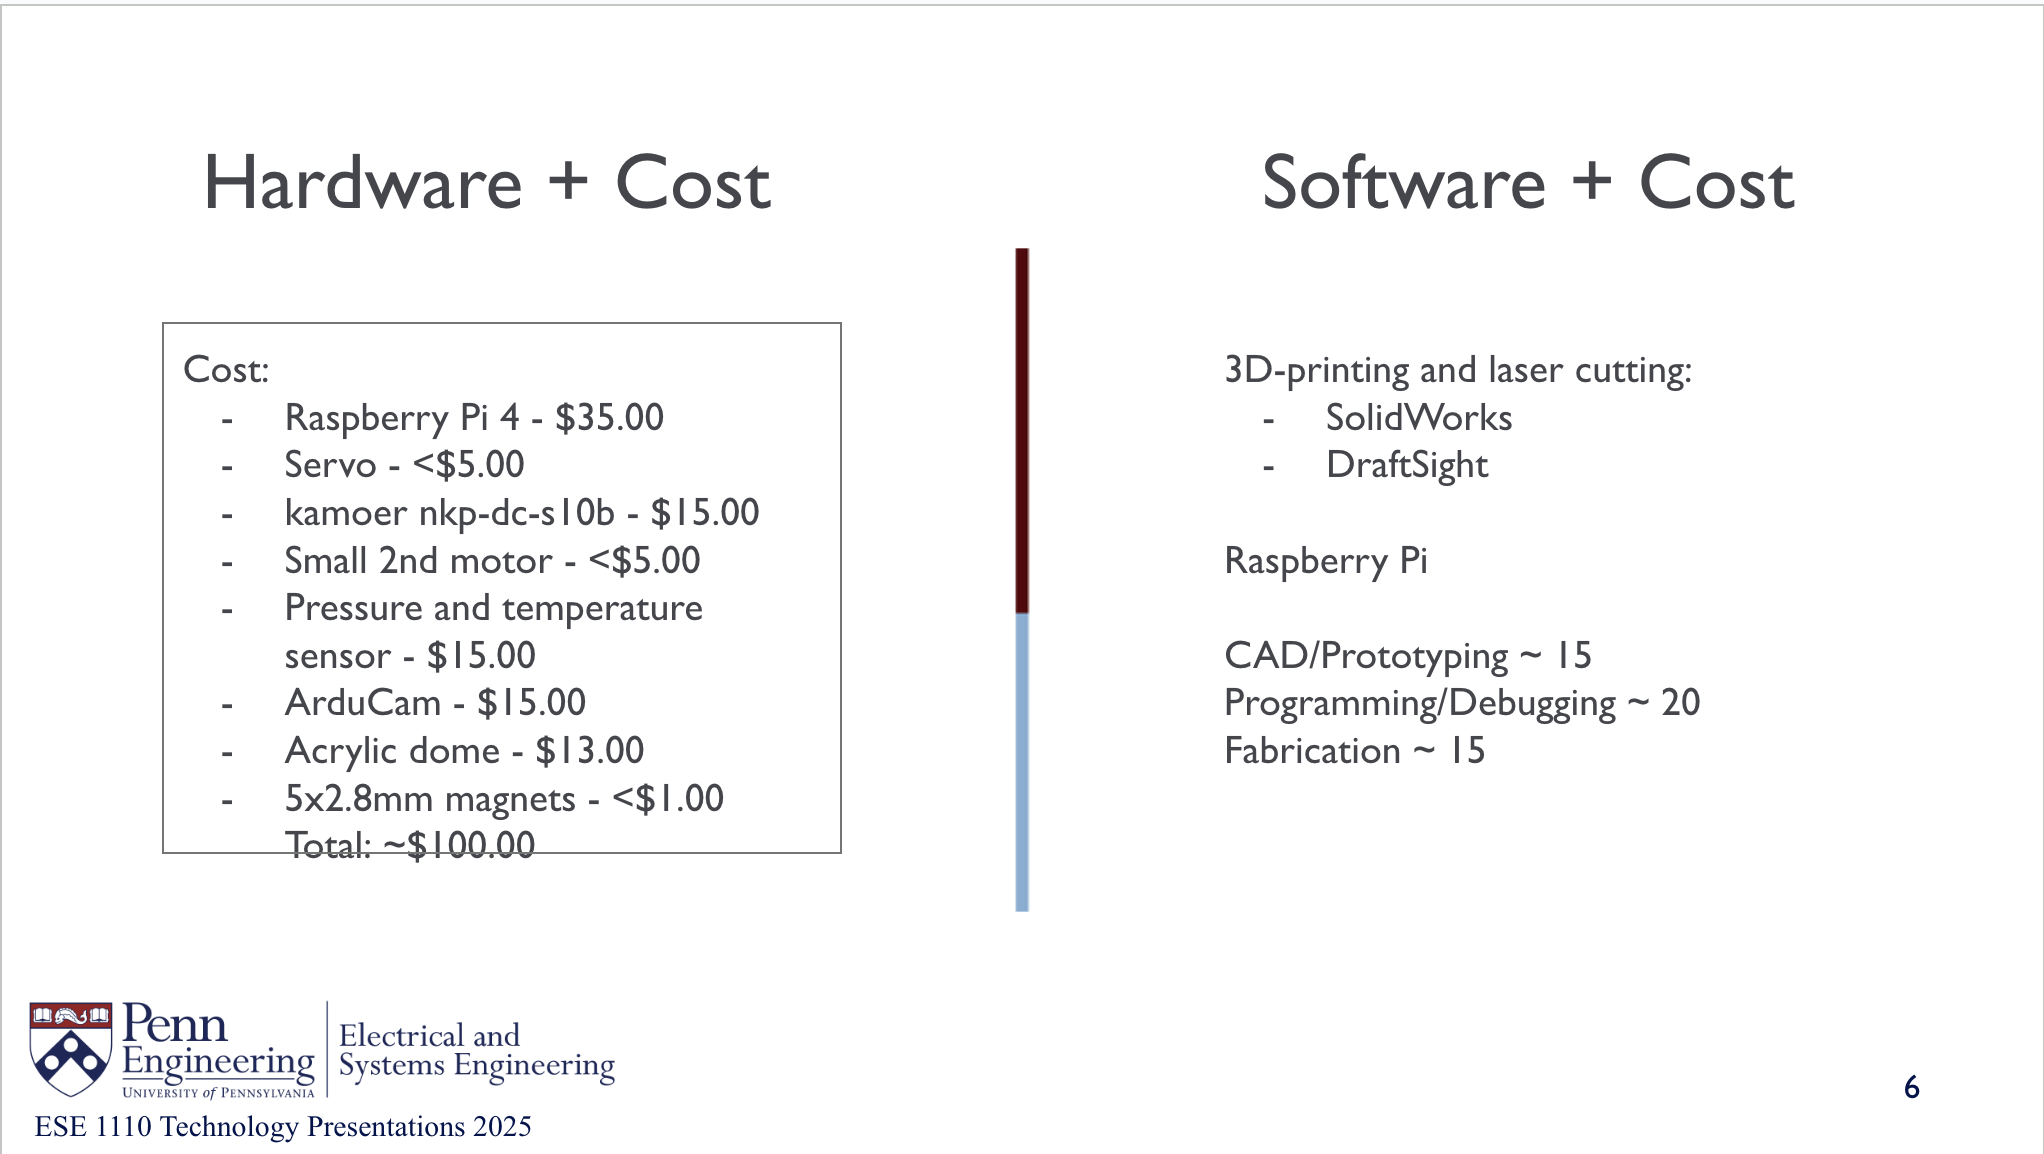
The submarine mounts a camera, propellers, and fins to allow controlled movement and visual monitoring underwater.
How we built it
We assembled the frame, installed propulsion and steering components, and integrated a camera system even though we couldn’t fully waterproof the body.
Challenges we ran into
We were unable to source the part needed to make the submarine watertight, which limited full submersion and testing.
Accomplishments that we're proud of
We successfully mounted the camera, propellers, and fins, creating a functional structure with stable control and clear imaging.
What we learned
We learned practical engineering skills, especially around mounting hardware, wiring components, and planning for waterproof design.
What's next for ESE 1110, Team 18, SubVoyager
Next, we plan to secure the missing waterproofing part, finalize sealing, and perform full underwater trials once everything is protected.

Log in or sign up for Devpost to join the conversation.