-
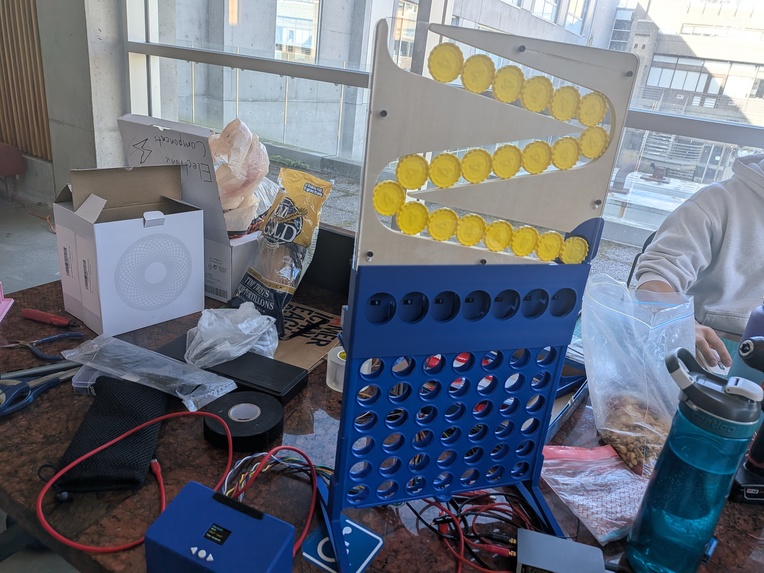
WIP pt.2
-
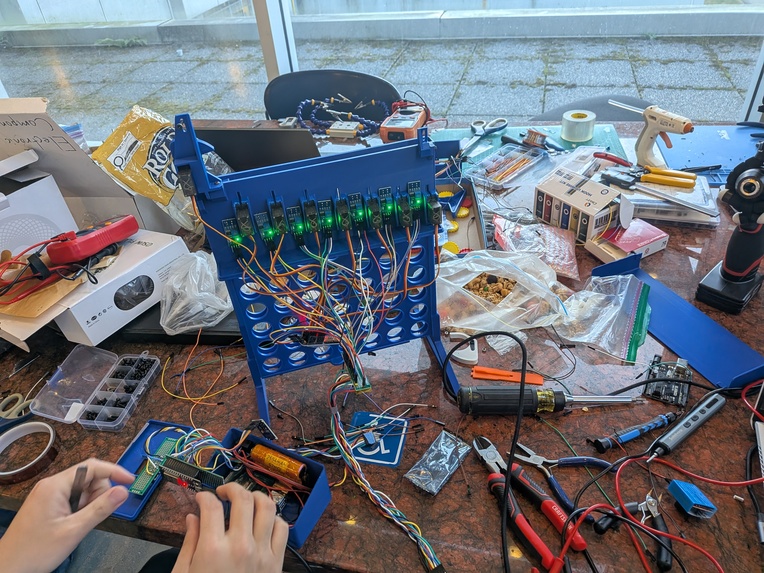
WIP pt.1
Inspiration
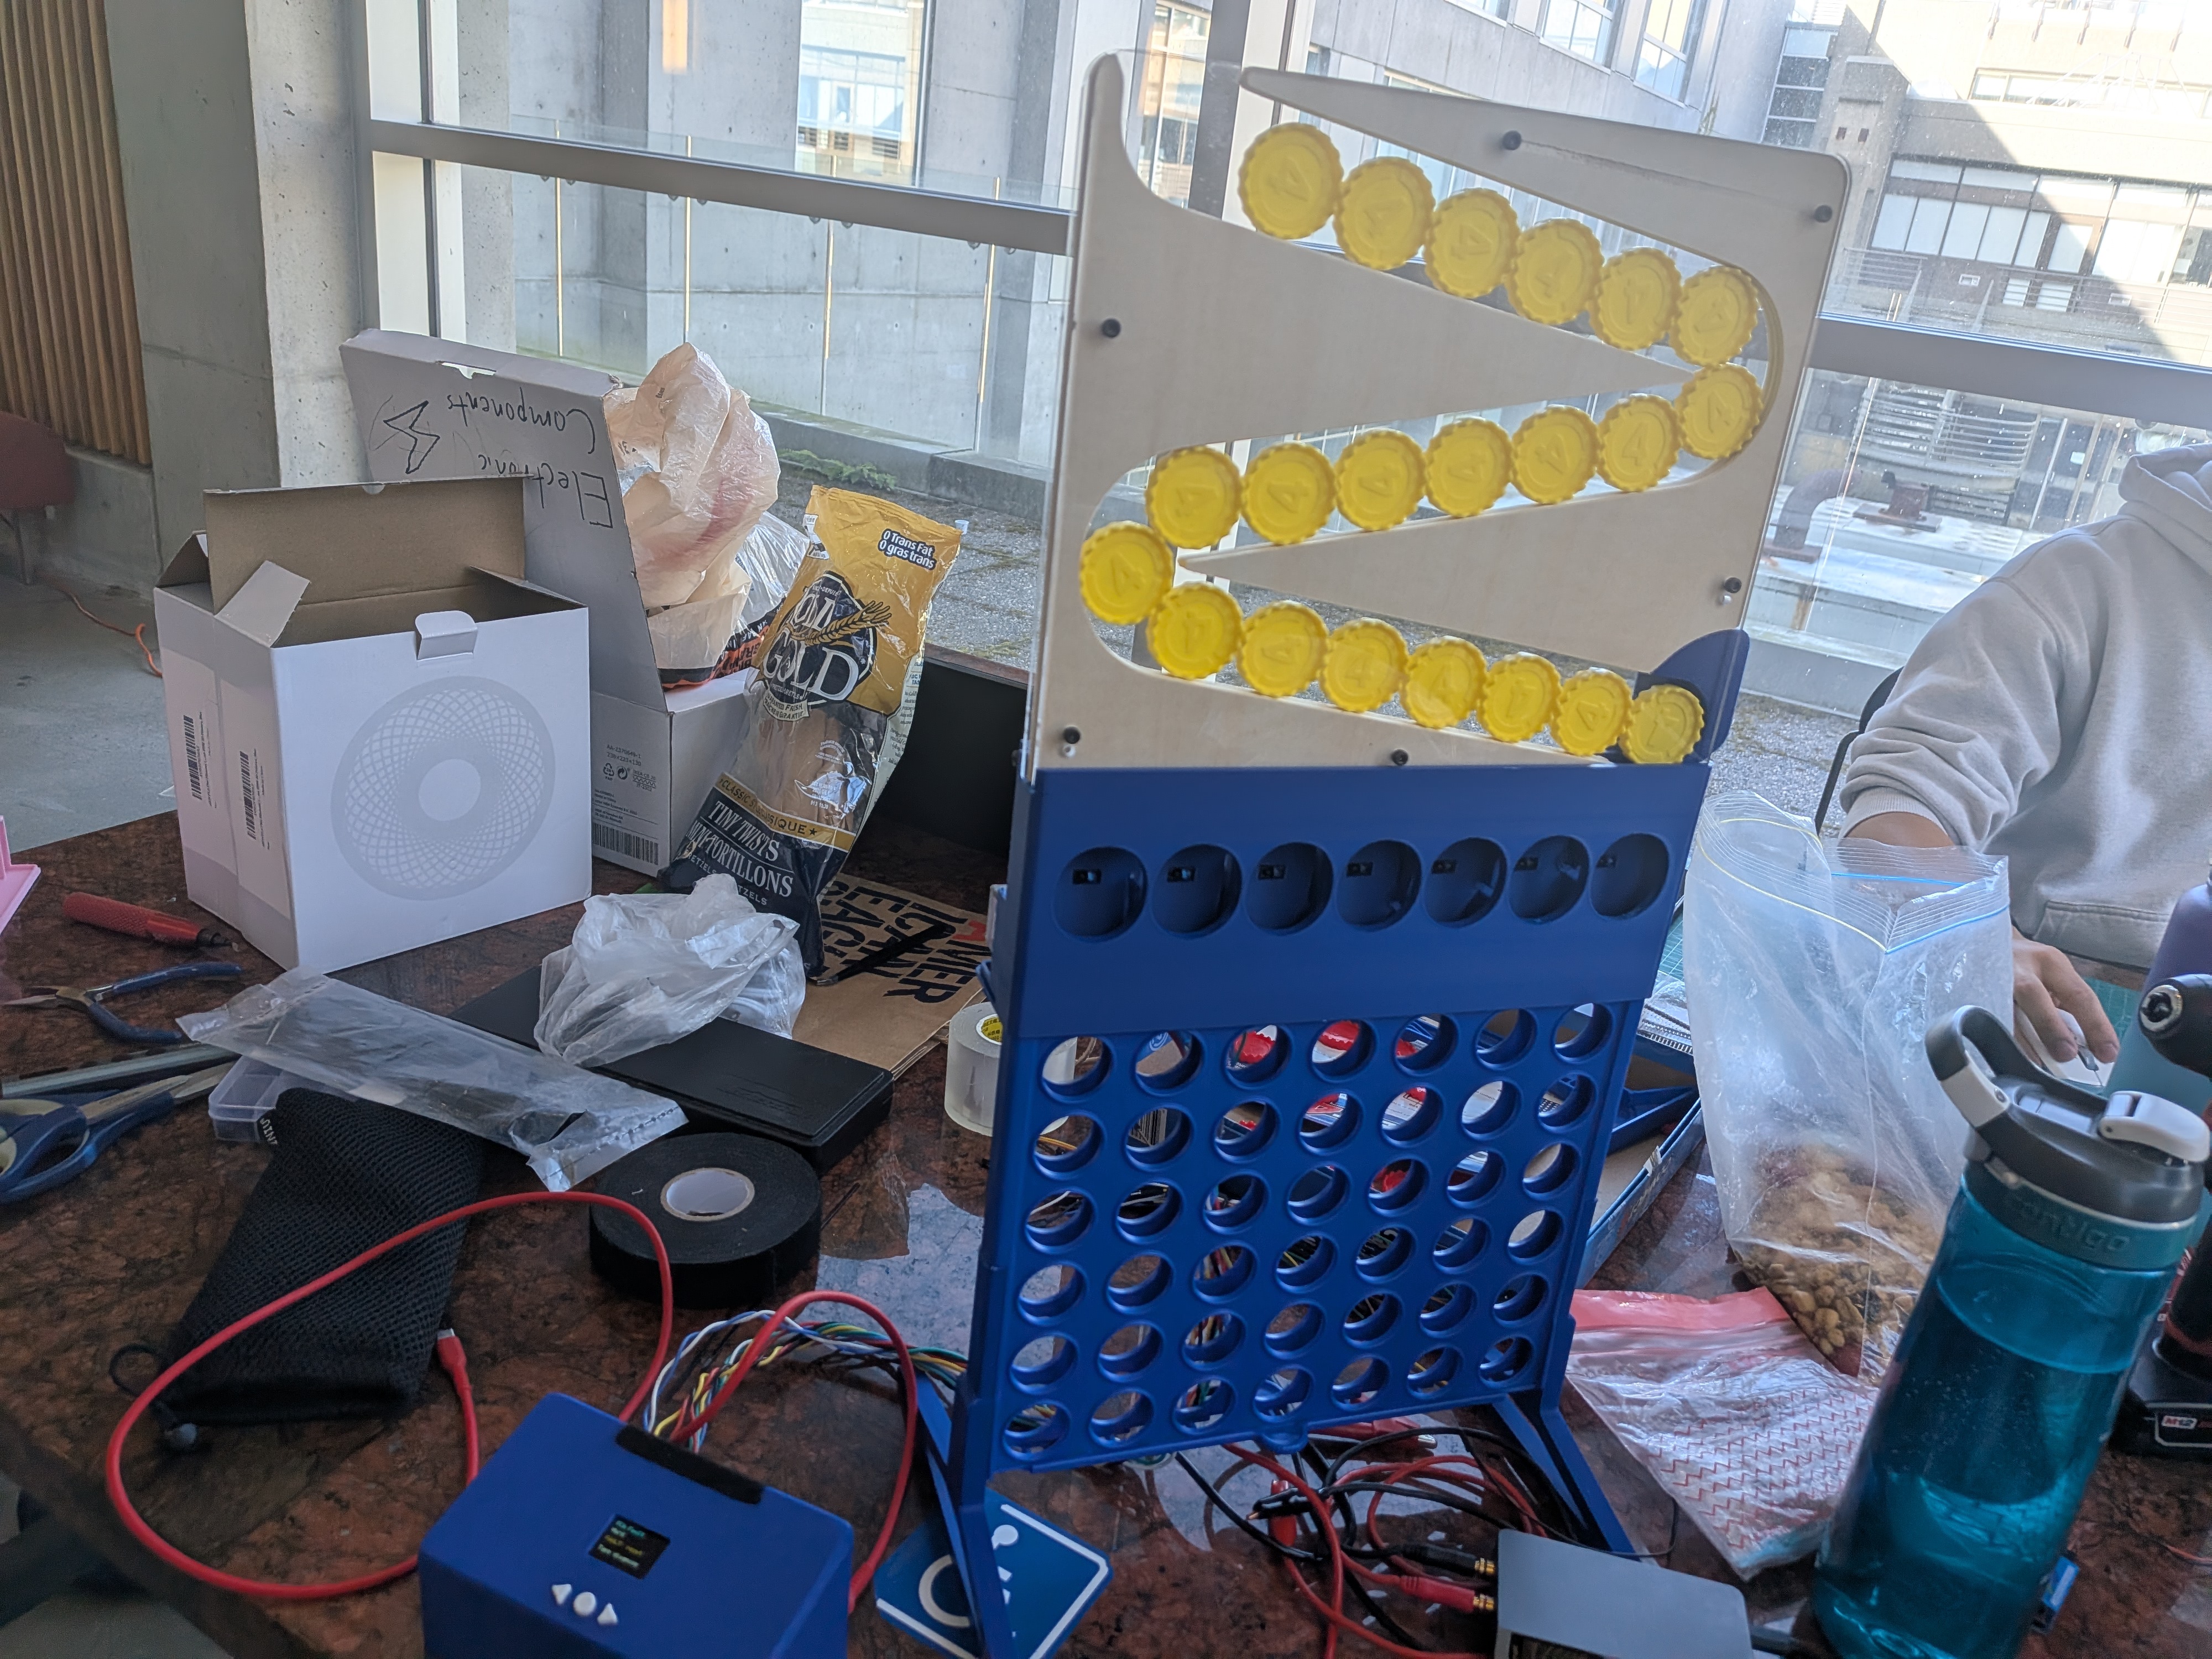
After our teammate experienced one too many losses in Connect4, we wanted to build something to level the playing field. Our answer to his problem was an unbeatable Connect4 robot that offers coaching advice at different ranges of difficulty. Watch your friend take turns against a computer algorithm, slowly falling into a position with no return.
What It Does
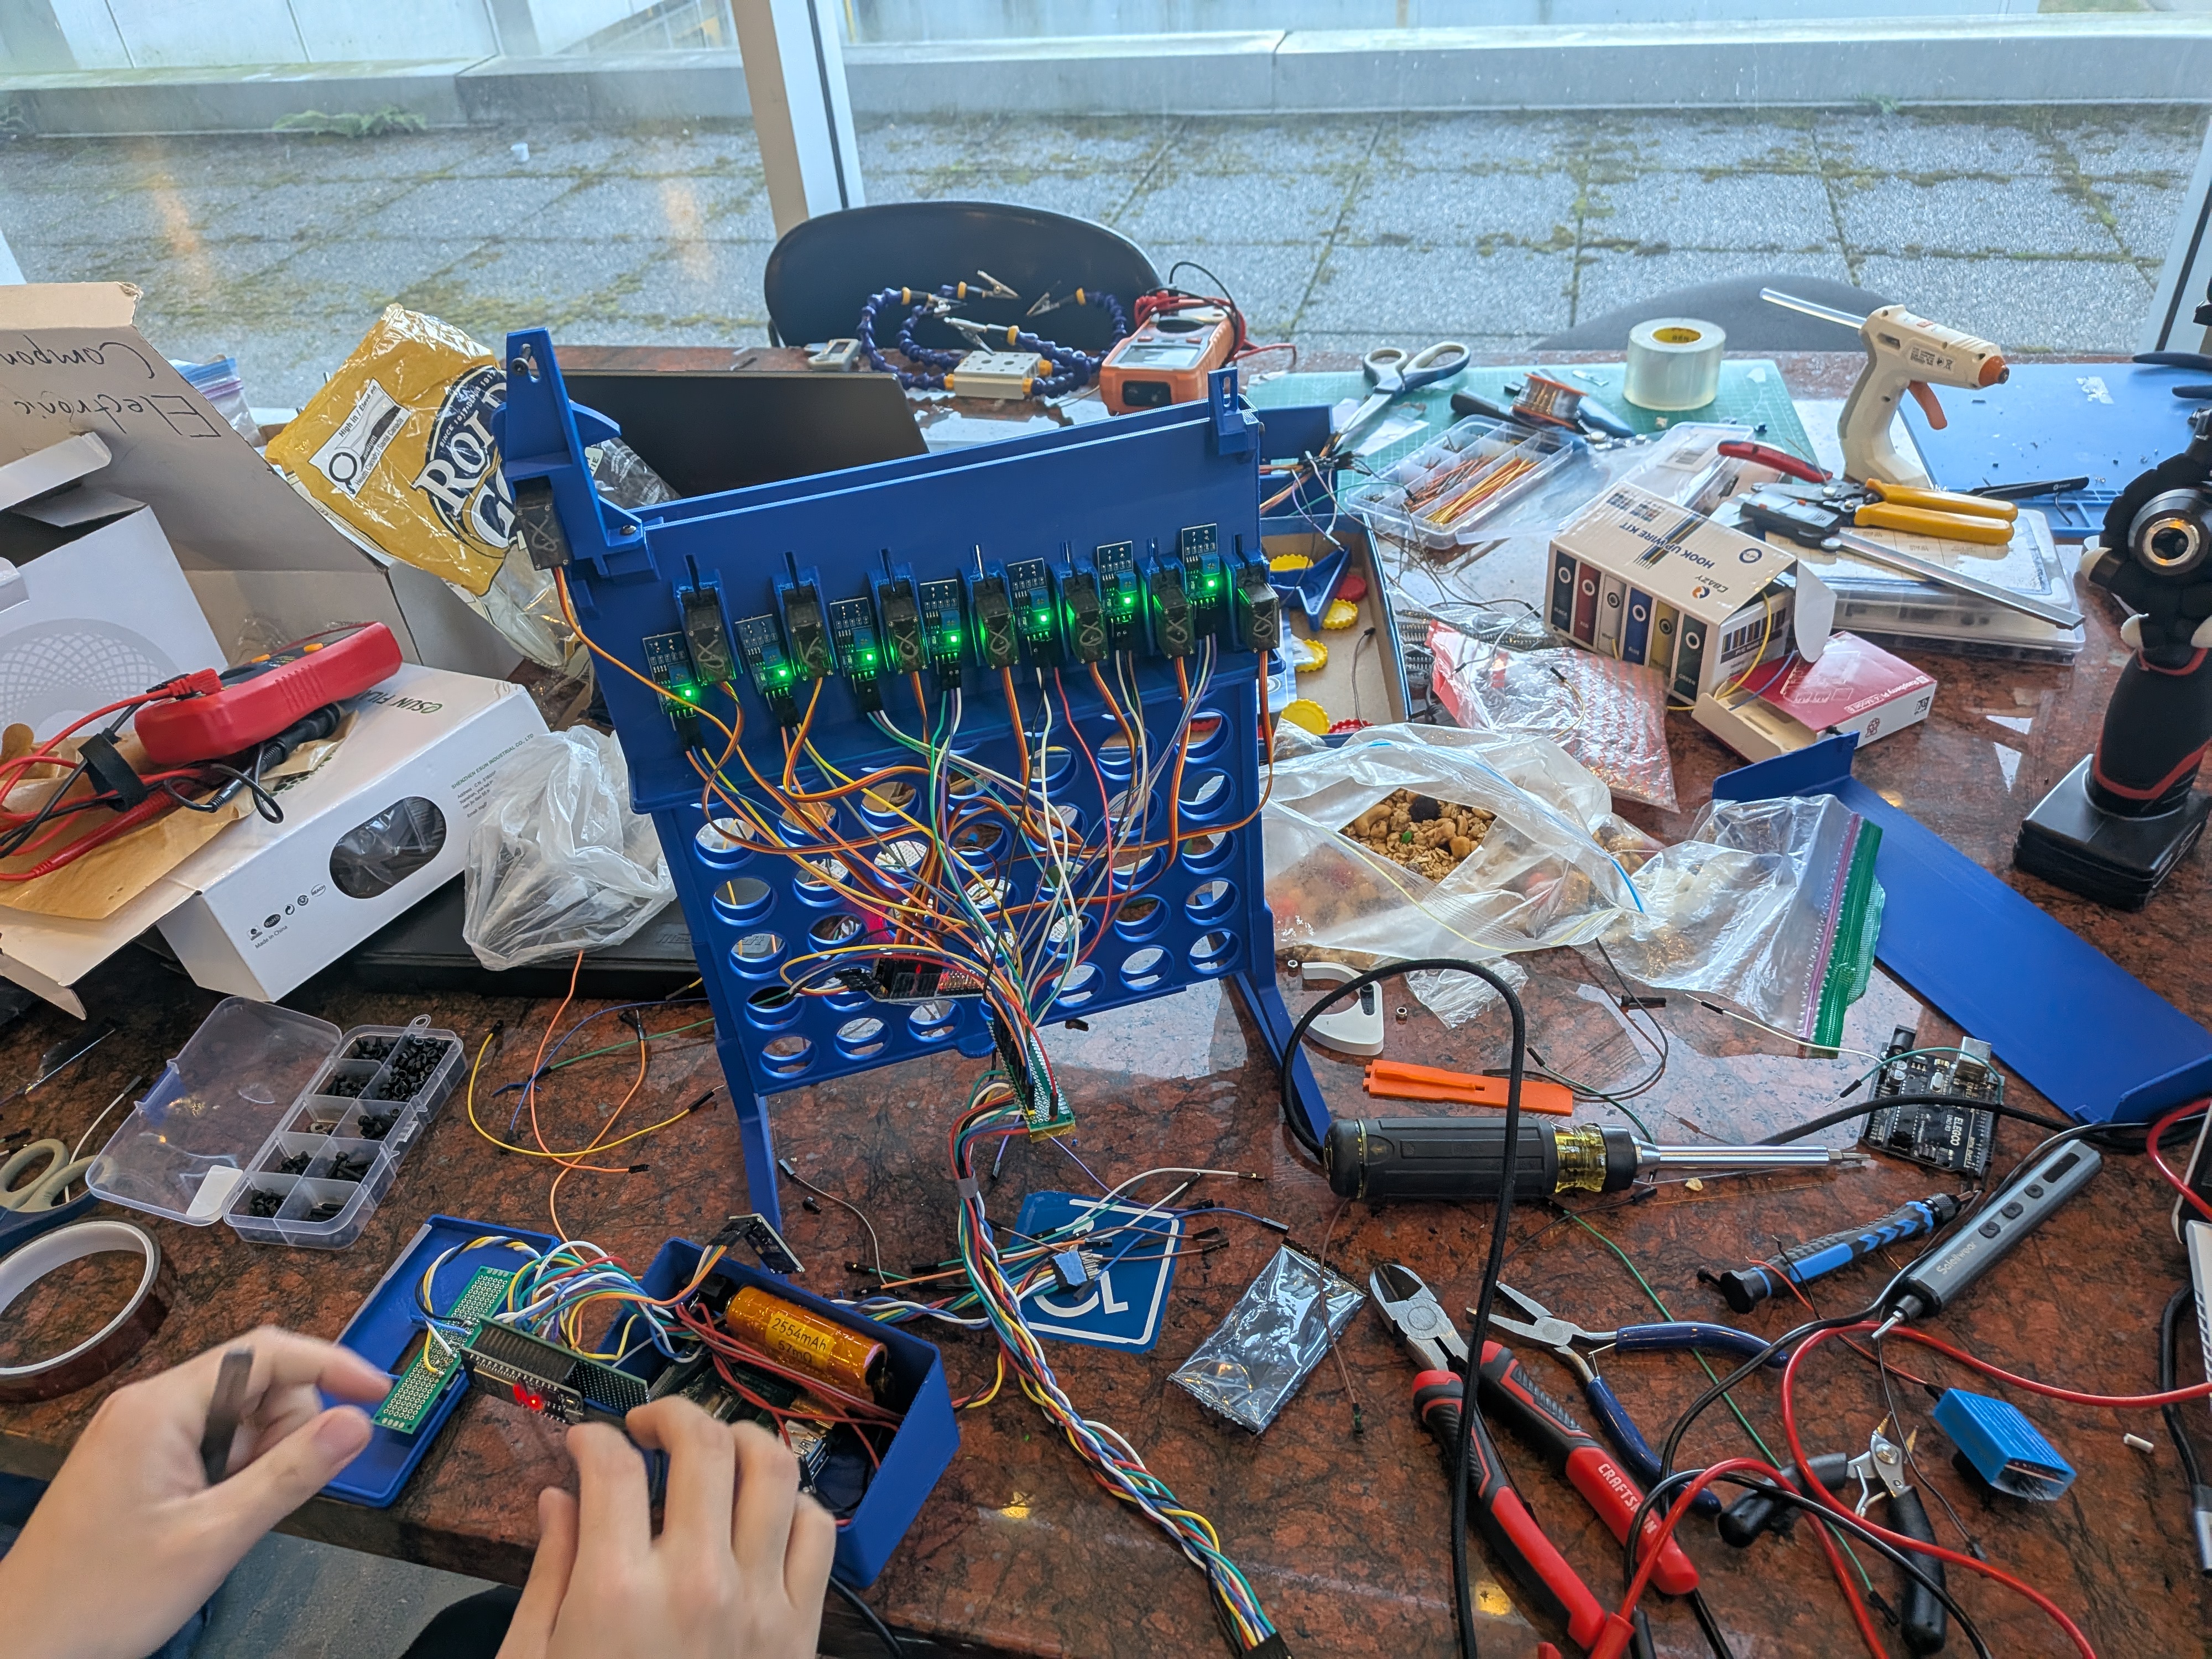
Disconnect4 tracks your moves using infrared sensors and feeds them to the open-source Minimax algorithm for game analysis. The best opposing move is then executed by turning the corresponding servo motor.
How We Built It
Our project is made from several CNC and 3D printed parts, and off-the-shelf electronics. The brains consist of an RPi4 and an ESP32 to strategize and control servo operations. A total of 8 servo motors index and direct game disks into target columns. Menu options and game modes are displayed on an RGB OLED screen.
We used the open-source Minimax algorithm with alpha-beta pruning on and ESP32 for computer moves. link
Challenges We Ran Into
The main challenge we ran into while hacking were integration issues with hardware (lots of integration issues with hardware.) Incorrect tolerancing for parts with limited time to re-manufacture was challenging as well. We also found out that the IR sensors we chose had tons of variation depending on ambient lighting which resulted in poor sensitivity and limited our packaging options.
What We Learned
We learned never to underestimate a time crunch and how much time integrating systems will take. Although we may have achieved the goal of playing against a robot, unfortunately due to time constraints some of the AI coaching features we wanted to incorporate didn't make the final cut.
What's Next for Disconnect4
After building an functional proof of concept robot, we are excited to take the hardware integration and troubleshooting skills we learned in into industry.
Built With
- c++
- cnc
- esp32
- fdm
- rpi4
- solidworks


Log in or sign up for Devpost to join the conversation.