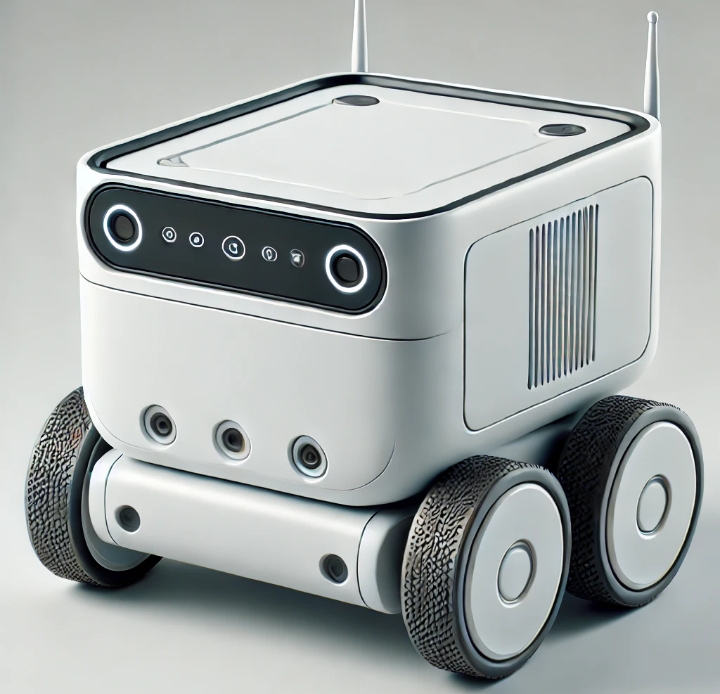
About the Project
Inspiration
The idea for the Delivery Robot was inspired by the need to assist individuals in their daily lives, particularly the elderly, differently-abled, or those with busy schedules. We envisioned a solution that could reduce physical effort and enhance convenience by automating small but repetitive tasks like delivering items within a home or workspace. The concept of combining robotics and coding to create something impactful for society motivated us to embark on this project.
What We Learned
Throughout the development process, we gained valuable knowledge in:
Hardware Integration: Understanding motor drivers, ultrasonic sensors, and microcontroller connections.
Programming Skills: Writing efficient and structured code for Arduino to handle navigation and obstacle avoidance.
Team Collaboration: Working together to solve challenges and integrate hardware and software seamlessly.
Problem-Solving: Debugging issues with motor control and sensor accuracy, which sharpened our troubleshooting skills.
How We Built It
- Planning:
We sketched a design and outlined the robot's features, such as movement, obstacle avoidance, and carrying capacity.
- Hardware Setup:
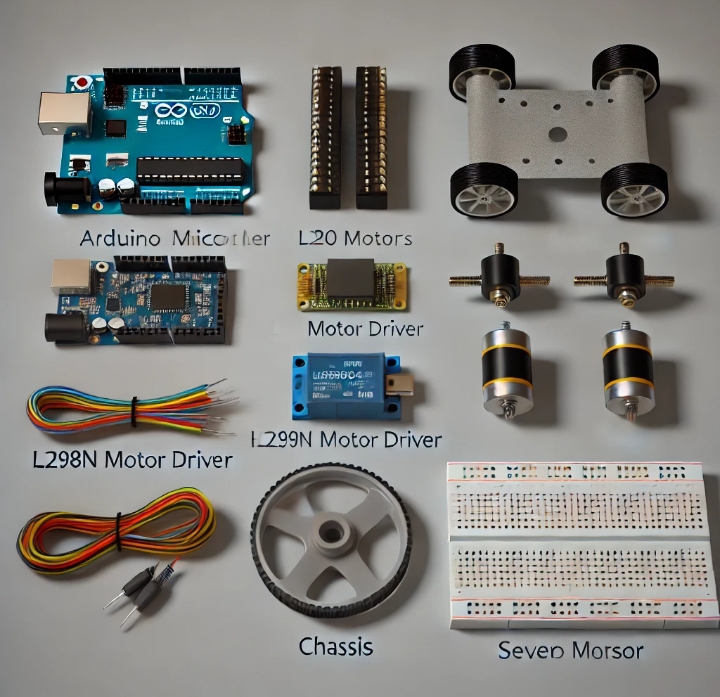
Used an Arduino Uno as the microcontroller.
Integrated DC motors and an L298N motor driver for movement.
Added an ultrasonic sensor for detecting obstacles.
Built the chassis with a stable tray for carrying items.
- Software Development:
Programmed the Arduino to control the motors and process input from the ultrasonic sensor.
Implemented logic for obstacle avoidance and route navigation.
- Testing and Iteration:
Conducted multiple tests to fine-tune motor speed and sensor sensitivity.
Made adjustments to ensure stability and smooth operation on various surfaces.
Challenges Faced....
Obstacle Detection: Initially, the ultrasonic sensor gave inconsistent readings due to interference, so we adjusted its positioning and fine-tuned the code.
Power Management: Ensuring the motors had sufficient power without draining the battery too quickly was a balancing act.
Navigation Precision: The robot occasionally veered off course, so we calibrated the motor speeds and tested in different environments.
Hardware Failures: Loose connections caused intermittent issues, requiring us to reinforce soldering and connections.
Conclusion
Building the Delivery Robot was a rewarding experience that combined creativity, coding, and problem-solving. It not only enhanced our technical skills but also showed us the potential of robotics to positively impact people's lives. We hope to further improve this project by adding features like voice commands, app control, and IoT integration.

Log in or sign up for Devpost to join the conversation.