-
-
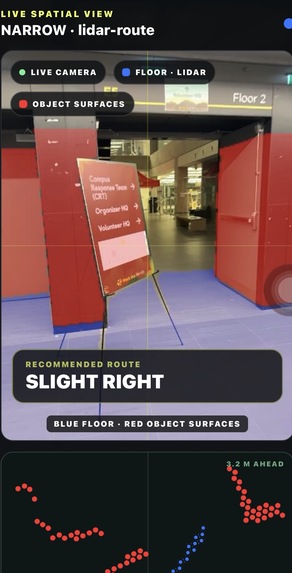
Multi Object Segmentation
-
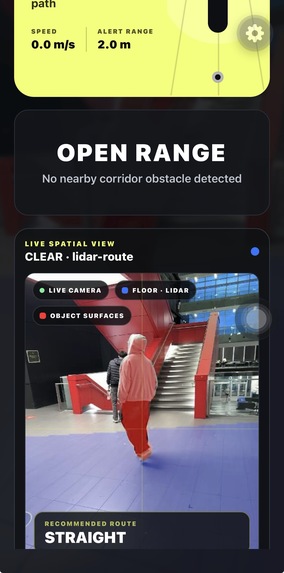
Moving Objects Detection
-
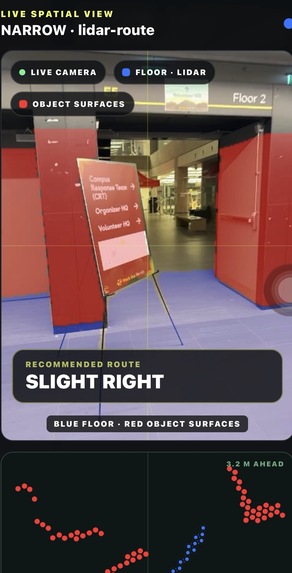
Auomated Guidance
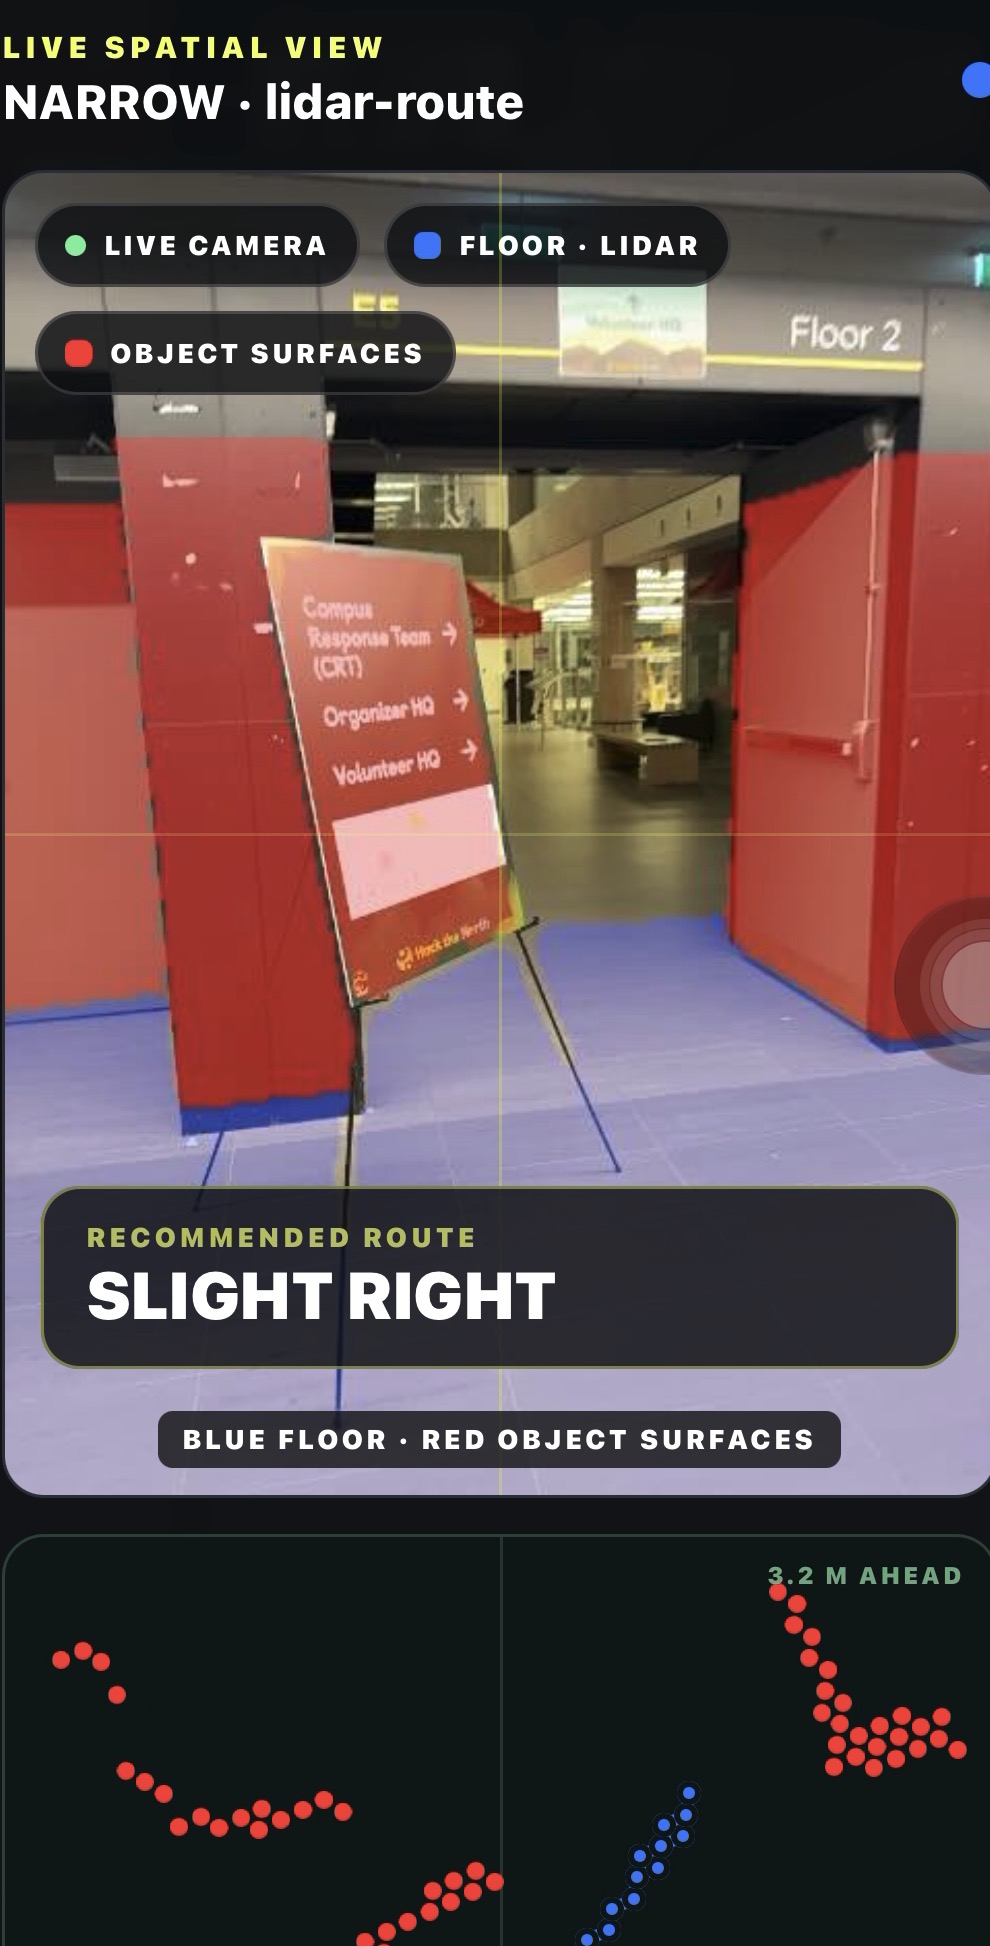
## Why we built it
At Hack Canada, we saw how many opportunities can exist in one room. There were sponsor booths, mentors, workshops, and people
Now imagine trying to navigate that same space without being able to see.
A crowded room full of tables, people, cables, and unexpected obstacles can quickly become difficult or unsafe to move through. In Canada, 7.4% of people aged 15 and older, almost 2.2 million people, live with a seeing disability.
This project also became personal for our team. One of our teammates has a grandmother who experiences the challenges that come with reduced vision. Something as simple as walking through an unfamiliar space can create uncertainty and make independence much harder.
That is where NoBumpsIntended started.
## What NoBumpsIntended does
NoBumpsIntended is a virtual walkin stick sytem that provides an extra layer of awareness for blind and low-vision users.
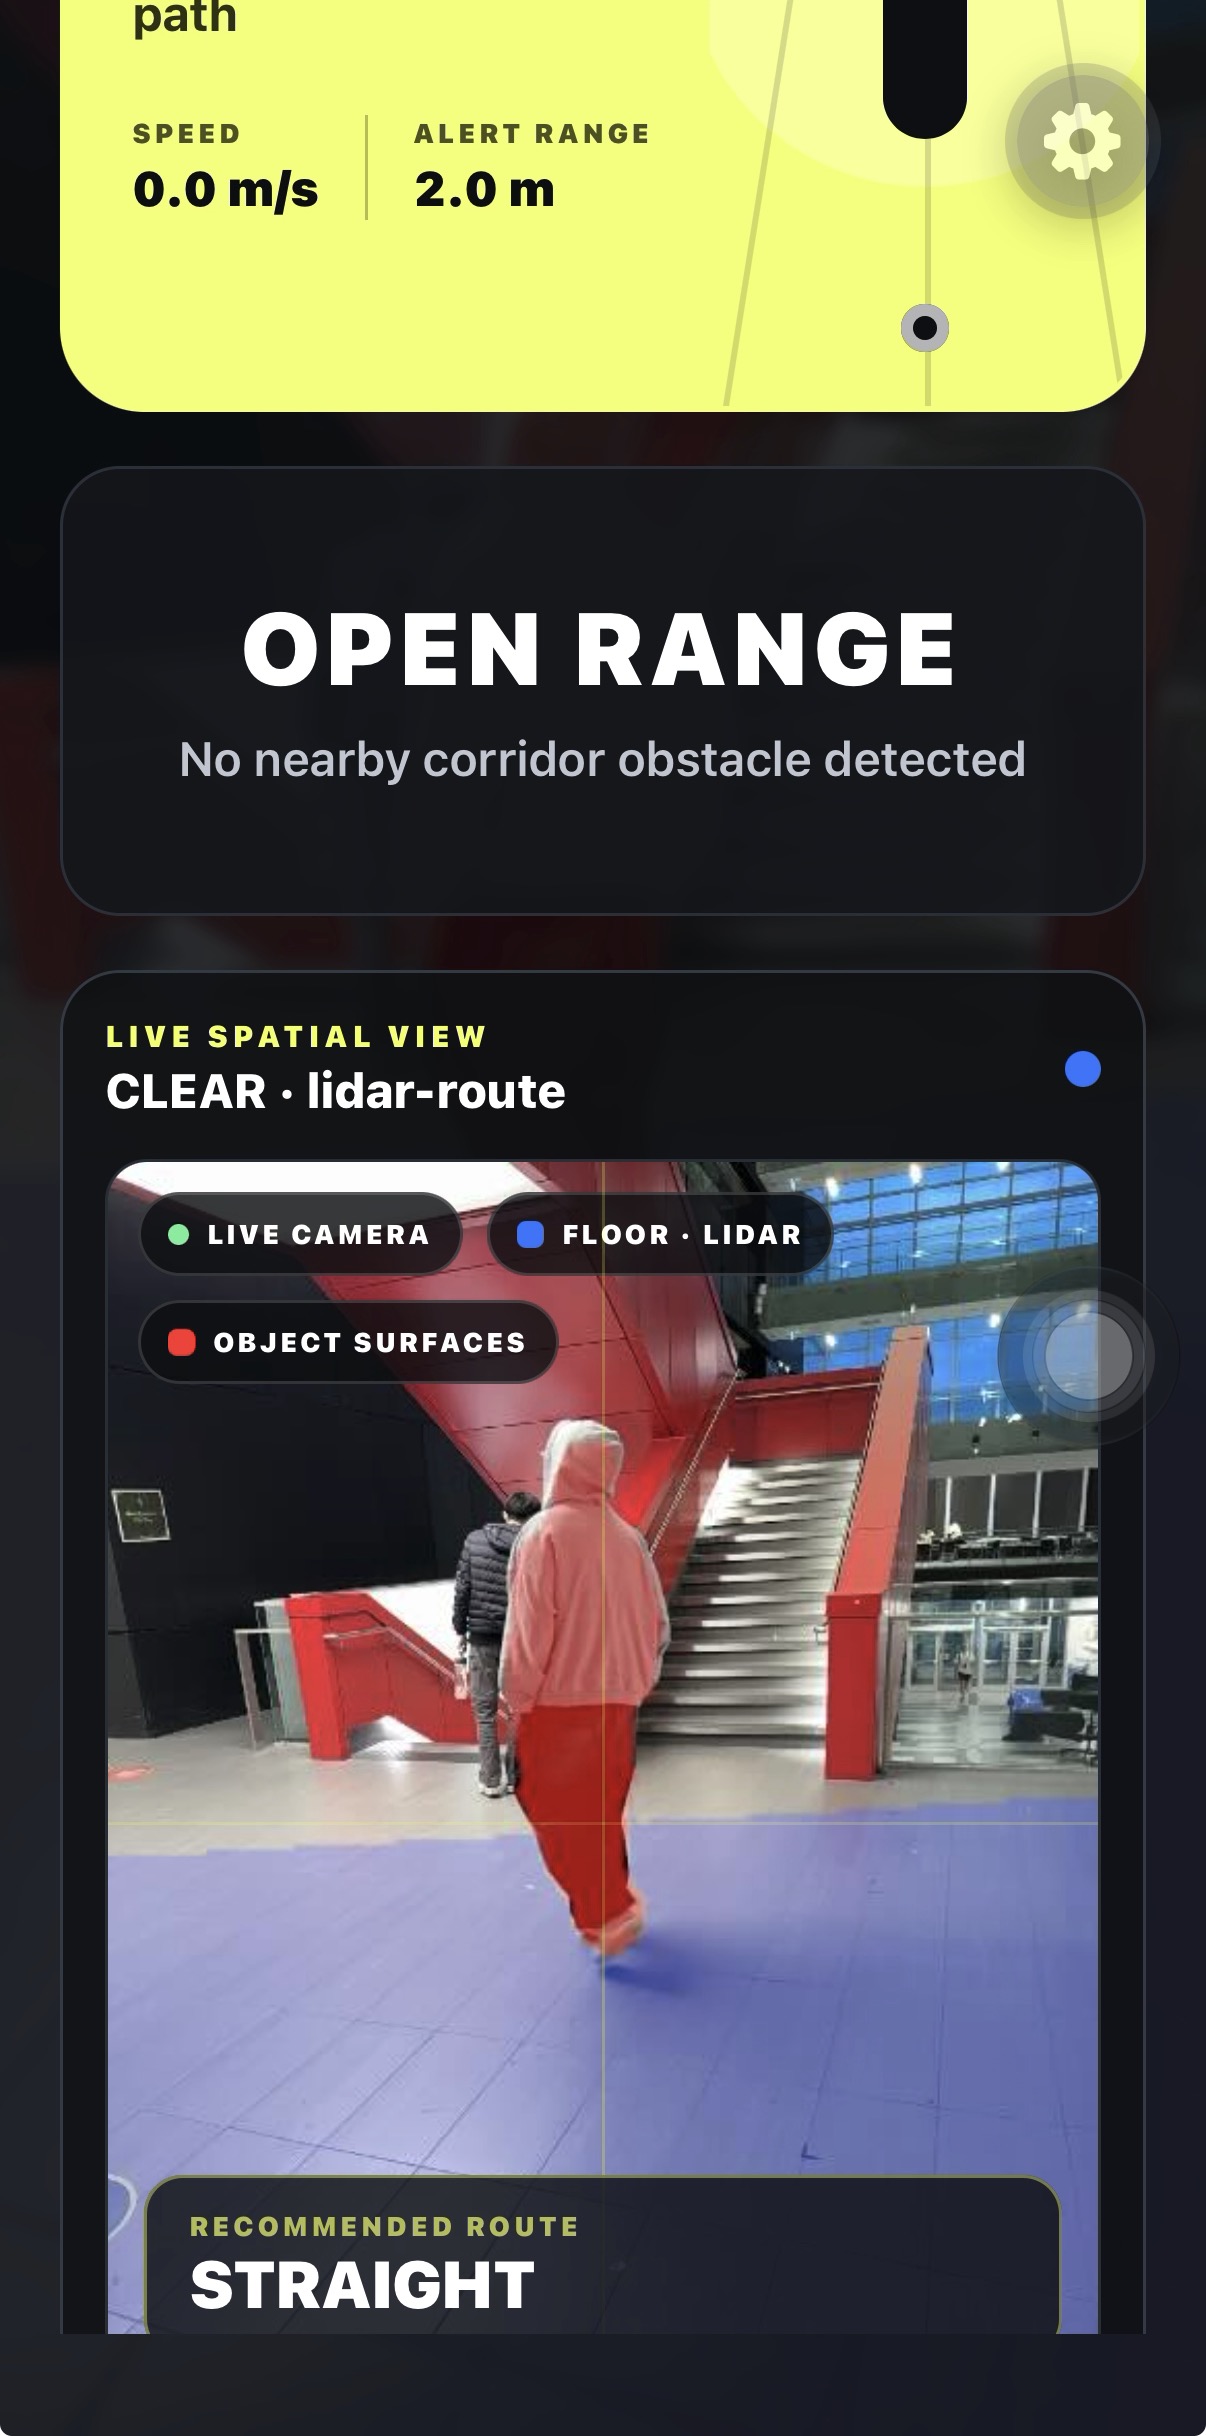
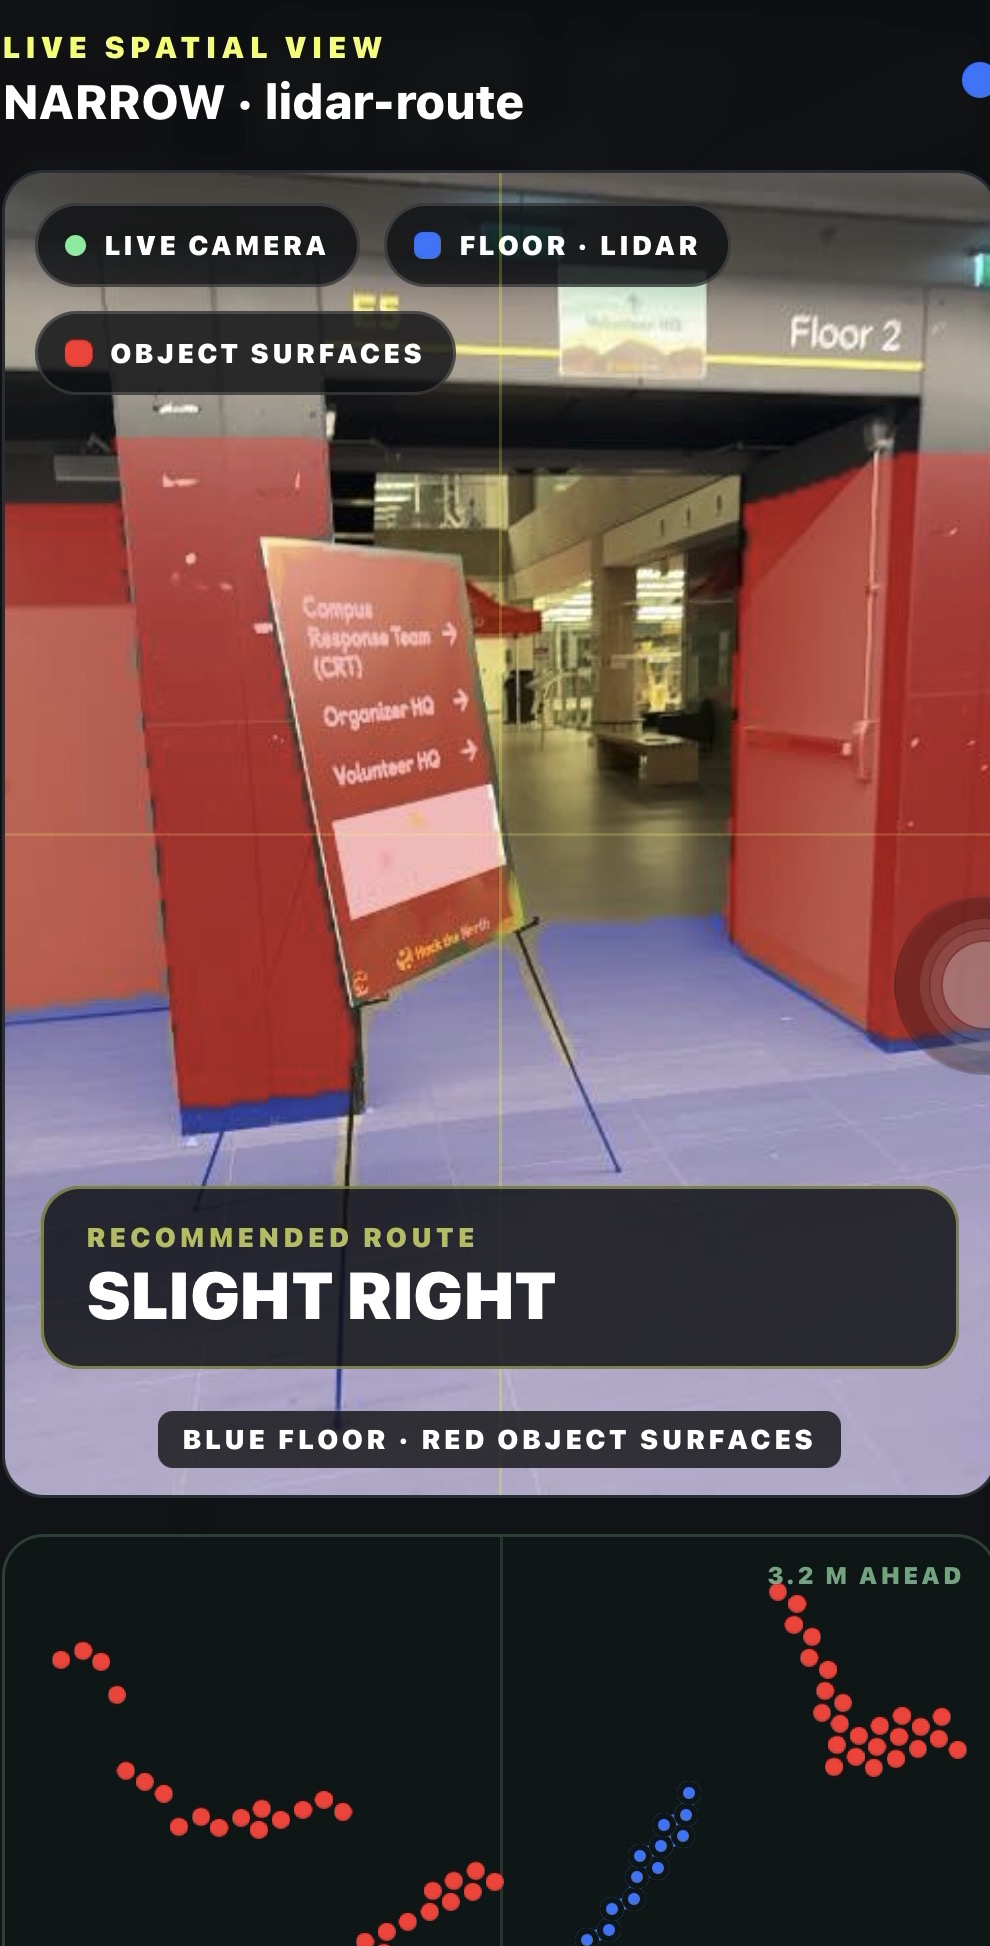
The app uses the LiDAR sensor on supported iPhones and iPads (Strapped to head or chest) to scan the space ahead. It identifies obstacles, detects open pathways, and provides guidance through audio, visuals, and haptic feedback.
Our lightweight local segmentation model helps distinguish walkable space from obstacles. We trained the H100 GPU on BaseTen infrastructure, then optimized it to run directly on the device. This allows the system t respond quickly without sending the entire camera feed to the cloud.
The system divides the user’s path into left, center, and right sections. If an obstacle appears directly ahead, NoBumpsIntended can give warnings such as “caution,” “near,” or “stop.” If there is more open space to one side, it can provide natural-language guidance such as “slight left” or “right.”
Users can also ask questions like, “What is around me?” The natural-language companion responds with a short, understandable description while the local LiDAR safety system continues running in the background.
## How we built it
We built the mobile app using Expo, React Native, and TypeScript. We created a custom Swift Expo module to connect the app to Apple’s ARKit and LiDAR systems as well as live real-time models from Gemini & OpenAI
The core safety loop runs locally on the device, so basic obstacle detection does not depend on an internet connection. We added a local route planner, haptic alerts, speech feedback, ground-hazard warnings, natural-language guidance, and accessibility-friendly controls.
## Challenges and what we learned
One of our biggest challenges was making the system useful without pretending it was perfect. Sensors can be noisy, objects can be hidden, and not every hazard can be detected reliably.
Because of that, NoBumpsIntended is designed to be conservative. It is meant to work alongside a walking stick, guide dog, or mobility training, not replace them. A walking stick provides physical feedback at ground level, while PathFinder provides additional awareness farther ahead.
We learned that accessibility cannot be treated as a feature added at the end. It has to influence the design, interaction, and safety decisions from the beginning.
## What’s next
Our next steps are testing with blind and low-vision users, improving detection and making the natural-language guidance even more useful in real environments.
Our goal is simple: make any space especially one like HackTheNorth more accessible, so nobody misses an opportunity because they cannot safely navigate the room.
Built With
- a*-pathfinding
- accessibility
- arkit
- assistive-technology
- computer-vision
- core-ml
- elevenlabs
- expo.io
- gemini
- haptics
- ios
- lidar
- natural-language-processing
- node.js
- on-device-ai
- react-native
- segmentation
- speech-synthesis
- swift
- typescript
- voice

Log in or sign up for Devpost to join the conversation.