Inspiration
Crowd disasters often happen because dangerous density levels are detected too late. I wanted to explore whether an AI‑driven predictive model could help event teams identify risk earlier and trigger faster responses. This POC tests that idea through a real‑time simulation with a human‑in‑the‑loop (HITL) workflow to ensure operator control.
What it does
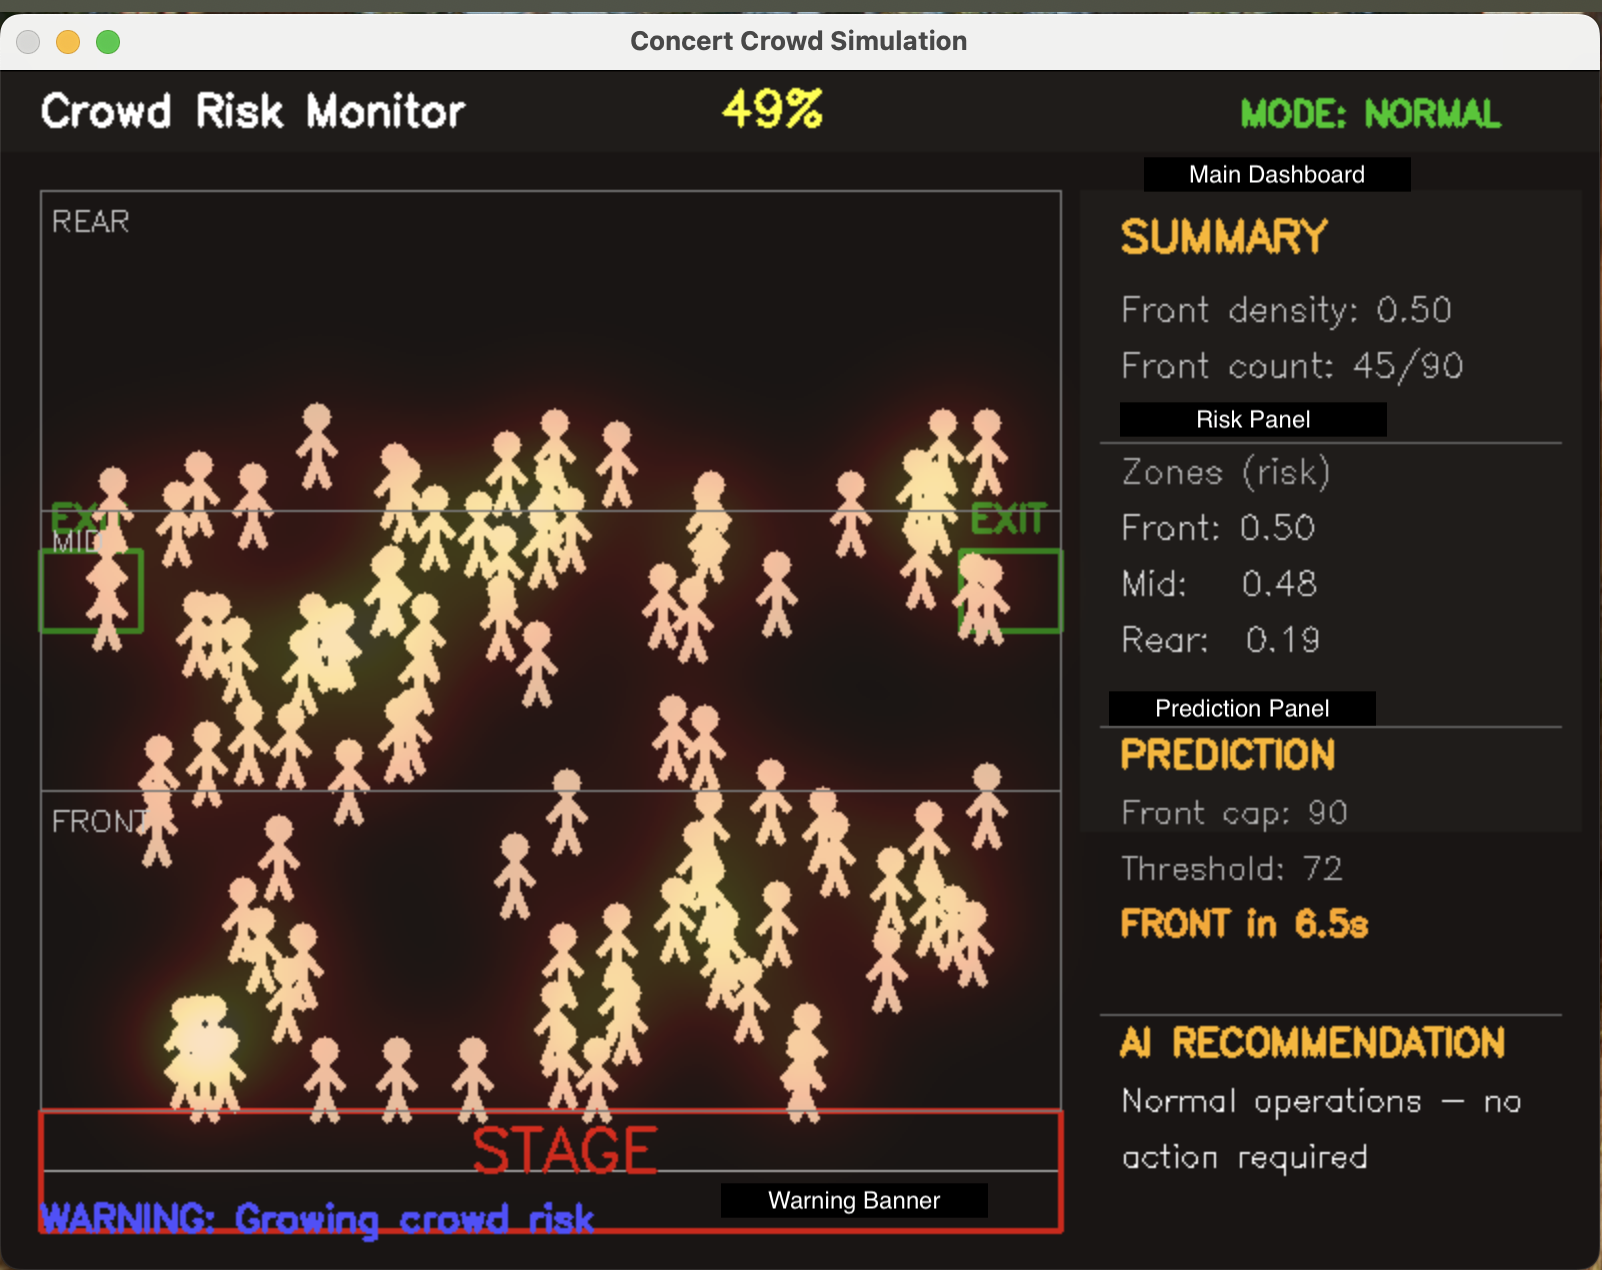
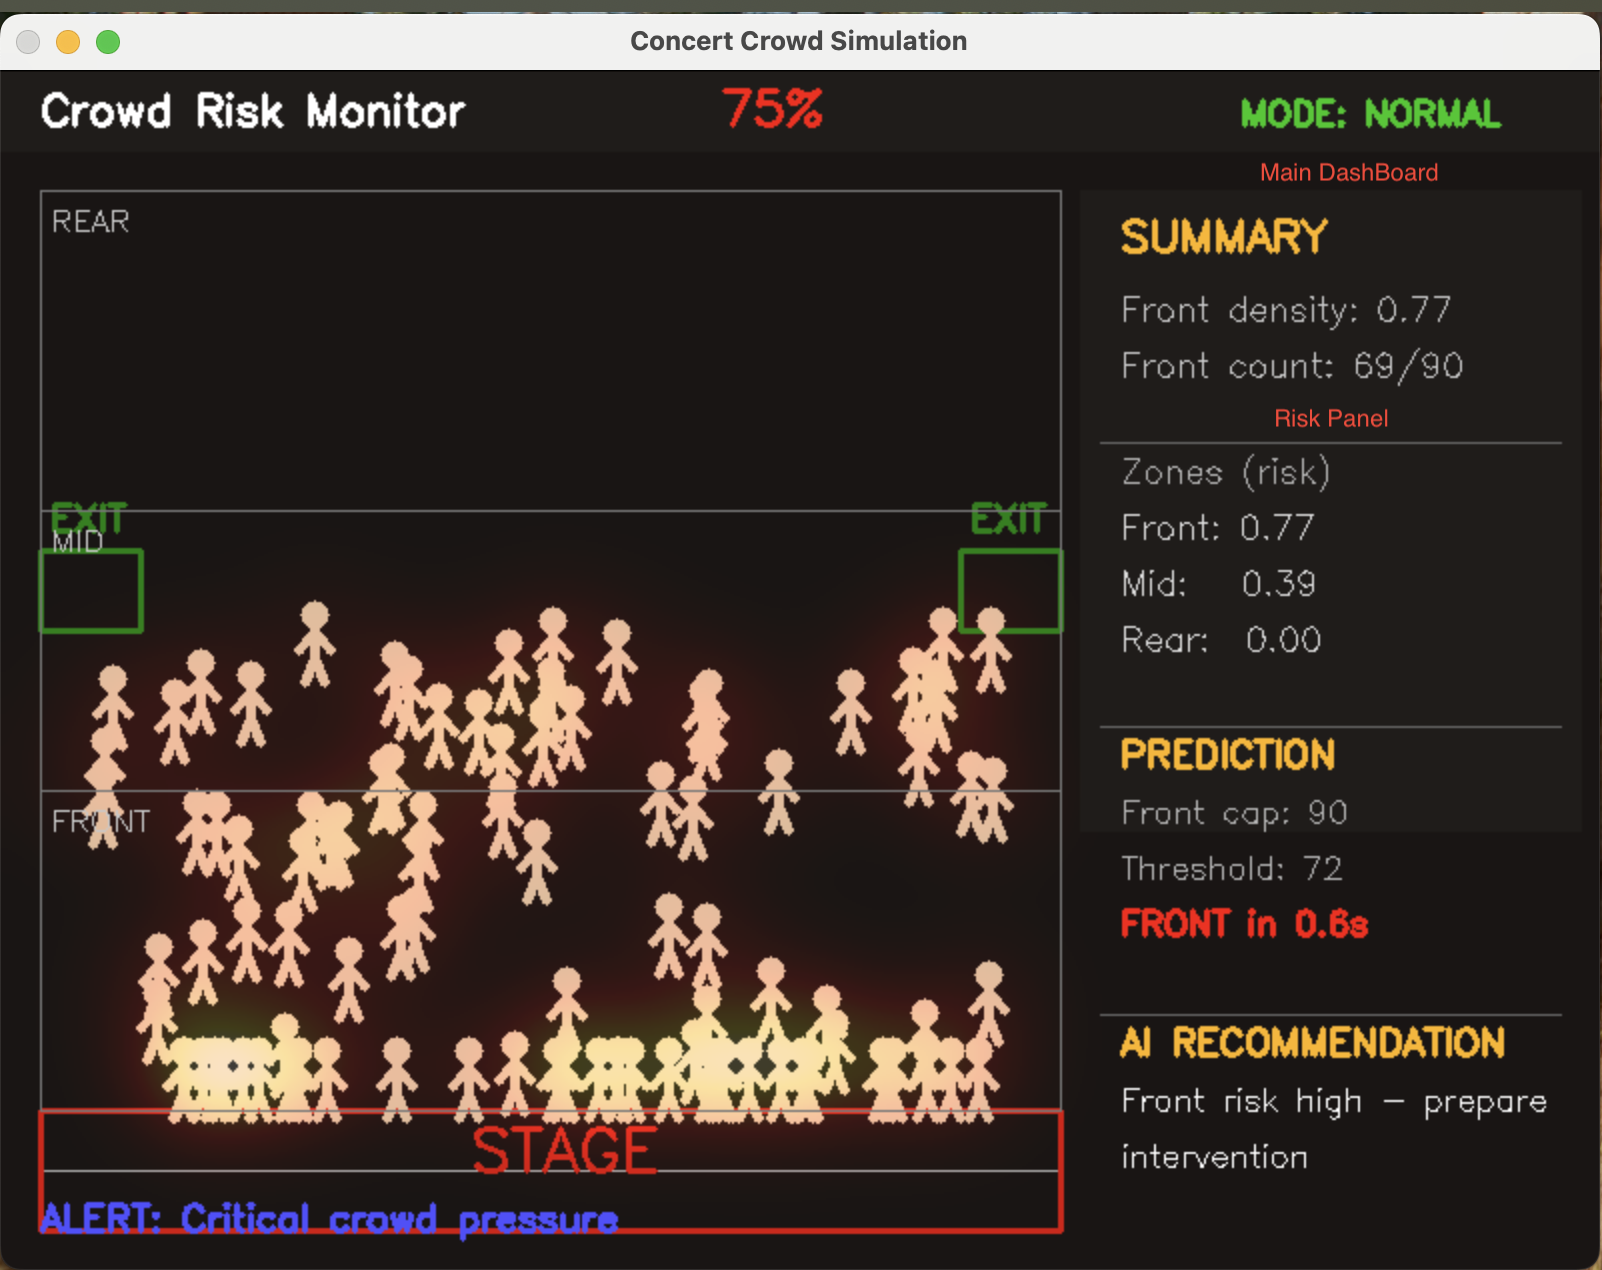
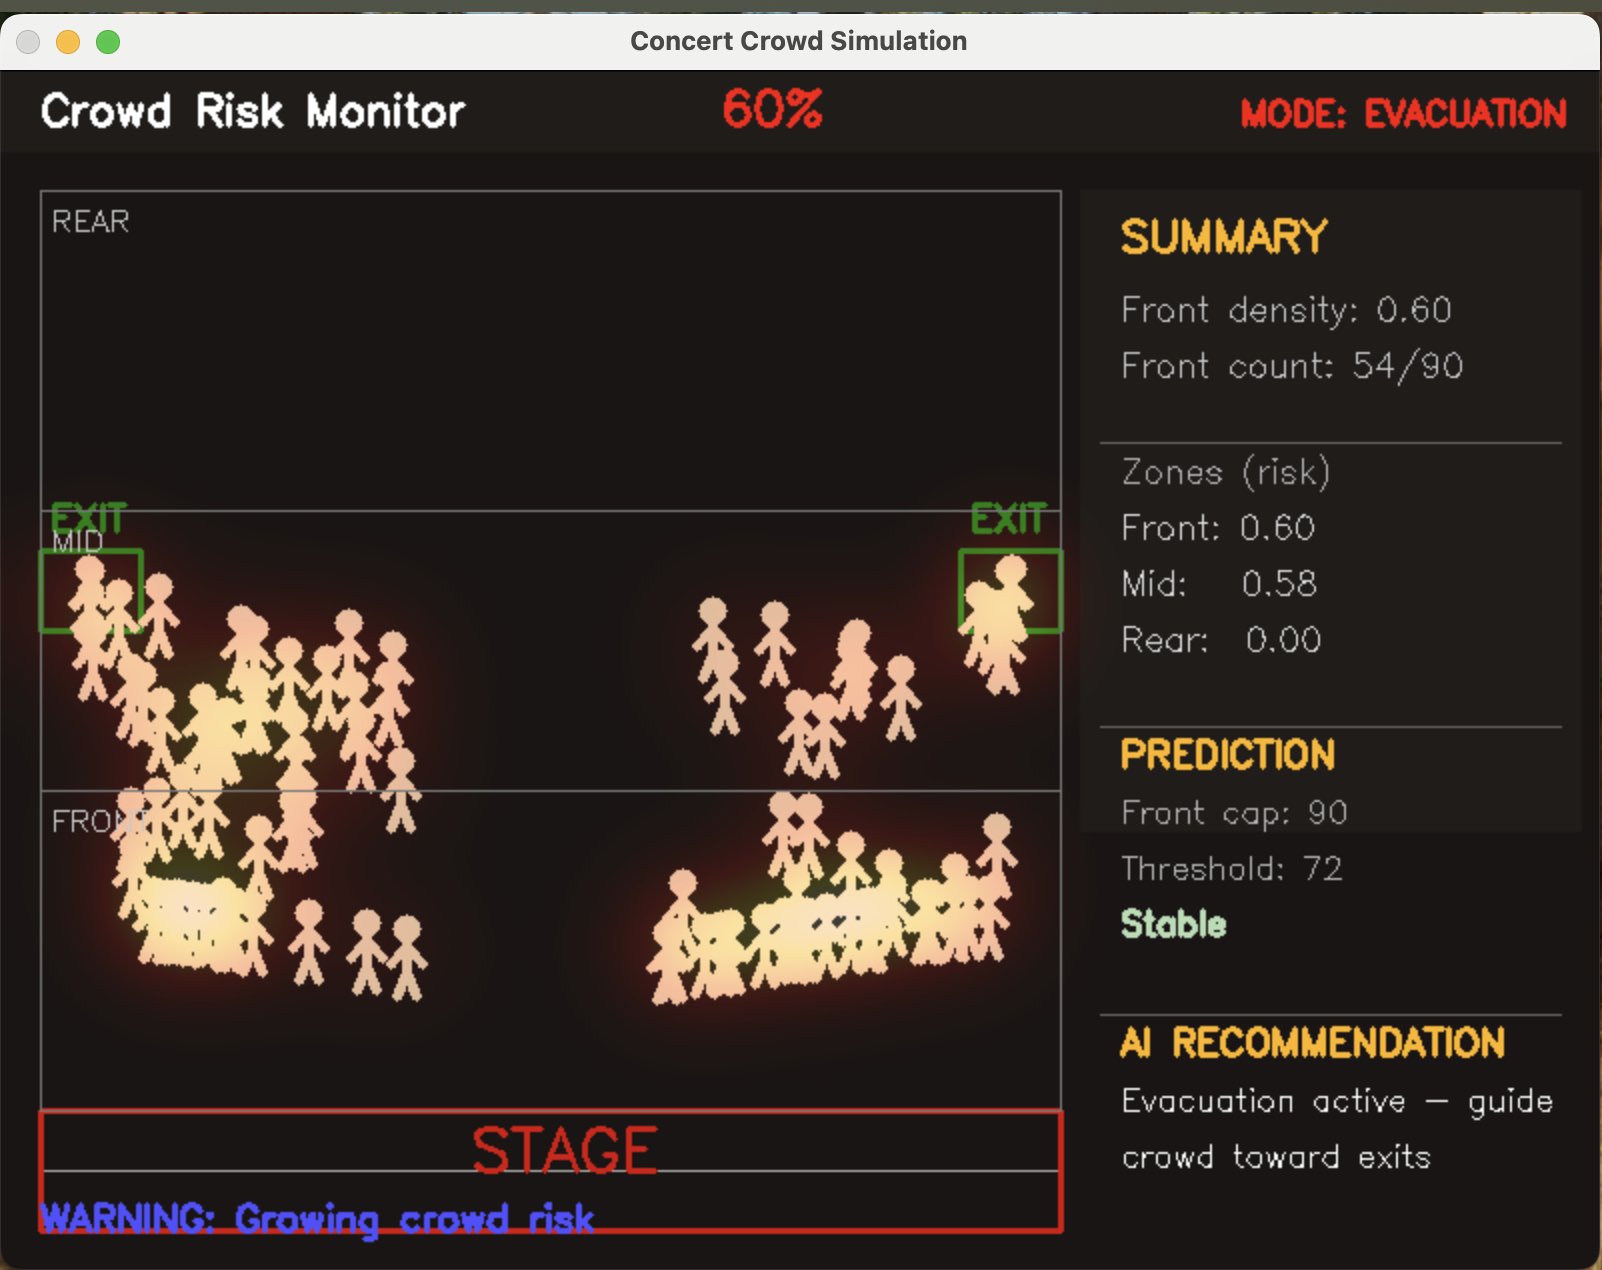
CrowdSynthetic monitors real‑time crowd density, calculates zone‑based risk, predicts saturation timing, and automatically recommends evacuation when thresholds are crossed. The system follows a human‑in‑the‑loop approach: the operator reviews alerts and manually triggers evacuation mode. It visualizes crowd movement, risk buildup, and AI recommendations in a clean dashboard.
How I built it
I developed the full simulation engine, density calculations, risk scoring model, predictive logic, and evacuation trigger system. I designed the UI using OpenCV, built the real‑time update loop, and produced the demo video and project documentation. The workflow was intentionally designed as human‑in‑the‑loop, ensuring operators validate alerts and make final decisions.
Challenges
The biggest challenge was designing a risk model that feels realistic while keeping the simulation lightweight. Balancing UI clarity with rapid updates required multiple iterations. Ensuring smooth transitions between NORMAL and EVAC modes—while keeping the operator in control—also required careful tuning.
Accomplishments
I built a complete end‑to‑end POC that demonstrates real‑time crowd monitoring, predictive risk analysis, and operator‑triggered evacuation logic. The final UI is clean, readable, and communicates safety information effectively. The demo video clearly showcases the system’s behavior and HITL workflow.
What’s next
Future versions will integrate real‑world crowd data, add computer vision for live camera feeds, build a web dashboard, and support multi‑zone evacuation routing. This POC focuses on the core simulation, risk model, HITL workflow, and UI; the next step is connecting it to real environments and expanding operator decision‑support tools.
Built with
- Python
- NumPy
- OpenCV
- Custom risk model
- Custom prediction engine
- Human‑in‑the‑loop workflow

Log in or sign up for Devpost to join the conversation.