-
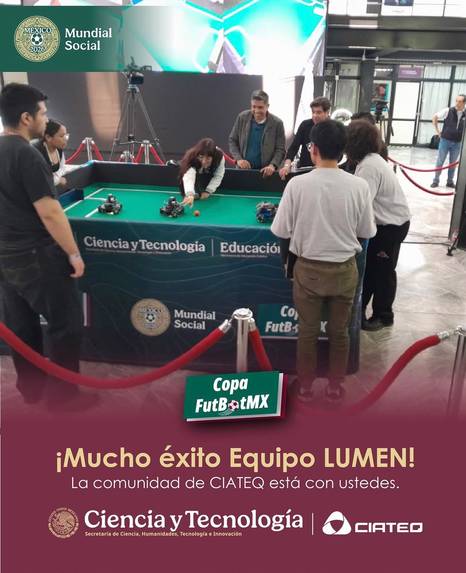
Publication made by CIATEQ
-
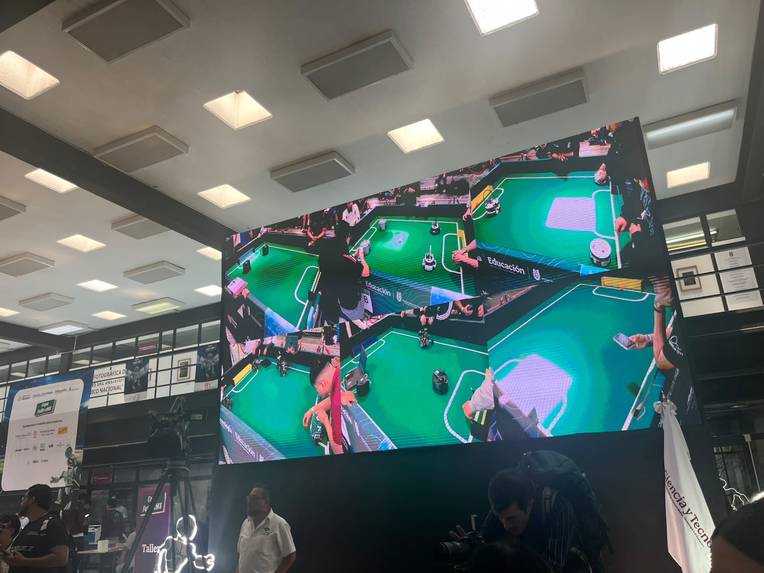
Competition day!
-
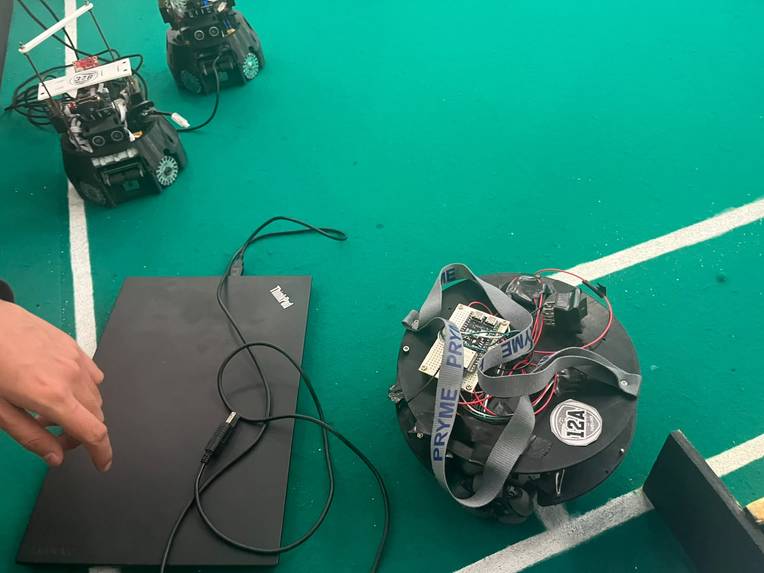
Funny side note: We were actually 1v2'ing the entire competition because our other robot died. :[
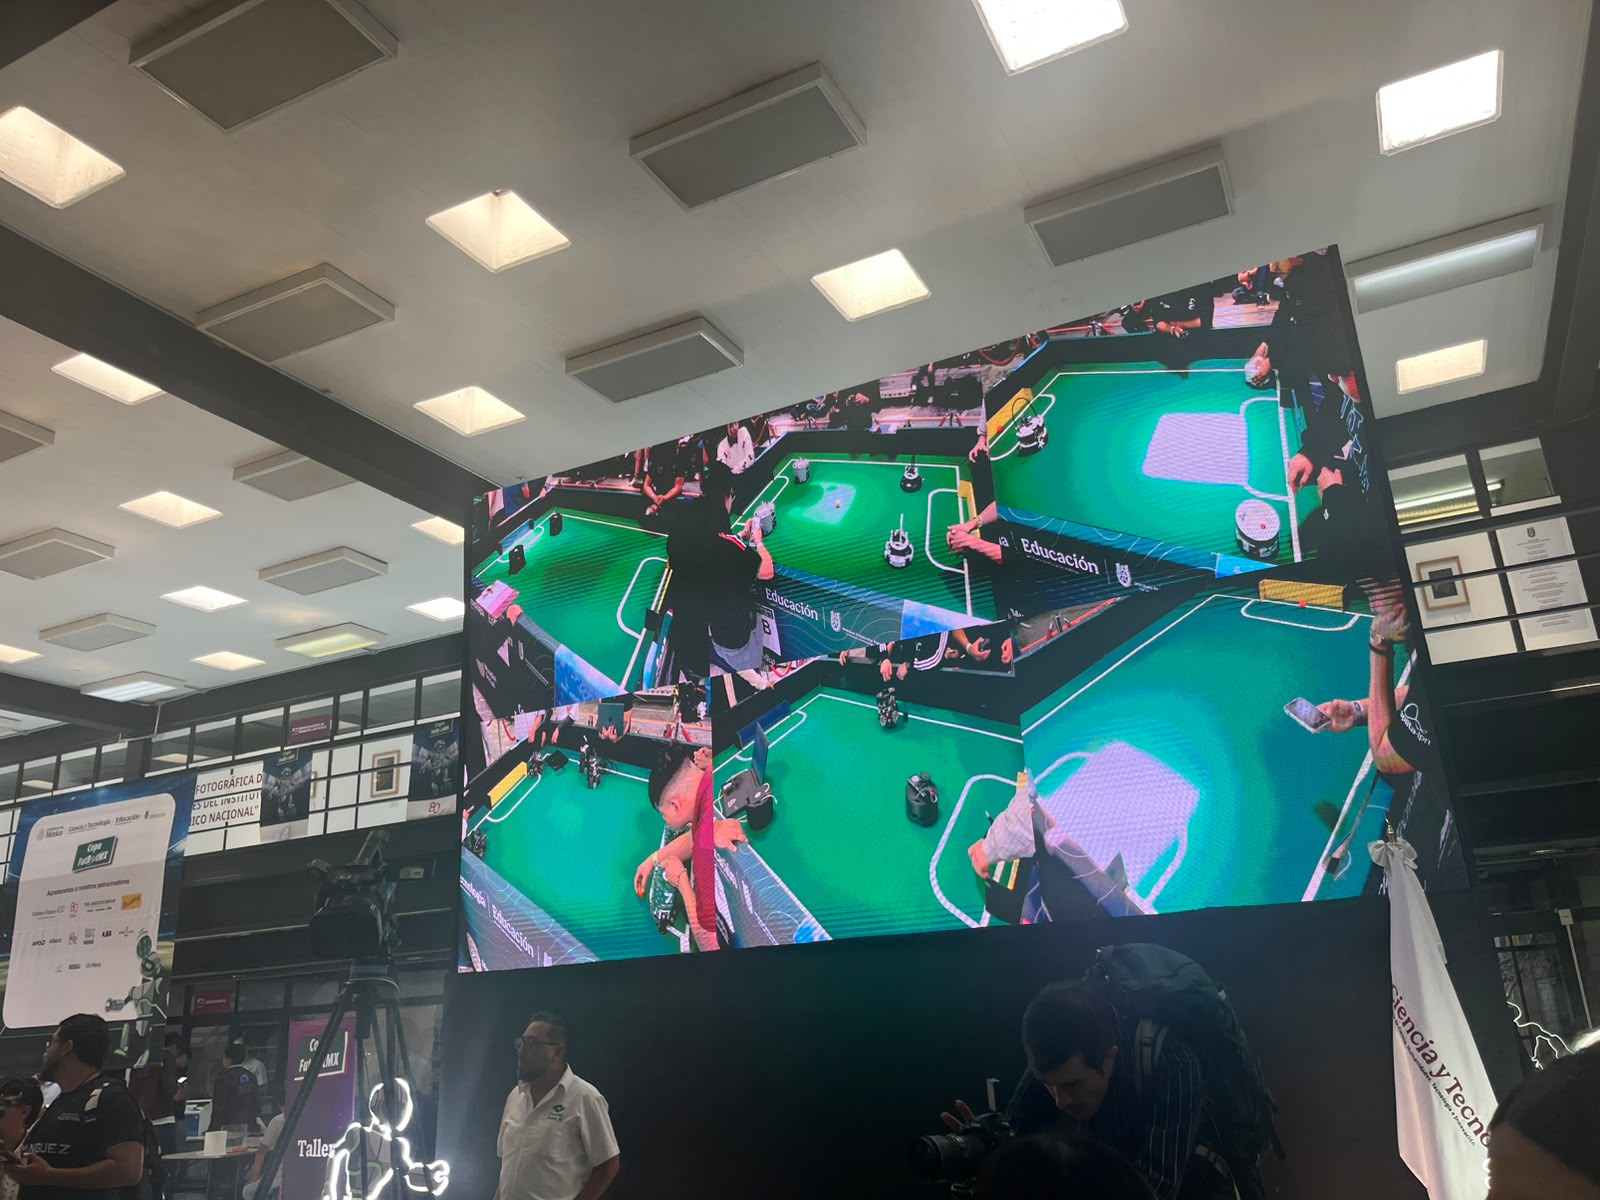
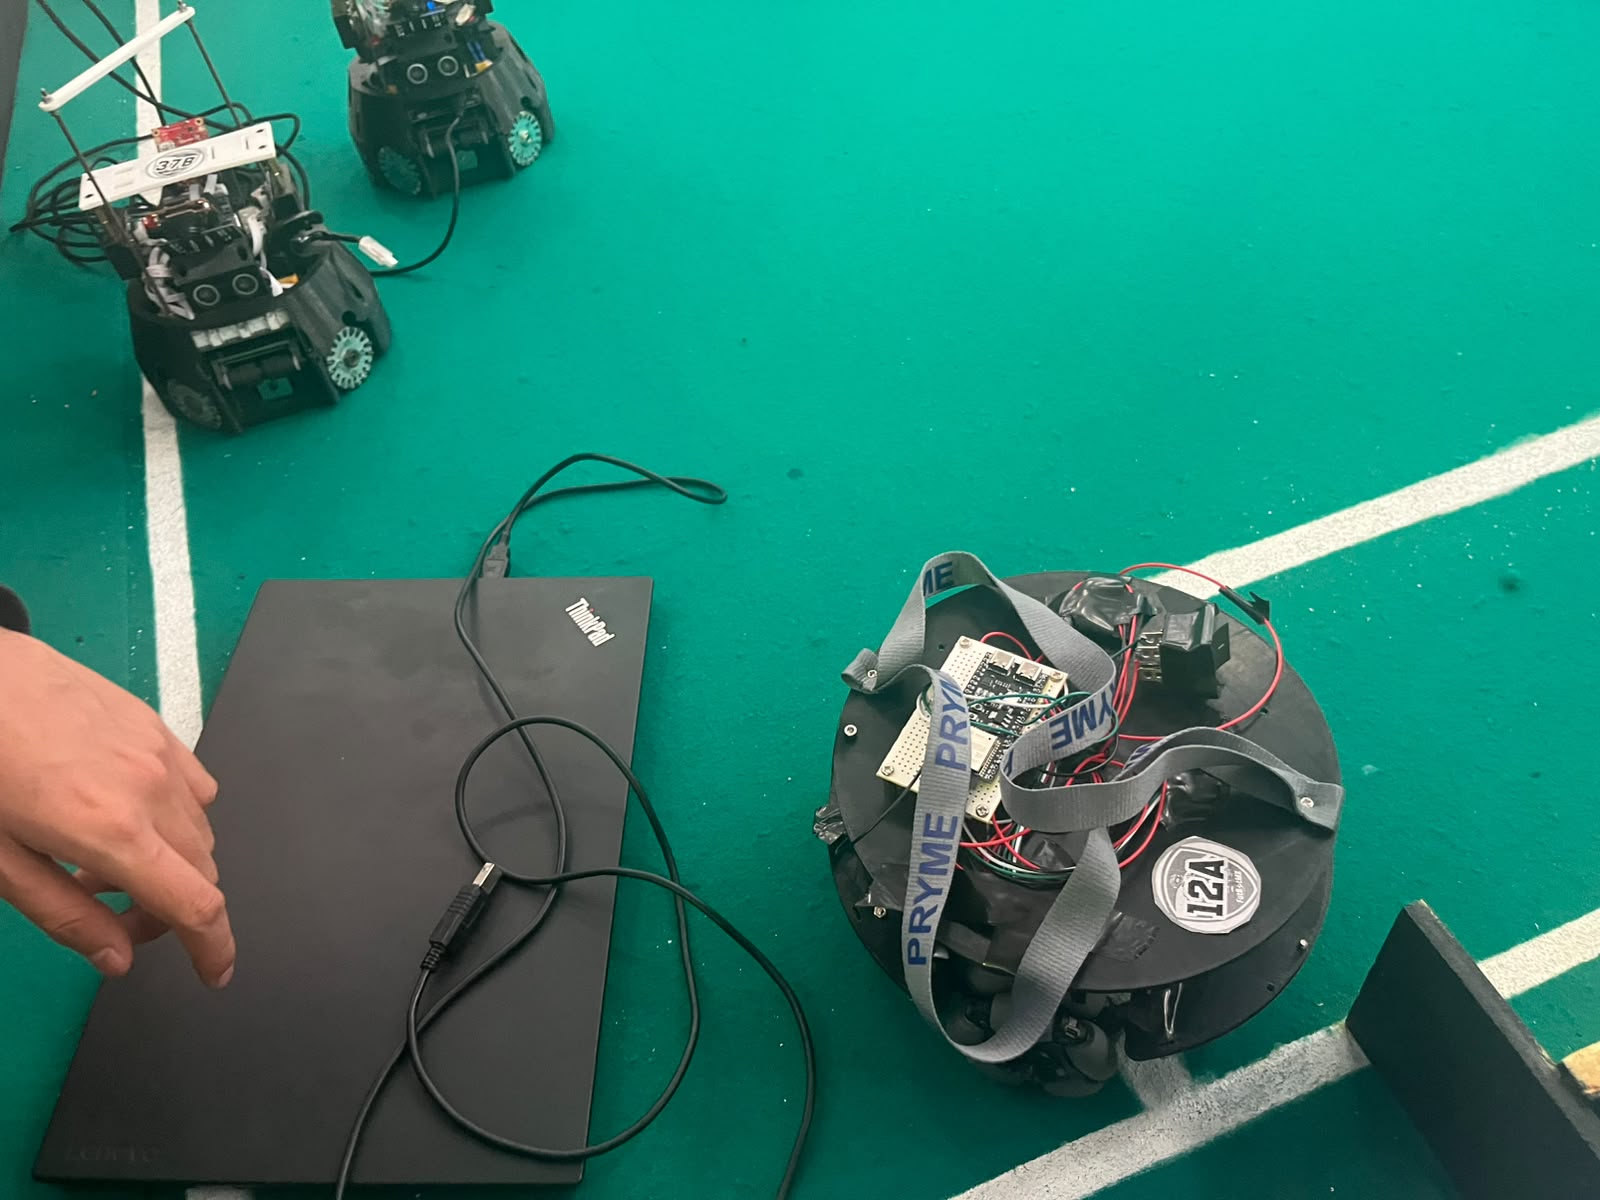
Copa FutBotMX 2026 — Team Lumen - Sponsored by CIATEQ
Autonomous robotic soccer for the Agile Category | June 24–26, 2026 · UPIITA-IPN, Mexico City

The Team
We are a three-person student team from Mexico, sponsored and supported by CIATEQ — Centro de Tecnología Avanzada A.C., a leading applied research and technology center.
| Member | Role |
|---|---|
| Miguel (Team Leader) | Software architecture, firmware, algorithms & control |
| Enrique | Electronics design, PCB integration & software support |
| Norma | Mechanical design, robot structure, chassis & hardware assembly |
We are competing in the Categoría Ágil — the infrared ball detection category — where two fully autonomous robots per team play 2×10-minute matches with no remote control allowed.
What We're Building
Two fully autonomous soccer robots capable of detecting an IR-emitting ball, tracking it, making coordinated decisions, and scoring goals — all without any human intervention during play.
The robots communicate wirelessly with each other via ESP-NOW, share game state in real time, and divide responsibilities between an attacker and a defender role. Everything from ball detection to motor control runs on-board at ≥100 Hz.
Technical Overview
Hardware Platform
| Component | Specification |
|---|---|
| Microcontroller | ESP32-S3 |
| Drive system | 3-wheel omnidirectional (holonomic) |
| Ball detection | 7× VS1838B IR receiver array |
| Line detection | 4× TCS34725 RGB color sensors (via TCA9545A I²C mux) |
| Orientation | BMI160 6-axis IMU (gyro + accelerometer) |
| Actuator | Solenoid kicker |
| Communication | ESP-NOW (inter-robot), Wi-Fi AP (telemetry dashboard) |
| Max weight | 1.4 kg |
| Max diameter | 22 cm |
Software Architecture
The firmware is written in C++17 using PlatformIO with the Arduino core for ESP32-S3. Key design principles:
- Non-blocking main loop targeting ≥ 100 Hz — no
delay()inloop() - FreeRTOS mutexes for thread-safe sensor data sharing
- State machine for autonomous behavior:
IDLE → SEARCH → APPROACH → DRIBBLE → SHOOT - Inverse kinematics for 3-wheel omnidirectional drive
- Web telemetry dashboard served directly from the robot over Wi-Fi
Project Structure
Copa-FutBotMX-2026/
├── src/
│   ├── main.cpp                  ← Entry point, main loop
│   ├── config/
│   │   └── config.h              ← Pin definitions, PID gains, timing constants
│   ├── core/
│   │   ├── state.h / .cpp        ← Global robot state (role, FSM, sensor data)
│   │   └── SensorManager.h / .cpp← Unified sensor access layer
│   ├── drivers/
│   │   ├── motor_control.h / .cpp← Holonomic motor driver + inverse kinematics
│   │   └── kicker.h / .cpp       ← Solenoid kicker with cooldown logic
│   ├── sensors/
│   │   ├── ir_sensor_array.h / .cpp   ← IR ball detection + circular mean angle
│   │   ├── ColorSensorArray.h / .cpp  ← Line/boundary detection (TCS34725)
│   │   └── gyro.h / .cpp              ← BMI160 IMU integration
│   ├── behaviors/
│   │   └── strategy.h / .cpp     ← Game state machine + role logic
│   ├── comms/
│   │   └── comms.h / .cpp        ← ESP-NOW inter-robot communication
│   └── net/
│       ├── wifi.h / .cpp         ← Wi-Fi AP/STA management
│       └── web_server.h / .cpp   ← Async REST API + telemetry dashboard
├── shared/
│   ├── ir_protocol.h             ← ESP-NOW message structs (roles, states)
│   ├── field_constants.h         ← Field dimensions in cm
│   └── debug_utils.h             ← LOG() macro (disabled in production builds)
├── data/
│   ├── index.html                ← Telemetry dashboard UI
│   ├── style.css
│   └── script.js
├── docs/
│   ├── BOM.md                    ← Bill of Materials (required for registration)
│   └── poster/
└── platformio.ini
Project Highlights
IR Ball Tracking
The robot uses 7 infrared receivers arranged around its perimeter. A monostable retriggerable filter removes noise, and a circular mean algorithm calculates the precise angle to the ball — even when multiple sensors fire simultaneously.
Holonomic Drive
Three omni-wheels at 90°, 210°, and 330° allow the robot to move in any direction instantly — forward, sideways, diagonal — without rotating first. Full inverse kinematics implemented from scratch.
Live Telemetry Dashboard
Each robot hosts a web dashboard over its own Wi-Fi access point. From any browser on the same network you can monitor:
- Robot role and game state
- IR sensor array (radar view)
- Gyro/IMU heading and orientation
- RGB color sensor readings
- Real-time uptime and emergency stop
Inter-Robot Coordination
Both robots communicate at ≥10 Hz using ESP-NOW (no router required). They share ball angle, confidence, heading, and role — enabling cooperative strategies like one robot defending while the other attacks.
Gallery
Photos and GIFs will be added as the build progresses.
| Robot Build | Telemetry Dashboard | Field Test |
|---|---|---|
| (coming soon) | (coming soon) | (coming soon) |
Getting Started
Prerequisites
- PlatformIO (VS Code extension recommended)
- ESP32-S3 board
Resources
Licencia / License
This project is developed for academic and competition purposes. See LICENSE for details.
🇲🇽 Versión en Español
For our sponsor, teammates, and the Mexican robotics community — here's a complete overview in Spanish.
Copa FutBotMX 2026 — Equipo CIATEQ
Este repositorio contiene el firmware completo y la arquitectura de software para nuestros dos robots de fútbol autónomos, con los que competimos en la Copa FutBotMX 2026, Categoría Ágil (24–26 de junio, UPIITA-IPN, Ciudad de México).
El Equipo
Somos un equipo de tres estudiantes mexicanos, patrocinados y apoyados por CIATEQ — Centro de Tecnología Avanzada A.C..
| Integrante | Área |
|---|---|
| Miguel (Líder) | Software: arquitectura, firmware, algoritmos y control |
| Enrique | Electrónica: diseño de circuitos, integración de PCB y apoyo en software |
| Norma | Hardware: diseño mecánico, estructura del chasis y ensamblaje |
¿Qué estamos construyendo?
Dos robots de fútbol completamente autónomos capaces de detectar una pelota emisora de IR, rastrearla, tomar decisiones coordinadas y marcar goles — sin ninguna intervención humana durante el juego.
Los robots se comunican entre sí de forma inalámbrica mediante ESP-NOW, comparten estado de juego en tiempo real y se dividen responsabilidades entre el rol de atacante y defensor. Todo el procesamiento ocurre en el robot a ≥100 Hz.
Resumen Técnico
Plataforma de hardware:
- Microcontrolador ESP32-S3
- Sistema de tracción omnidireccional de 3 ruedas (holonómico)
- 7 receptores IR VS1838B para detección de pelota
- 4 sensores de color TCS34725 para detección de líneas blancas
- IMU BMI160 de 6 ejes para orientación
- Patada solenoide
- Comunicación ESP-NOW entre robots + dashboard de telemetría vía Wi-Fi
Software:
- C++17 con PlatformIO y Arduino core para ESP32-S3
- Loop principal no bloqueante a ≥100 Hz
- Máquina de estados para comportamiento autónomo
- Cinemática inversa para tracción omnidireccional
- Dashboard de telemetría en tiempo real accesible desde el navegador
Estado del Proyecto
| Subsistema | Estado |
|---|---|
| Control de motores (holonómico) | ✅ Implementado |
| Detección IR de pelota | ✅ Implementado |
| Sensores de color / línea | ✅ Implementado |
| IMU / giroscopio | ✅ Implementado |
| Comunicación ESP-NOW | ✅ Implementado |
| Dashboard de telemetría Wi-Fi | ✅ Implementado |
| Patada (kicker solenoide) | ✅ Implementado |
| Estrategia y lógica de juego | 🔄 En desarrollo |
| Chasis + llantas + ensamble físico | 🔄 En progreso |
| Pruebas de campo completas | 🔜 Pendiente |
🤝 Agradecimientos
Agradecemos a CIATEQ por el patrocinio, las instalaciones y el apoyo técnico brindado a lo largo de este proyecto. Su respaldo ha sido fundamental para llevar este equipo a la competencia.
Desarrollado con 💚 en México · Copa FutBotMX 2026
Built With
- c
- c++
- css
- html
- javascript
- robotics

Log in or sign up for Devpost to join the conversation.