Closed Loop Motor Control System (QNX RTOS)
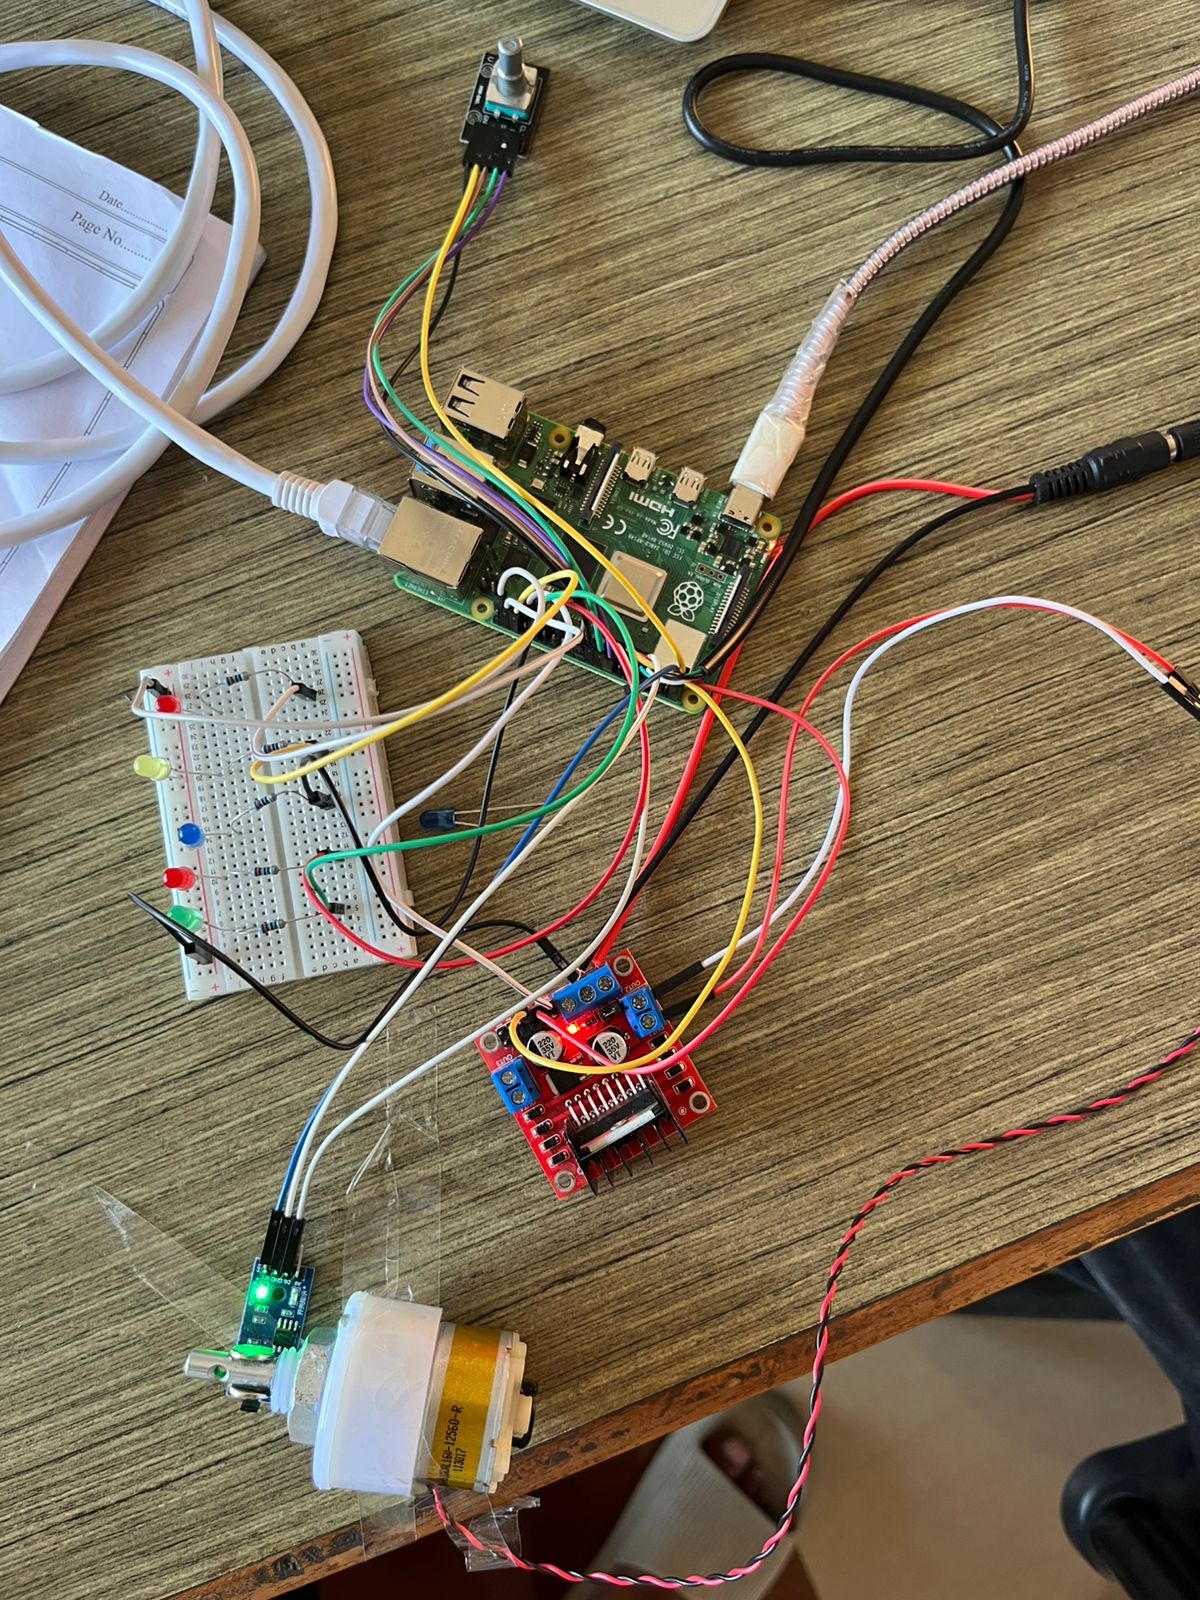
A real-time, multithreaded embedded C application running on QNX RTOS that implements a deterministic closed-loop control system. The system reads feedback from a Hall sensor, processes it through a PID controller, and drives a DC motor via PWM using GPIO on Raspberry Pi 4.
Features
Real-time closed-loop control using feedback PID controller (Proportional + Integral + Derivative) Deterministic execution with 10ms fixed control loop Multithreaded design (Sensor, Controller, Actuator) Priority-based scheduling using SCHED_RR Direction control (Forward / Reverse / Stop) LED visualization for system state CSV logging for analysis (/tmp/log.csv) Safe shutdown with GPIO reset on termination Mutex-based shared memory communication
Hardware Requirements
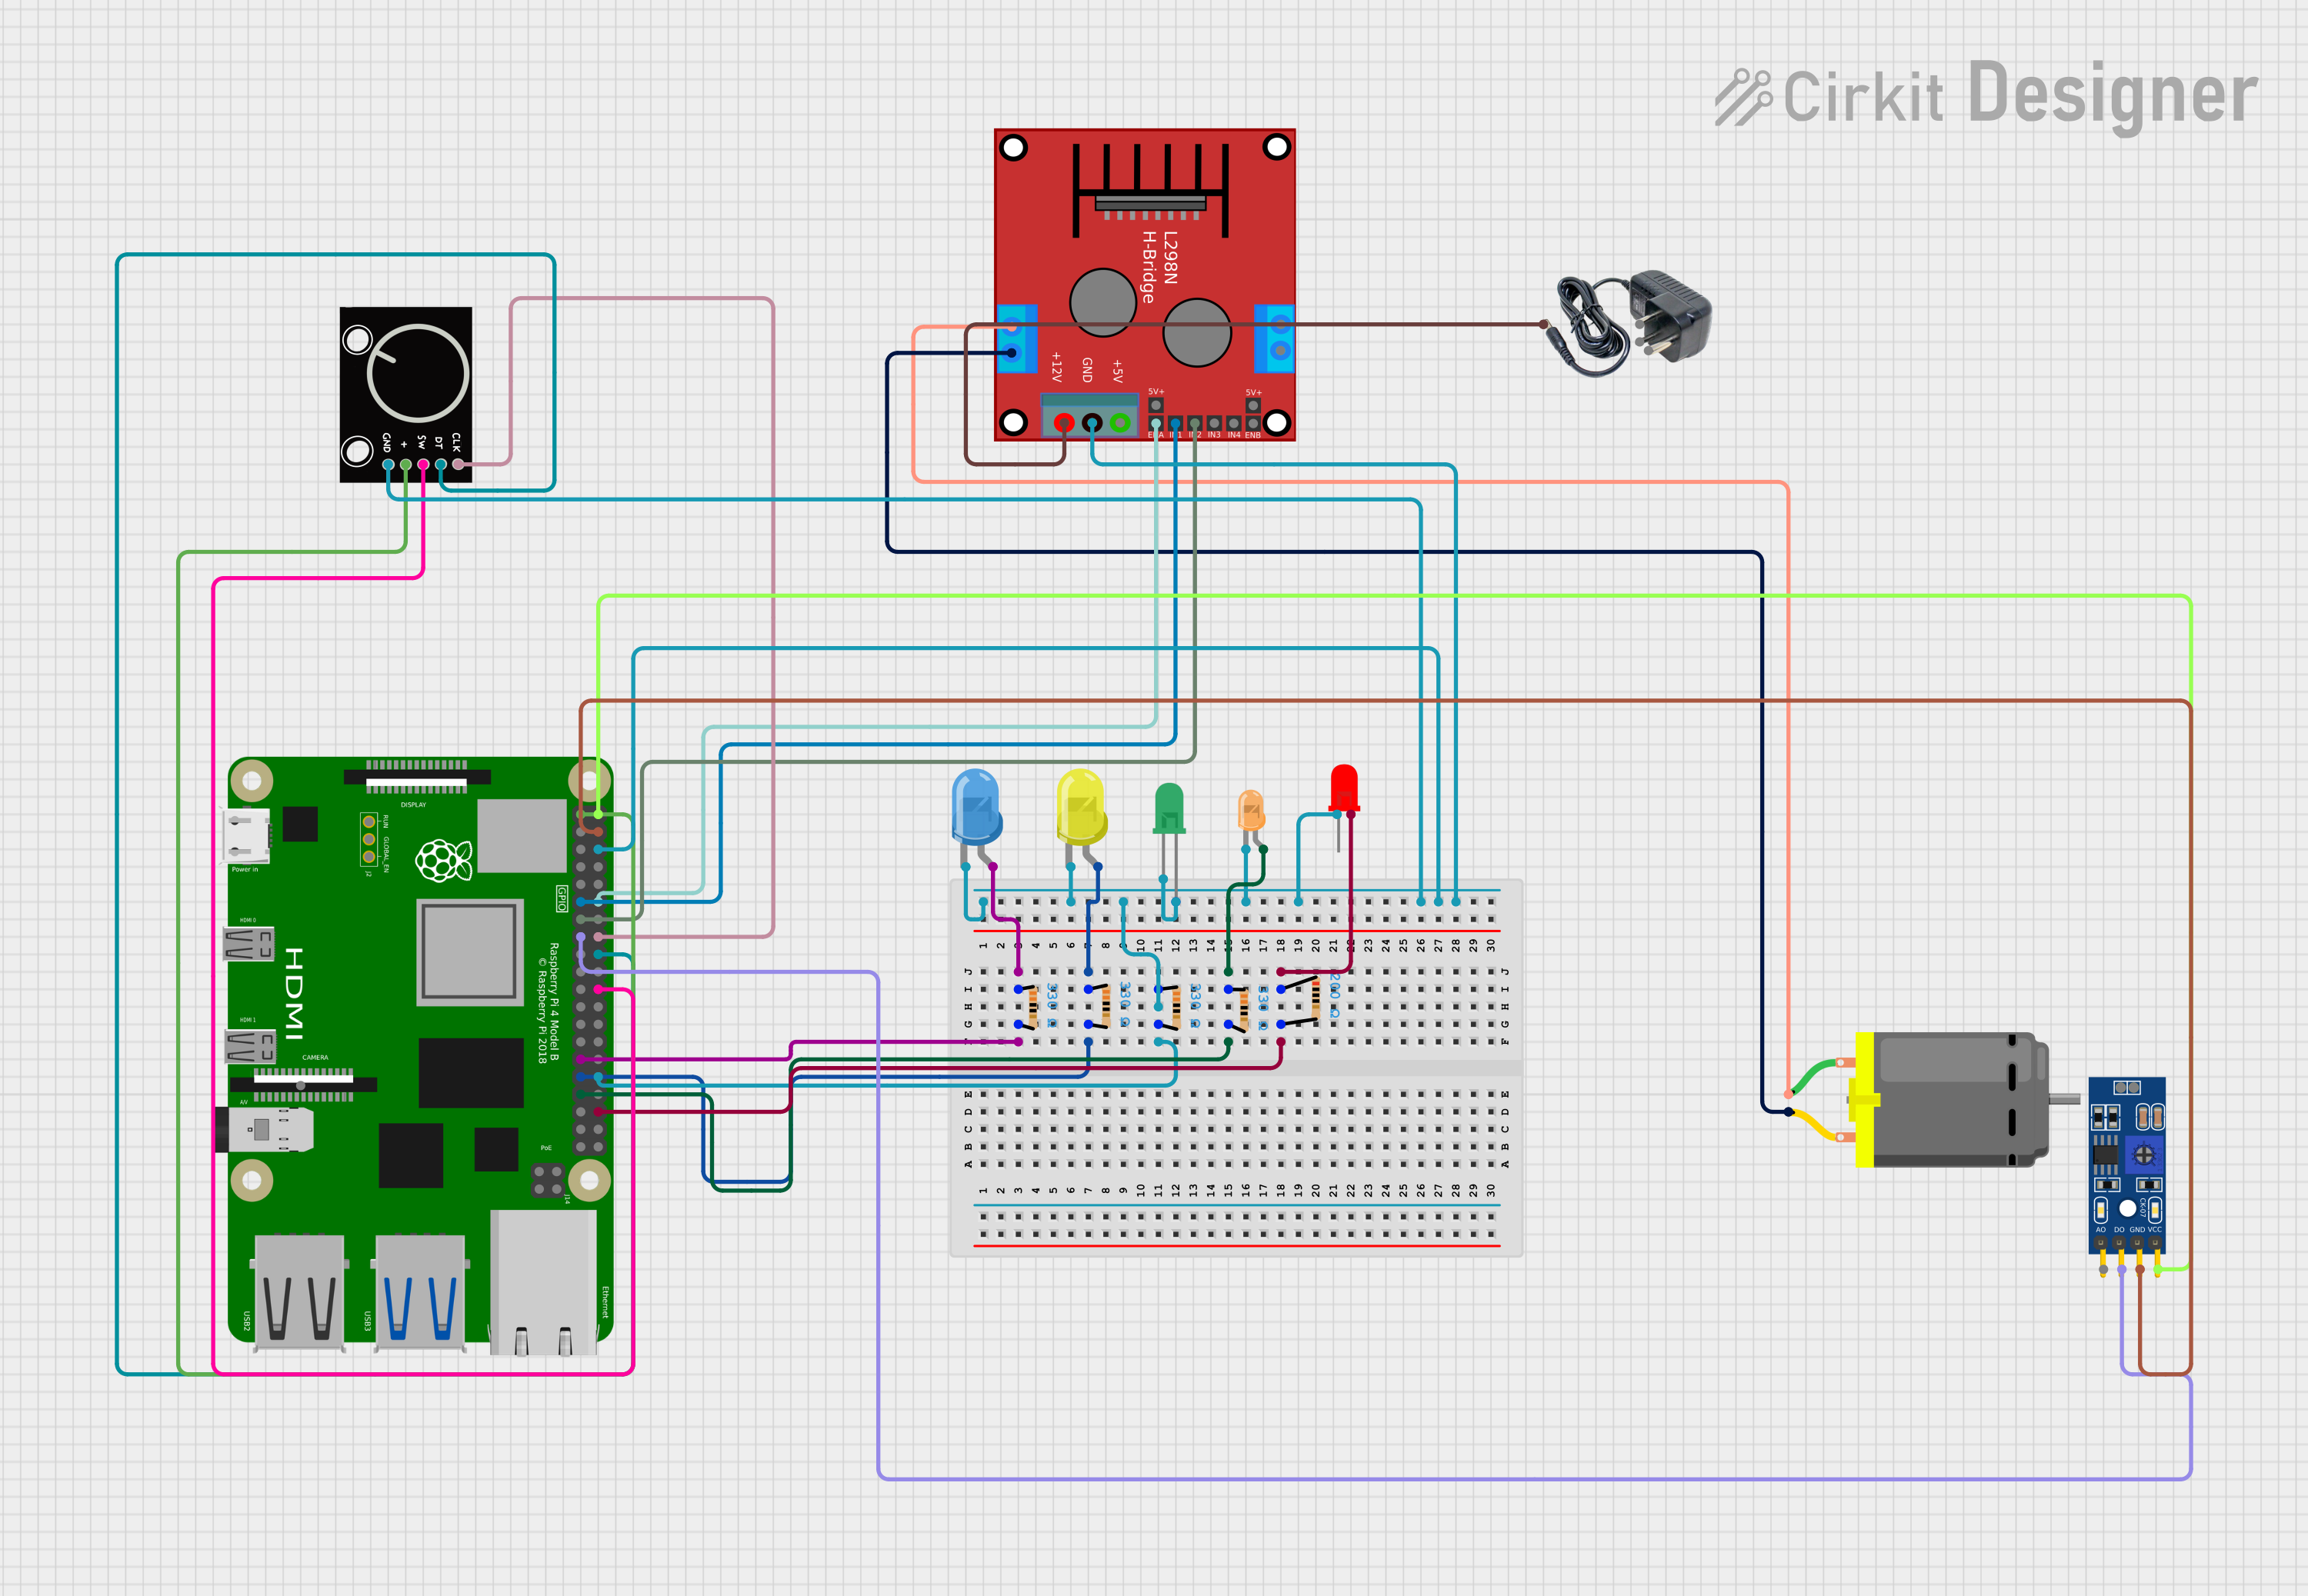
Raspberry Pi 4 QNX Neutrino RTOS (7.x / 8.x) L298N Motor Driver DC Motor LM393 Hall Effect Sensor Small Magnet (attached to motor shaft) LEDs (5x for status indication)
Jumper wires + Power supply
GPIO Configuration
Component GPIO Pin PWM Output GPIO 13 Motor IN1 GPIO 17 Motor IN2 GPIO 27 Hall Sensor GPIO 22 Green LED GPIO 5 Red LED GPIO 6 Blue LED GPIO 12 Yellow LED GPIO 16
White LED GPIO 20
System Architecture
Control Loop Flow Sensor → Controller → Actuator → Sensor (feedback loop) Threads & Scheduling Task Priority Role Sensor Task Medium (15) Reads encoder (Hall sensor) Controller Task High (20) Executes PID algorithm Actuator Task Medium (15) Drives motor & LEDs
✔ Scheduling Policy: SCHED_RR
✔ Loop Period: 10ms (deterministic)
Control Logic
Setpoint (SP): Target encoder count Feedback: Hall sensor pulse count Error: SP - Encoder PID Equation:
Output = KP * error + KI * integral + KD * derivative
LED Indication
LED Condition Green Forward Red Reverse Blue Low speed Yellow Medium speed White High speed
Logging
Data is logged to:
/tmp/log.csv
Format:
Setpoint,Encoder,Speed,Direction,Green,Red,Blue,Yellow,White
Build Instructions
We are Using QNX Momentics IDE Import project
clean Project
Build
Terminal Build: make clean make
Run Instructions
./closed_loop_contol_system
Stop Program (IMPORTANT)
CTRL + C
✔ Motor stops immediately ✔ LEDs turn OFF ✔ Cleanup ensures safe shutdown
Known Limitation
Uses Hall sensor (single channel) Cannot detect direction inherently
Reverse control is approximated using software logic


Log in or sign up for Devpost to join the conversation.