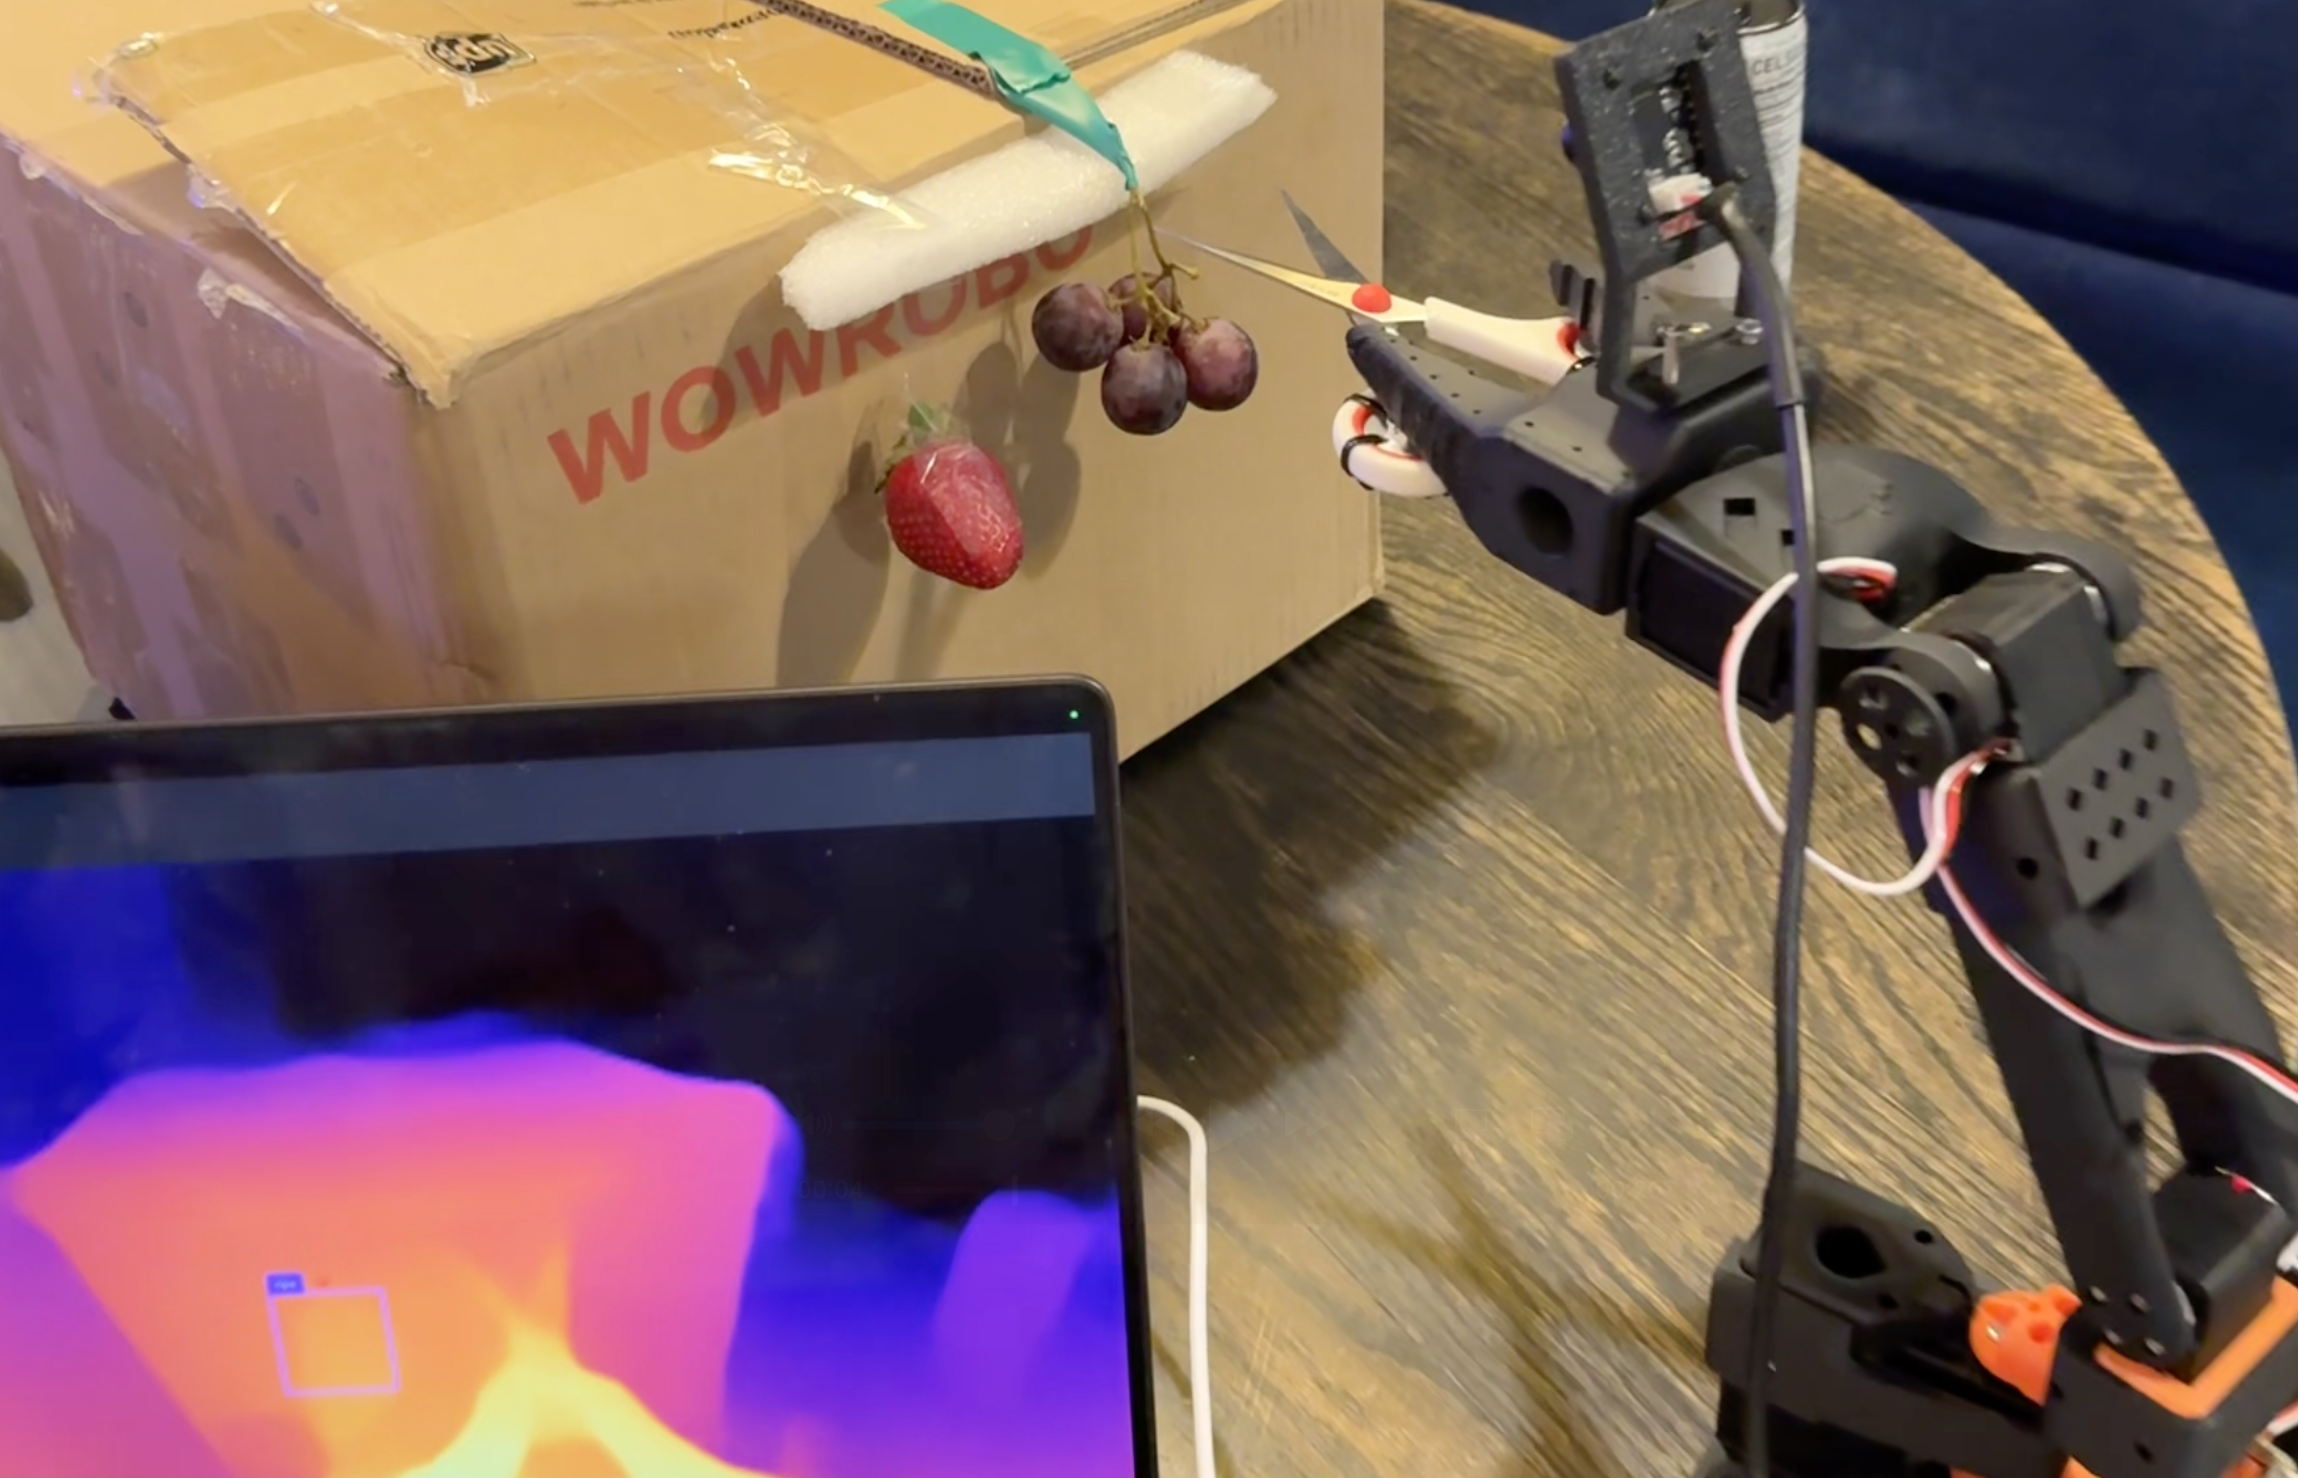
Berry farming robotic arm that uses depth maps from an RGB camera to intelligently find the midpoints of berry bounding boxes and determining stem location.
Barry, The Berry Farmer
Harvesting berries is an extraneous and back-breaking task. We built Barry to solve this and autonomous the process of Berry picking (in theory).
Updates

Leave feedback in the comments!
Log in or sign up for Devpost to join the conversation.