-
-
-
-
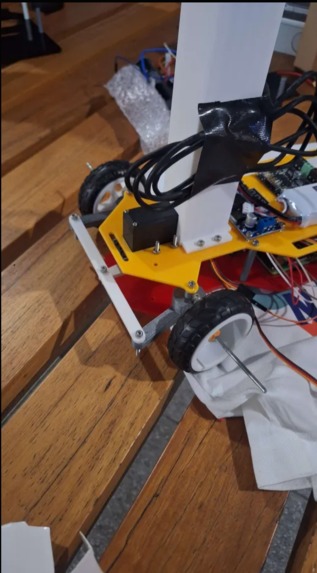
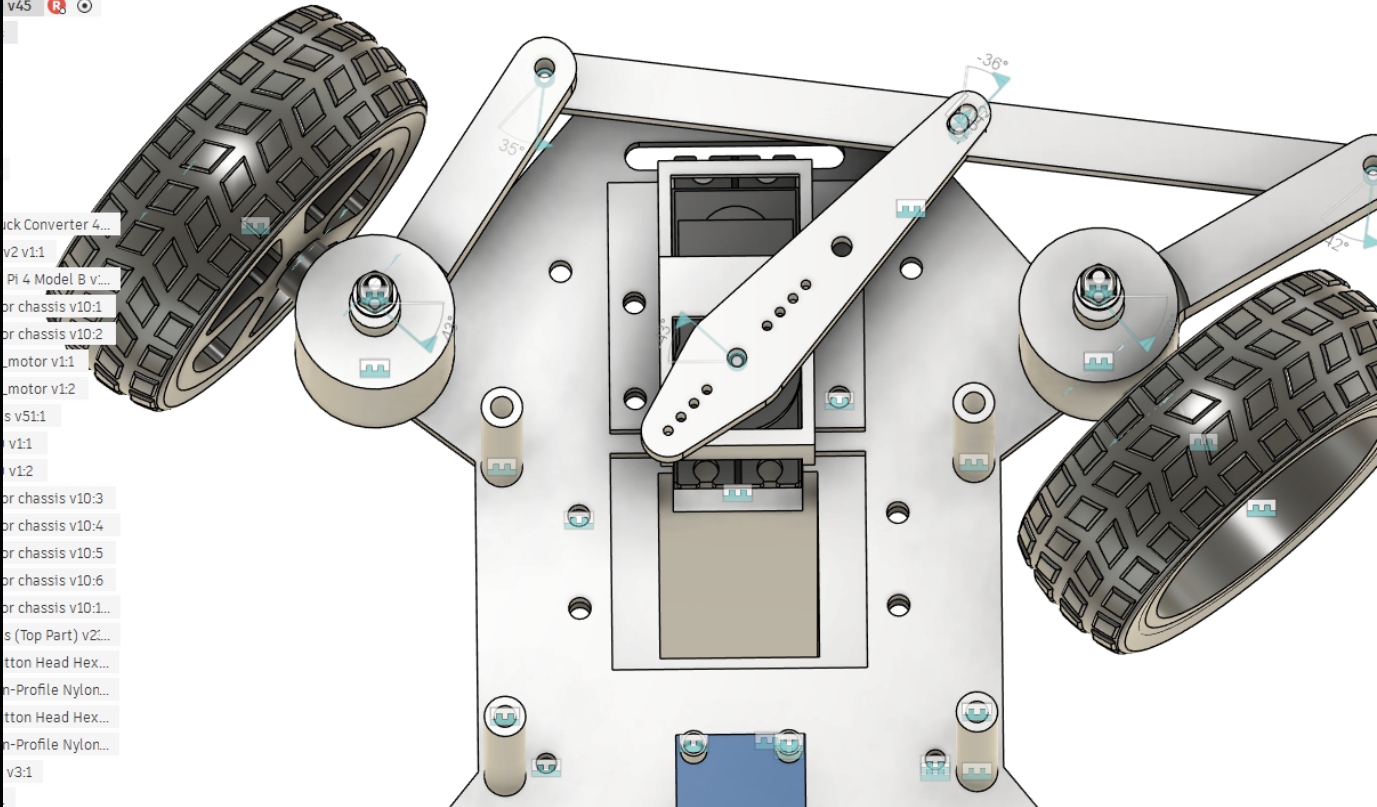
Ackermann design
-
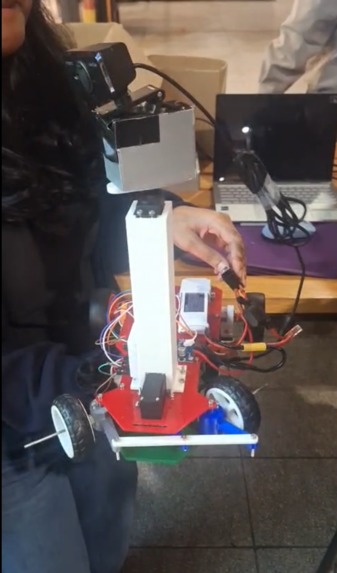
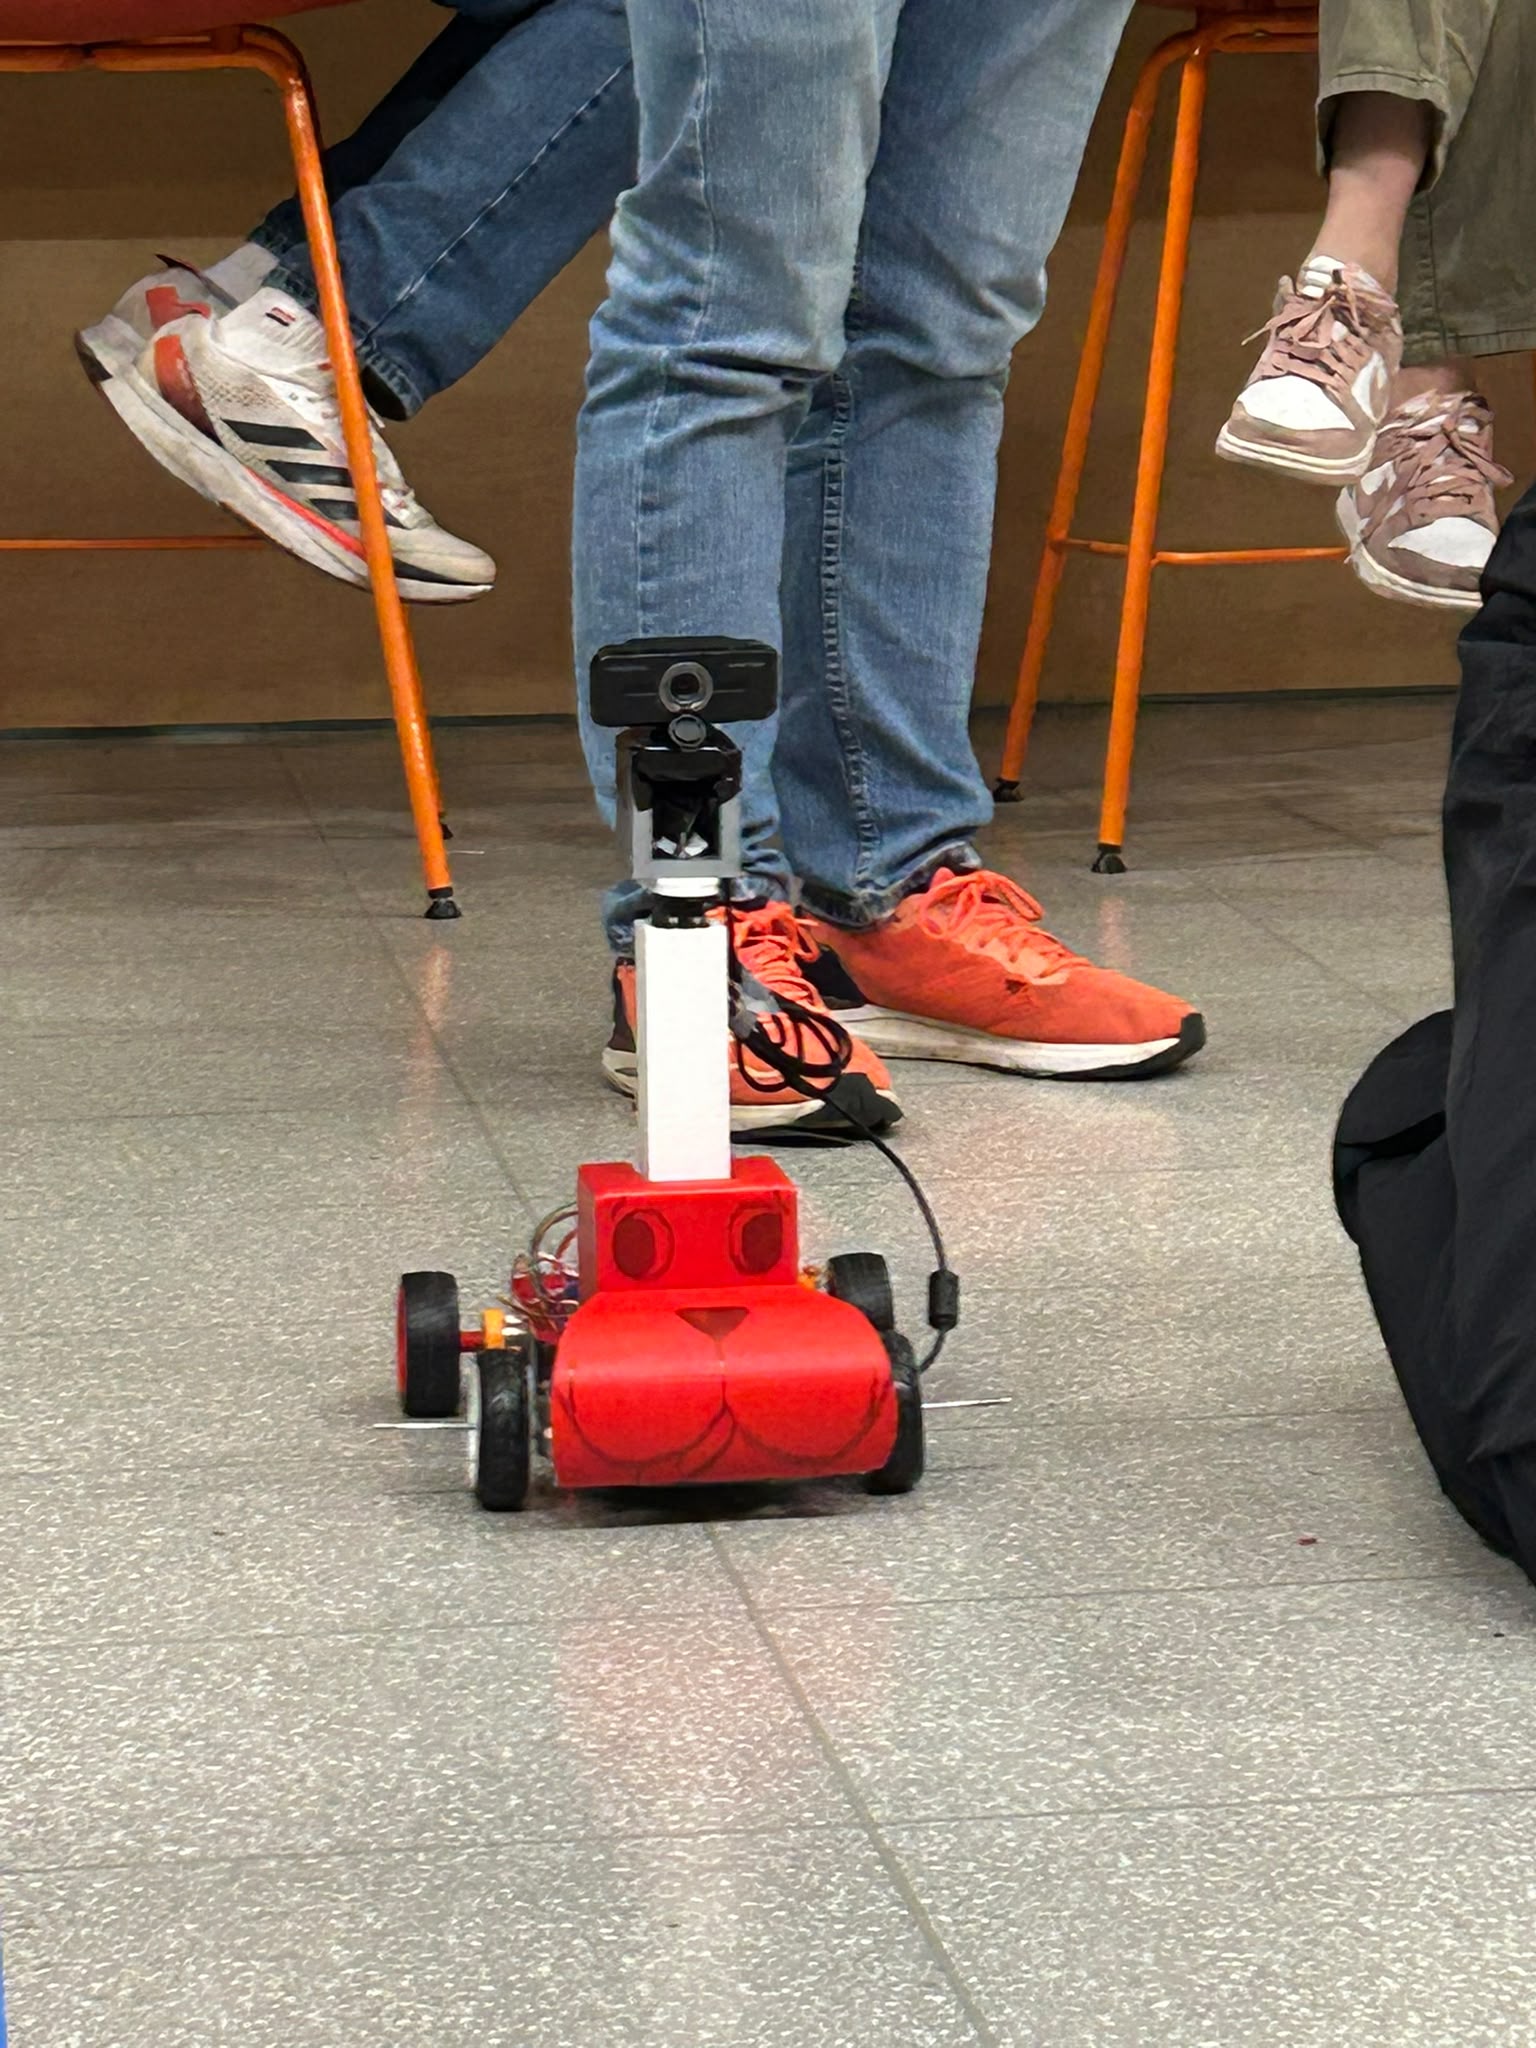
Ackermann in action
-
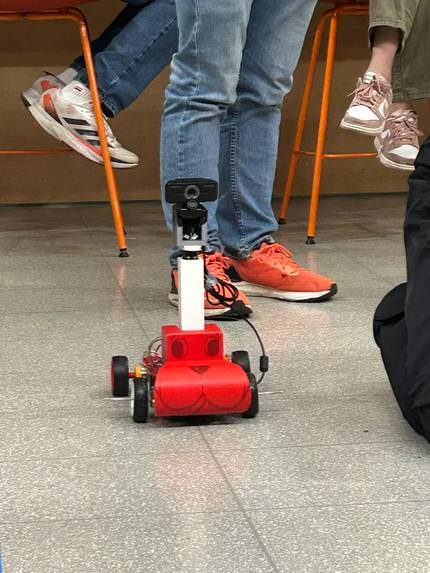
-
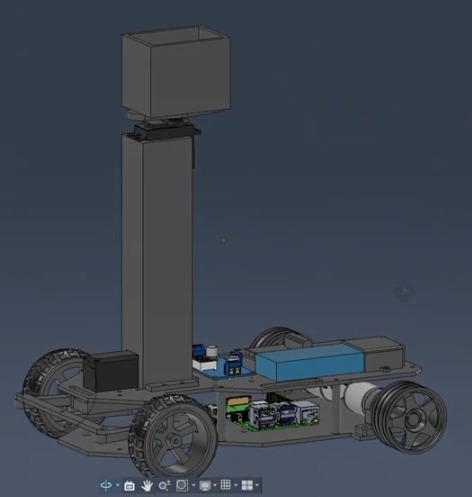
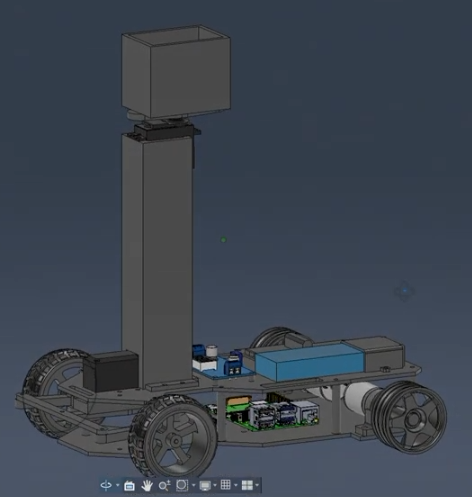
Chassis in cad
-
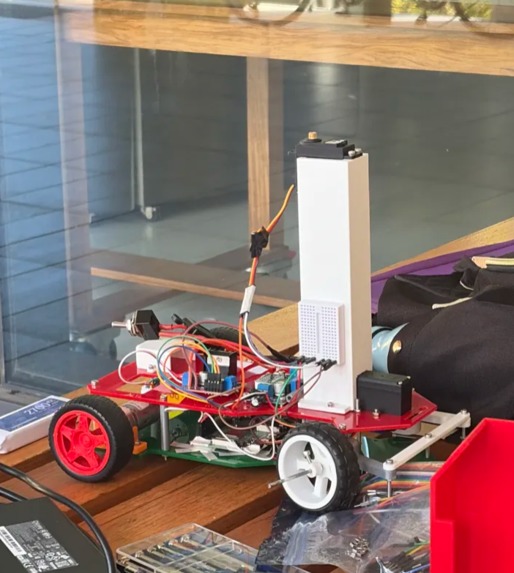
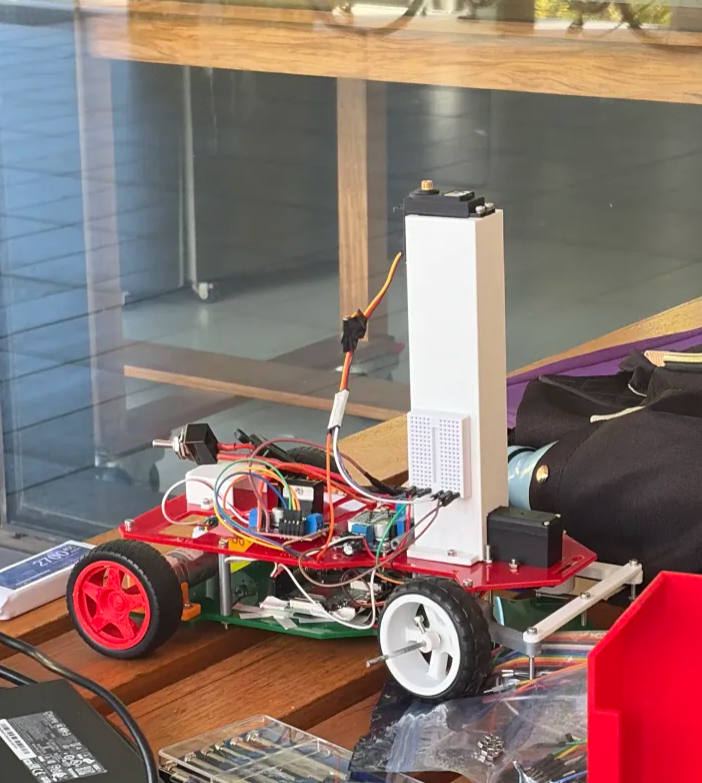
Chassis design
-
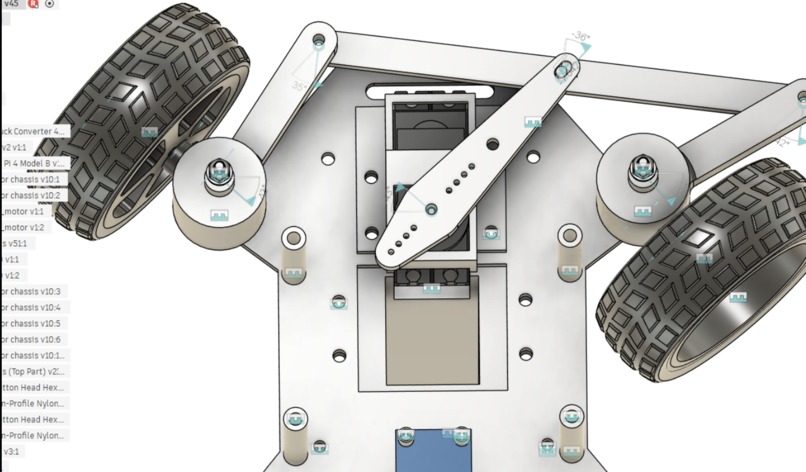
Ackermann design in cad
Inspiration
Competing in the Annual Droid Racing Challenge hosted by QUT in Brisbane
What it does
Autonomous Lane Detection that travels around a track bounded by coloured lines, using various algorithms to stay within the track
How we built it
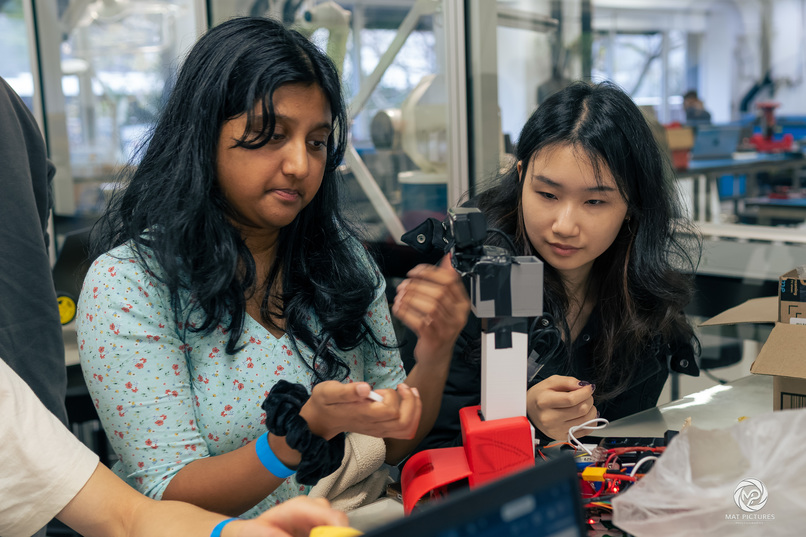
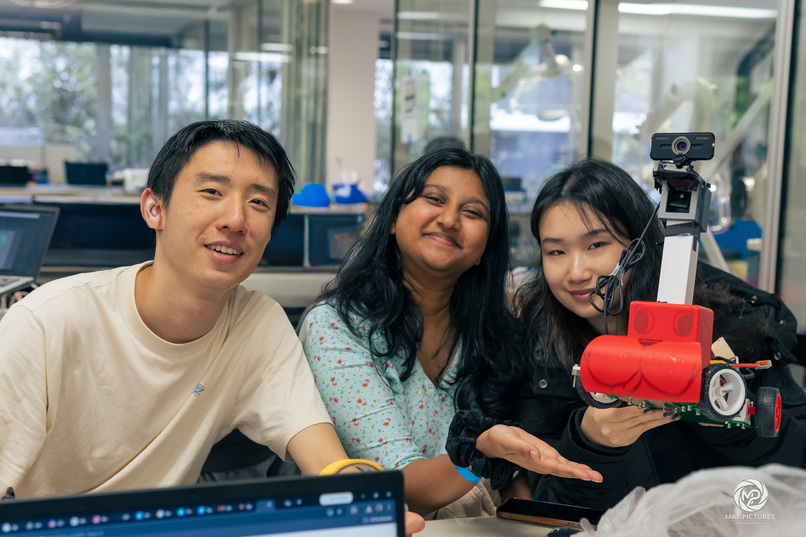
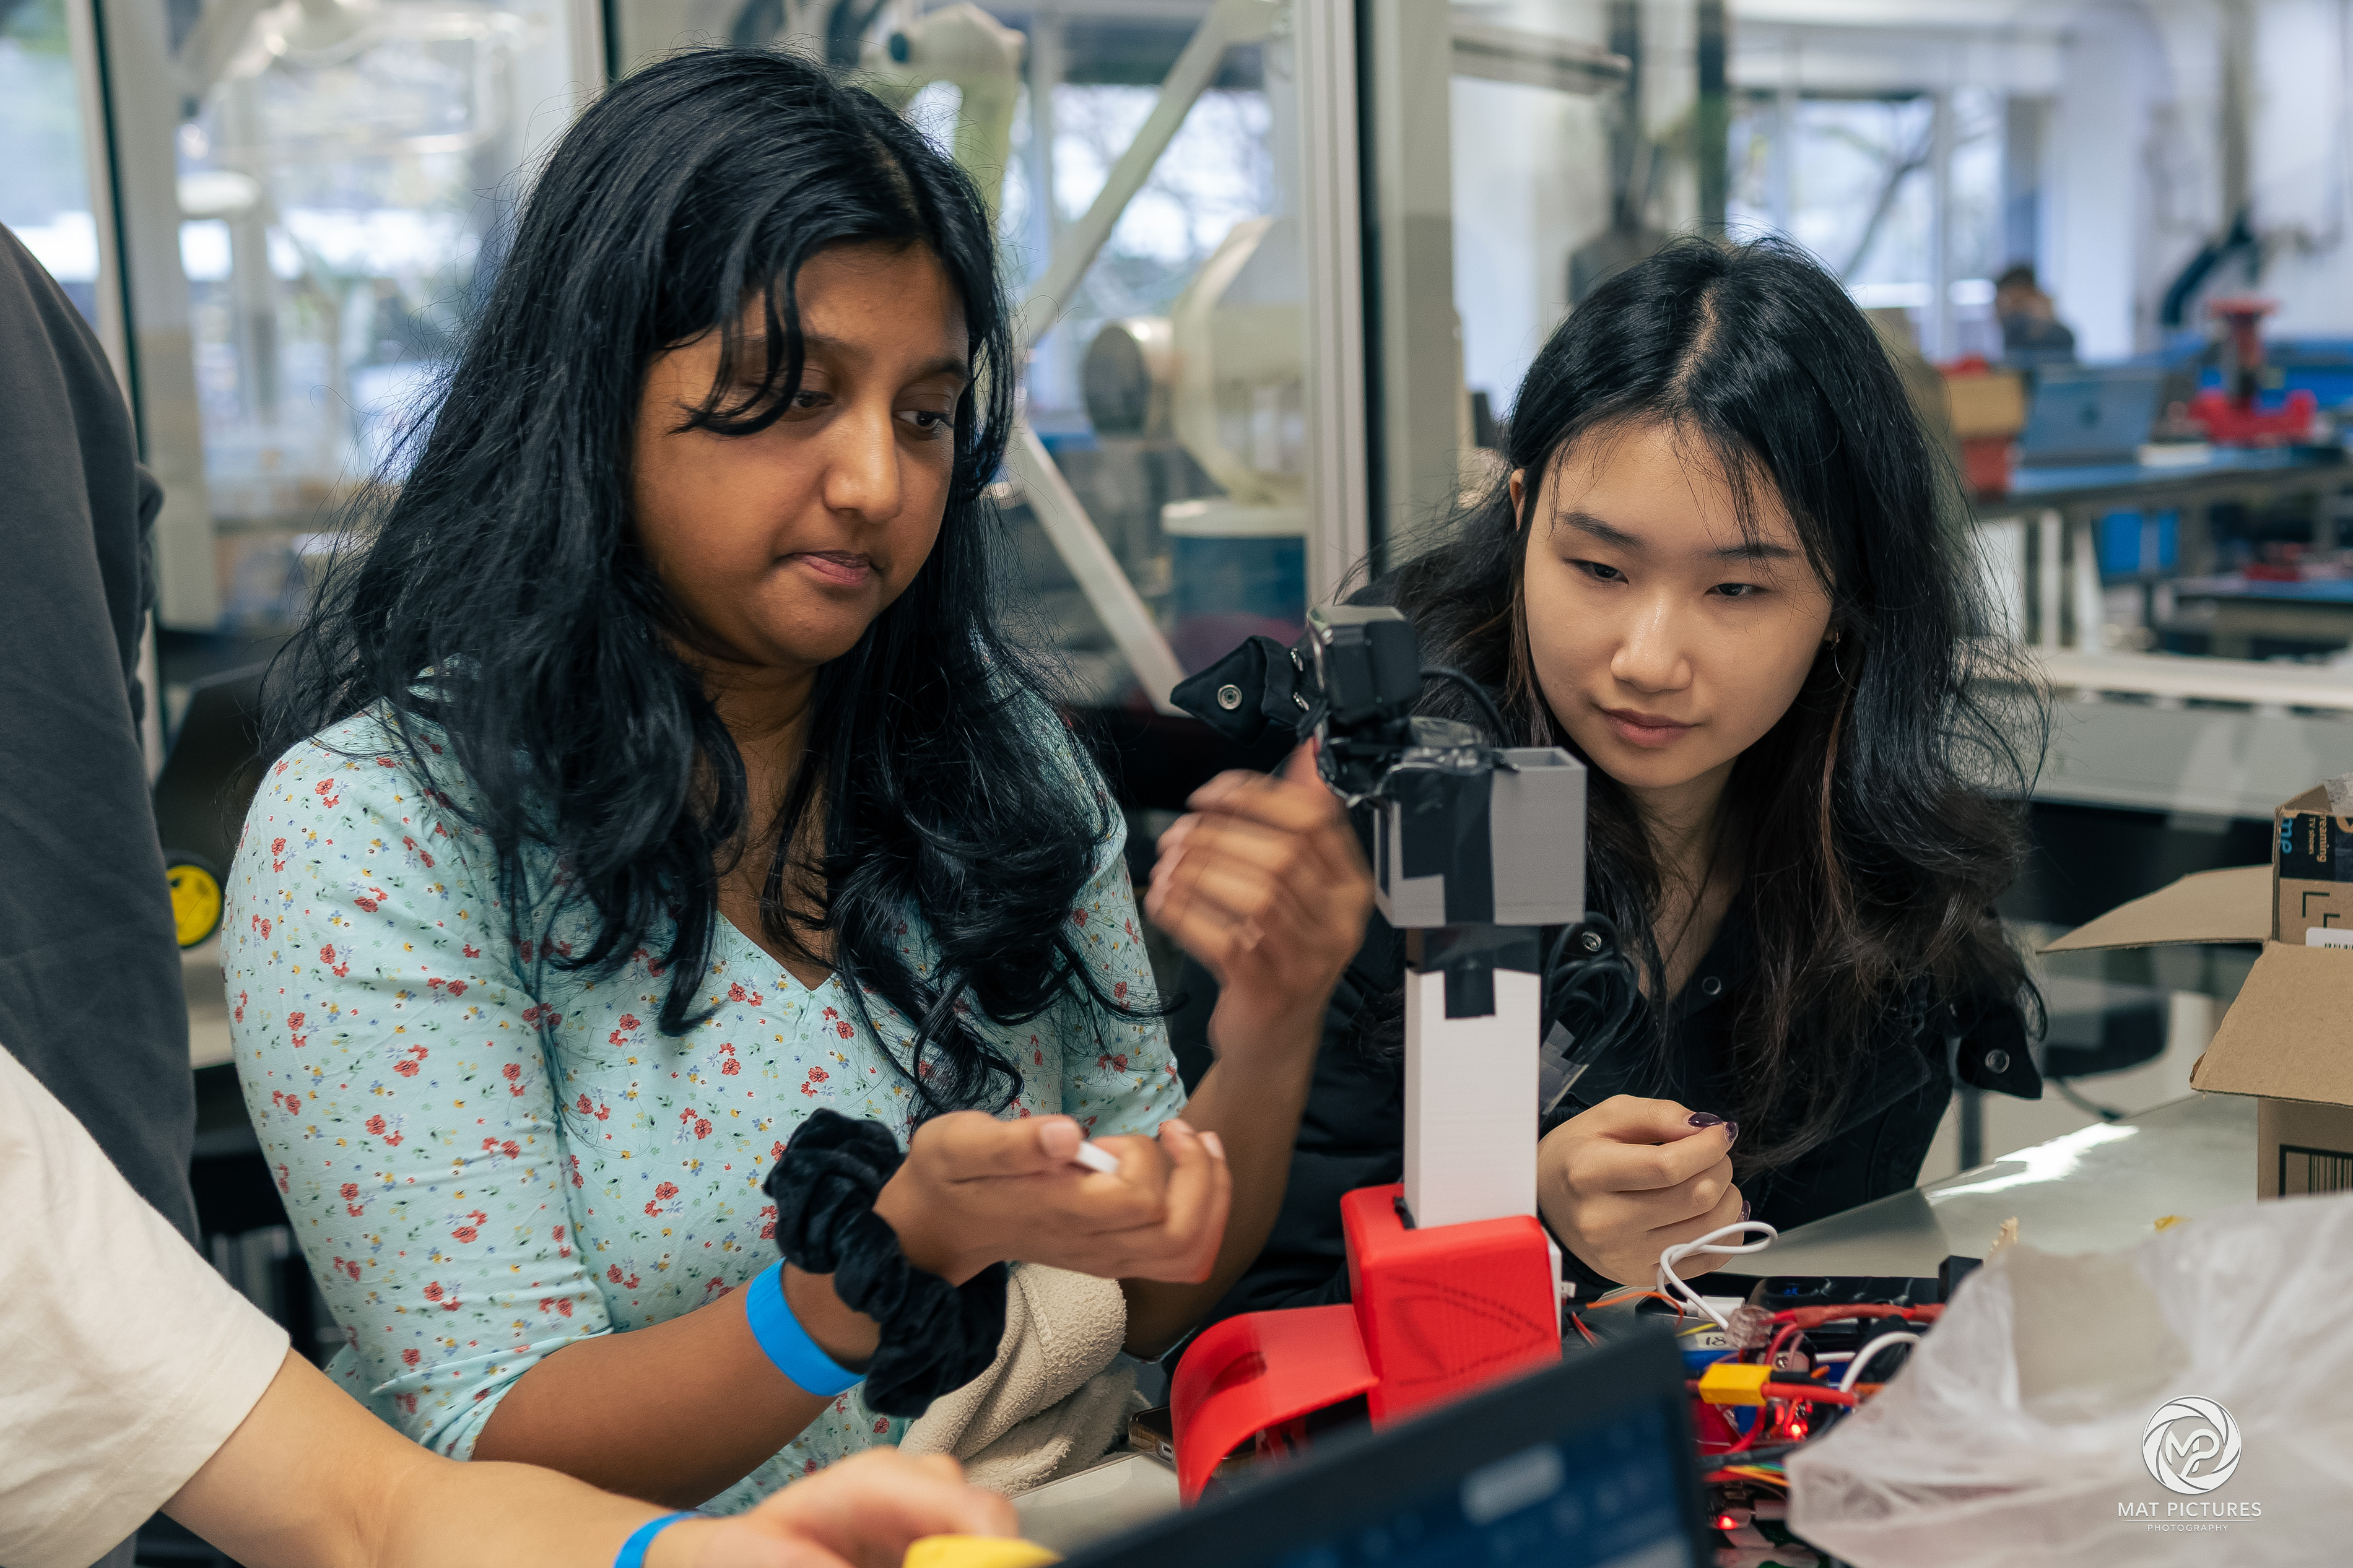
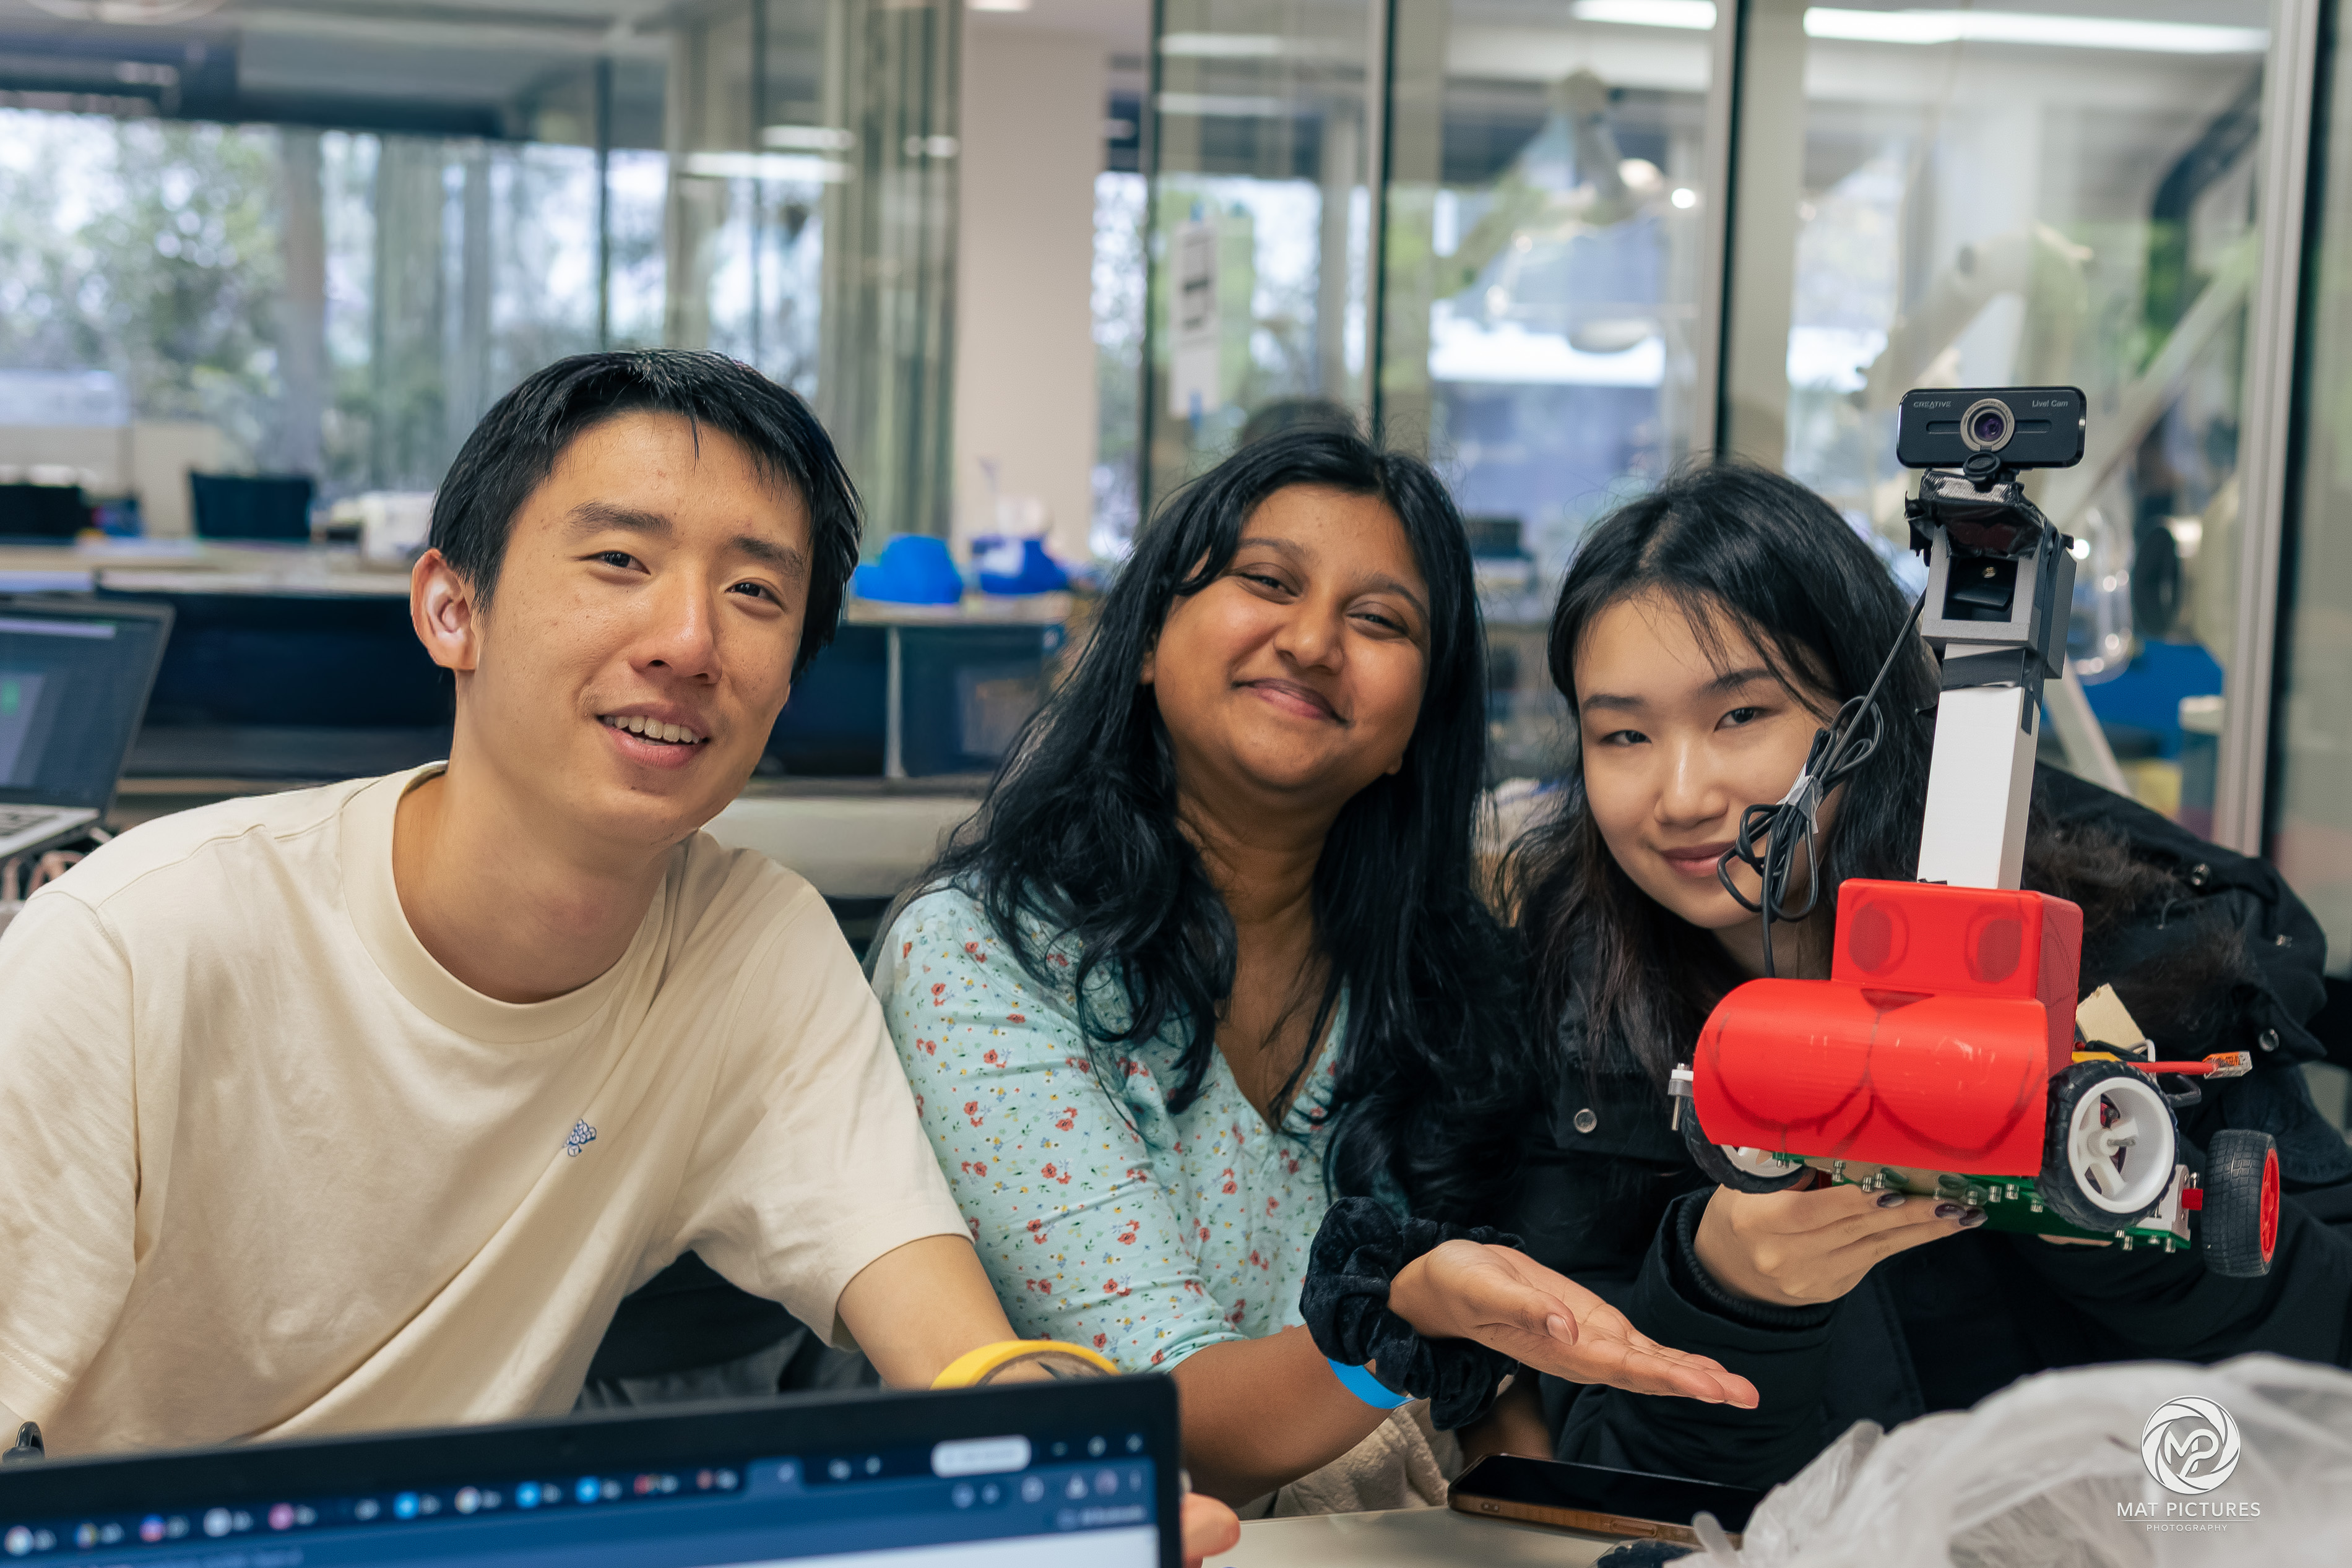
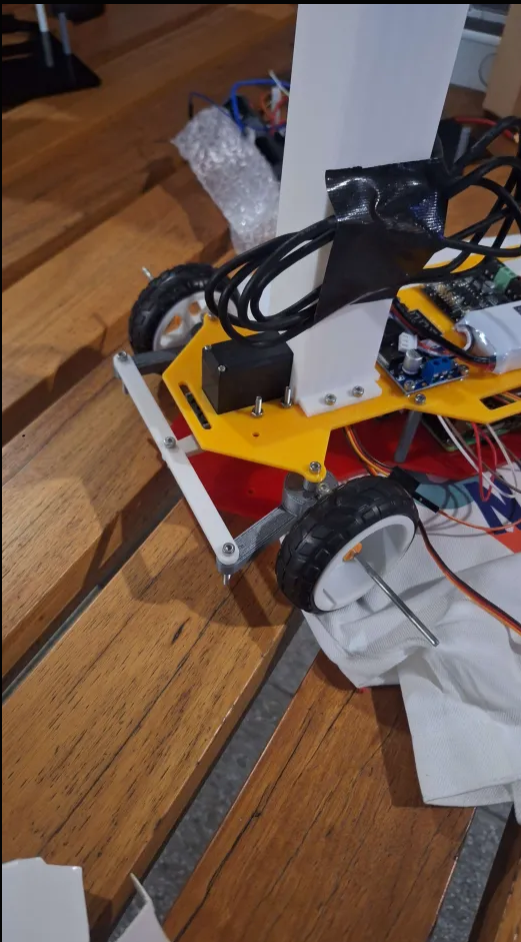
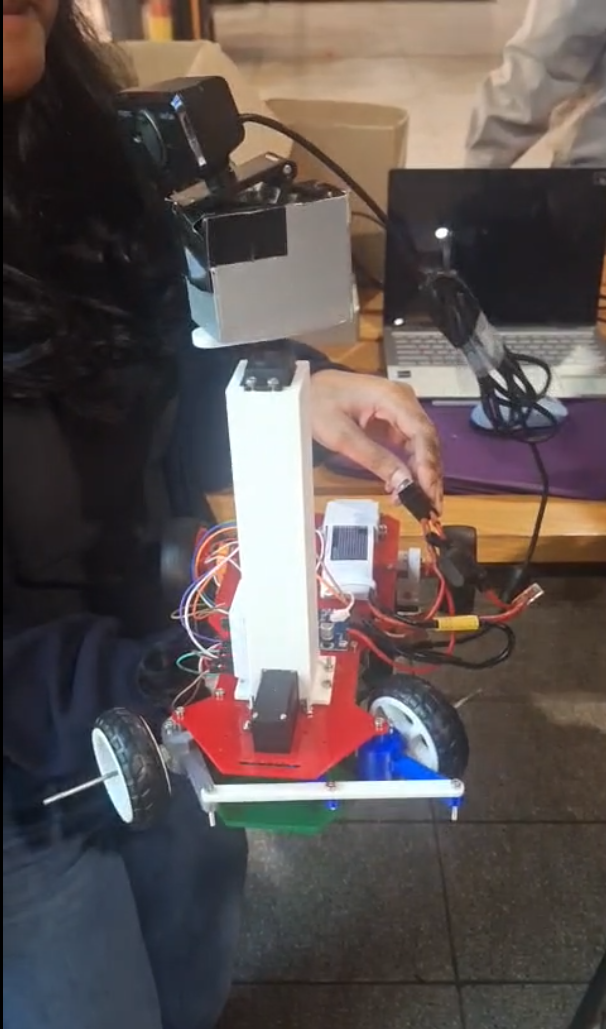
Built it using Ackermann Steering and a protective front shell, as well as a hybrid PID and Bang-Bang algorithm for the software
Challenges we ran into
Some of the wiring was quite a bit of a challenge, since a lot of the time the connections just weren't working for some reason and our motors and/or servos wouldn't run. We had a problem with the battery as well, so we had to switch to using both a battery and a portable charger separately for the Raspberry Pi, so that it wouldn't keep disconnecting.
Accomplishments that we're proud of
Being the first time to complete a full lap of the track in a comfortable time, even though we couldn't improve on this too much afterwards. Proud of the team for giving their all until the end when we had more code working, but unfortunately one of our soldered wires snapped off right before our final race and we couldn't get it back on in time.
What we learned
Everyone in the team gained knowledge in various aspects, whether it be working in a team or on their respective technical roles, such as learning more about computer vision and motor control for the software
