Inspiration
Our inspiration for this project is that we are bad at first person shooter video games. The biggest struggle for us is aiming. Most modern games have powerful anti-cheats which prevent people from using software to improve their aim; but does their anti-cheat prevent people from using hardware...?
What it does
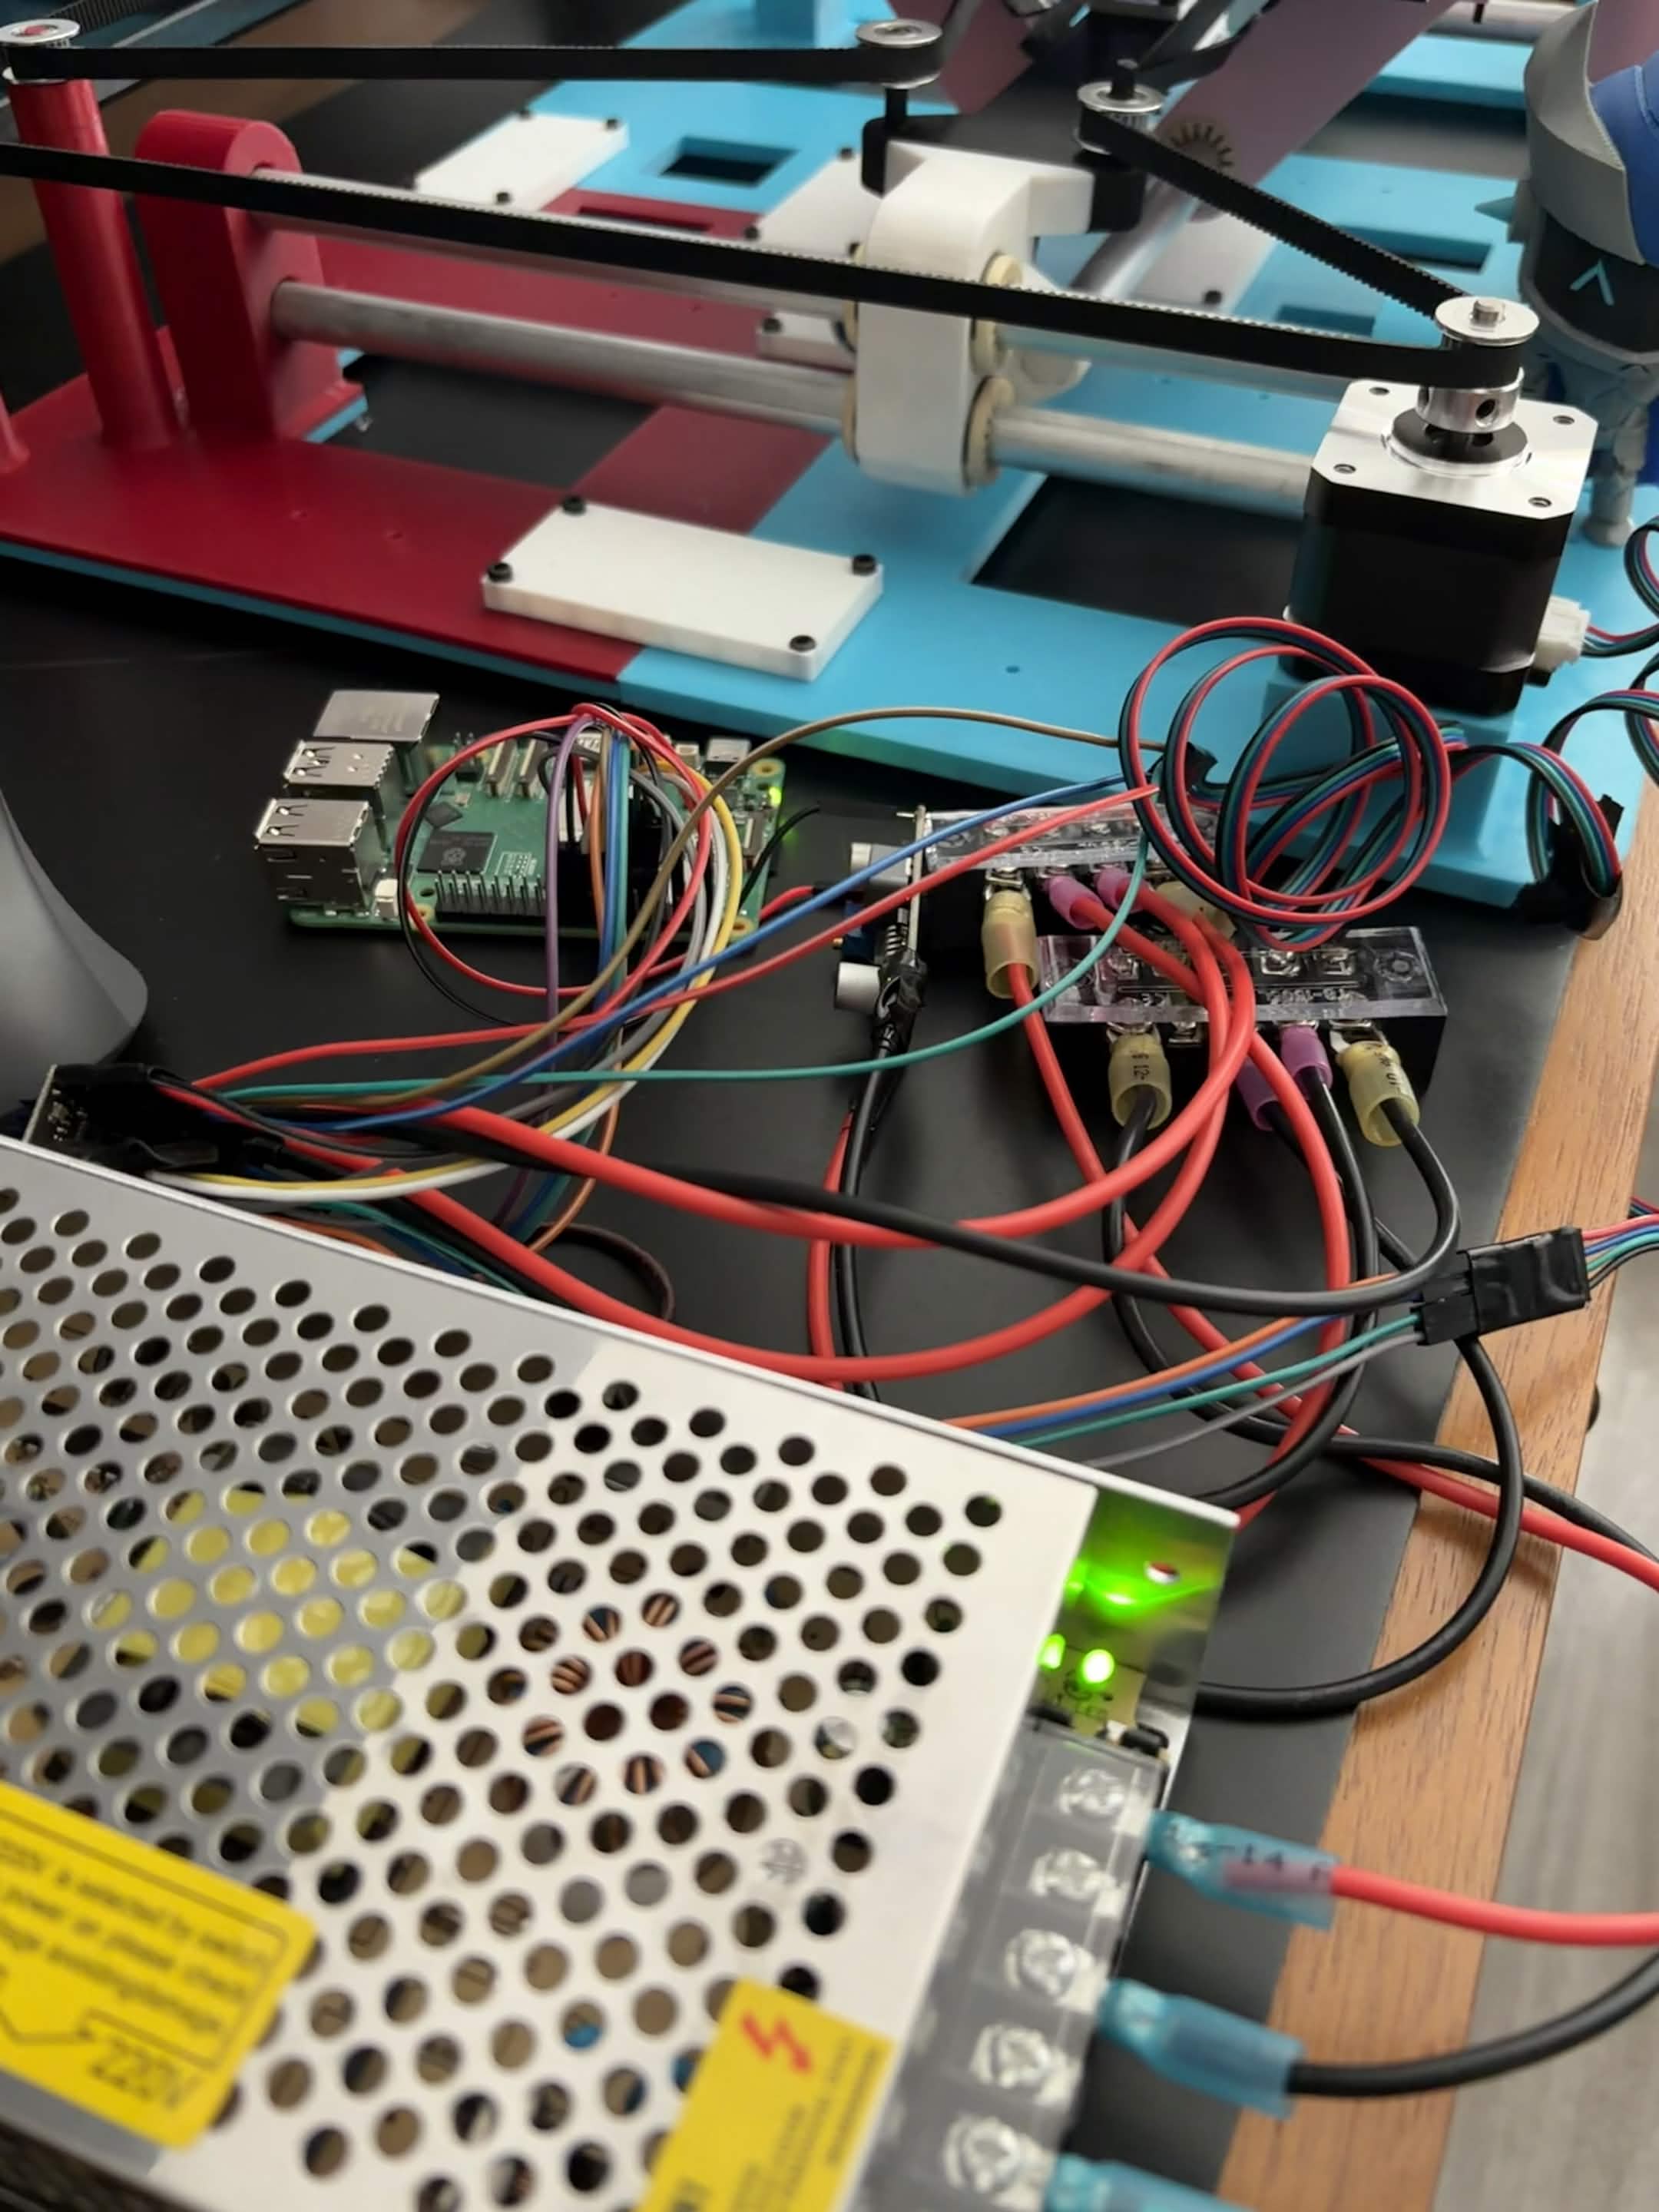
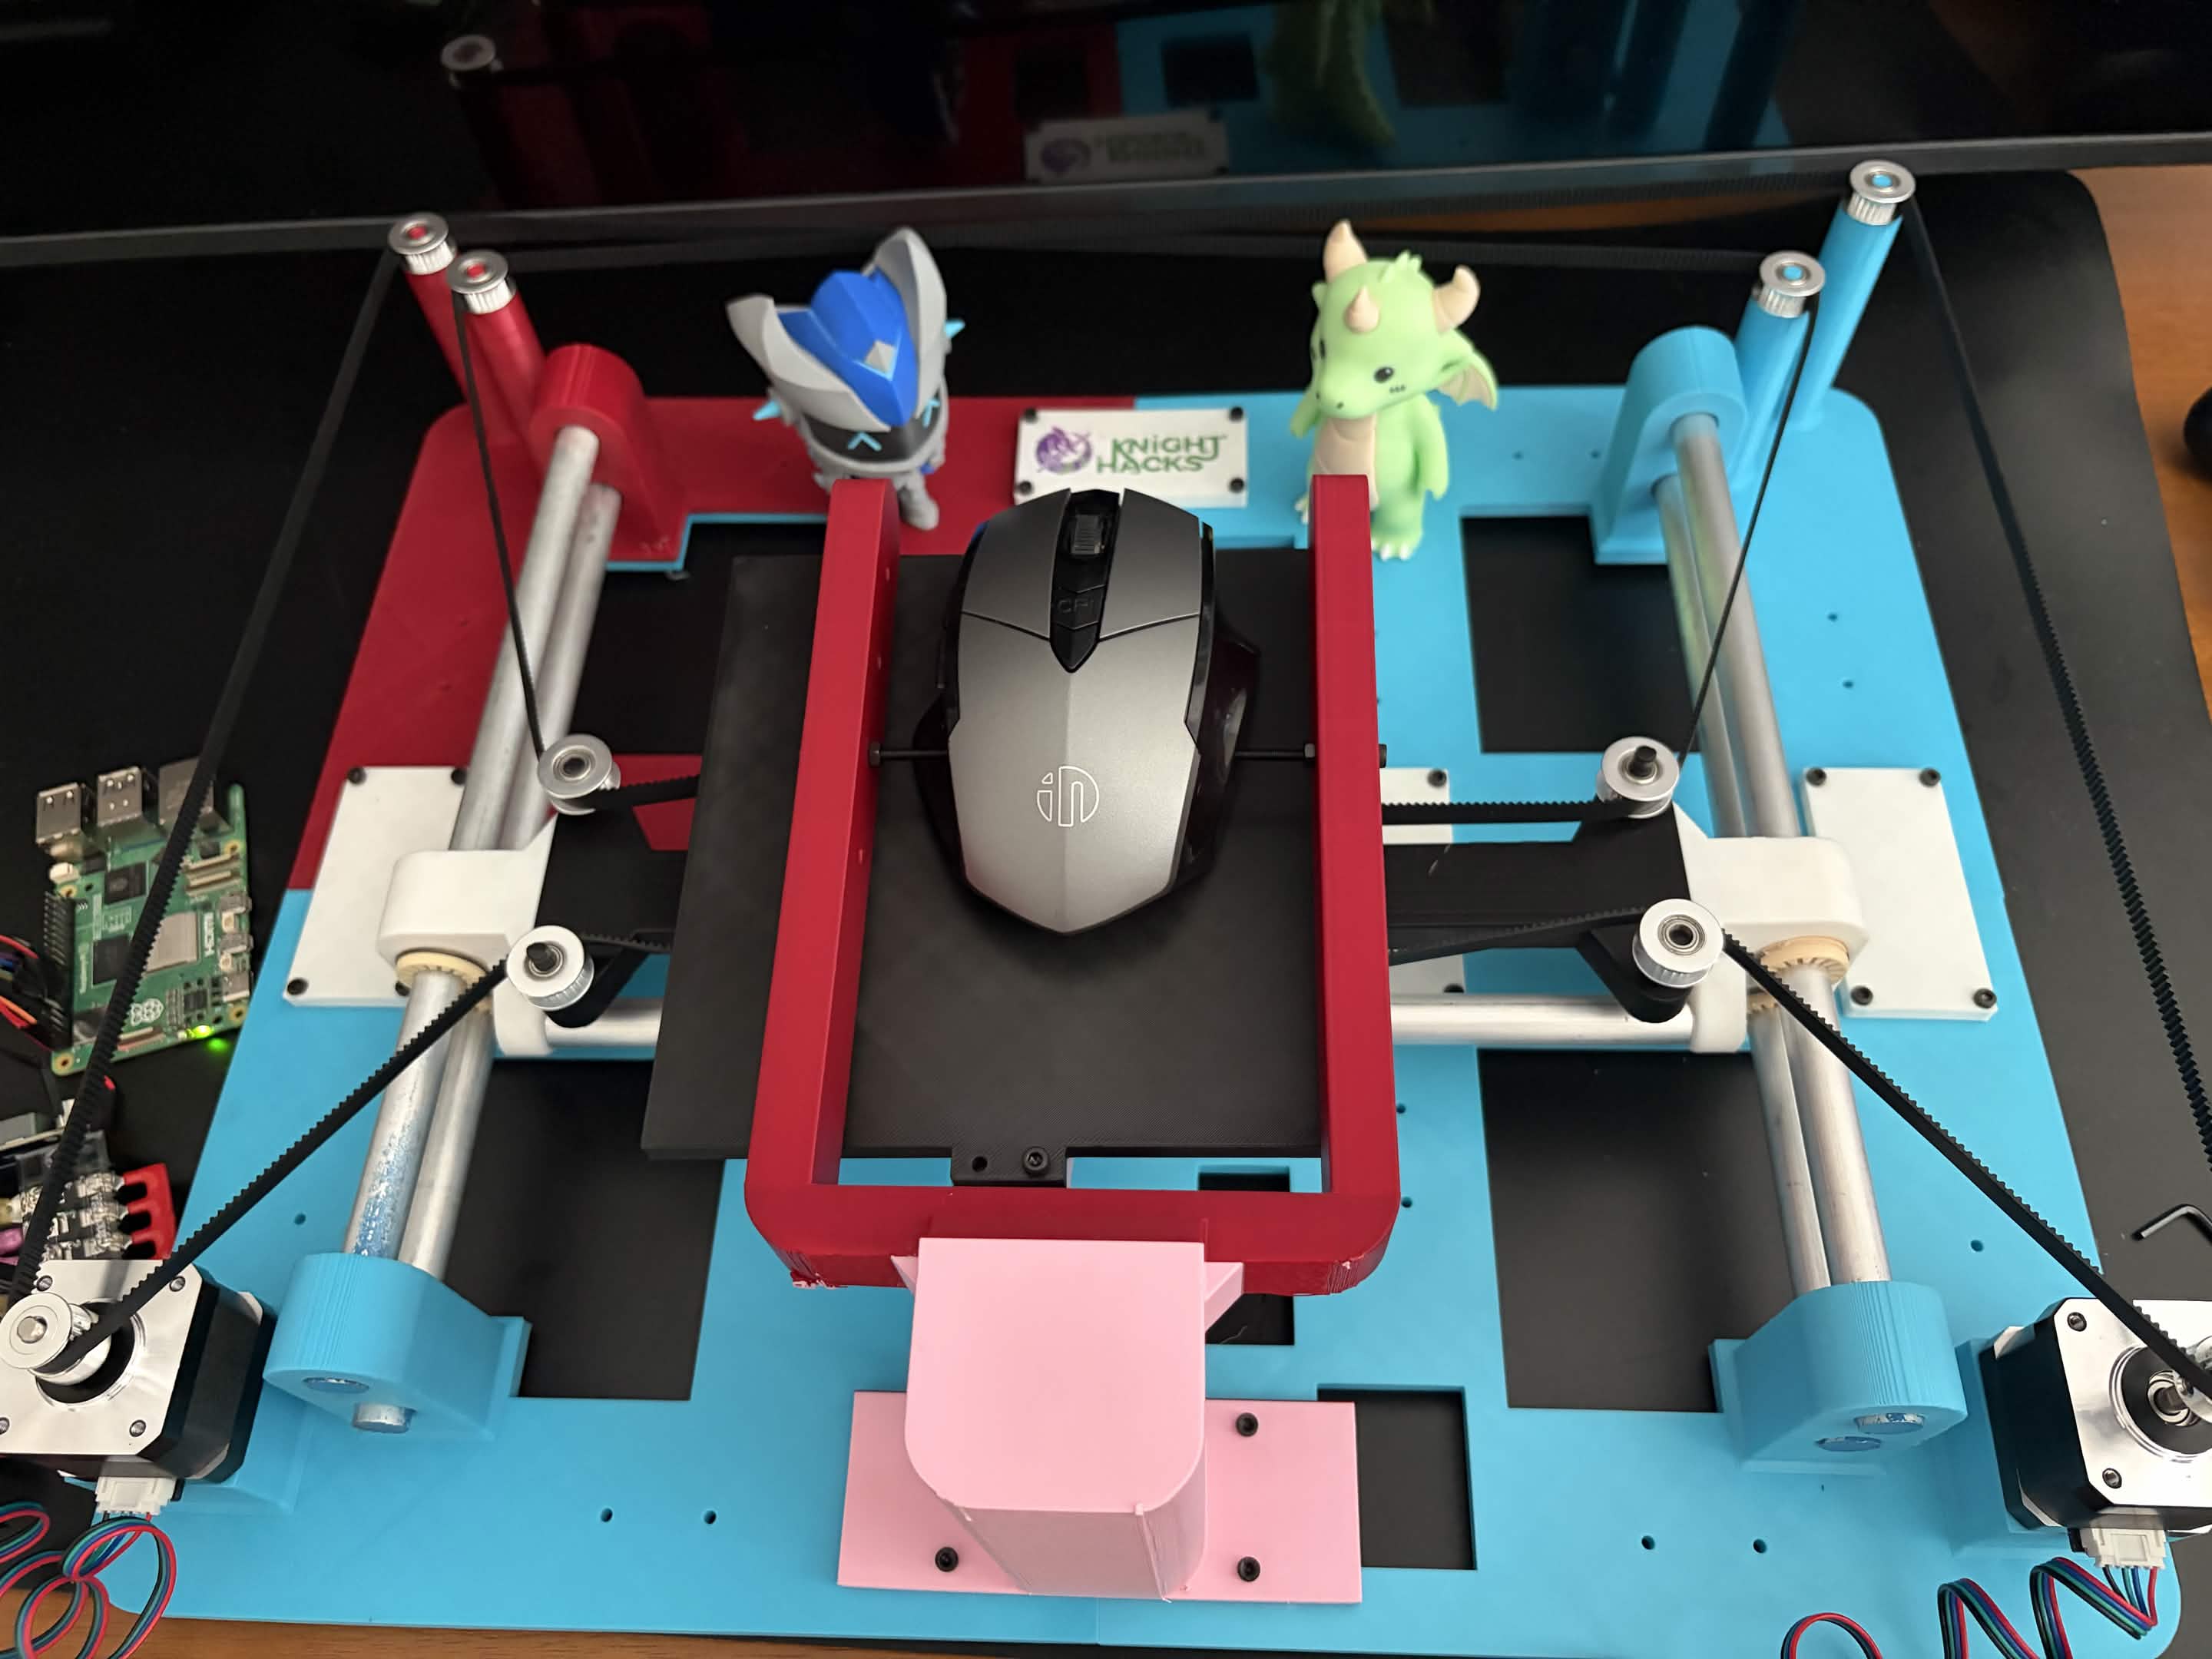
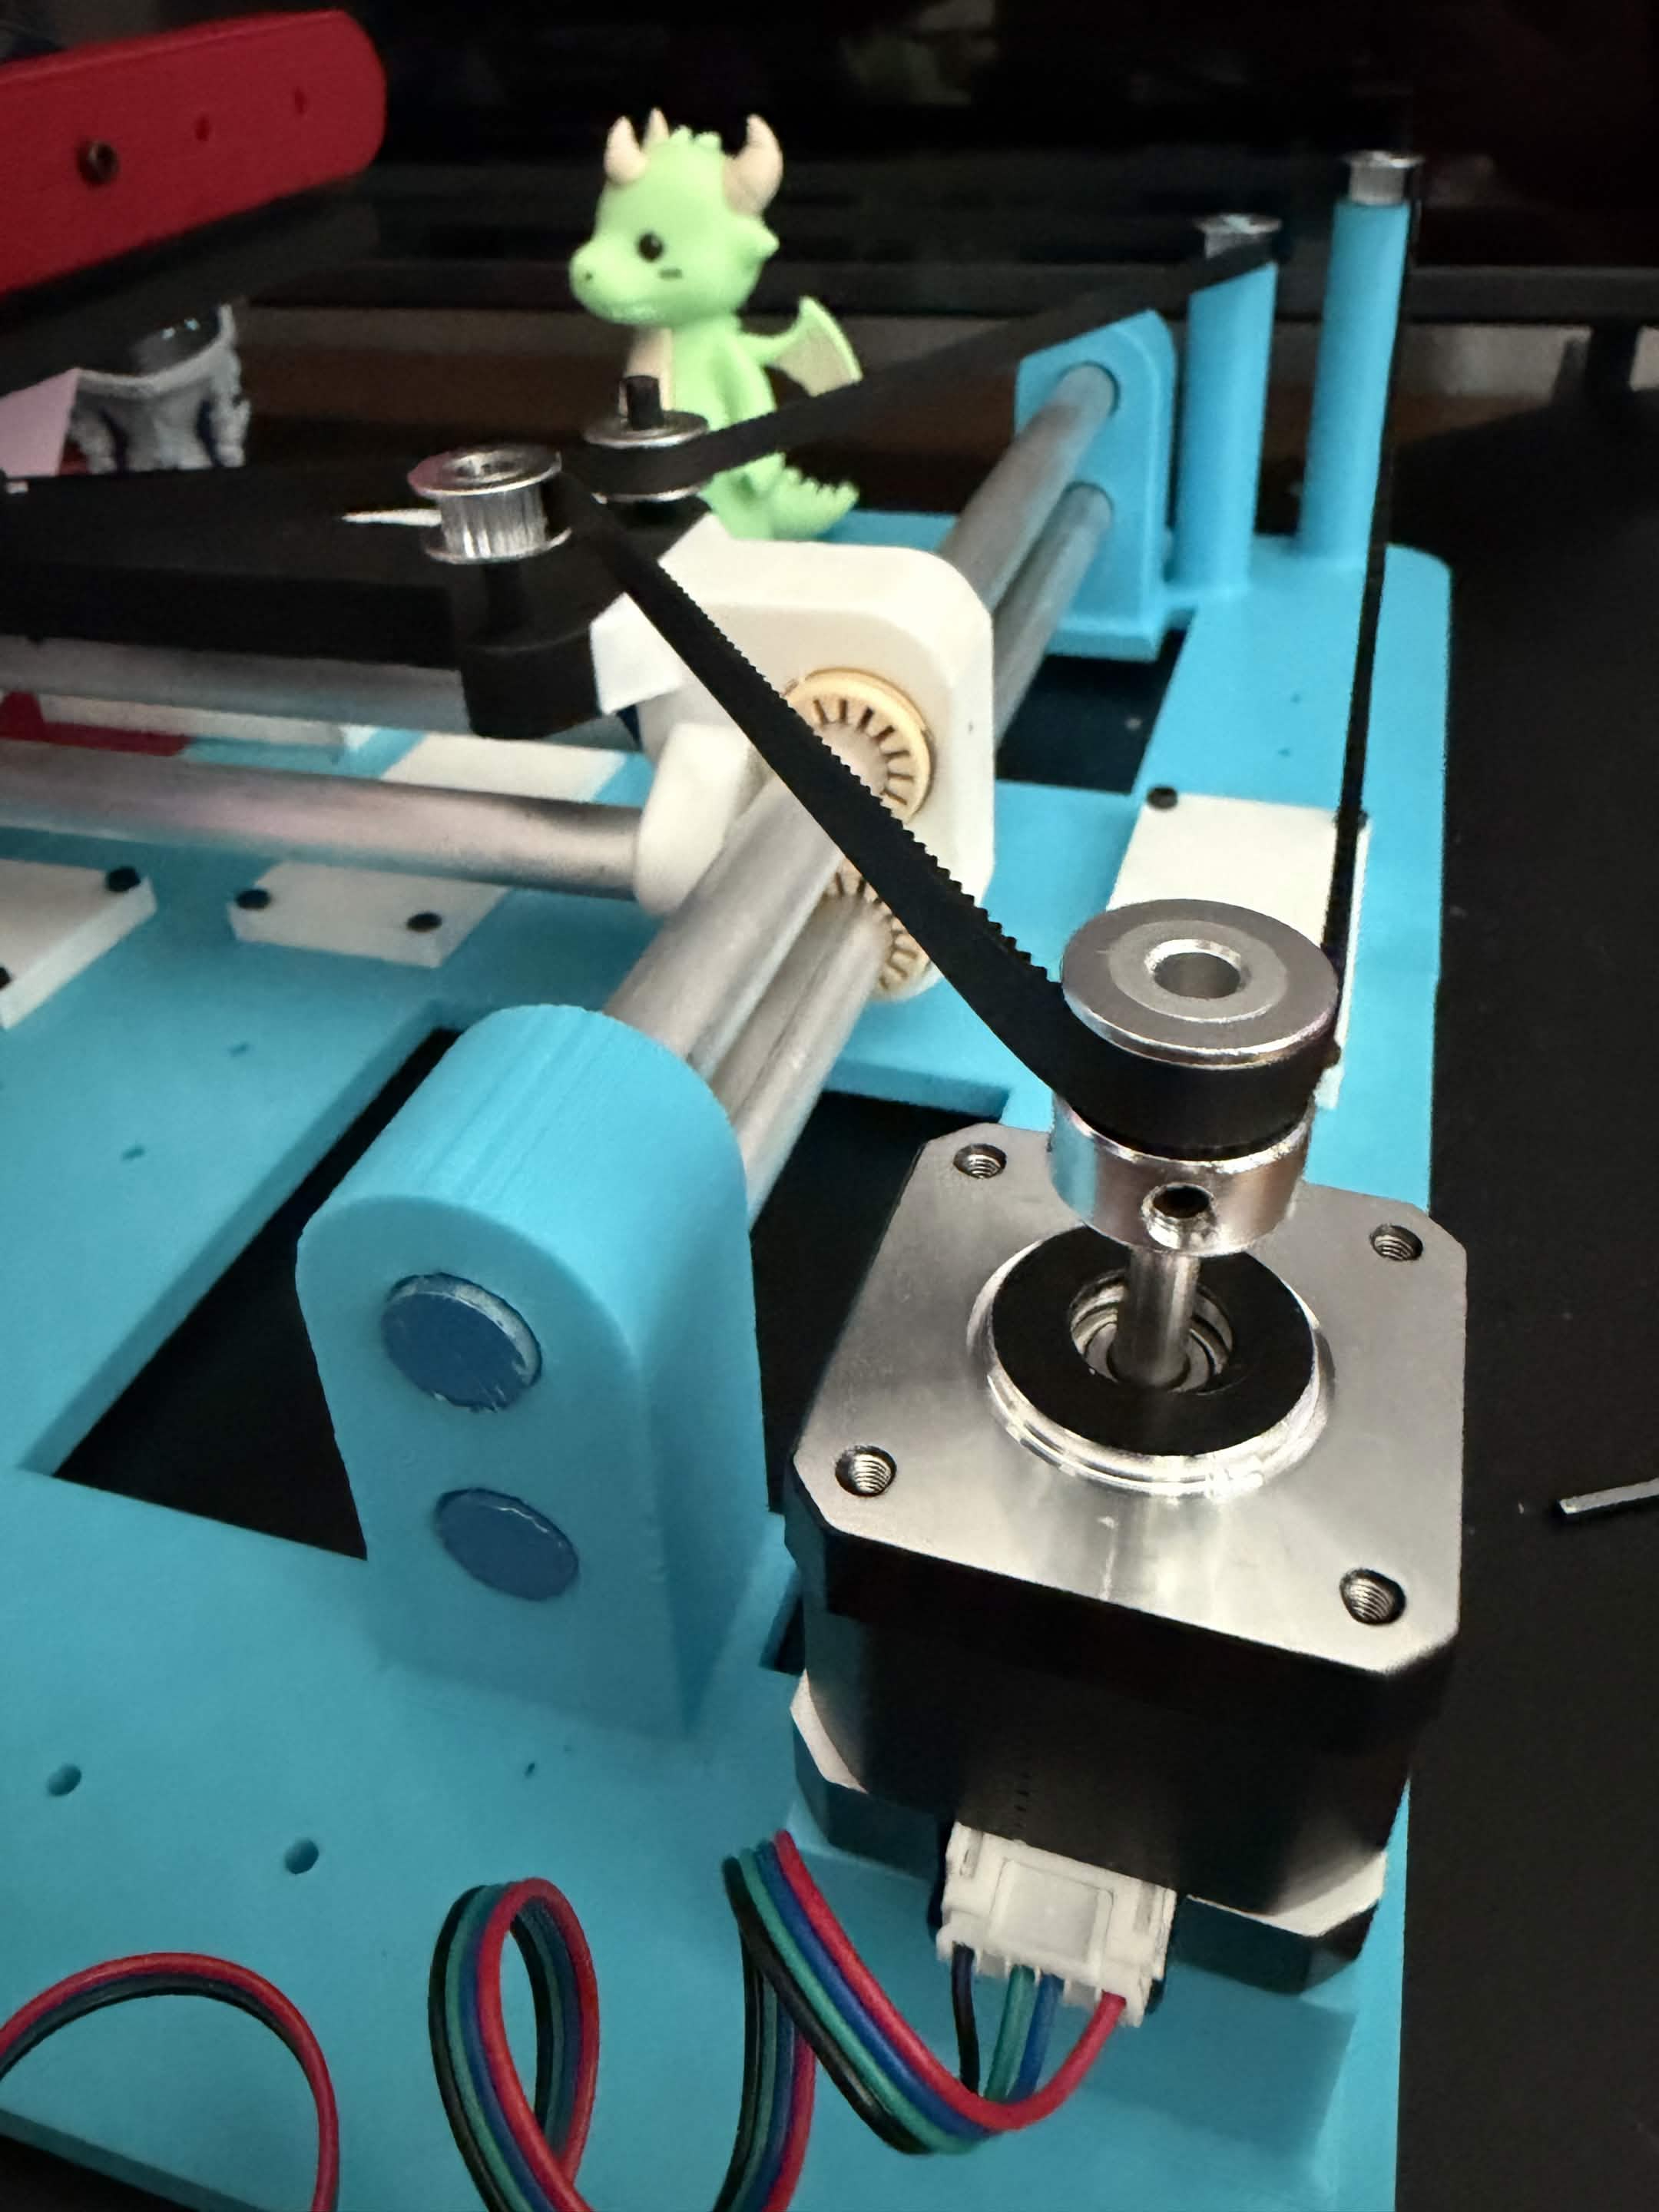
Our project captures live footage of the popular video game Valorant and moves the mouse using a custom build CoreXY robot
How we built it
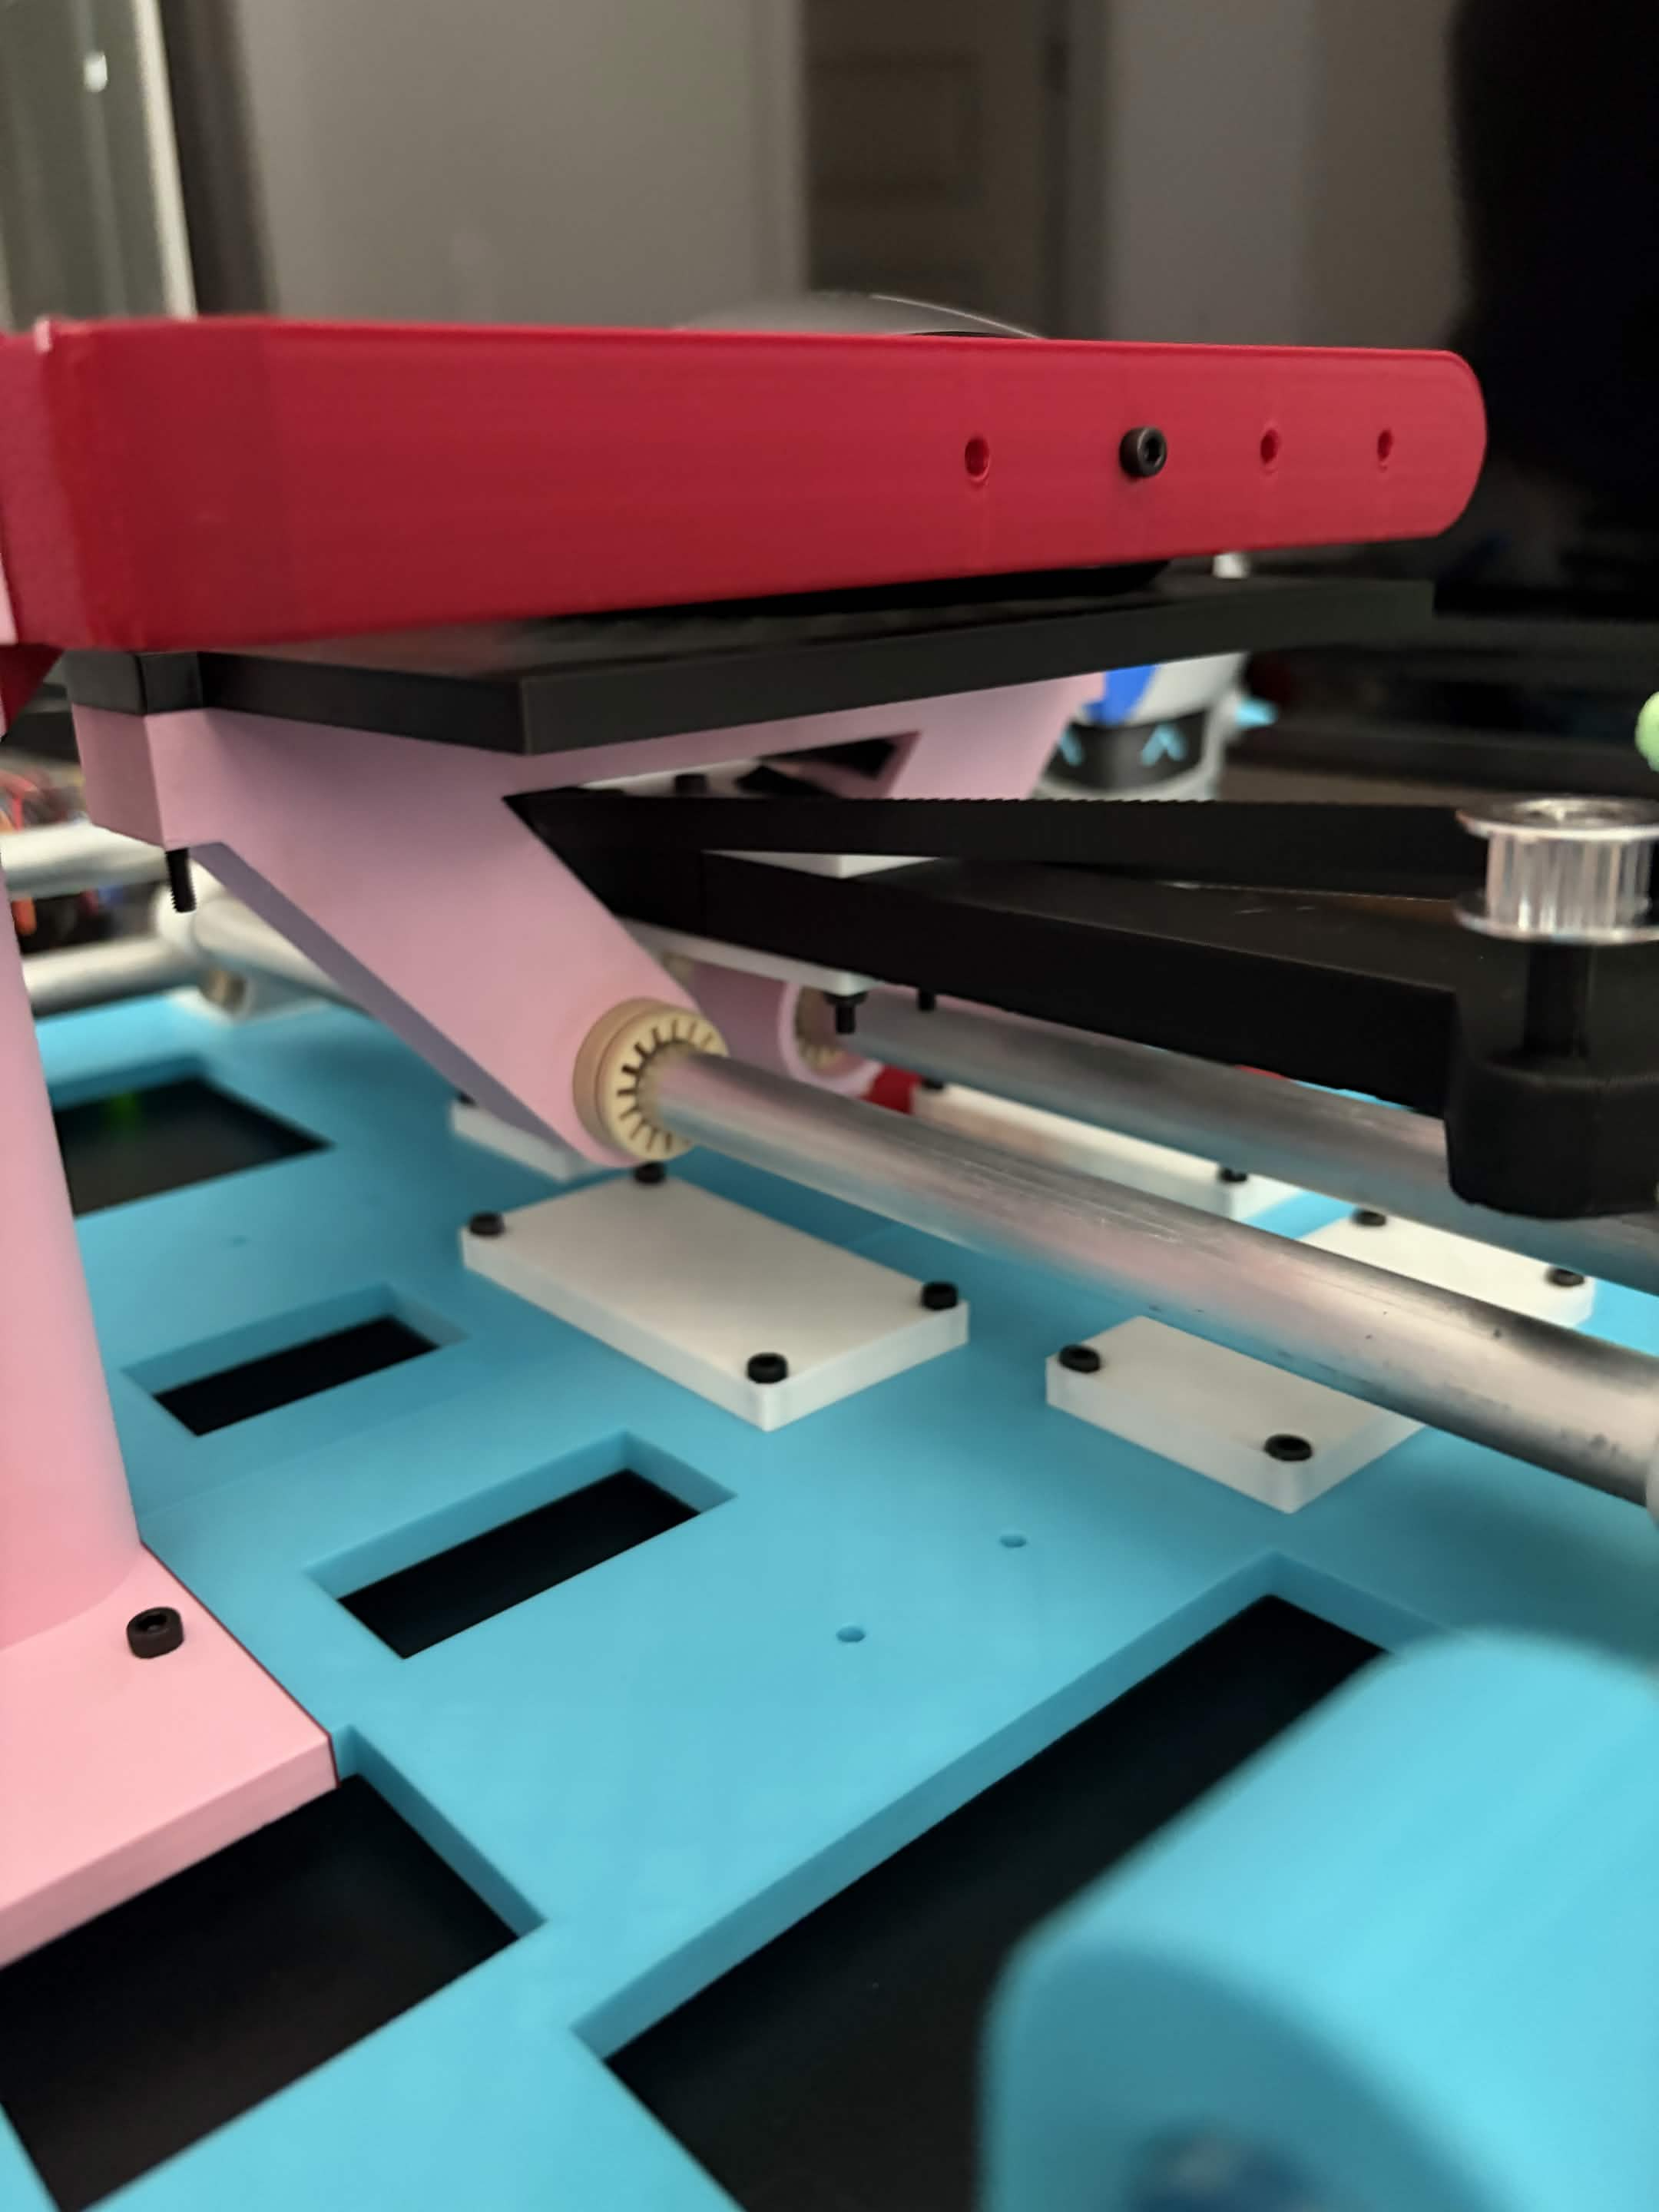
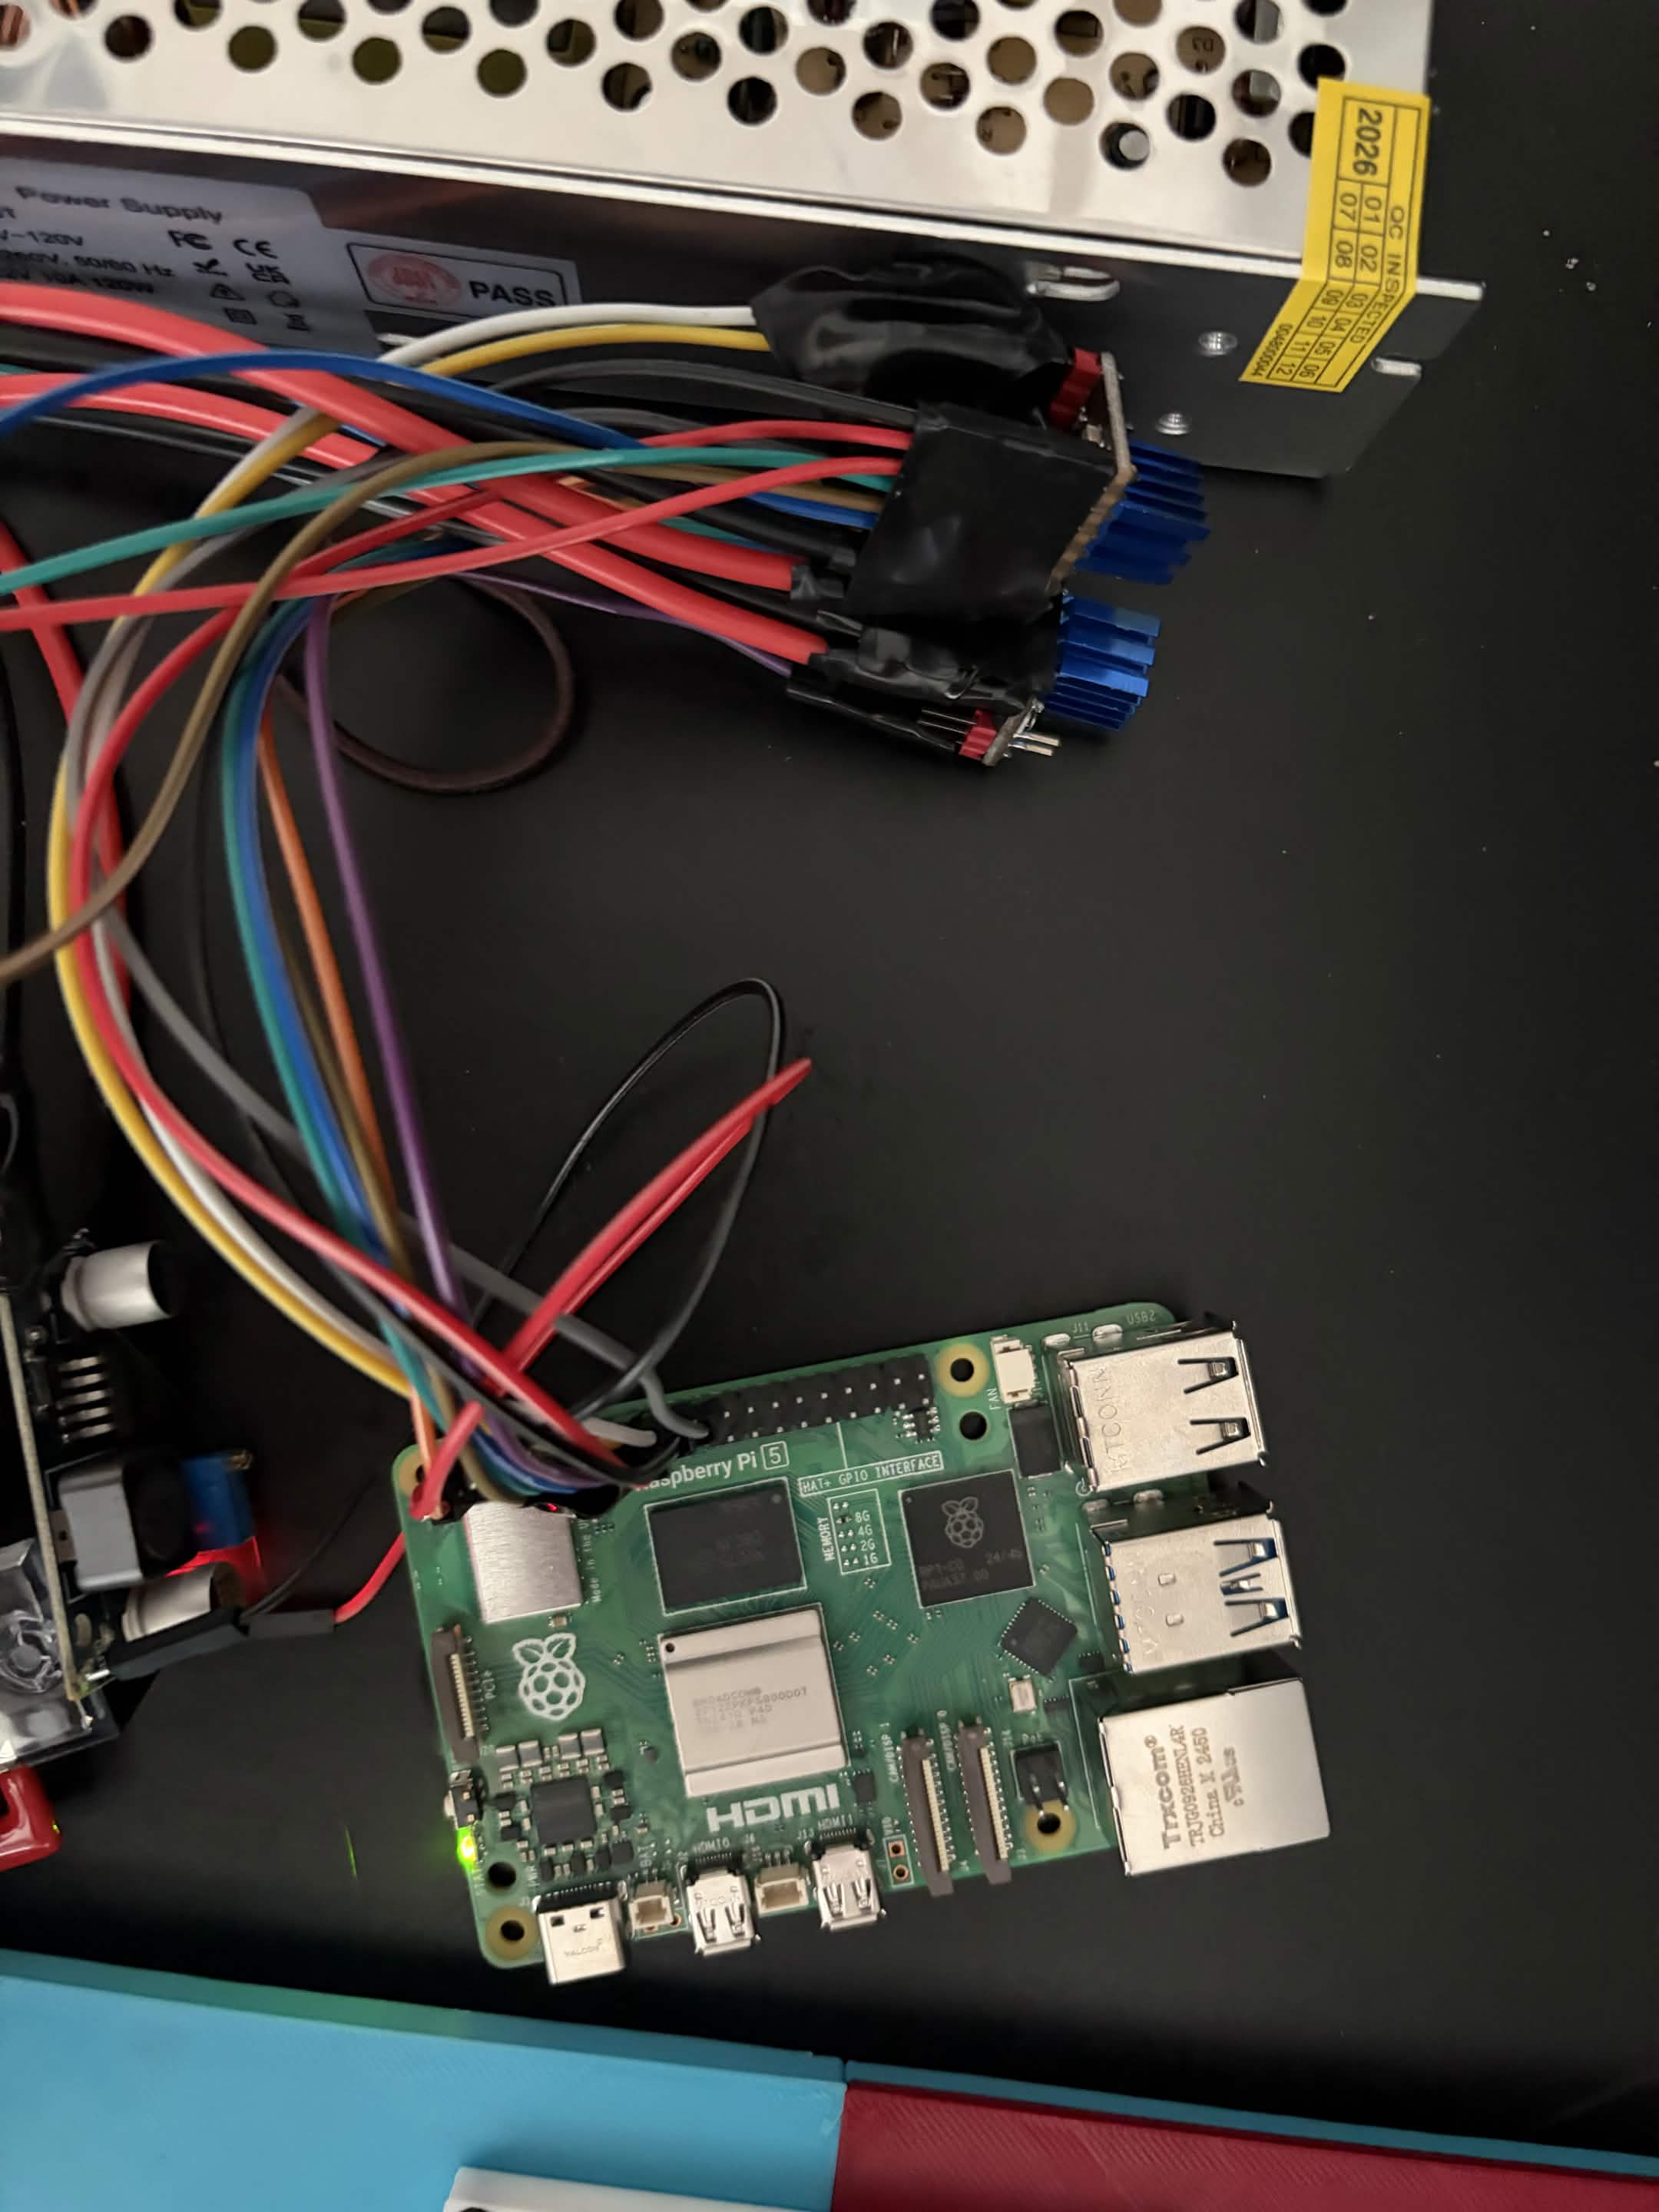
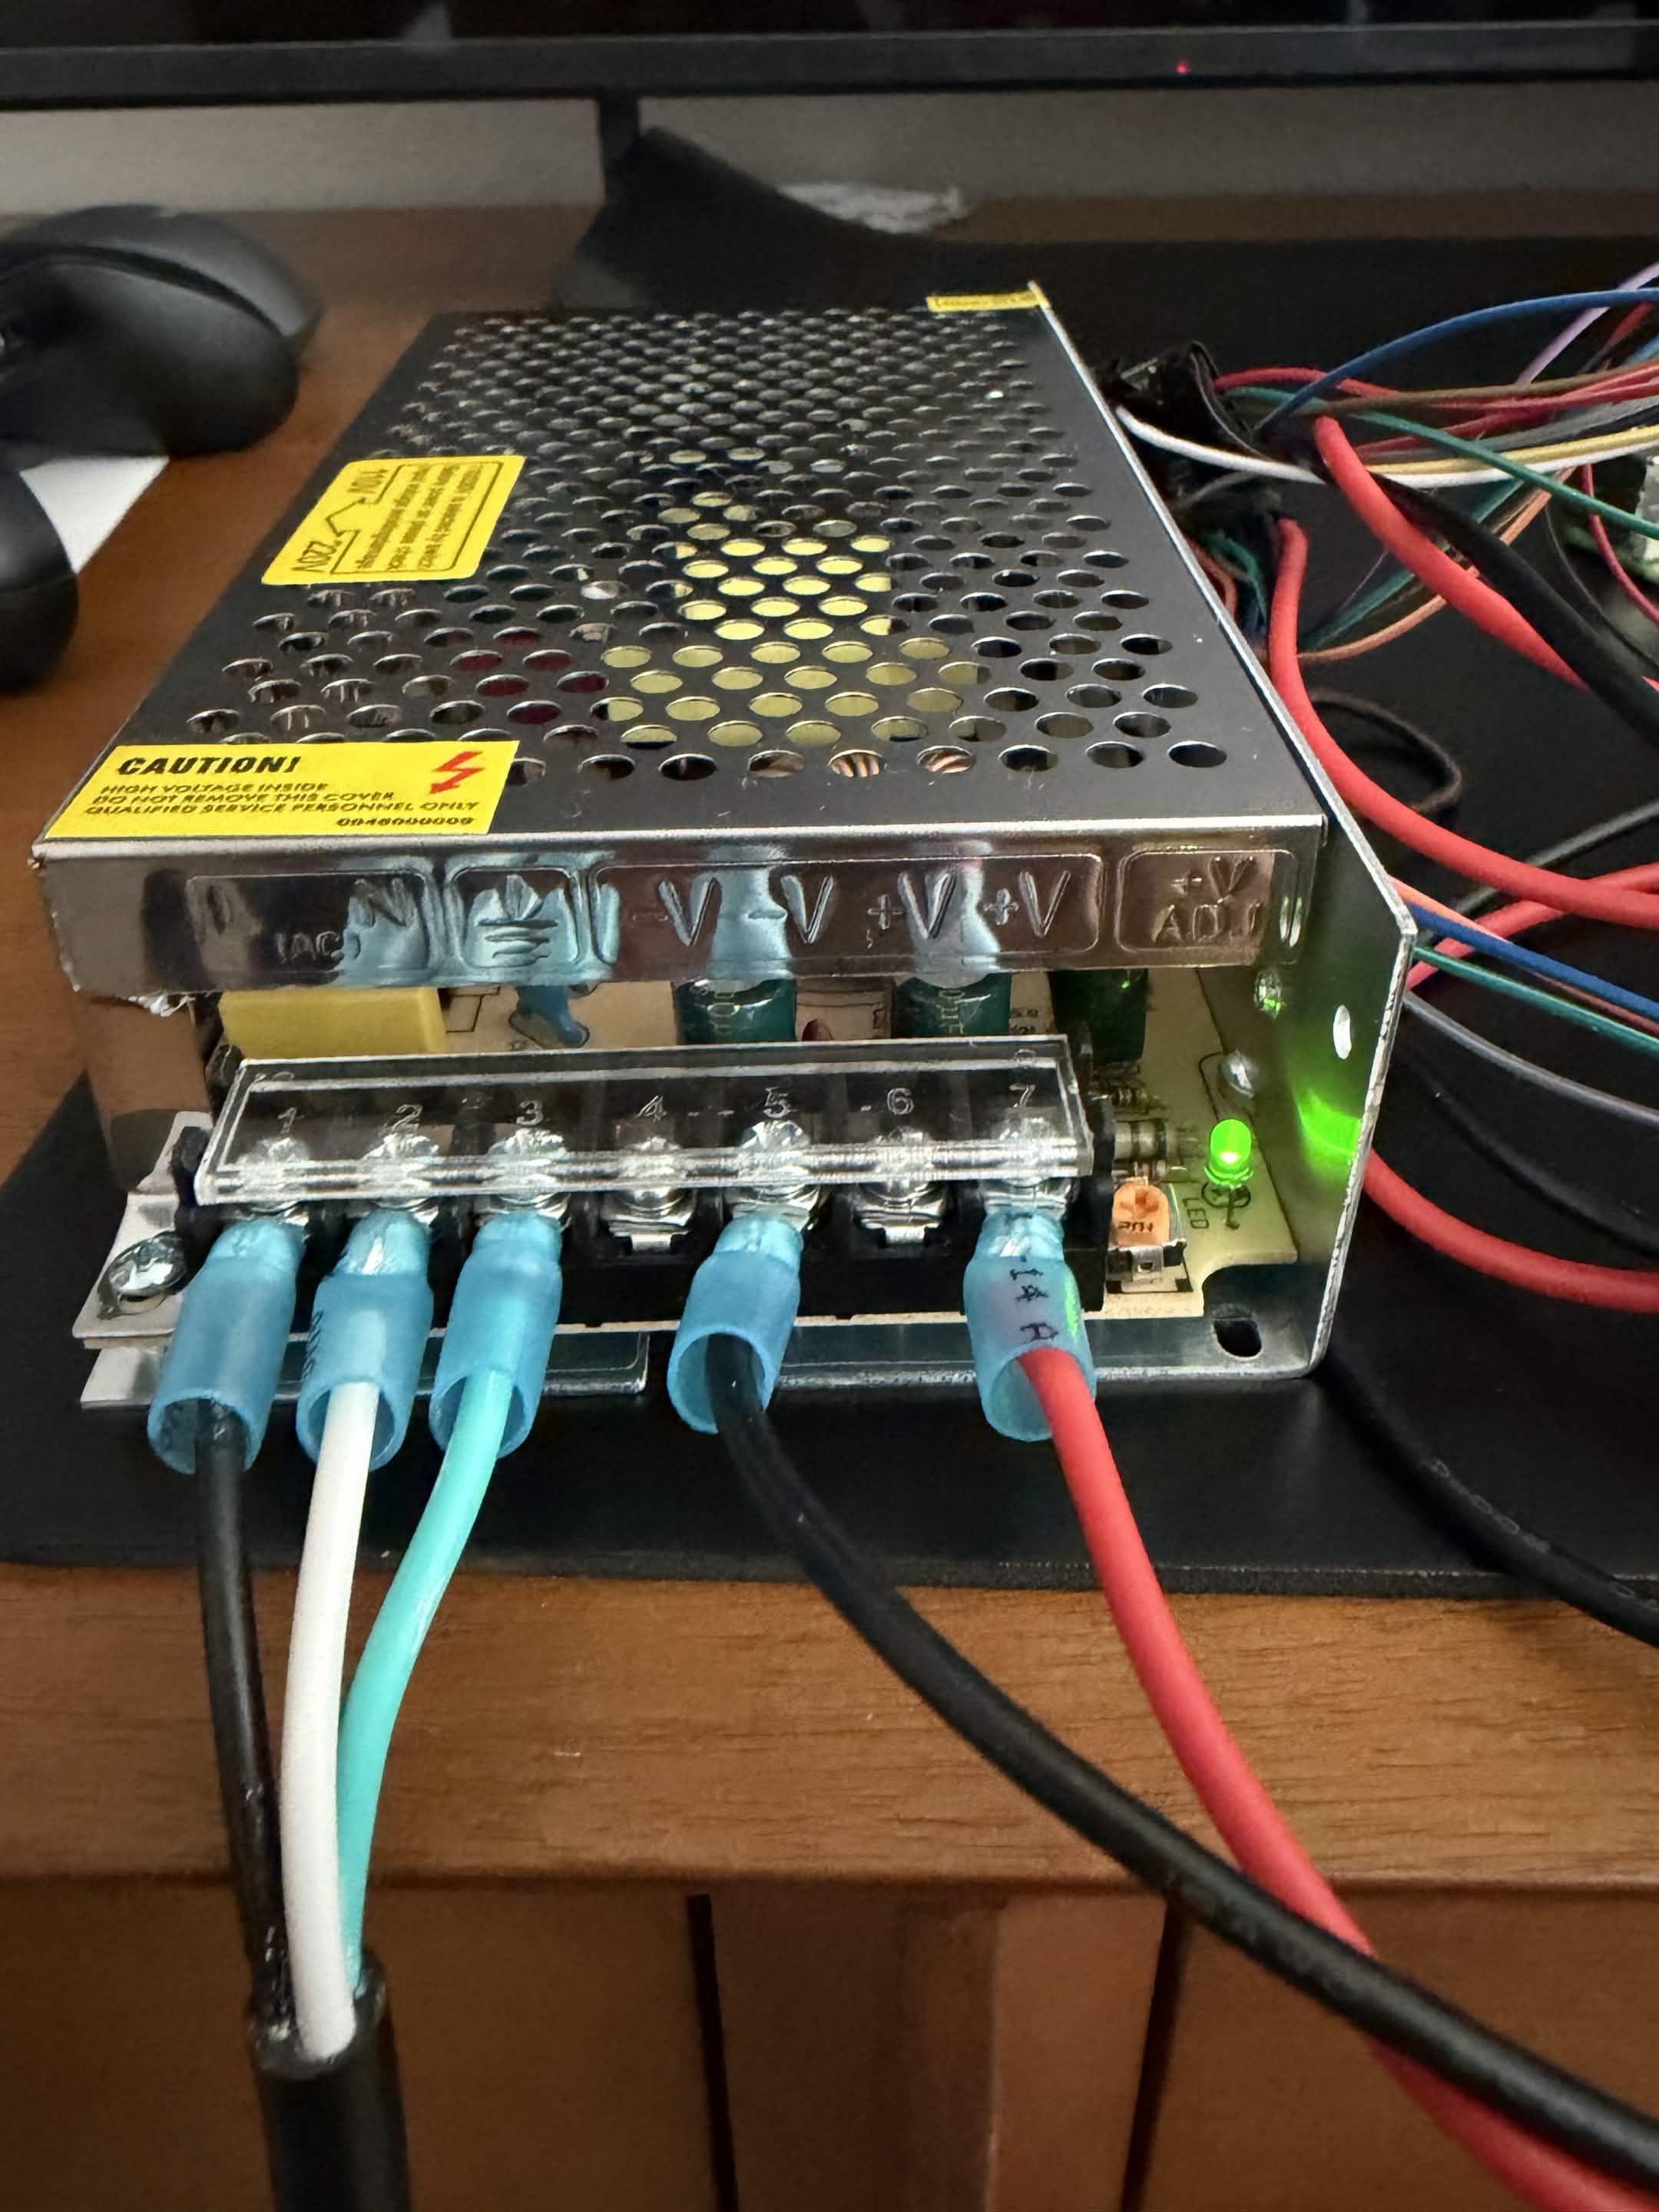
We 3D printed most of the parts on the robot as well as using off the shelf components. For the software, we record the footage using python and send the data over to a Raspberry Pi over web sockets.
Challenges we ran into
The biggest challenge we ran into was time. Design, printing, assembly, and programming all occurred over the period of the hackathon. Doing this with a 3 person team was very challenging. We also struggled a lot with assembly. Due to the amount of parts, we were unable to re-print most of the assembly. Therefore, we had to improvise on how some parts worked.
Accomplishments that we're proud of
- This robot is capable of aiming at a player
- Once the CAD was complete, no major revision was done to the design.
What we learned
We learned a lot about computer vision, web sockets, and writing firmware for stepper motor drivers.
What's next for Aim Not
In the future, we hope to improve the mobility of the device. Currently, there is some slight binding which makes the motion slightly jitterly. The aim could also be improved.
Built With
- 3d-printing
- codex
- python
- raspberry-pi

Log in or sign up for Devpost to join the conversation.