-
-
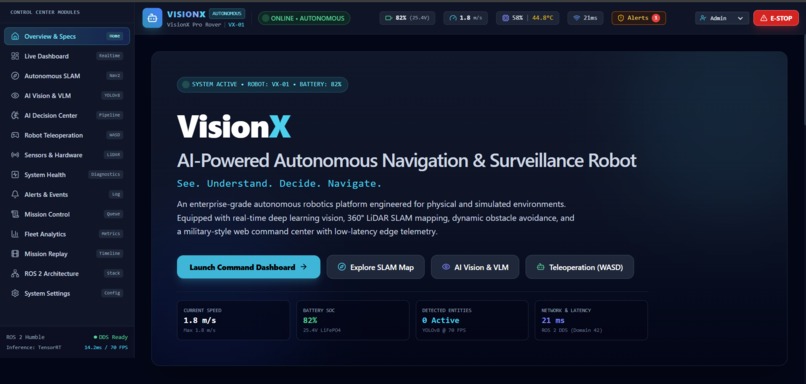
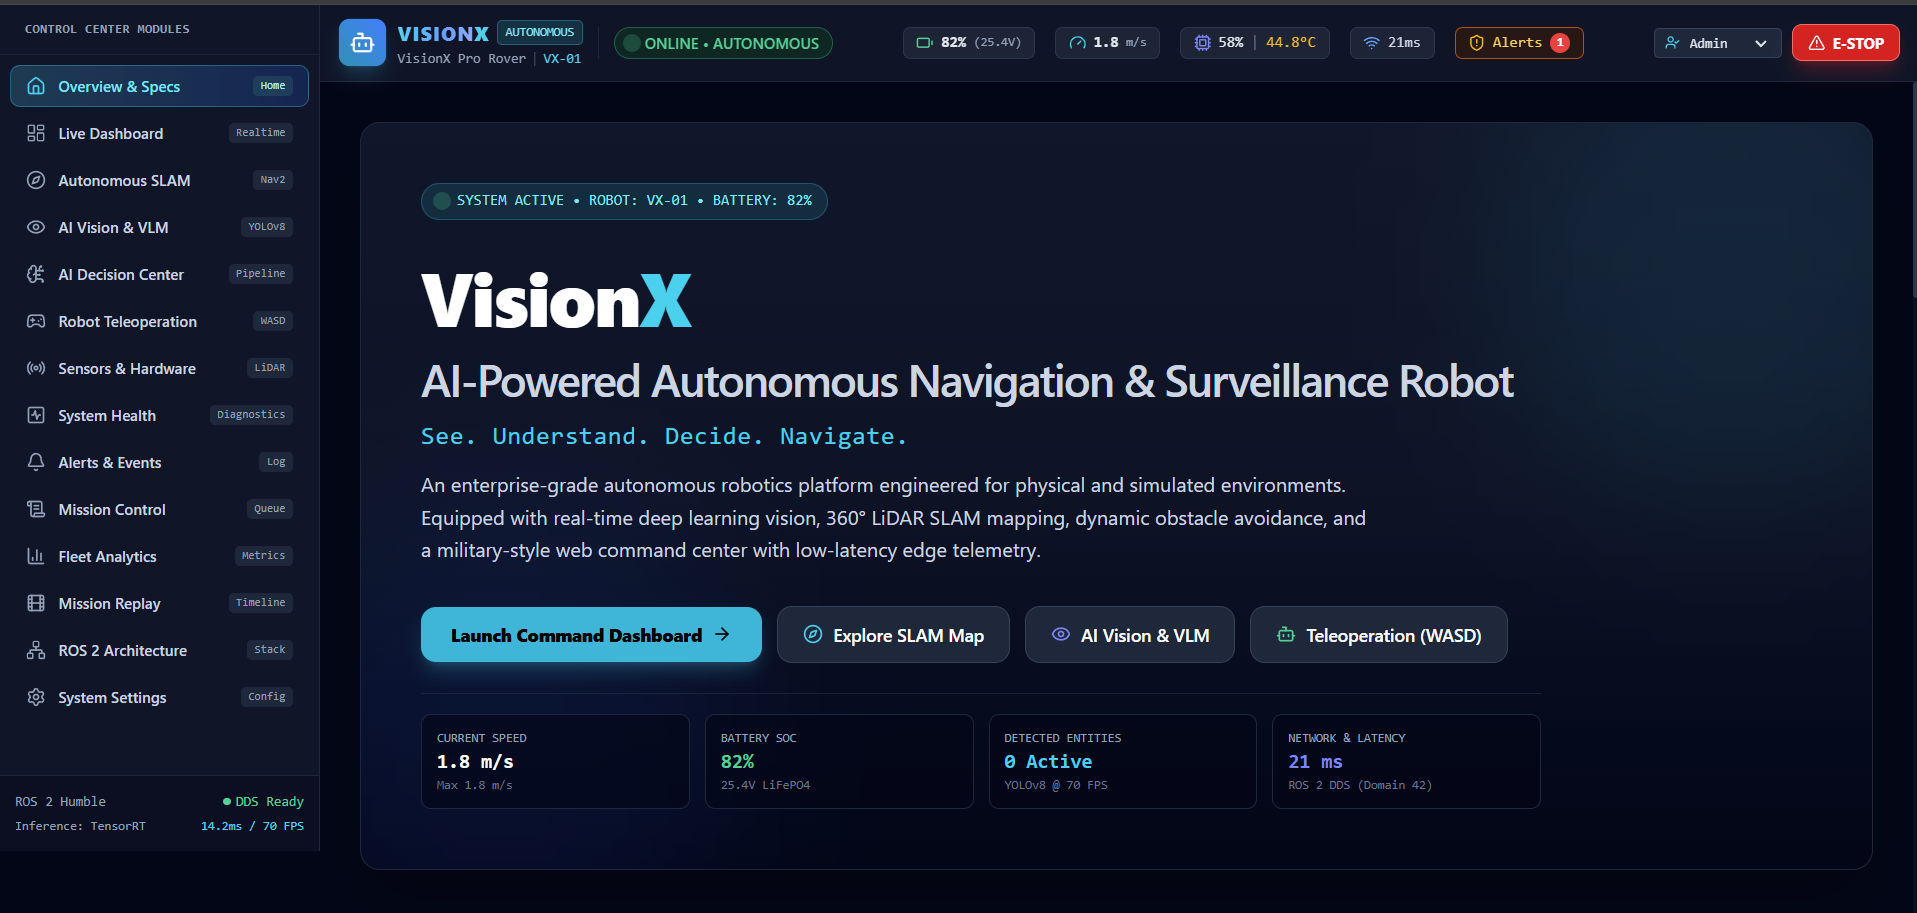
Frontpage
-
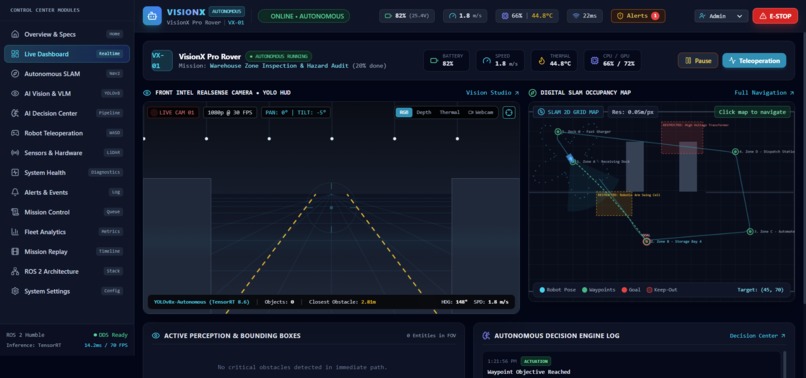
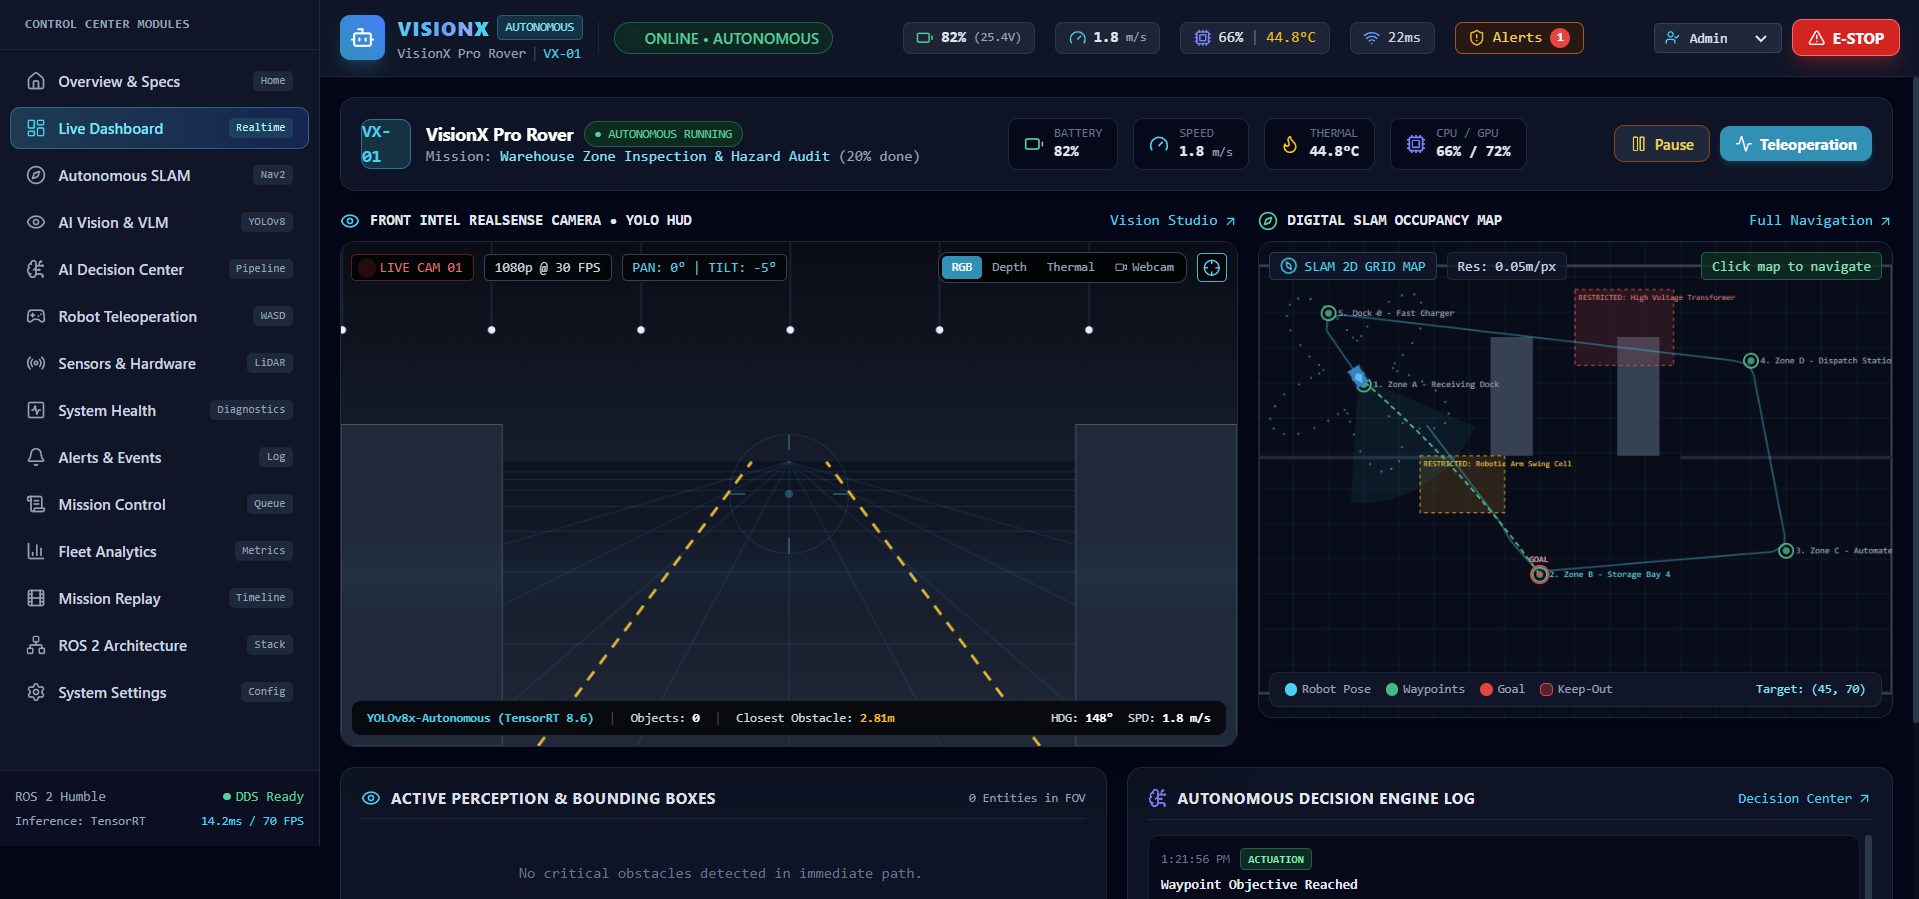
Dashboard
-
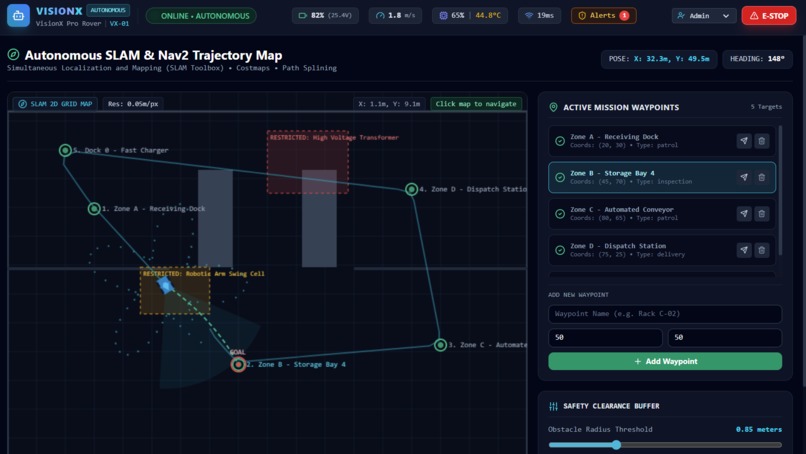
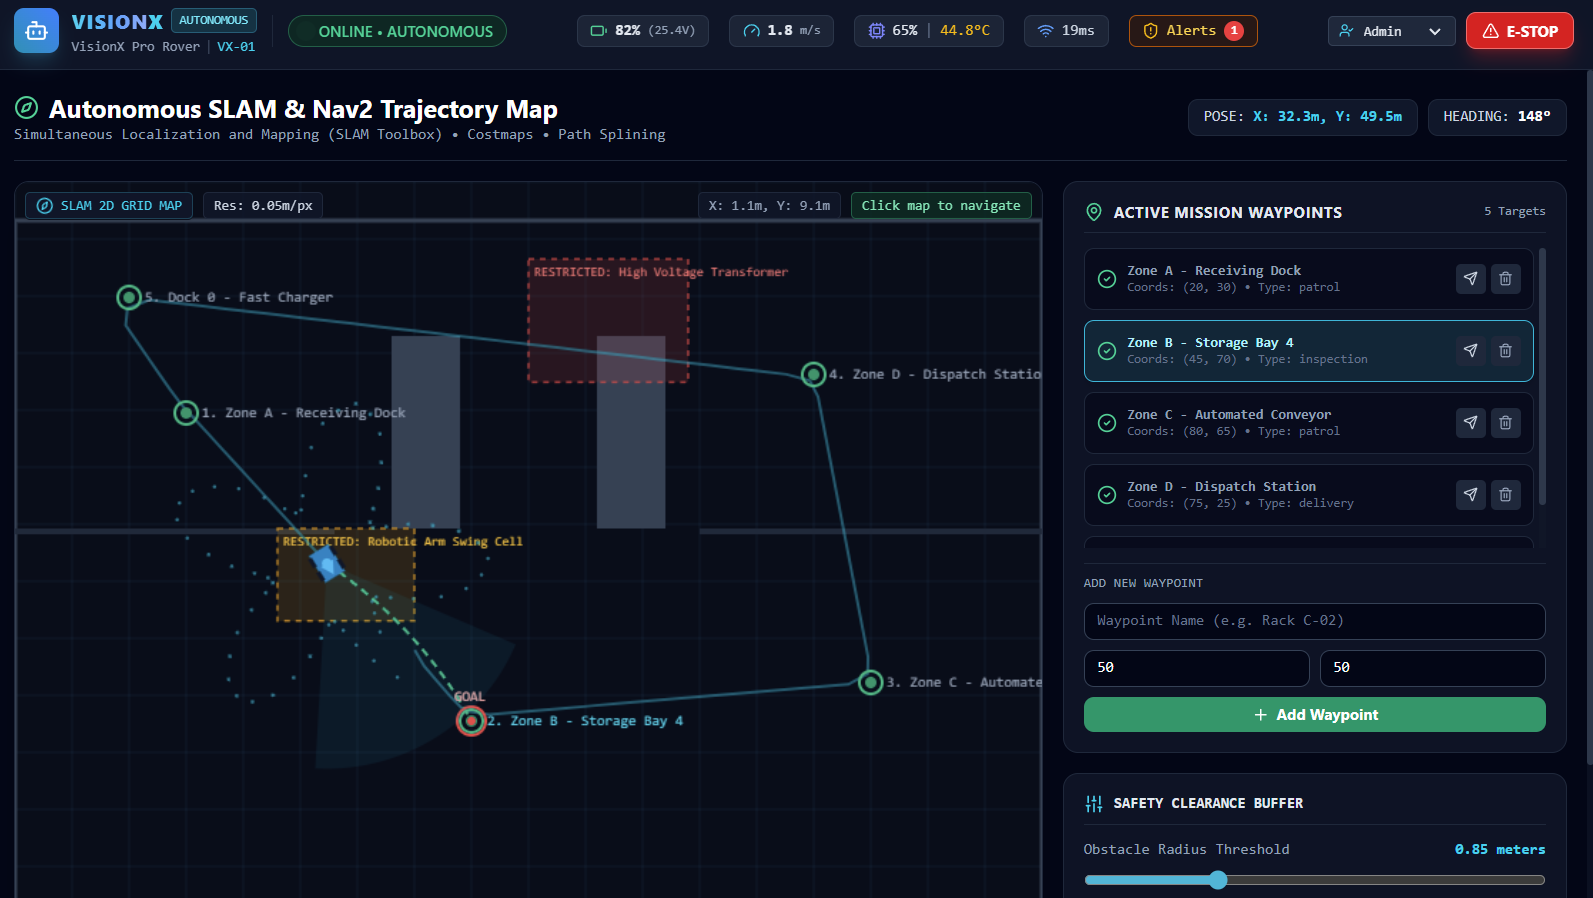
Autonomous SLAM
-
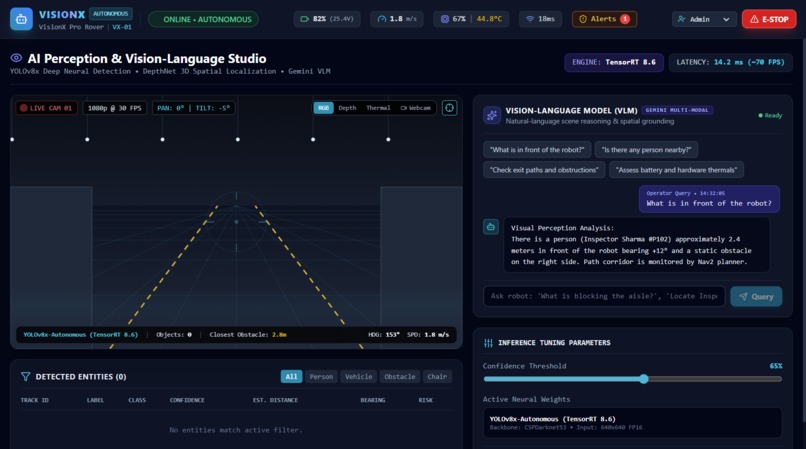
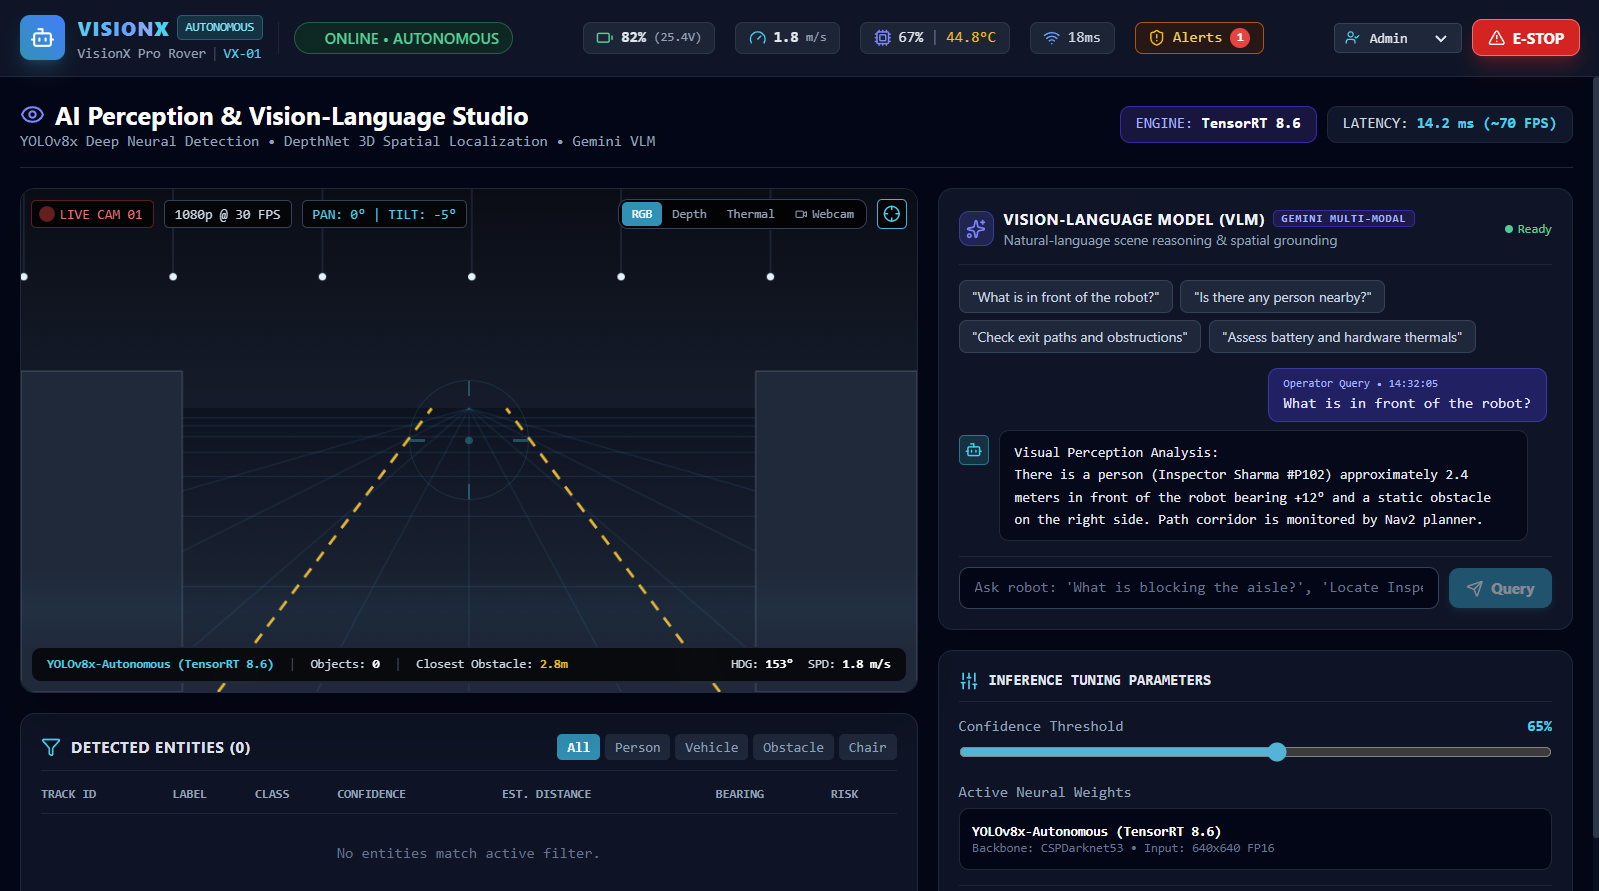
Ai perception and & Vision Language Studio
-
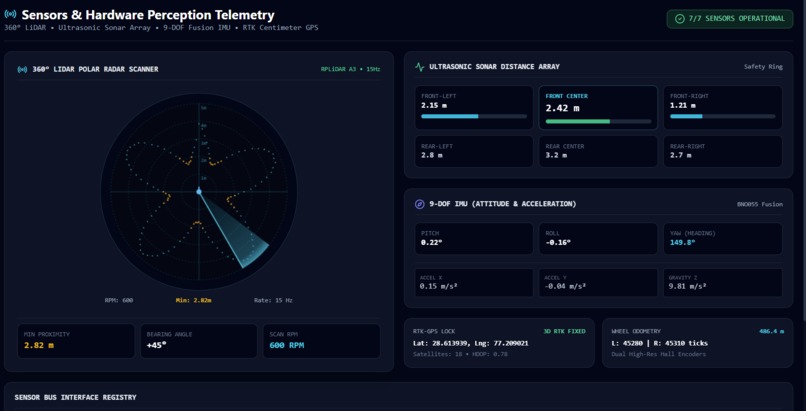
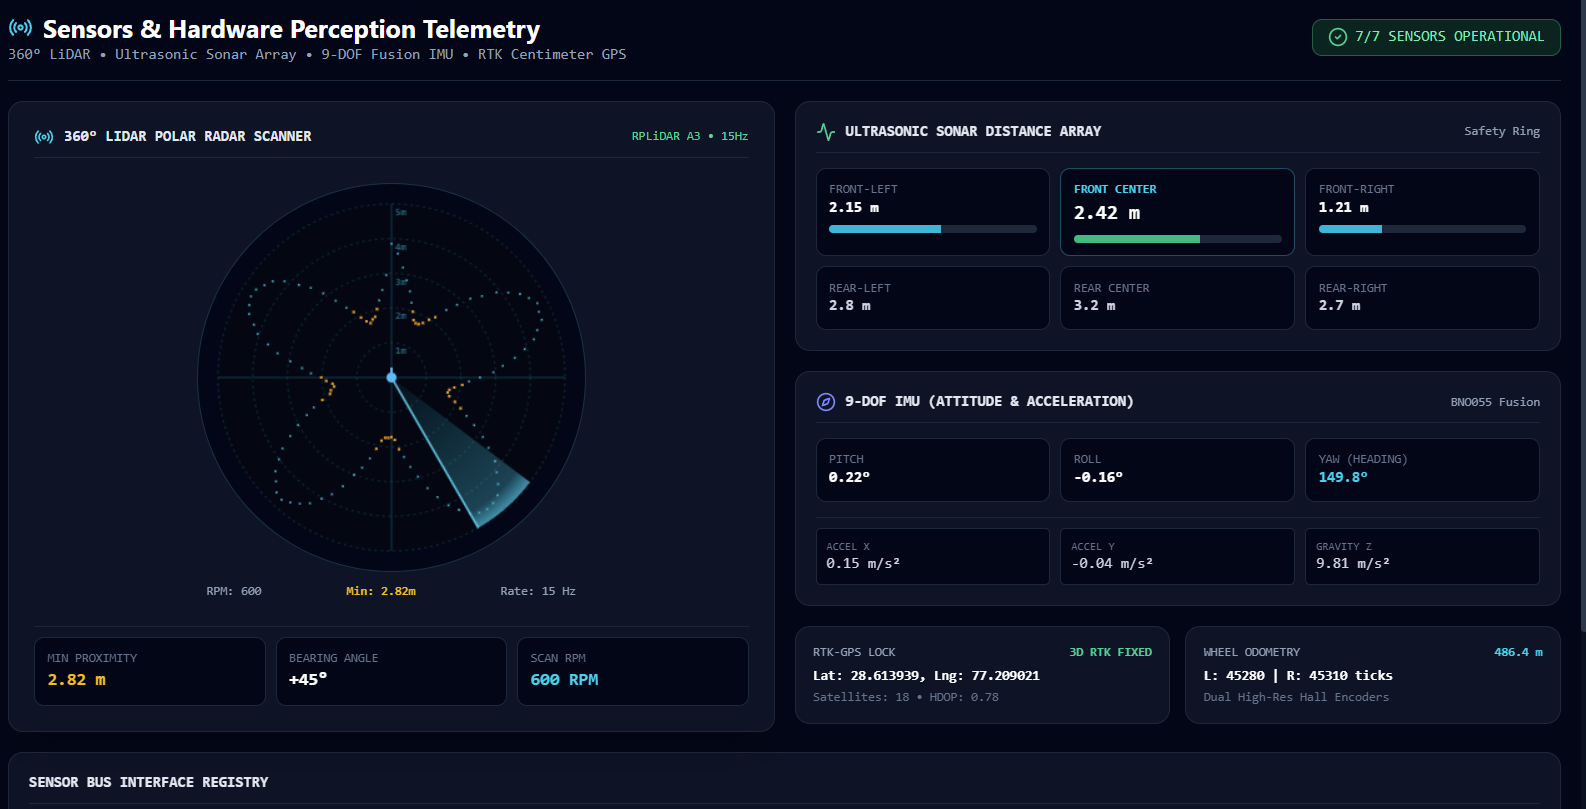
Sensors & Hardware perception Telemetry
Inspiration
We wanted to build a robot that can see, understand its surroundings, make decisions, and navigate autonomously instead of relying completely on predefined commands.
What it does
VisionX is an AI-powered autonomous navigation and surveillance robot. It uses computer vision, depth sensing, SLAM, and AI reasoning to detect objects, understand the environment, plan routes, avoid obstacles, and navigate toward a target.
How we built it
We combined React, TypeScript, Tailwind CSS, Vite, Node.js, Express.js, Python, ROS 2, ROS 2 Humble, Nav2, SLAM, YOLOv8, TensorRT, ByteTrack, Gemini AI, Computer Vision, Intel RealSense, RPLiDAR, WebSocket, REST API, MQTT, NVIDIA Jetson, Autonomous Navigation, Robotics, AI
Challenges we ran into
The main challenge was integrating AI vision, depth data, sensors, navigation, telemetry, and robot control into one reliable real-time system.
Accomplishments that we're proud of
We built an end-to-end platform connecting AI perception with autonomous navigation and a real-time command center.
What we learned
We learned how computer vision, AI reasoning, robotics, SLAM, navigation, and web technologies can work together to create an autonomous system.
What's next for AI-powered Autonomous Navigation & Surveillance Robot
We plan to add advanced object recognition, voice commands, multi-robot coordination, automatic docking, predictive maintenance, and smarter AI-based task planning.


Log in or sign up for Devpost to join the conversation.