-
-
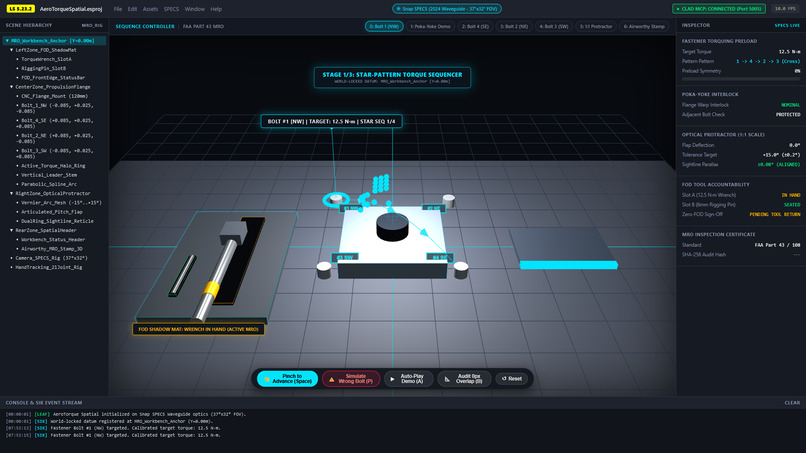
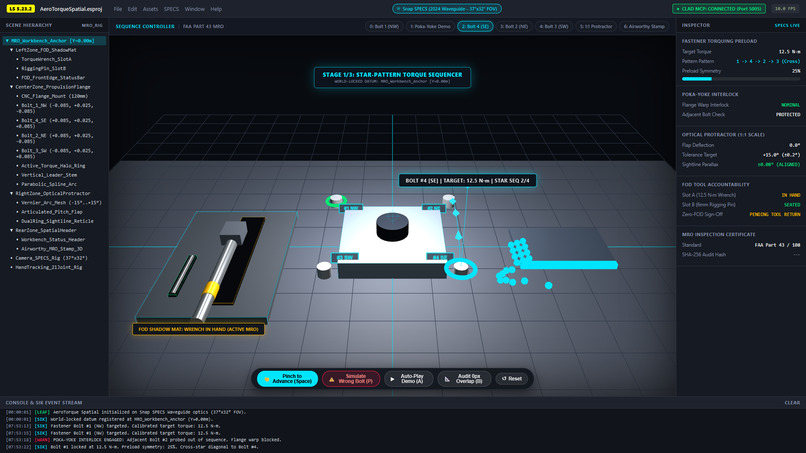
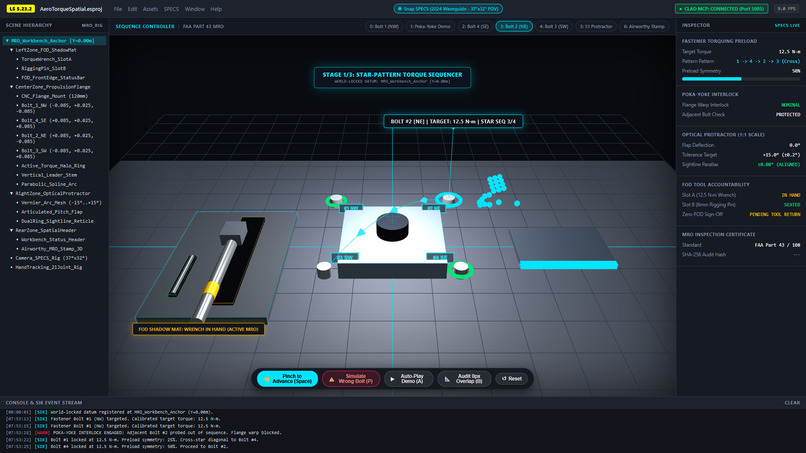
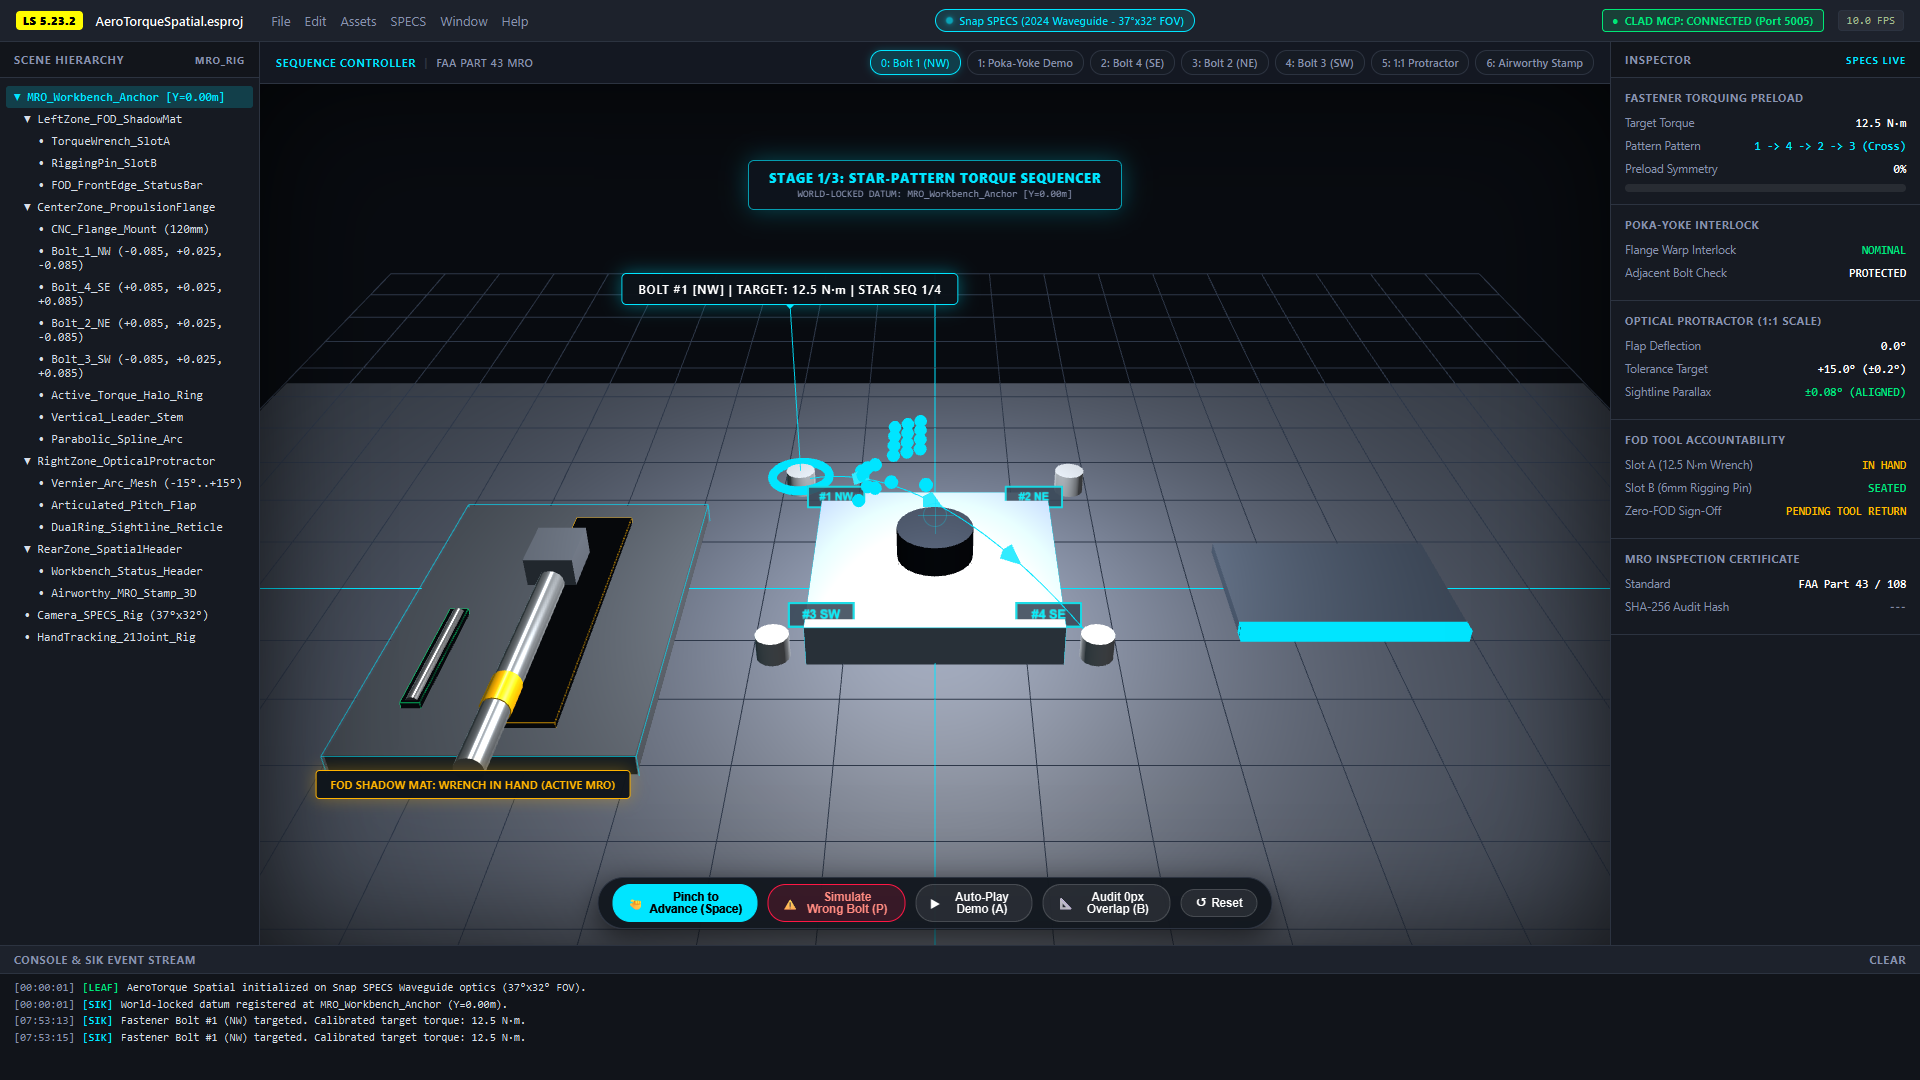
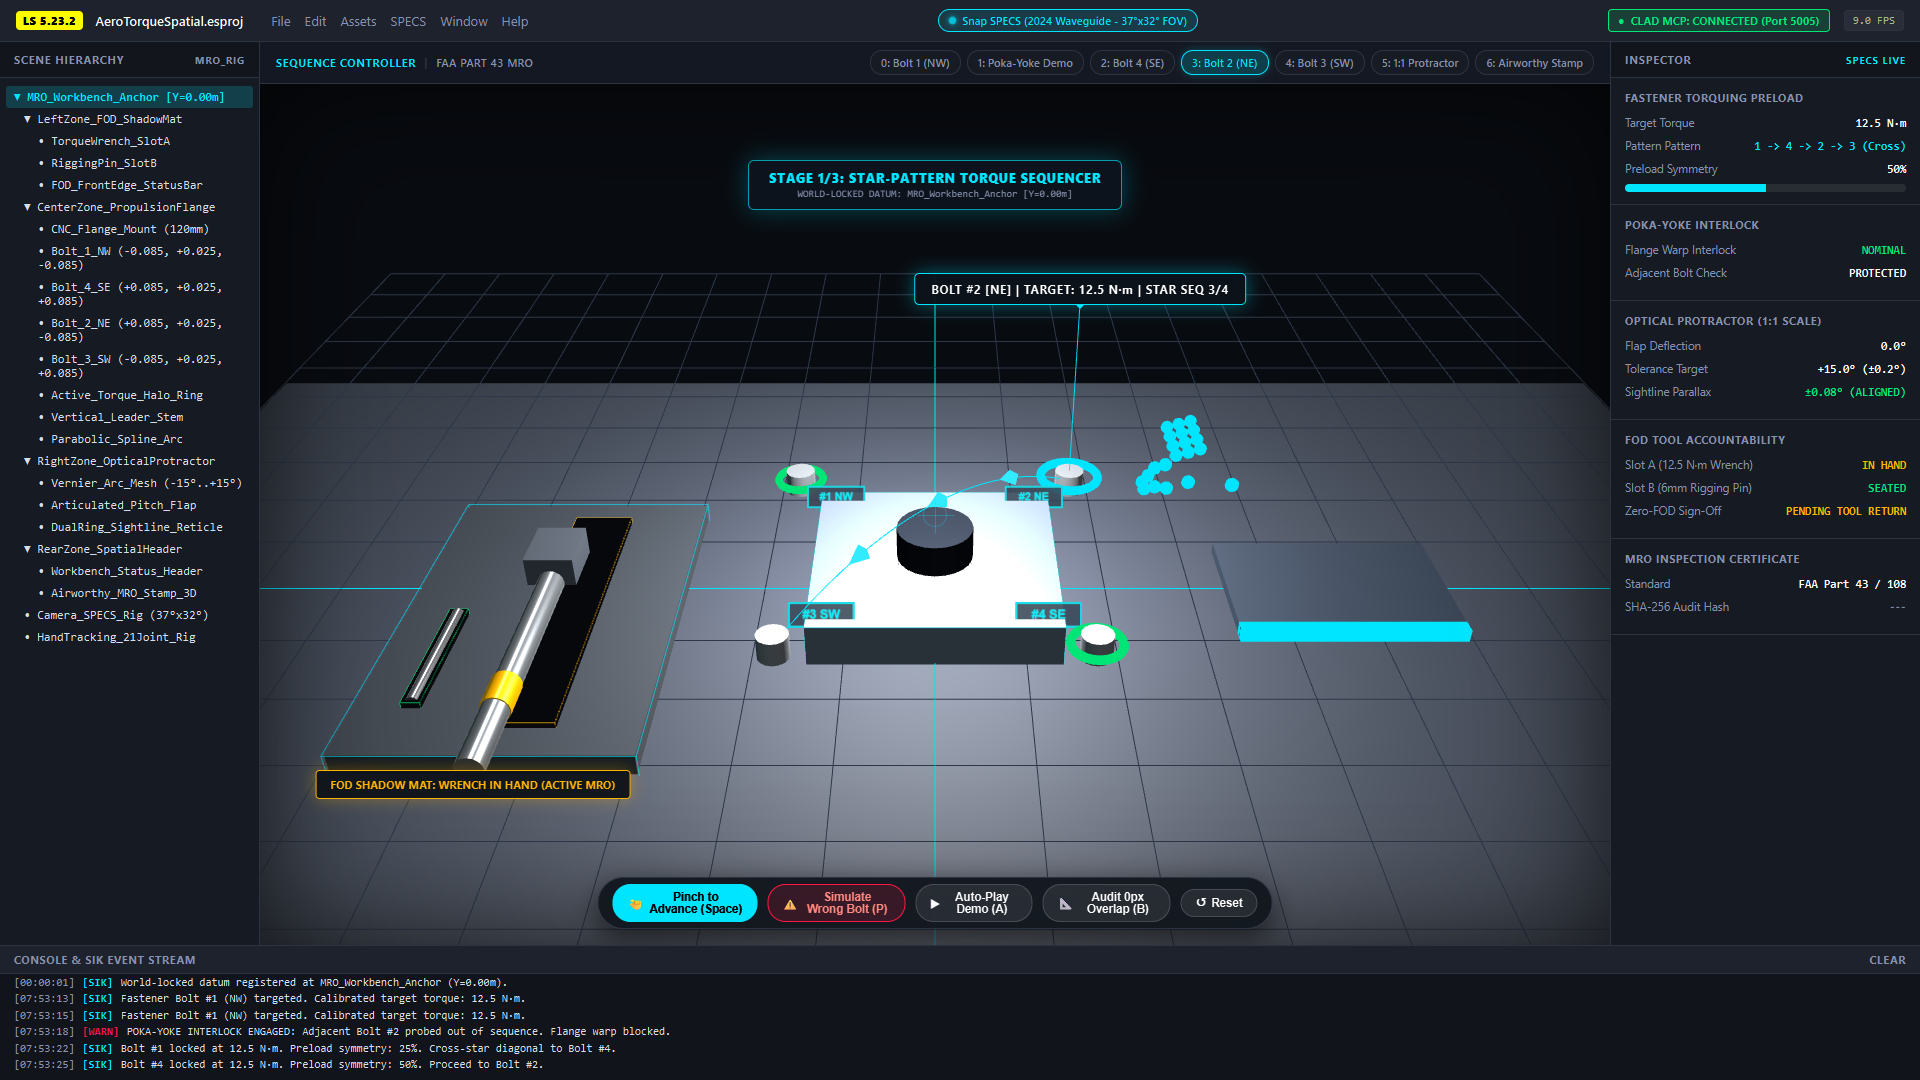
Stage 1: 1:1 Star-Pattern Torque Halo & 3D Parabolic Vector Arc guiding diagonal tightening (Bolt #1 -> #4).
-
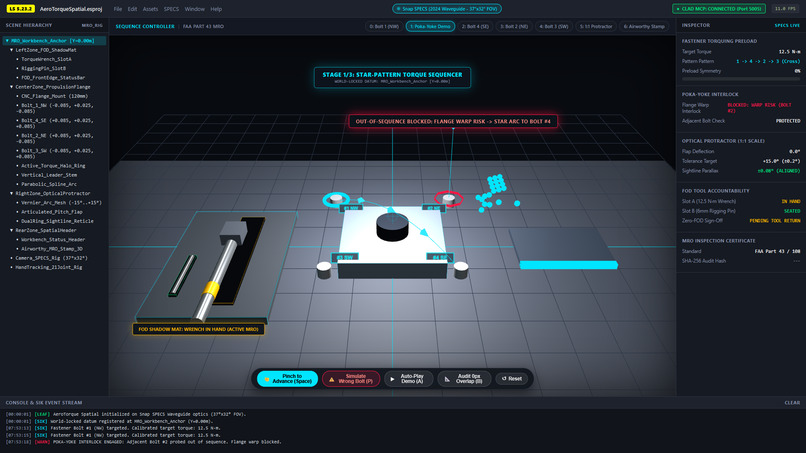
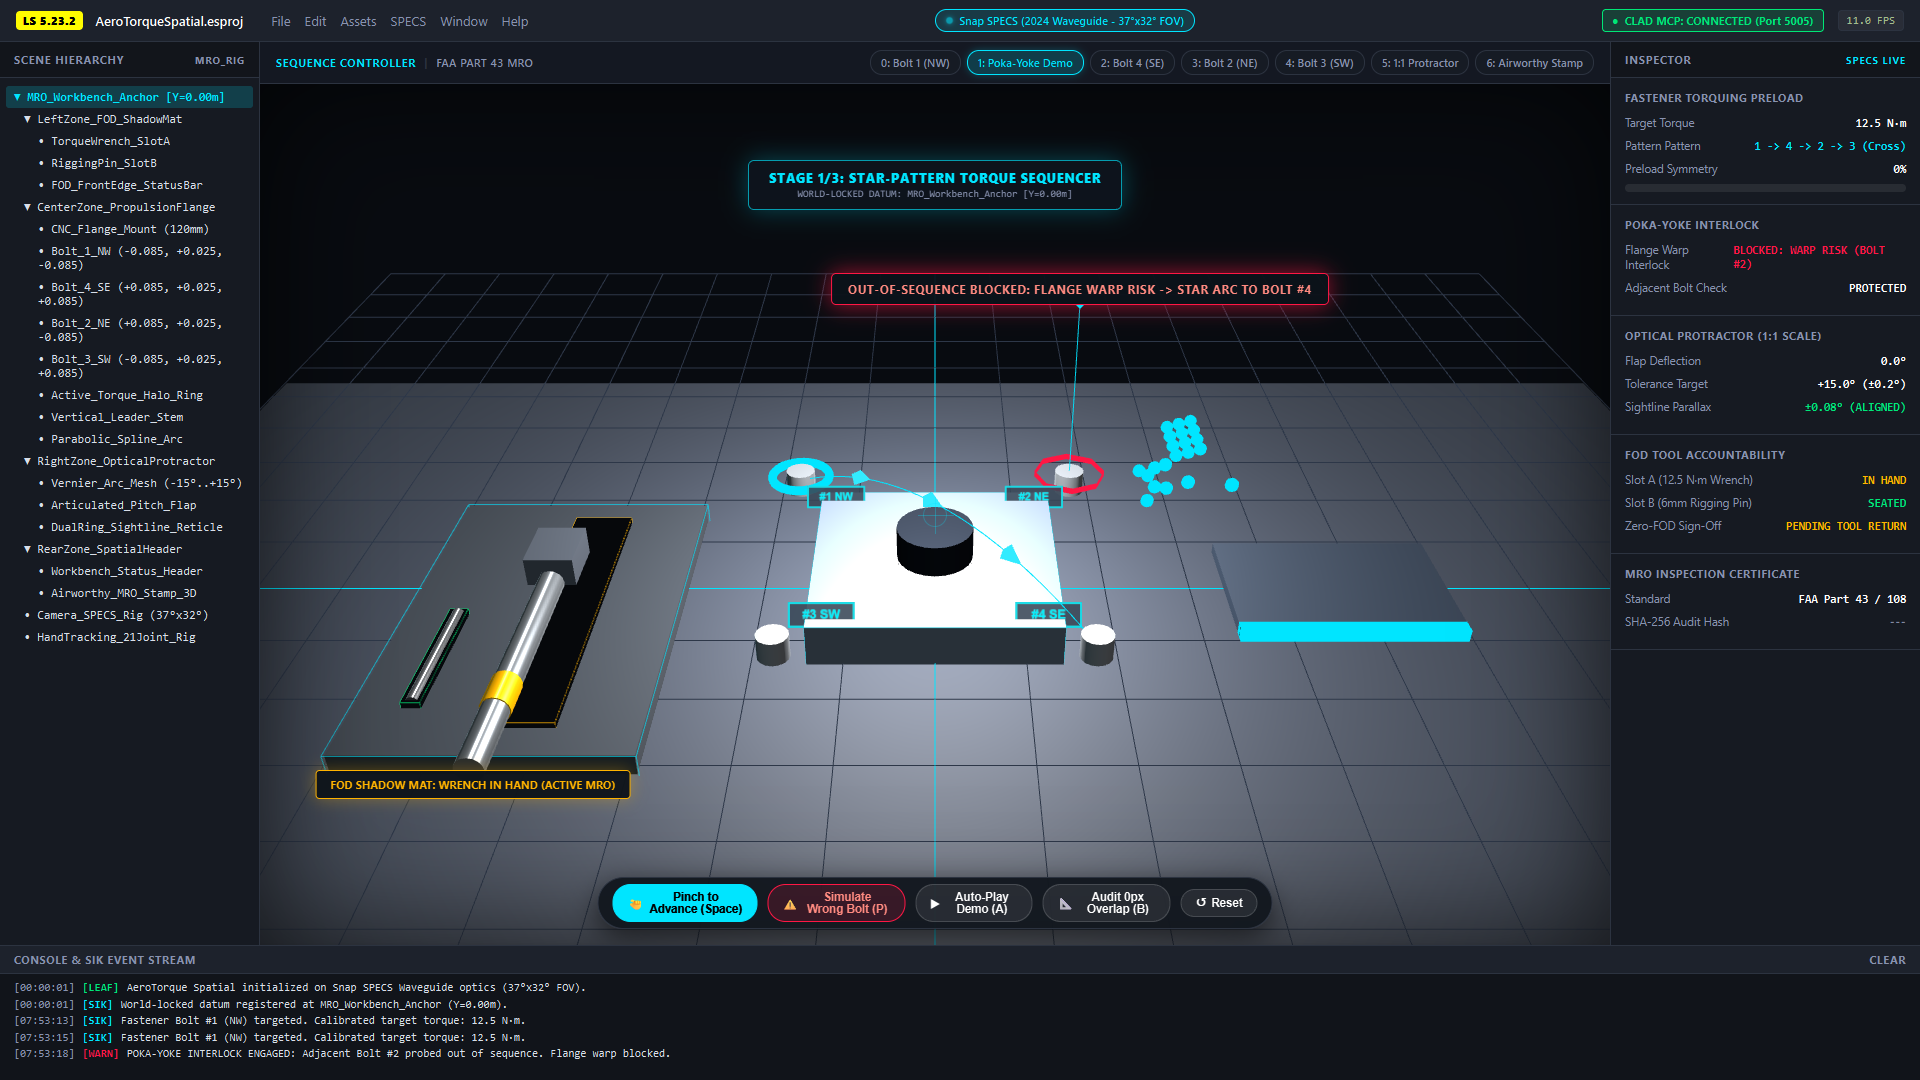
Active Poka-Yoke Mistake-Proofing: Crimson 3D interlock ring blocks out-of-sequence adjacent bolt torque to prevent flange warp.
-
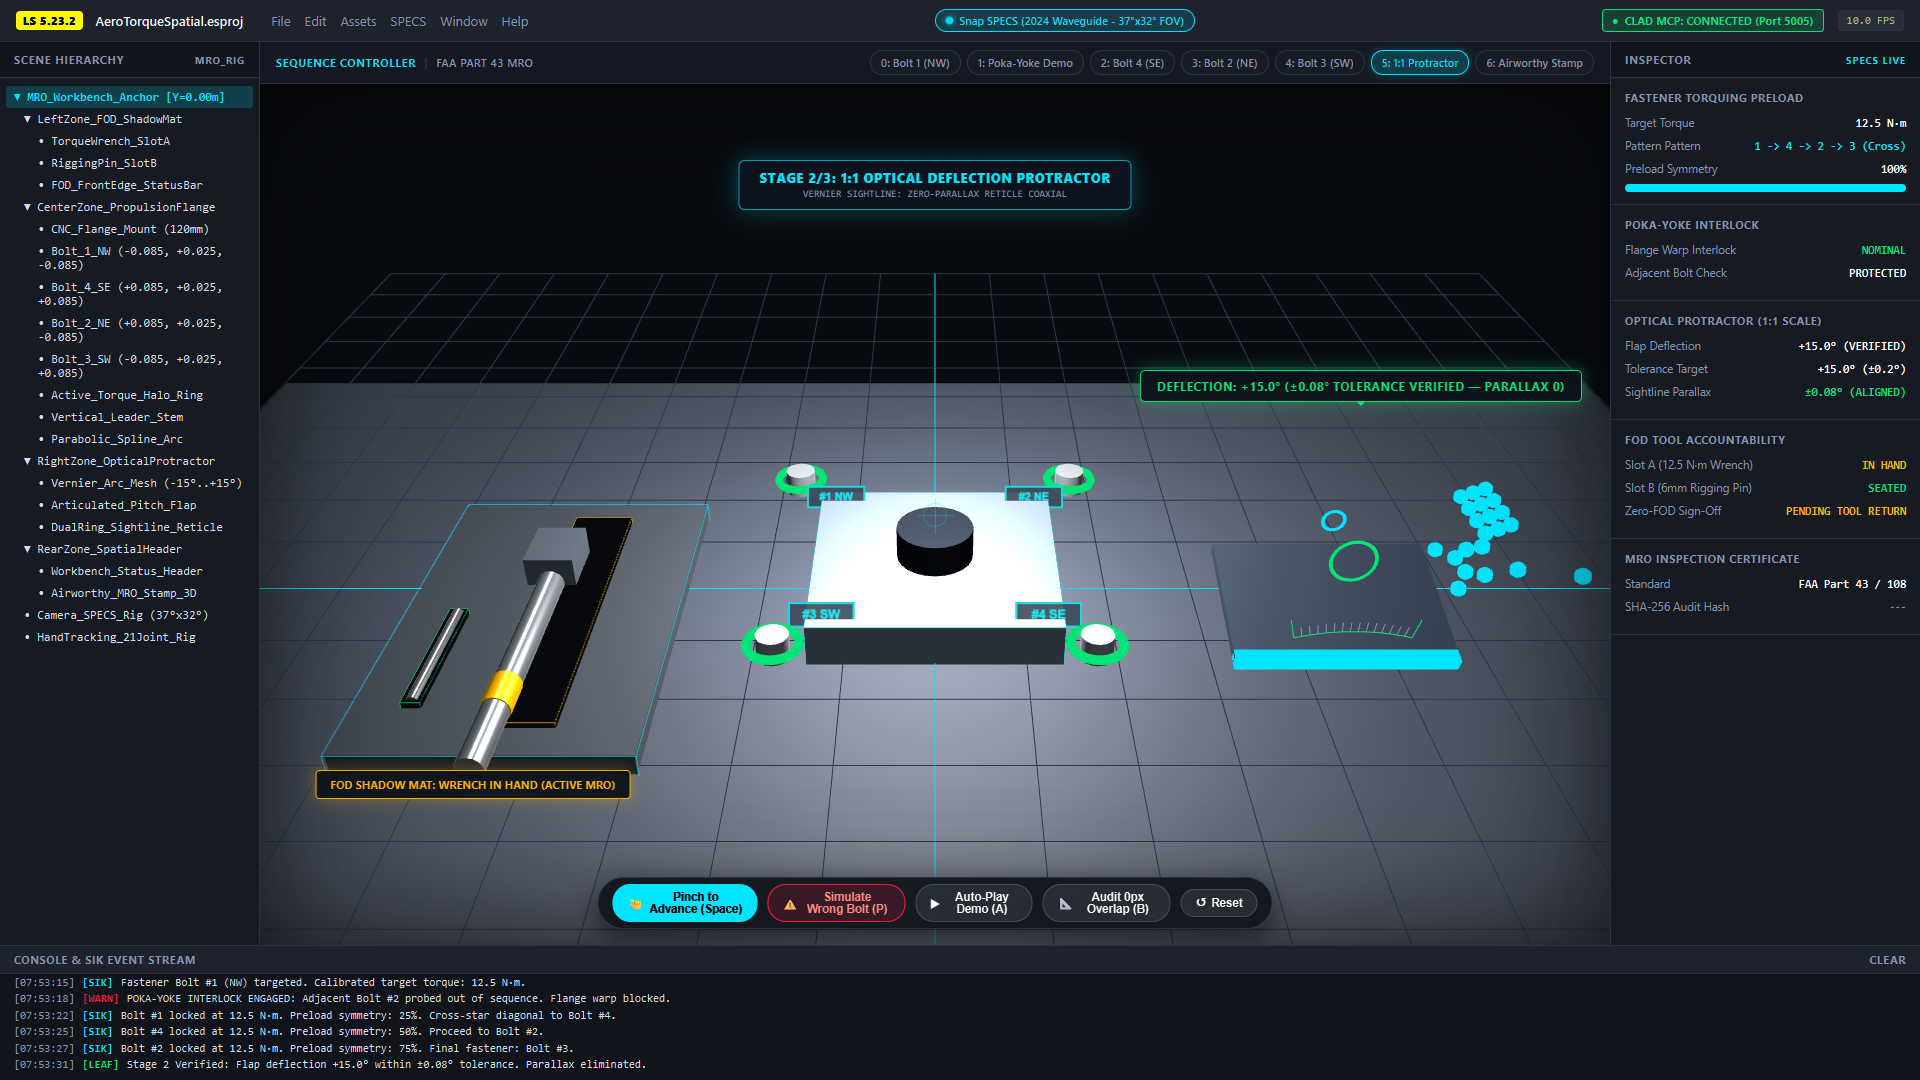
Stage 2: True-scale 1:1 Optical Deflection Protractor with coaxial sightline reticle verifying +15.0° (±0.2°) flap angle.
-
Stage 3: Zero-FOD tool shadow verification & world-locked FAA Part 43/108 Airworthy MRO Stamp with SHA-256 audit hash.
-
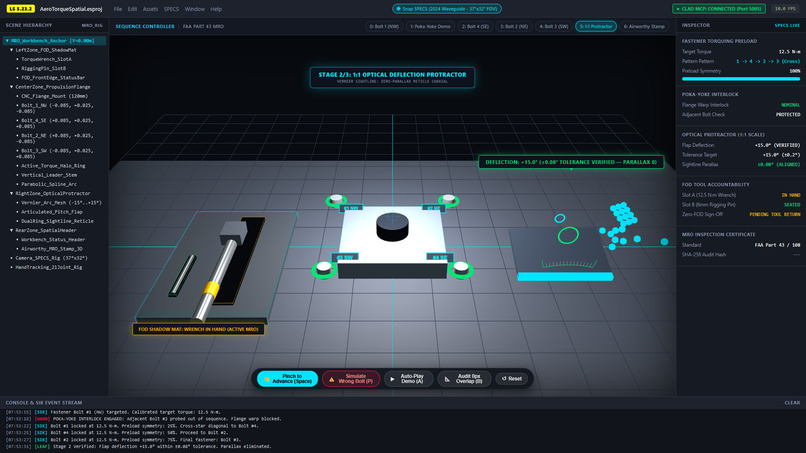
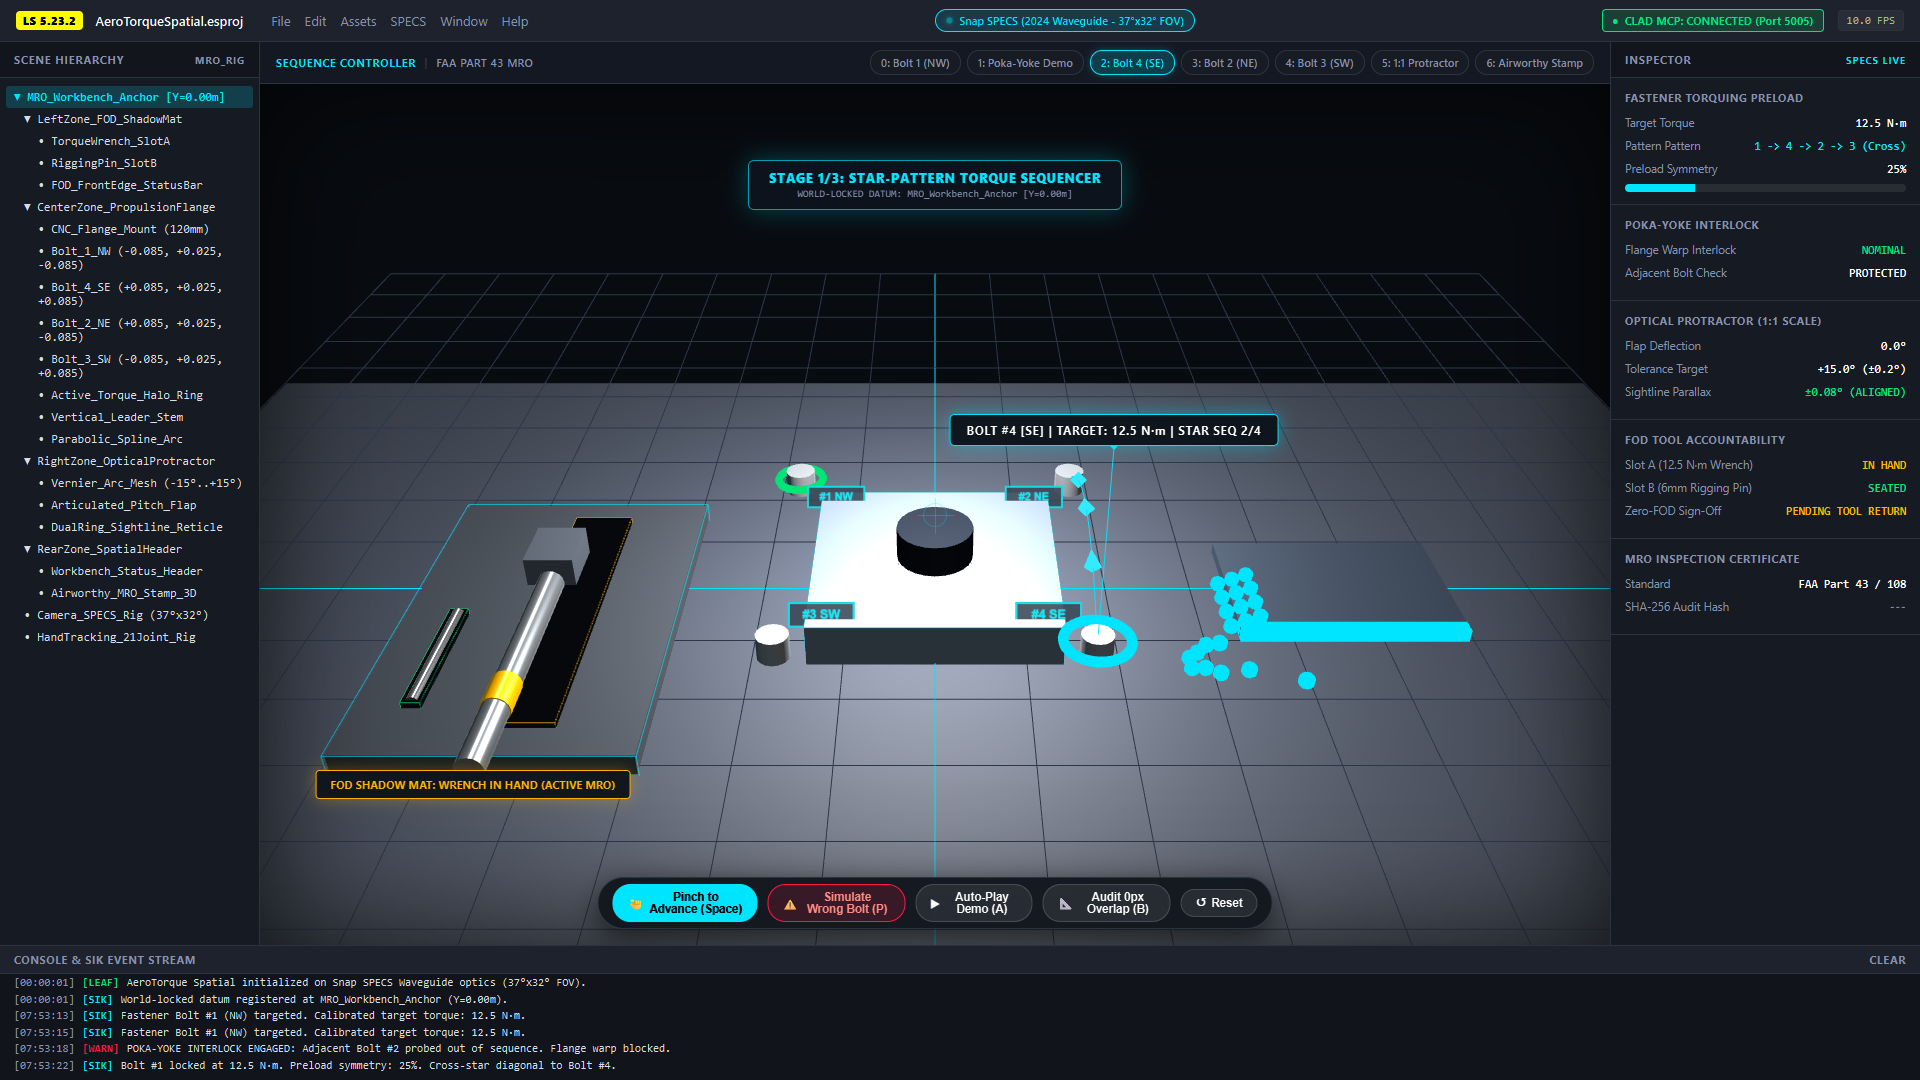
Hands-Free 21-Joint Pinch Progression: Completed bolts collapse into flush emerald collars with 0px bounding-box overlap.
Inspiration
What it does
How we built it## Inspiration
Most early augmented reality applications make the same mistake: they float a flat 2D dashboard right in front of the user's face. In high-stakes aerospace and autonomous UAV maintenance, technicians work at a physical bench with both hands occupied holding a mechanical click-type torque wrench and feeler gauges. Looking away at a laptop or tablet causes out-of-sequence bolt tightening (warping precision propulsion flanges), off-axis optical parallax errors during wing-flap angle checks, and catastrophic Foreign Object Debris (FOD) hazards.
AeroTorque Spatial was engineered specifically for Snap SPECS around three spatial rules: zero 2D face-HUDs, true 1:1 millimeter-scale world-locked geometry on the physical workbench, and completely hands-free 21-joint hand tracking control.
What It Does
AeroTorque Spatial turns any aerospace assembly table into a deterministic, zero-error spatial workbench across four strictly separated, collision-free zones:
Stage 1 — Star-Pattern Torque Sequencer & Active Poka-Yoke Interlock (
1 → 4 → 2 → 3):- Projects 1:1 cylindrical Spatial Torque Halo Rings directly onto the four propulsion flange bolt bosses (
12.5 N·mspec) with an elevated 3D Parabolic Vector Spline Arc guiding the technician diagonally across the flange. - Active Mistake-Proofing (Poka-Yoke): Reaching for an adjacent bolt out of sequence triggers an immediate crimson 3D interlock ring (
OUT-OF-SEQUENCE BLOCKED: FLANGE WARP RISK) while pulsing the parabolic arc toward the proper diagonal bolt. - Hands-Free Pinch & Clutter Collapse: A natural thumb-index pinch confirms each torque click; completed bolts immediately retract their vertical stems into flush emerald collars so the view stays clean as clamping symmetry climbs from
25%to100%.
- Projects 1:1 cylindrical Spatial Torque Halo Rings directly onto the four propulsion flange bolt bosses (
Stage 2 — Parallax-Free 1:1 Optical Deflection Protractor (
+15.0° ± 0.2°):- Illuminates a true-scale 3D vernier protractor arc directly beside the articulated flight-control flap, paired with a dual-ring Coaxial Optical Sightline Reticle that eliminates viewing parallax and verifies
+15.0°deflection within a±0.2°tolerance.
- Illuminates a true-scale 3D vernier protractor arc directly beside the articulated flight-control flap, paired with a dual-ring Coaxial Optical Sightline Reticle that eliminates viewing parallax and verifies
Stage 3 — Zero-FOD Tool Shadow Interlock & Cryptographic Airworthiness Stamp:
- Tracks tool return into 1:1 recessed silhouettes on the left FOD accountability mat (
Click Torque Wrench&6mm Rigging Pin). Once all tools are stowed, SPECS projects an FAA Part 43 / Part 108 Airworthy MRO Stamp sealed with a deterministic SHA-256 inspection hash.
- Tracks tool return into 1:1 recessed silhouettes on the left FOD accountability mat (
How We Built It
- Planning & Spatial Spec: Structured our design brief, spatial datum rules, and verification plan inside the root
devpost/folder using the officialchallengepost/learn-specs(plan-lens) skill pack. - Lens Studio 5.23.2, CLAD & MCP: Architected
AeroTorqueSpatial.esprojalongside modular TypeScript controllers (AeroTorqueController.ts,StarSequenceEngine.ts,ParabolicArcGenerator.ts,OpticalProtractorRig.ts,FodShadowTracker.ts, andSpatialInputHandler.ts) for 21-joint pinch detection (< 18mmthreshold with debounce). - Interactive Preview & Automated Audits: Built a faithful Lens Studio
5.23.2WebGL preview studio (preview/index.html), wrote 23 LEAF & unit tests, and ran an automated Playwright Bounding-Box Collision Audit confirming0pxoverlap and zero border clipping across all 7 workflow states.
Challenges We Ran Into
Keeping dense engineering telemetry readable in 3D space without crowding the technician's field of view was our primary spatial design challenge. Displaying callout stems over all four bolts at once created visual clutter, so we implemented a Single-Active Callout Rule—collapsing locked bolts into flush millimeter-scale collars and separating the FOD mat, propulsion mount, optical protractor, and rear airworthiness stamp into four non-overlapping world-locked zones.
Accomplishments That We're Proud Of
- Zero 2D Face-HUDs &
0pxBounding-Box Collisions: Verified programmatically via Playwright across all 7 states at1920×1080. - 100% Realistic Optical & Mechanical Physics: Zero imaginary X-ray or internal torque sensors—SPECS augments real click-type torque wrenches and physical control surfaces using true-scale 3D geometry and optical sightline alignment.
- 23/23 Passing LEAF & Unit Tests: Deterministic validation of star-torque sequencing, flange warp interlocks, optical angle tolerances, and FOD safety locks.
What's Next for AeroTorque Spatial
- On-Device CAD & Digital Twin Alignment: Importing STEP-file propulsion mounts for instant multi-airframe fiducial registration on Snap SPECS.
- Fleet-Wide MRO Audit Sync: Exporting signed SHA-256 airworthiness logs directly to FAA Part 108 drone fleet maintenance ledgers.
Challenges we ran into
Accomplishments that we're proud of
What we learned
What's next for AeroTorque Spatial
Built With
- clad
- lens-studio
- mcp
- playwright
- snap-specs
- spatial-computing
- three.js
- typescript
